


accelerometer Can internal PLL affect control logic in MEMS sensor
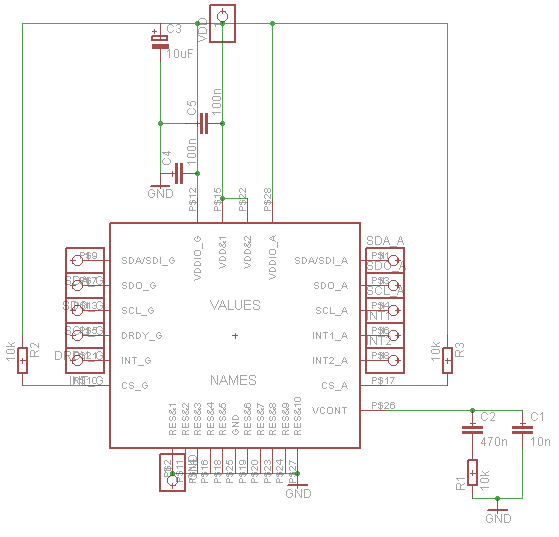
Description: Establish communication between the microcontroller unit (MCU) and the accelerometer using either I2C or SPI protocols. It has been noted that shorting the phase-locked loop (PLL) filter input in the device does not affect the readings from the gyroscope or the overall operation. It is assumed that the PLL is only present in the accelerometer section of the device. There is no available data on the operation of the PLL, and the filter design is based on the datasheet, with the device board constructed independently. There is a possibility that the improper functioning of the device is due to a poorly designed filter.
The communication between the MCU and the accelerometer can be achieved using either the I2C (Inter-Integrated Circuit) or SPI (Serial Peripheral Interface) protocols, both of which are widely used for interfacing microcontrollers with peripheral devices. I2C is a two-wire interface that allows multiple devices to communicate with a single MCU, while SPI is a four-wire interface that provides faster data transfer rates and is typically used for applications requiring high-speed communication.
The PLL filter plays a crucial role in stabilizing the output signals from the accelerometer. The PLL is used to synchronize the frequency of the output signal with the input signal, ensuring accurate readings. If shorting the PLL filter input does not impact the gyroscope readings, it may indicate that the PLL is not functioning as intended or is improperly integrated within the circuit.
The design of the PLL filter must adhere to specific parameters outlined in the accelerometer's datasheet, which includes component values and configurations that optimize performance. If the filter is not designed correctly, it could lead to noise issues, signal distortion, or inadequate filtering of the output signals. This could explain the observed discrepancies in device operation and readings.
To ensure proper functionality, it is essential to verify the design of the PLL filter by cross-referencing the component values with the recommendations in the datasheet. Additionally, testing the filter's performance using simulation tools or prototyping can provide insights into any potential design flaws. It is advisable to consider revising the filter design to enhance the overall performance of the device, particularly in terms of the accuracy and reliability of the accelerometer readings.Achieve communication between MCU and accelerometer trough I2C nor SPI. I observed that shorting PLL filter input in device causes no effect on both gyro readings and operation. My assumption is that PLL is present only in accelerometer part of the device. I have no data regarding PLL operation, the filter is built upon datasheet and board for device is built by myself.
Is it possible that inappropriate operation of device is caused by badly designed filter
The communication between the MCU and the accelerometer can be achieved using either the I2C (Inter-Integrated Circuit) or SPI (Serial Peripheral Interface) protocols, both of which are widely used for interfacing microcontrollers with peripheral devices. I2C is a two-wire interface that allows multiple devices to communicate with a single MCU, while SPI is a four-wire interface that provides faster data transfer rates and is typically used for applications requiring high-speed communication.
The PLL filter plays a crucial role in stabilizing the output signals from the accelerometer. The PLL is used to synchronize the frequency of the output signal with the input signal, ensuring accurate readings. If shorting the PLL filter input does not impact the gyroscope readings, it may indicate that the PLL is not functioning as intended or is improperly integrated within the circuit.
The design of the PLL filter must adhere to specific parameters outlined in the accelerometer's datasheet, which includes component values and configurations that optimize performance. If the filter is not designed correctly, it could lead to noise issues, signal distortion, or inadequate filtering of the output signals. This could explain the observed discrepancies in device operation and readings.
To ensure proper functionality, it is essential to verify the design of the PLL filter by cross-referencing the component values with the recommendations in the datasheet. Additionally, testing the filter's performance using simulation tools or prototyping can provide insights into any potential design flaws. It is advisable to consider revising the filter design to enhance the overall performance of the device, particularly in terms of the accuracy and reliability of the accelerometer readings.Achieve communication between MCU and accelerometer trough I2C nor SPI. I observed that shorting PLL filter input in device causes no effect on both gyro readings and operation. My assumption is that PLL is present only in accelerometer part of the device. I have no data regarding PLL operation, the filter is built upon datasheet and board for device is built by myself.
Is it possible that inappropriate operation of device is caused by badly designed filter
SAA1064
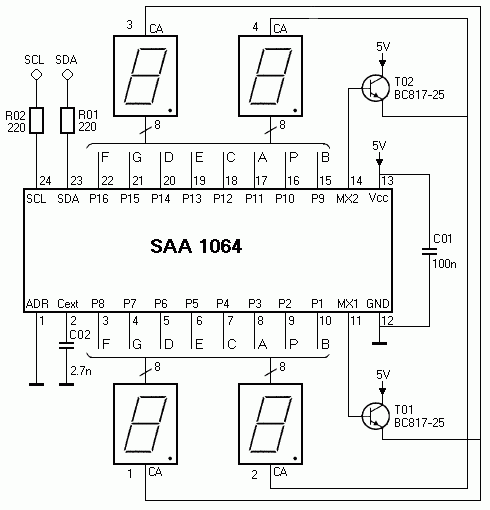
Each integrated circuit (IC) on the I²C bus requires a unique address. Typically, these ICs can choose from a range of 2 to 8 possible addresses, enabling multiple chips of the same type to coexist on a single bus. The...
PLL FM Demodulator Circuit Module
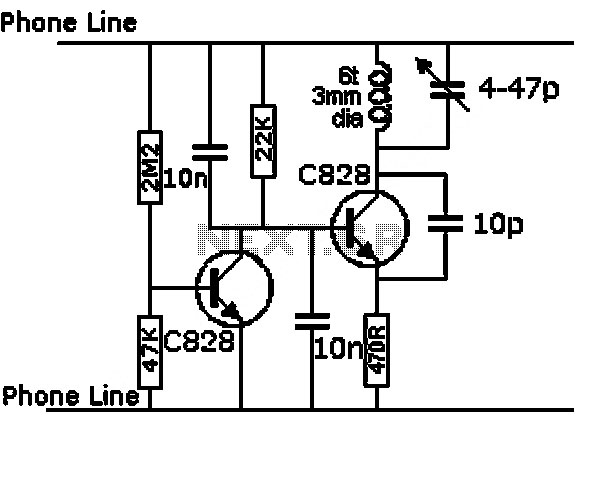
This circuit is a Phase-Locked Loop (PLL) system designed for use as an FM demodulator. The output of the Voltage-Controlled Oscillator (VCO) follows the FM signal, with the input voltage to the VCO being proportional to its output frequency. Consequently,...
Phase Locked Loop (PLL) Operating Principle Phase Detector VCO LPF
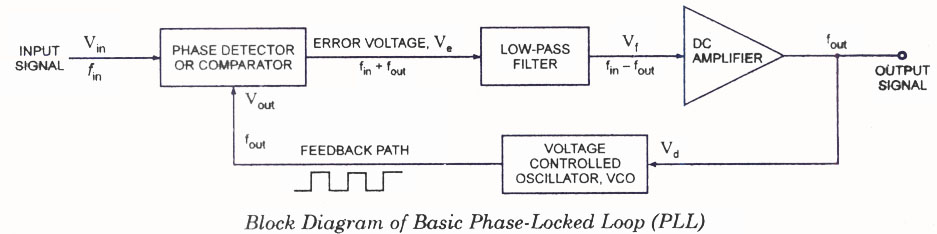
The operating principle of a Phase Locked Loop (PLL) is illustrated with a block diagram that includes a Phase Detector, Voltage Controlled Oscillator, and Low Pass Filter.
A Phase Locked Loop (PLL) is an essential electronic circuit used in various applications...
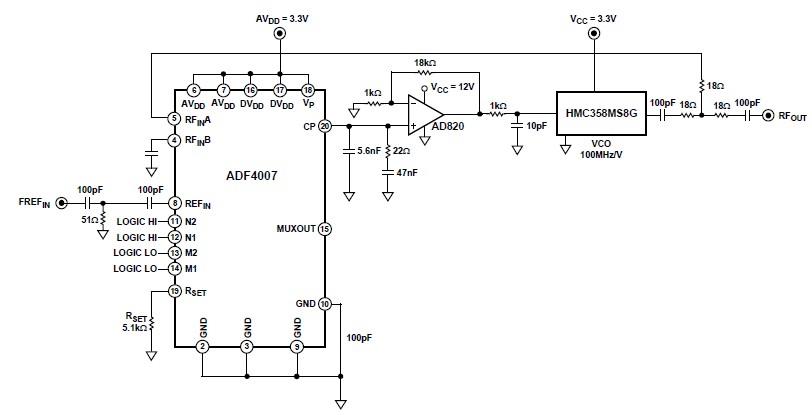
Schematic Diagram ADF-4007 6.7GHz Local oscillator circuit
The ADF4007 high-frequency divider Phase-Locked Loop (PLL) synthesizer can be utilized in a variety of communication applications. It operates up to 7.5 GHz on the RF side and 120 MHz at the Phase Frequency Detector (PFD). The device includes a...
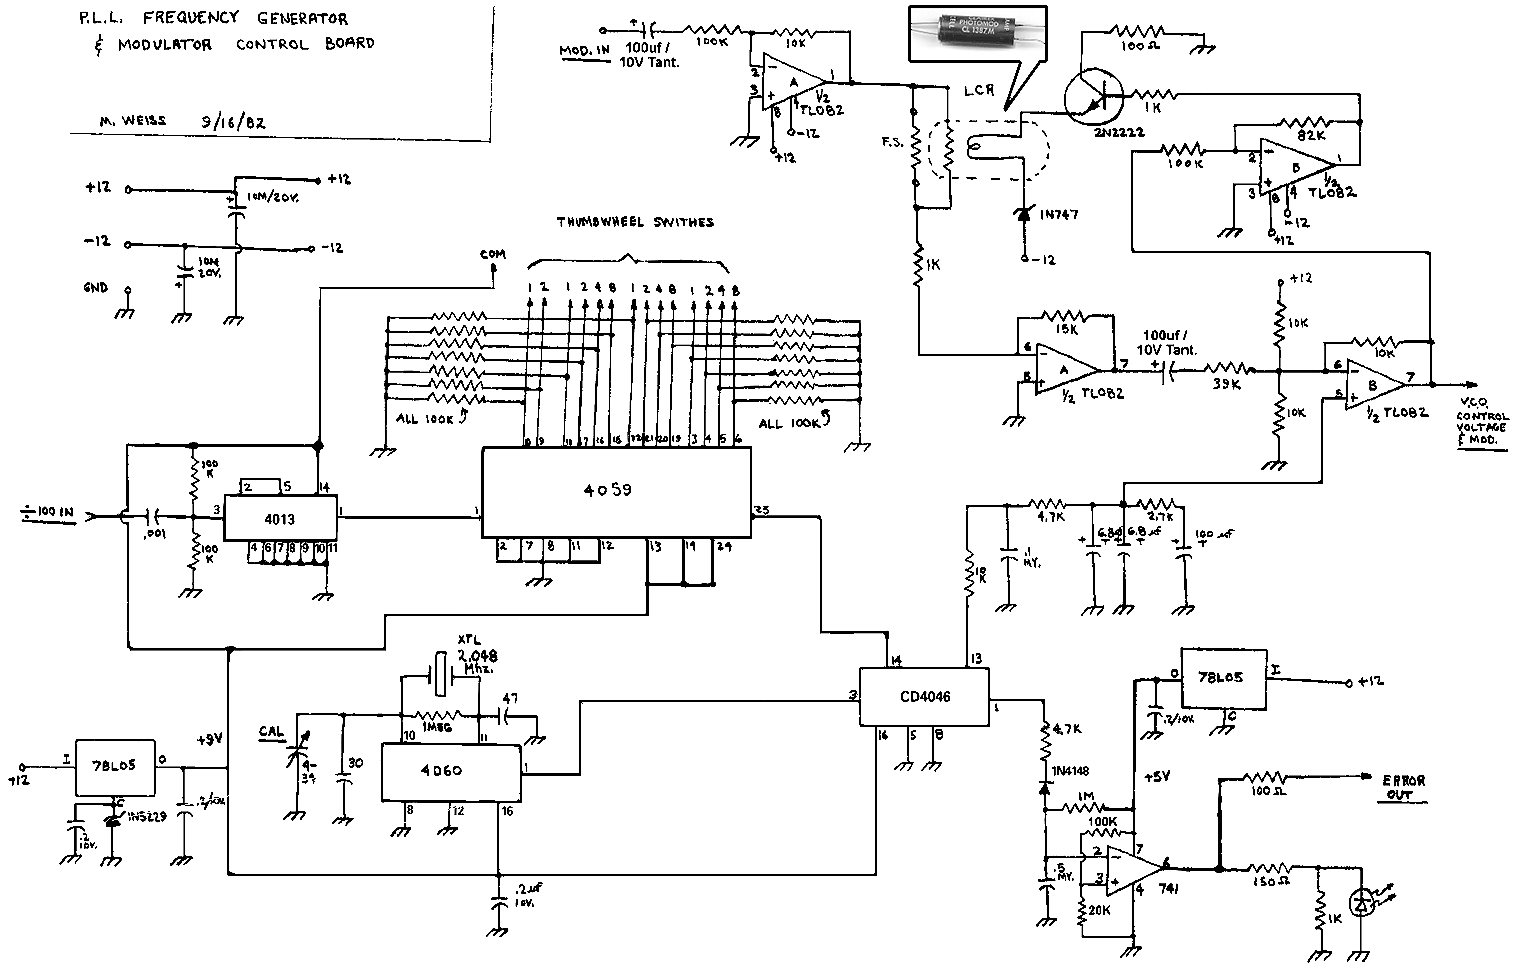
PLL Exciter-2
This is a Phase-Locked Loop (PLL) controller designed to operate with a Voltage-Controlled Oscillator (VCO) and modulator. These two modules should be utilized together to create a complete baseband-capable exciter unit. The PLL controller incorporates a stable crystal-controlled reference and...
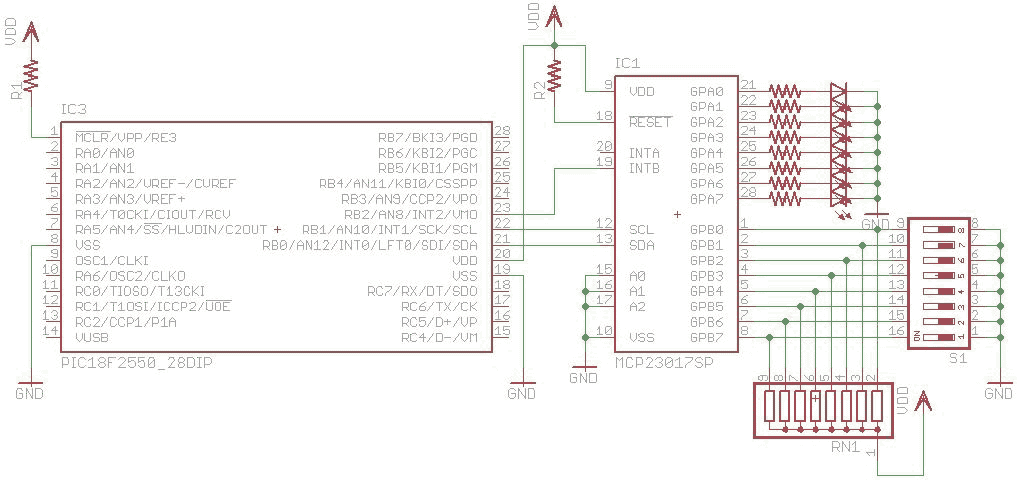
I2C using (MSSP)
I2C are widely use for to communicate with external peripheral such as port expender, EEPROM, Real Time Clock etc. The Master Synchronous Serial Port (MSSP) module in PIC18 can be used to communicated with I2C peripheral. MSSP module can be...
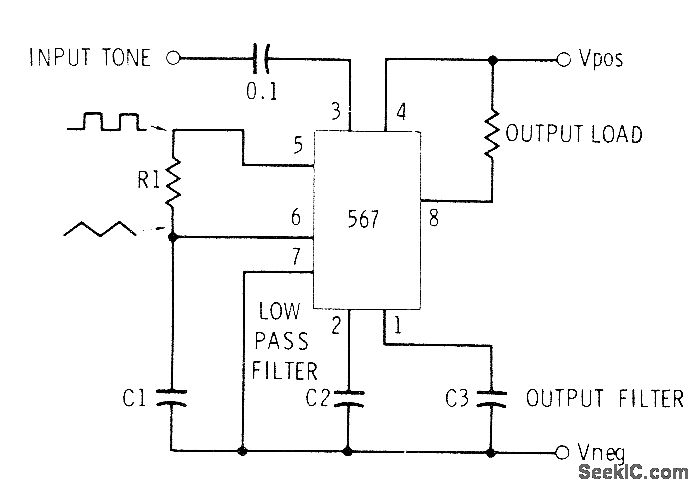
PLL SINGLE TONE DECODER
This circuit can be utilized for Touch-Tone decoding as well as for telephone line and wireless control applications using a single audio frequency. The operating center frequency is determined by components H1 and C1. The resistor R1 should be within...
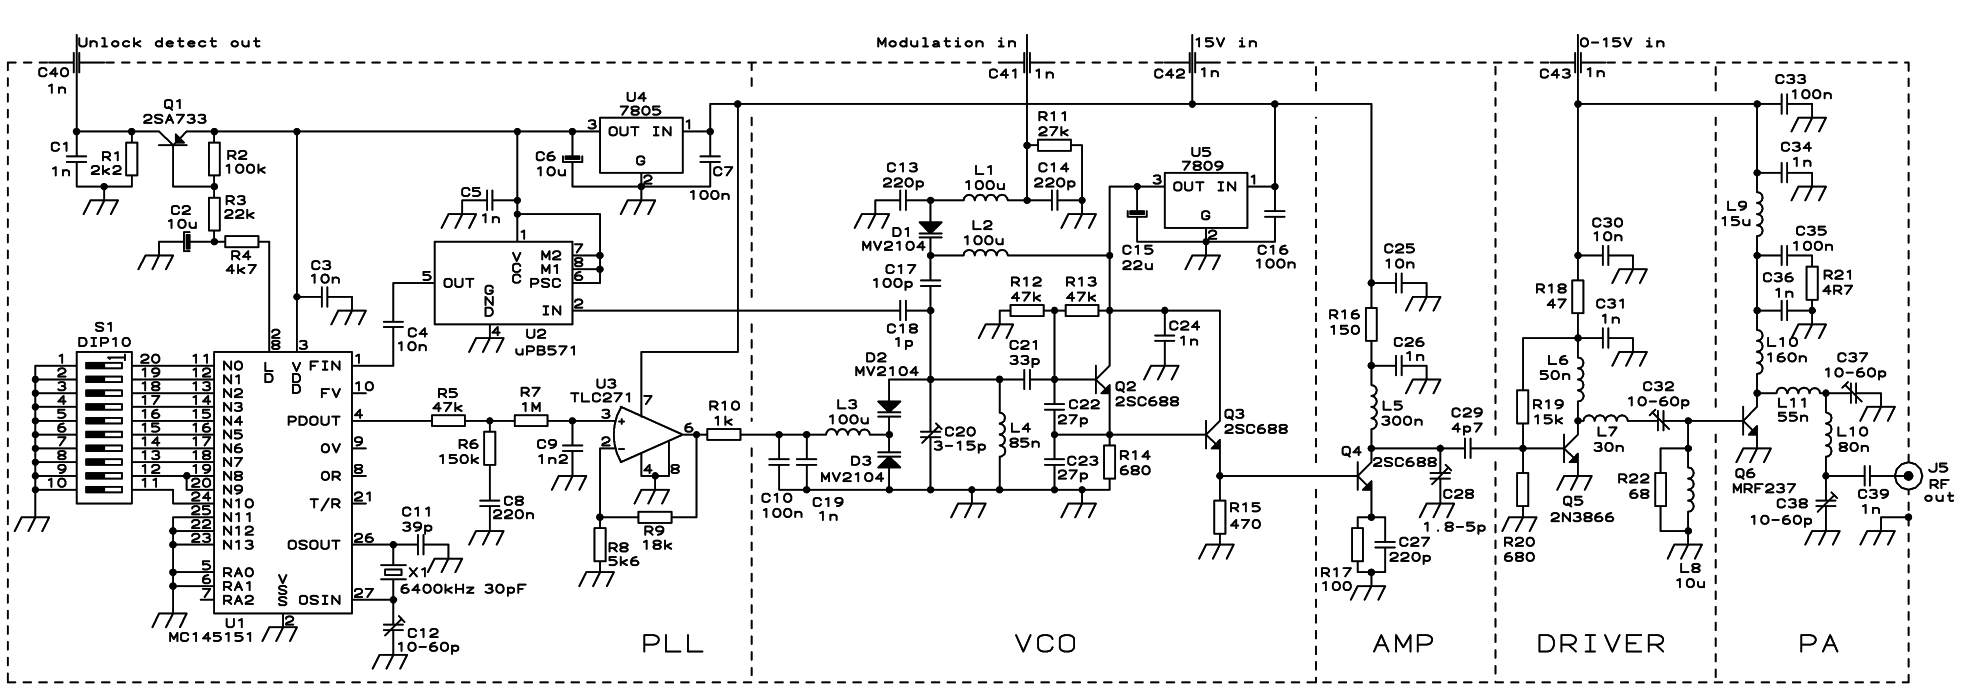
PLL FM Transmitter Circuit
The PLL transmitter exciter is designed to provide a stable, low noise, frequency-selectable RF signal, which is amplified to a controllable output power sufficient to drive a power amplifier. It utilizes a PLL frequency synthesizer based on the MC145151, covering...
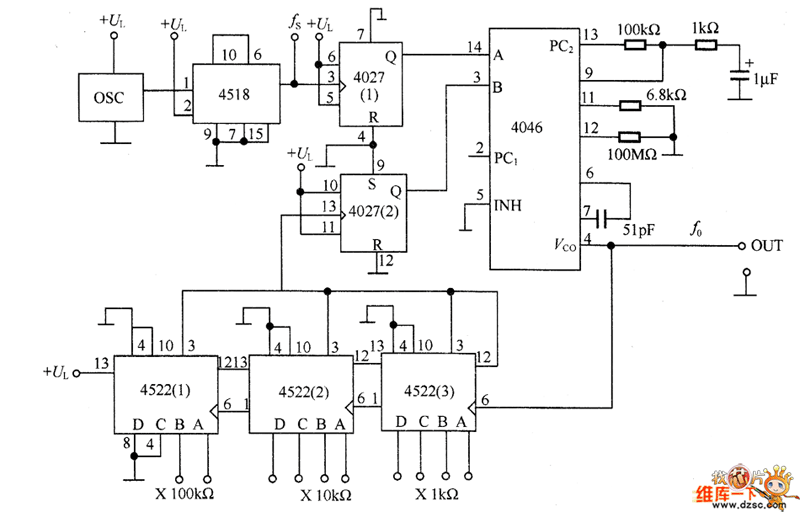
The PLL synthesized oscillator circuit diagram
The PLL synthesizer oscillator circuit is a feedback loop consisting of a reference oscillator, phase comparator, loop filter, voltage-controlled oscillator, programmable frequency divider, and various other components. In this circuit, the reference oscillator employs a crystal oscillator (OSC) to output...