


5-motor hexapod circuit
#motor control
#H-bridge
#hexapod
#BEAM robotics
#microcontroller
#motor driver
#robotics
#walking robot
#DIY robot
#circuit design
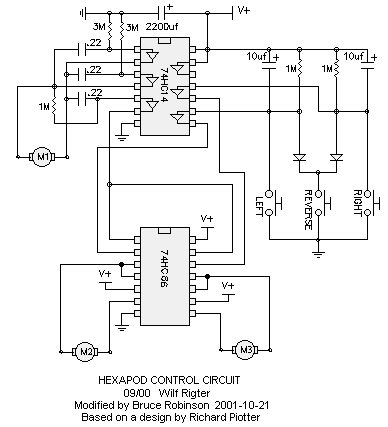
Description: This circuit has a long history, originating from an idea by Rich Piotter and later refined by Wilf Rigter and Bruce Robinson. The final result does not include the necessary motor drivers, which are typically H-bridge based, but presents a high-level circuit. Rich Piotter initially shared this circuit in a post to the Yahoo BEAM group on September 25, 2000, identified as post #5955. Shortly thereafter, Wilf Rigter showcased his version in post #6020. Over the following year, Bruce Robinson made further simplifications, reducing the pin count and leading to the circuit diagram presented. This final iteration was introduced to the public indirectly through an announcement by "Sparky" Garvin in Yahoo groups post #19029.
This circuit represents a collaborative evolution of design ideas within the community, reflecting iterative enhancements that improve functionality and usability. The initial concept by Rich Piotter laid the groundwork for a circuit intended for robotic applications, particularly in the domain of BEAM robotics, which emphasizes minimalistic and efficient designs.
Wilf Rigter's contribution focused on refining the circuit to enhance its performance, likely addressing issues such as component count and overall complexity. The simplification process by Bruce Robinson further streamlined the design, making it more accessible for hobbyists and engineers alike. The reduction in pin count suggests a move towards a more compact and efficient circuit layout, which is crucial in applications where space and power efficiency are paramount.
Although the final schematic does not depict the motor drivers, it is essential to consider that H-bridge configurations are typically employed in such circuits to control the direction and speed of motors. An H-bridge allows for bidirectional control of a motor, enabling it to rotate in both clockwise and counterclockwise directions, which is particularly useful in robotic applications where maneuverability is required.
The announcement by "Sparky" Garvin served to disseminate this innovative design within the community, highlighting the importance of collaboration and shared knowledge in the field of electronics. The cumulative efforts of these engineers illustrate the iterative nature of circuit design, where each version builds upon the last, leading to more refined and effective solutions for practical applications. This circuit's legacy continues to inspire new designs and improvements in the realm of robotics and beyond.This circuit has a long and storied history - starting with an idea by Rich Piotter, then being honed and simplified by Wilf Rigter and Bruce Robinson. The final result does not show the necessary motor drivers (usually H-bridge based), but here`s the high-level circuit: Rich started this off with a circuit he posted to the Yahoo BEAM group on 9/
25/2000 in post #5955. A few days later, Wilf presented his version of the circuit in Yahoo groups post #6020. Over the course of the next year, Bruce simplified things a bit, reducing pin count, yielding the circuit diagram above. This final version was unleashed upon the world indirectly, via an announcement by "Sparky" Garvin in Yahoo groups post #19029.
This circuit represents a collaborative evolution of design ideas within the community, reflecting iterative enhancements that improve functionality and usability. The initial concept by Rich Piotter laid the groundwork for a circuit intended for robotic applications, particularly in the domain of BEAM robotics, which emphasizes minimalistic and efficient designs.
Wilf Rigter's contribution focused on refining the circuit to enhance its performance, likely addressing issues such as component count and overall complexity. The simplification process by Bruce Robinson further streamlined the design, making it more accessible for hobbyists and engineers alike. The reduction in pin count suggests a move towards a more compact and efficient circuit layout, which is crucial in applications where space and power efficiency are paramount.
Although the final schematic does not depict the motor drivers, it is essential to consider that H-bridge configurations are typically employed in such circuits to control the direction and speed of motors. An H-bridge allows for bidirectional control of a motor, enabling it to rotate in both clockwise and counterclockwise directions, which is particularly useful in robotic applications where maneuverability is required.
The announcement by "Sparky" Garvin served to disseminate this innovative design within the community, highlighting the importance of collaboration and shared knowledge in the field of electronics. The cumulative efforts of these engineers illustrate the iterative nature of circuit design, where each version builds upon the last, leading to more refined and effective solutions for practical applications. This circuit's legacy continues to inspire new designs and improvements in the realm of robotics and beyond.This circuit has a long and storied history - starting with an idea by Rich Piotter, then being honed and simplified by Wilf Rigter and Bruce Robinson. The final result does not show the necessary motor drivers (usually H-bridge based), but here`s the high-level circuit: Rich started this off with a circuit he posted to the Yahoo BEAM group on 9/
25/2000 in post #5955. A few days later, Wilf presented his version of the circuit in Yahoo groups post #6020. Over the course of the next year, Bruce simplified things a bit, reducing pin count, yielding the circuit diagram above. This final version was unleashed upon the world indirectly, via an announcement by "Sparky" Garvin in Yahoo groups post #19029.
synchronizing fireflies ng
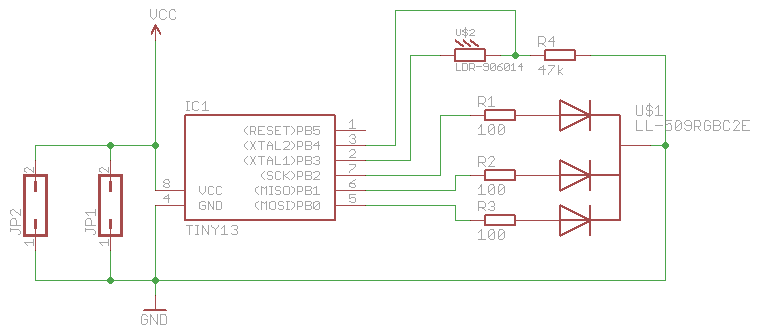
This is a remake of the fireflies project that was created a year ago. The concept revolves around the emergence of patterns, particularly the synchronization of hundreds or thousands of fireflies. Initially, they flash randomly, but over time, influenced by...
Protecting Microcontroller Input Pins from Soft Power Switch
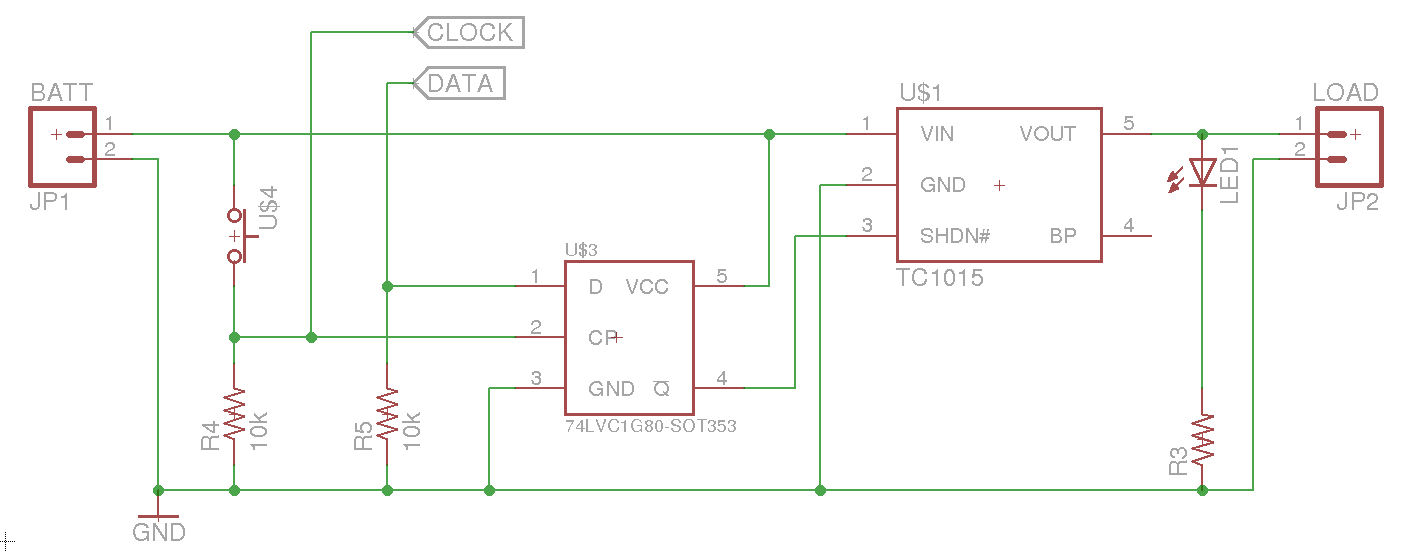
A soft power switch for a microcontroller is designed such that a momentary switch can activate the circuit, including the microcontroller. When the switch is pressed a second time, the microcontroller is capable of shutting itself down after executing necessary...
Power supplies for microcontroller based projects
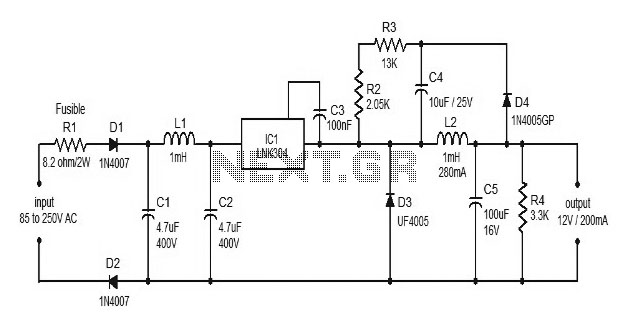
This document discusses the use of small microcontrollers, such as those from the PIC and Atmel series, which typically operate at 5V and require less than 100mA for complete system functionality. Some PICs can function at lower voltages, such as...
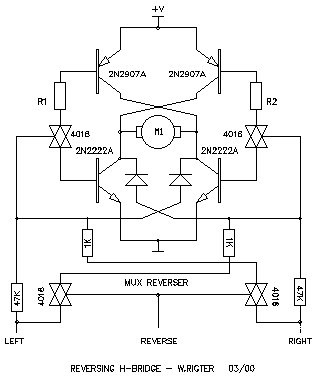
Wilf Rigter`s reversing H-bridge
This H-bridge variant was one of the first in which the reversing circuitry is built into the driver, rather than (as is more-commonly done) into the control circuitry upstream of the driver. This is a handy circuit, though, for 2-motor...
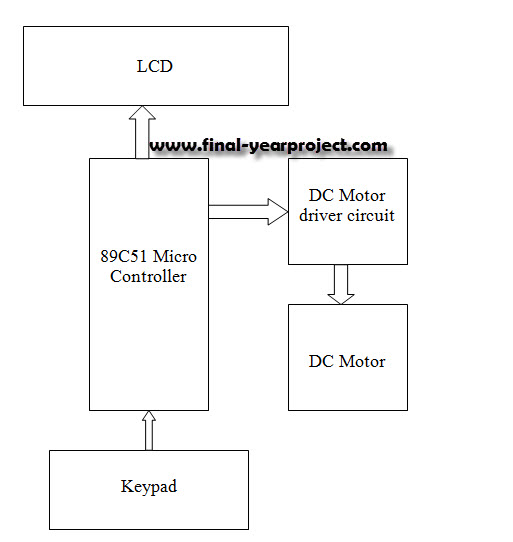
Speed Control of DC Motor using Microcontroller by using PWM ECE Project
This report details an electronic project focused on the speed control of a DC motor using a microcontroller and PWM (Pulse Width Modulation). The system integrates a microcontroller with an LCD, keypad, and a DC motor driver. The microcontroller generates...
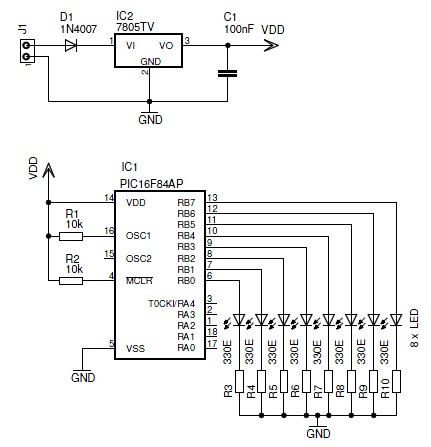
knight Rider
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
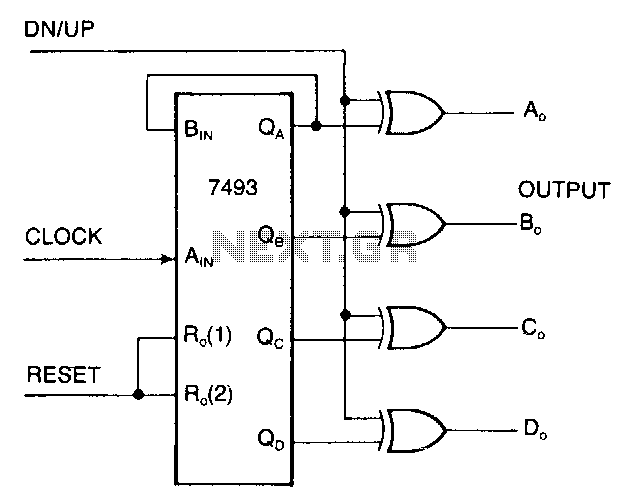
Eight-digit-microprocessor-display
The display interface utilizes the ICM7218A/B in conjunction with an 8048 family microcontroller. An 8-bit data bus (DBO/DB7-IDO/ID7) facilitates the transfer of control and data information to the 7218 display interface during successive WRITE pulses. The mode input pins on...
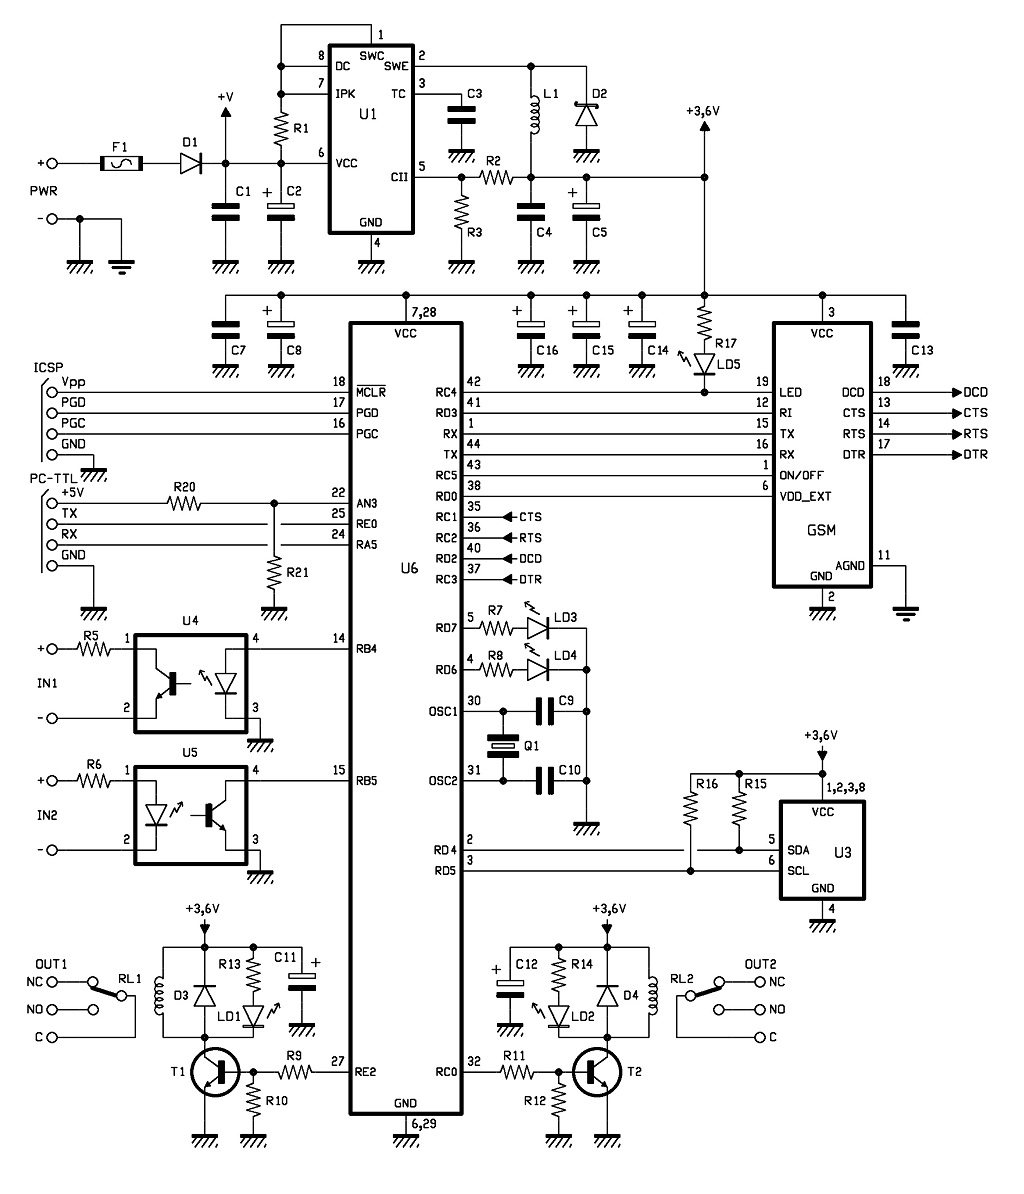
GSM Remote Control 2 IN and 2 OUT Part 2 Schematic
The control of the system is managed by a Microchip PIC18F46K20-I/PT microcontroller, which is programmed with firmware to oversee the activity of the GSM/GPRS module, monitor the logic conditions of two opto-isolated inputs, and send commands to two relays within...
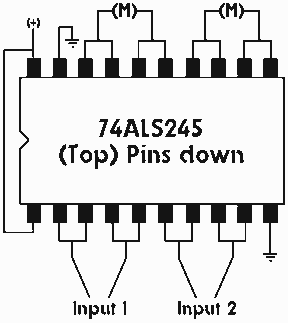
Single IC chip Motor Driver for robots
A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. This...