


Wilf Rigter`s reversing H-bridge
#H-bridge
#motor control
#reversing circuitry
#driver circuit
#2-motor walkers
#motor phasing
#electronic driver
#circuit design
#DC motor
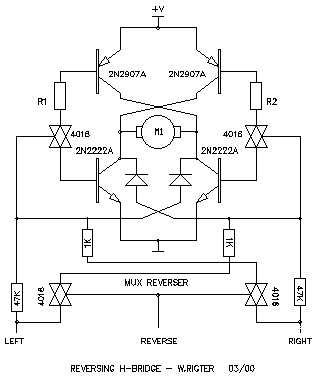
Description: This H-bridge variant was one of the first in which the reversing circuitry is built into the driver, rather than (as is more-commonly done) into the control circuitry upstream of the driver. This is a handy circuit, though, for 2-motor walkers -- as all that is required to reverse one is to reverse the phasing of one of the motors.
The described H-bridge circuit is a pivotal component in motor control applications, particularly for robotic systems such as two-motor walkers. An H-bridge allows for bidirectional control of DC motors by enabling current to flow through the motor in either direction. This specific variant distinguishes itself by integrating the reversing circuitry directly within the driver, streamlining the design and reducing the complexity typically associated with external control circuitry.
In this configuration, the H-bridge consists of four switches, typically implemented using transistors or MOSFETs, arranged in an 'H' shape. The two motors are connected across the horizontal legs of the 'H', while the vertical legs are connected to the power supply and ground. By controlling the state of the switches, the circuit can reverse the polarity applied to the motor terminals.
For a two-motor walker, the ability to reverse one motor independently allows for more versatile movement patterns. To achieve this, the control logic can be designed to selectively activate the switches associated with the motor that requires reversal. For instance, if one motor is to be reversed, the switches connected to that motor are toggled, while the other motor continues to operate in its original direction.
This approach simplifies the control strategy, as only one motor's phasing needs to be adjusted for directional changes, rather than managing complex control signals for both motors simultaneously. Consequently, the H-bridge variant enhances the efficiency of motor control in robotic applications, facilitating smoother and more responsive maneuvering capabilities.
Overall, this integrated design not only saves space on the circuit board but also reduces the number of components required, leading to a more compact and cost-effective solution for driving dual motors in robotic systems.This H-bridge variant was one of the first in which the reversing circuitry is built into the driver, rather than (as is more-commonly done) into the control circuitry upstream of the driver. This is a handy circuit, though, for 2-motor walkers -- as all that is required to reverse one is to reverse the phasing of one of the motors.
The described H-bridge circuit is a pivotal component in motor control applications, particularly for robotic systems such as two-motor walkers. An H-bridge allows for bidirectional control of DC motors by enabling current to flow through the motor in either direction. This specific variant distinguishes itself by integrating the reversing circuitry directly within the driver, streamlining the design and reducing the complexity typically associated with external control circuitry.
In this configuration, the H-bridge consists of four switches, typically implemented using transistors or MOSFETs, arranged in an 'H' shape. The two motors are connected across the horizontal legs of the 'H', while the vertical legs are connected to the power supply and ground. By controlling the state of the switches, the circuit can reverse the polarity applied to the motor terminals.
For a two-motor walker, the ability to reverse one motor independently allows for more versatile movement patterns. To achieve this, the control logic can be designed to selectively activate the switches associated with the motor that requires reversal. For instance, if one motor is to be reversed, the switches connected to that motor are toggled, while the other motor continues to operate in its original direction.
This approach simplifies the control strategy, as only one motor's phasing needs to be adjusted for directional changes, rather than managing complex control signals for both motors simultaneously. Consequently, the H-bridge variant enhances the efficiency of motor control in robotic applications, facilitating smoother and more responsive maneuvering capabilities.
Overall, this integrated design not only saves space on the circuit board but also reduces the number of components required, leading to a more compact and cost-effective solution for driving dual motors in robotic systems.This H-bridge variant was one of the first in which the reversing circuitry is built into the driver, rather than (as is more-commonly done) into the control circuitry upstream of the driver. This is a handy circuit, though, for 2-motor walkers -- as all that is required to reverse one is to reverse the phasing of one of the motors.
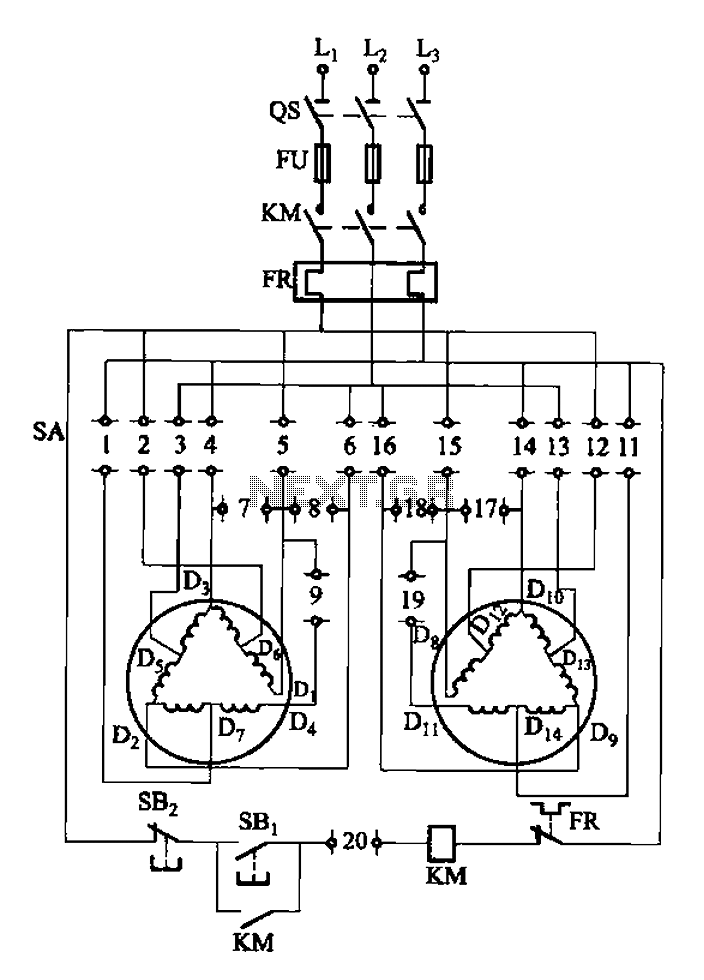
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
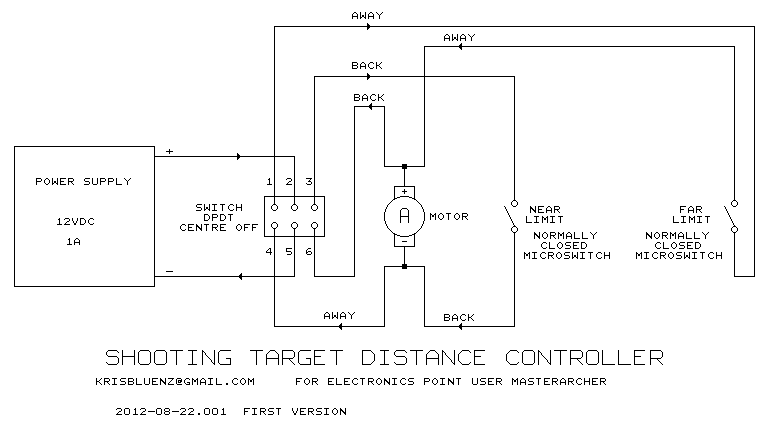
Motor control diy
The motor is rated at 6W, which corresponds to a current of 0.5 amps at a voltage of 12V. It is recommended to use a 12V DC power supply with a rating of 1A or higher. Any type of power...
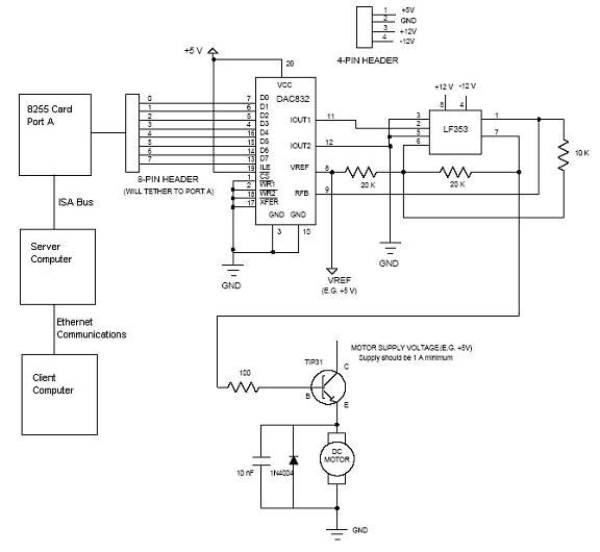
Open Loop Speed Control of a DC Motor via 8255 Controller
Open loop speed control of a DC motor is implemented using the 8255 Digital I/O Controller chip in conjunction with a TCP/IP server-client application programmed in Visual Basic. The DAC0832 chip serves as the Digital to Analog Converter. This project...
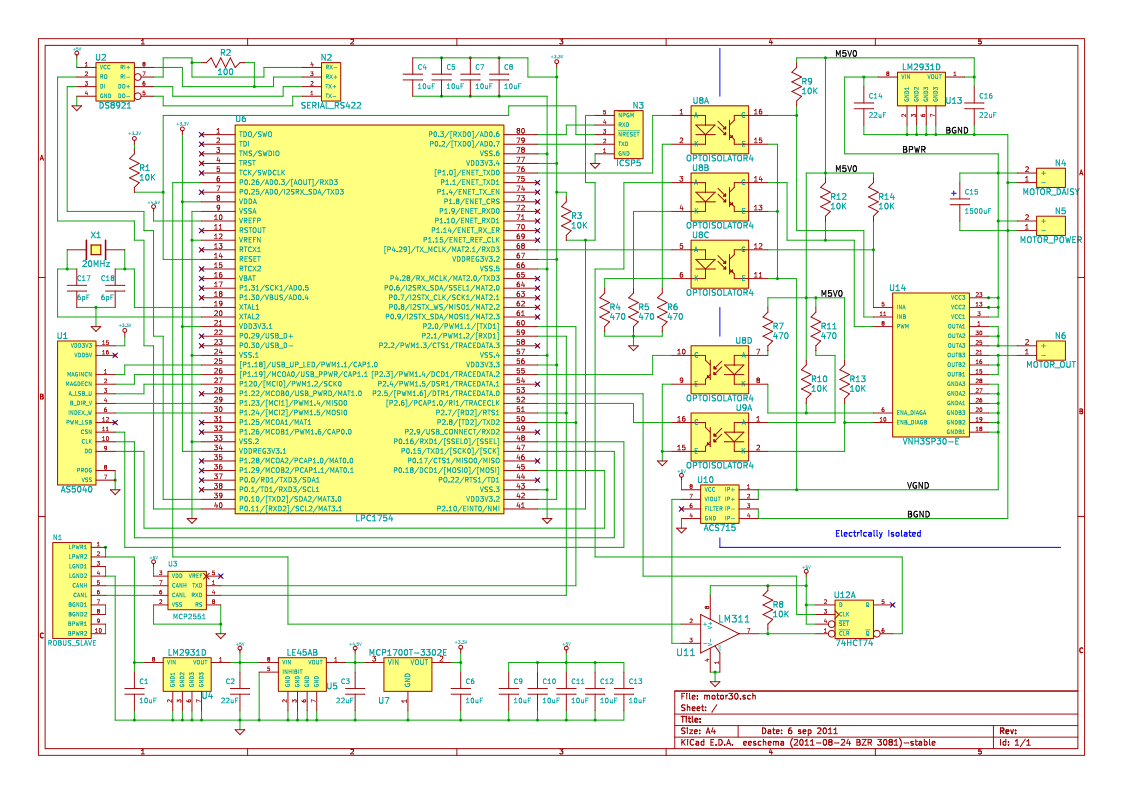
Motor30
The Motor30 board is an H-bridge designed to supply up to 30 Amperes of current to a motor. It features an integrated hall-effect shaft angle sensor. The module is fully opto-isolated to prevent motor noise from affecting the logic power...
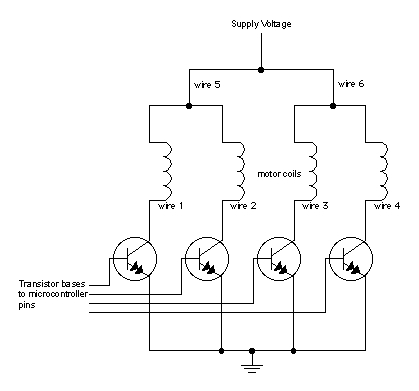
Motor circuits
When moving objects with microcontrollers, three types of motors are particularly useful: DC motors, servomotors, and stepper motors. Most motors operate on the electrical principle of induction. When electric current flows through a wire, it generates a magnetic field around...
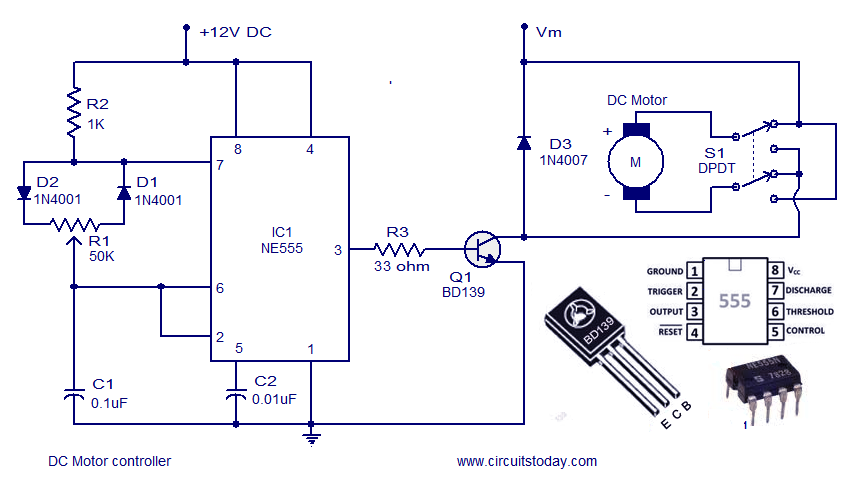
Dc motor speed controller circuit using NE555
A DC motor controller based on an NE555 timer is presented here. The direction of rotation of the DC motor can also be changed using this DC motor speed control circuit.
The described circuit utilizes the NE555 timer IC in astable...
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
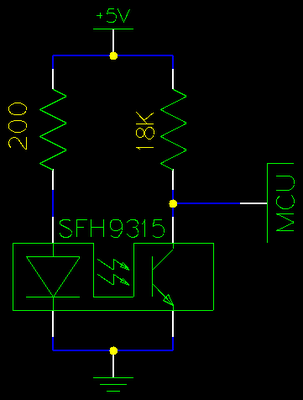
Gray Projects
After learning to operate the device, it became evident that inertia posed a significant challenge. The constructed system is notably heavy, making it difficult to initiate motor operation at full speed. Despite having some understanding of physics, practical experience is...
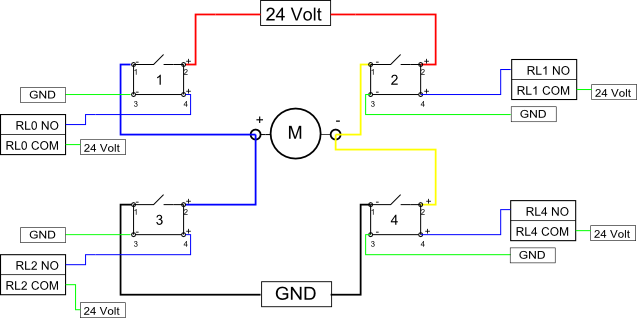
quick jobs h bridge circuit to drive
Eight solid-state relays (SSR) and an ADAM-4068 (Serial-I/O device) are utilized to wire a circuit for controlling a motor in a robotic application. The ADAM-6048 is a versatile device that facilitates control of digital inputs and outputs via RS-485 serial...