


quick jobs h bridge circuit to drive
#H-bridge
#solid-state relay
#RS-485
#serial communication
#motor driver
#robot
#ADAM-4068
#SSR
#digital control
#high current
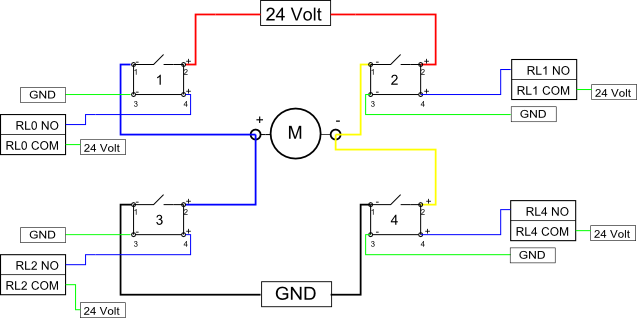
Description: Eight solid-state relays (SSR) and an ADAM-4068 (Serial-I/O device) are utilized to wire a circuit for controlling a motor in a robotic application. The ADAM-6048 is a versatile device that facilitates control of digital inputs and outputs via RS-485 serial communication, adhering to the protocol outlined in its manual. The output of the ADAM is rated at 0.5 amperes, which is suitable for controlling the SSR that can handle up to 40 amperes each. When the output is set to "high," current can flow from the common (COM) terminal to the normally open (NO) terminal. This can be visualized as a simple switch; when both pins are activated, they connect, allowing current to flow. Consequently, pin 1 and pin 2 of the SSR will connect, enabling a high current to pass through the motor. Unlike conventional relays, SSRs allow current to flow in only one direction, specifically from pin 2 to pin 1 and from pin 4 to pin 3, as indicated by the positive and negative signs in the accompanying diagram. Two SSRs were damaged due to a misunderstanding of this directional current flow.
The circuit design for controlling a motor using solid-state relays (SSRs) and the ADAM-4068 device involves several key components and considerations. The ADAM-4068 serves as a communication interface, allowing for the transmission of control signals to the SSRs through RS-485 serial communication. Each SSR is capable of managing high current loads, making them ideal for motor control applications.
To set up the circuit, the output from the ADAM-4068 is connected to the input terminals of the SSRs. The output signal from the ADAM is configured to switch to a "high" state when motor activation is required. This high signal enables current to flow from the common terminal (COM) to the normally open terminal (NO) of the SSR, effectively closing the circuit and powering the motor.
It is essential to ensure that the SSRs are correctly oriented in the circuit to prevent damage. The SSRs are designed to allow current to flow in a single direction; therefore, it is crucial to connect the positive and negative terminals correctly. The correct wiring configuration will ensure that when the control signal is activated, the SSR allows current to flow from the motor's power source through the SSR to the motor itself.
In addition, proper heat dissipation measures should be implemented, as SSRs can generate heat during operation, especially when controlling high currents. Heat sinks or proper ventilation should be considered to maintain optimal operating temperatures and ensure the longevity of the SSRs.
Overall, the combination of the ADAM-4068 and SSRs provides a robust solution for motor control in robotic applications, allowing for precise control and reliable operation. Proper attention to circuit design, component orientation, and heat management is vital for successful implementation.8 solid-state-relay (SSR) and ADAM-4068 (Serial-I/O device) and ask me to wire a circuit to control a motor for his robot. ADAM-6048 is a handy device that let you control digital input and output via RS-485, serial communication given a protocol in its manual.
Output of ADAM is rated at 0. 5 ampere so I use it to control the SSR which can operate up to 40 ampere each. When output set to "high", current will able to flow from COM to NO. Best to imagine it as a simple switch, when push both pin will connect and let a current flowing. Then pin 1 and pin 2 of SSR will connect and let a (high) current passthrough the motor. Unlike normal relay, SSR let current pass in only one direction, from pin 2 to pin 1 and from pin 4 to pin 3 as I indicate + and - sign in above diagram. I blown 2 SSR because of this ignorance!
The circuit design for controlling a motor using solid-state relays (SSRs) and the ADAM-4068 device involves several key components and considerations. The ADAM-4068 serves as a communication interface, allowing for the transmission of control signals to the SSRs through RS-485 serial communication. Each SSR is capable of managing high current loads, making them ideal for motor control applications.
To set up the circuit, the output from the ADAM-4068 is connected to the input terminals of the SSRs. The output signal from the ADAM is configured to switch to a "high" state when motor activation is required. This high signal enables current to flow from the common terminal (COM) to the normally open terminal (NO) of the SSR, effectively closing the circuit and powering the motor.
It is essential to ensure that the SSRs are correctly oriented in the circuit to prevent damage. The SSRs are designed to allow current to flow in a single direction; therefore, it is crucial to connect the positive and negative terminals correctly. The correct wiring configuration will ensure that when the control signal is activated, the SSR allows current to flow from the motor's power source through the SSR to the motor itself.
In addition, proper heat dissipation measures should be implemented, as SSRs can generate heat during operation, especially when controlling high currents. Heat sinks or proper ventilation should be considered to maintain optimal operating temperatures and ensure the longevity of the SSRs.
Overall, the combination of the ADAM-4068 and SSRs provides a robust solution for motor control in robotic applications, allowing for precise control and reliable operation. Proper attention to circuit design, component orientation, and heat management is vital for successful implementation.8 solid-state-relay (SSR) and ADAM-4068 (Serial-I/O device) and ask me to wire a circuit to control a motor for his robot. ADAM-6048 is a handy device that let you control digital input and output via RS-485, serial communication given a protocol in its manual.
Output of ADAM is rated at 0. 5 ampere so I use it to control the SSR which can operate up to 40 ampere each. When output set to "high", current will able to flow from COM to NO. Best to imagine it as a simple switch, when push both pin will connect and let a current flowing. Then pin 1 and pin 2 of SSR will connect and let a (high) current passthrough the motor. Unlike normal relay, SSR let current pass in only one direction, from pin 2 to pin 1 and from pin 4 to pin 3 as I indicate + and - sign in above diagram. I blown 2 SSR because of this ignorance!
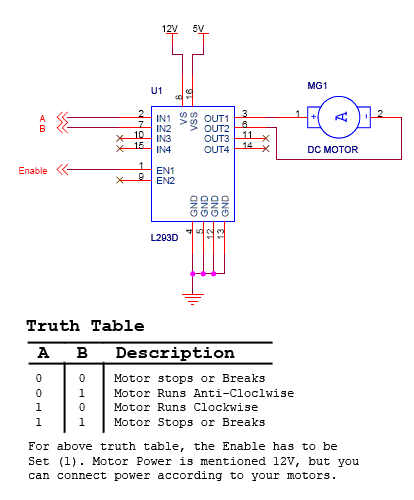
h bridge Where to place decoupling capacitor
This circuit is designed to drive a motor, and it has been suggested that a decoupling capacitor should be included to mitigate voltage spikes. There are conflicting opinions on the placement of this capacitor; some advise positioning it close to...
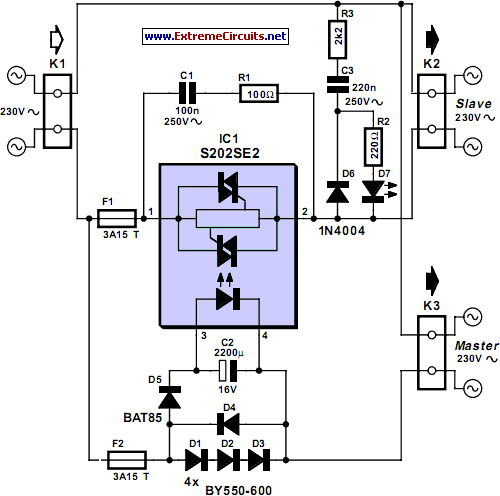
Master/Slave Switch
The circuit detects the mains current supplied to a master device and controls the on/off state of slave equipment. This functionality is particularly beneficial in environments such as hi-fi systems or home computers, where multiple peripheral devices can be managed...
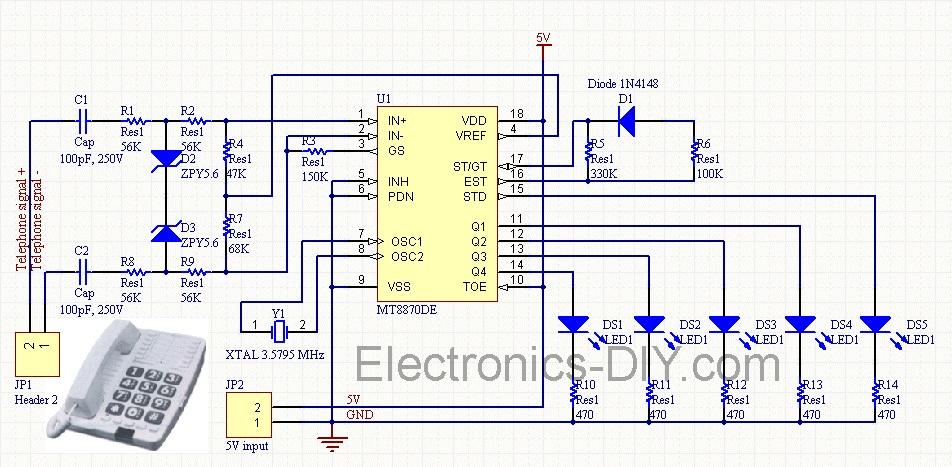
Cellphone Operated Land Rover (Mobile Phone Controlled Robot)
Cellphone Operated Land Rover (Mobile Phone Operated Robot). In this project, the robot is controlled by a mobile phone that makes a call to the mobile phone attached to the robot.
The cellphone operated Land Rover project involves the design and...
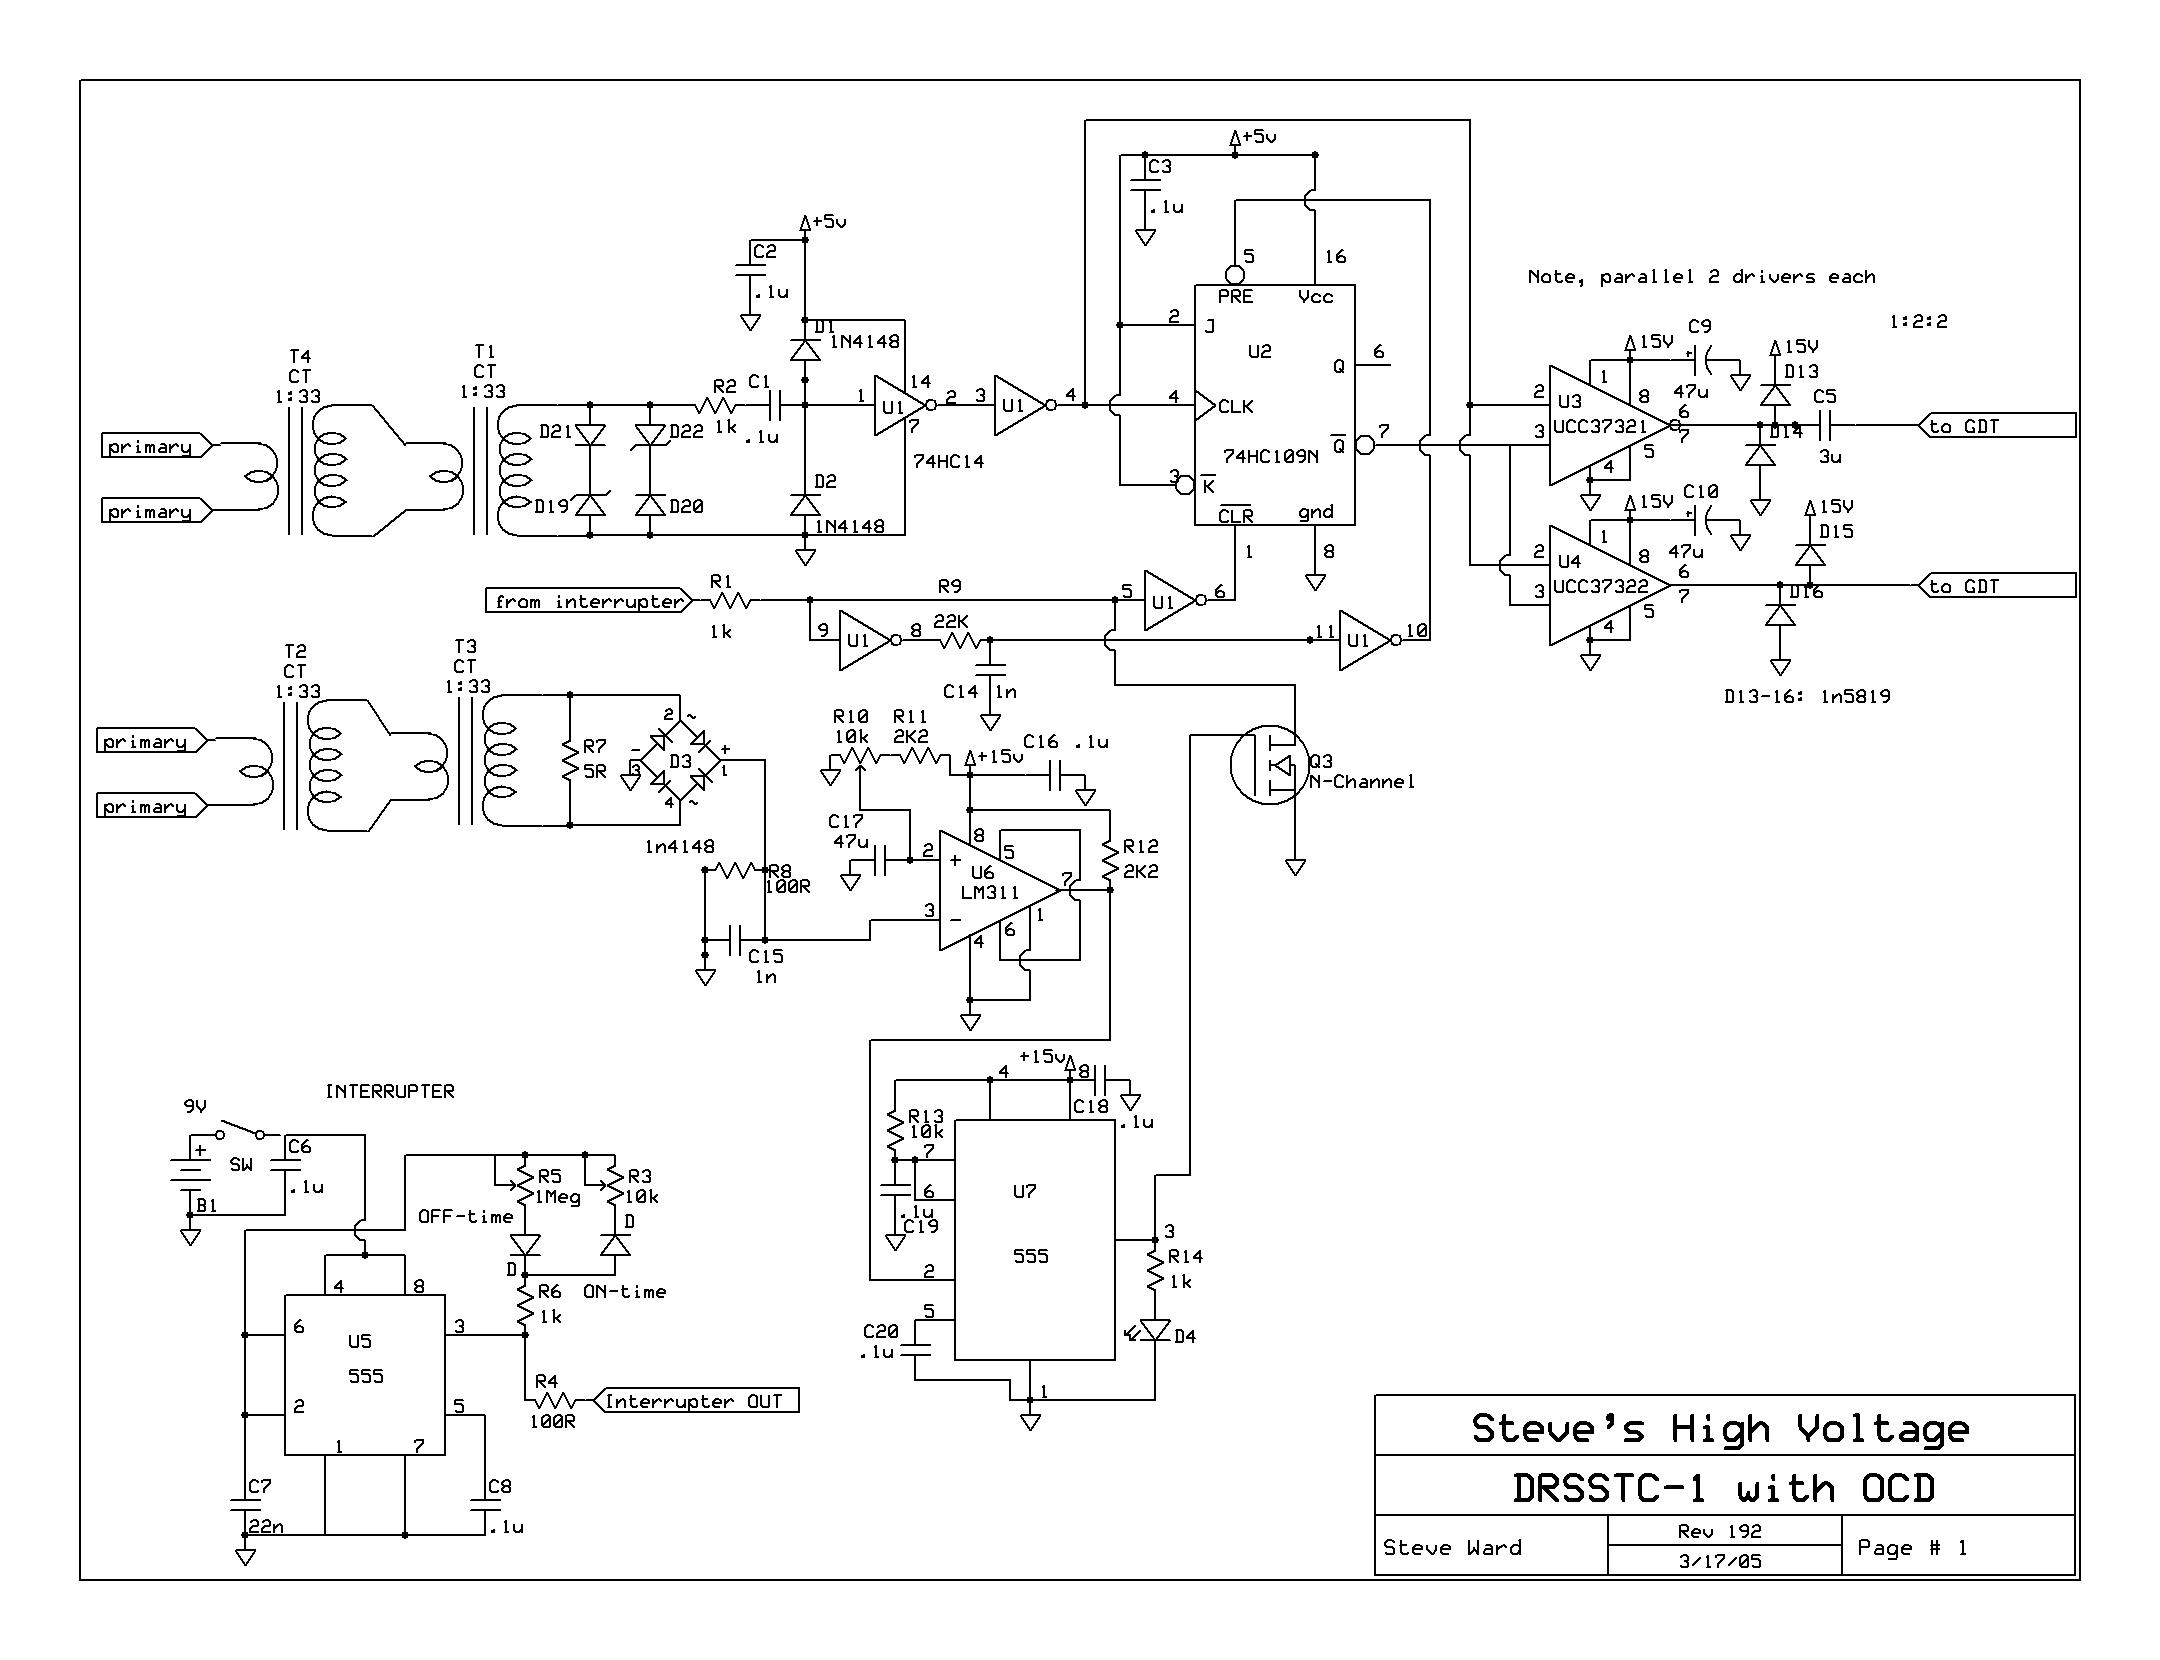
H-bridge of 40N60 mini-brick IGBTs
This first DRSSTC evolved from the ISSTC work previously undertaken. After discussions with Jimmy Hynes, the creator of the first DRSSTC, it was decided to implement a modified design. Hynes' DRSSTC utilized an oscillator to produce a high-frequency signal for...
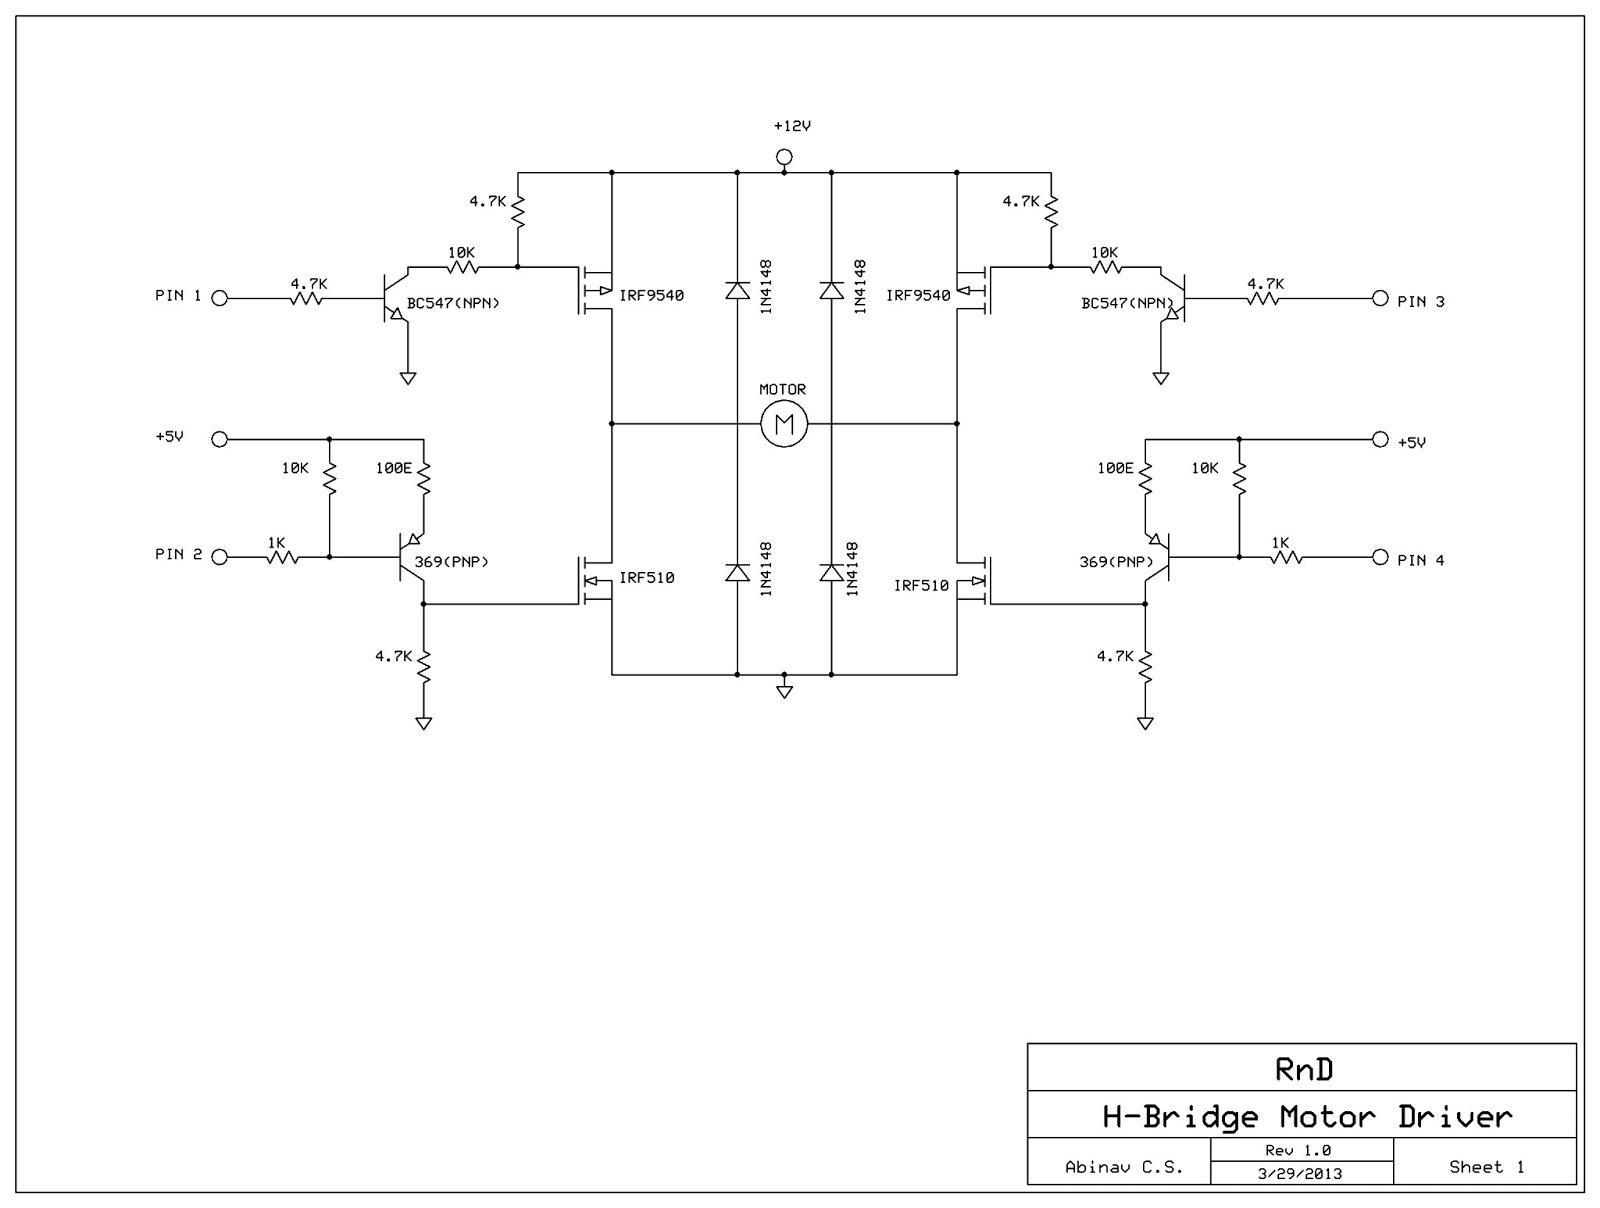
H-Bridge Motor Driver using MOSFETs and Transistors
This post discusses the construction of an H-Bridge Motor Driver circuit using simple MOSFETs and transistors. The primary feature of this H-Bridge is its ability to drive a motor in both directions. An H-Bridge is a circuit that allows voltage...
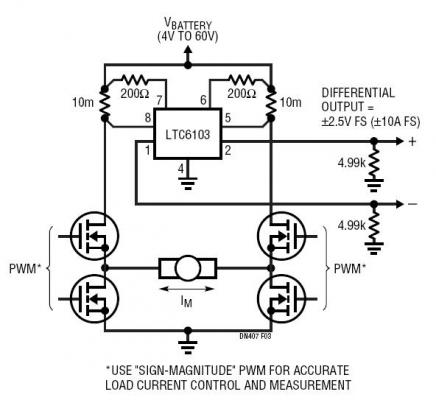
Bidirectional H-Bridge Monitoring with ADC-Friendly Differential Output
The dual outputs of the LTC6103 can be utilized independently for overload detection or combined as a differential pair to provide a bidirectional signal to an analog-to-digital converter (ADC). A typical circuit for a generic H-bridge application is illustrated. The...
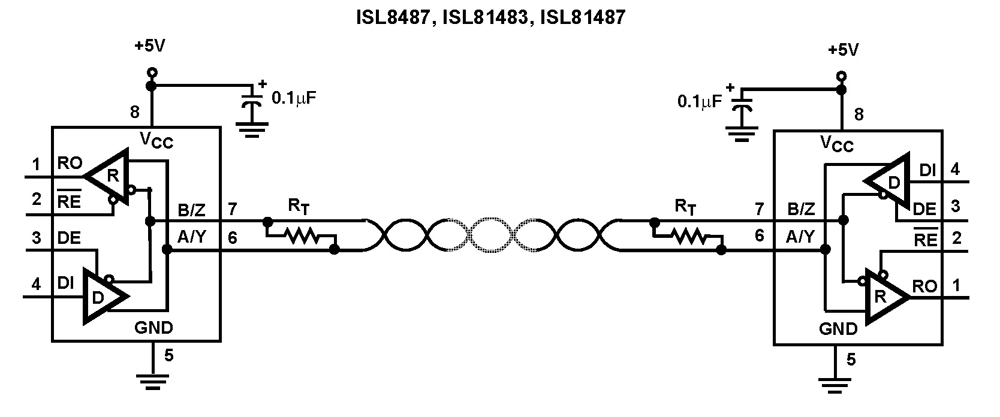
ISL81487 5V Half Duplex 5Mbps RS-485/RS-422 Transceiver
The Intersil RS-485/RS-422 devices are fractional unit load (UL), BiCMOS, 5V powered, single transceivers that comply with both RS-485 and RS-422 standards for balanced communication. This Intersil family is designed for 10% tolerance supplies (4.5V to 5.5V). The ISL81483 and...
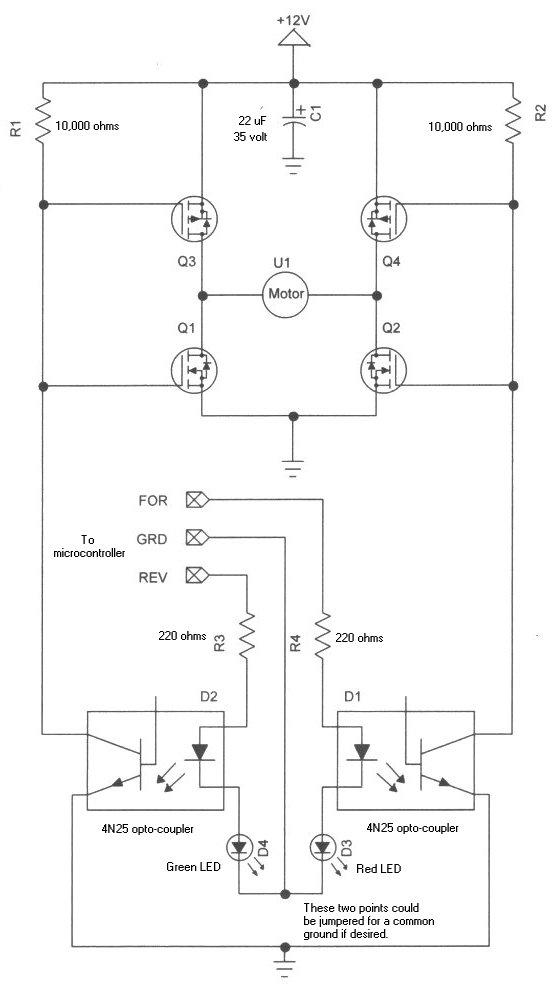
h bridge
Learning how to use power MOSFETs by building an H-bridge motor control.
The H-bridge motor control circuit is an essential configuration for driving DC motors in both forward and reverse directions. It utilizes four power MOSFETs arranged in a bridge configuration,...
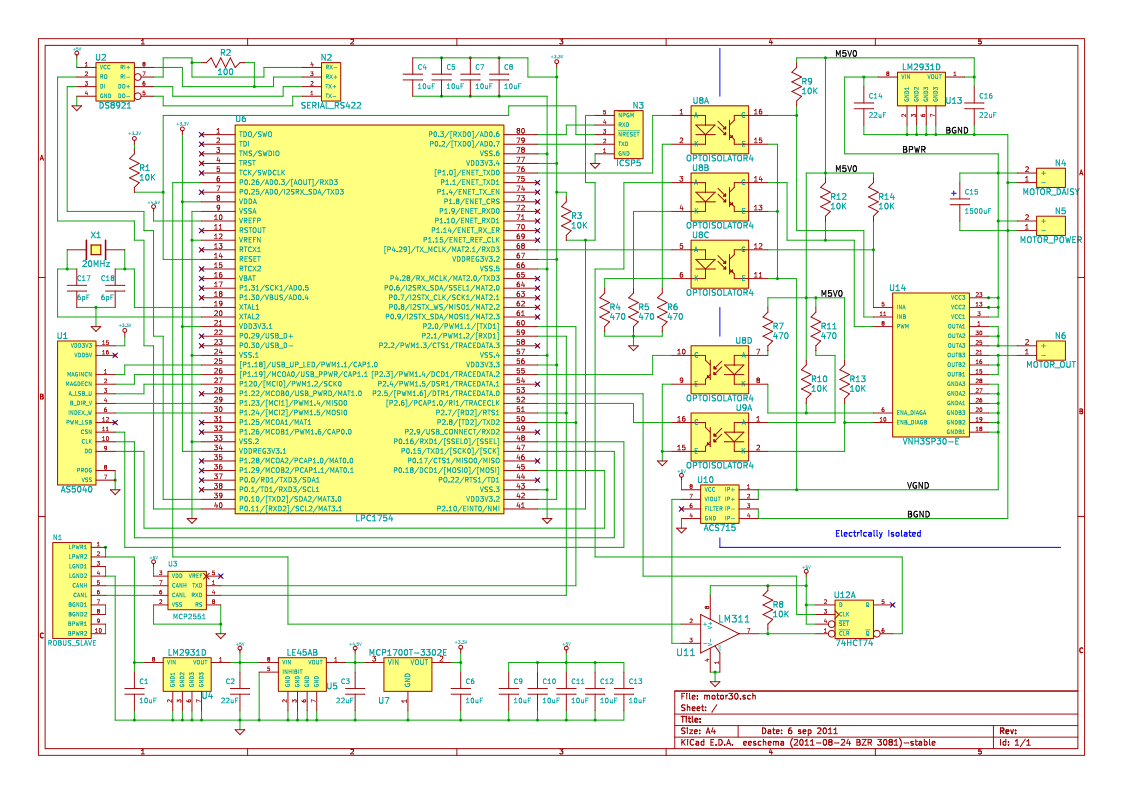
Motor30
The Motor30 board is an H-bridge designed to supply up to 30 Amperes of current to a motor. It features an integrated hall-effect shaft angle sensor. The module is fully opto-isolated to prevent motor noise from affecting the logic power...