


Unipolar Stepper Motor Controllers
#stepper motor
#motor driver
#integrated circuit
#compact design
#direction control
#stepping pulses
#5-wire
#6-wire
#8-wire
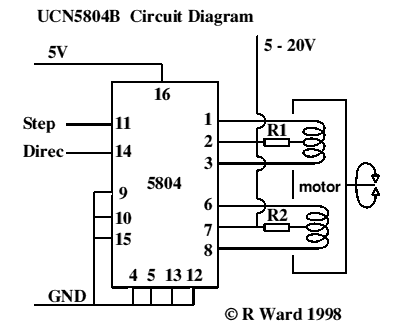
Description: This integrated circuit is highly efficient and does not require any external glue logic for operation. It features two pins to control a motor: one for direction and the other for stepping pulse triggers. The design is compact and supports 5, 6, or 8 wire stepper motors. The 5 and 8 wire motors are variations of the 6 wire motor, where the 5 wire motor has its two common wires from the coils' center taps connected internally, reducing external connections. However, there can be some confusion regarding the coil connections, which may require trial and error for proper pairing without causing damage. For 8 wire motors, the center taps need to be identified independently, and experimentation may be necessary to determine the correct polarity. Resistors R1 and R2 are recommended when the supply voltage exceeds approximately 10 volts, primarily for tuning motor response times at high speeds. Data sheets provide additional details. Six wire motors are widely available and offer clear connections, making them suitable for applications requiring significant power, such as printers. Non-functional dot matrix printers are common sources for these motors, which can also provide belts, pulleys, gears, and possibly a power supply for experimental use.
The integrated circuit described is designed to efficiently drive stepper motors with minimal external components, making it ideal for compact applications. The two control pins facilitate straightforward operation by allowing users to manage both the direction of the motor and the timing of the stepping pulses. This simplicity is particularly advantageous in scenarios where space and complexity must be minimized.
When dealing with 5 or 8 wire stepper motors, it is essential to recognize their configurations. The 5 wire motor's internal connection of the center taps streamlines the wiring process, but users must be cautious during setup to ensure the correct connections of the remaining coil ends. This may involve some experimentation, as the identification of coil pairs can lead to confusion. The 8 wire motors, while more flexible due to their additional wires, require careful mapping of the center taps and an understanding of coil polarities, which may necessitate testing to achieve optimal performance.
The inclusion of resistors R1 and R2 becomes critical when operating at higher voltages, as they help manage the current and voltage levels to the motor, ensuring reliable operation and protecting the circuit from potential damage. These resistors are particularly useful in high-speed applications, where the response time of the motor is crucial for maintaining performance.
In practical applications, six wire stepper motors are preferred due to their widespread availability and ease of connection. These motors are commonly used in various devices, including printers, where their power capabilities are essential. For those seeking to experiment with stepper motors, non-working dot matrix printers serve as an excellent resource, providing not only motors but also additional mechanical components like belts and gears that can be repurposed for various projects. This approach not only promotes hands-on learning but also encourages innovation in motor control applications.This is a very good integrated circuit. There is no need for any external glue logic to drive the circuit, there is only 2 pins to drive the motor, one for controlling the direction and the other to trigger the stepping pulses. It provides a very compact design that drives 5 or 6 or 8 wire stepper motors. The 5 or 8 wire stepper motors are treated as a variation on the 6 wire motor. That is, the 5 has the two common wires from the coils center taps joined inside the motor (saves joining them outside the motor), however some confusion may occur with the ends of the other coils as to which joins with which, however trial and error to determine this will not hurt anything. In the 8 wire motor case the joined center taps will have to worked out by you. You will know which coil is joined to which coil, however experimentation may be required to determine polarity.
The resistors R1 & R2 are only necessary if the supply voltage to the motors is above 10 volts or so, and are really only necessary near max voltages and tuning the response times of the motor for high speeds. See data sheets for details. There should be very little problem getting hold of six wire motors that make the connections obvious.
These motors are by far the most common where any degree of power is required, e. g. in printers. Non-working dot matrix printers are fairly common now-a-days and the motors in them are excellent starting points for experimentation. You will also get belts, pulleys and gears thrown in (may be even a power supply if your are adventurous).
The integrated circuit described is designed to efficiently drive stepper motors with minimal external components, making it ideal for compact applications. The two control pins facilitate straightforward operation by allowing users to manage both the direction of the motor and the timing of the stepping pulses. This simplicity is particularly advantageous in scenarios where space and complexity must be minimized.
When dealing with 5 or 8 wire stepper motors, it is essential to recognize their configurations. The 5 wire motor's internal connection of the center taps streamlines the wiring process, but users must be cautious during setup to ensure the correct connections of the remaining coil ends. This may involve some experimentation, as the identification of coil pairs can lead to confusion. The 8 wire motors, while more flexible due to their additional wires, require careful mapping of the center taps and an understanding of coil polarities, which may necessitate testing to achieve optimal performance.
The inclusion of resistors R1 and R2 becomes critical when operating at higher voltages, as they help manage the current and voltage levels to the motor, ensuring reliable operation and protecting the circuit from potential damage. These resistors are particularly useful in high-speed applications, where the response time of the motor is crucial for maintaining performance.
In practical applications, six wire stepper motors are preferred due to their widespread availability and ease of connection. These motors are commonly used in various devices, including printers, where their power capabilities are essential. For those seeking to experiment with stepper motors, non-working dot matrix printers serve as an excellent resource, providing not only motors but also additional mechanical components like belts and gears that can be repurposed for various projects. This approach not only promotes hands-on learning but also encourages innovation in motor control applications.This is a very good integrated circuit. There is no need for any external glue logic to drive the circuit, there is only 2 pins to drive the motor, one for controlling the direction and the other to trigger the stepping pulses. It provides a very compact design that drives 5 or 6 or 8 wire stepper motors. The 5 or 8 wire stepper motors are treated as a variation on the 6 wire motor. That is, the 5 has the two common wires from the coils center taps joined inside the motor (saves joining them outside the motor), however some confusion may occur with the ends of the other coils as to which joins with which, however trial and error to determine this will not hurt anything. In the 8 wire motor case the joined center taps will have to worked out by you. You will know which coil is joined to which coil, however experimentation may be required to determine polarity.
The resistors R1 & R2 are only necessary if the supply voltage to the motors is above 10 volts or so, and are really only necessary near max voltages and tuning the response times of the motor for high speeds. See data sheets for details. There should be very little problem getting hold of six wire motors that make the connections obvious.
These motors are by far the most common where any degree of power is required, e. g. in printers. Non-working dot matrix printers are fairly common now-a-days and the motors in them are excellent starting points for experimentation. You will also get belts, pulleys and gears thrown in (may be even a power supply if your are adventurous).
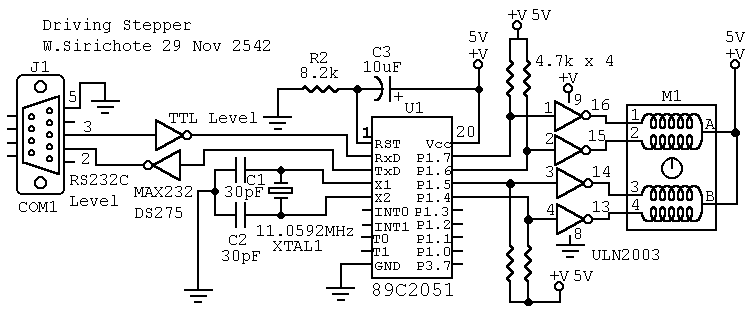
Driving Stepper
M1 is a stepper taken from an old disk drive. There are five pins, i.e., common, coil 1, 2, 3 and 4. Resistance measured between common pin and each coil is about 75 Ohms. Driving current for each coil is...
Pick
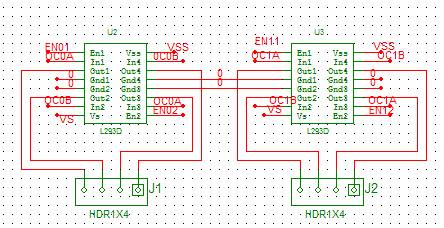
The second component is a Signal Distribution Board that transmits voltage, ground, and various signals throughout the system. This board is based on the design found on its dedicated page: Signal Distribution Board. The 7400 pick system is equipped with...
stepper motor interfacing connections
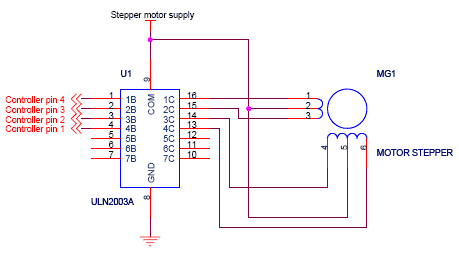
Stepper motor interfacing with a microcontroller. Full-step and half-step stepper control. Working principles and basics of stepper motors. Tutorial on 6-lead unipolar stepper motors and bipolar stepper motors.
Stepper motors are widely used in various applications requiring precise control of angular...
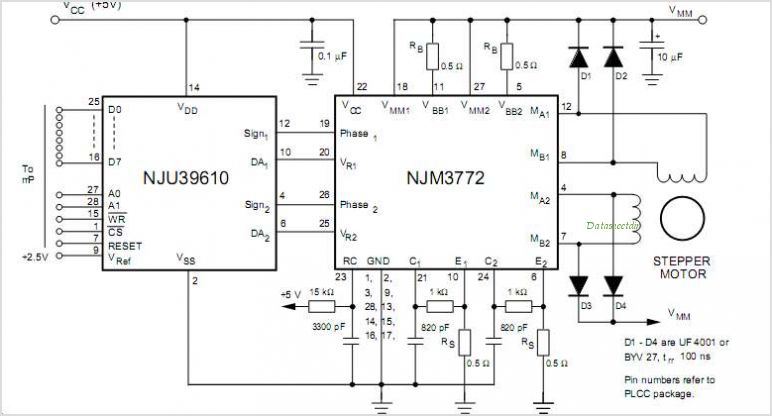
NJM3772 NJM3772 DUAL STEPPER MOTOR DRIVER
This device is a two-line audio EMI filter array designed for speaker applications. It provides greater than 35 dB attenuation at frequencies ranging from 800 MHz to 3.0 GHz. Additionally, this device offers ESD protection by clamping transients from static...
stepper motor controller schematic
A pulse motor, commonly known as a stepper motor, is defined as a motor that changes its excitation state according to input pulse signals, allowing it to move forward at a specific angle or distance. If the excitation state remains...

Music Driven Motor Schematic
Music Driven Motor Schematic. The geared motor drives the stem of a dancing flower to the beat of music.
The music-driven motor schematic involves a geared motor that is activated in response to sound signals, specifically music. This design typically incorporates...
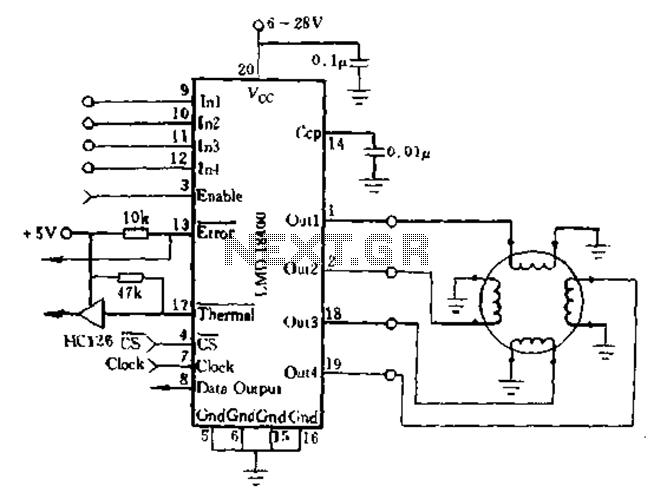
LMD18400 for four-phase stepper motor drive
The DMOS power switch exhibits an ON-state resistance with a positive temperature coefficient, allowing for the parallel connection of four switches to increase load current, resulting in a monolithic design. The LMD18400 can drive one, two, or four small DC...
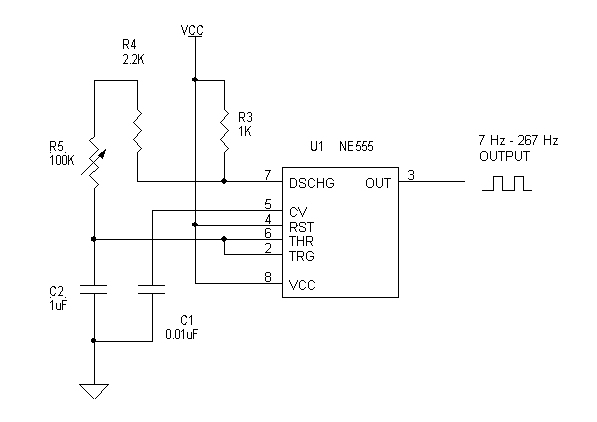
stepper motor tester
To build a stepper motor tester, the circuit includes two sets of drivers that support both unipolar and bipolar stepper motors. The control circuit and driver circuit are powered by separate supplies, allowing compatibility with a wider range of motor...
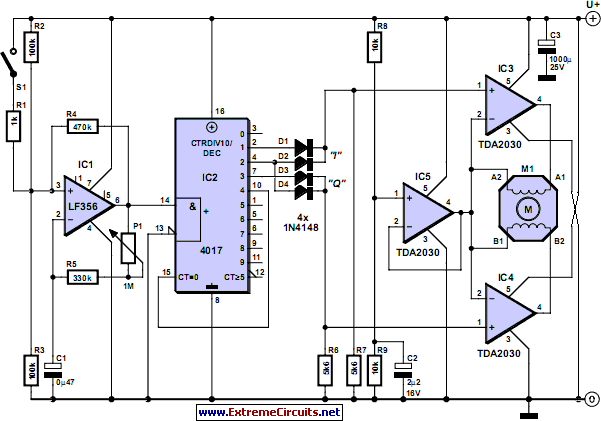
stepper motor controller
Stepper motors come in various versions and sizes, accommodating a range of operating voltages. This general-purpose controller is capable of functioning with voltages from approximately 5 V to 18 V, driving the motor with a peak voltage equal to half...