


stepper motor interfacing connections
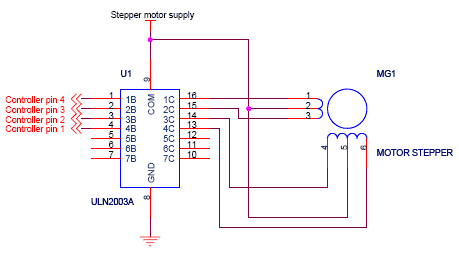
Description: Stepper motor interfacing with a microcontroller. Full-step and half-step stepper control. Working principles and basics of stepper motors. Tutorial on 6-lead unipolar stepper motors and bipolar stepper motors.
Stepper motors are widely used in various applications requiring precise control of angular position, speed, and acceleration. They are particularly useful in robotics, CNC machinery, and 3D printers due to their ability to divide a full rotation into a large number of steps. The interfacing of stepper motors with microcontrollers allows for the implementation of complex control algorithms that can enhance the performance of these motors.
The two primary types of stepper motors are unipolar and bipolar. A 6-lead unipolar stepper motor typically consists of two coils with a center tap, allowing for simpler control since current can flow in one direction through each coil. In contrast, bipolar stepper motors have two coils without a center tap, requiring more complex control circuitry to reverse the current direction.
Microcontrollers can control stepper motors in two main modes: full-step and half-step. In full-step mode, the motor is driven by energizing one coil at a time, resulting in a step size equal to the motor's step angle. Half-step mode alternates between energizing one coil and both coils together, effectively halving the step size and allowing for smoother motion and improved resolution.
To implement stepper motor control, a microcontroller can be programmed to send signals to a driver circuit that interfaces with the motor. The driver circuit is responsible for managing the current flowing through the motor coils and can include components such as H-bridges or dedicated stepper motor driver ICs. The microcontroller's output pins are connected to the driver inputs, and the control logic can be implemented using simple timing loops or more sophisticated control algorithms depending on the application's requirements.
In summary, interfacing a stepper motor with a microcontroller involves understanding the motor's operating principles, selecting the appropriate type of motor, and implementing control strategies to achieve the desired performance. This knowledge is essential for designing effective systems that utilize stepper motors for precise motion control.stepper motor interfacing with microcontroller. Full step and half step stepper control. working and basics of stepper motor. 6 lead unipolar stepper motor tutorial, Bipolar Stepper Motor tutorial..
Stepper motors are widely used in various applications requiring precise control of angular position, speed, and acceleration. They are particularly useful in robotics, CNC machinery, and 3D printers due to their ability to divide a full rotation into a large number of steps. The interfacing of stepper motors with microcontrollers allows for the implementation of complex control algorithms that can enhance the performance of these motors.
The two primary types of stepper motors are unipolar and bipolar. A 6-lead unipolar stepper motor typically consists of two coils with a center tap, allowing for simpler control since current can flow in one direction through each coil. In contrast, bipolar stepper motors have two coils without a center tap, requiring more complex control circuitry to reverse the current direction.
Microcontrollers can control stepper motors in two main modes: full-step and half-step. In full-step mode, the motor is driven by energizing one coil at a time, resulting in a step size equal to the motor's step angle. Half-step mode alternates between energizing one coil and both coils together, effectively halving the step size and allowing for smoother motion and improved resolution.
To implement stepper motor control, a microcontroller can be programmed to send signals to a driver circuit that interfaces with the motor. The driver circuit is responsible for managing the current flowing through the motor coils and can include components such as H-bridges or dedicated stepper motor driver ICs. The microcontroller's output pins are connected to the driver inputs, and the control logic can be implemented using simple timing loops or more sophisticated control algorithms depending on the application's requirements.
In summary, interfacing a stepper motor with a microcontroller involves understanding the motor's operating principles, selecting the appropriate type of motor, and implementing control strategies to achieve the desired performance. This knowledge is essential for designing effective systems that utilize stepper motors for precise motion control.stepper motor interfacing with microcontroller. Full step and half step stepper control. working and basics of stepper motor. 6 lead unipolar stepper motor tutorial, Bipolar Stepper Motor tutorial..

Microcontroller Voltmeter / Ammeter with LCD
The rectifier bridge voltage is determined by the U2 element; refer to its datasheet for the maximum voltage specifications. The minimum voltage at this pin should not fall below approximately 9V, or 6.5V if low-dropout type U2 and U3 voltage...
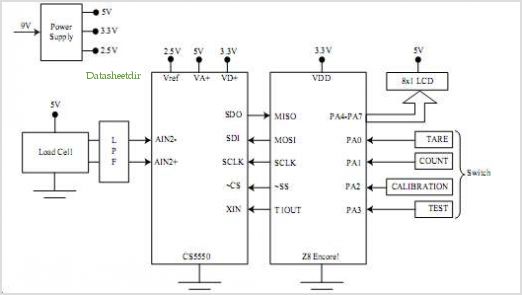
High Resolution Digital Weigh-scale Design Using Z8 Encore! ?® Microcontrollers
The SP6691 circuit is designed to provide a high output voltage using a lower voltage boost regulator by incorporating a charge pump circuit. This configuration can convert a standard 30V boost regulator into a 60V boost regulator if necessary. Testing...
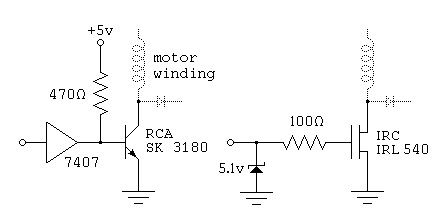
Stepper Motor Circuits
To control a stepper motor, each winding must be energized individually in a specific and timed sequence. This energization is carried out by a driver circuit, which acts as an amplifier. The timing is managed by an indexer circuit, while...
Stepper Motor Control Circuit
This circuit is not visually appealing nor easy to implement, requiring considerable effort. The stepper motor consists of two coils, necessitating the use of two LMD18245 chips to manage the current flow through these coils. It is noteworthy that motor...
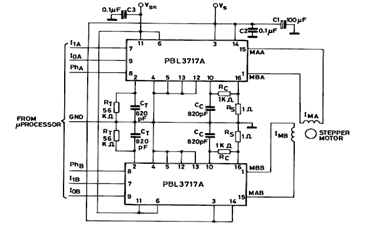
Two Phase Bipolar Stepper Motor Driver Circuit using PBL3717A
The diagram below illustrates a Two Phase Bipolar Stepper Motor Driver utilizing the PBL3717A. It depicts two PBL3717A integrated circuits (ICs) that control and drive two bipolar stepper motors.
The Two Phase Bipolar Stepper Motor Driver circuit is designed to efficiently...
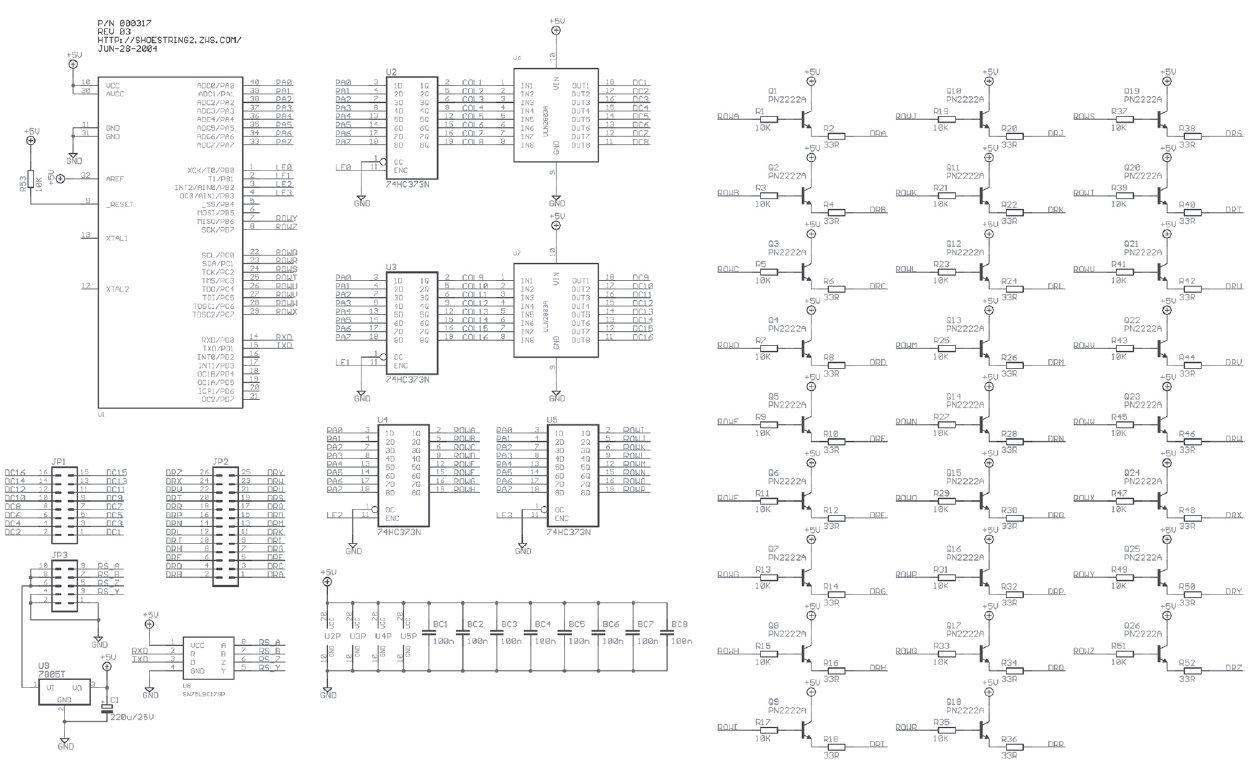
RS 422 Compatible Indicator
The design involves creating a circuit and programming for a stepper motor controller, developing a speed-controlled DC motor circuit for the propulsion system of the project, and designing a navigation system using a MEMS accelerometer circuit. This section deviates slightly...
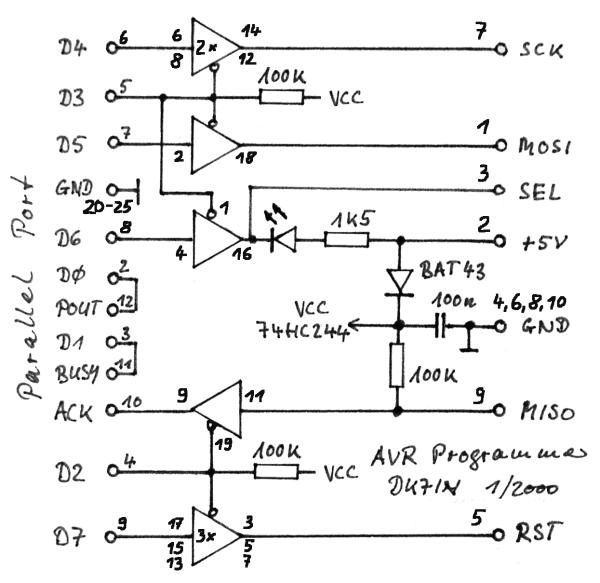
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
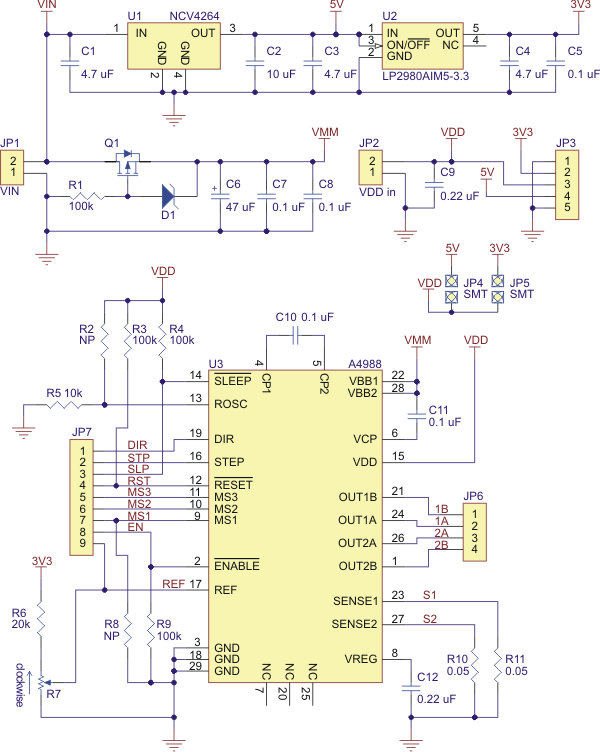
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
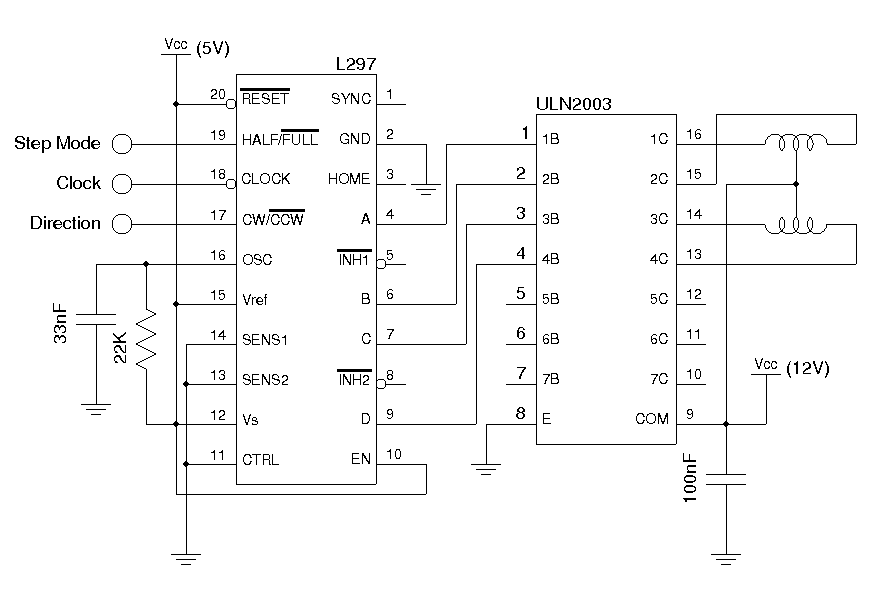
A Unipolar Stepper Motor Driver
The drive circuits for unipolar stepper motors are typically straightforward. In their simplest configuration, a transistor or MOSFET is employed to control each section of the windings. The control signal must be supplied programmatically to the four windings of the...