


A Unipolar Stepper Motor Driver
#stepper motor
#motor driver
#transistor
#MOSFET
#MCU
#unipolar
#windings
#control signal
#programming
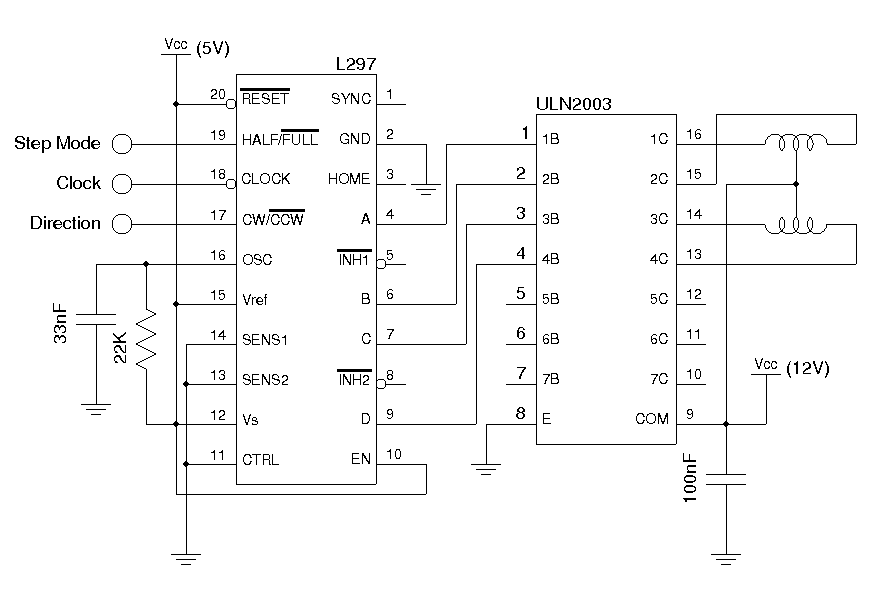
Description: The drive circuits for unipolar stepper motors are typically straightforward. In their simplest configuration, a transistor or MOSFET is employed to control each section of the windings. The control signal must be supplied programmatically to the four windings of the unipolar stepper motor via a microcontroller unit (MCU). The programming can become complex when managing the stepping mode (e.g., half-stepping/full-stepping), stepping direction, and rotation speed. The L297 integrated circuit is utilized to generate the necessary stepping signals for the stepper motor. The SENSE, CONTROL, INH, and VRef pins can be used together to achieve finer pulse width modulation (PWM) current control and faster decay; however, these features are rarely required in most applications. Consequently, these features have been omitted by connecting the CONTROL and SENSE pins to ground and setting VRef to Vcc, while the INH pins remain unused, simplifying the circuit. For testing purposes, an Arduino MCU board was employed, using digital pin 10 to generate the required clock signal. For ease of use, the step mode and direction pins are grounded (indicating full step and counterclockwise rotation), though these pins can also be controlled programmatically. The program itself is straightforward, requiring only the generation of a clock signal. The following code utilizes the bit-banging method to produce a clock signal at approximately 250 Hz:
```cpp
int PIN_CLK = 10;
void setup() {
pinMode(PIN_CLK, OUTPUT);
digitalWrite(PIN_CLK, LOW);
}
void loop() {
digitalWrite(PIN_CLK, HIGH);
delay(2);
digitalWrite(PIN_CLK, LOW);
delay(2);
}
```
The circuit for driving unipolar stepper motors is designed to achieve simplicity while still allowing for effective control of motor functions. The use of transistors or MOSFETs as switches for each winding ensures that the current through the coils can be controlled with minimal components. The L297 IC serves as the core of the control system, generating necessary signals for stepping and direction.
In a typical configuration, the four windings of the unipolar stepper motor are connected to the outputs of the L297. The SENSE pin, when employed, allows for current sensing, enabling the implementation of current limiting features through PWM control. However, in this simplified design, the SENSE and CONTROL pins are grounded, which means that the motor operates without additional complexity, providing sufficient performance for many applications.
The Arduino MCU acts as the control unit, generating a clock signal that dictates the stepping of the motor. The choice of digital pin 10 for output is common, and the program structure allows for easy modifications should the user wish to implement different stepping modes or directions later on. The bit-banging method used in the code provides a straightforward way to control the timing of the pulses sent to the motor, ensuring consistent operation.
The circuit can be easily expanded or modified, allowing for additional features such as microstepping or more complex control algorithms if needed in future applications. The design is versatile and can serve as a foundational platform for various robotics and automation projects involving unipolar stepper motors.The drive circuits for Unipolar stepper motors are usually very simple. In its simplest form, a transistor or MOSFET is used to drive each section of the windings. With this design, the control signal must be supplied programmatically to the four windings of the unipolar stepper motor via an MCU. The programming can become quite complex when the s tepping mode (e. g. half stepping/full stepping), stepping direction and rotation speed all need to be controlled. Basically, the L297 is used to generate the stepping signals needed by the stepper motor. The SENSE, CONTROL, INH and VRef pins can be used in tandem to provide finer PWM current control and faster decay. But in all but the most strict applications, these features are rarely needed. So I omitted these features by tying CONTROL and SENSE pins to the ground and set VRef to Vcc. The INH pins are left unused. This way the complexity of the circuit is greatly reduced. If you intend to use these pins, please refer to the following application note (AN470). To test this circuit, I used an Arduino MCU board and used digital pin 10 to generate the required clock signal.
For simplicity, the step mode pin and the direction pin are grounded (full step, counter clockwise) as seen in the picture below, but these two pins can also be controlled programmatically. The actual program is very simple, all we needed to do is to provide a clock signal. The following code used the bit-banging method to generate the clock signal at roughly 250 Hz. int PIN_CLK = 10; void setup() { pinMode(PIN_CLK, OUTPUT); digitalWrite(PIN_CLK, LOW); } void loop() { digitalWrite(PIN_CLK, HIGH); delay(2); digitalWrite(PIN_CLK, LOW); delay(2); }
```cpp
int PIN_CLK = 10;
void setup() {
pinMode(PIN_CLK, OUTPUT);
digitalWrite(PIN_CLK, LOW);
}
void loop() {
digitalWrite(PIN_CLK, HIGH);
delay(2);
digitalWrite(PIN_CLK, LOW);
delay(2);
}
```
The circuit for driving unipolar stepper motors is designed to achieve simplicity while still allowing for effective control of motor functions. The use of transistors or MOSFETs as switches for each winding ensures that the current through the coils can be controlled with minimal components. The L297 IC serves as the core of the control system, generating necessary signals for stepping and direction.
In a typical configuration, the four windings of the unipolar stepper motor are connected to the outputs of the L297. The SENSE pin, when employed, allows for current sensing, enabling the implementation of current limiting features through PWM control. However, in this simplified design, the SENSE and CONTROL pins are grounded, which means that the motor operates without additional complexity, providing sufficient performance for many applications.
The Arduino MCU acts as the control unit, generating a clock signal that dictates the stepping of the motor. The choice of digital pin 10 for output is common, and the program structure allows for easy modifications should the user wish to implement different stepping modes or directions later on. The bit-banging method used in the code provides a straightforward way to control the timing of the pulses sent to the motor, ensuring consistent operation.
The circuit can be easily expanded or modified, allowing for additional features such as microstepping or more complex control algorithms if needed in future applications. The design is versatile and can serve as a foundational platform for various robotics and automation projects involving unipolar stepper motors.The drive circuits for Unipolar stepper motors are usually very simple. In its simplest form, a transistor or MOSFET is used to drive each section of the windings. With this design, the control signal must be supplied programmatically to the four windings of the unipolar stepper motor via an MCU. The programming can become quite complex when the s tepping mode (e. g. half stepping/full stepping), stepping direction and rotation speed all need to be controlled. Basically, the L297 is used to generate the stepping signals needed by the stepper motor. The SENSE, CONTROL, INH and VRef pins can be used in tandem to provide finer PWM current control and faster decay. But in all but the most strict applications, these features are rarely needed. So I omitted these features by tying CONTROL and SENSE pins to the ground and set VRef to Vcc. The INH pins are left unused. This way the complexity of the circuit is greatly reduced. If you intend to use these pins, please refer to the following application note (AN470). To test this circuit, I used an Arduino MCU board and used digital pin 10 to generate the required clock signal.
For simplicity, the step mode pin and the direction pin are grounded (full step, counter clockwise) as seen in the picture below, but these two pins can also be controlled programmatically. The actual program is very simple, all we needed to do is to provide a clock signal. The following code used the bit-banging method to generate the clock signal at roughly 250 Hz. int PIN_CLK = 10; void setup() { pinMode(PIN_CLK, OUTPUT); digitalWrite(PIN_CLK, LOW); } void loop() { digitalWrite(PIN_CLK, HIGH); delay(2); digitalWrite(PIN_CLK, LOW); delay(2); }
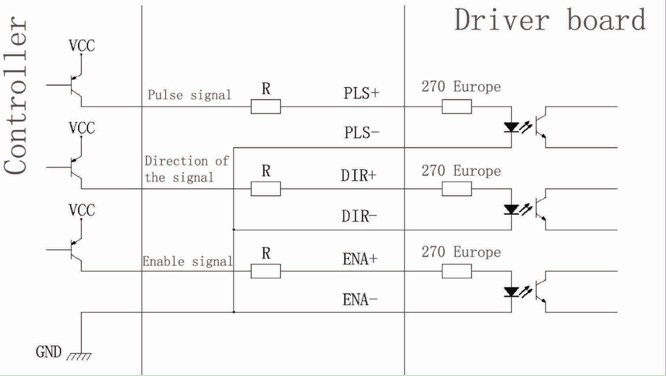
TB6600 5A Single Axis 5A CNC Stepper Driver For CNC Milling Machine DIY Max 50V
This is a two-phase hybrid stepping motor with a dynamic voltage range of 12 to 48V and a maximum current rating of less than 5A. The motor has an outer diameter ranging from 35 to 86 mm. The drive employs...
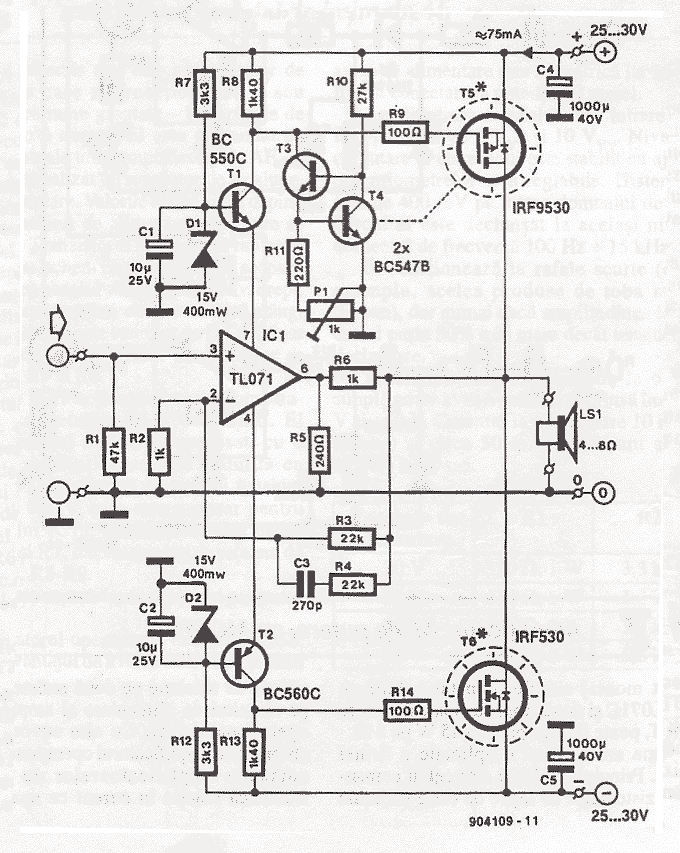
70 Watt MOSFET Audio Amplifier
This simple power MOSFET audio amplifier circuit utilizes a TL071C operational amplifier and two MOSFETs (IRF9530 and IRF530), capable of delivering up to 45 Watts to an 8-ohm speaker. The schematic is based on a Siliconix application and incorporates variations...

Music Driven Motor Schematic
Music Driven Motor Schematic. The geared motor drives the stem of a dancing flower to the beat of music.
The music-driven motor schematic involves a geared motor that is activated in response to sound signals, specifically music. This design typically incorporates...
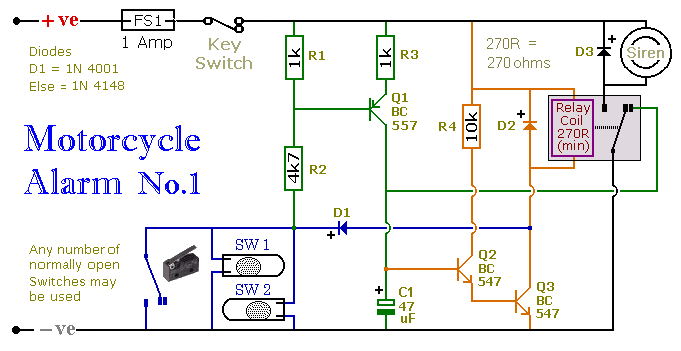
A Transistor Based Motorcycle Alarm circuit
This circuit includes a timed output and an automatic reset feature. It can be manually operated using a key switch or a concealed switch. By incorporating an external relay, the circuit will automatically engage or immobilize the machine each time...
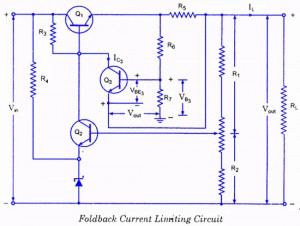
Controlled Transistor Series Regulator With Overload and Short-Circuit Protection
If the load resistance (RL) is reduced or the load terminals are accidentally shorted, a very large load current will flow, potentially damaging the pass transistor (Q1), diode, or other components. Fuse protection may not be sufficient, as the transistor...
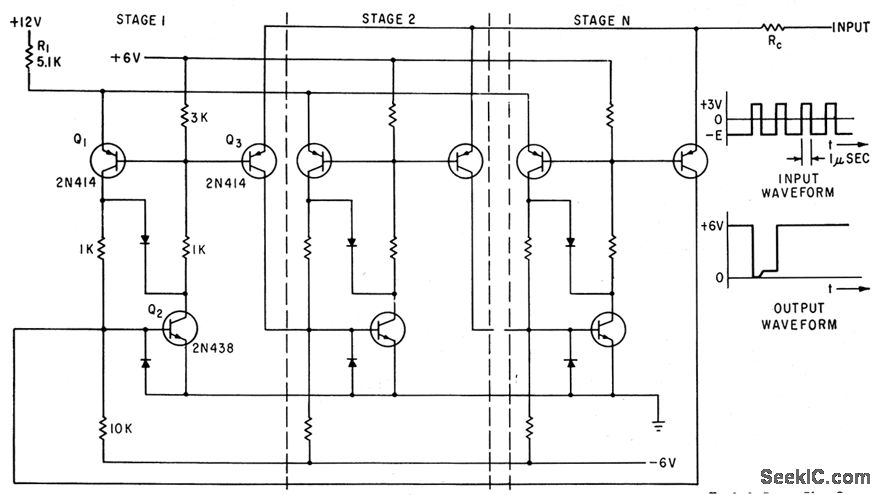
TRANSISTORIZED THYRATRON RING COUNTER
Each bistable circuit comprises two oppositely-symmetrical germanium transistors, two diodes, and four resistors. An additional transistor, Q, facilitates the transition of the conducting state to the next position when actuated by a transfer pulse. The absence of capacitors allows for...
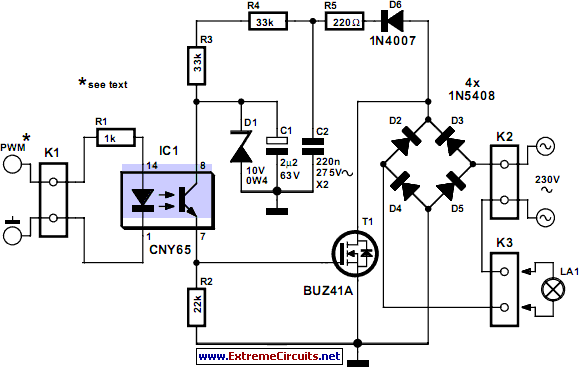
Dimmer With A MOSFET
This circuit demonstrates that dimmers designed for mains voltage do not necessarily require a triac. Instead, a MOSFET (BUZ41A, 500 V/4.5 A) is utilized within a diode bridge to manage the voltage across an incandescent bulb using pulse-width modulation (PWM)....
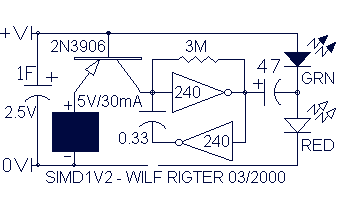
Wilf Rigter`s SIMD1 V2
In the never-ending quest for simplicity, even one extra diode is a price I loathe to pay. To avoid using extra components, it struck me that the two diodes in SIMD1 V1 were connected like the two junctions in one...
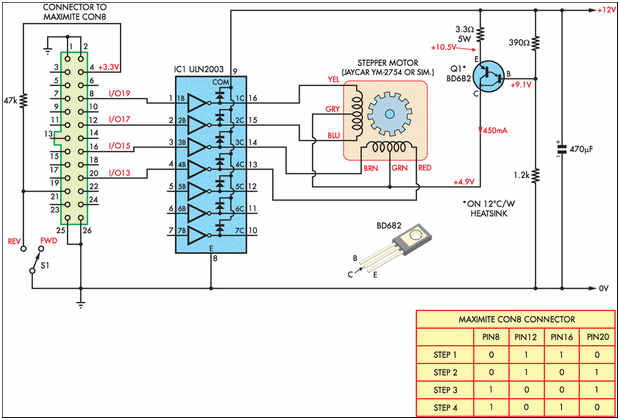
Rotate a stepper motor using a computer
Designing and implementing this circuit was an exciting endeavor. The design of the interface involved learning how to control a device from a computer. A parallel port cable was utilized for this purpose, enabling instant control of the stepper motor....