


The brake a little dynamic braking circuit
#braking circuit
#dynamic braking
#motor shutdown
#jog control
#electrical braking
#motor driver
#power electronics
#control system
#industrial automation
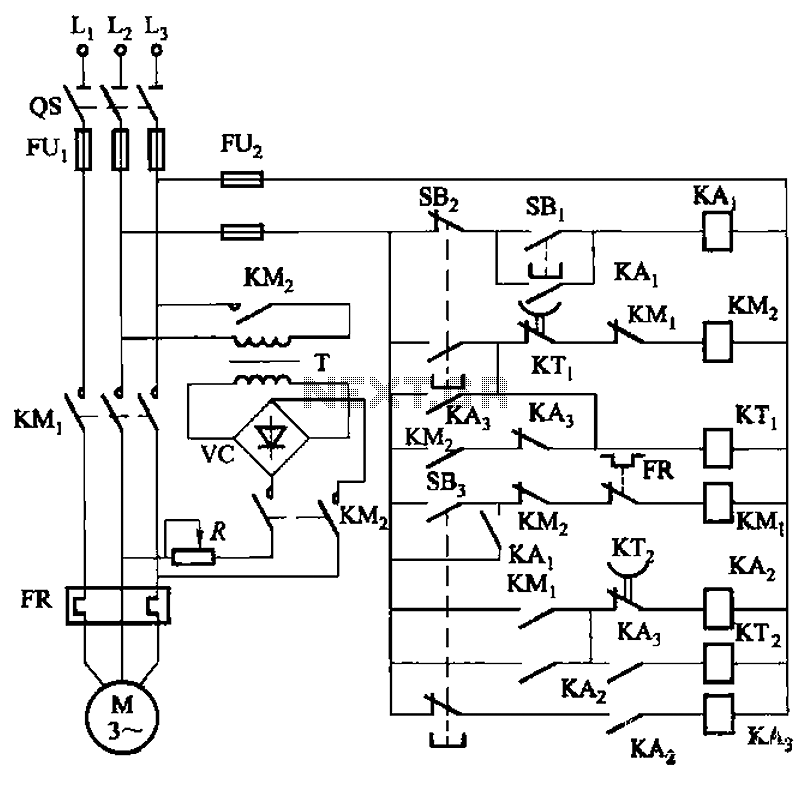
Description: The circuit depicted in Figure 3-143 demonstrates a braking mechanism for a motor that operates effectively during normal shutdown and jog operations. The circuit includes several components, such as the start button (SBz), stop button (SBz), and jog button (SB3). The normal braking duration is determined by the relay KTi, which can be adjusted between 3 to 4 seconds. During jog control, if the time interval between jogs is less than twice the tuning time of relay KTz (adjustable between 2 to 3 seconds), the normally closed contact will remain engaged. When the SB3 jog button is pressed, the circuit opens the brake; if the interval exceeds twice the jog tuning time or the jog operation ends, the normally closed contacts of KTz will disconnect the timer, causing the relay KAz and KA3 to lose power. Consequently, the normally open contact of KA3 will disconnect, leading to the deactivation of contactor KM2 and the cessation of braking.
The circuit operates through a combination of relays and buttons that control the braking process effectively. The start button (SBz) initiates the motor operation, while the stop button (SBz) halts it. The jog button (SB3) allows for momentary operation of the motor, facilitating precise control during tasks that require brief bursts of movement.
The adjustable relay KTi defines the normal braking time, ensuring that the motor comes to a stop within a predetermined duration, enhancing safety and operational efficiency. The timing adjustments for both KTi and KTz provide flexibility in the braking response, accommodating different operational requirements based on load conditions or specific application needs.
In the jog mode, the circuit exhibits a sophisticated control mechanism. If the jog operation is performed with intervals shorter than the specified tuning time of KTz, the braking system remains engaged, allowing for rapid successive jogs without fully disengaging the brake. This feature is particularly useful in applications where precise positioning or repetitive movements are required.
Conversely, if the interval exceeds the set threshold, the system automatically transitions to a safe state by disconnecting the relay KAz and KA3, which in turn disengages the contactor KM2. This ensures that the motor is completely released from the braking action, preventing potential mechanical stress or overheating from prolonged braking engagement.
Overall, the circuit design provides a robust solution for motor control, effectively balancing between operational flexibility and safety through adjustable timing parameters and strategic relay configurations. Circuit shown in Figure 3-143. The line not only make the braking effect of the motor is in the normal shutdown, and jog through the process and has a good braking effect. Figu re, SBz the start button, SBz the stop button, SB3 jog button. Normal braking time by the time the decision relay KTi (3-4s, adjustable). When the jog control, if the time interval of less than two jog KTz tuning time (2 ~ 3s, adjustable), the delay does not turn off normally closed contact, then press the SB3 is jogging, pine SB3 that is open to the brake; if the interval is greater than twice jog KT2 tuning time, or jog end, KTz normally closed contacts disconnect timer, relay KAz, KA3 has lost power release, KA3 normally open contact disconnect and contactor KM2 missing, and released end braking.
The circuit operates through a combination of relays and buttons that control the braking process effectively. The start button (SBz) initiates the motor operation, while the stop button (SBz) halts it. The jog button (SB3) allows for momentary operation of the motor, facilitating precise control during tasks that require brief bursts of movement.
The adjustable relay KTi defines the normal braking time, ensuring that the motor comes to a stop within a predetermined duration, enhancing safety and operational efficiency. The timing adjustments for both KTi and KTz provide flexibility in the braking response, accommodating different operational requirements based on load conditions or specific application needs.
In the jog mode, the circuit exhibits a sophisticated control mechanism. If the jog operation is performed with intervals shorter than the specified tuning time of KTz, the braking system remains engaged, allowing for rapid successive jogs without fully disengaging the brake. This feature is particularly useful in applications where precise positioning or repetitive movements are required.
Conversely, if the interval exceeds the set threshold, the system automatically transitions to a safe state by disconnecting the relay KAz and KA3, which in turn disengages the contactor KM2. This ensures that the motor is completely released from the braking action, preventing potential mechanical stress or overheating from prolonged braking engagement.
Overall, the circuit design provides a robust solution for motor control, effectively balancing between operational flexibility and safety through adjustable timing parameters and strategic relay configurations. Circuit shown in Figure 3-143. The line not only make the braking effect of the motor is in the normal shutdown, and jog through the process and has a good braking effect. Figu re, SBz the start button, SBz the stop button, SB3 jog button. Normal braking time by the time the decision relay KTi (3-4s, adjustable). When the jog control, if the time interval of less than two jog KTz tuning time (2 ~ 3s, adjustable), the delay does not turn off normally closed contact, then press the SB3 is jogging, pine SB3 that is open to the brake; if the interval is greater than twice jog KT2 tuning time, or jog end, KTz normally closed contacts disconnect timer, relay KAz, KA3 has lost power release, KA3 normally open contact disconnect and contactor KM2 missing, and released end braking.

Electrical_Subsystem
The following data and mapping pertain to the 2-D shift mapping algorithm that the controller will utilize to determine when and if a shift should occur. The solid lines on the graph indicate up-shift boundaries, while the dashed lines represent...
Control System for Cold Atom Experiments
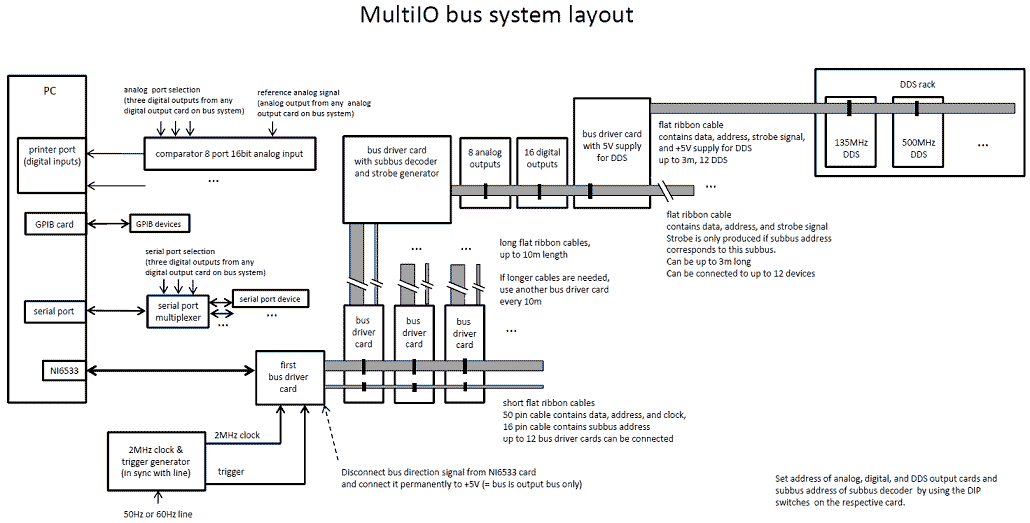
We have developed a powerful yet inexpensive and easy to construct experiment control system. The construction of the system together with the control software is described here. All circuits and software are free to download and use for nonprofit. The...
Big Trak Motor Driver Schematic
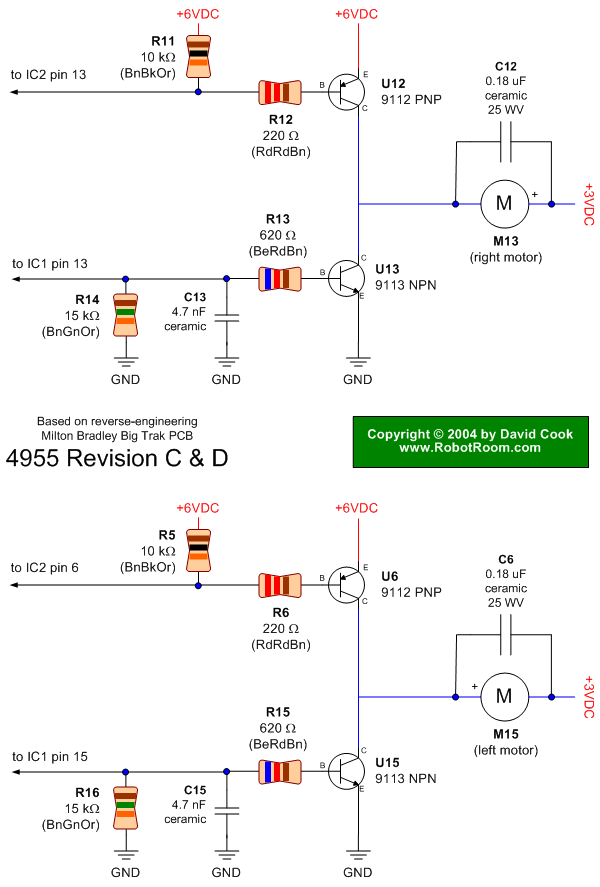
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...
One-way operation of a dynamic braking circuit
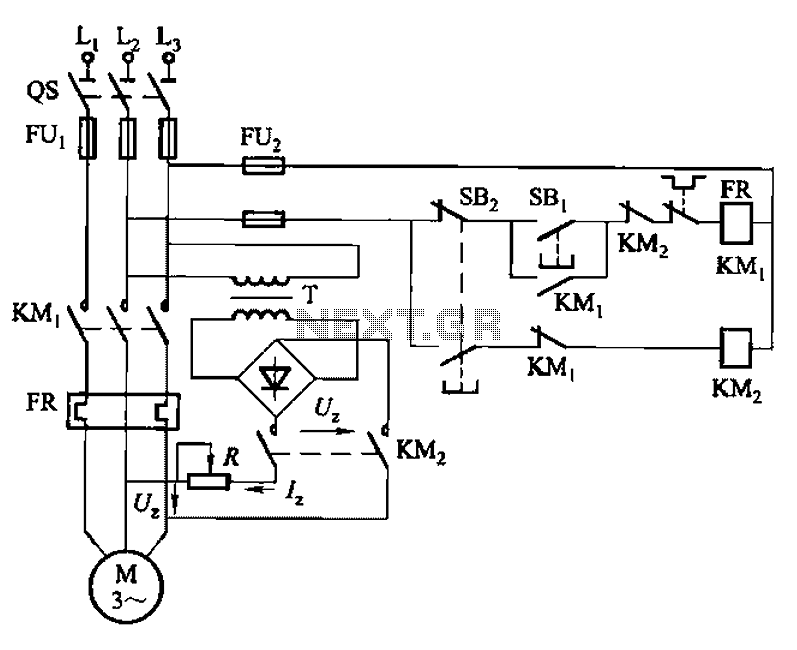
The 3133 circuit is illustrated in Figure 3-133. It features dynamic braking controlled manually via buttons in three separate lines. In part (a) of the figure, the dynamic braking DC power supply is depicted with a step-down transformer and a...
Six-way operation of the dynamic braking circuit
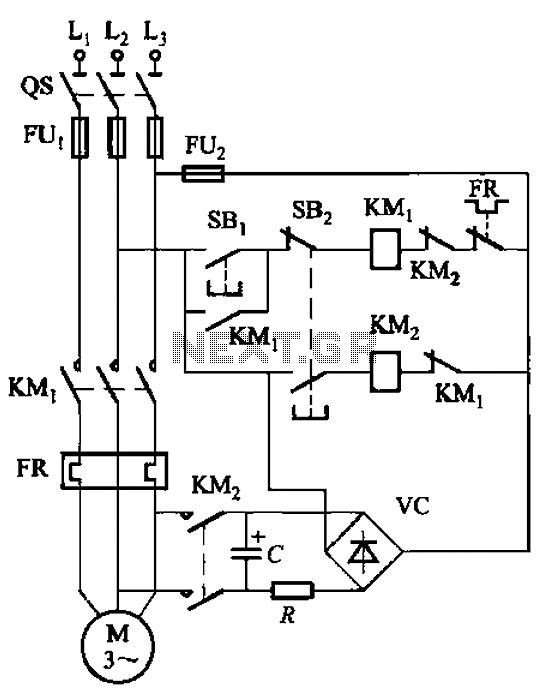
The circuit depicted in Figure 3-138 utilizes the principle of energy storage through capacitor discharge to achieve braking. The capacitance (C) and resistance (R) parameters are determined based on the size of the motor power. The capacitance (C) is typically...
Forward and reverse operation of the dynamic braking circuit 2
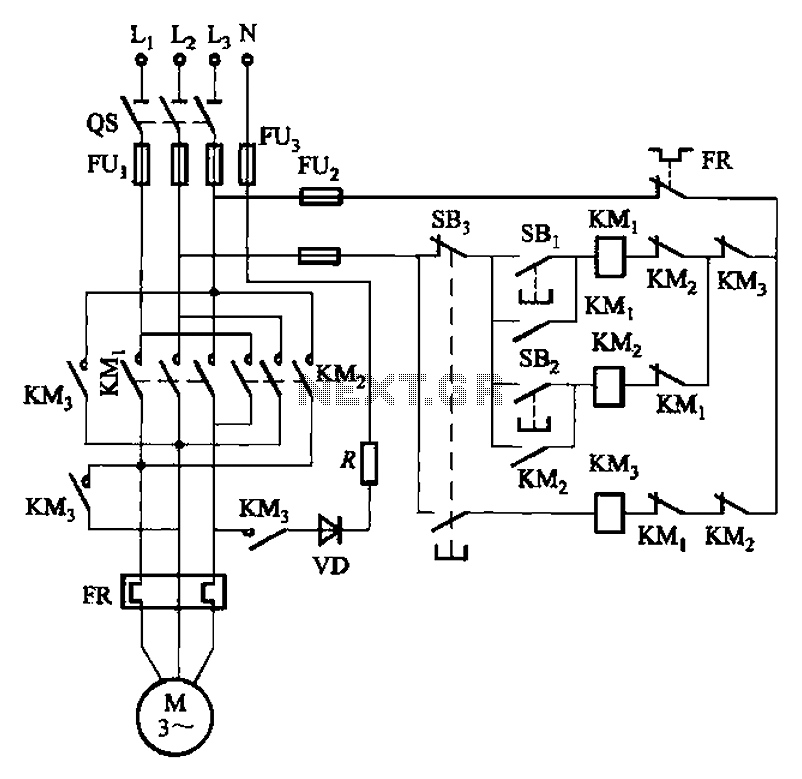
The circuit illustrated in Figure 3-145 employs a rectifier diode brake for neutral grounding in a three-phase, four-wire power supply system.
This circuit design incorporates a rectifier diode brake, which plays a crucial role in ensuring the safety and reliability of...

Music Driven Motor Schematic
Music Driven Motor Schematic. The geared motor drives the stem of a dancing flower to the beat of music.
The music-driven motor schematic involves a geared motor that is activated in response to sound signals, specifically music. This design typically incorporates...
Jog shuttle function with automatic control circuit
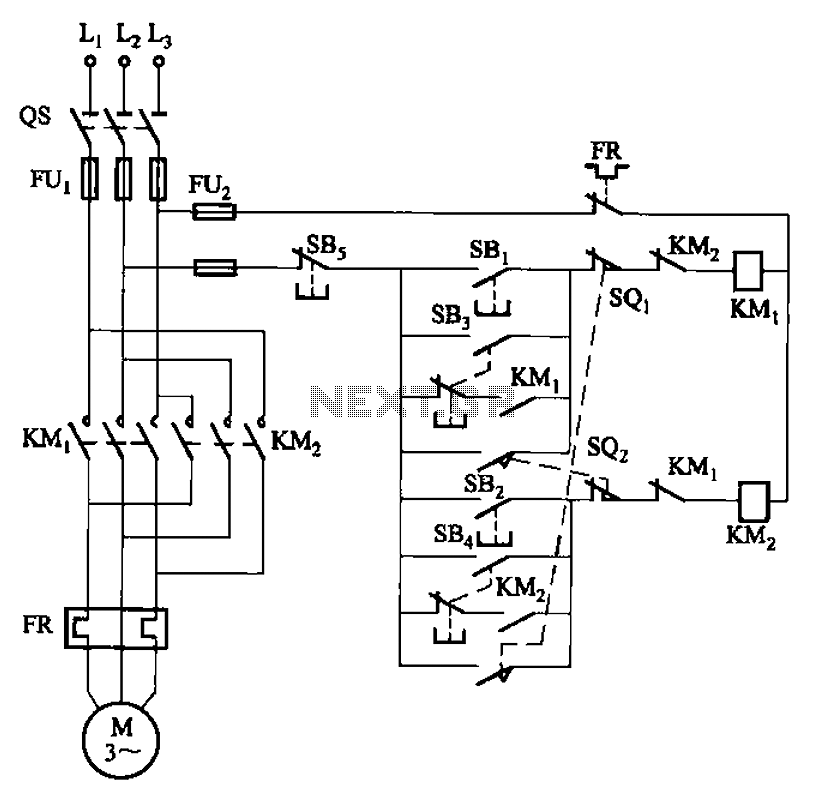
The circuit depicted in Figure 3-27 features a jog function that allows for precise adjustments of moving components. In the figure, SB3 and SB4 represent the forward jog and reverse jog buttons, respectively. When the SB3 button is pressed, the...
Seven one-way operation of the dynamic braking circuit
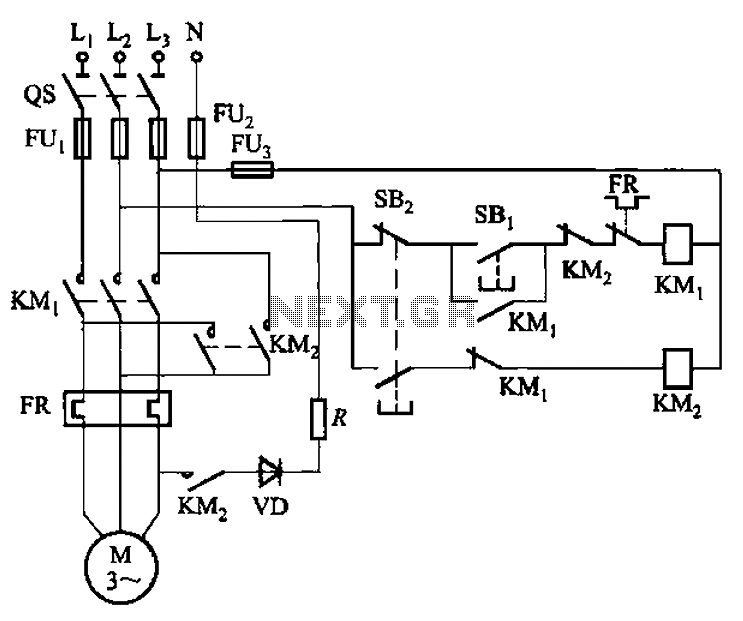
The circuit shown in Figure 3-139 utilizes a rectifier diode brake for neutral grounding in a three-phase, four-wire power supply system.
The circuit employs a rectifier diode configuration to achieve effective neutral grounding, which is crucial for maintaining system stability and...