


One-way operation of a dynamic braking circuit
#dynamic braking
#DC power supply
#manual control
#button control
#motor
#braking circuit
#three lines
#3133 circuit
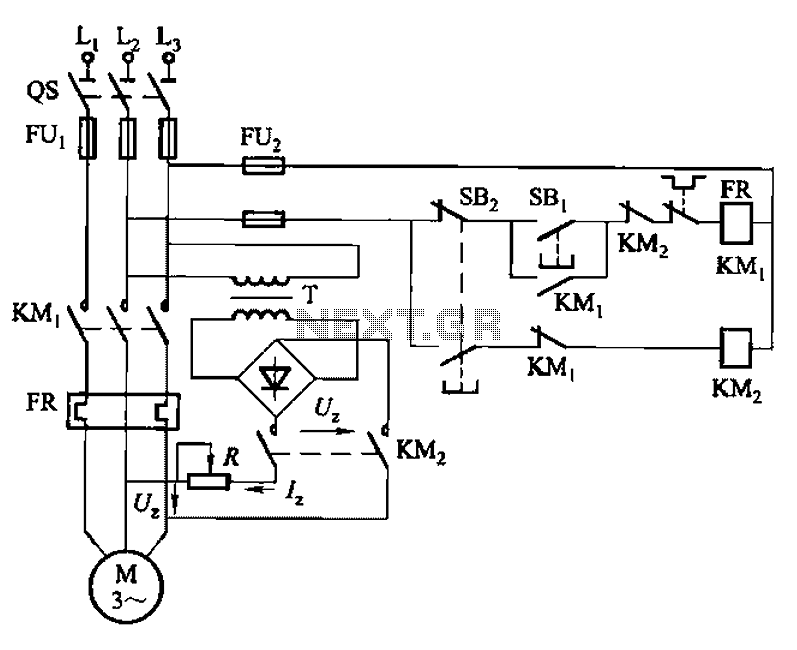
Description: The 3133 circuit is illustrated in Figure 3-133. It features dynamic braking controlled manually via buttons in three separate lines. In part (a) of the figure, the dynamic braking DC power supply is depicted with a step-down transformer and a rectifier bridge. Part (c) shows that the current for dynamic braking is obtained through a diode, indicating that while both methods function similarly, the first method offers a superior braking effect. This circuit is typically utilized in applications requiring braking for motors up to 7.5 kW. For motors with larger power ratings, a three-phase rectifier circuit should be employed in conjunction with the DC power braking system.
The 3133 circuit design incorporates a dynamic braking system that is essential for applications where rapid deceleration of motors is required. The circuit operates by converting the kinetic energy of the motor into electrical energy, which is then dissipated as heat in a resistive load.
The dynamic braking system is controlled manually through a set of buttons, allowing operators to engage or disengage the braking process as needed. This feature is particularly useful in scenarios where immediate stopping is necessary, such as in conveyor systems or industrial machinery.
The power supply for the dynamic braking circuit is derived from a step-down transformer, which reduces the AC voltage to a level suitable for the rectification process. The rectifier bridge converts the AC voltage to DC, providing a stable power source for the braking system. The inclusion of diodes in the circuit ensures that current flows in the correct direction, allowing for effective energy conversion during the braking phase.
Furthermore, the circuit's design is optimized for motors rated up to 7.5 kW, making it a reliable choice for medium-sized applications. For larger motors, it is advisable to implement a three-phase rectifier circuit to handle the increased power demands efficiently. This adaptation ensures that the braking system remains effective and responsive, even under high-load conditions.
Overall, the 3133 circuit exemplifies a practical approach to dynamic braking in electric motor applications, combining manual control with robust electrical components to achieve effective deceleration and energy management.3133 circuit shown in FIG. Figure 3-133 (a), dynamic braking (b), (c) the three lines by manually (button) control. Wherein FIG. (A), (b) the dynamic braking DC power supply wi th step-down transformer, rectifier bridge rectifier obtained, FIG. (C) The current power dynamic braking win by a diode obtained similar they work, but the former than the latter braking effect is good. This circuit, commonly used in the following 7. 5kW, braking demanding situations. For larger power motors, brake should be used with DC power three-phase rectifier circuit.
The 3133 circuit design incorporates a dynamic braking system that is essential for applications where rapid deceleration of motors is required. The circuit operates by converting the kinetic energy of the motor into electrical energy, which is then dissipated as heat in a resistive load.
The dynamic braking system is controlled manually through a set of buttons, allowing operators to engage or disengage the braking process as needed. This feature is particularly useful in scenarios where immediate stopping is necessary, such as in conveyor systems or industrial machinery.
The power supply for the dynamic braking circuit is derived from a step-down transformer, which reduces the AC voltage to a level suitable for the rectification process. The rectifier bridge converts the AC voltage to DC, providing a stable power source for the braking system. The inclusion of diodes in the circuit ensures that current flows in the correct direction, allowing for effective energy conversion during the braking phase.
Furthermore, the circuit's design is optimized for motors rated up to 7.5 kW, making it a reliable choice for medium-sized applications. For larger motors, it is advisable to implement a three-phase rectifier circuit to handle the increased power demands efficiently. This adaptation ensures that the braking system remains effective and responsive, even under high-load conditions.
Overall, the 3133 circuit exemplifies a practical approach to dynamic braking in electric motor applications, combining manual control with robust electrical components to achieve effective deceleration and energy management.3133 circuit shown in FIG. Figure 3-133 (a), dynamic braking (b), (c) the three lines by manually (button) control. Wherein FIG. (A), (b) the dynamic braking DC power supply wi th step-down transformer, rectifier bridge rectifier obtained, FIG. (C) The current power dynamic braking win by a diode obtained similar they work, but the former than the latter braking effect is good. This circuit, commonly used in the following 7. 5kW, braking demanding situations. For larger power motors, brake should be used with DC power three-phase rectifier circuit.
motor switch led circuit
The strategy involves assembling the circuit in stages, testing each component as it is integrated. Once all connections are established and can be controlled or read correctly by the computer, the main program can be developed with assurance that all...
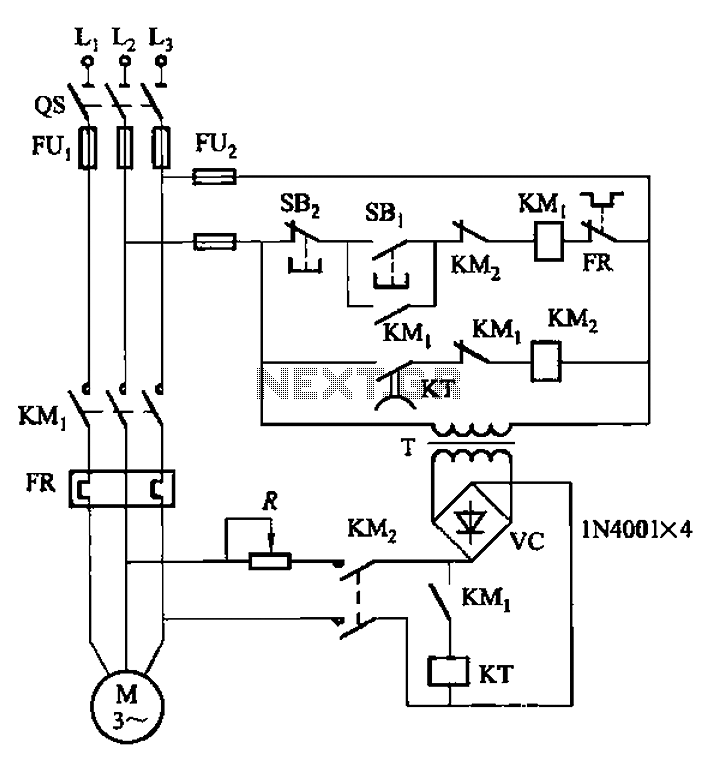
Way operation dynamic braking circuit 2
The circuit depicted in Figure 3-134 utilizes an automatic control braking mechanism, which is an enhancement based on the time relay system shown in Figure 3-133 (a). The KT control allows for an adjustable braking time of 2 to 4...
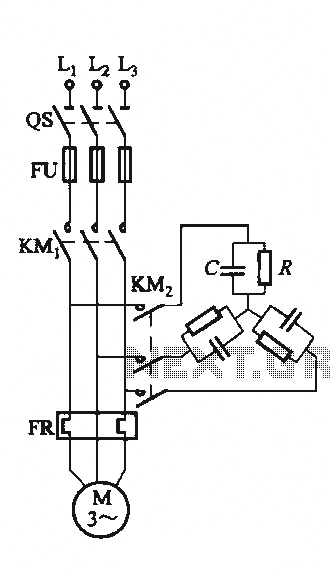
Single-speed motor excitation from the electrical braking circuit
The circuit illustrated in Figure 3-151 consists of capacitor banks arranged in a specific configuration. Figure 3-151 (a) depicts capacitor banks connected in a shaped configuration, which is suitable for shaped or Y-connected motors. Figure 3-151 (b) shows Y-connected capacitor...
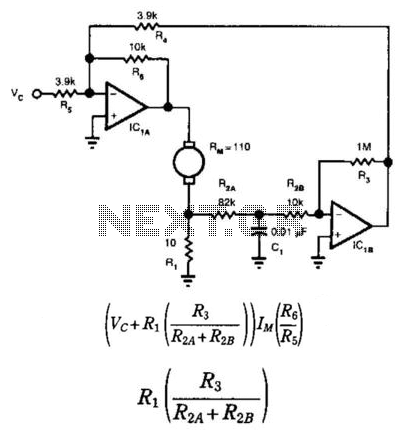
Tachometerless Motor Speed Control
This circuit provides bidirectional speed regulation for small motors and does not require a tachometer. The voltage applied to the motor's windings, which is determined by summing amplifier IC1A, is expressed as a function of the command voltage (Vc) and...
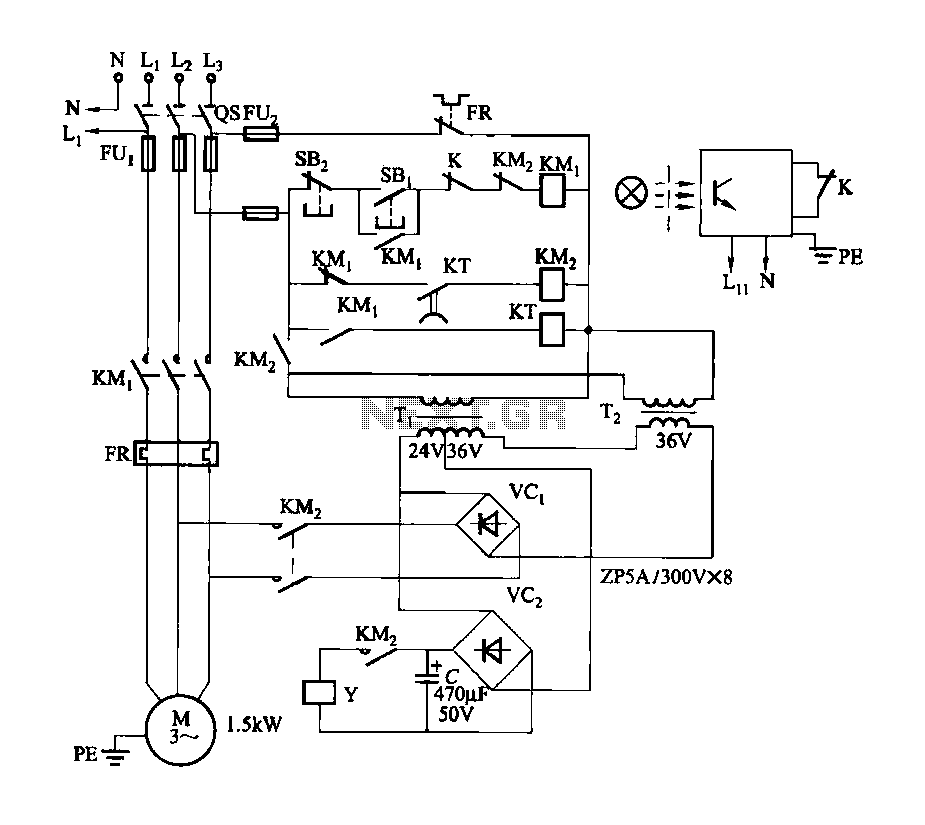
Ten-way operation of the dynamic braking circuit
Figure 3-142 illustrates the reel control circuit. The coiler is utilized for winding plastic banding, such as grafting tape, onto a plastic reel. To prevent the plastic tape from being pulled off due to its low tensile strength, the motor...
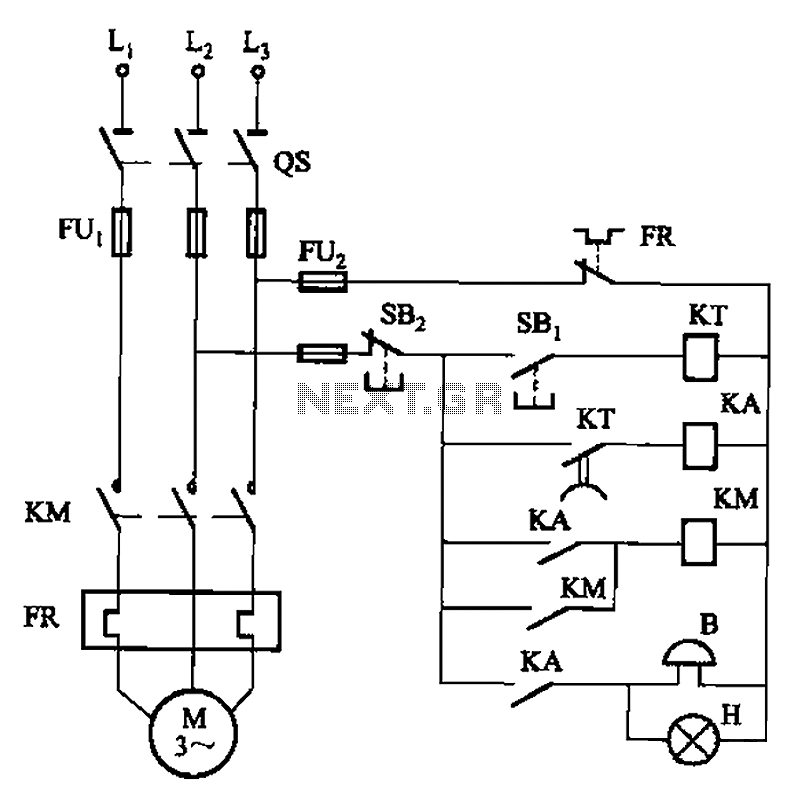
It can send a signal to start forward rotation start circuit
The circuit shown in Figure 3-21 is designed to produce a motor startup sound and a light signal indicating the completion of the startup process, after which the signal ceases. This circuit is tailored to control the motor for a...
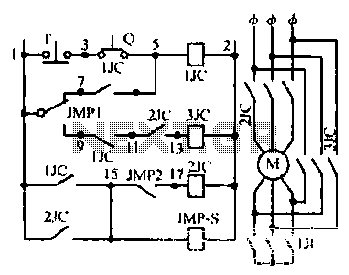
Motor Y starting circuit shape
Motor windings are set to connect in a Y configuration while the load is active. The system includes an electric suction mechanism, and the motor is designed to operate under specific conditions. It is rated for 600 revolutions per minute...
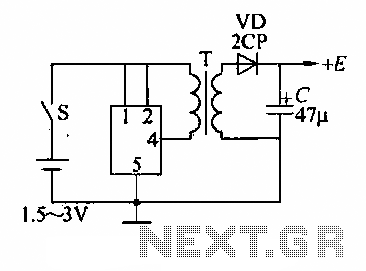
A DC power supply boost circuit
A DC booster circuit is illustrated in the figure, which represents a step-up transformer circuit diagram. The step-up transformer (T) can be utilized to power small transistor radios. The winding ratio can be adjusted to achieve the desired output voltage....
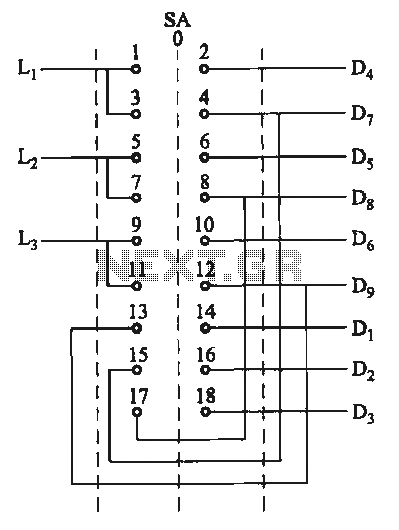
Switching two-speed motor control circuit
The motor switch control circuit depicted in the figure provides two speed settings for counter-steering, allowing for operation at two speeds in opposite directions.
The motor switch control circuit is designed to facilitate the operation of a motor at two distinct...