


Tachometerless Motor Speed Control
#motor
#speed control
#bidirectional
#tachometerless
#voltage regulation
#small motors
#PWM
#DC motor
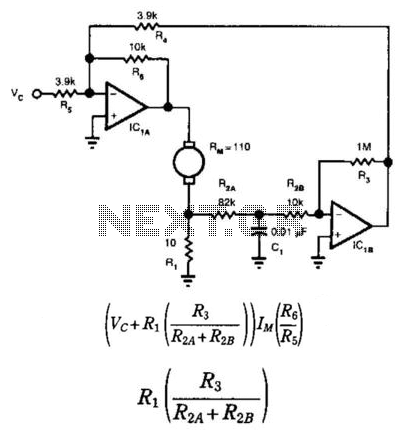
Description: This circuit provides bidirectional speed regulation for small motors and does not require a tachometer. The voltage applied to the motor's windings, which is determined by summing amplifier IC1A, is expressed as a function of the command voltage (Vc) and the motor current (IM). By setting the motor's winding resistance and brush resistance (RM) accordingly, the command voltage becomes proportional to the motor winding's counter electromotive force (emf). Capacitor CI offers compensation. The value of resistor R1 should be set to 5 to 10% of RM's value, which can typically be found in the motor's specification sheet.
This circuit is designed for effective speed control of small motors in applications where precise regulation is essential. The use of a summing amplifier (IC1A) allows for the integration of multiple input signals, thereby facilitating the desired control over the motor's operation. The command voltage (Vc) is the primary input that dictates the motor's speed, while the motor current (IM) provides feedback necessary for maintaining stability and performance.
The relationship between the command voltage and the motor's counter emf is crucial, as it ensures that the motor operates efficiently within its specified limits. By configuring the motor's winding resistance and brush resistance (RM), the circuit achieves a balance that allows the command voltage to effectively counteract the back emf generated during motor operation. This balance is essential for achieving the desired speed regulation without the need for additional sensing devices such as tachometers.
Capacitor CI plays a vital role in compensating for any variations in the motor's performance, which may arise due to changes in load or supply voltage. This compensation is necessary to maintain consistent operational characteristics and prevent oscillations that could lead to instability in motor speed.
Furthermore, the selection of resistor R1 is critical, as its value should be set to 5 to 10% of RM's value. This ratio ensures that the feedback loop remains responsive while providing adequate damping to avoid excessive overshoot or oscillation in the motor's speed. The RM value can typically be referenced from the motor's specification sheet, allowing for accurate and reliable circuit design.
Overall, this circuit design is well-suited for applications requiring precise control of small motors, providing a straightforward solution that eliminates the need for complex feedback systems while maintaining efficiency and performance. This provides bidirectional speed regulation for small motors and requires no tachometer. The voltage th at summing amplifier IC1A applies to the motor"s windings equals: where Vc is the command voltage and IM is the motor current. If you set the motor"s winding resistance and brush resistance (RM) equal to: the command voltage will be proportional to the motor winding"s counter emf.
CI provides compensation. Set Rl"s value so that it equals 5 to 10% of RM"s value. You can generally find RM"s value in a motor"s spec sheet.
This circuit is designed for effective speed control of small motors in applications where precise regulation is essential. The use of a summing amplifier (IC1A) allows for the integration of multiple input signals, thereby facilitating the desired control over the motor's operation. The command voltage (Vc) is the primary input that dictates the motor's speed, while the motor current (IM) provides feedback necessary for maintaining stability and performance.
The relationship between the command voltage and the motor's counter emf is crucial, as it ensures that the motor operates efficiently within its specified limits. By configuring the motor's winding resistance and brush resistance (RM), the circuit achieves a balance that allows the command voltage to effectively counteract the back emf generated during motor operation. This balance is essential for achieving the desired speed regulation without the need for additional sensing devices such as tachometers.
Capacitor CI plays a vital role in compensating for any variations in the motor's performance, which may arise due to changes in load or supply voltage. This compensation is necessary to maintain consistent operational characteristics and prevent oscillations that could lead to instability in motor speed.
Furthermore, the selection of resistor R1 is critical, as its value should be set to 5 to 10% of RM's value. This ratio ensures that the feedback loop remains responsive while providing adequate damping to avoid excessive overshoot or oscillation in the motor's speed. The RM value can typically be referenced from the motor's specification sheet, allowing for accurate and reliable circuit design.
Overall, this circuit design is well-suited for applications requiring precise control of small motors, providing a straightforward solution that eliminates the need for complex feedback systems while maintaining efficiency and performance. This provides bidirectional speed regulation for small motors and requires no tachometer. The voltage th at summing amplifier IC1A applies to the motor"s windings equals: where Vc is the command voltage and IM is the motor current. If you set the motor"s winding resistance and brush resistance (RM) equal to: the command voltage will be proportional to the motor winding"s counter emf.
CI provides compensation. Set Rl"s value so that it equals 5 to 10% of RM"s value. You can generally find RM"s value in a motor"s spec sheet.
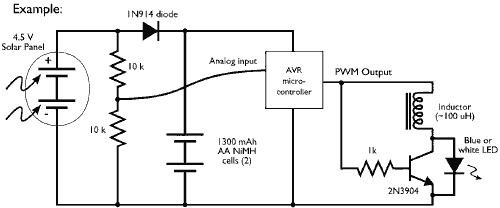
Microcontroller driving a Joule Thief circuit
This example demonstrates the PWM (pulse-width modulation) output of a microcontroller controlling a Joule Thief style voltage booster to power a white LED.
The circuit described utilizes a microcontroller to generate a PWM signal, which is an effective method for controlling...
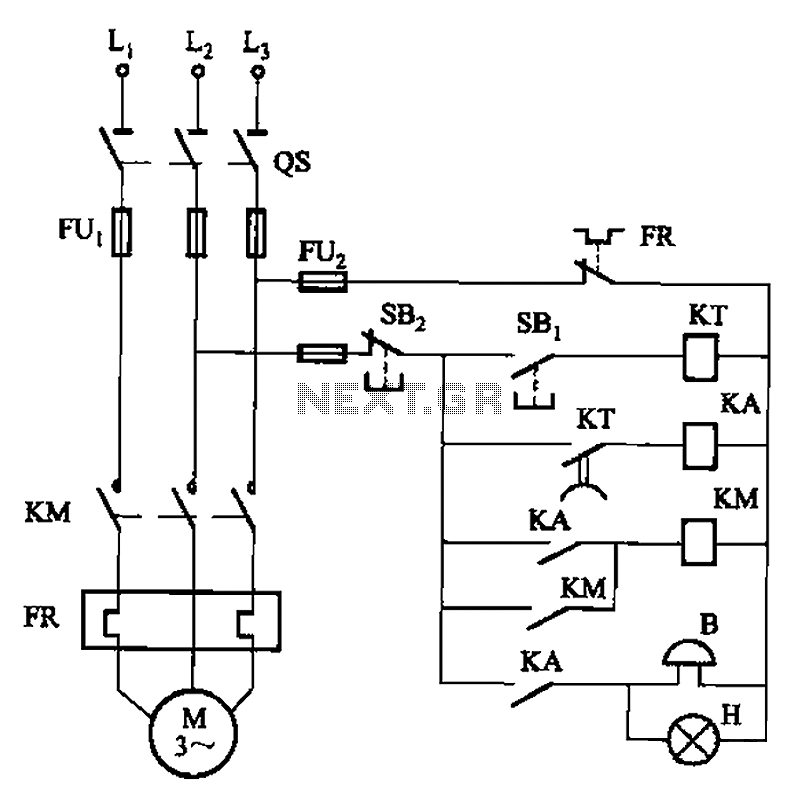
It can send a signal to start forward rotation start circuit
The circuit shown in Figure 3-21 is designed to produce a motor startup sound and a light signal indicating the completion of the startup process, after which the signal ceases. This circuit is tailored to control the motor for a...
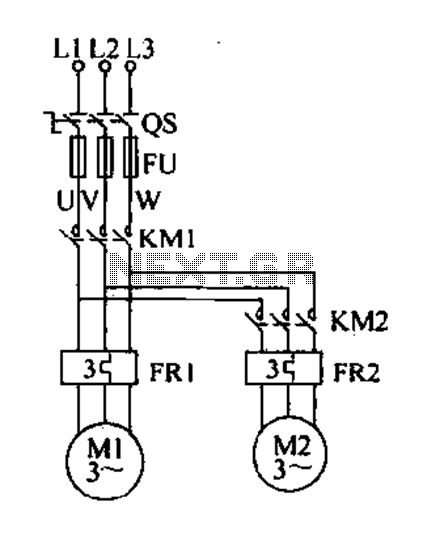
Delay starting a motor control circuit
Delay starting a motor control circuit
The motor control circuit designed for delayed activation incorporates a timing mechanism that ensures the motor does not start immediately upon receiving power. This is particularly useful in applications where a staggered startup is...
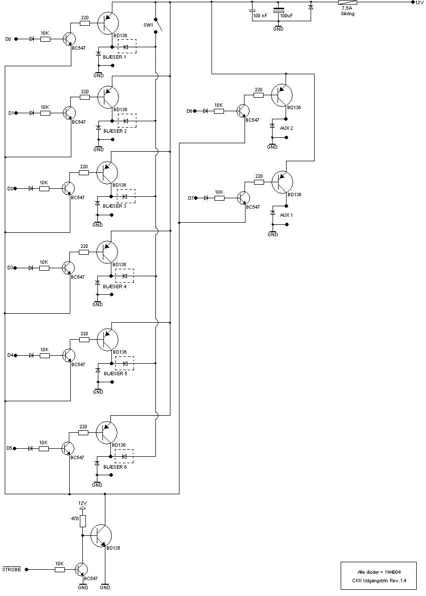
8 Channel software controlled fanbus with PWM
When discussing fan control, there are generally two methods: linear control and pulse-width modulation (PWM) control. Linear control is the most commonly used method, which involves reducing the voltage supplied to the fan. For a fan rated at 12 volts,...
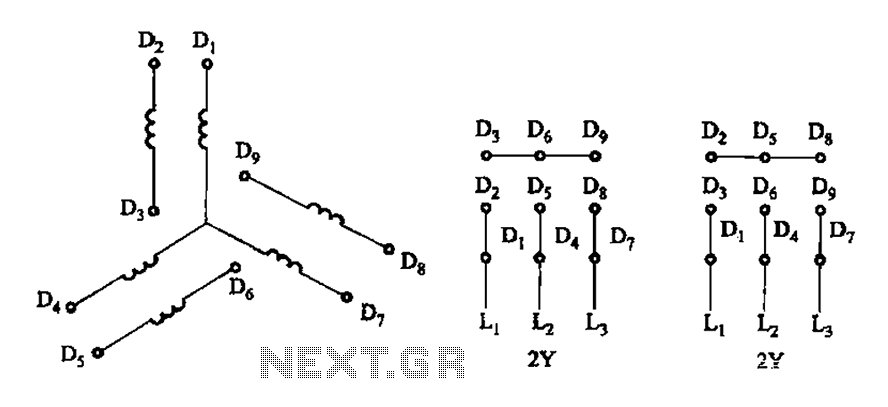
Two-speed motor stator winding 2Y-2Y connection
As illustrated in Figure 3-105, this diagram depicts the lead wiring configuration for a two-speed motor stator with a 2Y/2Y connection.
The two-speed motor stator wiring diagram is essential for understanding the configuration and operation of the motor. In this setup,...
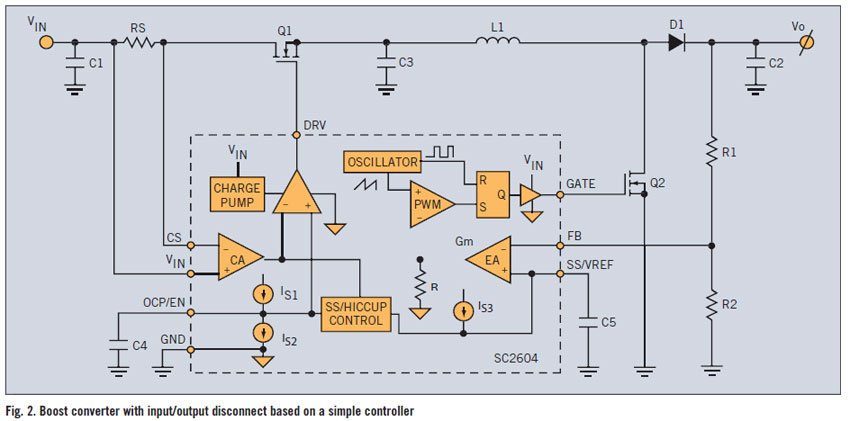
simple pwm boost converter io disconnect solves malfunctions
A PWM boost converter in a simple controller has a DC path from input VIN to VOUT, which is utilized for high-efficiency power conversion.
A PWM (Pulse Width Modulation) boost converter is an essential component in power electronics, designed to step...
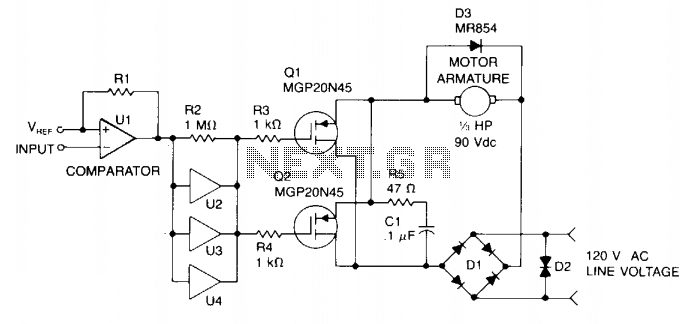
Pwm motor speed control
Speed control is achieved through pulse width modulation (PWM) of the gates of two MGP20N45 TMOS devices. Consequently, the motor speed is directly proportional to the pulse width of the incoming digital signal, which can be generated by a microprocessor...
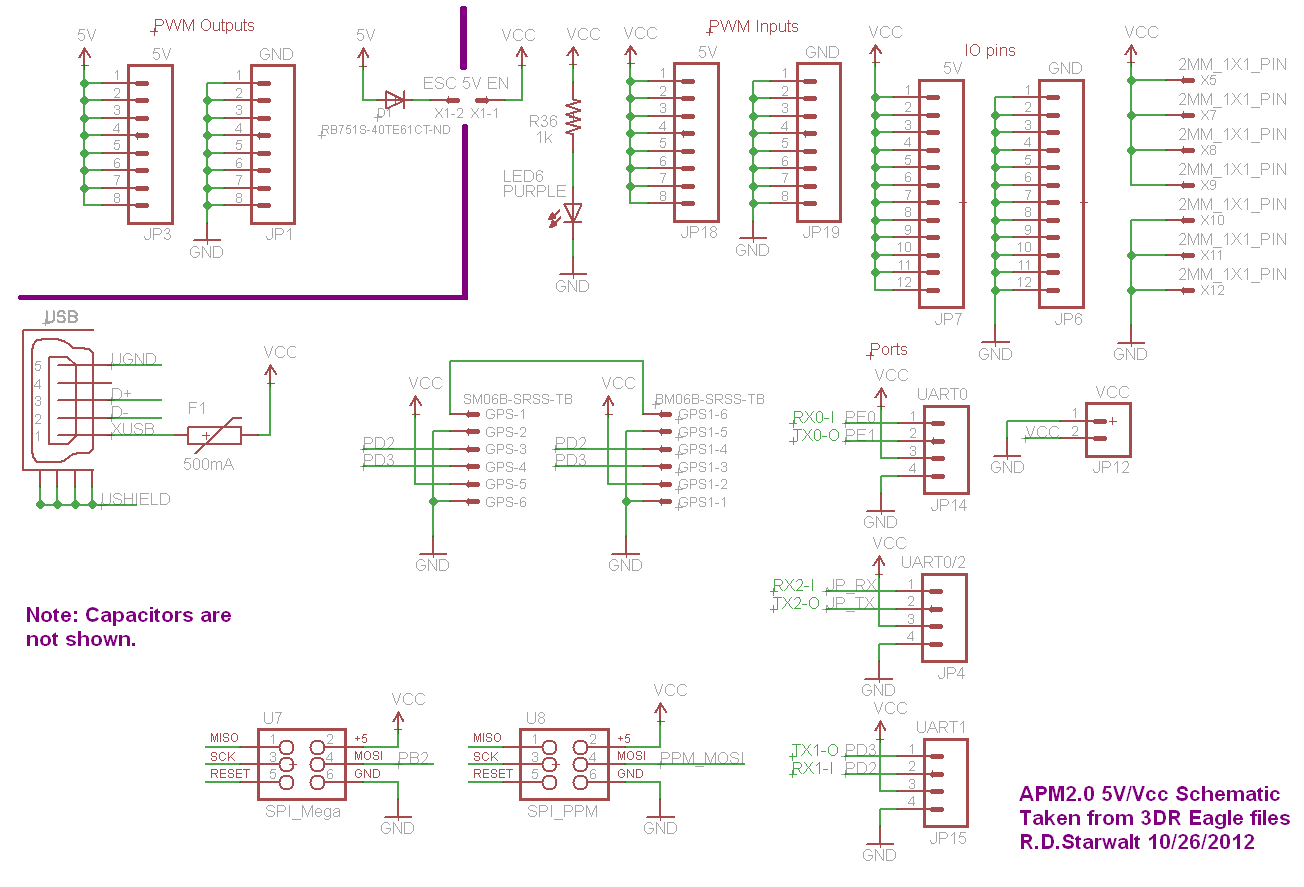
APM2.0 5V/Vcc Schematic
The PWM Output section has been separated into the upper left corner, delineated by a heavy purple line that is bridged by jumper JP1 on the APM2.0. This design choice highlights that diode D1 allows current to pass through JP1,...
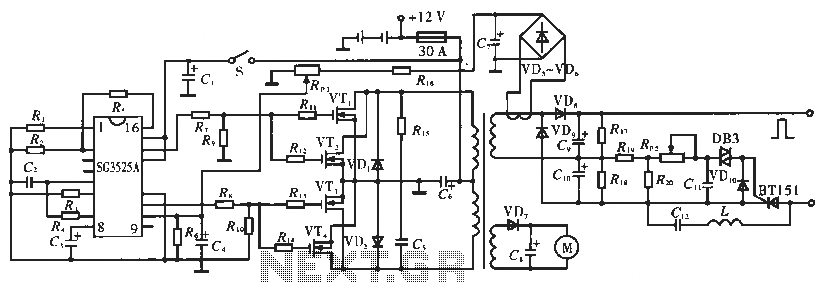
Electronic pulse circuitry fishing
The circuit utilizes the SC3525A, a PWM silicon chip from US General Semiconductor. It features an error amplifier with an inverting input at pin 1. Pin 2 serves as the non-inverting input for the error amplifier. Pins 5 and 6...