


Pwm motor speed control
#PWM
#speed control
#TMOS
#microprocessor
#digital logic
#comparator
#inverter
#bridge rectifier
#motor armature
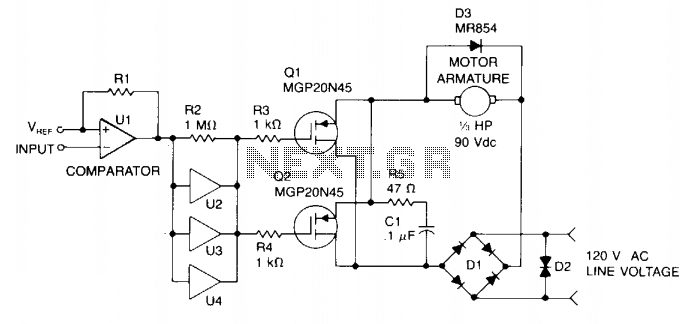
Description: Speed control is achieved through pulse width modulation (PWM) of the gates of two MGP20N45 TMOS devices. Consequently, the motor speed is directly proportional to the pulse width of the incoming digital signal, which can be generated by a microprocessor or digital logic circuit. The incoming signal is fed into comparator U1, and then it is processed by paralleled inverters U2, U3, and U4 that drive the two TMOS devices, which ultimately control the power supplied to the motor armature. A bridge rectifier D1 provides full-wave power, which is filtered by resistor R5 and capacitor C1. Additionally, a free-wheeling diode D3 (MR854) is included to prevent high voltage across Q1 and Q2. A back-to-back zener diode, D2, is utilized to protect against transients and high voltage surges.
The described circuit operates by utilizing pulse width modulation to control the speed of a DC motor. The MGP20N45 TMOS devices serve as high-efficiency switches that modulate the power delivered to the motor based on the PWM signal's duty cycle. The PWM signal is generated by a microprocessor or digital logic circuit, which allows for precise control of the motor speed.
The comparator U1 is essential for comparing the PWM signal with a reference voltage, ensuring accurate timing and switching of the TMOS devices. The output from U1 is then sent to a set of paralleled inverters (U2, U3, and U4), which amplify the signal to ensure that the gates of the TMOS devices receive a sufficient drive voltage. This configuration helps in achieving rapid switching and minimizes power loss during operation.
The bridge rectifier D1 converts the AC input voltage to a DC output, ensuring that the motor receives a consistent power supply. The filtering components, R5 and C1, smooth out the rectified voltage, providing a stable DC supply to the motor and reducing voltage ripple.
The inclusion of the free-wheeling diode D3 is crucial for protecting the TMOS devices from voltage spikes that may occur when the motor is switched off. This diode allows for the safe dissipation of inductive kickback generated by the motor's coils, thereby preventing potential damage to the switching devices.
Furthermore, the back-to-back zener diode D2 serves as a protective measure against transient voltage spikes and high voltage surges that could otherwise exceed the voltage ratings of the components in the circuit. By clamping excessive voltages, D2 ensures the longevity and reliability of the circuit under varying operational conditions.
Overall, this circuit design effectively integrates PWM control, robust voltage regulation, and protective components to achieve efficient motor speed control while safeguarding against potential electrical hazards.Speed control is accomplished by pulse width modulating the gates of two MGP20N45 TMOS devices. Therefore, motor speed is proportional to the pulse width of the incoming digital signal, which can be generated by a microprocessor or digital logic. The incoming signal is applied to comparator Ul, then to paralleled inverters U2, U3, and U4 that drive the two TMOS devices, which, in turn, control power applied to the motor armature.
Bridge rectifier Dl supplies fullwave power that is filtered by R5 and Cl. Free-wheeling diode D3 (MR854) prevents high voltage across Ql and Q2. A back-to-back zener diode, D2, protects against transients and high voltage surges.
The described circuit operates by utilizing pulse width modulation to control the speed of a DC motor. The MGP20N45 TMOS devices serve as high-efficiency switches that modulate the power delivered to the motor based on the PWM signal's duty cycle. The PWM signal is generated by a microprocessor or digital logic circuit, which allows for precise control of the motor speed.
The comparator U1 is essential for comparing the PWM signal with a reference voltage, ensuring accurate timing and switching of the TMOS devices. The output from U1 is then sent to a set of paralleled inverters (U2, U3, and U4), which amplify the signal to ensure that the gates of the TMOS devices receive a sufficient drive voltage. This configuration helps in achieving rapid switching and minimizes power loss during operation.
The bridge rectifier D1 converts the AC input voltage to a DC output, ensuring that the motor receives a consistent power supply. The filtering components, R5 and C1, smooth out the rectified voltage, providing a stable DC supply to the motor and reducing voltage ripple.
The inclusion of the free-wheeling diode D3 is crucial for protecting the TMOS devices from voltage spikes that may occur when the motor is switched off. This diode allows for the safe dissipation of inductive kickback generated by the motor's coils, thereby preventing potential damage to the switching devices.
Furthermore, the back-to-back zener diode D2 serves as a protective measure against transient voltage spikes and high voltage surges that could otherwise exceed the voltage ratings of the components in the circuit. By clamping excessive voltages, D2 ensures the longevity and reliability of the circuit under varying operational conditions.
Overall, this circuit design effectively integrates PWM control, robust voltage regulation, and protective components to achieve efficient motor speed control while safeguarding against potential electrical hazards.Speed control is accomplished by pulse width modulating the gates of two MGP20N45 TMOS devices. Therefore, motor speed is proportional to the pulse width of the incoming digital signal, which can be generated by a microprocessor or digital logic. The incoming signal is applied to comparator Ul, then to paralleled inverters U2, U3, and U4 that drive the two TMOS devices, which, in turn, control power applied to the motor armature.
Bridge rectifier Dl supplies fullwave power that is filtered by R5 and Cl. Free-wheeling diode D3 (MR854) prevents high voltage across Ql and Q2. A back-to-back zener diode, D2, protects against transients and high voltage surges.
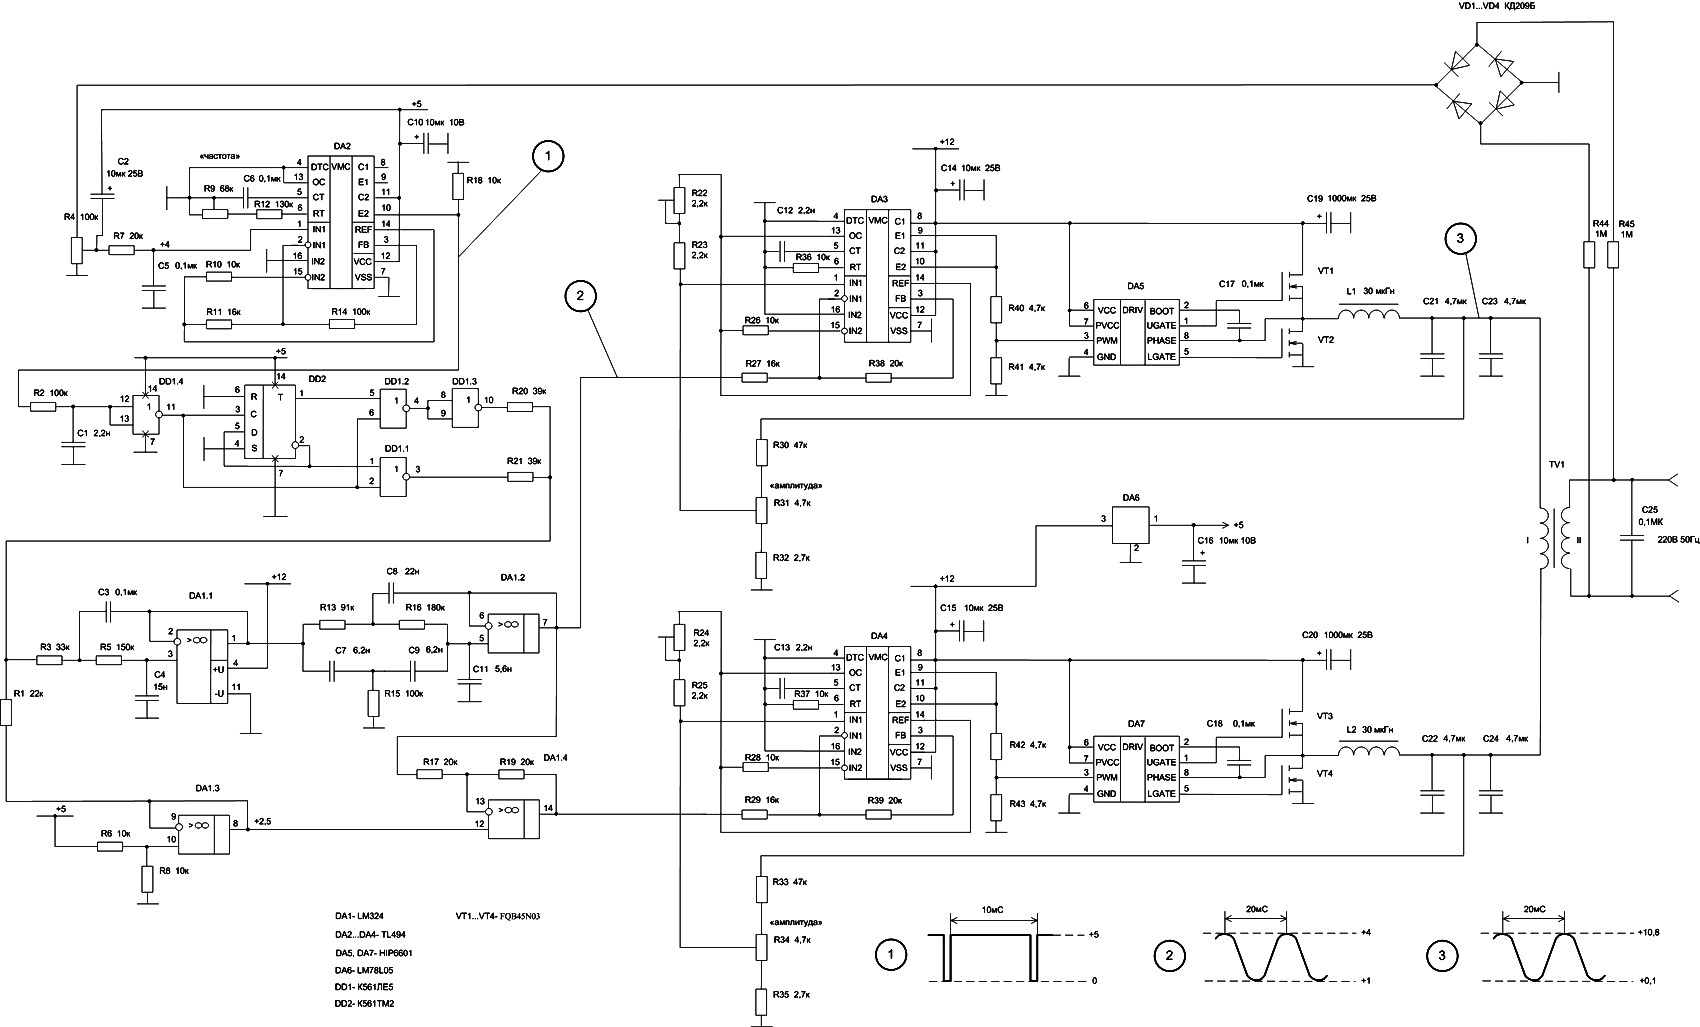
12VDC to 220VAC Inverter with Sine Wave Output
The 50W inverter circuit is built using the power MOSFET FQB45N03 and the IC TL494. This inverter converts a 12-14V DC input from a car battery into a 220V AC output with a 50Hz sine wave frequency. The main oscillator,...
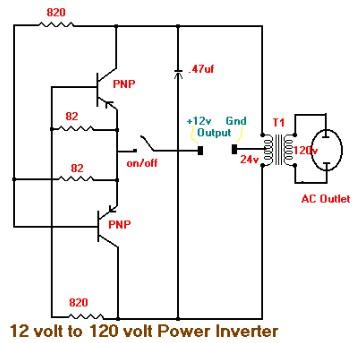
15W Inverter Circuit 12VDC to 120VAC
This is the schematic diagram of a 15W inverter circuit. The circuit is based on a PNP power transistor such as the TIP32 and other similar transistors. This inverter produces a square wave output, which may cause some noticeable hum...
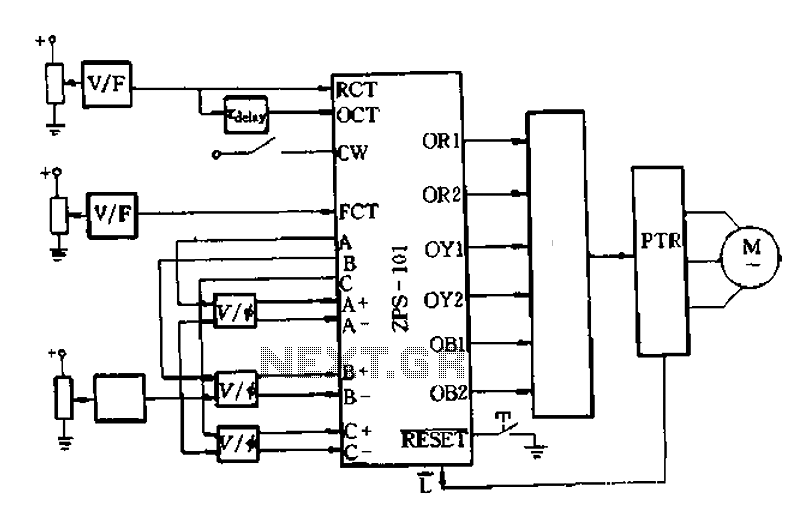
Analog PWM connection with FIG zps-101 interface
An AC-DC-AC circuit utilizes a power transistor as a switching device with analog control, as recommended in the wiring diagram of Figure 6-10. This circuit generates a voltage-controlled oscillator (VCO) using OCT and FCT, with RCT available for OCT delay....
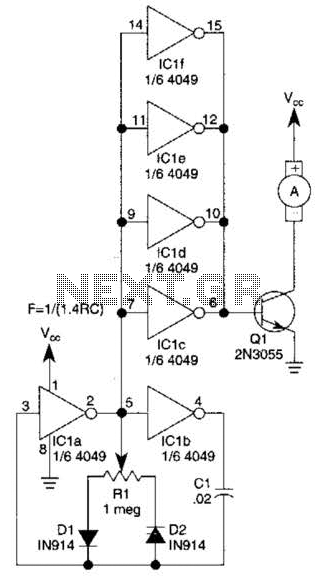
Pwm Motor-Drive Circuit Circuit
This circuit will drive a small DC motor over a wide range of speeds without stalling by controlling the duty cycle of the motor, rather than the supply voltage.
The described circuit utilizes pulse width modulation (PWM) to effectively control the...
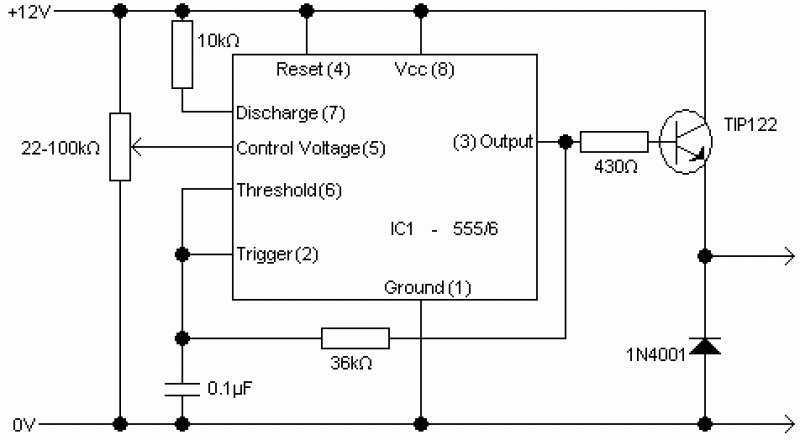
PWM Motor Control circuit
This controller is designed primarily for controlling model trains and can deliver approximately 12-15 Volts, though it operates effectively at voltages as low as 3V, including a 6V supply for certain accessories. The maximum output current is theoretically around 5...
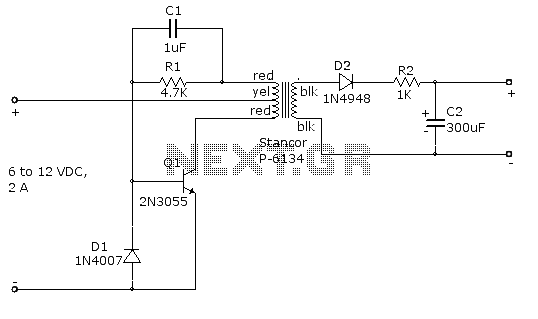
Super Simple Inverter
This is an example of a simple inverter that can be used to power a fluorescent lamp and a small strobe. This circuit will produce over 400 VDC from a 12 VDC, 2.5 A.
The described inverter circuit is designed to...
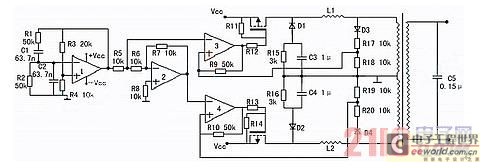
Brief introduction of circuit diagram of the inverter and principle
The inverter is a device that converts direct current (DC) from a battery or storage battery into alternating current (AC), typically at 220 volts and 50 Hz, producing either sine waves or rectangular waves. It serves as a common emergency...
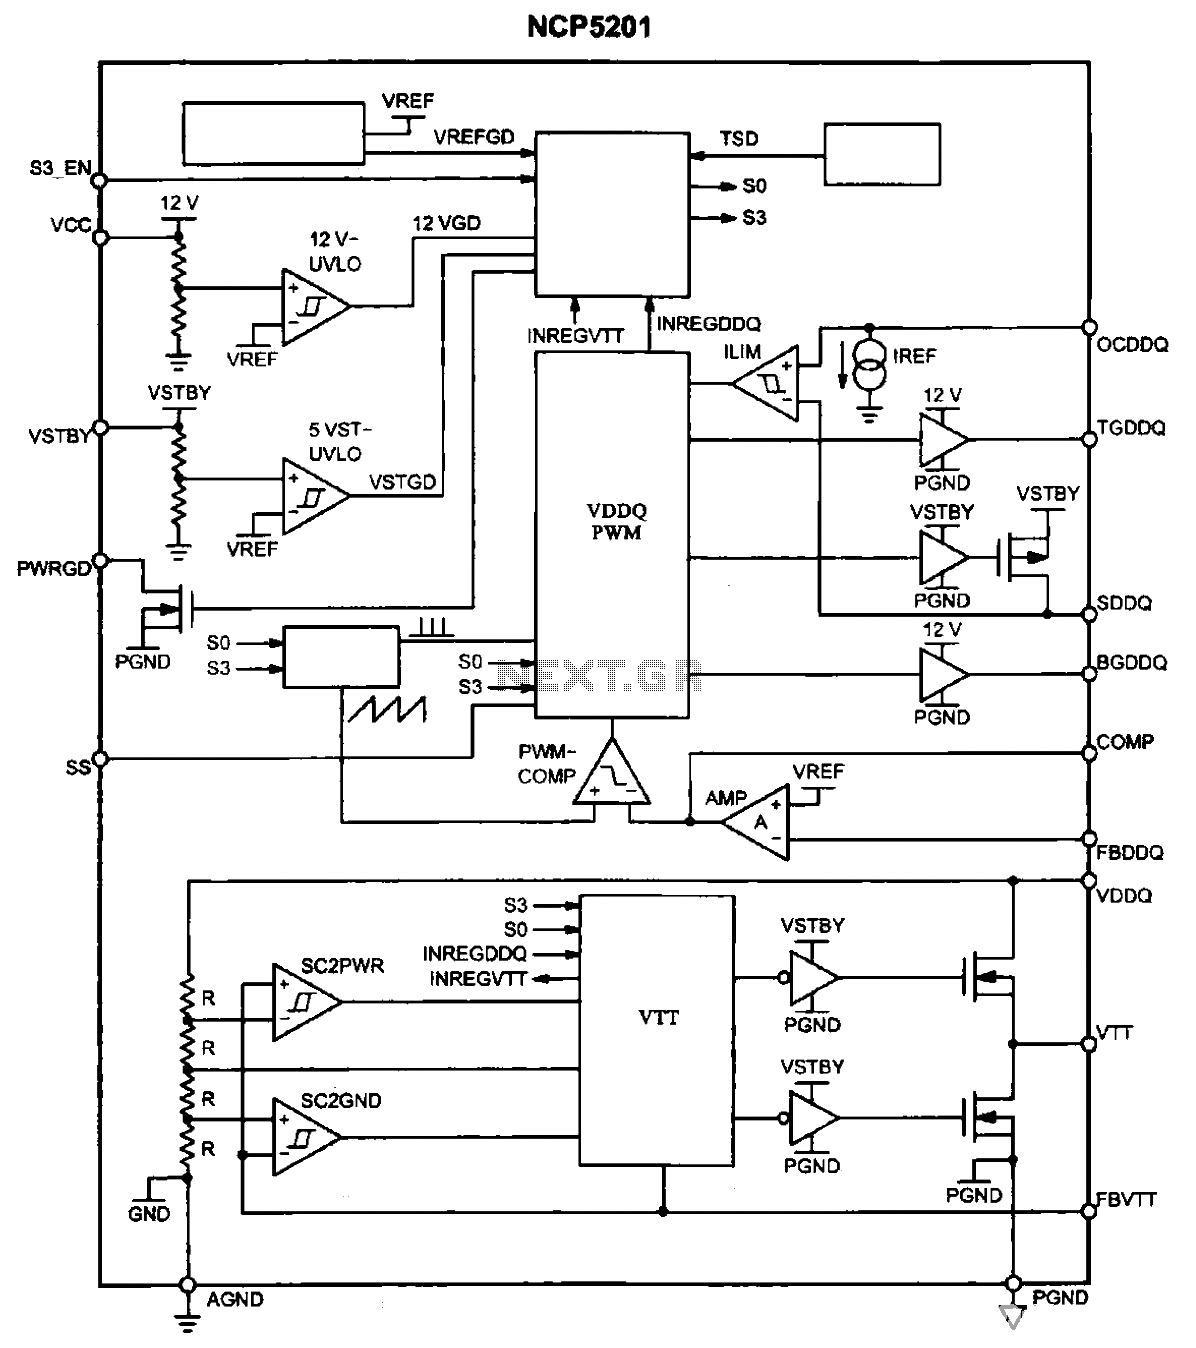
Internal functional block diagram of NCP5201
The NCP5201 chip contains two sets of PWM signal generating circuits, each with a dedicated set of output pins. These circuits produce two opposite phase PWM signals, which are applied to the gates of three field effect transistors. This arrangement...
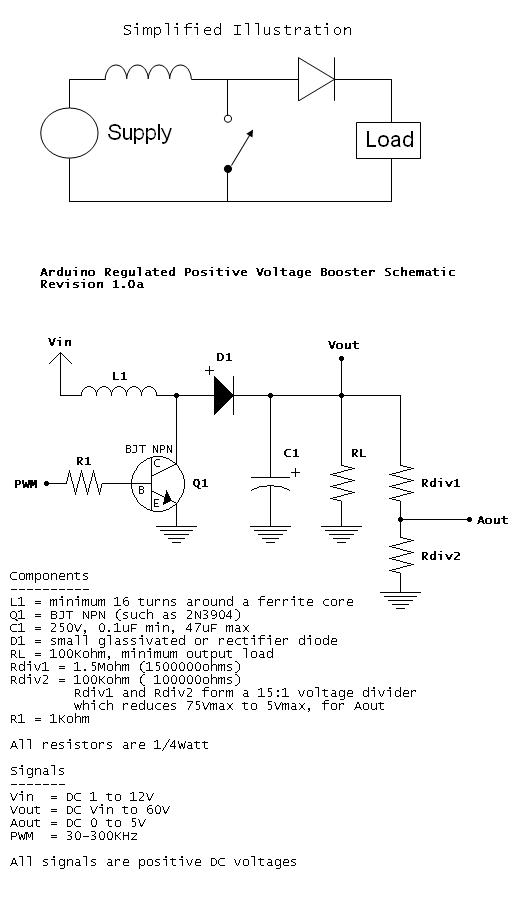
Regulated Positive Voltage Booster
When Q1 is active, a larger current begins to flow through L1 to ground. When Q1 is switched off, the current through L1 tries to remain constant, resulting in an increased voltage. By varying the PWM duty cycle, the current...