


Stepping Motor Driver
#stepping motor
#driver
#full steps
#reverse
#active hold
#power off
#motor control
#XNOR gate
#coils
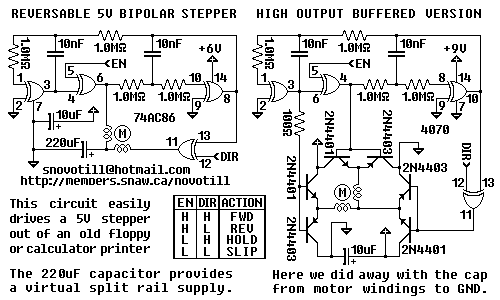
Description: The circuit is not particularly susceptible to motor transients and supports FULL STEPS FORWARD, FULL STEPS REVERSE, ACTIVE HOLD, and POWER OFF aka RELEASED. If the motor does not turn then swap around the leads of ONE of the two coils. To reverse the sense of the EN signal simply rework the circuit around an XNOR gate.
This circuit is designed for controlling a stepper motor with features that allow for precise movement in both forward and reverse directions, as well as maintaining its position when powered. The operation modes include FULL STEPS FORWARD and FULL STEPS REVERSE, which enable the motor to move incrementally by energizing the motor coils in a specific sequence.
The ACTIVE HOLD feature is essential for applications where the motor must maintain its position without moving, ensuring that the motor does not lose its holding torque when not actively stepping. The POWER OFF or RELEASED mode allows for the motor to be powered down completely, which can be useful for reducing energy consumption when the motor is not in use.
In the event that the motor does not turn, a troubleshooting step involves swapping the leads of one of the two coils. This adjustment can correct the phase of the motor coils, which is crucial for proper operation. The circuit incorporates an EN (enable) signal that controls the activation of the motor. To modify the behavior of the EN signal, the circuit can be reconfigured using an XNOR gate. This logic gate will allow for the reversal of the EN signal sense, enabling flexibility in the control logic depending on the system requirements.
Overall, the circuit is robust against motor transients, which are sudden changes in voltage or current that can occur during motor operation, ensuring reliable performance in various applications. The design considerations make it suitable for environments where precise motor control is necessary.The circuit is not particularly susceptible to motor transients and supports FULL STEPS FORWARD, FULL STEPS REVERSE, ACTIVE HOLD, and POWER OFF aka RELEASED. If the motor does not turn then swap around the leads of ONE of the two coils. To reverse the sense of the EN signal simply rework the circuit around an XNOR gate.
This circuit is designed for controlling a stepper motor with features that allow for precise movement in both forward and reverse directions, as well as maintaining its position when powered. The operation modes include FULL STEPS FORWARD and FULL STEPS REVERSE, which enable the motor to move incrementally by energizing the motor coils in a specific sequence.
The ACTIVE HOLD feature is essential for applications where the motor must maintain its position without moving, ensuring that the motor does not lose its holding torque when not actively stepping. The POWER OFF or RELEASED mode allows for the motor to be powered down completely, which can be useful for reducing energy consumption when the motor is not in use.
In the event that the motor does not turn, a troubleshooting step involves swapping the leads of one of the two coils. This adjustment can correct the phase of the motor coils, which is crucial for proper operation. The circuit incorporates an EN (enable) signal that controls the activation of the motor. To modify the behavior of the EN signal, the circuit can be reconfigured using an XNOR gate. This logic gate will allow for the reversal of the EN signal sense, enabling flexibility in the control logic depending on the system requirements.
Overall, the circuit is robust against motor transients, which are sudden changes in voltage or current that can occur during motor operation, ensuring reliable performance in various applications. The design considerations make it suitable for environments where precise motor control is necessary.The circuit is not particularly susceptible to motor transients and supports FULL STEPS FORWARD, FULL STEPS REVERSE, ACTIVE HOLD, and POWER OFF aka RELEASED. If the motor does not turn then swap around the leads of ONE of the two coils. To reverse the sense of the EN signal simply rework the circuit around an XNOR gate.
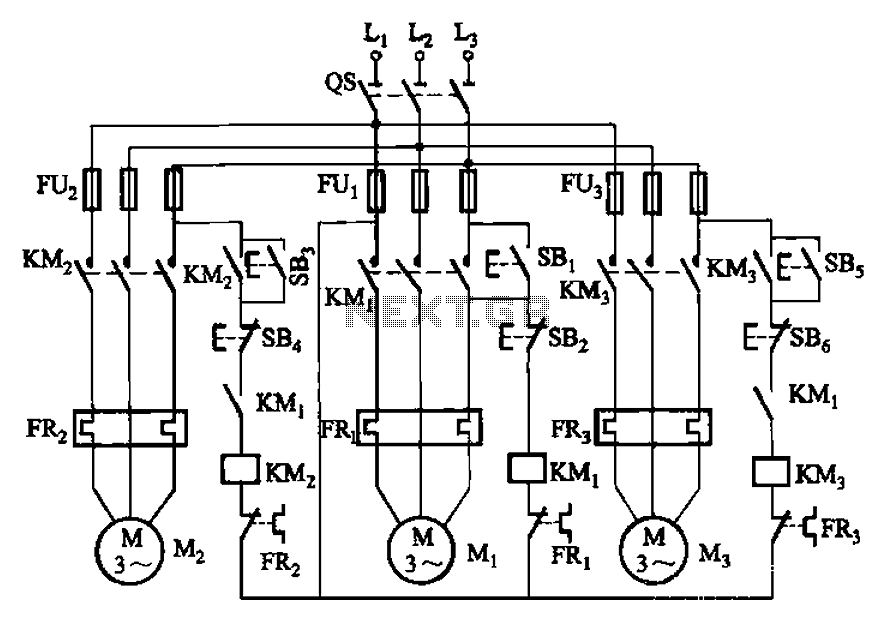
Three motor control circuit start and stop sequence requirements
The circuit shown in Figure 3-89 illustrates a system where starting motor M1 allows motors M2 and M3 to initiate operation. Upon shutdown, motor Mz can be stopped first; however, once motor M1 is stopped (by pressing switch SB2), motors...
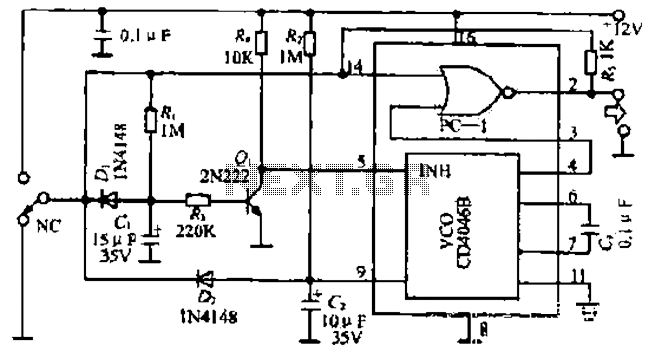
Rapid control circuit of a stepping motor
The figure illustrates a circuit involving dark tomb electric locks, specifically the fti: al: 4046B and XOR gate as the primary control mechanism. It emits pulses and utilizes silicon for successive pulse generation. The circuit operates with a normal button...
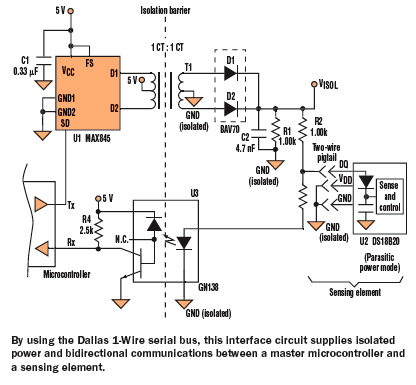
Add Ramp To Stepping Motor
Stepping motor controllers are frequently preferred over complex software-driven controllers due to their low cost. However, stepping motors tend to exhibit low torque at high speeds, necessitating a starting ramp to avoid stalling during startup. This circuit provides a one-chip...
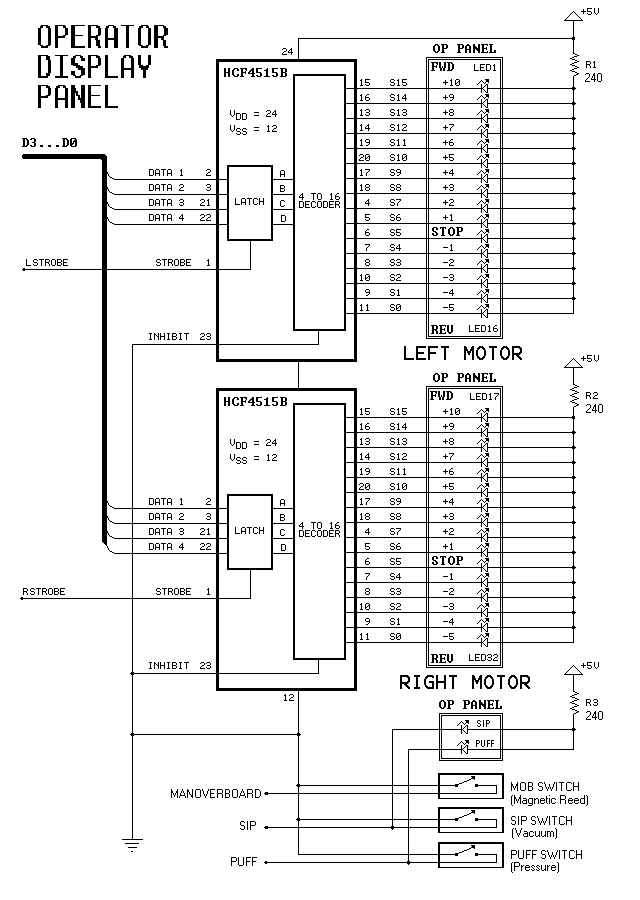
Dual-Motor SIP&PUFF Controlled Kayak System
The YouTube video below demonstrates the quick and easy setup of the system at the launch site.
The provided description indicates a focus on the efficiency of system installation at a launch site, as showcased in a YouTube video. In an...
Gray Projects
After learning to operate the device, it became evident that inertia posed a significant challenge. The constructed system is notably heavy, making it difficult to initiate motor operation at full speed. Despite having some understanding of physics, practical experience is...
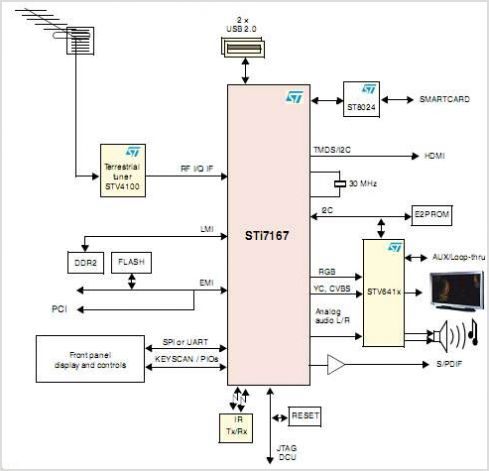
STI7167 Advanced STB Decoder With Integrated DVB-T/DVB-C Demodulator
The STK672-050 is a unipolar constant-current chopper-type externally-excited 4-phase stepping motor driver hybrid integrated circuit (IC) that utilizes MOSFET power devices. It features a built-in microstep operation-supported 4-phase distributed controller, enabling the realization of a high torque, low vibration, and...
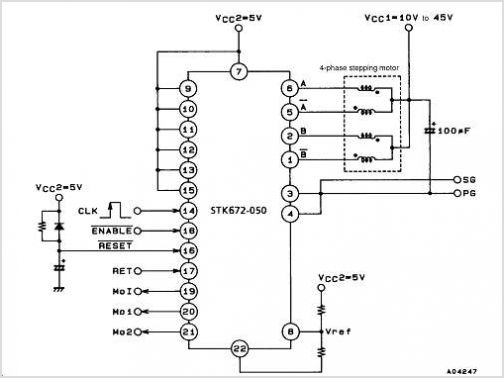
STK672-050 Microstep Operation-supported 4-phase Stepping Motor Driver (io= 3.0a) Semicon Device
The STM1061 low power voltage detector monitors battery, power supply, and regulated system voltages. A precision voltage reference and comparator assess the V_CC input, comparing it with a specified voltage threshold. When V_CC falls below the defined trip point threshold,...
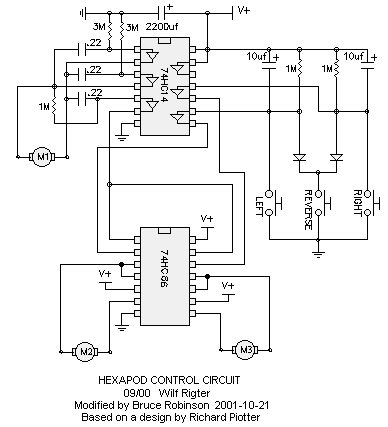
5-motor hexapod circuit
This circuit has a long history, originating from an idea by Rich Piotter and later refined by Wilf Rigter and Bruce Robinson. The final result does not include the necessary motor drivers, which are typically H-bridge based, but presents a...
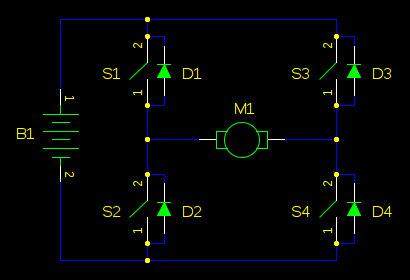
boost Why should I worry about a motor causing my supply voltage to shoot up when the back-EMF cant exceed the supply voltage
In motor control circuits, precautions must be taken to prevent the motor from feeding back into the power supply, which can cause the supply voltage to rise and potentially damage components. However, unless an external force is accelerating the motor,...