


Add Ramp To Stepping Motor
#stepping motor
#motor controller
#ramp circuit
#torque control
#startup protection
#low cost
#hardware solution
#stall prevention
Description: Stepping motor controllers are frequently preferred over complex software-driven controllers due to their low cost. However, stepping motors tend to exhibit low torque at high speeds, necessitating a starting ramp to avoid stalling during startup. This circuit provides a one-chip solution to address this issue. The core component of the circuit is the 555 timer U1, configured as an astable multivibrator. A 50-millisecond on time was chosen to ensure compatibility with the stepping motor driver, while the off time is approximately equal to 1.1 times the product of R2 and C2. A 10-millisecond off time was selected for the final speed of the stepping motor.
The described circuit utilizes a 555 timer in an astable configuration to generate a pulse-width modulation (PWM) signal that controls the stepping motor's operation. The 555 timer is a versatile integrated circuit commonly used for timing applications, and its configuration as an astable multivibrator allows it to produce a continuous square wave output.
In this application, the on time of 50 milliseconds and off time of approximately 10 milliseconds are critical to achieving the desired stepping motor performance. The on time determines how long the motor receives power, while the off time influences the motor's ability to reach its final speed without stalling. The values of resistors and capacitors used in the circuit must be carefully selected to ensure that the timing characteristics align with the motor's specifications.
The circuit may include additional components such as diodes for flyback protection, which safeguard the 555 timer and other sensitive components from voltage spikes generated when the motor is de-energized. Proper layout and grounding techniques should be employed to minimize noise and ensure stable operation, especially in environments where electromagnetic interference (EMI) may be present.
Overall, this circuit provides a cost-effective and efficient solution for controlling stepping motors, enabling their use in various applications where precise positioning and speed control are required. The simplicity of the design, combined with the reliability of the 555 timer, makes it an attractive option for engineers and hobbyists alike.Due to their low cost, stepping-motor controllers are often chosen over full-blown, software-driven controllers for a number of applications. However, stepping motors provide rather low torque at high speeds, thus they usually require a starting ramp to prevent them from stalling at startup.
This circuit is a one-chip solution to that problem. Lying at the heart of the circuit is the 555 timer U1, which is configured as an astable multivibrator. In this case, a 50-m on time was selected to be compatible with the stepping-motor driver. The off time is approximately equal to 1. 1R2C2. A 10-ms off time was selected for the final speed of the stepping motor.
The described circuit utilizes a 555 timer in an astable configuration to generate a pulse-width modulation (PWM) signal that controls the stepping motor's operation. The 555 timer is a versatile integrated circuit commonly used for timing applications, and its configuration as an astable multivibrator allows it to produce a continuous square wave output.
In this application, the on time of 50 milliseconds and off time of approximately 10 milliseconds are critical to achieving the desired stepping motor performance. The on time determines how long the motor receives power, while the off time influences the motor's ability to reach its final speed without stalling. The values of resistors and capacitors used in the circuit must be carefully selected to ensure that the timing characteristics align with the motor's specifications.
The circuit may include additional components such as diodes for flyback protection, which safeguard the 555 timer and other sensitive components from voltage spikes generated when the motor is de-energized. Proper layout and grounding techniques should be employed to minimize noise and ensure stable operation, especially in environments where electromagnetic interference (EMI) may be present.
Overall, this circuit provides a cost-effective and efficient solution for controlling stepping motors, enabling their use in various applications where precise positioning and speed control are required. The simplicity of the design, combined with the reliability of the 555 timer, makes it an attractive option for engineers and hobbyists alike.Due to their low cost, stepping-motor controllers are often chosen over full-blown, software-driven controllers for a number of applications. However, stepping motors provide rather low torque at high speeds, thus they usually require a starting ramp to prevent them from stalling at startup.
This circuit is a one-chip solution to that problem. Lying at the heart of the circuit is the 555 timer U1, which is configured as an astable multivibrator. In this case, a 50-m on time was selected to be compatible with the stepping-motor driver. The off time is approximately equal to 1. 1R2C2. A 10-ms off time was selected for the final speed of the stepping motor.
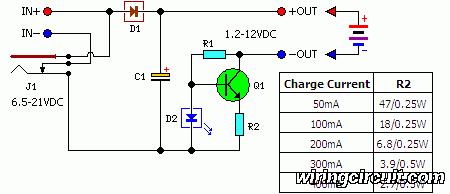
Low Cost Universal Battery Charger Schematic
This is a simple and low-cost NiCd and NiMH battery charger. The schematic diagram indicates that the charging current (I) should be set to 1/10 of the battery's rated capacity. For instance, if the battery has a rated capacity of...
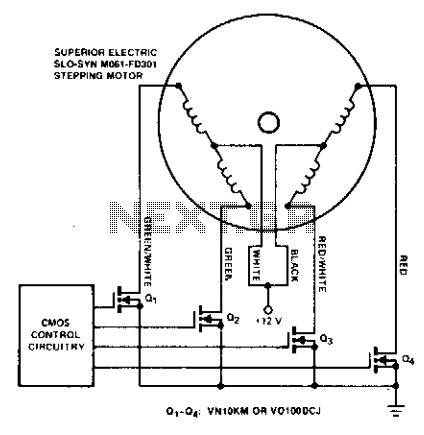
Stepping motor driver
Stepping motors are commonly utilized in disk drives and machine control applications. MOSPOWER transistors serve as excellent motor drivers due to their immunity to second breakdown. It is important to note that snubbing networks are unnecessary since load line shaping...
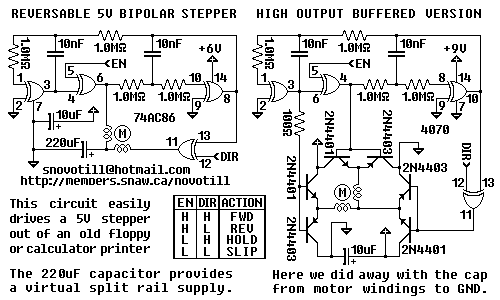
Stepping Motor Driver
The circuit is not particularly susceptible to motor transients and supports FULL STEPS FORWARD, FULL STEPS REVERSE, ACTIVE HOLD, and POWER OFF aka RELEASED. If the motor does not turn then swap around the leads of ONE of the two...

working principles of motor control
After dismantling a Chinese copy of a Segway, an examination of the motor controller was conducted. After several hours of work with a multimeter, pen, paper, and KiCad, a block diagram and schematic of the motor controller were developed. This...
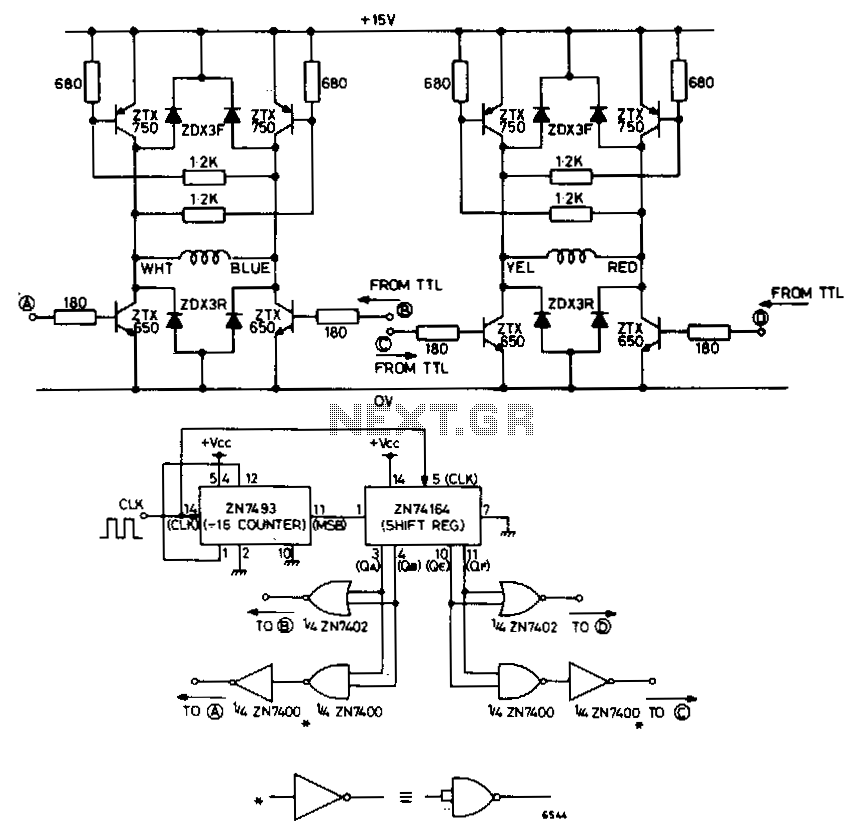
Stepping-motor-drive
The circuit depicted in Fig. 62-15A is intended to drive a 15-V, two-phase, bipolar stepping motor, delivering a bidirectional single-level voltage across each winding with currents reaching up to 9.6 A. It comprises two identical transistor bridge stages that utilize...
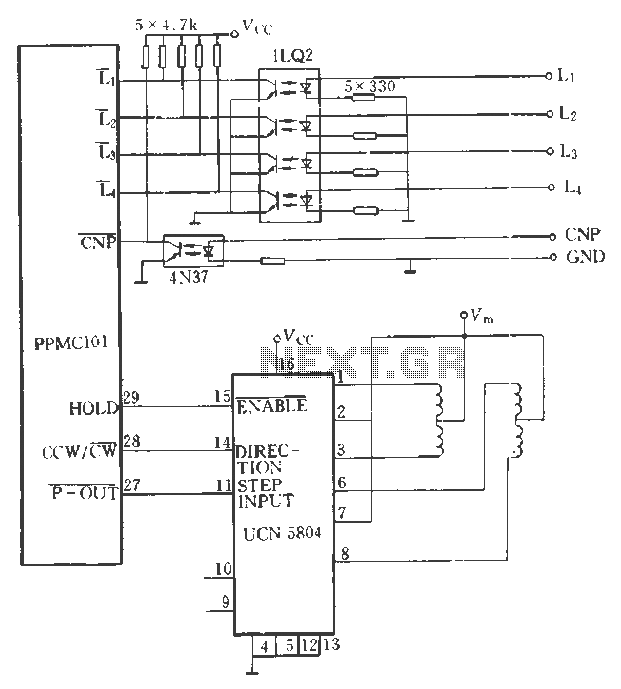
PPMC and stepping motor driver IC dedicated connection circuit
The PPMC external UChl 5804 demonstrates a four-phase stepping motor drive integrated circuit (IC) that is depicted in a downward motion. It utilizes the P-OUT, counterclockwise (ccw) / clockwise (cw), and HOLD outputs. The UCN5804 pins 9 and 10 can...
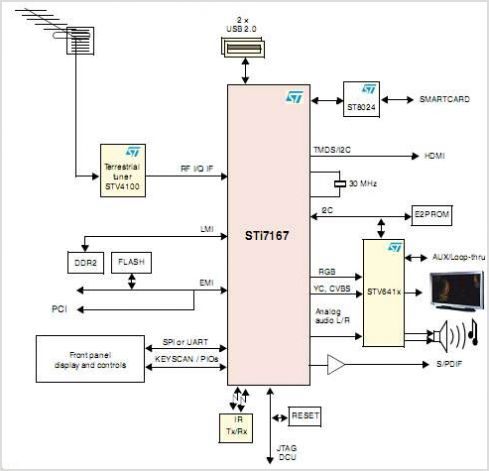
STI7167 Advanced STB Decoder With Integrated DVB-T/DVB-C Demodulator
The STK672-050 is a unipolar constant-current chopper-type externally-excited 4-phase stepping motor driver hybrid integrated circuit (IC) that utilizes MOSFET power devices. It features a built-in microstep operation-supported 4-phase distributed controller, enabling the realization of a high torque, low vibration, and...
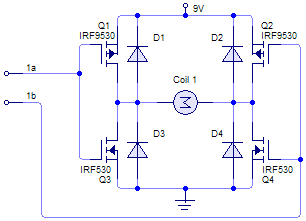
GENERAL DIAGRAM OF MOTOR CONTROLLER
General Diagram of Motor Controller Manual PDF Download.
The motor controller is an essential component in various applications, including robotics, electric vehicles, and industrial machinery. It regulates the operation of electric motors by controlling parameters such as speed, direction, and torque....
Stepping Motor Driver
The circuit is not particularly susceptible to motor transients and supports FULL STEPS FORWARD, FULL STEPS REVERSE, ACTIVE HOLD, and POWER OFF aka RELEASED. If the motor does not turn then swap around the leads of ONE of the two...