


servo motor
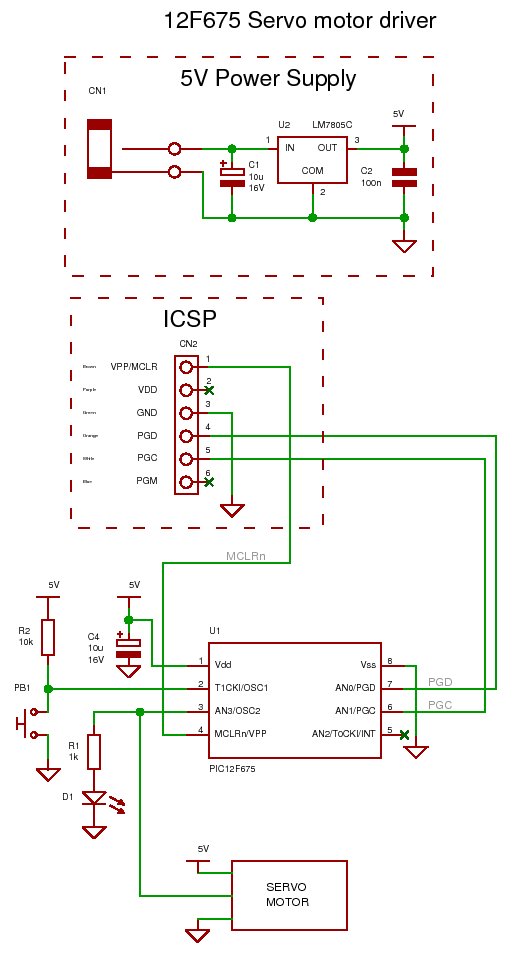
Description: How to generate the signal for controlling a standard (RC) servo motor using a PIC microcontroller.
To control a standard RC servo motor with a PIC microcontroller, it is essential to generate a pulse-width modulation (PWM) signal that dictates the position of the servo. The PWM signal is characterized by its duty cycle, which determines the angle of the servo arm. Typically, a standard RC servo motor expects a PWM signal with a frequency of approximately 50 Hz, where the pulse width ranges from 1 ms to 2 ms. A 1 ms pulse corresponds to a 0-degree position, while a 2 ms pulse corresponds to a 180-degree position.
The process begins with configuring the PIC microcontroller's timer to generate the PWM signal. For instance, Timer 1 can be set up in the PIC microcontroller to create an interrupt that occurs at a frequency of 50 Hz. The interrupt service routine (ISR) will then toggle a digital output pin connected to the servo control line. The width of the pulse can be adjusted by modifying the timer's compare register, allowing for precise control over the servo's position.
The following steps outline the implementation:
1. **Configuration of Timer**: Set up Timer 1 in the PIC microcontroller to generate interrupts at a frequency of 50 Hz. This involves setting the appropriate prescaler and period values based on the microcontroller's clock frequency.
2. **PWM Signal Generation**: In the ISR, toggle the output pin connected to the servo. The pulse width can be controlled by using a variable that defines the duration of the high state of the output pin. This variable should be set to correspond with the desired angle of the servo.
3. **Mapping Angles to Pulse Widths**: Create a function that maps the desired angle (0 to 180 degrees) to the corresponding pulse width (1 ms to 2 ms). This can be achieved through a linear interpolation based on the angle input.
4. **Output to Servo**: Ensure that the output pin is connected to the control line of the servo motor. The servo will respond to the PWM signal by adjusting its position according to the pulse width received.
5. **Testing and Calibration**: Once the circuit is assembled, it is crucial to test the output signal with an oscilloscope to confirm that the pulse widths are accurate and correspond to the desired angles. Calibration may be necessary to account for any discrepancies between the expected and actual servo positions.
By following these steps and ensuring proper configuration of the PIC microcontroller, a reliable control signal for a standard RC servo motor can be generated, enabling precise movement and positioning in various applications.How to generate the signal for contolling a standard (RC) servo motor using a PIC microcontroller..
To control a standard RC servo motor with a PIC microcontroller, it is essential to generate a pulse-width modulation (PWM) signal that dictates the position of the servo. The PWM signal is characterized by its duty cycle, which determines the angle of the servo arm. Typically, a standard RC servo motor expects a PWM signal with a frequency of approximately 50 Hz, where the pulse width ranges from 1 ms to 2 ms. A 1 ms pulse corresponds to a 0-degree position, while a 2 ms pulse corresponds to a 180-degree position.
The process begins with configuring the PIC microcontroller's timer to generate the PWM signal. For instance, Timer 1 can be set up in the PIC microcontroller to create an interrupt that occurs at a frequency of 50 Hz. The interrupt service routine (ISR) will then toggle a digital output pin connected to the servo control line. The width of the pulse can be adjusted by modifying the timer's compare register, allowing for precise control over the servo's position.
The following steps outline the implementation:
1. **Configuration of Timer**: Set up Timer 1 in the PIC microcontroller to generate interrupts at a frequency of 50 Hz. This involves setting the appropriate prescaler and period values based on the microcontroller's clock frequency.
2. **PWM Signal Generation**: In the ISR, toggle the output pin connected to the servo. The pulse width can be controlled by using a variable that defines the duration of the high state of the output pin. This variable should be set to correspond with the desired angle of the servo.
3. **Mapping Angles to Pulse Widths**: Create a function that maps the desired angle (0 to 180 degrees) to the corresponding pulse width (1 ms to 2 ms). This can be achieved through a linear interpolation based on the angle input.
4. **Output to Servo**: Ensure that the output pin is connected to the control line of the servo motor. The servo will respond to the PWM signal by adjusting its position according to the pulse width received.
5. **Testing and Calibration**: Once the circuit is assembled, it is crucial to test the output signal with an oscilloscope to confirm that the pulse widths are accurate and correspond to the desired angles. Calibration may be necessary to account for any discrepancies between the expected and actual servo positions.
By following these steps and ensuring proper configuration of the PIC microcontroller, a reliable control signal for a standard RC servo motor can be generated, enabling precise movement and positioning in various applications.How to generate the signal for contolling a standard (RC) servo motor using a PIC microcontroller..
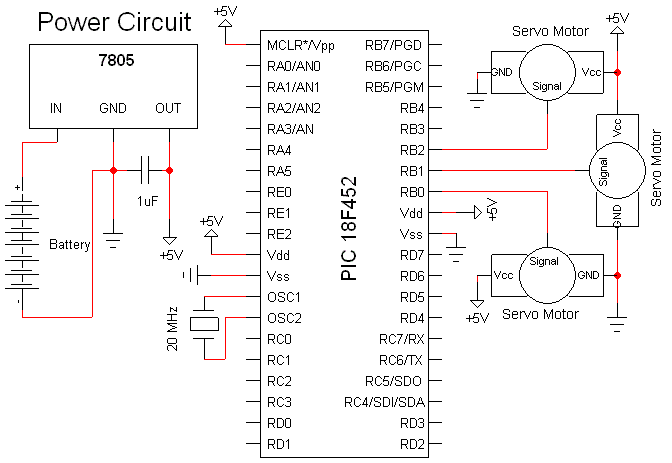
Servo Motor Control Circuit
The Olimex P-40 development board will be utilized, though the circuit can also be constructed on a breadboard due to its simplicity. The schematic for the initial implementation of servo control is provided below. Servos, like any motors, can draw...
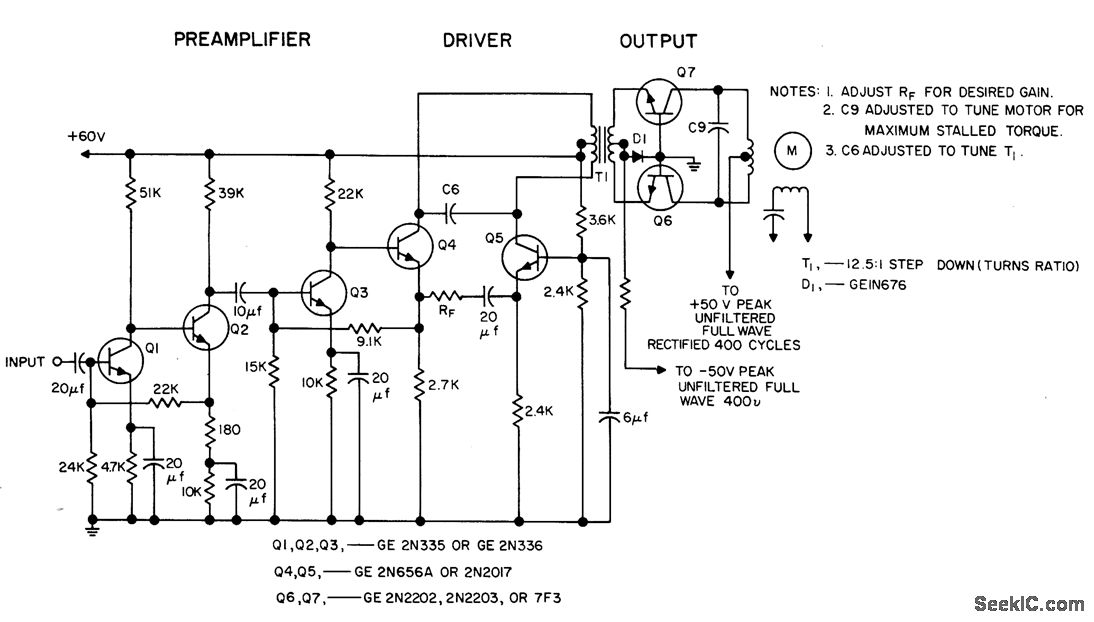
COMPLETE 3 W 400 CPS SERVO AMPLIFIER
The circuit is capable of driving a 3W servo motor in an ambient temperature range of -55 to 125 degrees Fahrenheit, provided that capacitors rated for 125 degrees Fahrenheit are utilized. The gain can be adjusted over a range of...
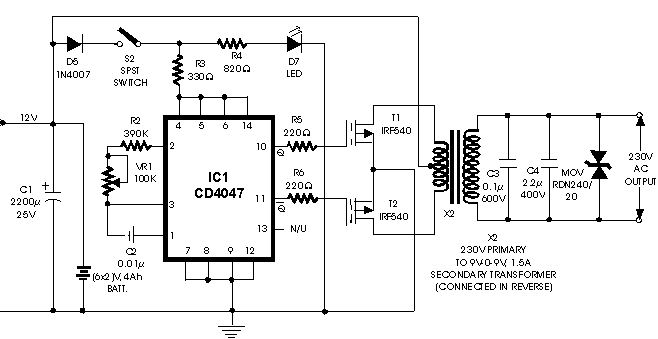
pic based modified sine wave inverter
A PIC-based inverter circuit is being developed that utilizes two P-channel MOSFETs (F9540N) along with a center-tapped 12-0-12/230V transformer.
The proposed circuit design incorporates a microcontroller from the PIC family, which serves as the main control unit for the inverter operation....
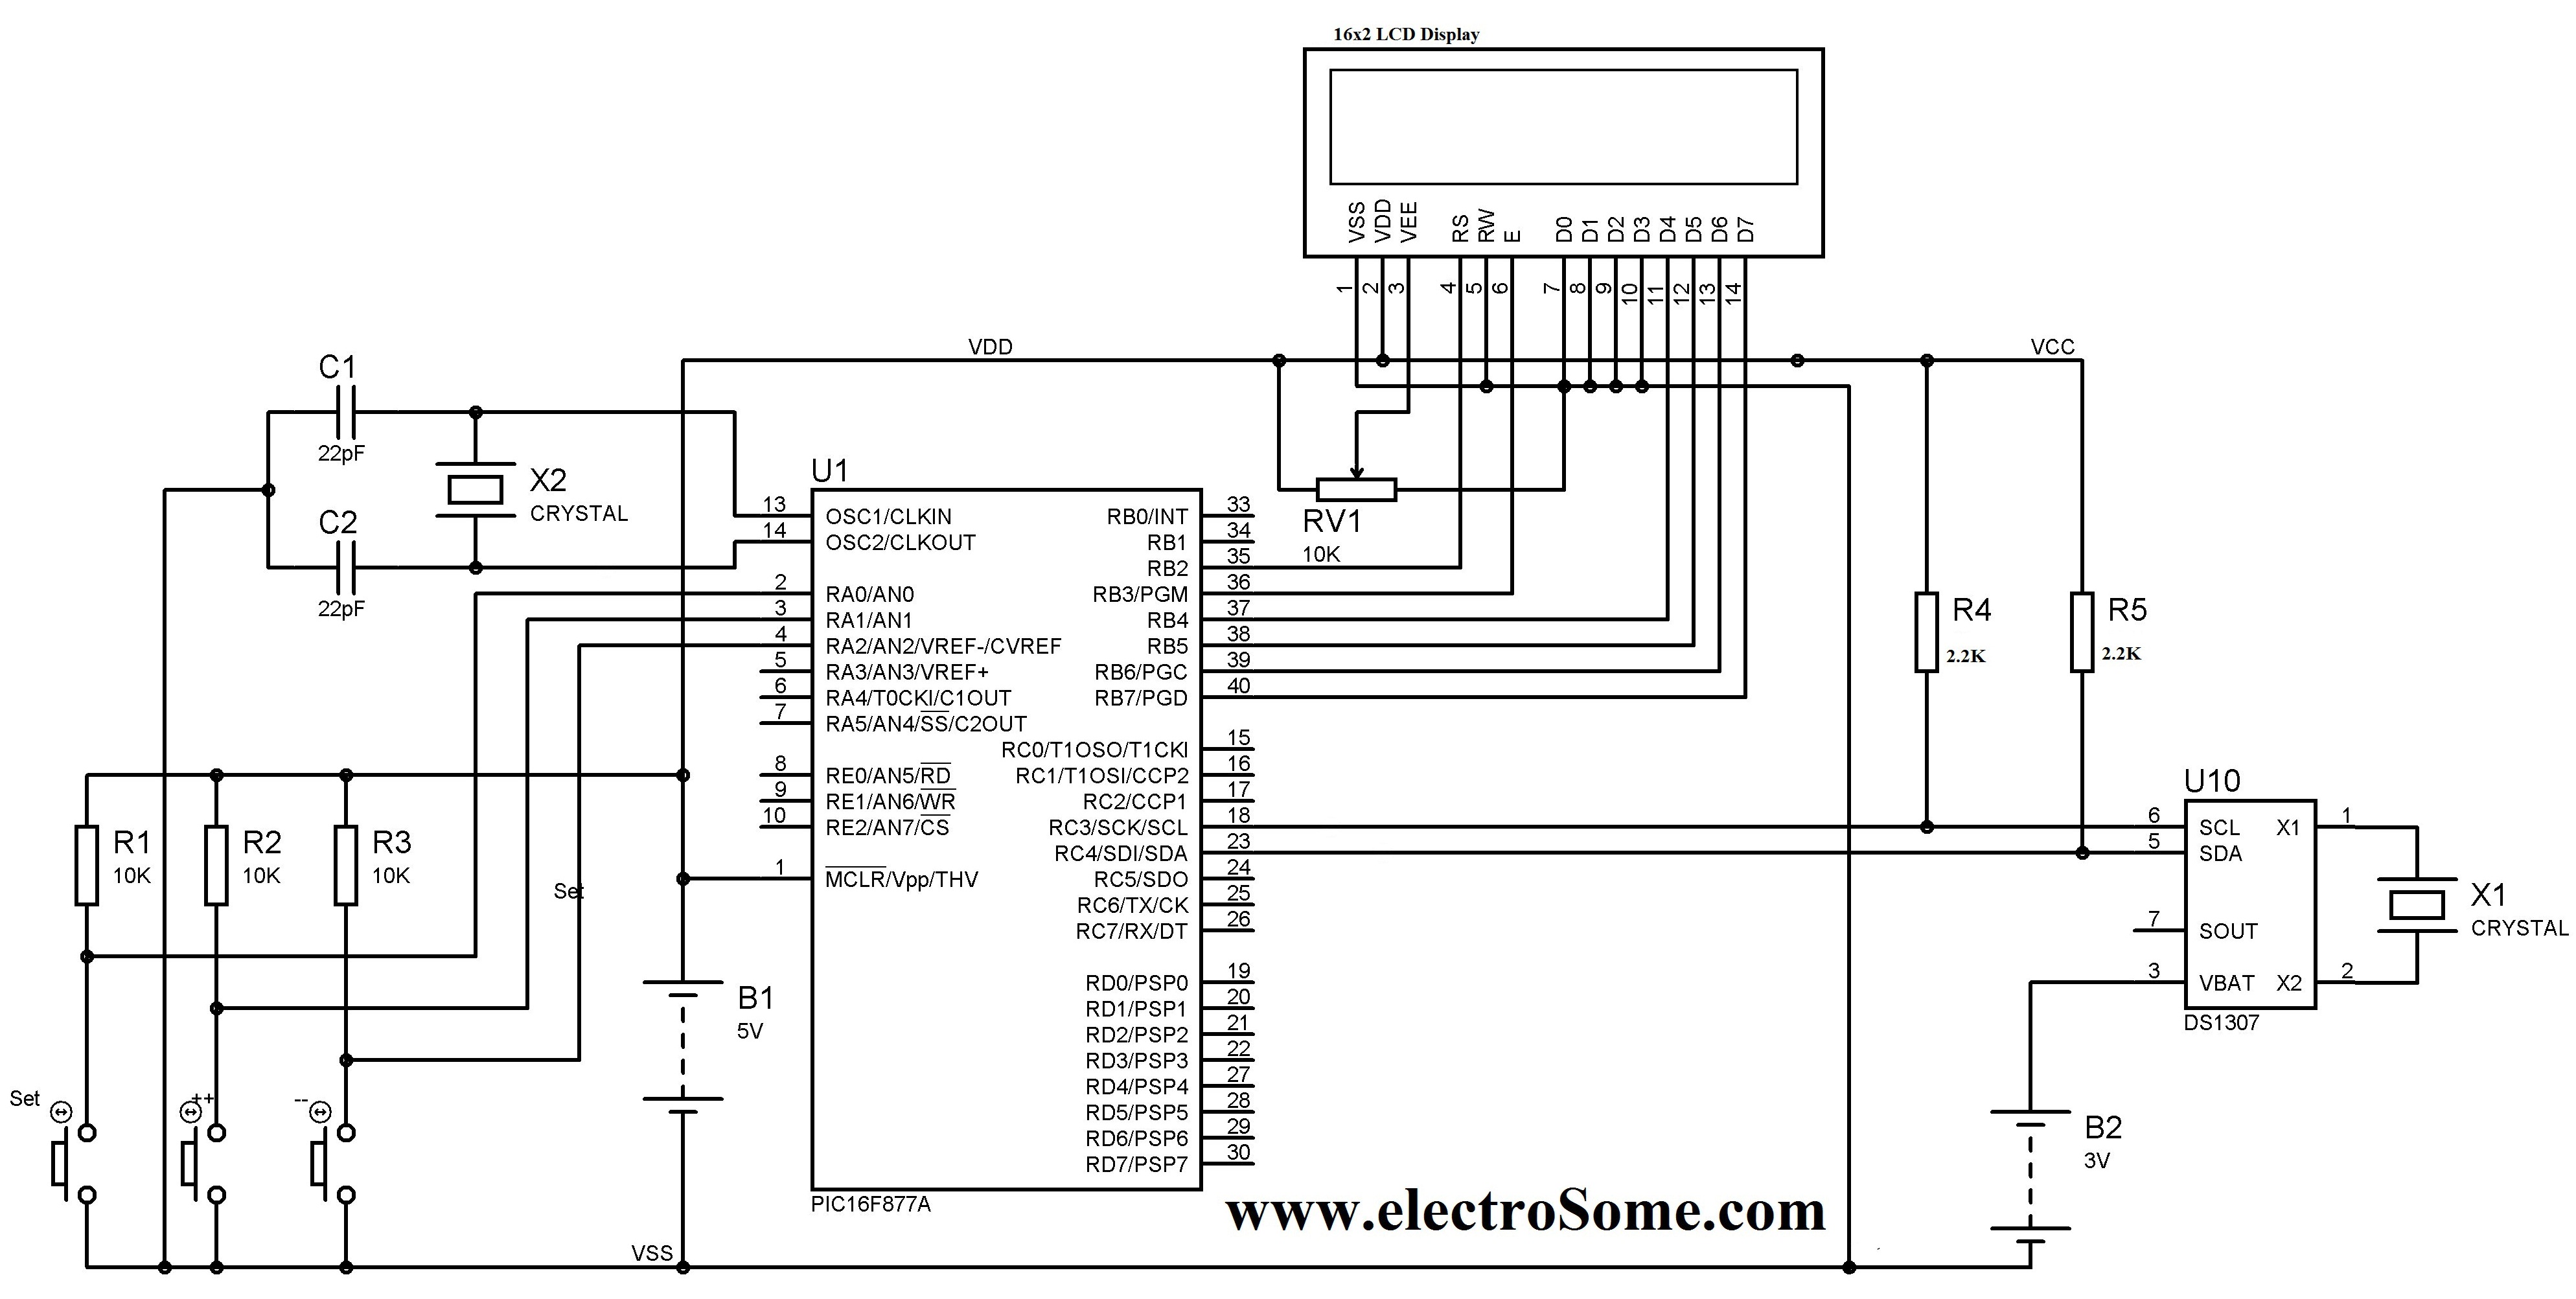
digital clock pic microcontroller ds1307
A digital clock can be constructed using a PIC microcontroller, DS1307 real-time clock (RTC), and a 16x2 LCD display. The DS1307 RTC operates in either 24-hour or 12-hour mode with an AM/PM indicator. It adjusts automatically for months with fewer...
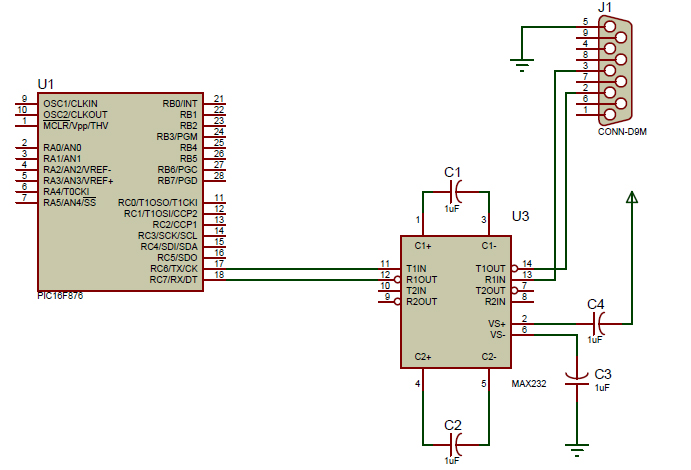
pic serial communition in pic microcontroller
An introductory post on how to use serial communication in PIC Microcontrollers to send data to a PC. When considering serial communication, the primary thought is the transmission of data in a sequential manner. Until now, the focus has been...
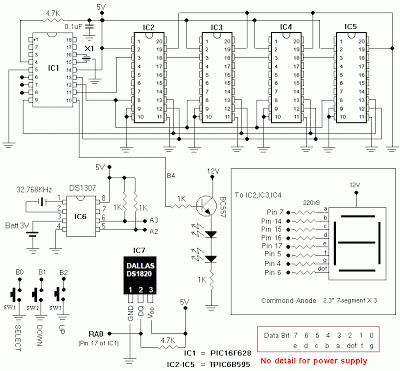
digital clock and temperature block
The diagram illustrates a block diagram for an agenda alarm and agenda thermometer system. It includes one temperature sensor, a real-time clock (RTC), a microcontroller (PIC), an EEPROM, a 7-segment display, and a keyboard. The EEPROM is utilized to expand...
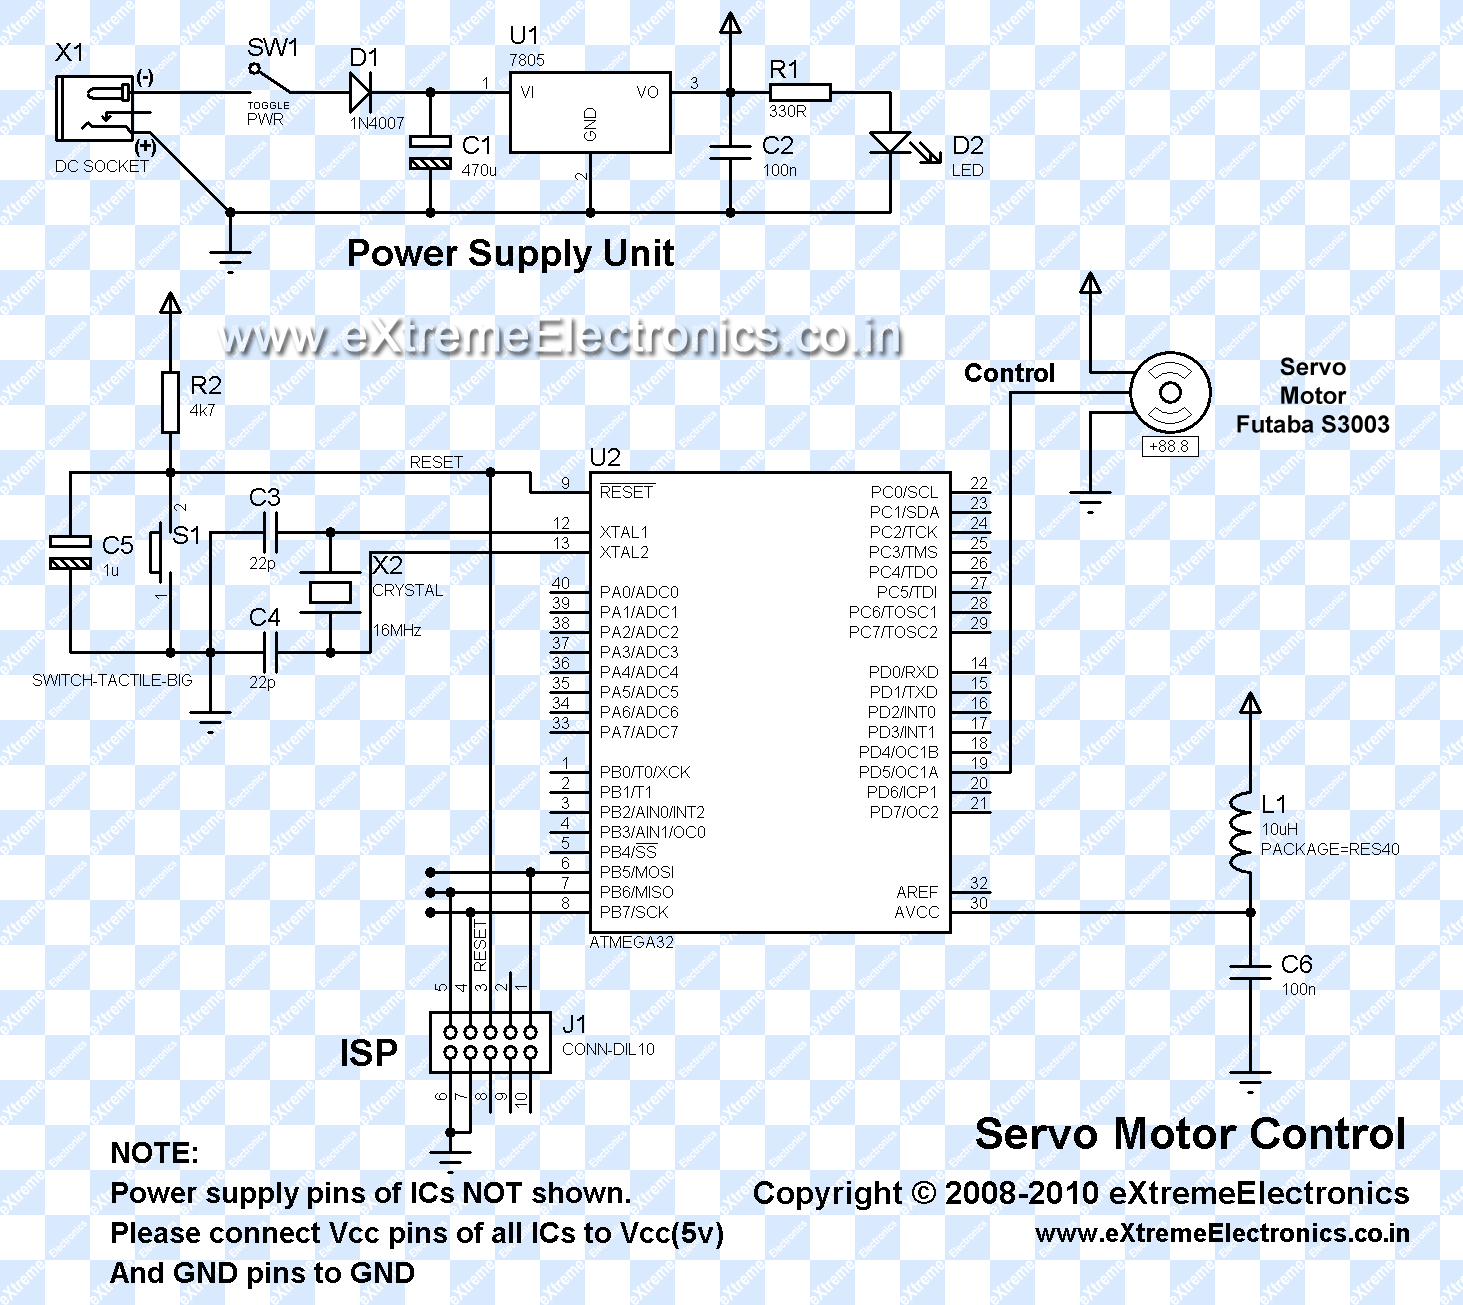
Servo Motor Control by Using AVR ATmega32 Microcontroller
This article is intended for complete beginners with servo motors. It provides an overview of the basic theory behind servo motors and offers detailed instructions on how to utilize them with AVR microcontrollers such as the ATmega32.
Servo motors are electromechanical...
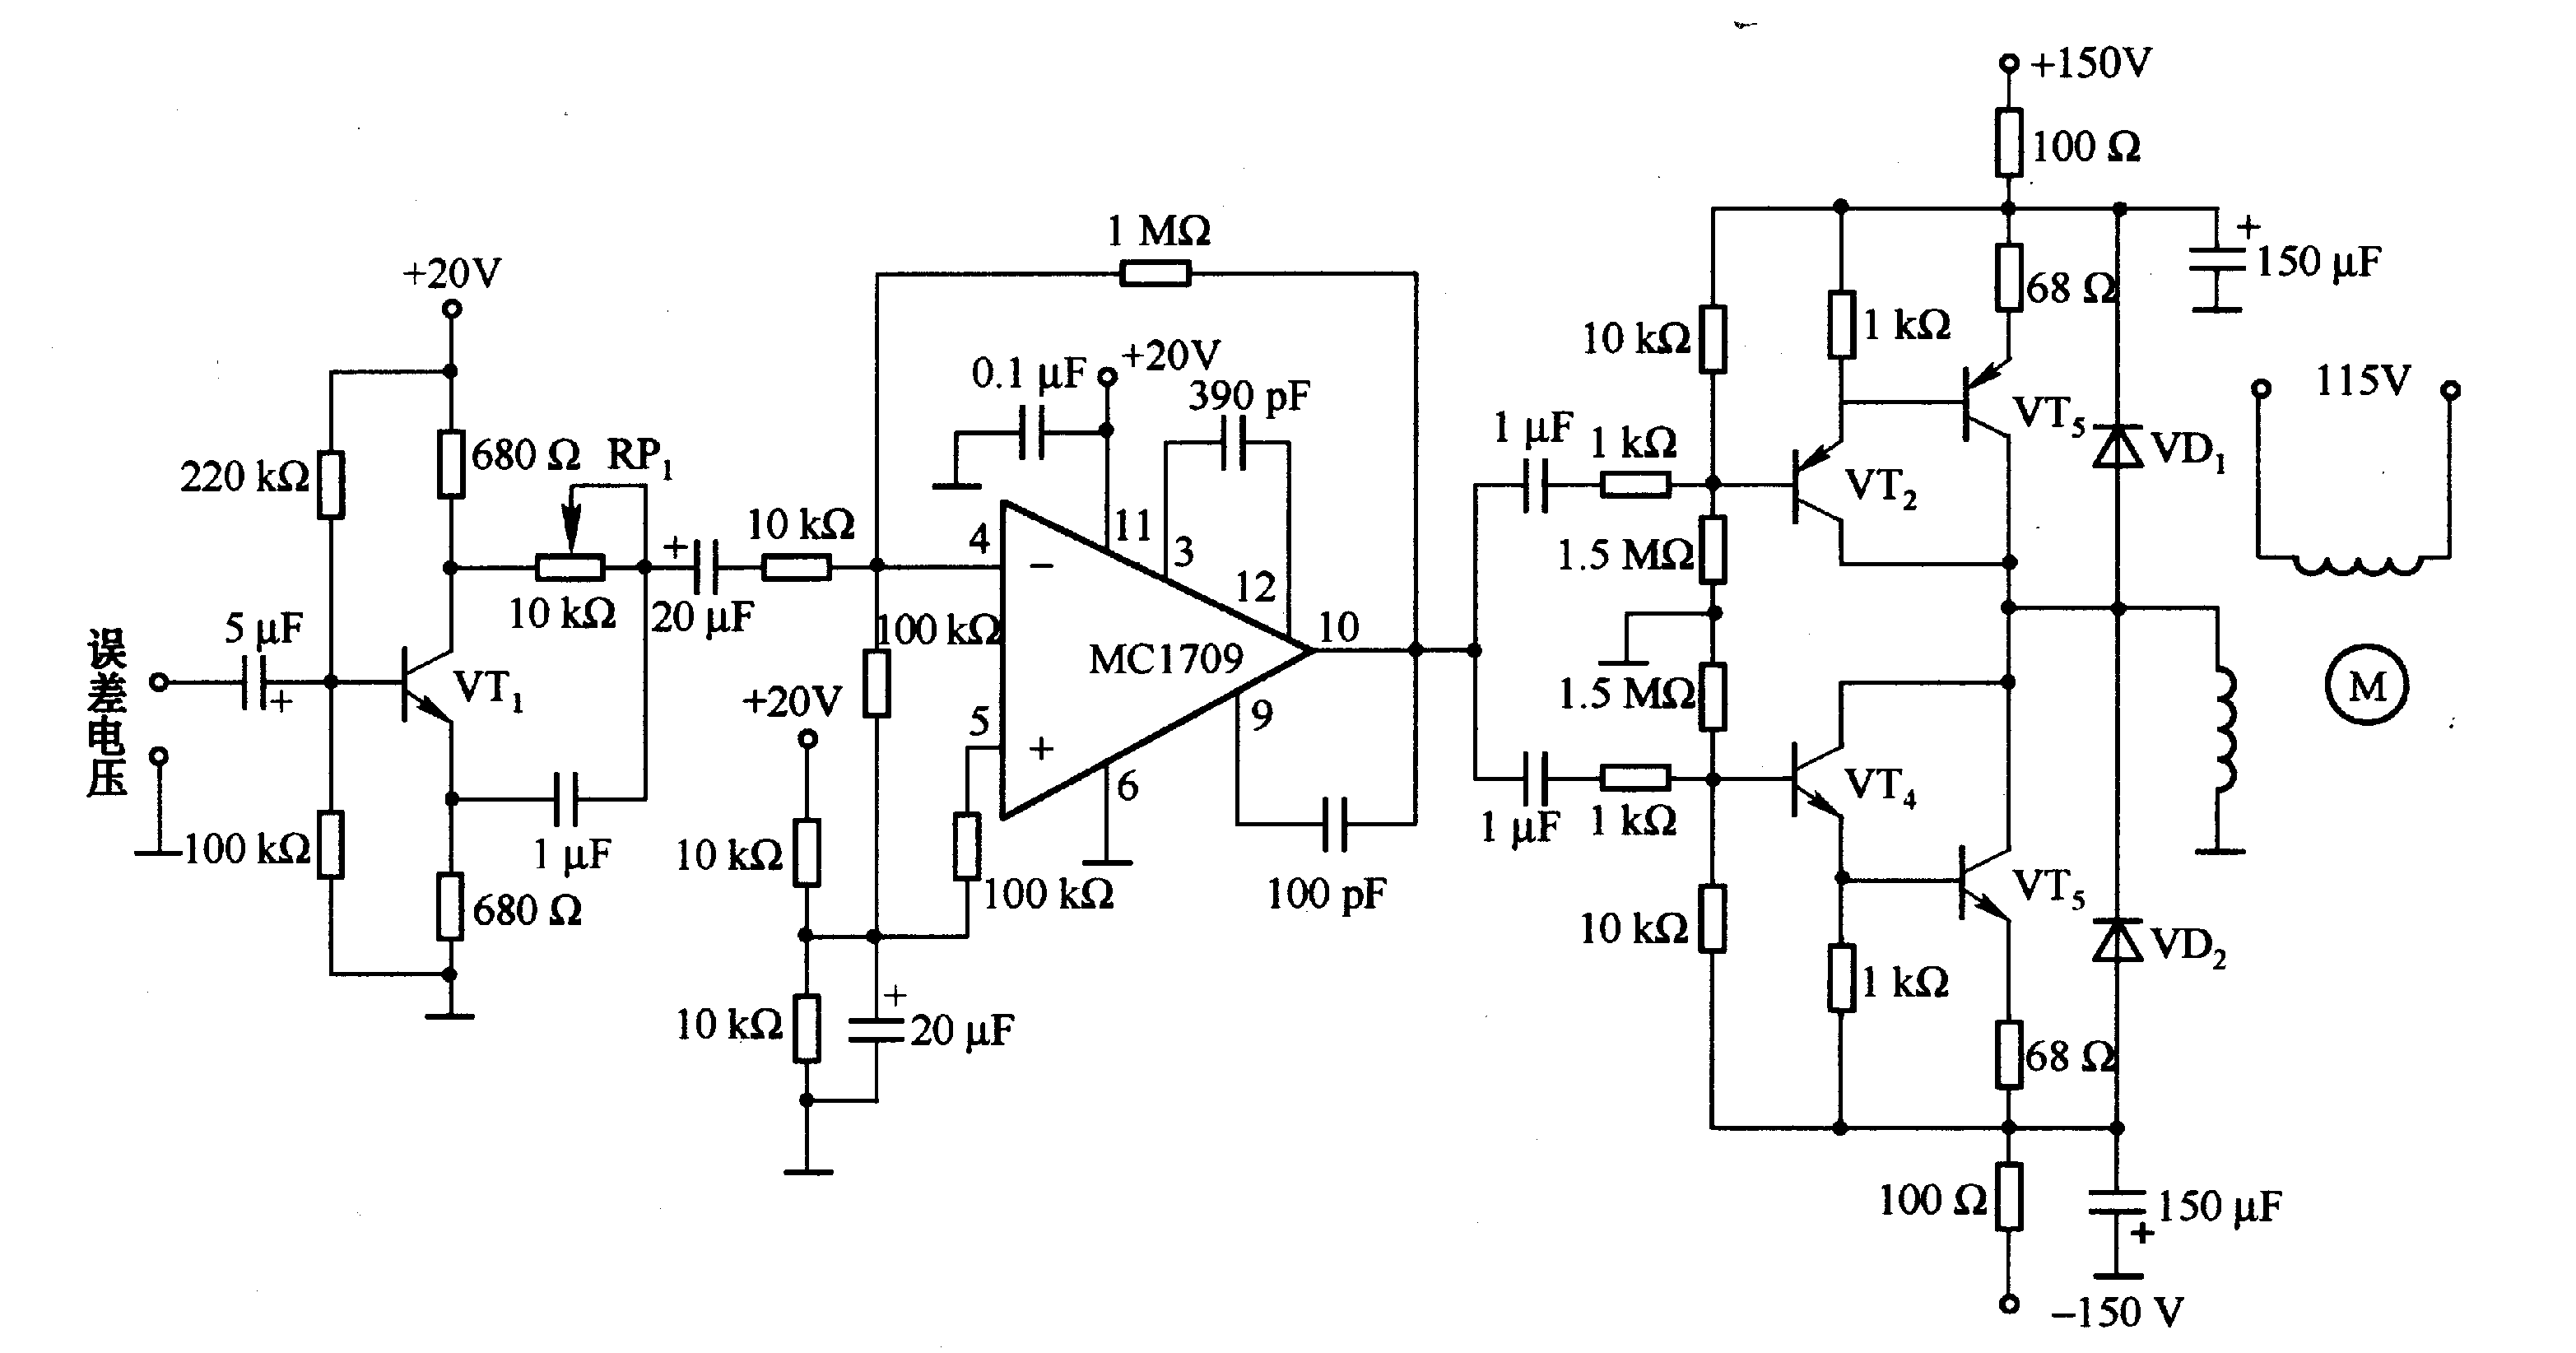
The control circuit of two-phase servo motor
A two-phase servo motor features a field winding and a control winding. When there is a 90° phase difference between the two, it generates rotational torque. A potentiometer connected to the motor shaft measures the voltage difference between the actual...
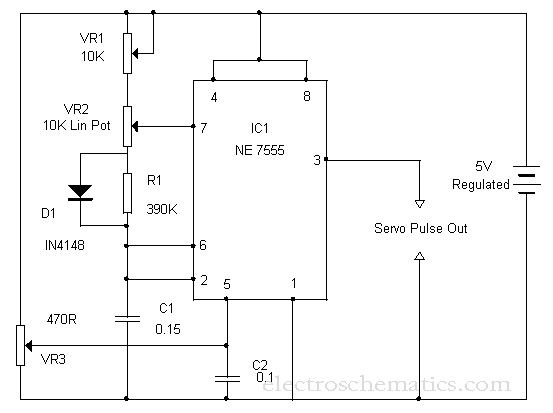
Servo Motor Controller Circuit
This is a simple basic design of a servo motor controller with a pulse generator. It utilizes the CMOS IC 7555 in astable mode to generate pulses for driving the motor.
The servo motor controller circuit employs the CMOS IC 7555...