


SAA1042 stepper motor control circuit
#stepper motor
#SAA1042
#12V drive
#current control
#phase winding
#motor driver
#RE resistor
#circuit diagram
#application example
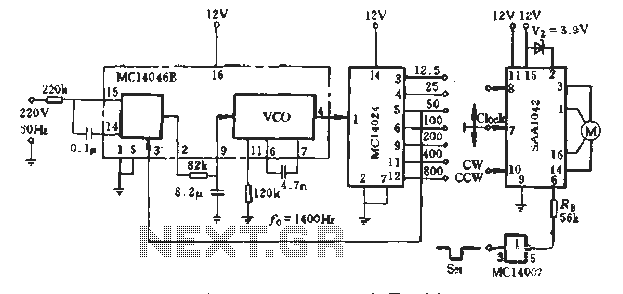
Description: A typical application example is presented, demonstrating the SAA1042 12V stepper motor drive configuration. The phase winding current is set at 200mA. According to RB Figure 5-10, a resistor value of RE = 56kΩ is selected. This resistor is connected to the output of the NAND gate MC14007. The clock signal is generated by the MC14046 and MC14024 PLL frequency synthesizer, producing a stepping clock frequency ranging from 12.5 to 500Hz, which allows for seven gear selections.
The SAA1042 stepper motor driver operates with a supply voltage of 12V, making it suitable for applications requiring precise control of motor positioning. The selection of a 200mA phase winding current indicates that the motor is designed to operate efficiently at this current level, ensuring optimal performance while minimizing power consumption and heat generation.
The resistor RE, valued at 56kΩ, plays a crucial role in setting the appropriate biasing conditions for the driver circuit, ensuring stable operation and preventing excessive current draw that could lead to overheating or damage. The integration of the NAND gate MC14007 facilitates logic operations essential for controlling the stepper motor's direction and stepping sequence.
The clock signal, generated by the MC14046 and MC14024 PLL frequency synthesizer, is vital for the timing of the stepper motor's operation. By producing a frequency range of 12.5 to 500Hz, the system allows for a variety of stepping speeds, enabling users to select from seven distinct gear ratios. This flexibility is particularly beneficial in applications requiring different levels of torque and speed, enhancing the overall versatility of the stepper motor system.
The design exemplifies a well-integrated approach to controlling stepper motors, utilizing standard components to achieve reliable and efficient motor control in various applications, from robotics to automated machinery.A typical application example shown, SAA1042 12V stepper drive motivation, phase winding current is taken as 200mA. Choose from the RB Figure 5-10, taking RE = 56kfl. It is connected to the output of NAND gate MC14007. Figure 5-9 clock by MC14046 and MC14024 PLL frequency synthesizer composition produced. Stepping clock in 12. 5- SOOHz carve seven gear selection.
The SAA1042 stepper motor driver operates with a supply voltage of 12V, making it suitable for applications requiring precise control of motor positioning. The selection of a 200mA phase winding current indicates that the motor is designed to operate efficiently at this current level, ensuring optimal performance while minimizing power consumption and heat generation.
The resistor RE, valued at 56kΩ, plays a crucial role in setting the appropriate biasing conditions for the driver circuit, ensuring stable operation and preventing excessive current draw that could lead to overheating or damage. The integration of the NAND gate MC14007 facilitates logic operations essential for controlling the stepper motor's direction and stepping sequence.
The clock signal, generated by the MC14046 and MC14024 PLL frequency synthesizer, is vital for the timing of the stepper motor's operation. By producing a frequency range of 12.5 to 500Hz, the system allows for a variety of stepping speeds, enabling users to select from seven distinct gear ratios. This flexibility is particularly beneficial in applications requiring different levels of torque and speed, enhancing the overall versatility of the stepper motor system.
The design exemplifies a well-integrated approach to controlling stepper motors, utilizing standard components to achieve reliable and efficient motor control in various applications, from robotics to automated machinery.A typical application example shown, SAA1042 12V stepper drive motivation, phase winding current is taken as 200mA. Choose from the RB Figure 5-10, taking RE = 56kfl. It is connected to the output of NAND gate MC14007. Figure 5-9 clock by MC14046 and MC14024 PLL frequency synthesizer composition produced. Stepping clock in 12. 5- SOOHz carve seven gear selection.
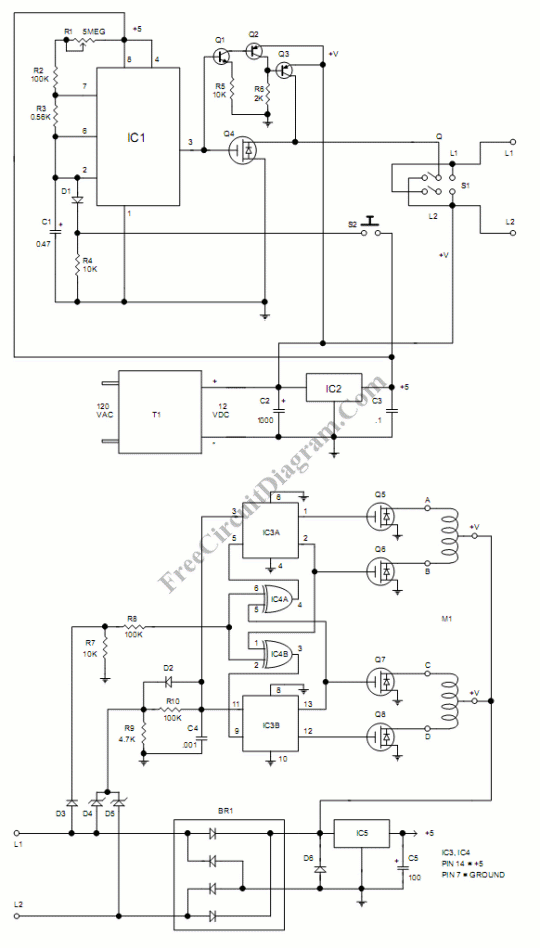
Stepper Motor Controller
A stepper motor provides a simple, low-cost, and precise method for position control. It can be driven by a circuit that is mounted near the motor and controlled by a microcontroller.
Stepper motors are widely utilized in applications requiring precise control...
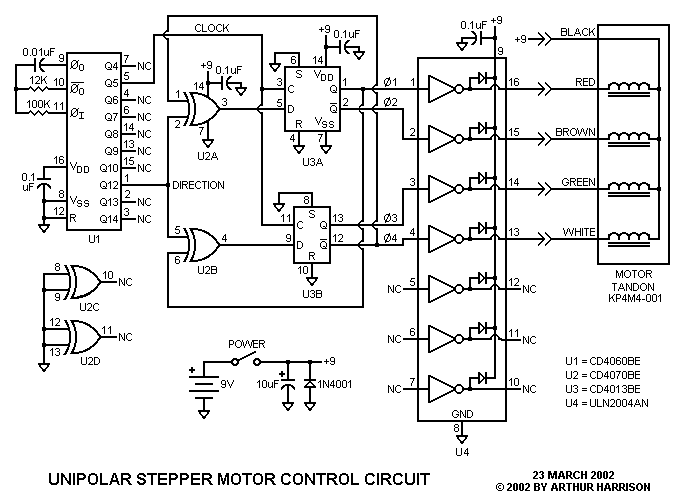
Unipolar Stepper Motor Control Circuit
This circuit controls a small, four-phase, five-wire, unipolar stepper motor, commonly designated as the "KP4M4-001." This type of motor was utilized in many 5 1/4" floppy disk drives in older computers. Although now obsolete, such disk drives are often available...
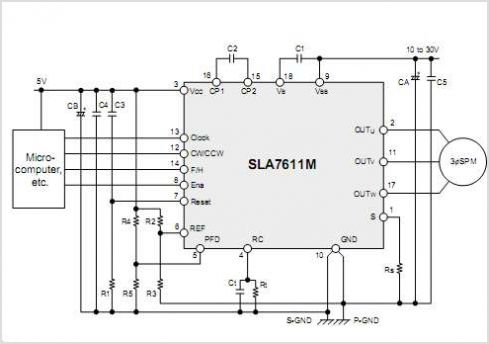
SLA7611M 3-Phase Stepper Motor Driver ICs
The SM5021 series consists of crystal oscillator module ICs fabricated using NPC's Molybdenum-gate CMOS technology. These ICs integrate high-frequency, low current consumption oscillator and output buffer circuits. They feature highly accurate thin-film feedback resistors and high-frequency capacitors, which eliminate the...
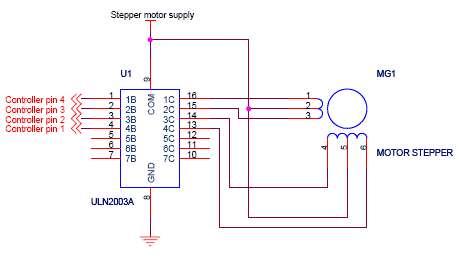
stepper motor interfacing connections
Stepper motor interfacing with a microcontroller. Full-step and half-step stepper control. Working principles and basics of stepper motors. Tutorial on 6-lead unipolar stepper motors and bipolar stepper motors.
Stepper motors are widely used in various applications requiring precise control of angular...
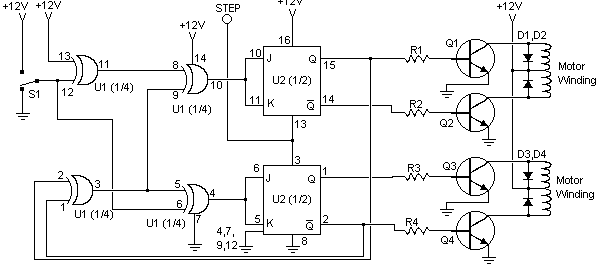
Stepper Motor Controller
I found this circuit in my files. I don't know where it came from, but it looks like I photocopied it from somewhere years ago. I have been told that it came from "The Robot Builder's Bonanza", by Gordan McComb....
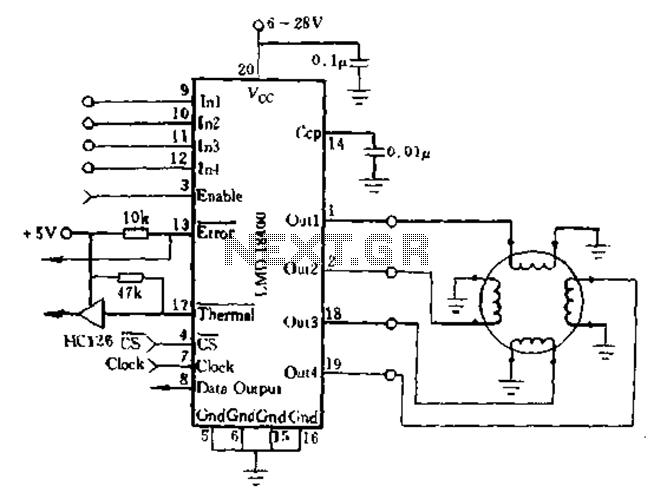
LMD18400 for four-phase stepper motor drive
The DMOS power switch exhibits an ON-state resistance with a positive temperature coefficient, allowing for the parallel connection of four switches to increase load current, resulting in a monolithic design. The LMD18400 can drive one, two, or four small DC...
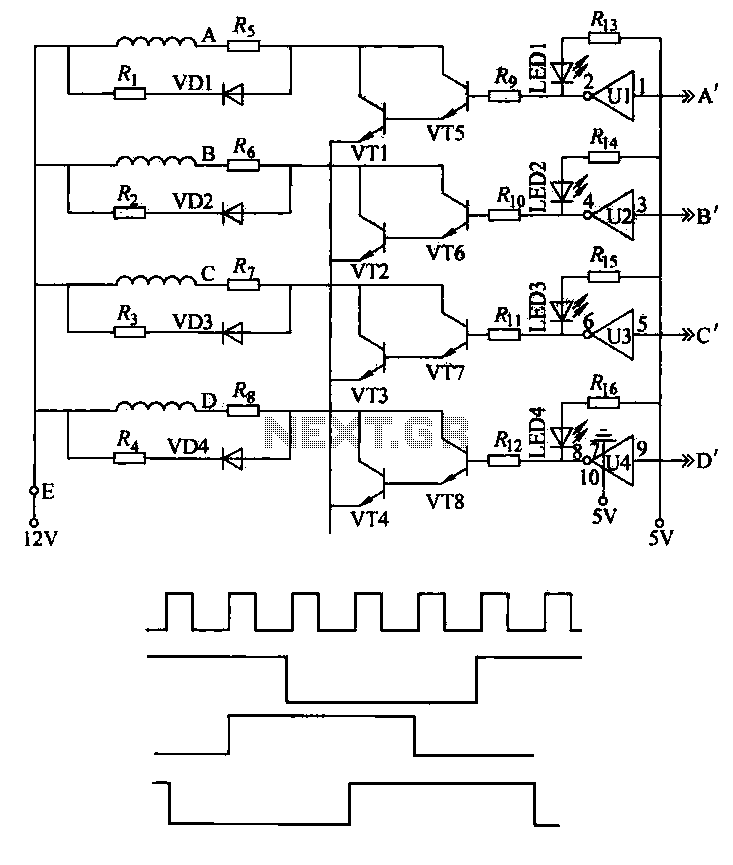
Stepper motor control circuit
This machine utilizes the FD-CAS-923 1-stepper motor control experiment board with a 4-phase stepper motor to avoid its schematic shown in Figure 4-42a. The JK1 cop 40 core flat cable connector allows for signal arrangements compatible with EICE51 simulation interfaces,...
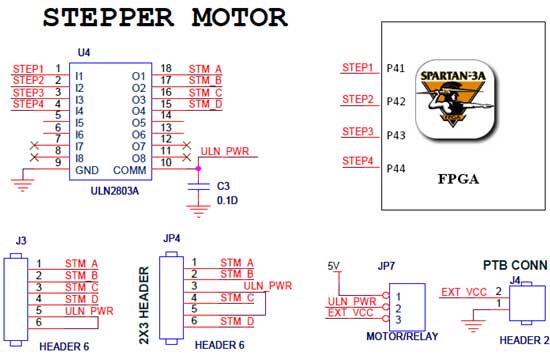
stepper motor interfacing with spartan 3an fpga
The Spartan-3an board features external interfacing for stepper motors, as illustrated in the accompanying figure. The stepper motor is driven by the ULN2803A, which is a high-voltage, high-current Darlington transistor array. The ULN2803 serves as a driver for the port...
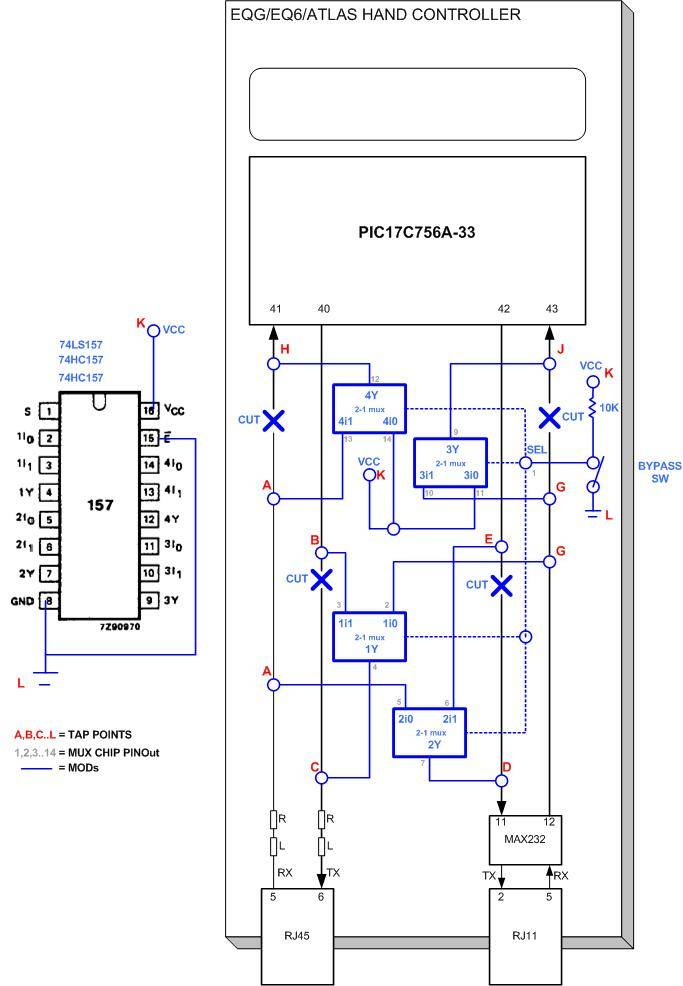
EQG MOD FOR DIRECT STEPPER MOTOR ACCESS
The modifications allow direct access to the stepper motor controls of the mount. Any erroneous commands or invalid data sent to the mount could inadvertently activate the stepper motors, leading to potential damage to connected equipment as the motors may...