


Unipolar Stepper Motor Control Circuit
#stepper motor
#unipolar
#KP4M4-001
#floppy disk drive
#surplus
#four-phase
#five-wire
#obsolete
#control circuit
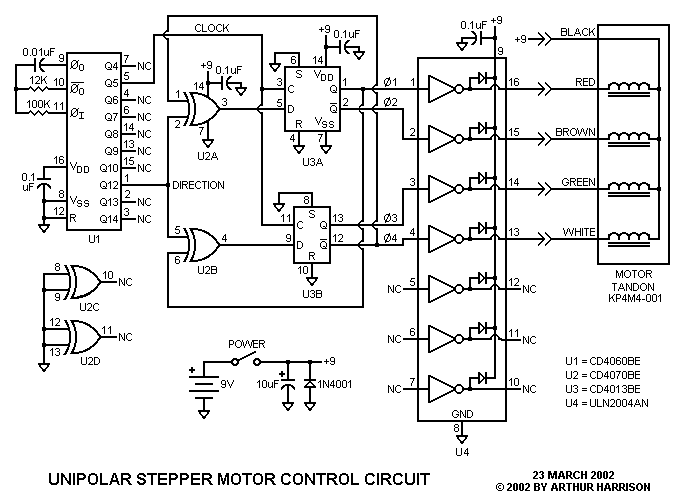
Description: This circuit controls a small, four-phase, five-wire, unipolar stepper motor, commonly designated as the "KP4M4-001." This type of motor was utilized in many 5 1/4" floppy disk drives in older computers. Although now obsolete, such disk drives are often available on the surplus market for a fraction of the motor's original cost. The stepper motors are easy to extract from the drives and are suitable for various applications. This arrangement was used in a scale model of a RADAR set to control the position of a miniature parabolic antenna. It is important to note that some 5 1/4" floppy disk drives used a four-wire "bipolar" motor, which is not compatible with this circuit. Referring to the schematic, U1 contains a relaxation oscillator and a binary ripple counter. The Q5 output of U1 provides a 100 Hertz square wave for the clock inputs of "D" flip-flops U3A and U3B. The Q12 output of U1 provides a level that alternates between "low" and "high" logic levels every 64 cycles of Q5. This signal is applied to the inputs of exclusive-or gates U2A and U2B. The flip-flops and gates form a quadrature waveform generator with complementary outputs. These waveforms are applied to U4, a set of Darlington drivers capable of providing the required sink current for the motor. The waveforms and their relationships are illustrated in the accompanying figure. The motor rotates one step, or 3.6 degrees, for each positive clock transition. Rotation occurs in one direction for 230.4 degrees (64 clock cycles x 3.6 degrees), and then reverses. Clockwise rotation occurs when the Q12 output of U1 is at a logic "high" level, and counterclockwise rotation occurs when it is "low." If desired, pins 2 and 5 of gates U2A and U2B may be disconnected from the counter and alternatively provided with an external direction control signal. The 12K timing resistor may be substituted with other values, with greater resistance decreasing the motor's speed. The maximum speed is determined by the motor's mechanical characteristics and load torque. For the prototype, operating at 9 volts, the clock frequency could be increased to 250 Hertz while still providing smooth operation. The circuit uses about 160 milliamperes at 9 volts, with the majority of the current consumed by the motor. Therefore, a power supply is recommended instead of a battery for continuous operation. The circuit will operate from 6 to 12 volts, depending on load torque and speed.
The circuit design is structured around a unipolar stepper motor, specifically the KP4M4-001 model. This motor operates through a four-phase system, which allows for precise control of its rotational position. The primary components include a relaxation oscillator and a binary ripple counter integrated within U1, which generates the necessary clock signals for the flip-flops. The Q5 output from U1 is critical as it produces a 100 Hertz signal, effectively driving the motor's step transitions.
The use of "D" flip-flops U3A and U3B is essential for maintaining the state of the motor control signals. These flip-flops receive the clock signal from U1 and output the necessary control signals that determine the direction and stepping of the motor. The complementary outputs generated by the exclusive-or gates U2A and U2B create the quadrature waveforms that are pivotal for the motor's operation. This configuration allows for smooth and controlled stepping of the motor, providing a reliable method for positioning applications such as in radar systems.
The Darlington drivers in U4 serve as the interface between the control signals and the motor, supplying the necessary current to drive the motor coils. This is crucial, as stepper motors require significant current to achieve the desired torque and speed. The relationship between the clock frequency and motor speed is also notable; increasing the clock frequency results in faster motor rotation, up to the limits defined by the motor's mechanical characteristics and load conditions.
The circuit is designed to be versatile, operating effectively within a voltage range of 6 to 12 volts. This flexibility allows for adjustments based on specific application requirements, including load torque and desired speed. The recommendation for a power supply over batteries for continuous operation underscores the current demands of the motor, which can draw up to 160 milliamperes at 9 volts. Overall, this circuit exemplifies a practical application of stepper motor technology in electronic control systems, providing a reliable solution for precise movement in various engineering and hobbyist projects.This circuit controls a small, four-phase, five-wire, unipolar stepper motor, commonly designated the "KP4M4-001. " This type of motor was used in many 5 1/4" floppy disk drives in older computers. Now obsolete, such disk drives are often available on the surplus market for a small fraction of the motor`s original cost.
The stepper motors are easy to extract from the drives, and are ideal for many applications. This arrangement was used in the scale model of a RADAR set to control the position of a miniature parabolic antenna. (Note that some 5 1/4" floppy disk drives used a four-wire "bipolar" motor, which is not compatible with this circuit.
) Referring to the schematic, U1 contains a relaxation oscillator and a binary ripple counter. U1`s Q5 output provides a 100 Hertz square wave for the clock inputs of "D" flip-flops U3A and U3B. U1`s Q12 output provides a level that alternates between "low" and "high" logic levels every 64 cycles of Q5. This signal is applied to the inputs of exclusive-or gates U2A and U2B. The flip-flops and gates form a quadrature waveform generator with complimentary outputs. These waveforms are applied to U4, a set of Darlington drivers capable of providing the required sink current for the motor.
The waveforms and their relationships are illustrated in the following figure. The motor rotates one step, or 3. 6 degrees, for each positive clock transition. Rotation occurs in one direction for 230. 4 degrees (64 clock cycles x 3. 6 degrees), and then reverses. Clockwise rotation occurs when U1`s Q12 output is a logic "high" level, and counterclockwise rotation occurs when it is "low. " If desired, pins 2 and 5 of gates U2A and U2B may be disconnected from the counter, and alternatively provided with an external direction control signal.
The 12K timing resistor may be substituted with other values, with greater resistance decreasing the motor`s speed. The maximum speed is determined by the motor`s mechanical characteristics and load torque. For the prototype, operating at 9 volts, the clock frequency could be increased to 250 Hertz, while still providing smooth operation.
The circuit uses about 160 milliamperes at 9 volts, with a majority of the current consumed by the motor. Therefore, a power supply is recommended in lieu of a battery if continuous operation is desired. The circuit will operate from 6 to 12 volts, depending on load torque and speed.
The circuit design is structured around a unipolar stepper motor, specifically the KP4M4-001 model. This motor operates through a four-phase system, which allows for precise control of its rotational position. The primary components include a relaxation oscillator and a binary ripple counter integrated within U1, which generates the necessary clock signals for the flip-flops. The Q5 output from U1 is critical as it produces a 100 Hertz signal, effectively driving the motor's step transitions.
The use of "D" flip-flops U3A and U3B is essential for maintaining the state of the motor control signals. These flip-flops receive the clock signal from U1 and output the necessary control signals that determine the direction and stepping of the motor. The complementary outputs generated by the exclusive-or gates U2A and U2B create the quadrature waveforms that are pivotal for the motor's operation. This configuration allows for smooth and controlled stepping of the motor, providing a reliable method for positioning applications such as in radar systems.
The Darlington drivers in U4 serve as the interface between the control signals and the motor, supplying the necessary current to drive the motor coils. This is crucial, as stepper motors require significant current to achieve the desired torque and speed. The relationship between the clock frequency and motor speed is also notable; increasing the clock frequency results in faster motor rotation, up to the limits defined by the motor's mechanical characteristics and load conditions.
The circuit is designed to be versatile, operating effectively within a voltage range of 6 to 12 volts. This flexibility allows for adjustments based on specific application requirements, including load torque and desired speed. The recommendation for a power supply over batteries for continuous operation underscores the current demands of the motor, which can draw up to 160 milliamperes at 9 volts. Overall, this circuit exemplifies a practical application of stepper motor technology in electronic control systems, providing a reliable solution for precise movement in various engineering and hobbyist projects.This circuit controls a small, four-phase, five-wire, unipolar stepper motor, commonly designated the "KP4M4-001. " This type of motor was used in many 5 1/4" floppy disk drives in older computers. Now obsolete, such disk drives are often available on the surplus market for a small fraction of the motor`s original cost.
The stepper motors are easy to extract from the drives, and are ideal for many applications. This arrangement was used in the scale model of a RADAR set to control the position of a miniature parabolic antenna. (Note that some 5 1/4" floppy disk drives used a four-wire "bipolar" motor, which is not compatible with this circuit.
) Referring to the schematic, U1 contains a relaxation oscillator and a binary ripple counter. U1`s Q5 output provides a 100 Hertz square wave for the clock inputs of "D" flip-flops U3A and U3B. U1`s Q12 output provides a level that alternates between "low" and "high" logic levels every 64 cycles of Q5. This signal is applied to the inputs of exclusive-or gates U2A and U2B. The flip-flops and gates form a quadrature waveform generator with complimentary outputs. These waveforms are applied to U4, a set of Darlington drivers capable of providing the required sink current for the motor.
The waveforms and their relationships are illustrated in the following figure. The motor rotates one step, or 3. 6 degrees, for each positive clock transition. Rotation occurs in one direction for 230. 4 degrees (64 clock cycles x 3. 6 degrees), and then reverses. Clockwise rotation occurs when U1`s Q12 output is a logic "high" level, and counterclockwise rotation occurs when it is "low. " If desired, pins 2 and 5 of gates U2A and U2B may be disconnected from the counter, and alternatively provided with an external direction control signal.
The 12K timing resistor may be substituted with other values, with greater resistance decreasing the motor`s speed. The maximum speed is determined by the motor`s mechanical characteristics and load torque. For the prototype, operating at 9 volts, the clock frequency could be increased to 250 Hertz, while still providing smooth operation.
The circuit uses about 160 milliamperes at 9 volts, with a majority of the current consumed by the motor. Therefore, a power supply is recommended in lieu of a battery if continuous operation is desired. The circuit will operate from 6 to 12 volts, depending on load torque and speed.
Stepper Motor Driver Carrier with Voltage Regulator
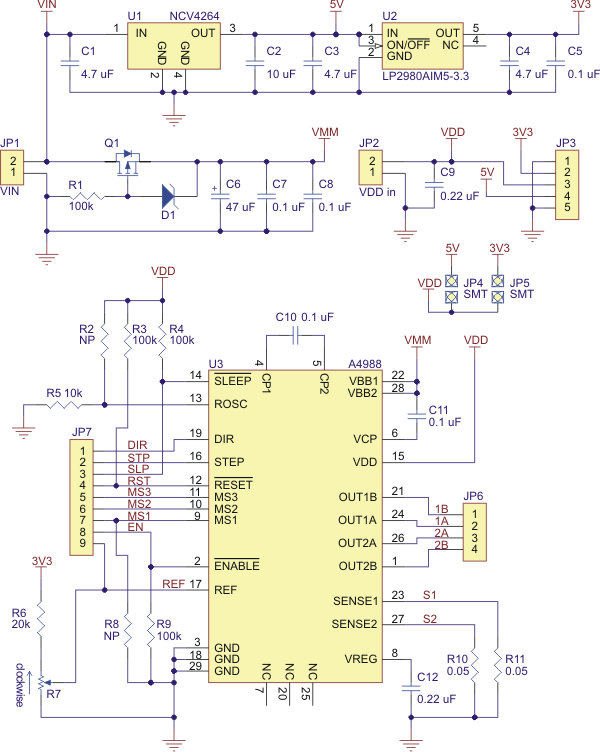
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
EQG MOD FOR DIRECT STEPPER MOTOR ACCESS
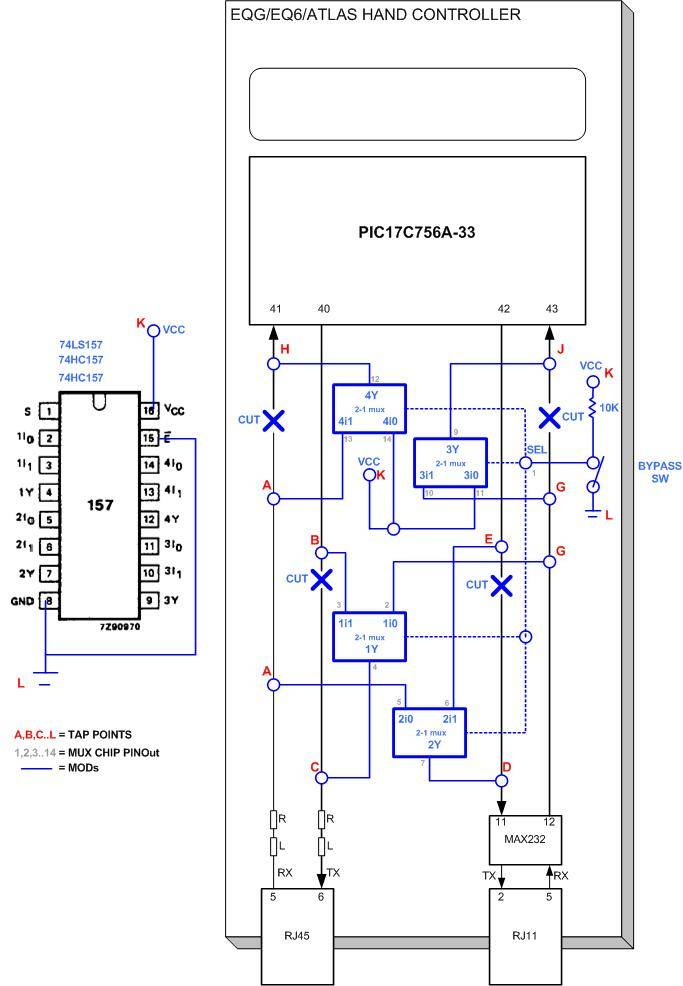
The modifications allow direct access to the stepper motor controls of the mount. Any erroneous commands or invalid data sent to the mount could inadvertently activate the stepper motors, leading to potential damage to connected equipment as the motors may...
A Unipolar Stepper Motor Drive Using The Z8 Encore! ?® Mcu
NEC's UPB1008K is a Silicon RFIC specifically designed for handheld low-power, low-cost GPS receivers. The integrated circuit combines a low-noise amplifier (LNA) followed by a double-conversion RF/IF downconverter block and a phase-locked loop (PLL) frequency synthesizer on a single chip....
circuit explanation of stepper motor
A Darlington connection-type transistor is utilized for driving the coil. In this configuration, two stages of transistors are connected in series, resulting in a high current gain, where the "hfe" of the Darlington transistor is the product of the "hfe"...
Pick
The second component is a Signal Distribution Board that transmits voltage, ground, and various signals throughout the system. This board is based on the design found on its dedicated page: Signal Distribution Board. The 7400 pick system is equipped with...
DIY Stepper Controller Circuit
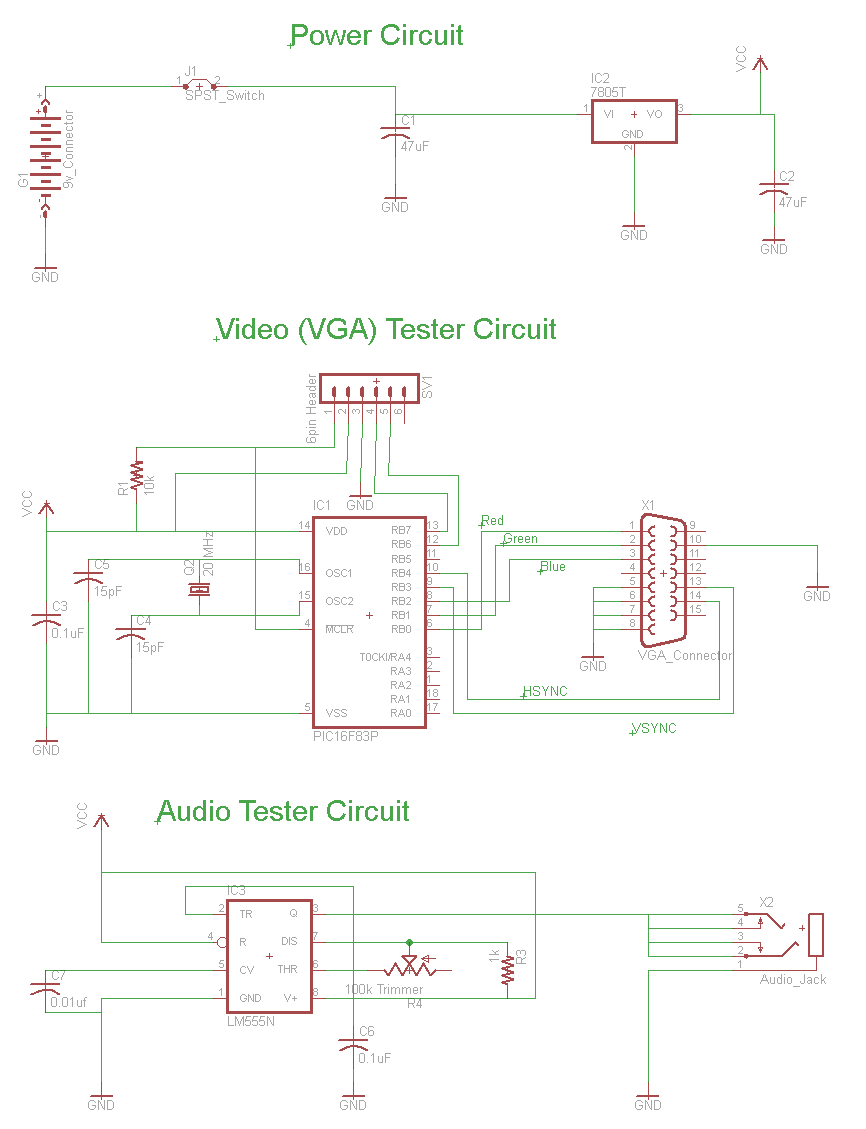
The schematic for the board is illustrated below. The three primary components of the board include (1) the power input and voltage regulation, (2) the L297 input and outputs, and (3) the L298 stepper motor control circuit. The motor is...
Switchmode Constant Current Source
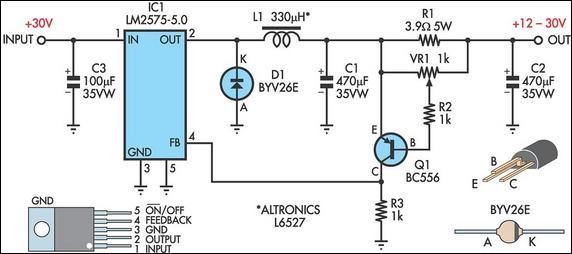
Operating a stepper motor with a fixed (constant) voltage supply leads to inadequate torque at high speeds, often causing the motor to stall at relatively low speeds. To address this issue, various solutions can be implemented, one of which involves...
Two Wires-Stepper Motor Controller
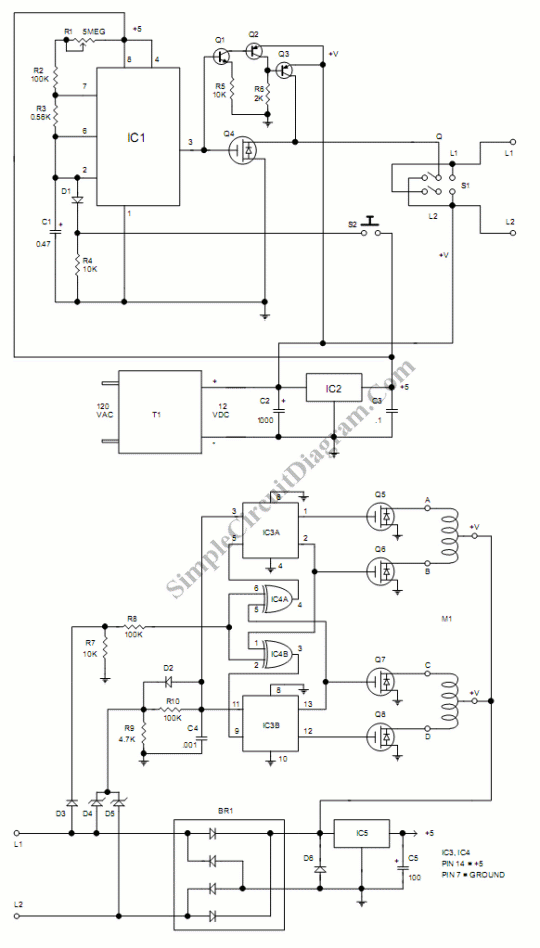
To achieve a low-cost, accurate, and simple position control system, a stepper motor can be utilized. A circuit designed to drive the motor should be mounted in proximity to the motor itself.
Stepper motors are widely employed in applications requiring precise...
control motor controller stepper
If the control circuit of this motor driver is based on a microcontroller or digital component, it is advisable to implement a buffer for each port that controls the stepper motor driver. This precaution helps prevent overloading the microcontroller ports....