


Pwm-motor-controller
#PWM
#motor controller
#SN75603
#SN75604
#full-bridge
#bidirectional control
#timer
#FET current-regulator diode
#astable mode
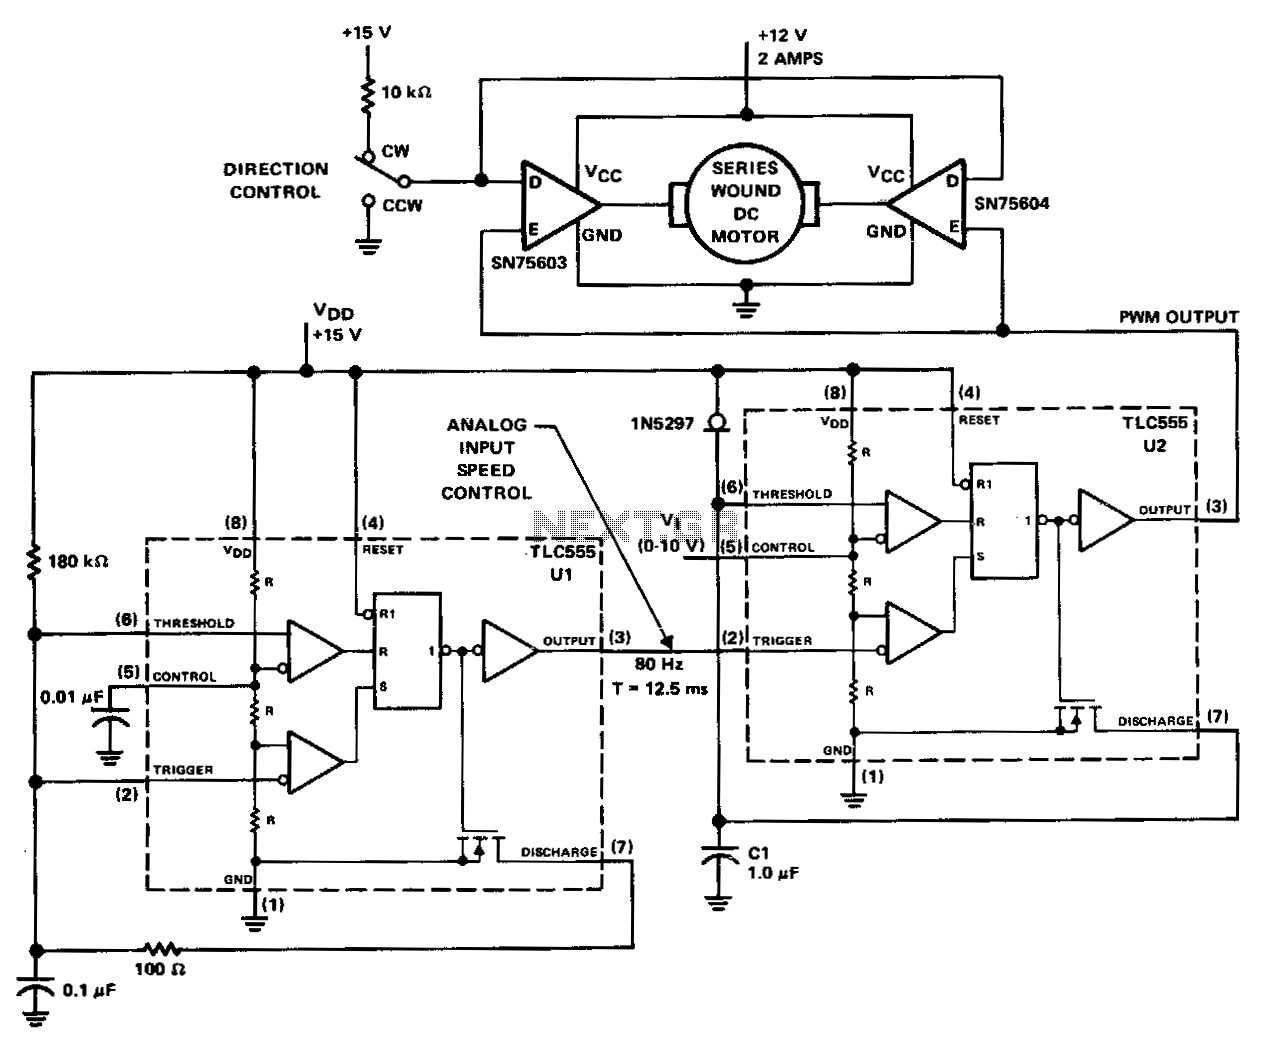
Description: The PWM controller utilizes complementary half-H peripheral drivers SN75603 and SN75604, featuring totem-pole outputs rated at 40 V and 2.0 A. These drivers effectively configure the motor in a full-bridge setup, enabling bidirectional control. Timer U1 operates in astable mode at a frequency of 80 Hz. The 100-ohm discharge resistor results in an 8-microsecond trigger pulse, which is coupled to the trigger input of timer U2. Timer U2 functions as the PWM generator. Capacitor C1 is charged linearly with a constant current of 1 mA from the 1N5297, a FET current-regulator diode. Motor speed is controlled by supplying a DC voltage of 0 to 10 V to control input pin 5 of U2. As the control voltage increases, the width of the output pulse at pin 3 also increases. These pulses manage the on/off time of the two motor drivers. The trigger pulse width from timer U1 limits the minimum possible duty cycle from U2.
The PWM (Pulse Width Modulation) controller circuit is designed to provide effective motor control through a full-bridge configuration, utilizing the SN75603 and SN75604 drivers. This configuration allows for efficient bi-directional operation of the motor, making it suitable for applications requiring precise speed and direction control.
The core of the circuit is based on two timers, U1 and U2. Timer U1 is configured in astable mode, generating a continuous square wave signal at a frequency of 80 Hz. The output pulse from U1 is determined by the resistor-capacitor (RC) timing network, specifically a 100-ohm resistor that discharges to create an 8-microsecond pulse. This pulse is critical as it serves as a trigger for timer U2, which is responsible for generating the PWM signal.
Timer U2 operates as a PWM generator, where the duty cycle can be adjusted based on the control voltage applied to its input pin 5. The input voltage can range from 0 to 10 V, allowing for fine control over the motor speed. As the control voltage increases, the output pulse width from U2 at pin 3 also increases, effectively controlling the motor drivers' on and off states.
Capacitor C1 plays a significant role in this circuit by being charged linearly through a constant current of 1 mA supplied by the 1N5297 FET current-regulator diode. This linear charging ensures that the PWM signal can be modulated accurately, leading to a smooth and responsive motor speed adjustment.
Overall, this PWM controller design is effective for applications requiring precise motor control, with the ability to adjust speed and direction efficiently through a straightforward voltage control mechanism. The integration of the timers and the drivers ensures reliable operation and performance in various electronic motor control systems.The PWM controller uses complementary half-H peripheral drivers SN75603 and SN75604, with totem-pole outputs rated at 40 V and 2.0 A. These drivers effectively place the motor in a full-bridge configuration, which has the ability to provide bidirectional control.
Timer U1 operates in the astable mode at a frequency of 80Hz. The 100-0 discharge resistor results in an 8-p.s trigger pulse which is coupled to the trigger input of timer U2. Timer U2 serves as the PWM generator. Capacitor C1 is charged linearly with a constant current of 1 mA from the 1N5297, which is an FET current-regulator diode.
Motor speed is controlled by feeding a de voltage of 0 to 10 V to control input pin 5 of U2. As the control voltage increases, the width of the output pulse pin 3 also increases. These pulses controLthe on/ off time of the two motor drivers. The trigger pulse width of timer U1 limits the minimum possible duty cycle from U2.
The PWM (Pulse Width Modulation) controller circuit is designed to provide effective motor control through a full-bridge configuration, utilizing the SN75603 and SN75604 drivers. This configuration allows for efficient bi-directional operation of the motor, making it suitable for applications requiring precise speed and direction control.
The core of the circuit is based on two timers, U1 and U2. Timer U1 is configured in astable mode, generating a continuous square wave signal at a frequency of 80 Hz. The output pulse from U1 is determined by the resistor-capacitor (RC) timing network, specifically a 100-ohm resistor that discharges to create an 8-microsecond pulse. This pulse is critical as it serves as a trigger for timer U2, which is responsible for generating the PWM signal.
Timer U2 operates as a PWM generator, where the duty cycle can be adjusted based on the control voltage applied to its input pin 5. The input voltage can range from 0 to 10 V, allowing for fine control over the motor speed. As the control voltage increases, the output pulse width from U2 at pin 3 also increases, effectively controlling the motor drivers' on and off states.
Capacitor C1 plays a significant role in this circuit by being charged linearly through a constant current of 1 mA supplied by the 1N5297 FET current-regulator diode. This linear charging ensures that the PWM signal can be modulated accurately, leading to a smooth and responsive motor speed adjustment.
Overall, this PWM controller design is effective for applications requiring precise motor control, with the ability to adjust speed and direction efficiently through a straightforward voltage control mechanism. The integration of the timers and the drivers ensures reliable operation and performance in various electronic motor control systems.The PWM controller uses complementary half-H peripheral drivers SN75603 and SN75604, with totem-pole outputs rated at 40 V and 2.0 A. These drivers effectively place the motor in a full-bridge configuration, which has the ability to provide bidirectional control.
Timer U1 operates in the astable mode at a frequency of 80Hz. The 100-0 discharge resistor results in an 8-p.s trigger pulse which is coupled to the trigger input of timer U2. Timer U2 serves as the PWM generator. Capacitor C1 is charged linearly with a constant current of 1 mA from the 1N5297, which is an FET current-regulator diode.
Motor speed is controlled by feeding a de voltage of 0 to 10 V to control input pin 5 of U2. As the control voltage increases, the width of the output pulse pin 3 also increases. These pulses controLthe on/ off time of the two motor drivers. The trigger pulse width of timer U1 limits the minimum possible duty cycle from U2.
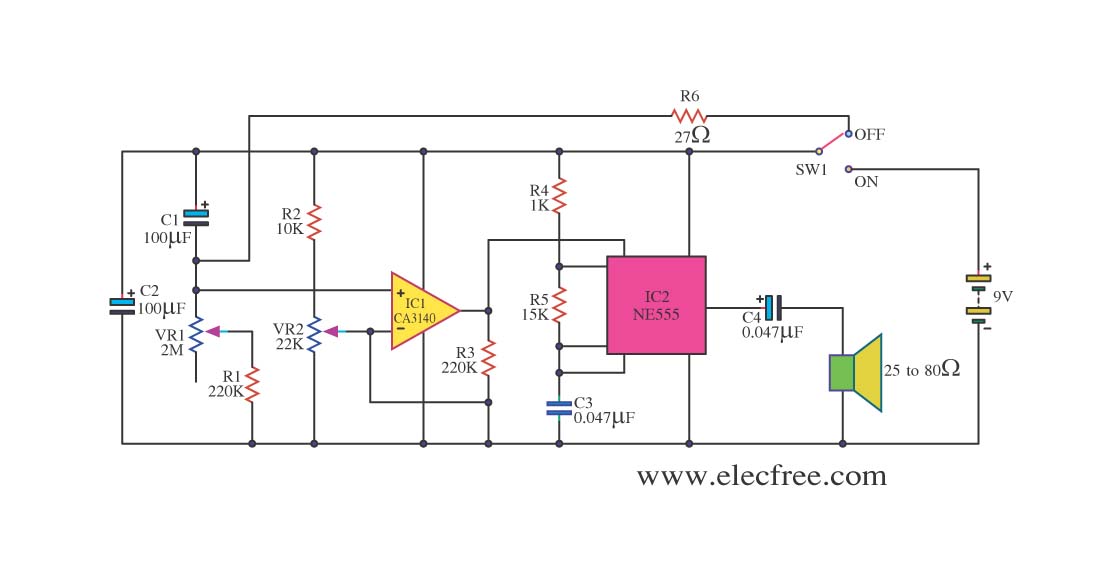
Simple Timer by CA3140 + NE555
This circuit sets the time using a simple model that can accurately maintain the time over extended periods. It employs the CA3140 integrated circuit for its functionality.
The circuit utilizes the CA3140 operational amplifier, which is known for its high precision...
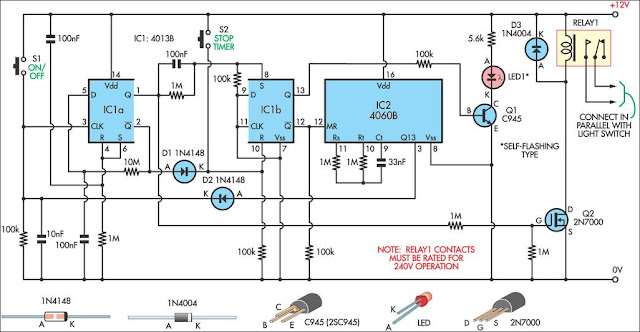
Switch Timer For Bathroom Light
This 9-minute timer switch is designed to control lighting in a toilet or bathroom. The timer is activated by pressing switch S1 and deactivated by pressing S1 again. If the switch is not turned off, the light will automatically turn...
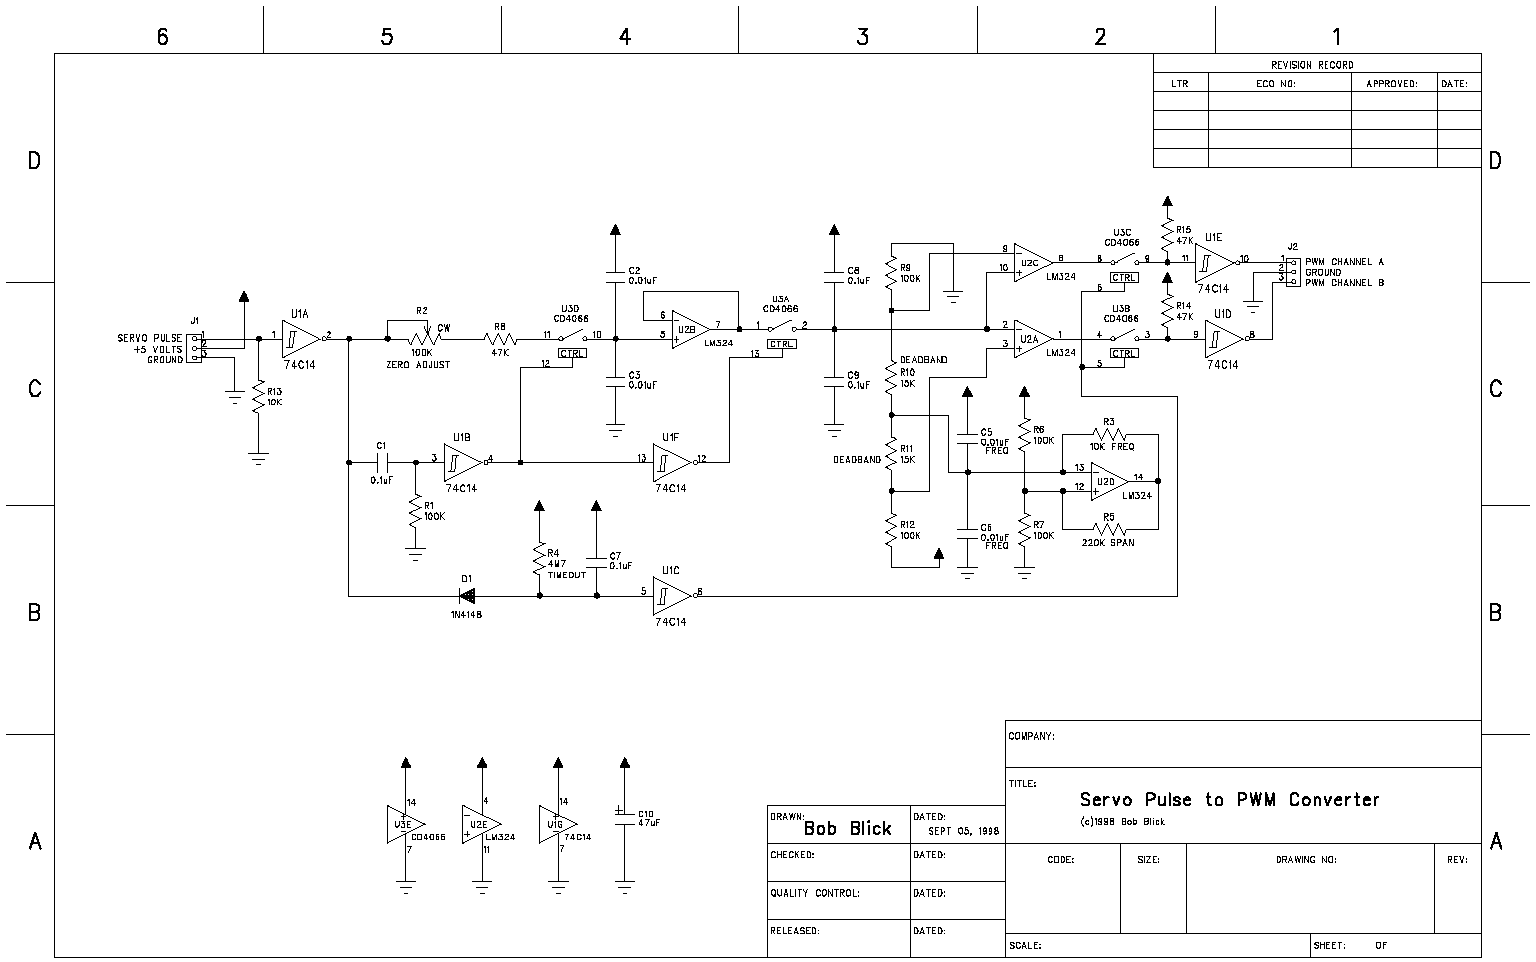
Servo pulse to PWM converter
The circuit presented on this page attempts to be an interface to convert pulses such as provided by a Basic Stamp or R/C receiver to a dual PWM (Pulse Width Modulation) signal required by an H-bridge. The simplest circuit would...
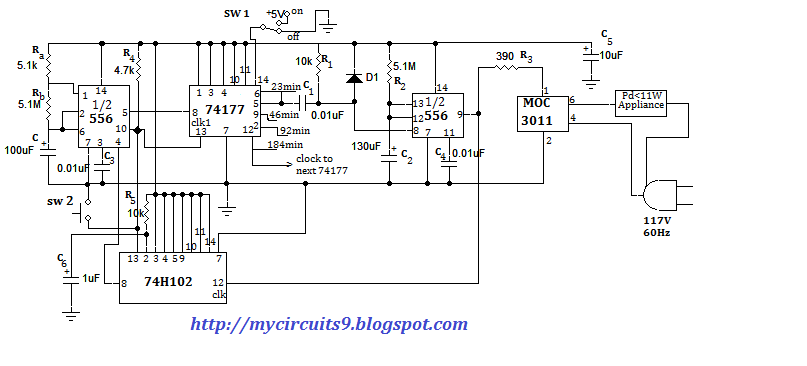
APPLIANCE CONTROL USING TIMER - PROJECT
This document presents an electronic project focused on device control using a timer. This circuit allows for the activation of an appliance at a specified time for a predetermined duration. It can be applied to manage the operation of systems...
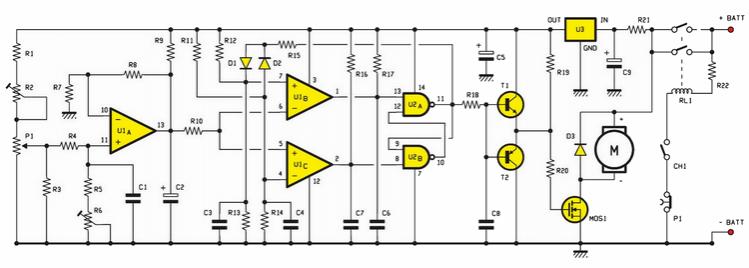
PWM circuit
An electric scooter and E-Bike PWM speed controller circuit has been constructed. However, the oscillator is not functioning as intended. The printed circuit board has been checked and is confirmed to be in good condition, including all resistors.
The electric scooter...
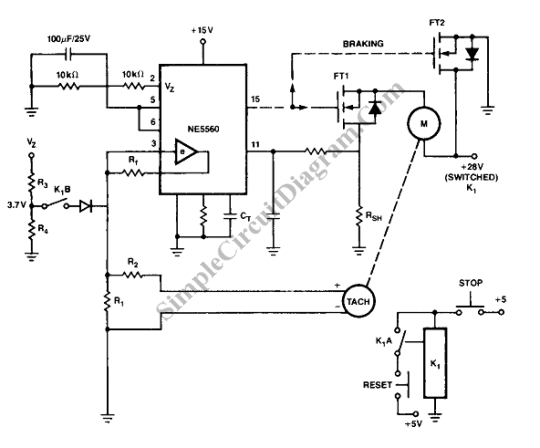
Constant Speed PWM Motor Control
A constant speed motor control can be achieved using closed-loop (servo) control. A constant speed motor maintains a steady speed regardless of variations in load.
In a closed-loop control system, feedback is utilized to compare the actual speed of the motor...
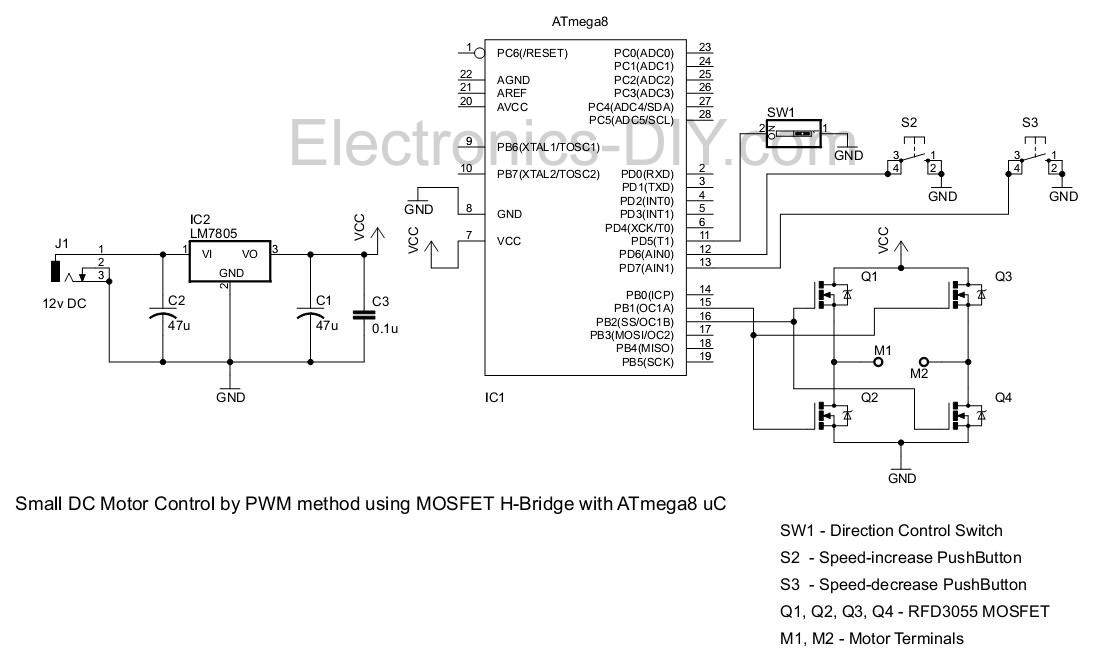
PWM Motor Driver with MOSFET H-Bridge and AVR ATmega8
This project involves controlling a small DC motor, sourced from an old personal cassette player, using the ATmega8 microcontroller. The ATmega8 features three PWM channels, of which two are utilized in this application. The PWM signals are sent to a...
really need help on PWM and PPM circuit
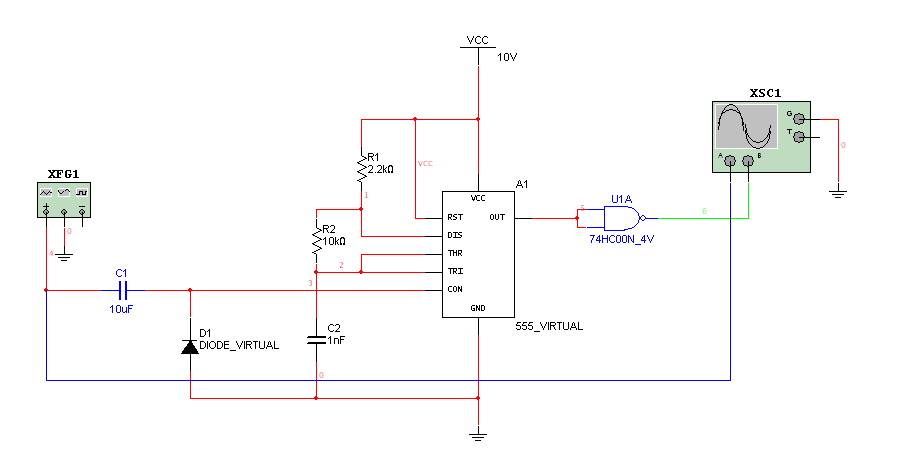
Hello everyone. I need some help. I have constructed a PWM and PPM circuit. The output is functioning smoothly, but I am experiencing some problems and I am not very experienced.
The PWM (Pulse Width Modulation) and PPM (Pulse Position Modulation)...
Furnace Fuel Miser Circuit
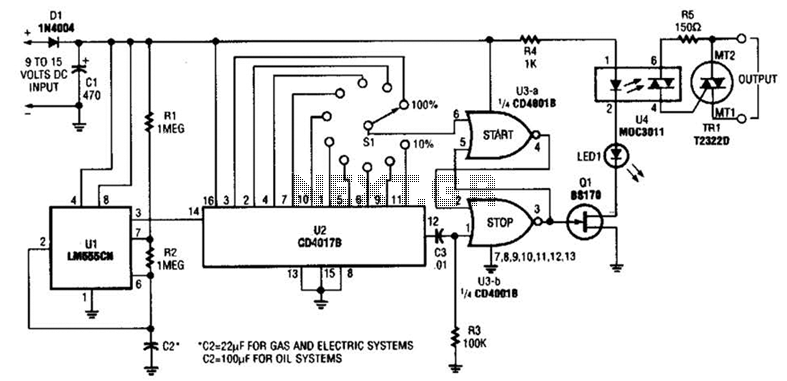
A timer (LM555CN) and decode counter are utilized to generate duty cycles ranging from 10% to 100% for controlling the operational time of a heating system. V2 operates as a decode counter that can be adjusted for duty cycles between...