


Constant Speed PWM Motor Control
#PWM
#closed loop
#servo control
#constant speed
#motor driver
#feedback control
#load regulation
#speed control
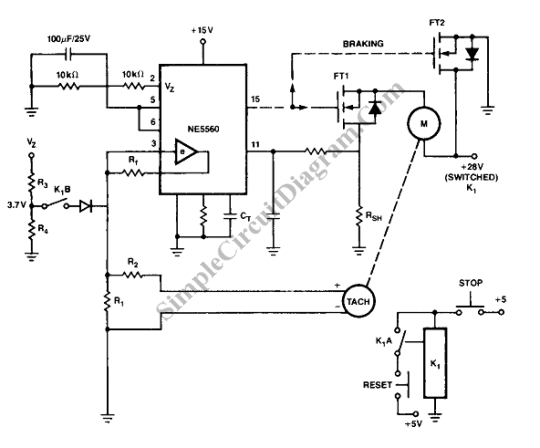
Description: A constant speed motor control can be achieved using closed-loop (servo) control. A constant speed motor maintains a steady speed regardless of variations in load.
In a closed-loop control system, feedback is utilized to compare the actual speed of the motor with the desired speed, allowing for adjustments to be made in real-time. This is typically accomplished through the use of sensors that monitor the motor's speed and provide this information to a controller, which processes the data and adjusts the input to the motor accordingly.
The essential components of a closed-loop motor control system include a motor, a speed sensor (such as an encoder or tachometer), a controller (often a microcontroller or a dedicated motor control IC), and a power driver circuit. The speed sensor measures the actual speed of the motor and sends this data to the controller. The controller calculates the difference between the desired speed and the actual speed, known as the error signal. Based on this error, the controller adjusts the duty cycle of the PWM signal sent to the power driver, which in turn controls the voltage and current supplied to the motor.
In designing the schematic for a closed-loop motor control system, it is crucial to select an appropriate motor type (e.g., DC, stepper, or brushless) based on the application requirements. The power driver circuit must be capable of handling the motor's current and voltage specifications. Additionally, the choice of feedback sensor impacts the overall accuracy and responsiveness of the control system.
The controller may implement various control algorithms, such as proportional-integral-derivative (PID) control, to optimize performance. The tuning of PID parameters is vital for achieving the desired response characteristics, including stability, speed of response, and minimal steady-state error.
Overall, a closed-loop constant speed motor control system is integral in applications requiring precise speed regulation, such as robotics, conveyor systems, and automated machinery. Proper design and implementation of the control circuitry ensure that the motor operates efficiently and reliably under varying load conditions.To make a constant speed motor control we can use Closed loop (servo) control. Constant speed motor is a motor that has constant speed although the load is..
In a closed-loop control system, feedback is utilized to compare the actual speed of the motor with the desired speed, allowing for adjustments to be made in real-time. This is typically accomplished through the use of sensors that monitor the motor's speed and provide this information to a controller, which processes the data and adjusts the input to the motor accordingly.
The essential components of a closed-loop motor control system include a motor, a speed sensor (such as an encoder or tachometer), a controller (often a microcontroller or a dedicated motor control IC), and a power driver circuit. The speed sensor measures the actual speed of the motor and sends this data to the controller. The controller calculates the difference between the desired speed and the actual speed, known as the error signal. Based on this error, the controller adjusts the duty cycle of the PWM signal sent to the power driver, which in turn controls the voltage and current supplied to the motor.
In designing the schematic for a closed-loop motor control system, it is crucial to select an appropriate motor type (e.g., DC, stepper, or brushless) based on the application requirements. The power driver circuit must be capable of handling the motor's current and voltage specifications. Additionally, the choice of feedback sensor impacts the overall accuracy and responsiveness of the control system.
The controller may implement various control algorithms, such as proportional-integral-derivative (PID) control, to optimize performance. The tuning of PID parameters is vital for achieving the desired response characteristics, including stability, speed of response, and minimal steady-state error.
Overall, a closed-loop constant speed motor control system is integral in applications requiring precise speed regulation, such as robotics, conveyor systems, and automated machinery. Proper design and implementation of the control circuitry ensure that the motor operates efficiently and reliably under varying load conditions.To make a constant speed motor control we can use Closed loop (servo) control. Constant speed motor is a motor that has constant speed although the load is..
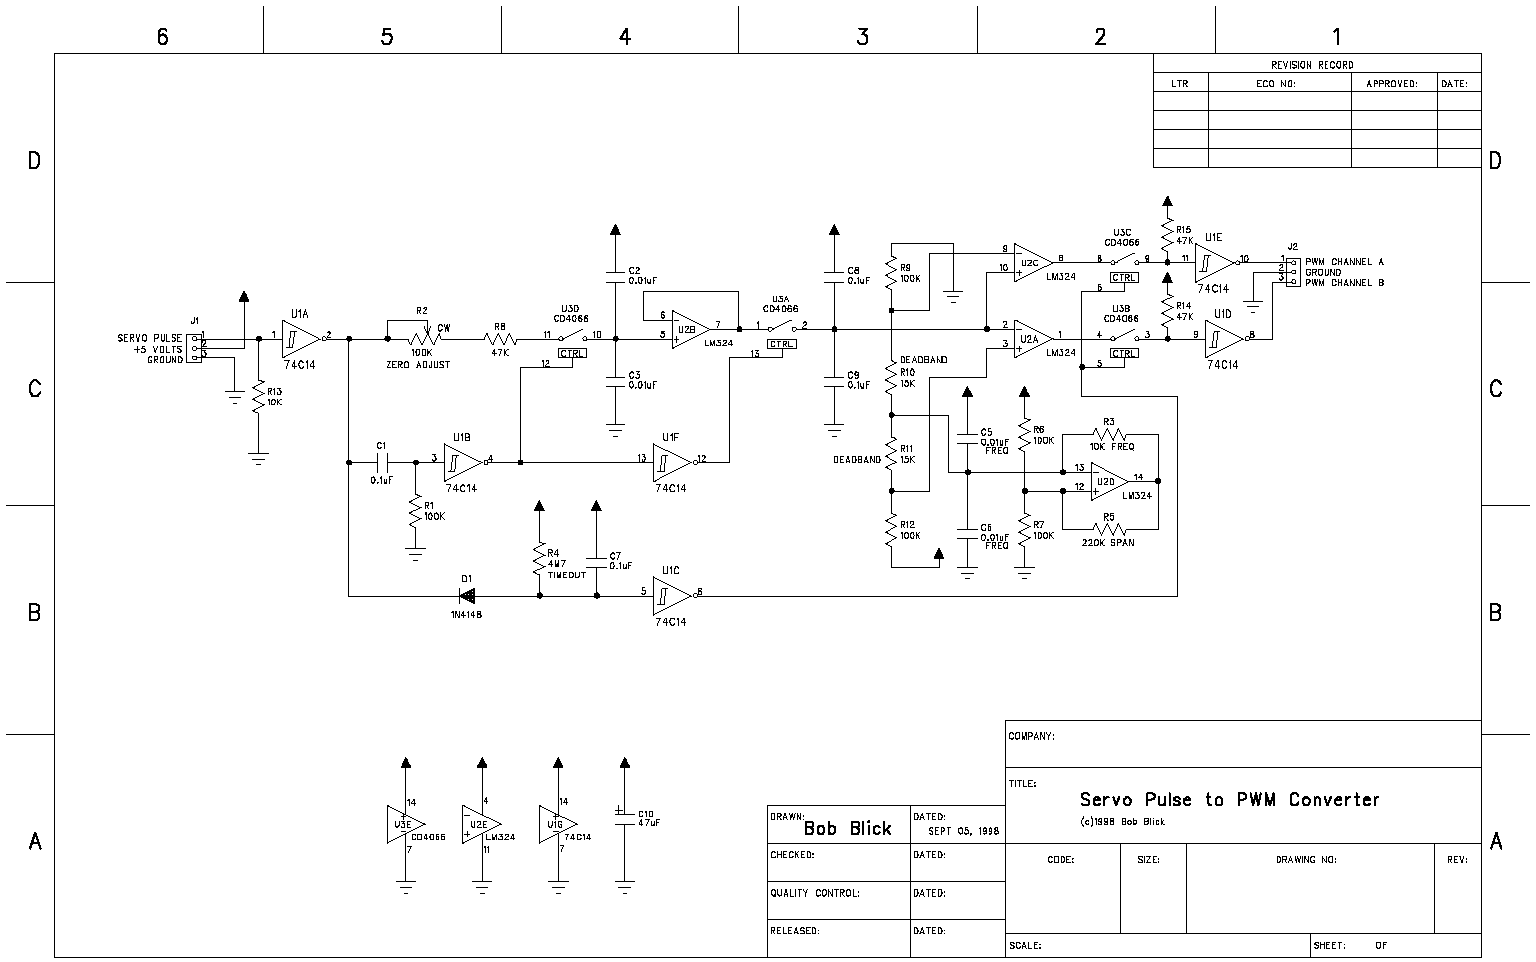
Servo pulse to PWM converter
The circuit presented on this page attempts to be an interface to convert pulses such as provided by a Basic Stamp or R/C receiver to a dual PWM (Pulse Width Modulation) signal required by an H-bridge. The simplest circuit would...
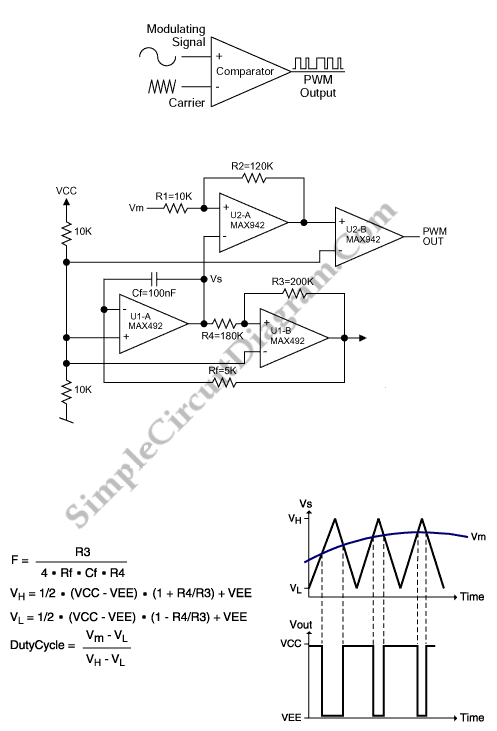
PWM Modulator Using Op-Amp
This is a simple PWM modulator circuit. Comparing the message signal to a ramp or triangular waveform is the simplest way to produce a PWM signal. When the...
The PWM (Pulse Width Modulation) modulator circuit operates by comparing a modulating signal,...
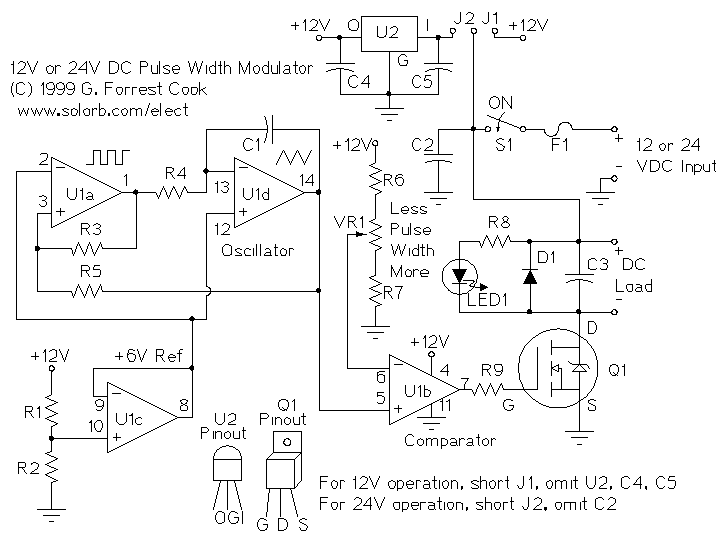
PWM Motor Speed Controller
A pulse width modulator (PWM) is a device that may be used as an efficient light dimmer or DC motor speed controller. The circuit described here is for a general purpose device that can control DC devices which draw up...
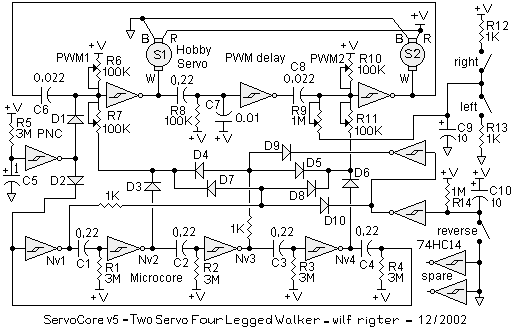
Servocore 2-motor walker circuit
There is an advantage in using continuously active PWM signals. The main reason is that the asynchronous frequencies of the PWM core and microcore can sometimes result in a shortened PWM pulse. The servo recognizes this as a command for...
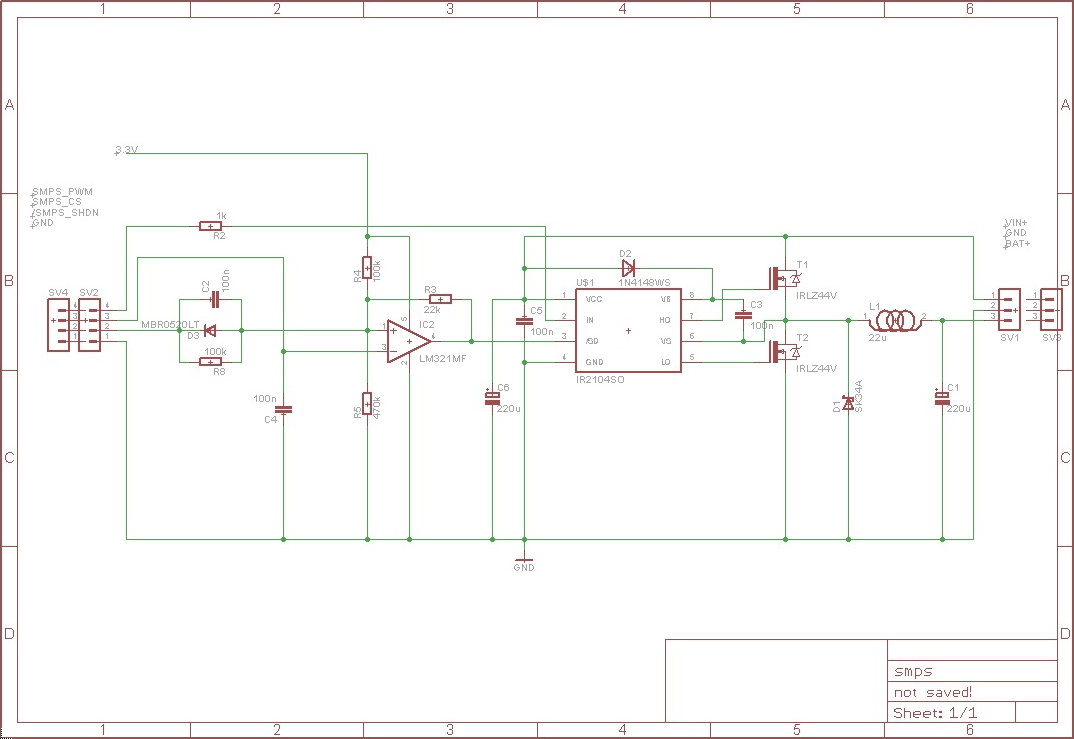
pwm Why is the MOSFET driver in this circuit dying
The circuit receives an input voltage (Vin), which is processed through a Switch Mode Power Supply (SMPS) utilizing two MOSFETs driven by an IR2104 driver. The output is directed to the battery positive terminal (Bat+). An LM321 operates as a...
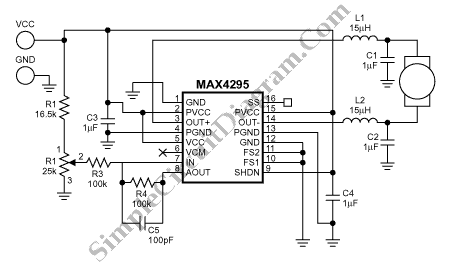
PWM Motor Speed Control Using Class D Audio Amplifier
This is a Class D audio amplifier circuit used to control the PWM motor speed. This circuit has two advantages for battery-powered portable devices. First, it provides high efficiency, which extends battery life.
The Class D audio amplifier operates by modulating...
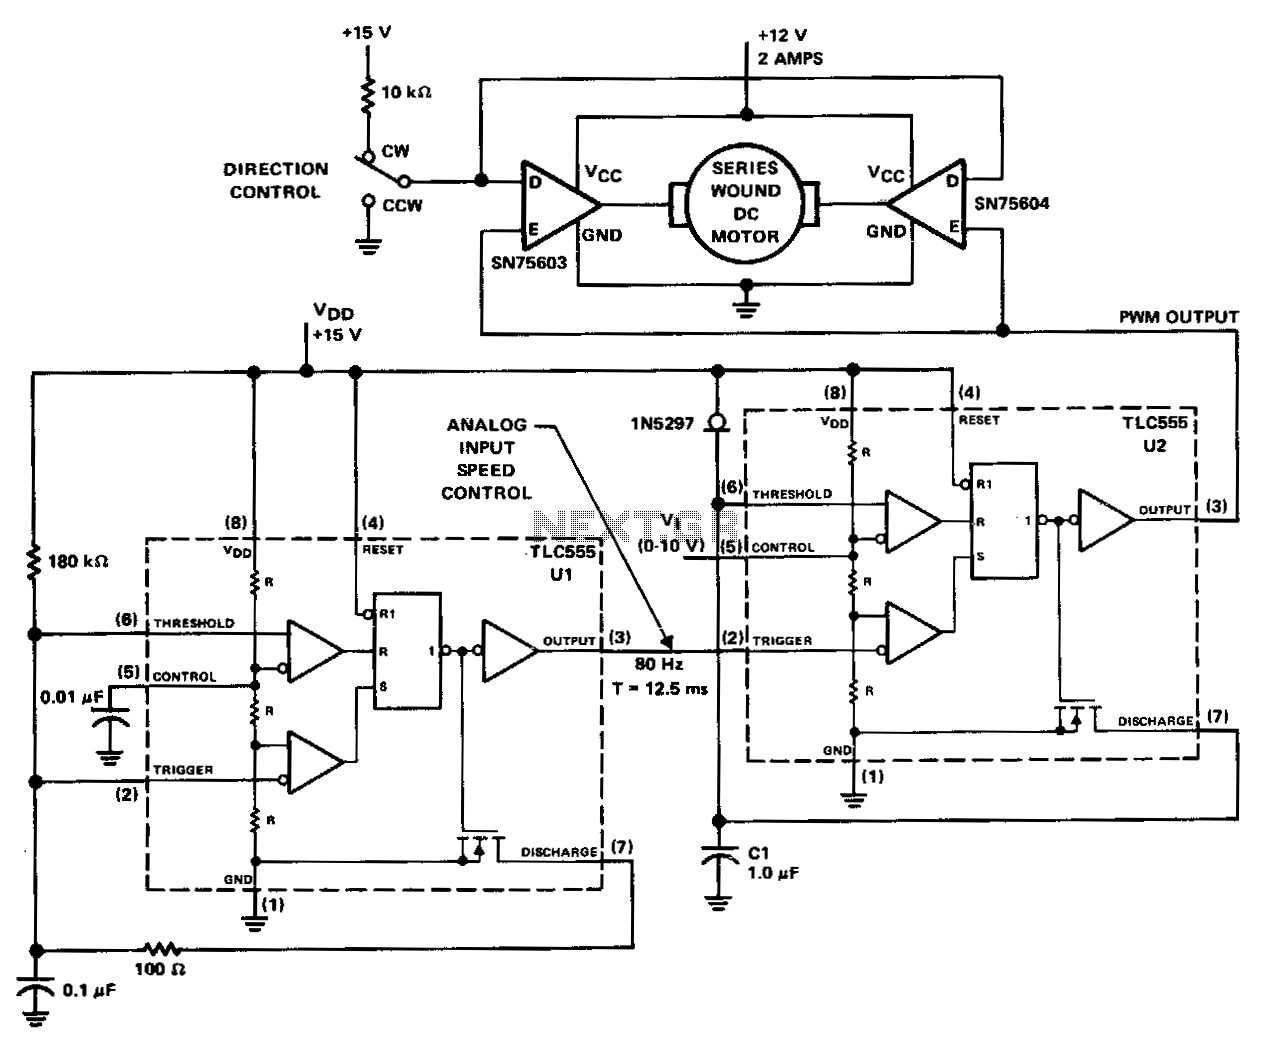
Pwm-motor-controller
The PWM controller utilizes complementary half-H peripheral drivers SN75603 and SN75604, featuring totem-pole outputs rated at 40 V and 2.0 A. These drivers effectively configure the motor in a full-bridge setup, enabling bidirectional control. Timer U1 operates in astable mode...
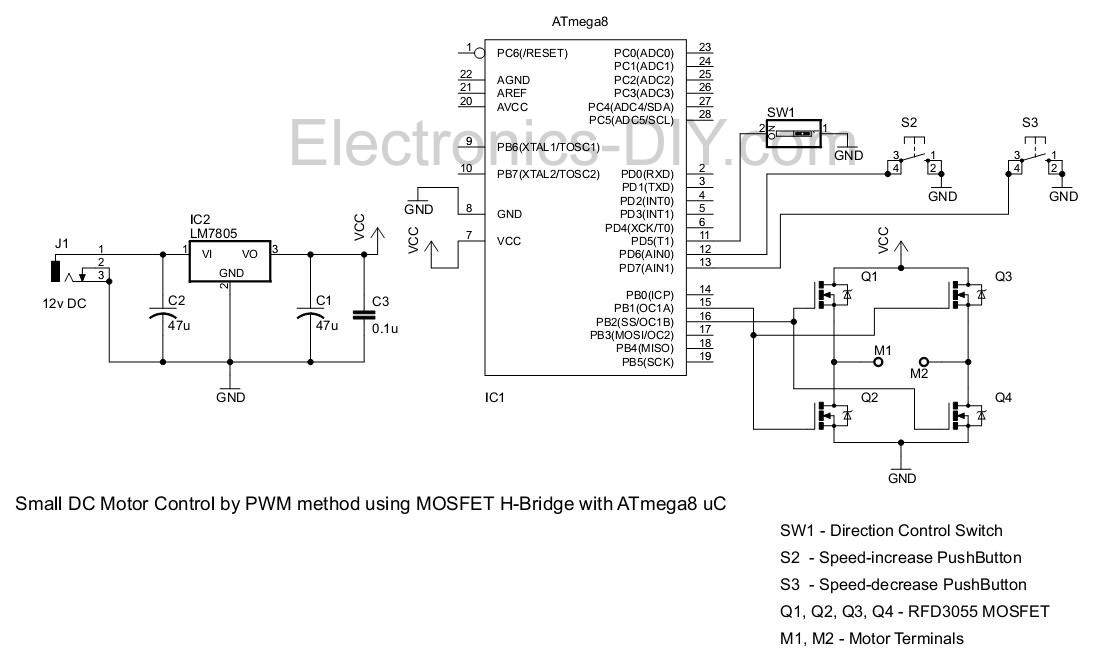
PWM Motor Driver with MOSFET H-Bridge and AVR ATmega8
This project involves controlling a small DC motor, sourced from an old personal cassette player, using the ATmega8 microcontroller. The ATmega8 features three PWM channels, of which two are utilized in this application. The PWM signals are sent to a...
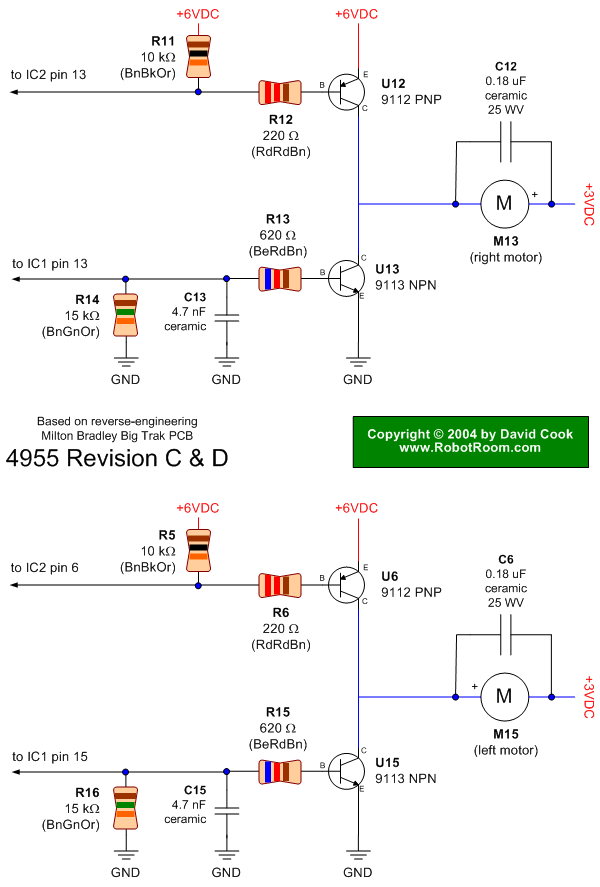
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...