


Closed Loop PWM Motor Control
#PWM
#closed loop
#servo control
#constant speed
#motor driver
#feedback
#speed regulation
#DC motor
#control system
#PID
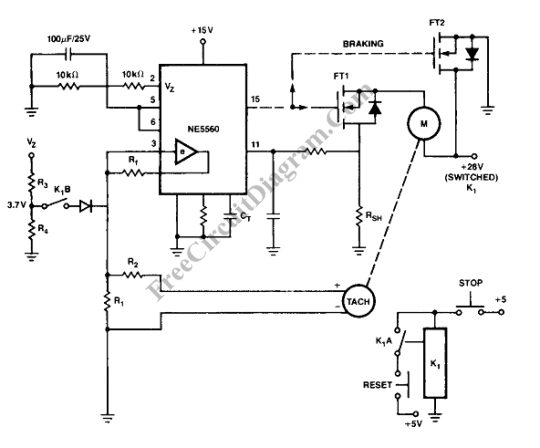
Description: Closed loop motor control is utilized for maintaining constant speed in motor operations. This means that the motor's speed is regulated to remain steady.
Closed loop motor control systems, commonly referred to as servo control systems, are essential in applications requiring precise speed and position management. In such systems, feedback mechanisms are implemented to continuously monitor the output of the motor. This feedback is typically obtained from sensors that measure various parameters such as speed, position, and torque.
In a typical closed loop motor control circuit, a microcontroller or digital signal processor (DSP) serves as the central processing unit. It receives input from the sensors and compares the actual motor speed with the desired speed setpoint. If discrepancies are detected, the controller adjusts the input signal to the motor driver, which modulates the power supplied to the motor, thus correcting the speed.
The key components of a closed loop motor control circuit include:
1. **Motor**: The primary actuator that converts electrical energy into mechanical motion.
2. **Sensors**: Devices such as encoders or tachometers that provide real-time feedback on the motor's speed and position.
3. **Controller**: A microcontroller or DSP that processes the feedback data and generates control signals.
4. **Motor Driver**: An interface that amplifies the control signals from the controller to drive the motor effectively.
5. **Power Supply**: Provides the necessary voltage and current to the motor and driver circuit.
The advantages of closed loop control systems include improved accuracy, better performance under varying load conditions, and enhanced stability. By continuously adjusting the motor's operation based on real-time feedback, these systems can effectively reduce overshoot and oscillations, ensuring a smooth and consistent performance in various applications such as robotics, CNC machinery, and automated conveyor systems.Closed Loop Motor Control Closed loop (servo) control is used to make a constant speed motor control. Constant speed means that the speed of the motor will be.
Closed loop motor control systems, commonly referred to as servo control systems, are essential in applications requiring precise speed and position management. In such systems, feedback mechanisms are implemented to continuously monitor the output of the motor. This feedback is typically obtained from sensors that measure various parameters such as speed, position, and torque.
In a typical closed loop motor control circuit, a microcontroller or digital signal processor (DSP) serves as the central processing unit. It receives input from the sensors and compares the actual motor speed with the desired speed setpoint. If discrepancies are detected, the controller adjusts the input signal to the motor driver, which modulates the power supplied to the motor, thus correcting the speed.
The key components of a closed loop motor control circuit include:
1. **Motor**: The primary actuator that converts electrical energy into mechanical motion.
2. **Sensors**: Devices such as encoders or tachometers that provide real-time feedback on the motor's speed and position.
3. **Controller**: A microcontroller or DSP that processes the feedback data and generates control signals.
4. **Motor Driver**: An interface that amplifies the control signals from the controller to drive the motor effectively.
5. **Power Supply**: Provides the necessary voltage and current to the motor and driver circuit.
The advantages of closed loop control systems include improved accuracy, better performance under varying load conditions, and enhanced stability. By continuously adjusting the motor's operation based on real-time feedback, these systems can effectively reduce overshoot and oscillations, ensuring a smooth and consistent performance in various applications such as robotics, CNC machinery, and automated conveyor systems.Closed Loop Motor Control Closed loop (servo) control is used to make a constant speed motor control. Constant speed means that the speed of the motor will be.
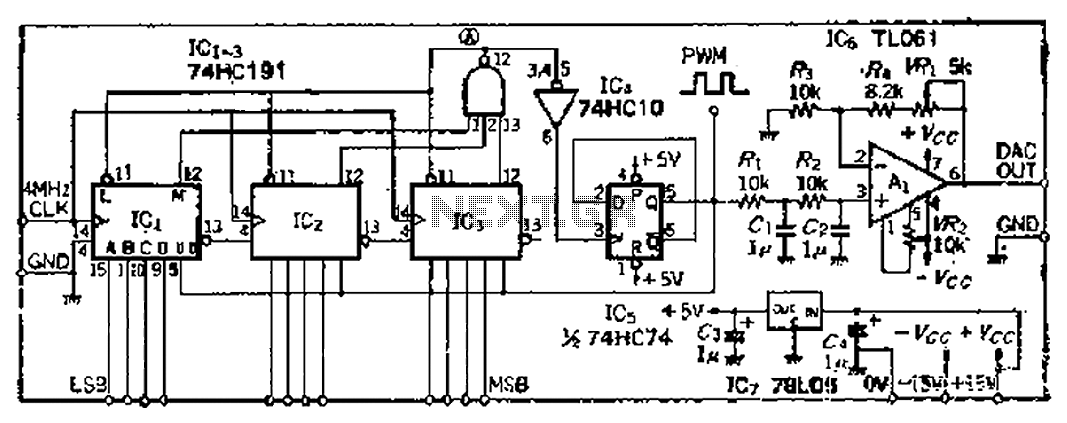
Easy to adjust high-precision PWM pulse width modulation 12-bit DA converter
A PWM clock signal is generated at 4096 times the input frequency, counting up (Q3) until the base of ICi-IC3 is full. The output point produces a maximum clock signal. On one side, voltage data is loaded into IC3, while...
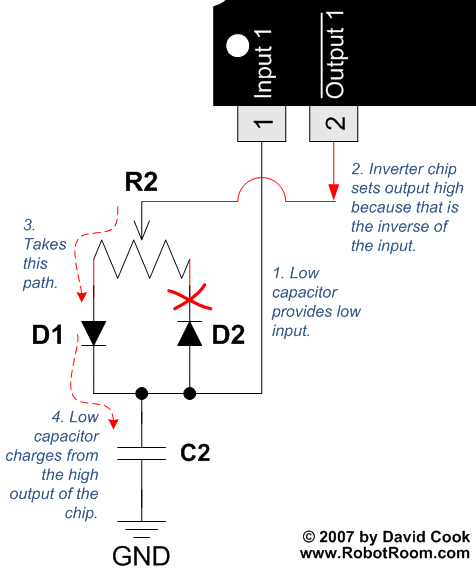
PWM - Pulse Width Modulation for DC Motor Speed and LED Brightness 2
To understand how the 74AC14 PWM circuit functions, it is essential to focus on the schematic section that includes the trimpot, diodes, capacitor, and the first inverter logic gate. Initially, when power is applied to the circuit, the capacitor is...
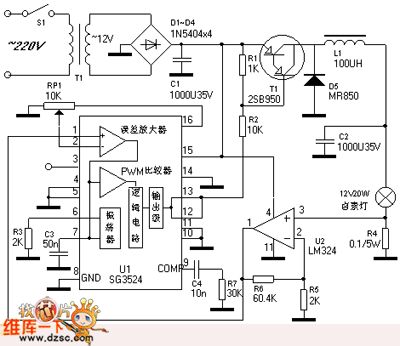
PWM Control Dimming Halogen Lamp
The PWM control dimming circuit for a halogen lamp is illustrated. The halogen lamp operates at a rated voltage of 12V with a nominal power of 20W. This dimmer circuit is capable of adjusting the intensity of the halogen lamp...
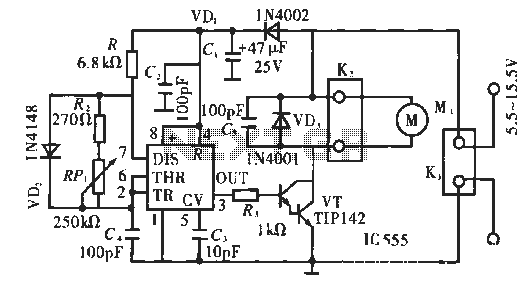
PWM DC motor speed control circuit
The circuit operates using pulse position modulation, which is a method distinct from the more commonly utilized pulse width modulation for speed control. A 555 timer is employed as a square wave modulator, generating output pulses with a fixed width...
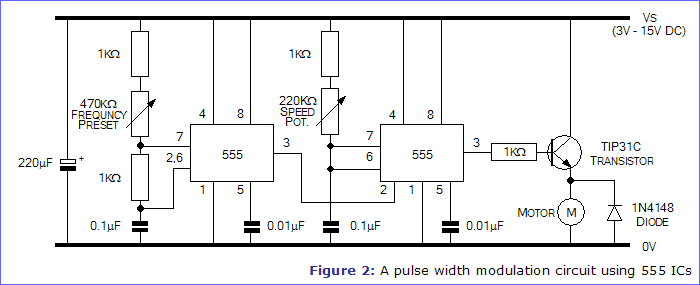
Pulse Width Modulation
The control of electric motors is a topic of interest for those involved in Meccano model building. Each model has specific motor requirements concerning available space, motor power, speed, frequency of start and stop, and the necessity for reduction gearing....
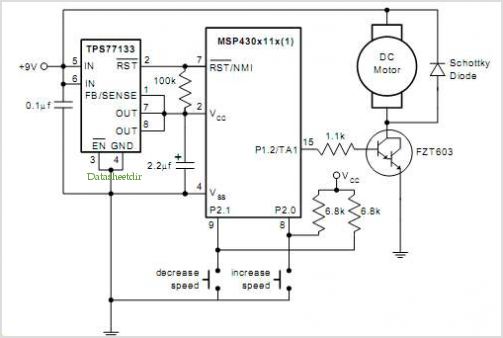
Pwm Dc Motor Control Using Timer A Of The Msp430
The QAMI5516 is an integrated demodulator and decoder solution designed for digital cable receivers, capable of handling compressed video, audio, and data services. This QAM demodulator executes intermediate frequency (IF) to MPEG-2 block processing of QAM carriers. The resulting demodulated...
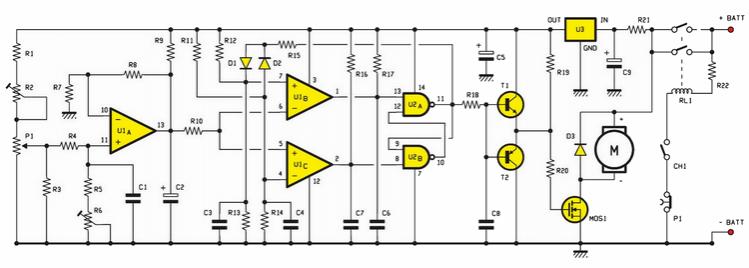
PWM circuit
An electric scooter and E-Bike PWM speed controller circuit has been constructed. However, the oscillator is not functioning as intended. The printed circuit board has been checked and is confirmed to be in good condition, including all resistors.
The electric scooter...
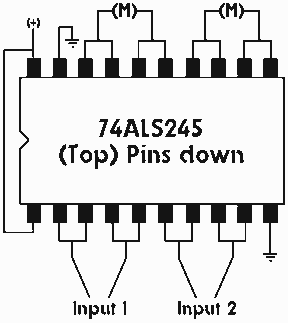
Single IC chip Motor Driver for robots
A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. This...
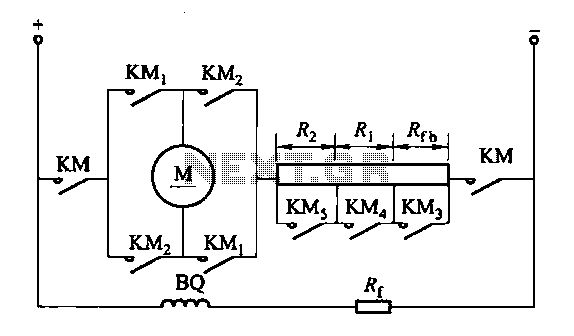
A DC motor reverse brake circuit
The circuit depicted in Figure 3-200 (a) illustrates the operation of a reverse braking system. When reverse braking is initiated, the forward contacts of contactor KMi open, and the reverse brake contactor KM3 disconnects while the reverse contactor KM2 contacts...