


knexapod
#PICAXE
#hexapod
#servo motors
#ultrasonic sensor
#obstacle avoidance
#K'nex
#robot
#microcontroller
#hobby project
#educational
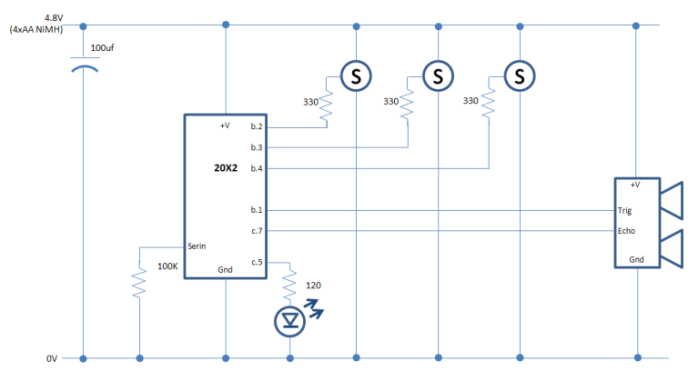
Description: K'nexapod is a hexapod robot constructed using K'nex building toys and managed by a PICAXE microcontroller. It is powered by small hobby servos, allowing it to move forward, backward, and turn. The robot features an ultrasonic sensor and operates based on a straightforward algorithm that enables it to navigate while avoiding obstacles.
The K'nexapod hexapod robot utilizes a combination of K'nex structural components and a PICAXE microcontroller to facilitate its movement and control. The design incorporates six legs, each driven by a small hobby servo motor, which provides the necessary propulsion for locomotion. This configuration allows the robot to perform complex movements, including forward and backward motion, as well as turning maneuvers.
The ultrasonic sensor plays a crucial role in the robot's navigation capabilities. By emitting ultrasonic waves and measuring the time it takes for the echoes to return, the sensor can detect the presence of obstacles within its vicinity. The data collected by the ultrasonic sensor is processed by the PICAXE microcontroller, which executes a simple algorithm designed to enable the robot to avoid collisions. This algorithm typically involves determining the distance to the nearest obstacle and adjusting the robot's movement accordingly, allowing it to change direction or stop when an obstacle is detected.
The overall design of the K'nexapod emphasizes modularity and ease of assembly, making it accessible for hobbyists and educational purposes. The use of K'nex building toys allows for a high degree of customization, enabling users to modify the robot's structure or functionality as desired. The integration of the PICAXE microcontroller and ultrasonic sensor not only enhances the robot's capabilities but also serves as an excellent platform for learning about robotics, programming, and sensor integration.K`nexapod is a hexapod robot built with K`nex building toys and controlled by a PICAXE microntroller. Propelled by small hobby servos it can move forward, backward, and make turns. It is equipped with an ultrasonic sensor and follows a simple algorithm to wander about while avoiding obstacles in its path..
The K'nexapod hexapod robot utilizes a combination of K'nex structural components and a PICAXE microcontroller to facilitate its movement and control. The design incorporates six legs, each driven by a small hobby servo motor, which provides the necessary propulsion for locomotion. This configuration allows the robot to perform complex movements, including forward and backward motion, as well as turning maneuvers.
The ultrasonic sensor plays a crucial role in the robot's navigation capabilities. By emitting ultrasonic waves and measuring the time it takes for the echoes to return, the sensor can detect the presence of obstacles within its vicinity. The data collected by the ultrasonic sensor is processed by the PICAXE microcontroller, which executes a simple algorithm designed to enable the robot to avoid collisions. This algorithm typically involves determining the distance to the nearest obstacle and adjusting the robot's movement accordingly, allowing it to change direction or stop when an obstacle is detected.
The overall design of the K'nexapod emphasizes modularity and ease of assembly, making it accessible for hobbyists and educational purposes. The use of K'nex building toys allows for a high degree of customization, enabling users to modify the robot's structure or functionality as desired. The integration of the PICAXE microcontroller and ultrasonic sensor not only enhances the robot's capabilities but also serves as an excellent platform for learning about robotics, programming, and sensor integration.K`nexapod is a hexapod robot built with K`nex building toys and controlled by a PICAXE microntroller. Propelled by small hobby servos it can move forward, backward, and make turns. It is equipped with an ultrasonic sensor and follows a simple algorithm to wander about while avoiding obstacles in its path..
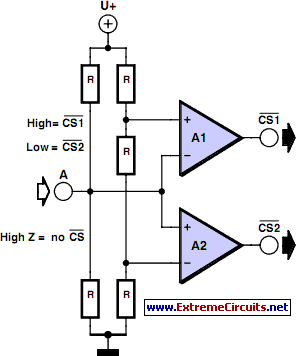
Multitasking Pins circuit
It is entirely logical that low-cost miniature microcontrollers have fewer pins than their larger counterparts, sometimes too few. Consideration has been given to how to economize on pins by making them perform the work of several. It was noted that...
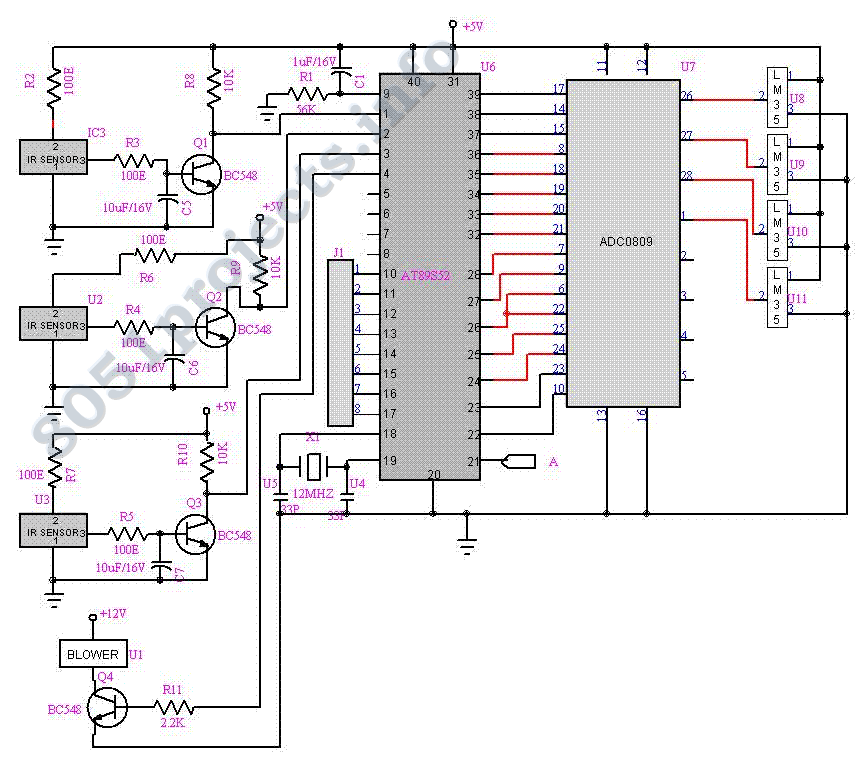
Fighting Robot circuit
The need for a device that can detect and extinguish a fire on its own is long past due. Many house fires originate when someone is either sleeping or not home. With the invention of such a device, people and...
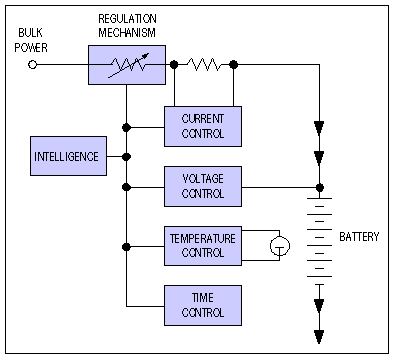
How to Design Battery Charger Applications that Require External Microcontrollers and Related System-Level Issues
Application note on designing linear and switch-mode (switching DC-DC converter current source) battery charger applications that require external microcontrollers and related system-level issues for notebook computers.
The application note provides guidance on the design of both linear and switching DC-DC converter...
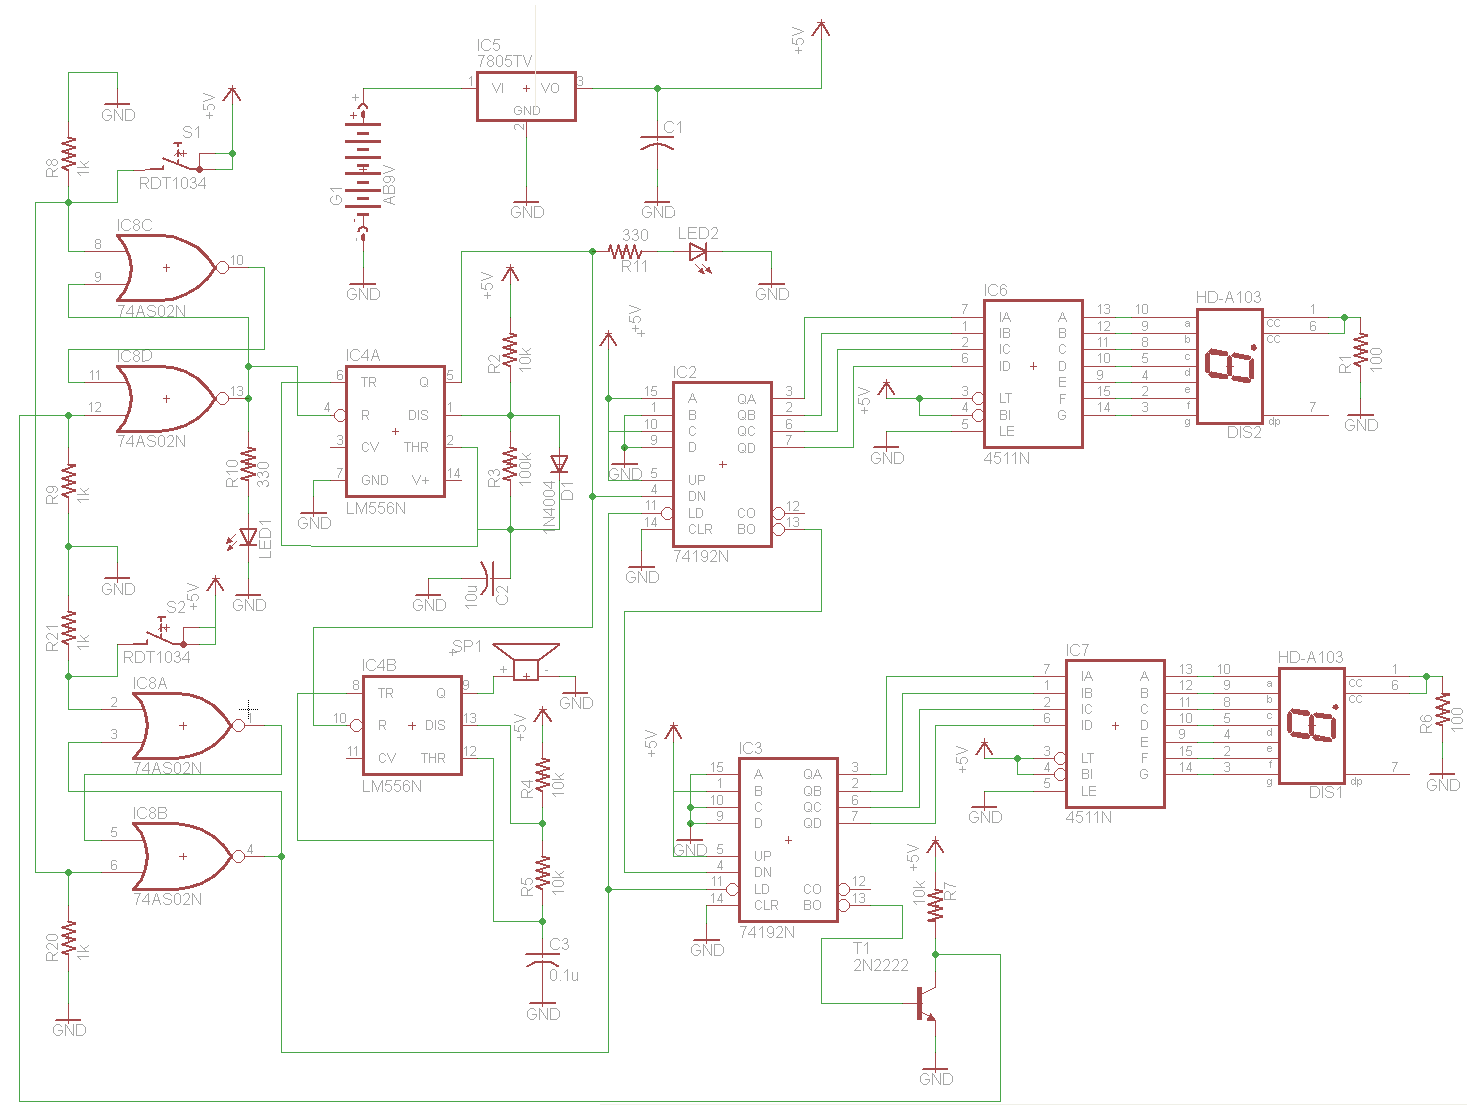
Robot Motor Control Schematic
The schematic for controlling the motors is divided into three main sections, each serving a distinct function. The primary components featured in the schematic include the PIC 18F252 microcontroller, the SN754410 motor driver, and 2N2222 transistors. At the top of...
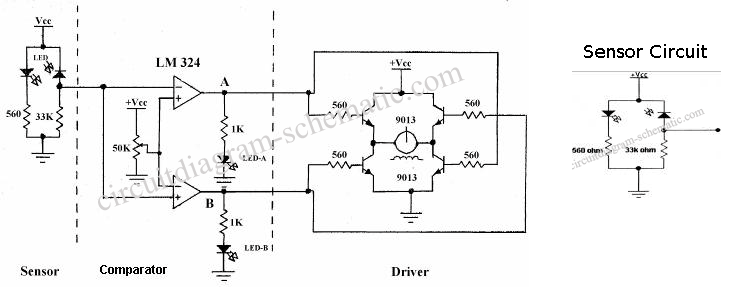
Sensor Circuit Of Analog Line Follower Robot
The following circuit illustrates the sensor circuit of an analog line follower robot. Features include control by a microcontroller and a sensor circuit.
The sensor circuit for an analog line follower robot is designed to detect the presence of a line...
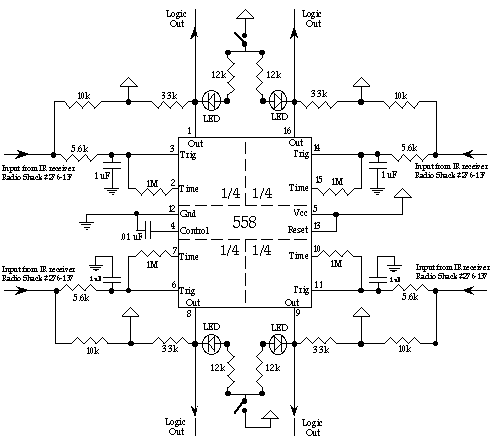
The Hoser Paper
A robot named "Wet Dream" was constructed to roam around, avoid collisions, locate people, and squirt them with an onboard motorized water gun. The robot was designed to maneuver in unstructured environments and react purposefully to various situations. "Wet Dream"...
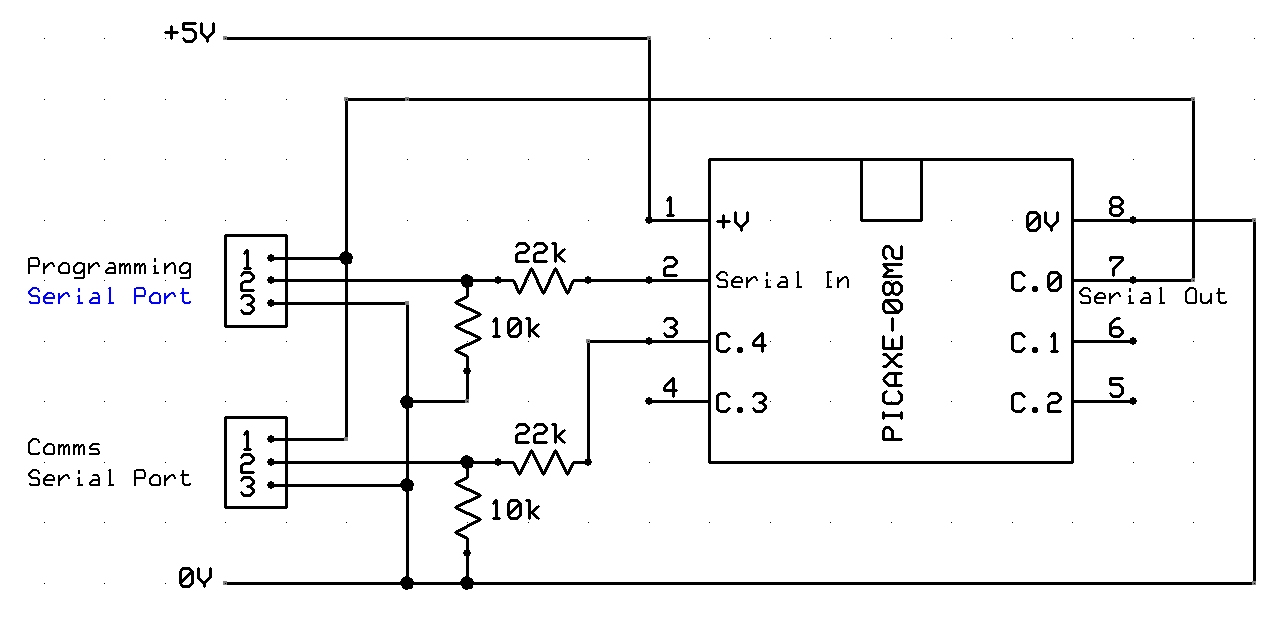
communicate with the picaxe
A tutorial on setting up RS232 communication with PICAXE, including a circuit diagram, serial cable configuration, PC communication program setup and configuration, along with sample code for PICAXE.
The RS232 communication setup for PICAXE microcontrollers is essential for enabling serial data...
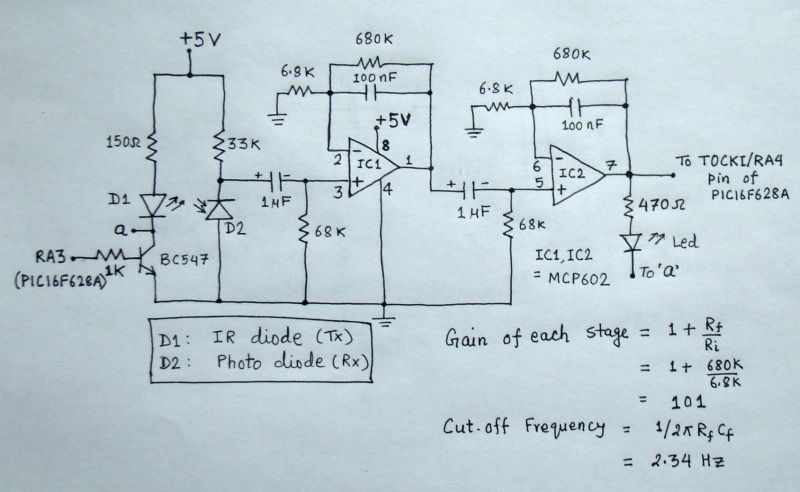
Microcontroller measures heart rate through fingertip
The reflected infrared (IR) signal detected by the photodiode is sent to a signal conditioning circuit, which filters out unwanted signals and amplifies the desired output.
The circuit begins with a photodiode that captures the reflected IR signals. The photodiode operates...
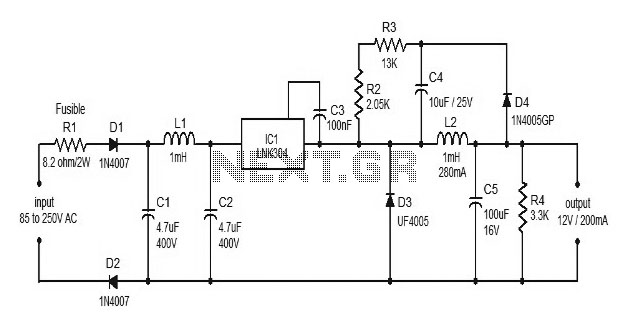
Power supplies for microcontroller based projects
This document discusses the use of small microcontrollers, such as those from the PIC and Atmel series, which typically operate at 5V and require less than 100mA for complete system functionality. Some PICs can function at lower voltages, such as...