


Using the MCU Timers
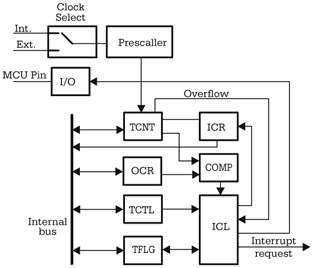
Description: Although there are significant variations between different implementations of the general-purpose timer in various microcontrollers, many similarities exist in the principles of operation and the structure of the timer subsystem. The central element of the timer subsystem is a counter, TCNT (8 or 16 bits in length), which may be read from or, in some cases, written to by software. The clock for TCNT is derived either from the system clock, divided by a programmable prescaler, or from an external clock applied to one of the MCU pins. Software control of the timer is executed through specific registers and commands.
The timer subsystem in microcontrollers serves multiple functions, including event counting, time delay generation, and pulse width modulation (PWM) signal generation. The TCNT counter operates in conjunction with various control registers that configure its mode of operation, such as normal mode, CTC (Clear Timer on Compare Match) mode, or PWM mode.
In normal mode, the TCNT increments on each clock cycle until it reaches its maximum value, at which point it resets to zero. In CTC mode, the timer counts up to a predefined value stored in a compare register (OCR), at which point an interrupt can be triggered, or an output pin can be toggled. PWM mode allows the generation of varying duty cycles for output signals, which is essential in applications such as motor control and signal modulation.
The programmable prescaler plays a crucial role in determining the timer's resolution and maximum count duration. By dividing the system clock frequency, the prescaler allows for longer time intervals to be measured with the same counter width. The selection of the prescaler value is often done via specific bits in a control register, allowing for flexibility in timing applications.
External clock sources can also be utilized, providing additional versatility in timer operations. This is particularly useful in applications requiring synchronization with external events or signals.
Overall, the timer subsystem's architecture is designed to be highly configurable, allowing for a wide range of applications in embedded systems, from simple timing tasks to complex signal generation and event handling. Understanding the operational principles and configurations of the timer subsystem is essential for effectively utilizing microcontrollers in various projects.Although there are significant variations between different implementations of the general-purpose timer in different microcontrollers, there are many similarities in the principles of operation and the structure of the timer subsystem. The central element of the timer subsystem is a counter, TCNT (8 or 16-bits in length), which may be read or (so
metimes) written by software. The clock for TCNT is obtained either from the system clock, divided by a programmable prescaler, or an external clock applied to one of the MCU pins. The software control upon the timer is performed by means of the.
The timer subsystem in microcontrollers serves multiple functions, including event counting, time delay generation, and pulse width modulation (PWM) signal generation. The TCNT counter operates in conjunction with various control registers that configure its mode of operation, such as normal mode, CTC (Clear Timer on Compare Match) mode, or PWM mode.
In normal mode, the TCNT increments on each clock cycle until it reaches its maximum value, at which point it resets to zero. In CTC mode, the timer counts up to a predefined value stored in a compare register (OCR), at which point an interrupt can be triggered, or an output pin can be toggled. PWM mode allows the generation of varying duty cycles for output signals, which is essential in applications such as motor control and signal modulation.
The programmable prescaler plays a crucial role in determining the timer's resolution and maximum count duration. By dividing the system clock frequency, the prescaler allows for longer time intervals to be measured with the same counter width. The selection of the prescaler value is often done via specific bits in a control register, allowing for flexibility in timing applications.
External clock sources can also be utilized, providing additional versatility in timer operations. This is particularly useful in applications requiring synchronization with external events or signals.
Overall, the timer subsystem's architecture is designed to be highly configurable, allowing for a wide range of applications in embedded systems, from simple timing tasks to complex signal generation and event handling. Understanding the operational principles and configurations of the timer subsystem is essential for effectively utilizing microcontrollers in various projects.Although there are significant variations between different implementations of the general-purpose timer in different microcontrollers, there are many similarities in the principles of operation and the structure of the timer subsystem. The central element of the timer subsystem is a counter, TCNT (8 or 16-bits in length), which may be read or (so
metimes) written by software. The clock for TCNT is obtained either from the system clock, divided by a programmable prescaler, or an external clock applied to one of the MCU pins. The software control upon the timer is performed by means of the.
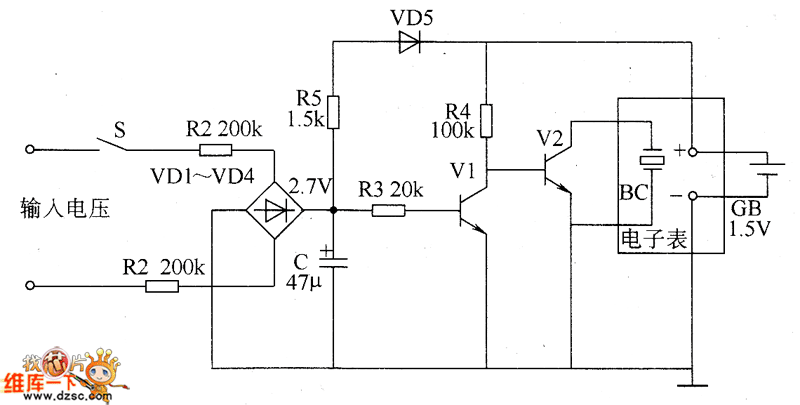
Cumulative timer circuit diagram
The cumulative timer circuit comprises resistor R1 and an internal crystal oscillator, represented in a chart. Resistors R1 and R2 are metal film types, while resistors R3 to R5 are rated at 1/8W and also of the metal film variety....
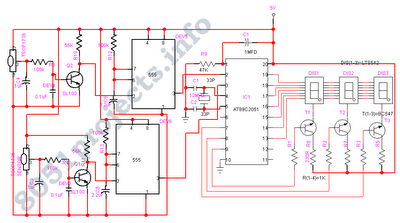
Digital visitor counter Schematic Diagram
The digital visitor counter is a reliable circuit designed to accurately count the number of persons or visitors in a room. When an individual enters the room, the counter increments by one, and when someone leaves, the counter decrements by...
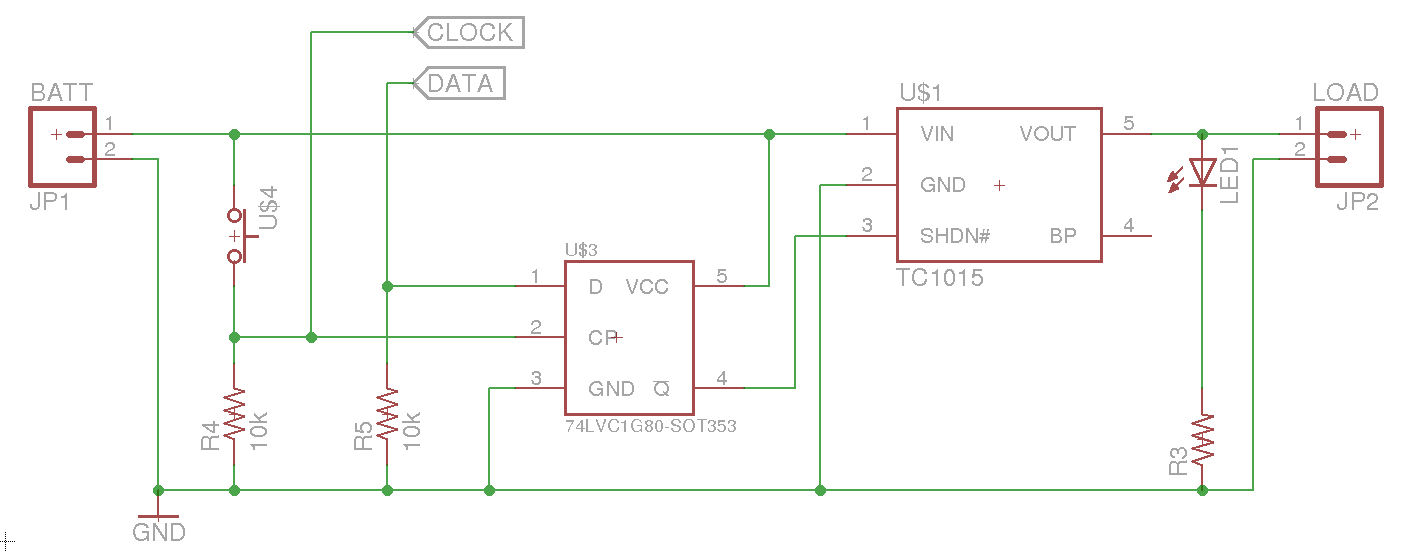
Protecting Microcontroller Input Pins from Soft Power Switch
A soft power switch for a microcontroller is designed such that a momentary switch can activate the circuit, including the microcontroller. When the switch is pressed a second time, the microcontroller is capable of shutting itself down after executing necessary...
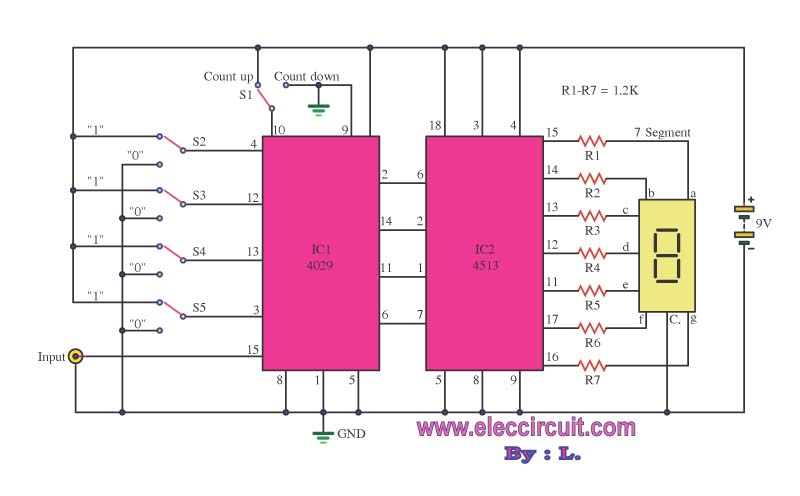
Counter display with led 7 segment by IC CMOS
This is a simple digital counter circuit utilizing the IC 4029 to process binary data, which is then sent to the IC 4513, a driver IC for a 7-segment display to show the output.
The digital counter circuit is designed using...
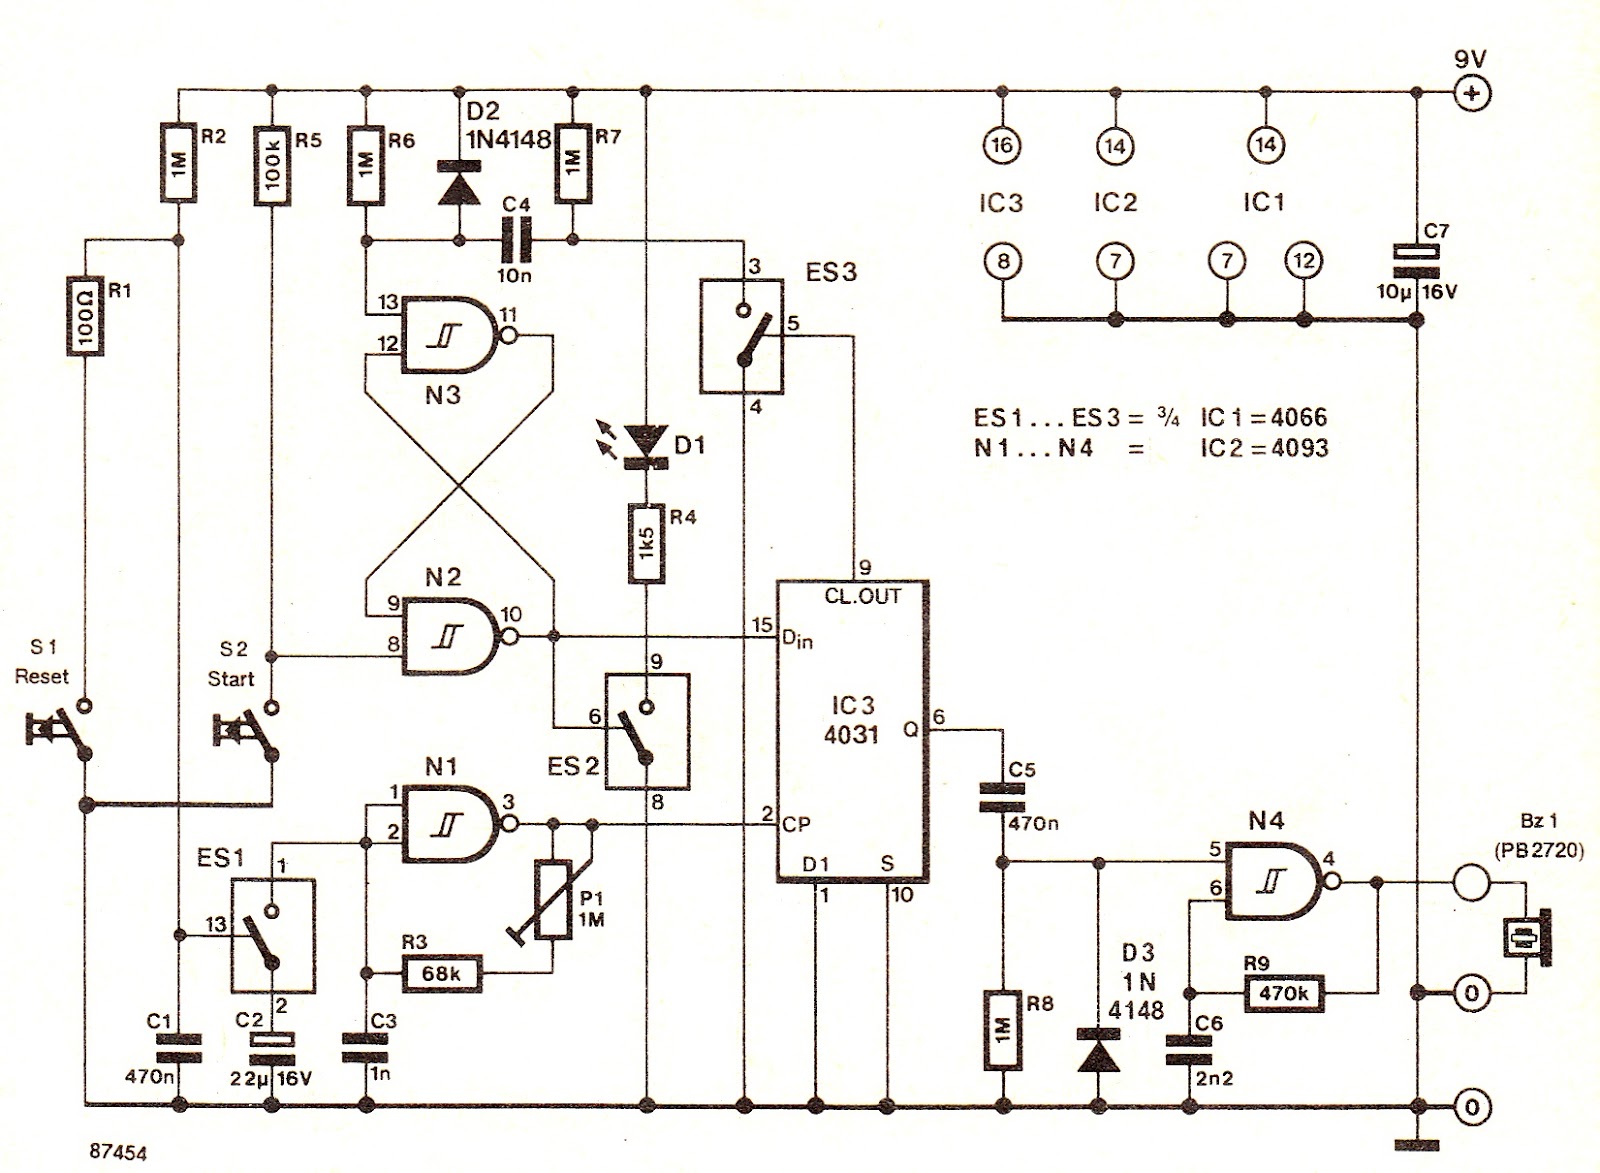
Bathroom Water Heater Timer
The electronic switch ES1 connects the frequency-determining capacitor to the input of clock oscillator N1. The logic level present at the Dm terminal of the integrated circuit is shifted to output Q at a speed defined by P1, allowing for...
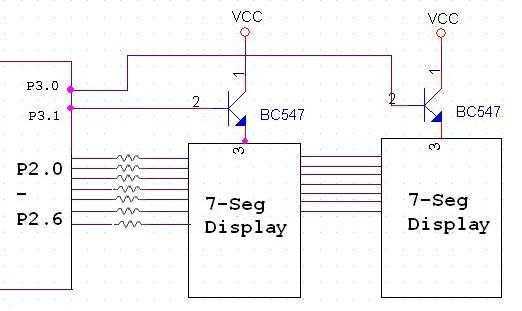
Interfacing seven segment to microcontroller
The Tutorial shows how to interface 7-segment display to a microcontroller. Also explains how do display more than one 7-segment on same data lines using scanning method. 7 Seg displays are are basically 7 LED's. It will be much easier...
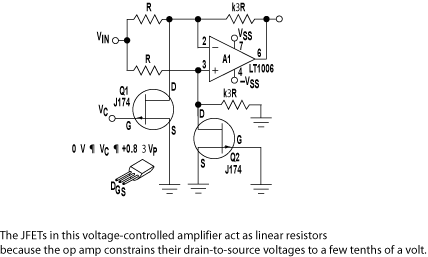
µP-Controlled Oscillator Delivers Rock-Bottom Distortion
Function generators are essential in the design, testing, and operation of encoders, modulators, demodulators, and measurement instruments. This document presents an economical method to construct a bus-controlled sinewave oscillator that exhibits exceptionally low distortion. The circuit produces a sinusoidal output...
DC motor driver for DCMP(AVR-008)
A microcontroller is used to control various types of DC motors, including permanent magnet DC motors, DC servo motors, and stepper motors. This project utilizes the AVR-008 microcontroller from Circuits-Home, which is frequently referred to as the 3-in-1 driver motor...
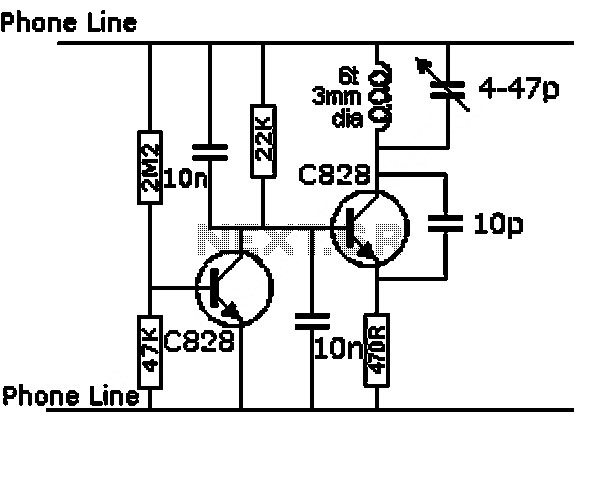
The Time Delay Circuit
The duration for which the circuit remains active is determined by the time required for the stored electrical current to leak back into the circuit, which keeps the transistor and the entire circuit energized. A resistor is present that limits...