


Based on 51 single-chip design and production of infrared remote control car
#AT89S51
#infrared remote control
#DC motor
#L289 driver
#autopilot
#tracing
#C language
#modular design
Description: An infrared remote control car utilizes the AT89S51 microcontroller as the core controller. The system operates DC motors via L298 drivers, enabling manual control, autopilot, and tracking functions. The software is modular and developed using the C programming language. The car features automatic and manual driving capabilities, including obstacle avoidance and path tracking. The hardware components are responsible for infrared signal transmission and reception, obstacle detection, and motor operation. The software handles signal detection, processing, and control functions. The AT89S51 microcontroller decodes infrared signals and manages motor operations based on input signals, including reversing and obstacle detection. The system includes an HT6221 remote control chip that modulates infrared signals, and an integrated IR receiver (1838) for signal reception. The L298 chip is employed for motor control, allowing for speed adjustments and direction changes. Obstacle and track detection utilize a reflective coupler module, with LM324 functioning as a voltage comparator to manage output levels.
The infrared remote control car is designed with a focus on functionality and modularity, leveraging the AT89S51 microcontroller as the central processing unit. The microcontroller processes infrared signals received from the HT6221 remote control, which encodes commands into pulse-modulated signals. The remote control operates at a frequency of 38 kHz, emitting signals that are detected by the IR receiver module (1838). The receiver demodulates these signals and sends the output to the microcontroller's input port (P3.2), enabling the car to respond to the commands.
The L298 motor driver IC is employed to control the DC motors, allowing for bidirectional control and speed modulation. The L298 can handle high voltage and current, making it suitable for driving the motors of the car. The enable pins (ENA, ENB) control the activation of the motor outputs, while the input pins (IN1, IN2, IN3, IN4) determine the direction of rotation. The output pins (OUT1, OUT2, OUT3, OUT4) are connected to the motors, facilitating their operation. Additionally, protective diodes (IN5819) are included to safeguard the circuit from back EMF generated when the motors are stopped.
For obstacle detection and path tracking, a reflective coupler module is utilized. This module consists of an infrared emitter and a phototransistor, which work together to detect obstacles in the car's path. The LM324 voltage comparator is employed to analyze the output from the phototransistor, providing a high or low signal based on the presence of an obstacle. This information is relayed to the microcontroller, which can then adjust the motor operations accordingly, ensuring smooth navigation and obstacle avoidance.
Overall, the design incorporates a well-integrated hardware and software system, allowing for versatile control of the infrared remote control car. The combination of manual and automatic driving features, alongside robust obstacle detection capabilities, enhances the functionality and user experience of the device.An infrared remote control car, the AT89S51 microcontroller as the core controller, DC motor with L289 drivers work to control the operation of car in this section with infrared remote control manual car driving, autopilot, tracing forward and other functions in this The modular design of software using C language. T he AT98C51 microcontroller as the core, making a IR remote control car, car driving with automatic and manual features such as driving and tracking progress. Autopilot, the process can move forward obstacle avoidance. Manual driving, remote control car forward, backward, left turn, turn right, speed up other operations.
tracing the car can move forward in accordance with pre-designed path forward. The system consists of hardware and software components. Hardware to complete some of the major infrared transmitting and receiving coded signals, obstacle detection, path detection, the occurrence of DC motor operation functions. Software mainly to complete the signal detection and processing, device drivers and control and other functions.
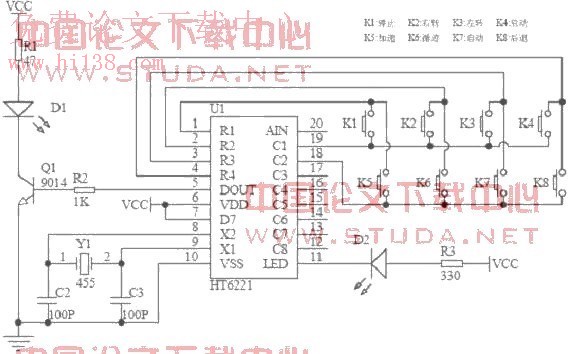
AT89S51 microcontroller infrared signal and decode the query, the query part of each input signal detection and appropriate treatment, including reversing the motor to determine whether an obstacle, to determine whether that payment in their car derailed and so on. system block diagram shown in Figure 1. The circuit of the main control device for the remote control chip HT6221, shown in Figure 2. HT6221 infrared pulse code modulated signal into 38KHZ by infrared emitting diodes infrared code sent in Figure 2 is the infrared emitting diodes D1, D2 is the key indicator, when a button is pressed light D2.
HT6221 encoding rule is: when a key is pressed more than 36ms, the chip oscillator enabled, if the button is pressed and the delay of about 108ms, 108ms launch this code from a start code (9ms), a result code (4. 5ms) low 8-bit address code (9ms ~ 18ms), high 8-bit address (9 ~ 18ms), 8-bit data code (9 ~ 18ms) and the 8-bit data number bit (9 ~ 18ms) form, if the key Press release not more than 108ms, then the code will only be launched from the start code (9ms) and the end code (2.
5ms) composed accordance with the connection on the map, K1 ~ K8 data codes are: 0x00, 0x01, 0x02, 0x03, 0x04, 0x05, 0x06, 0x07. The module uses an integrated IR receiver 1838, the circuit shown in Figure 3. Ceramic capacitor for the decoupling capacitor 104, DOUT is the output signal is demodulated, directly connected to the microcontroller ports P3.
2 there IR codes signal transmission, the output of the detector after the square wave signal shaping, and directly to the microcontroller. The module is mainly controlled by the IC L298 two motor rotating, and changing the motor speed, the circuit shown in Figure 4.
L298 chip is a high-voltage, high current queen bridge driver which SENSEA, SENSEB were two an H-bridge current feedback pin, when not directly grounded. VCC, VS is connected to the supply pin, the voltage ranges are 4. 5 ~ 7V, 2. 5 ~ 46V, design and microcontroller power supply terminal VCC terminal shared 5V supply, VS-side independent access 9V power supply.
ENA, ENB for the enable, low disables the output. IN1, IN2, IN3, IN4 for data input pin, OUT1, OUT2, OUT3, OUT4 as the data output pin. D1 ~ D8 are protected diode (IN5819, out for the release of the response generated when stopping the motor peak potential, otherwise it will Jihuai L298. Obstacle detection and track detection principle is the same from the economic point of view, the choice of the reflective coupler module, the circuit shown in Figure 5.
Optocoupler consists of a reflective infrared emission control components and a phototransistor. LM324 is a voltage comparator, when the level is greater than 3 feet 2 feet, the output 1 pin output high, otherwise the output low. high and low value depends on the level of LM324 to 2 feet, adjust
The infrared remote control car is designed with a focus on functionality and modularity, leveraging the AT89S51 microcontroller as the central processing unit. The microcontroller processes infrared signals received from the HT6221 remote control, which encodes commands into pulse-modulated signals. The remote control operates at a frequency of 38 kHz, emitting signals that are detected by the IR receiver module (1838). The receiver demodulates these signals and sends the output to the microcontroller's input port (P3.2), enabling the car to respond to the commands.
The L298 motor driver IC is employed to control the DC motors, allowing for bidirectional control and speed modulation. The L298 can handle high voltage and current, making it suitable for driving the motors of the car. The enable pins (ENA, ENB) control the activation of the motor outputs, while the input pins (IN1, IN2, IN3, IN4) determine the direction of rotation. The output pins (OUT1, OUT2, OUT3, OUT4) are connected to the motors, facilitating their operation. Additionally, protective diodes (IN5819) are included to safeguard the circuit from back EMF generated when the motors are stopped.
For obstacle detection and path tracking, a reflective coupler module is utilized. This module consists of an infrared emitter and a phototransistor, which work together to detect obstacles in the car's path. The LM324 voltage comparator is employed to analyze the output from the phototransistor, providing a high or low signal based on the presence of an obstacle. This information is relayed to the microcontroller, which can then adjust the motor operations accordingly, ensuring smooth navigation and obstacle avoidance.
Overall, the design incorporates a well-integrated hardware and software system, allowing for versatile control of the infrared remote control car. The combination of manual and automatic driving features, alongside robust obstacle detection capabilities, enhances the functionality and user experience of the device.An infrared remote control car, the AT89S51 microcontroller as the core controller, DC motor with L289 drivers work to control the operation of car in this section with infrared remote control manual car driving, autopilot, tracing forward and other functions in this The modular design of software using C language. T he AT98C51 microcontroller as the core, making a IR remote control car, car driving with automatic and manual features such as driving and tracking progress. Autopilot, the process can move forward obstacle avoidance. Manual driving, remote control car forward, backward, left turn, turn right, speed up other operations.
tracing the car can move forward in accordance with pre-designed path forward. The system consists of hardware and software components. Hardware to complete some of the major infrared transmitting and receiving coded signals, obstacle detection, path detection, the occurrence of DC motor operation functions. Software mainly to complete the signal detection and processing, device drivers and control and other functions.
AT89S51 microcontroller infrared signal and decode the query, the query part of each input signal detection and appropriate treatment, including reversing the motor to determine whether an obstacle, to determine whether that payment in their car derailed and so on. system block diagram shown in Figure 1. The circuit of the main control device for the remote control chip HT6221, shown in Figure 2. HT6221 infrared pulse code modulated signal into 38KHZ by infrared emitting diodes infrared code sent in Figure 2 is the infrared emitting diodes D1, D2 is the key indicator, when a button is pressed light D2.
HT6221 encoding rule is: when a key is pressed more than 36ms, the chip oscillator enabled, if the button is pressed and the delay of about 108ms, 108ms launch this code from a start code (9ms), a result code (4. 5ms) low 8-bit address code (9ms ~ 18ms), high 8-bit address (9 ~ 18ms), 8-bit data code (9 ~ 18ms) and the 8-bit data number bit (9 ~ 18ms) form, if the key Press release not more than 108ms, then the code will only be launched from the start code (9ms) and the end code (2.
5ms) composed accordance with the connection on the map, K1 ~ K8 data codes are: 0x00, 0x01, 0x02, 0x03, 0x04, 0x05, 0x06, 0x07. The module uses an integrated IR receiver 1838, the circuit shown in Figure 3. Ceramic capacitor for the decoupling capacitor 104, DOUT is the output signal is demodulated, directly connected to the microcontroller ports P3.
2 there IR codes signal transmission, the output of the detector after the square wave signal shaping, and directly to the microcontroller. The module is mainly controlled by the IC L298 two motor rotating, and changing the motor speed, the circuit shown in Figure 4.
L298 chip is a high-voltage, high current queen bridge driver which SENSEA, SENSEB were two an H-bridge current feedback pin, when not directly grounded. VCC, VS is connected to the supply pin, the voltage ranges are 4. 5 ~ 7V, 2. 5 ~ 46V, design and microcontroller power supply terminal VCC terminal shared 5V supply, VS-side independent access 9V power supply.
ENA, ENB for the enable, low disables the output. IN1, IN2, IN3, IN4 for data input pin, OUT1, OUT2, OUT3, OUT4 as the data output pin. D1 ~ D8 are protected diode (IN5819, out for the release of the response generated when stopping the motor peak potential, otherwise it will Jihuai L298. Obstacle detection and track detection principle is the same from the economic point of view, the choice of the reflective coupler module, the circuit shown in Figure 5.
Optocoupler consists of a reflective infrared emission control components and a phototransistor. LM324 is a voltage comparator, when the level is greater than 3 feet 2 feet, the output 1 pin output high, otherwise the output low. high and low value depends on the level of LM324 to 2 feet, adjust
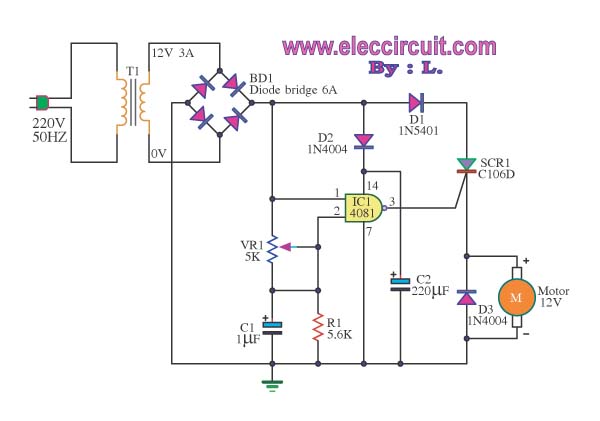
DC motor controller diagram with SCR and cmos ic
This is a speed motor controller circuit for a 12V DC motor. The speed of rotation of the spindle motor can be adjusted from 5 to 60 cycles per minute.
The speed motor controller circuit for a 12V DC motor typically...
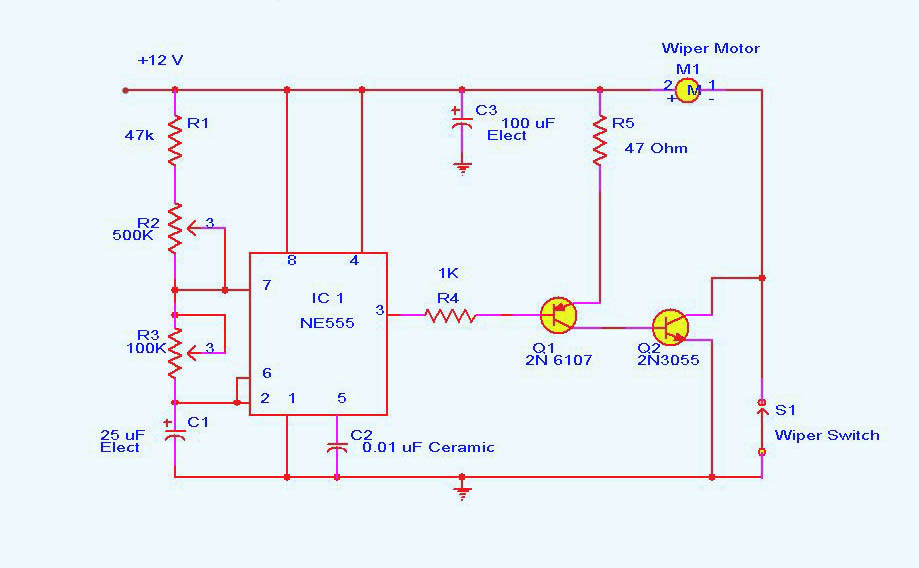
motor controller
DC motor control circuit using NE555. The 555 timer circuit has numerous applications. For those unfamiliar with its functionalities, an authoritative book can provide valuable insights. CircuitsToday offers an online store featuring reviews of three highly recommended books that delve...
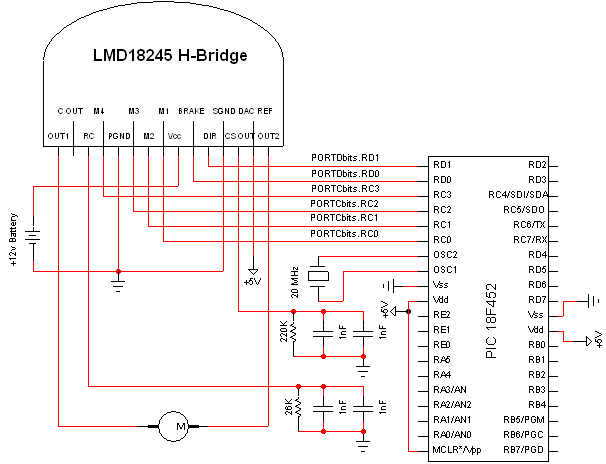
DC Motor Control circuit
The schematic presented below incorporates all the hardware components previously discussed. It is important to follow the tutorial precisely as shown. If a 220k resistor is unavailable, use the nearest higher value. Components are labeled to the best of the...
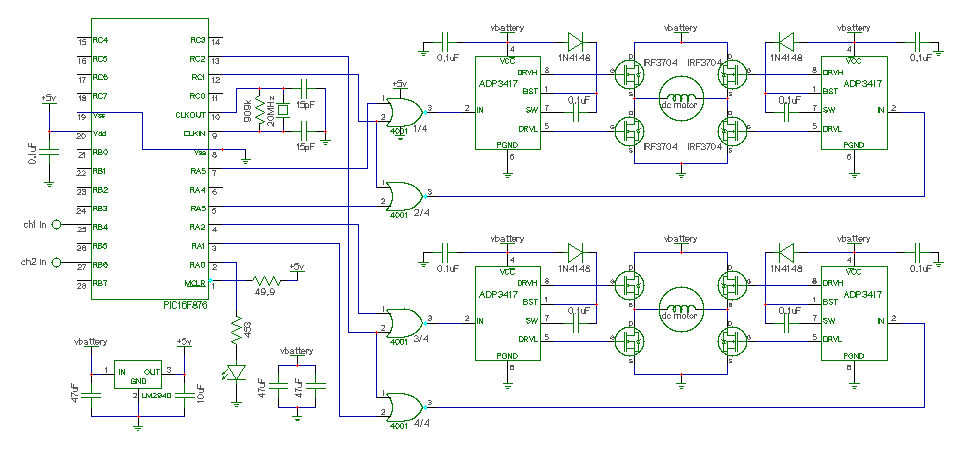
Dual DC motor speed control
Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC...
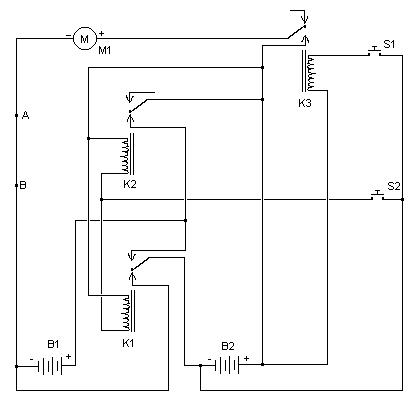
DC 2 speed Motor Controller
The simplest of all motor controllers (besides a straight on/off switch) is the contactor controller. I designed this contactor controller for use in my electric scooter project. It is based around three 12V relays, two 12V batteries, two switches and...
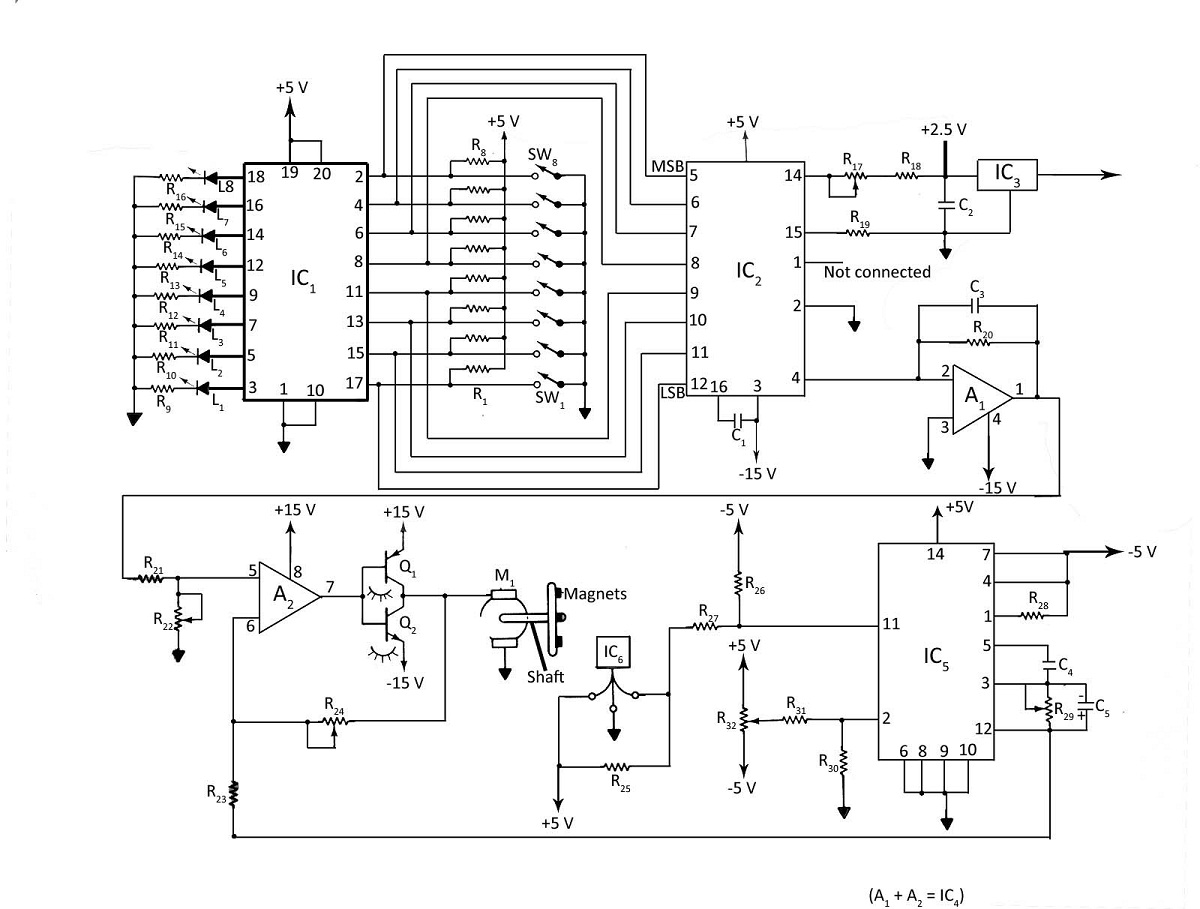
Digital DC Motor Speed Control With LED Display
Various techniques can be employed to control the speed of a DC motor, including phase-locked-loop principles, digital inputs, or analog inputs. Additionally, the motor's speed can be monitored using LED or LCD displays. The digital DC motor speed controller project...
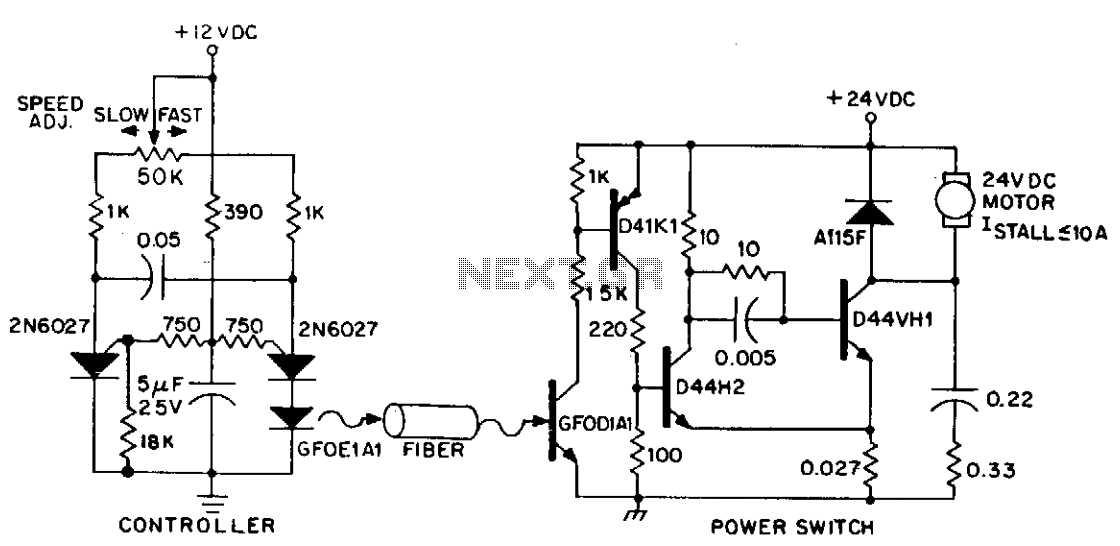
DC variable speed motor control
DC power can also be controlled using fiber optics. The circuit provides an insulated speed control path for a small DC actuator motor (less than Vn hp). The control logic is a self-contained module that requires approximately 300 mW at...
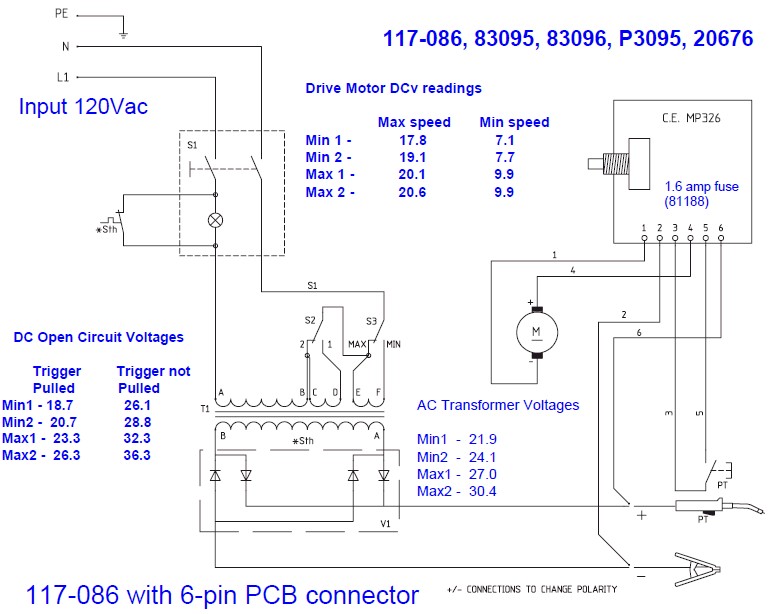
Need Help Deciphering Circuit Board Schematic
The wire speed DC motor consistently receives approximately 20 volts, irrespective of the switch position on the nozzle handle. The switch has been tested with an ohmmeter and functions properly. Even after disconnecting the switch from the circuit board, the...
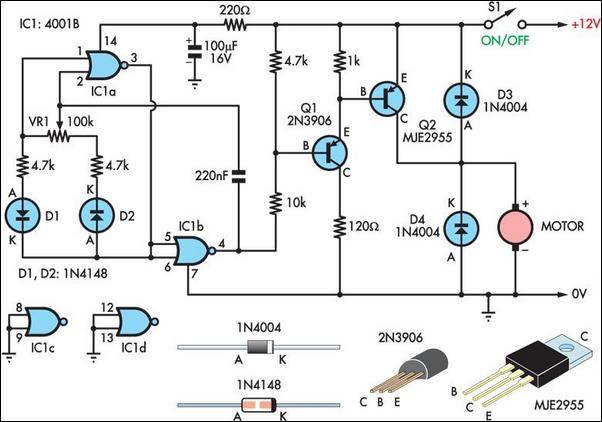
Two Basic Motor Speed Controllers
Two simple 12V DC motor speed controllers can be constructed for a minimal cost. These controllers take advantage of the principle that the rotational speed of a DC motor is directly proportional to the average value of its supply voltage....