


Dual DC motor speed control
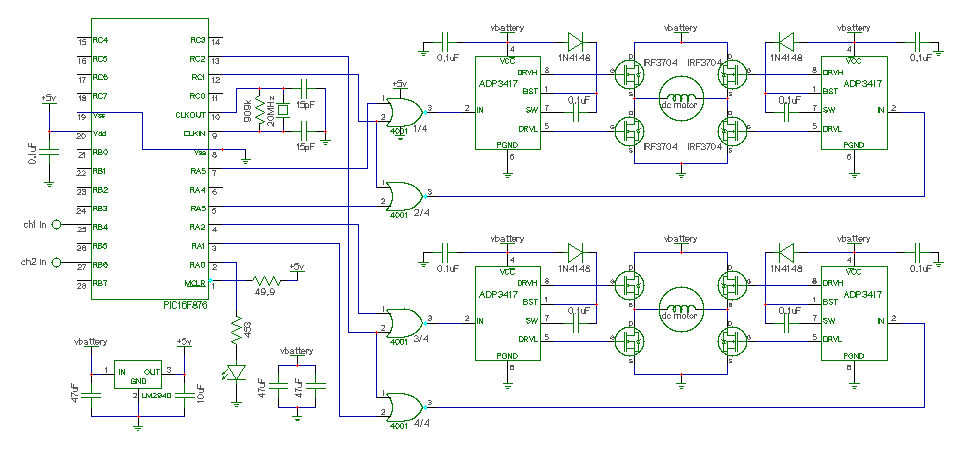
Description: Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC hobby receivers. Individual control of 2 motors. Mixing of steering and throttle into "tank like" drive control. BEC (battery eliminator circuit). Proportional forward and reverse on both motors. A Microchip PIC16F876 interfaces to a standard 2 channel RC receiver. The PIC device mixes the 2 channels together, and generates 2 PWM signals, and 4 direction signals. 4 4001 NOR gates combine the direction and PWM signals to drive Analog Devices ADP3417 MOSFET hi-lo drivers. More: The IRF3704 power MOSFET device was chosen for its large current capacity, low on resistance, and low gate threshold voltage. This device also has a large built-in reverse P-N junction diode capable of large currents, thus eliminating the need for external fly-back diodes. The ADP3417 MOSFET driver was ideal for this application. It operates with very low supply voltages, includes overlap protection (to make sure both hi and lo devices are never on at the same time), performs the bootstrap operation for the hi MOSFET, and uses very little supply current. The LM2940 regulator was chosen for its low dropout voltage (0.5v at 1.0amp load) features reverse battery protection, has a short circuit current limit, and also has thermal overload protection. Finally, the PIC16F876 was chosen for its 2 PWM outputs and large program space. This made the software easy to implement. A smaller PIC could have been used, but would make software development harder. To ease the job of building the circuit board, all of the parts were ordered in a large DIP format. A large format crystal was also ordered. The ADP3417 was only available in a small SOIC package, but it was soldered onto a DIP socket anyway. A much smaller circuit board could be built by using smaller SOIC packages for all of the components. The MOSFET devices are not heatsinked. This is a bad idea, but the DC motors being used don't draw much current (maybe 5 amps max, 0.5 amps typ), so the MOSFETs don't get hot.
The described circuit is an advanced DC motor speed control system utilizing an efficient PWM H-bridge configuration based on MOSFET technology. The design operates within a supply voltage range of 4.2 to 13 volts and can handle high currents up to 65 amps, making it suitable for driving large motors. It is designed to interface with standard RC hobby receivers, allowing for individual control of two motors. The system facilitates a "tank-like" driving experience by mixing steering and throttle inputs, which is particularly beneficial for robotics and remote-controlled vehicles.
At the core of the control logic is a Microchip PIC16F876 microcontroller, which receives signals from a two-channel RC receiver. The microcontroller processes these signals, generating two PWM outputs and four direction control signals. The use of four 4001 NOR gates enables the combination of PWM and direction signals, effectively driving the Analog Devices ADP3417 MOSFET high-low drivers. The ADP3417 is specifically chosen for its capability to operate at low supply voltages and includes features such as overlap protection to prevent simultaneous conduction of high and low side MOSFETs, thus enhancing reliability and efficiency.
The power MOSFETs utilized in this design are the IRF3704, selected for their high current handling capacity, low on-resistance, and low gate threshold voltage. The inclusion of an internal P-N junction diode within the MOSFETs eliminates the need for additional fly-back diodes, simplifying the circuit design.
To ensure stable operation, the design incorporates an LM2940 voltage regulator, which provides a low dropout voltage of 0.5 volts at a 1 amp load. This regulator also features reverse battery protection, short circuit current limiting, and thermal overload protection, contributing to the overall robustness of the system.
The choice of the PIC16F876 microcontroller is strategic, as it offers two PWM outputs and ample program space, facilitating easier software development. Although smaller PIC microcontrollers could have been employed, the larger model simplifies the coding process.
For practical assembly, all components were ordered in a DIP format, with the exception of the ADP3417, which was adapted to a DIP socket despite its SOIC package. This decision reflects a preference for ease of assembly over compactness, although a more space-efficient design could be achieved by utilizing smaller packages for all components. The design does not incorporate heatsinks for the MOSFETs, which is generally advisable; however, the expected current draw from the motors is low enough to mitigate overheating concerns.Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC hobby receivers. Individual control of 2 motors. Mixing of steering and throttle into "tank like" drive control. BEC (battery eliminator circuit). Proportional forward and reverse on both motors. A Microchip PIC16F876 interfaces to a standard 2 channel RC receiver. The PIC device mixes the 2 channels together, and generates 2 PWM signals, and 4 direction signals. 4 4001 NOR gates combine the direction and PWM signals to drive Analog Devices ADP3417 MOSFET hi-lo drivers. The IRF3704 power MOSFET device was chosen for it's large current capacity, low on resistance, and low gate threshold voltage. This device also has a large built in reverse P-N junction diode capable of large currents, thus eliminating the need for external fly-back diodes.
The ADP3417 MOSFET driver was ideal for this application. It operates with very low supply voltages, includes overlap protection (to make sure both hi and lo devices are never on at the same time), performs the bootstrap operation for the hi MOSFET, and uses very little supply current. The LM2940 regulator was chosen for it's low dropout voltage (0.5v at 1.0amp load) features reverse battery protection, has a short circuit current limit, and also has thermal overload protection.
Finally the PIC16F876 was chosen for it's 2 PWM outputs and large program space. This made the software easy to implement. A smaller PIC could have been used, but would make software development harder. To ease my job building the circuit board, I ordered all of the parts in a large DIP format. I even ordered a large format crystal. The ADP3417 was only available in a small SOIC package, but I soldered it onto a DIP socket anyway. A much smaller circuit board could be built by using smaller SOIC packages for all of the components. The MOSFET devices are not heatsinked. This is a bad idea, but the DC motors I am using don't draw much current (maybe 5 amps max, 0.5 amps typ), so the MOSFETs don't get hot.
The described circuit is an advanced DC motor speed control system utilizing an efficient PWM H-bridge configuration based on MOSFET technology. The design operates within a supply voltage range of 4.2 to 13 volts and can handle high currents up to 65 amps, making it suitable for driving large motors. It is designed to interface with standard RC hobby receivers, allowing for individual control of two motors. The system facilitates a "tank-like" driving experience by mixing steering and throttle inputs, which is particularly beneficial for robotics and remote-controlled vehicles.
At the core of the control logic is a Microchip PIC16F876 microcontroller, which receives signals from a two-channel RC receiver. The microcontroller processes these signals, generating two PWM outputs and four direction control signals. The use of four 4001 NOR gates enables the combination of PWM and direction signals, effectively driving the Analog Devices ADP3417 MOSFET high-low drivers. The ADP3417 is specifically chosen for its capability to operate at low supply voltages and includes features such as overlap protection to prevent simultaneous conduction of high and low side MOSFETs, thus enhancing reliability and efficiency.
The power MOSFETs utilized in this design are the IRF3704, selected for their high current handling capacity, low on-resistance, and low gate threshold voltage. The inclusion of an internal P-N junction diode within the MOSFETs eliminates the need for additional fly-back diodes, simplifying the circuit design.
To ensure stable operation, the design incorporates an LM2940 voltage regulator, which provides a low dropout voltage of 0.5 volts at a 1 amp load. This regulator also features reverse battery protection, short circuit current limiting, and thermal overload protection, contributing to the overall robustness of the system.
The choice of the PIC16F876 microcontroller is strategic, as it offers two PWM outputs and ample program space, facilitating easier software development. Although smaller PIC microcontrollers could have been employed, the larger model simplifies the coding process.
For practical assembly, all components were ordered in a DIP format, with the exception of the ADP3417, which was adapted to a DIP socket despite its SOIC package. This decision reflects a preference for ease of assembly over compactness, although a more space-efficient design could be achieved by utilizing smaller packages for all components. The design does not incorporate heatsinks for the MOSFETs, which is generally advisable; however, the expected current draw from the motors is low enough to mitigate overheating concerns.Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC hobby receivers. Individual control of 2 motors. Mixing of steering and throttle into "tank like" drive control. BEC (battery eliminator circuit). Proportional forward and reverse on both motors. A Microchip PIC16F876 interfaces to a standard 2 channel RC receiver. The PIC device mixes the 2 channels together, and generates 2 PWM signals, and 4 direction signals. 4 4001 NOR gates combine the direction and PWM signals to drive Analog Devices ADP3417 MOSFET hi-lo drivers. The IRF3704 power MOSFET device was chosen for it's large current capacity, low on resistance, and low gate threshold voltage. This device also has a large built in reverse P-N junction diode capable of large currents, thus eliminating the need for external fly-back diodes.
The ADP3417 MOSFET driver was ideal for this application. It operates with very low supply voltages, includes overlap protection (to make sure both hi and lo devices are never on at the same time), performs the bootstrap operation for the hi MOSFET, and uses very little supply current. The LM2940 regulator was chosen for it's low dropout voltage (0.5v at 1.0amp load) features reverse battery protection, has a short circuit current limit, and also has thermal overload protection.
Finally the PIC16F876 was chosen for it's 2 PWM outputs and large program space. This made the software easy to implement. A smaller PIC could have been used, but would make software development harder. To ease my job building the circuit board, I ordered all of the parts in a large DIP format. I even ordered a large format crystal. The ADP3417 was only available in a small SOIC package, but I soldered it onto a DIP socket anyway. A much smaller circuit board could be built by using smaller SOIC packages for all of the components. The MOSFET devices are not heatsinked. This is a bad idea, but the DC motors I am using don't draw much current (maybe 5 amps max, 0.5 amps typ), so the MOSFETs don't get hot.
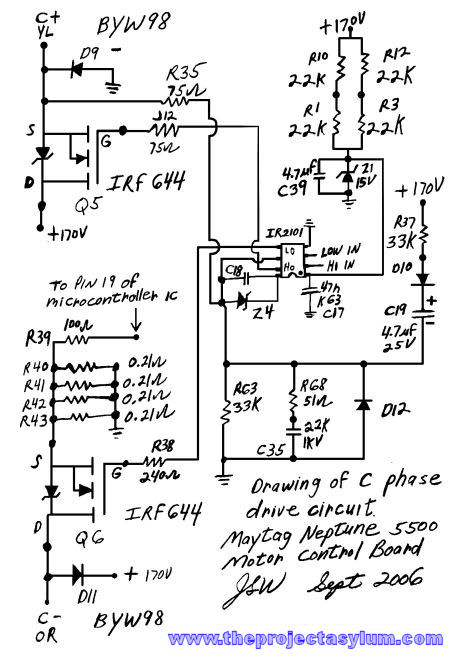
Maytag Neptune Schematic
This circuit is repeated for each of the three motor phases. The experience with repairing the motor control board in this washer involved a failure of the Q5 MOSFET on the C phase of the motor drive circuit, along with...
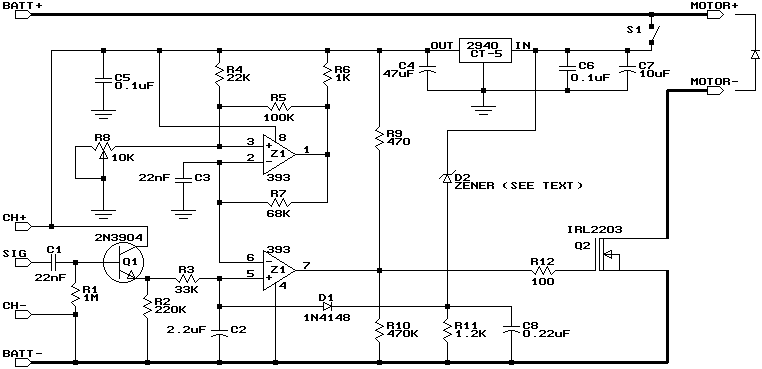
Build a Miniature High-Rate Speed Control with Battery Eliminator Circuit (BEC)
This design is based on a publication by Milan Lulic in the German magazine elektroModell. Lulic's design utilizes surface mount technology (SMT), while this version employs standard off-the-shelf components, making it more accessible for hobbyists. For those interested in a...
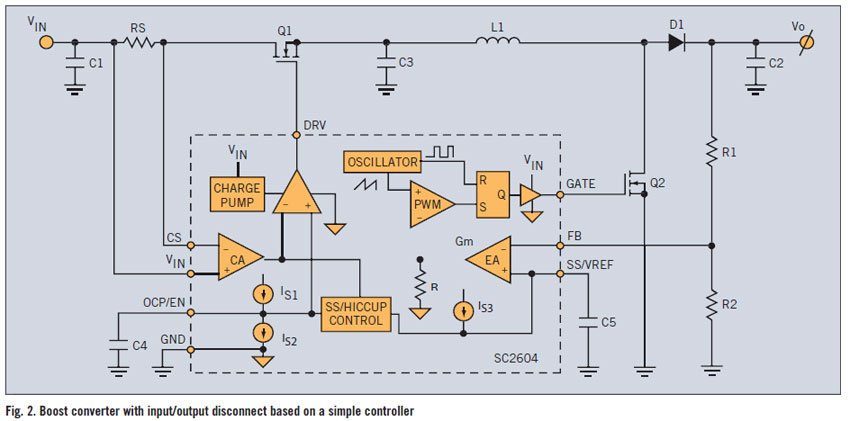
simple pwm boost converter io disconnect solves malfunctions
A PWM boost converter in a simple controller has a DC path from input VIN to VOUT, which is utilized for high-efficiency power conversion.
A PWM (Pulse Width Modulation) boost converter is an essential component in power electronics, designed to step...
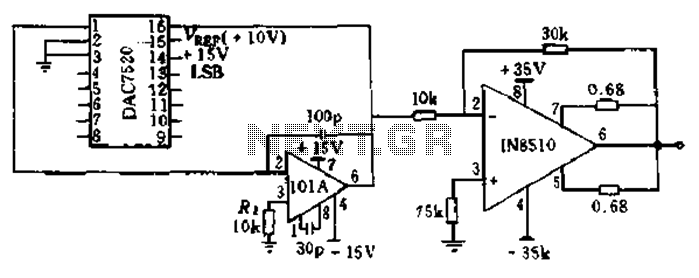
IN8510 and power motor driver circuit composed of DAC7520
The BTS412B functions as two high-side power MOSFET switches, while the BU271L components rated for 50V serve as the low-side switches. Together, these elements can form a bi-directional H-bridge DC motor drive circuit, as depicted in Figure 11-1l. This circuit...
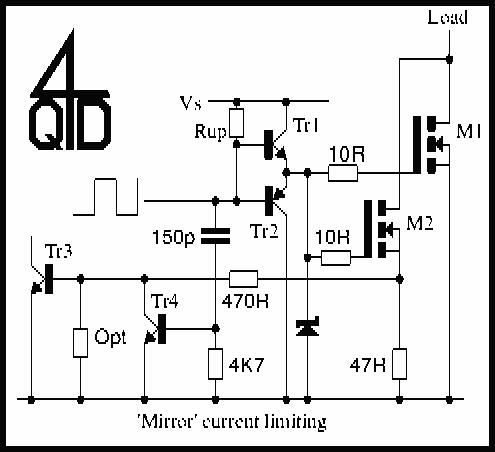
MOSFET current sensing
The circuit shows the method of mirror current sensing a MOSFET. A fully conducting MOSFET is resistive and behaves exactly as a resistor. It therefore you limit the voltage across the MOSFET when it is conducting you automatically limit the...
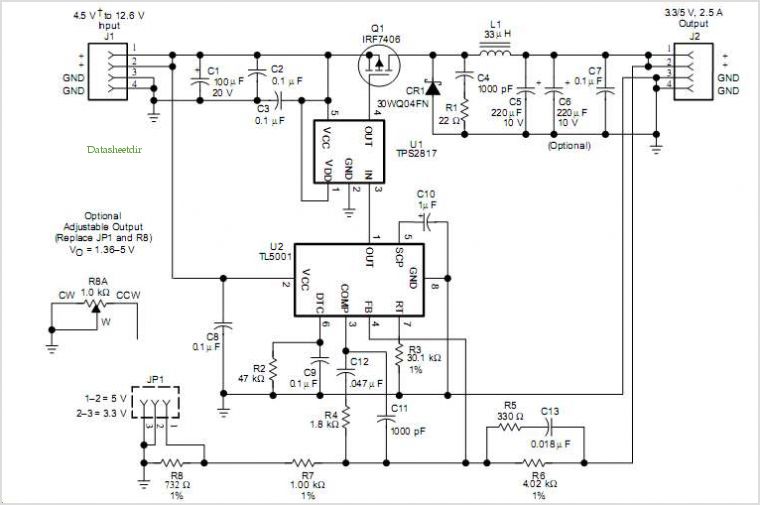
Tl5001 Pulse-width-modulation (pwm) Controller Coupled With A Tps2817 Mosfet Driver
The TLE6282G is an H-Bridge and Half Bridge Driver IC designed for high-current DC brush motor applications in PWM control mode. It is suitable for use in injector and valve applications across 12V, 24V, and 42V power networks. This IC...
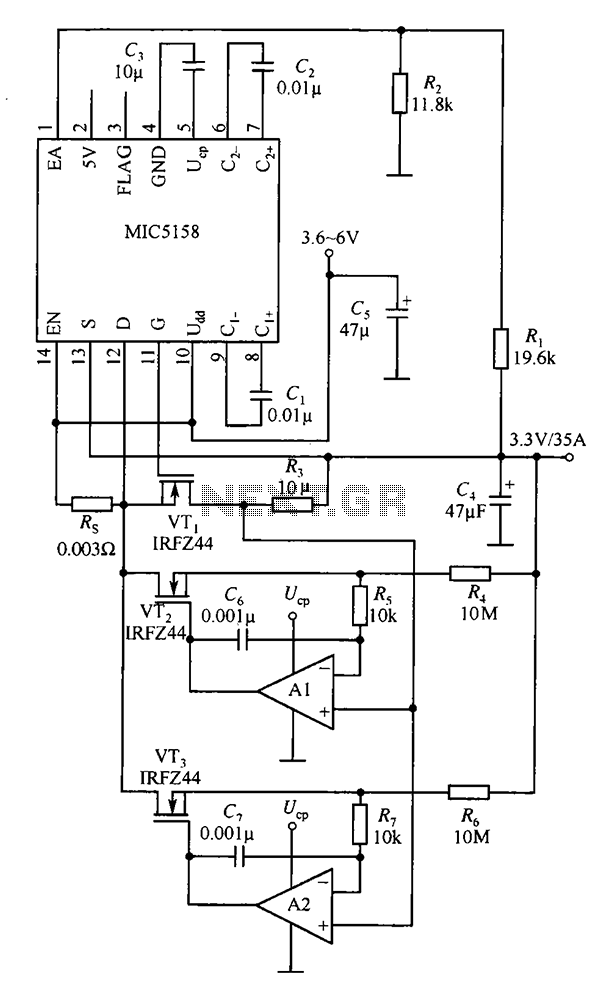
Consisting of a plurality of parallel MOSFET high current output linear regulator circuit MIC5158
The MIC5158 is designed to manage tasks by controlling multiple external N-channel MOSFETs in parallel, which enables high current or high power output for a linear regulator circuit. This is illustrated in the accompanying figure. The operational amplifier circuit functions...
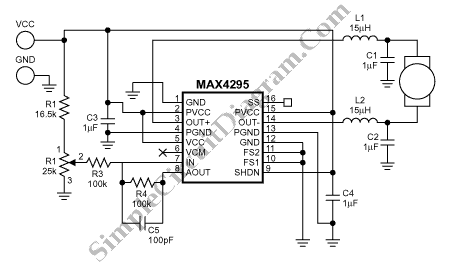
PWM Motor Speed Control Using Class D Audio Amplifier
This is a Class D audio amplifier circuit used to control the PWM motor speed. This circuit has two advantages for battery-powered portable devices. First, it provides high efficiency, which extends battery life.
The Class D audio amplifier operates by modulating...
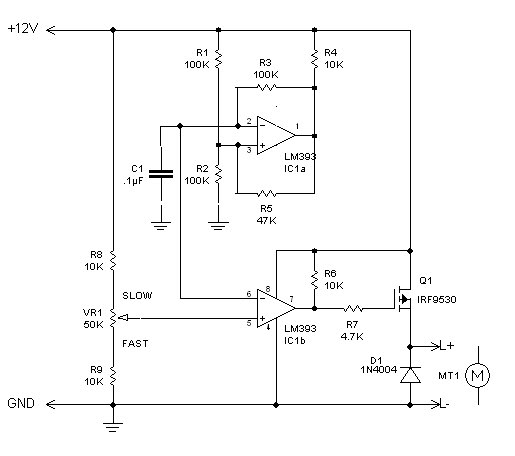
PWM circuit
The inquiry pertains to identifying the component within the circuit that regulates the minimum RPM achievable. The current operational range of the motor is between 1400 and 3700 RPM, and there is an interest in modifying the circuit to lower...