


Build a Miniature High-Rate Speed Control with Battery Eliminator Circuit (BEC)
#speed control
#BEC
#battery eliminator circuit
#hobbyist
#SMT
#off-the-shelf components
#current control
#DIY
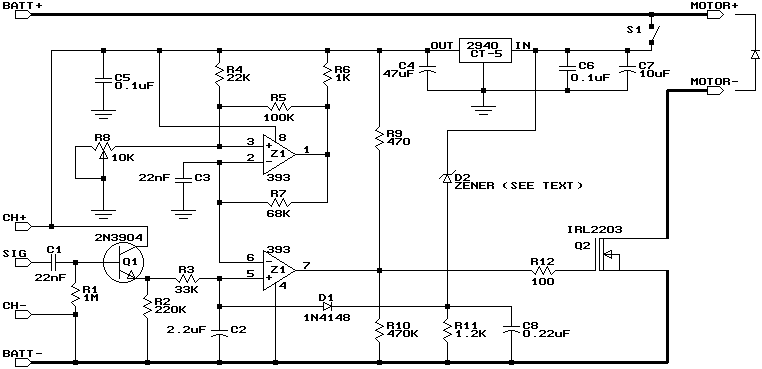
Description: This design is based on a publication by Milan Lulic in the German magazine elektroModell. Lulic's design utilizes surface mount technology (SMT), while this version employs standard off-the-shelf components, making it more accessible for hobbyists. For those interested in a non-BEC speed control with higher current capacity and a brake, please refer to another article titled "A Miniature High-Rate Speed Control with Brake." The circuit begins with a buffer, consisting of capacitor C1, resistor R1, and transistor Q1. This buffer isolates the receiver from the rest of the circuit, allowing for operation that is somewhat independent of the receiver model (though R8 may need adjustment if the receiver type is changed). Resistors R2, R3, and capacitor C2 create an integrator that generates an output voltage proportional to the input signal's pulse width. This output voltage ranges from approximately 1.15V for a 1ms input to 1.45V for a 2ms input at a frequency of 50 pulses per second. Zener diode Z1A, along with resistors R4 to R8 and capacitor C3, forms a 2.5kHz triangle wave generator. R8 adjusts the upper and lower limits of the triangle wave, which also influences the frequency, although this effect is not significant within the adjustment range. When properly set, the triangle wave across C3 oscillates between about 1.2V and 1.4V, covering the middle two-thirds of the integrator voltage range. Z1B functions as a comparator, comparing the integrator voltage with the triangle wave. When the integrator voltage exceeds the triangle wave voltage, Z1B outputs high; when it is lower, the output is low. At zero throttle, the integrator voltage (1.15V) remains below the triangle wave voltage (1.2V to 1.4V), keeping Z1B low. At full throttle, the integrator voltage (1.45V) is always above the triangle wave voltage, resulting in Z1B being high. At half throttle, the integrator voltage (1.3V) is above the triangle wave voltage half the time, causing Z1B to toggle high and low. The LM2940CT-5 low dropout voltage regulator provides the BEC functionality. Power from the motor battery flows through the arming/on-off switch S1 and is filtered by capacitors C6 and C7. The LM2940 outputs 5V, with C4 providing additional filtering and stabilization for the regulator while C5 offers further filtering. Diodes D1 and D2, along with resistor R11 and capacitor C8, constitute the low-voltage cut-off circuit. D2 is a Zener diode selected according to the desired cell count and cut-off voltage. The value for D2 should be the desired cut-off level minus 0.7 volts. For instance, with a configuration of 7x600AA cells, a reasonable cut-off level is 6.3V, or 0.9V per cell, making the appropriate value for D2 equal to 5.6V. As the motor battery voltage drops below the cut-off level, the voltage at the junction of D1, D2, R11, and C8 falls below 0.7V, which pulls the voltage at pin 5 of Z1 below 1.4V. R11 and C8 filter any motor noise from interfering with the control section of the circuit. The following table presents recommended Zener diode values for configurations of 6 to 10 cells, with the closest commonly available Zener voltages indicated. Cut-off levels around 0.9V per cell (highlighted in green) are suitable for high internal resistance cells such as 600AA or 600AE, while cut-off levels around 1.0V per cell (highlighted in yellow) are appropriate for low resistance cells like the 1000SCR.
The circuit design effectively demonstrates a robust approach to speed control in hobbyist applications, utilizing standard components to enhance accessibility while maintaining functionality. The integration of a buffer, integrator, triangle wave generator, and comparator ensures precise control of motor speed based on input signals, with provisions for low-voltage cut-off to protect the battery and ensure reliable operation. The use of a low dropout voltage regulator further enhances the reliability of the circuit, providing stable power to the control system. This design is particularly advantageous for hobbyists who may not have access to SMT components, allowing for easier assembly and troubleshooting.This design is based on one published by Milan Lulic in the German magazine elektroModell. Mr. Lulic`s design is for surface mount technology (SMT) construction, whereas mine uses standard off-the-shelf components, and is therefore better suited to construction by the hobbyist. If you`re interested in a non-BEC speed control with higher current capacity, and a brake, please see my other article, A Miniature High-Rate Speed Control with Brake. The circuit begins with a buffer, consisting of C1, R1, and Q1. This provides some isolation between the receiver and the rest of the circuit, and makes circuit operation somewhat independent of the model of receiver (although you may have to adjust R8 if you change receiver types). R2, R3, and C2 form an integrator, which produces an output voltage proportional to the pulse width of the input signal.
This output voltage varies from approximately 1. 15V for a 1ms input to 1. 45V for a 2ms input (at 50 pulses per second). Z1A, together with R4 through R8, and C3, form a 2. 5kHz triangle wave generator. R8 adjusts the upper and lower bounds of the triangle wave (it also affects the frequency, but within the range over which R8 must be adjusted, this is not significant). When properly adjusted, the triangle wave (which appears across C3) will oscillate between about 1. 2V and 1. 4V. This covers the middle 2/3 of the range that the integrator voltage covers. Z1B is used as a comparator, which compares the integrator voltage with the triangle wave. When the integrator voltage is above the voltage of the triangle wave, the output of Z1B is high; when it is below, it is low.
At zero throttle, the integrator voltage (1. 15V) is always below the triangle wave voltage (1. 2V to 1. 4V), so Z1B remains low. At full throttle, the integrator voltage (1. 45V) is always above the triangle wave voltage, so Z1B remains high. At half throttle, the integrator voltage (1. 3V) is above the triangle wave voltage half the time, so Z1B is high half the time and low half the time. The LM2940CT-5 low dropout voltage regulator provides the BEC facility. Power from motor battery flows through the arming/on-off switch S1, and is filtered by C6 and C7. The 2940 produces 5V on its output. C4 provides filtering, and also stabilizes the regulator. C5 provides additional filtering. D1, D2, R11, and C8 form the low-voltage cut-off circuit. D2 is a Zener diode which must be selected based on the desired cell count and cut-off voltage. The value of D2 should be the desired cut-off level minus 0. 7 volts. For example, with 7x600AA cells, a reasonable cut-off level is 6. 3V, or 0. 9V per cell. The desired value for D2 is thus 5. 6V. As the motor battery voltage drops below the cut-off level, the voltage at the junction of D1, D2, R11, and C8 drops below 0.
7V. This pulls the voltage at pin 5 of Z1 below 1. 4V. R11 and C8 serve to filter any motor noise from getting back into the control part of the circuit. The following table shows suggested Zener diode values for 6 to 10 cells: In each case, the closest commonly available Zener voltages are shown. Cut-off levels of around 0. 9V per cell (the green rows) are suitable for high internal resistance cells such as 600AA or 600AE. Cut-off levels of around 1. 0V per cell (the yellow rows) are suitable for low resistance cells, such as the 1000SCR. Note
The circuit design effectively demonstrates a robust approach to speed control in hobbyist applications, utilizing standard components to enhance accessibility while maintaining functionality. The integration of a buffer, integrator, triangle wave generator, and comparator ensures precise control of motor speed based on input signals, with provisions for low-voltage cut-off to protect the battery and ensure reliable operation. The use of a low dropout voltage regulator further enhances the reliability of the circuit, providing stable power to the control system. This design is particularly advantageous for hobbyists who may not have access to SMT components, allowing for easier assembly and troubleshooting.This design is based on one published by Milan Lulic in the German magazine elektroModell. Mr. Lulic`s design is for surface mount technology (SMT) construction, whereas mine uses standard off-the-shelf components, and is therefore better suited to construction by the hobbyist. If you`re interested in a non-BEC speed control with higher current capacity, and a brake, please see my other article, A Miniature High-Rate Speed Control with Brake. The circuit begins with a buffer, consisting of C1, R1, and Q1. This provides some isolation between the receiver and the rest of the circuit, and makes circuit operation somewhat independent of the model of receiver (although you may have to adjust R8 if you change receiver types). R2, R3, and C2 form an integrator, which produces an output voltage proportional to the pulse width of the input signal.
This output voltage varies from approximately 1. 15V for a 1ms input to 1. 45V for a 2ms input (at 50 pulses per second). Z1A, together with R4 through R8, and C3, form a 2. 5kHz triangle wave generator. R8 adjusts the upper and lower bounds of the triangle wave (it also affects the frequency, but within the range over which R8 must be adjusted, this is not significant). When properly adjusted, the triangle wave (which appears across C3) will oscillate between about 1. 2V and 1. 4V. This covers the middle 2/3 of the range that the integrator voltage covers. Z1B is used as a comparator, which compares the integrator voltage with the triangle wave. When the integrator voltage is above the voltage of the triangle wave, the output of Z1B is high; when it is below, it is low.
At zero throttle, the integrator voltage (1. 15V) is always below the triangle wave voltage (1. 2V to 1. 4V), so Z1B remains low. At full throttle, the integrator voltage (1. 45V) is always above the triangle wave voltage, so Z1B remains high. At half throttle, the integrator voltage (1. 3V) is above the triangle wave voltage half the time, so Z1B is high half the time and low half the time. The LM2940CT-5 low dropout voltage regulator provides the BEC facility. Power from motor battery flows through the arming/on-off switch S1, and is filtered by C6 and C7. The 2940 produces 5V on its output. C4 provides filtering, and also stabilizes the regulator. C5 provides additional filtering. D1, D2, R11, and C8 form the low-voltage cut-off circuit. D2 is a Zener diode which must be selected based on the desired cell count and cut-off voltage. The value of D2 should be the desired cut-off level minus 0. 7 volts. For example, with 7x600AA cells, a reasonable cut-off level is 6. 3V, or 0. 9V per cell. The desired value for D2 is thus 5. 6V. As the motor battery voltage drops below the cut-off level, the voltage at the junction of D1, D2, R11, and C8 drops below 0.
7V. This pulls the voltage at pin 5 of Z1 below 1. 4V. R11 and C8 serve to filter any motor noise from getting back into the control part of the circuit. The following table shows suggested Zener diode values for 6 to 10 cells: In each case, the closest commonly available Zener voltages are shown. Cut-off levels of around 0. 9V per cell (the green rows) are suitable for high internal resistance cells such as 600AA or 600AE. Cut-off levels of around 1. 0V per cell (the yellow rows) are suitable for low resistance cells, such as the 1000SCR. Note
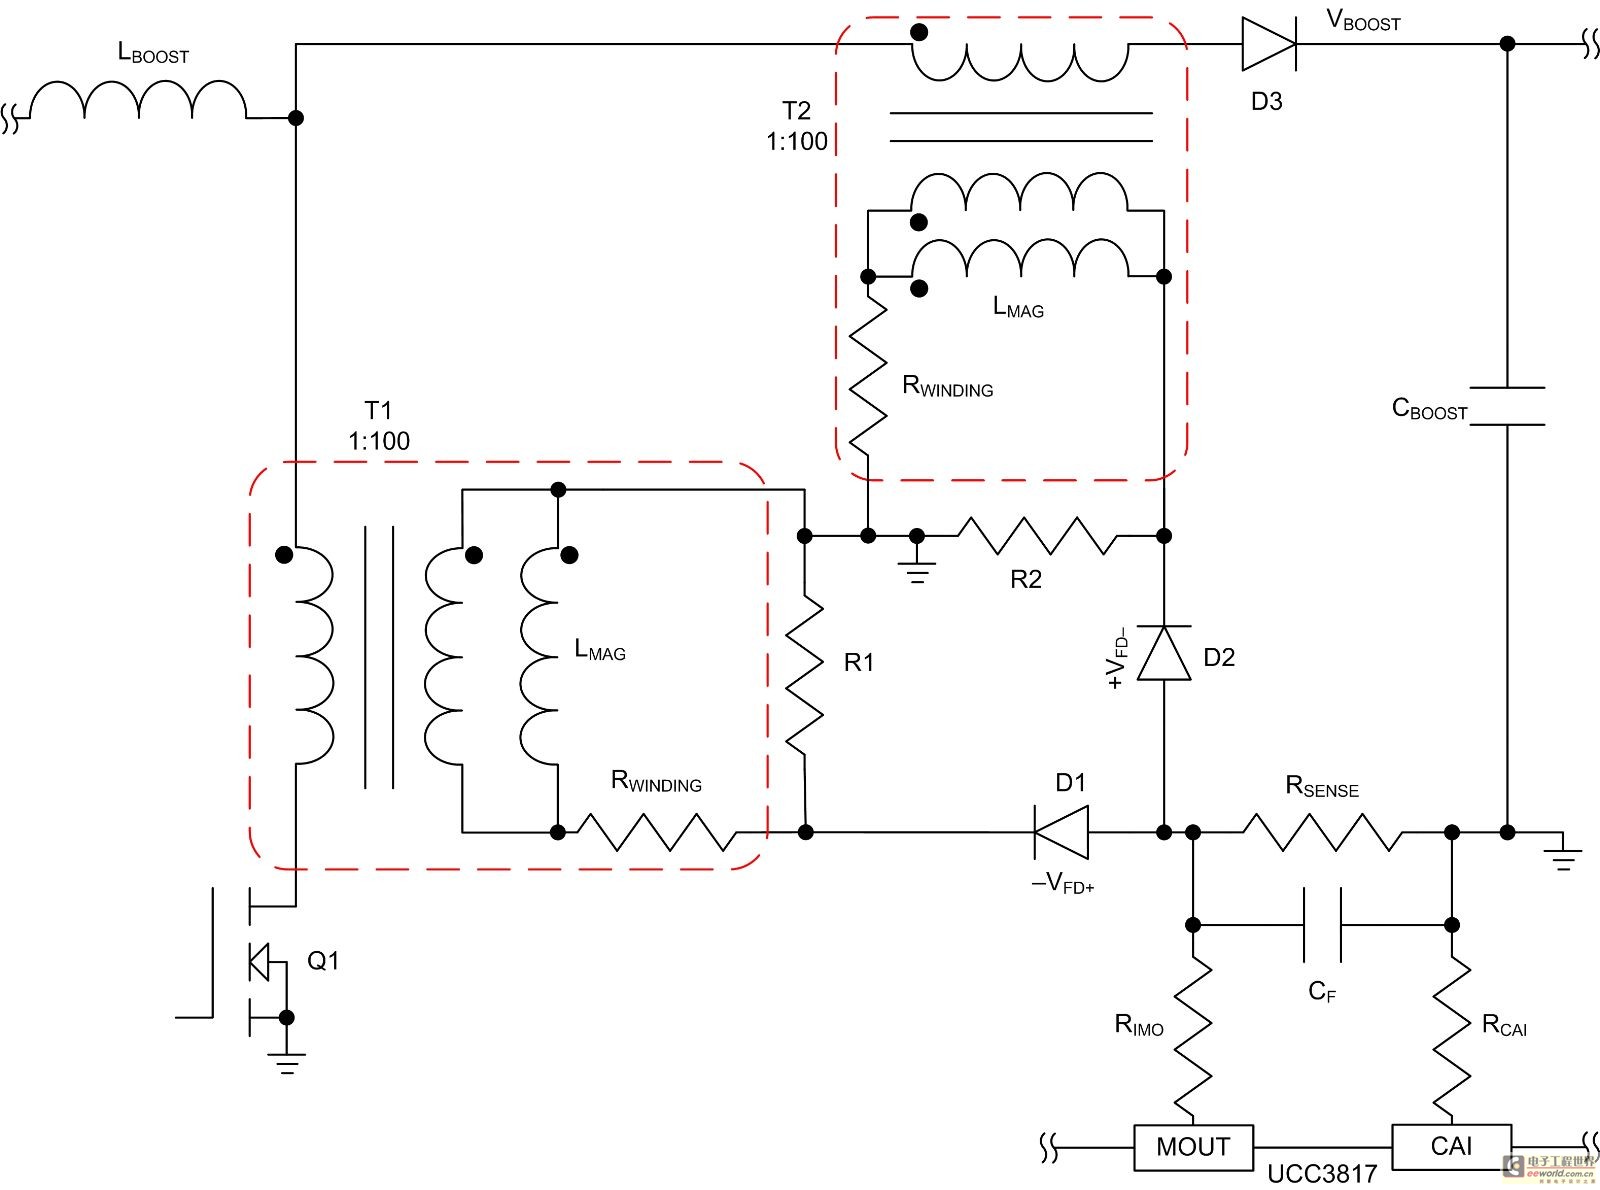
The electric current of mode control of the average current measures the circuit design of the voltage transformer
Mode control of the average current (CMC) is necessary to regulate the overall waveform of electric current during the rebuilding cycle. This text recommends selecting specific parameters related to the voltage transformer and outlines steps for designing a circuit that...
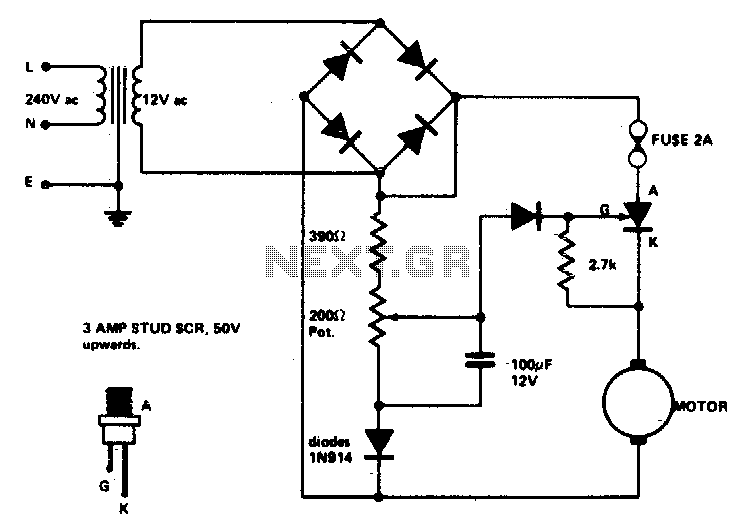
Speed control for model trains or cars
Low voltage speed control provides excellent starting torque and effective speed regulation. Additionally, a reversing switch can be integrated into the motor leads.
Low voltage speed control circuits are essential in applications where precise motor control is required, such as in...
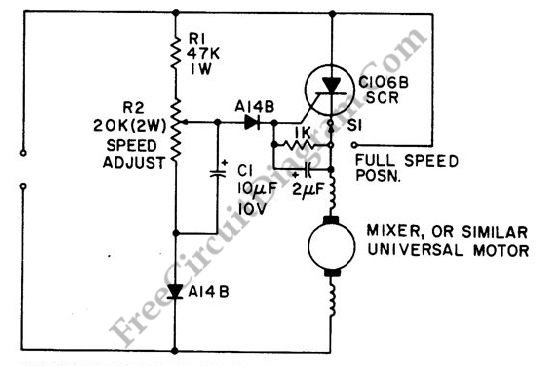
Mixer or Sewing Machine Motor Speed Control
A simple half-wave motor speed control circuit is effective for small universal AC/DC motors, with a maximum current capability of two amps RMS.
The half-wave motor speed control circuit utilizes a diode to allow current to flow in only one direction,...
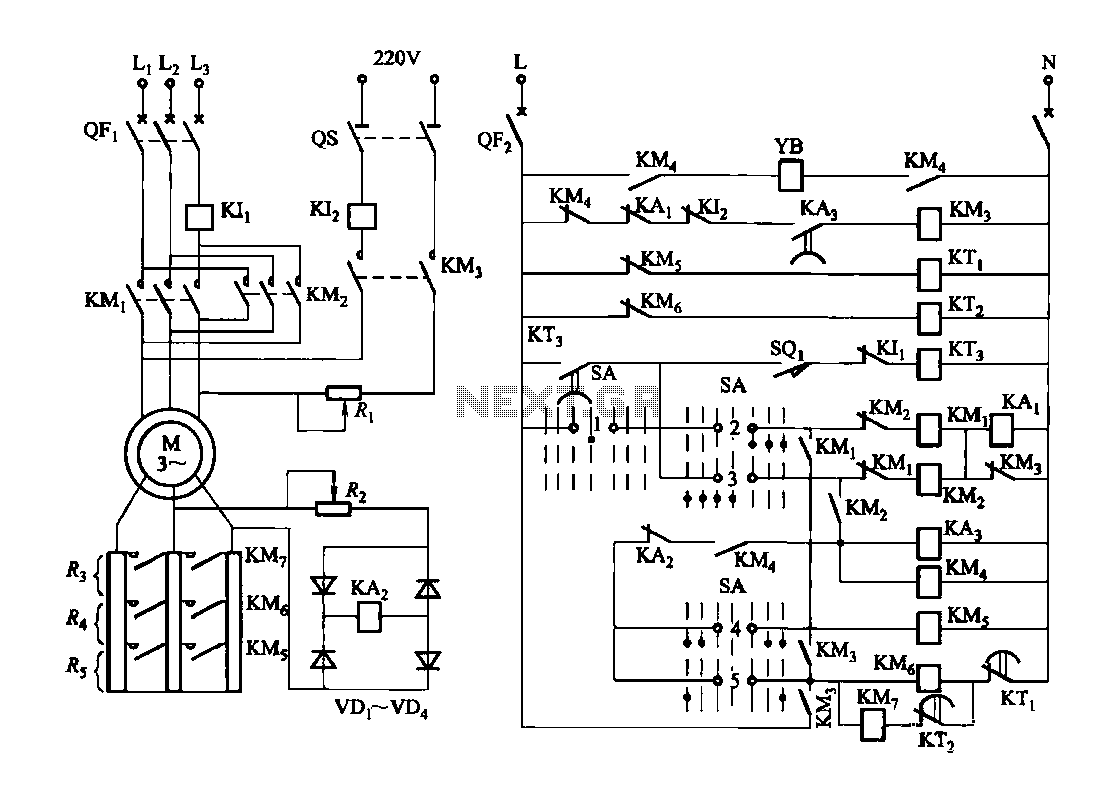
Forward and reverse speed control circuit can be integrated with a brake function
Figure 3173 illustrates a control circuit for a wound rotor induction motor that enables mechanical braking, dynamic braking, and reverse braking functions. The circuit includes various components such as relays, contactors, and time relays to manage the motor's speed in...
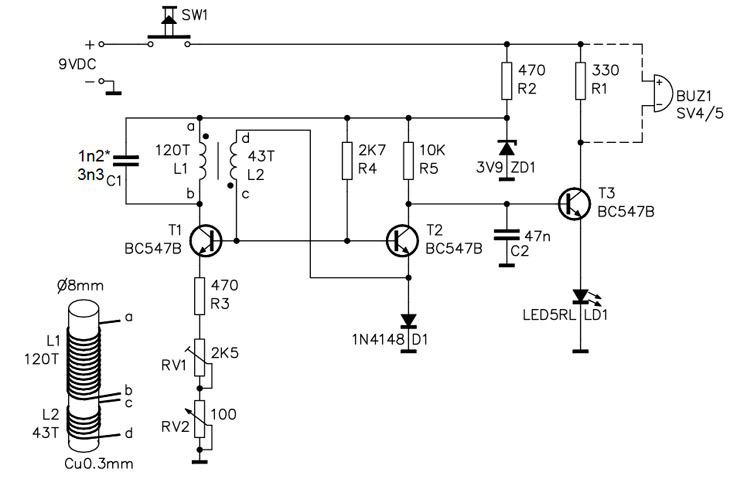
Homemade Metal Detector Kit
A simple home project can quickly become problematic if it encounters electric cables, gas, or water pipes, or the central heating system. Using a metal detector allows one to check for metal objects within walls, ceilings, or floors beforehand. An...
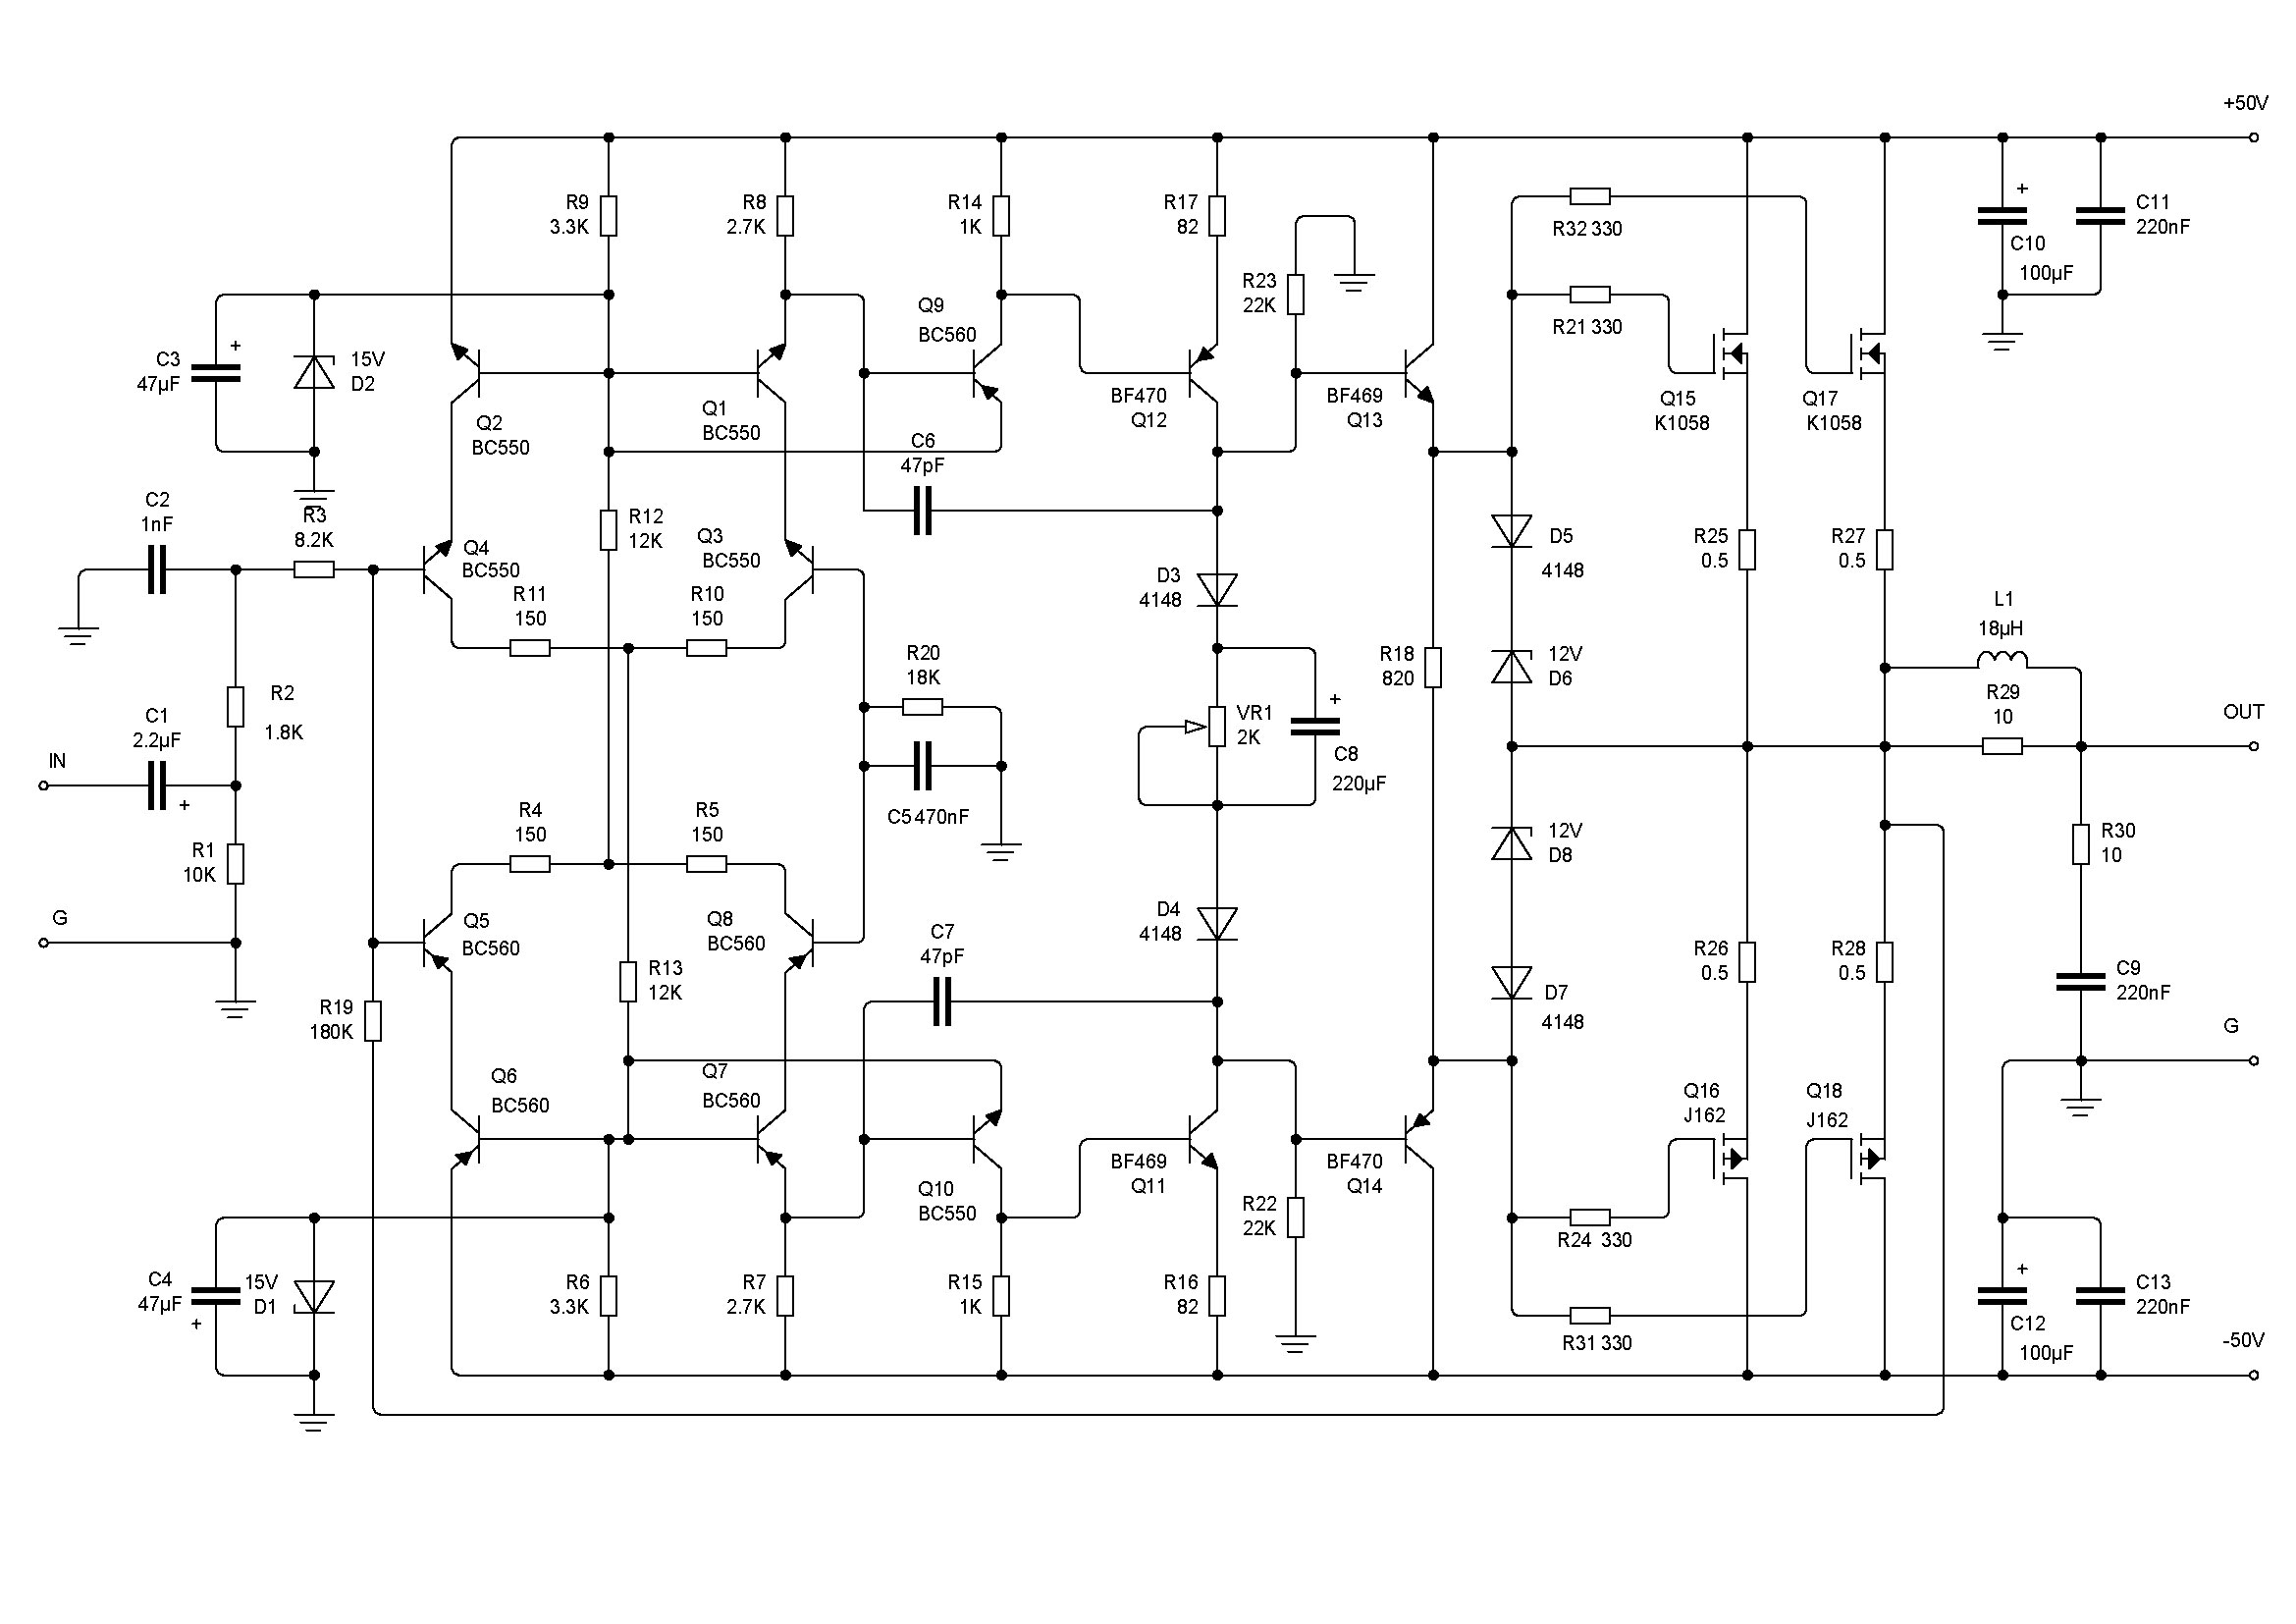
Crescendo ampilifier elektor1982
The Elector Crescendo was the first DIY amplifier that was not a kit. The design was sourced from the Elector magazines available at a local library.
The Elector Crescendo is an innovative audio amplifier designed for DIY enthusiasts. It features a...
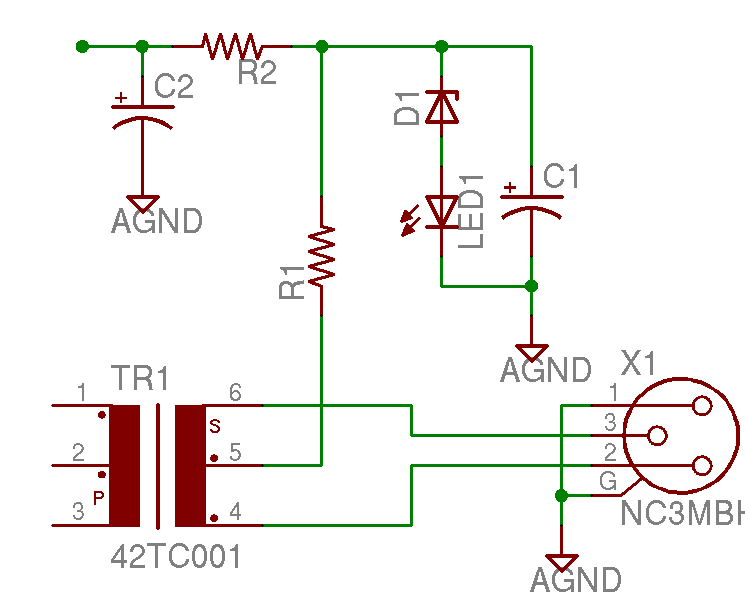
Help with a schematic please
A project is underway to construct the CountryHick DI as illustrated on DIYFactory, incorporating a few minor modifications. The final design aims to be a 1U unit with four inputs.
The CountryHick DI (Direct Injection) box is a crucial tool in...
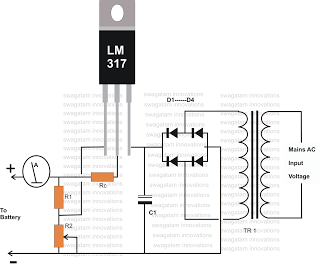
how to make inexpensive current
Charging any type of rechargeable battery is critical and requires attention, particularly regarding the current or rate at which the battery is charged. This factor is essential for maintaining the battery's lifespan and efficiency over time. The circuit diagram presented...
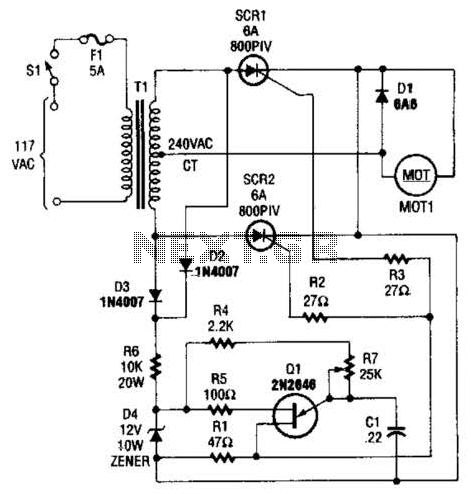
Speed-Control Switch Circuit
The speed-control switch provides effective control and stability across its entire operating range. This circuit utilizes two SCR devices arranged in a full-wave configuration to manage the DC power supplied to a motor. A center-tapped transformer is employed to provide...