


DC 2 speed Motor Controller
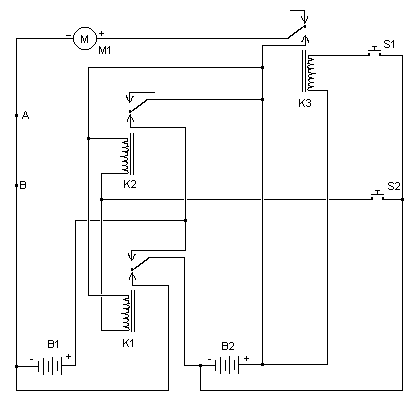
Description: The simplest of all motor controllers (besides a straight on/off switch) is the contactor controller. I designed this contactor controller for use in my electric scooter project. It is based around three 12V relays, two 12V batteries, two switches and of course a motor. Having no silicon to "fry", it is quite reliable and robust. A contactor controller works by rearranging the two (or more) supply batteries between series and parallel. This gives the motor a slow speed (batteries in parallel, current adds) and a fast speed (batteries in series, voltage adds). This assures that both batteries are discharged equally. When the circuit is "at rest", the batteries are connected in parallel, which allows easy recharging. More: K1, K2, K3 3 12V 30A SPDT Relay (See Notes) S1, S2 2 SPST Switch or Button B1, B2 2 12V Battery (See Notes) M1 1 12V or 24V Motor (See Notes) MISC 1 Case, Wire, etc.
Notes
S1 closes K3 and thus causes M1 to operate. S2 activates K1 and K2, reconfiguring the batteries for series operation and thus causes M1 to operate at "fast" speed. B1 and B2 should be chosen based on the current requirements of M1. Often, sealed lead-acid type batteries are available at local suppliers for surprisingly low prices. These batteries are ideal for things such as scooters, go-karts, etc. The relays are standard automotive type relays, available cheaply from any auto parts store. Your motor will depend on your requirements. 12V motors will normally run fine at 24V, and vice versa. You will notice that in series mode, all three relays only pull power from B2. This is because the relays have 12V coils, and it is impossible to switch the batteries from series to parallel and keep power to the coils at the same time. This does, however, mean that B2 is discharged slightly before B1. This should normally not be an issue unless the batteries are being drained completely "dead". Draining a battery dead is not good for it in any situation and should be avoided. If you wish, you can use a small 12V battery to run the relays separately. You can add two more speeds to this controller using the schematic below. It connects at points A and B shown above on the controller schematic. K1 is simply another of the same relay as used in the controller. S1 is another switch. R1 needs to be chosen based on your motor, but it will be of low value (under 10 Ohm) and high wattage (normally at least 100W). It must be capable of handling the full current drawn by the motor. This is not exactly an efficient way to limit current to the motor as excess current is dissipated as heat by the resistor, so it is normally only used for a "starter" speed.
The contactor motor controller is a straightforward yet effective design for controlling the speed of a DC motor, particularly in applications such as electric scooters. The circuit utilizes three 12V relays (K1, K2, K3), two 12V batteries (B1, B2), and two switches (S1, S2) to manage the power supply to the motor (M1).
In the idle state, both batteries are connected in parallel, allowing for easy recharging and ensuring that the voltage remains stable at 12V. When S1 is activated, K3 closes, providing power to the motor and initiating operation at a slow speed. For higher speeds, S2 is engaged, which activates relays K1 and K2 to reconfigure the battery connections into a series configuration. This arrangement increases the voltage supplied to the motor, thus allowing it to operate at a faster speed.
The selection of batteries (B1 and B2) is critical and should be based on the current rating of the motor (M1). Sealed lead-acid batteries are often recommended due to their availability and cost-effectiveness. The relays used in this controller are standard automotive relays rated for 30A, which are suitable for handling the motor's current requirements.
It is important to note that in series mode, only battery B2 supplies power to the relays. This design choice is made to simplify the switching mechanism, though it does lead to a slight imbalance in battery discharge rates. To mitigate potential issues from discharging one battery more than the other, it is advisable to avoid completely draining either battery, as this can lead to reduced battery lifespan.
For users seeking additional speed settings, the circuit can be modified by integrating additional components at designated points in the schematic. This includes adding another relay (K1) and switch (S1) along with a current-limiting resistor (R1), which should be selected based on the motor's specifications. The resistor should be of low resistance (under 10 Ohm) and high wattage to handle the motor's current without overheating.
Overall, this contactor controller design offers a reliable and straightforward solution for controlling motor speed in electric vehicles, with the flexibility to accommodate various battery and motor configurations.The simplest of all motor controllers (besides a straight on/off switch) is the contactor controller. I designed this contactor controller for use in my electric scooter project. It is based around three 12V relays, two 12V batteries, two switches and of course a motor. Having no silicon to "fry", it is quite reliable and robust. A contactor controller works by rearranging the two (or more) supply batteries between series and parallel.
This gives the motor a slow speed (batteries in parallel, current adds) and a fast speed (batteries in series, voltage adds). This assures that both batteries are discharged equally. When the circuit is "at rest", the batteries are connected in parallel, which allows easy recharging.
K1, K2, K3 3 12V 30A SPDT Relay (See Notes) S1, S2 2 SPST Switch or Button B1, B2 2 12V Battery (See Notes) M1 1 12V or 24V Motor (See Notes) MISC 1 Case, Wire, etc. Notes S1 closes K3 and thus causes M1 to operate. S2 activates K1 and K2, reconfiguring the batteries for series operation and thus causes M1 to operate at "fast" speed.
B1 and B2 should be chosen based on the current requirements of M1. Often, sealed lead-acid type batteries are available at local suppliers for surprisingly low prices. These batteries are ideal for things such as scooters, go-karts, etc. The relays are standard automotive type relays, available cheaply from any auto parts store. Your motor will depend on your requirements. 12V motors will normally run fine at 24V, and vice versa. You will notice that in series mode, all three relays only pull power from B2. This is because the relays have 12V coils, and it is impossible to switch the batteries from series to parallel and keep power to the coils at the same time. This does, however, mean that B2 is discharged slighty before B1. This should normally not be an issue unless the batteries are being drained completely "dead". Draining a battery dead is not good for it in any situation, and should be avoided. If you wish, you can use a small 12V battery to run the relays separately. You can add two more speeds to this controller using the schematic below. It connects at points A and B shown above on the controller schematic. K1 is simply another of the same relay as used in the controller. S1 is another switch. R1 needs to be chosen based on your motor, but it will be of low value (under 10 Ohm) and high wattage (normally at least 100W).
It must be capable of handling the full current drawn by the motor. This is not exactly an efficient way to limit current to the motor as excess current is dissipated as heat by the resistor, so it is normally only used for a "starter" speed.
Notes
S1 closes K3 and thus causes M1 to operate. S2 activates K1 and K2, reconfiguring the batteries for series operation and thus causes M1 to operate at "fast" speed. B1 and B2 should be chosen based on the current requirements of M1. Often, sealed lead-acid type batteries are available at local suppliers for surprisingly low prices. These batteries are ideal for things such as scooters, go-karts, etc. The relays are standard automotive type relays, available cheaply from any auto parts store. Your motor will depend on your requirements. 12V motors will normally run fine at 24V, and vice versa. You will notice that in series mode, all three relays only pull power from B2. This is because the relays have 12V coils, and it is impossible to switch the batteries from series to parallel and keep power to the coils at the same time. This does, however, mean that B2 is discharged slightly before B1. This should normally not be an issue unless the batteries are being drained completely "dead". Draining a battery dead is not good for it in any situation and should be avoided. If you wish, you can use a small 12V battery to run the relays separately. You can add two more speeds to this controller using the schematic below. It connects at points A and B shown above on the controller schematic. K1 is simply another of the same relay as used in the controller. S1 is another switch. R1 needs to be chosen based on your motor, but it will be of low value (under 10 Ohm) and high wattage (normally at least 100W). It must be capable of handling the full current drawn by the motor. This is not exactly an efficient way to limit current to the motor as excess current is dissipated as heat by the resistor, so it is normally only used for a "starter" speed.
The contactor motor controller is a straightforward yet effective design for controlling the speed of a DC motor, particularly in applications such as electric scooters. The circuit utilizes three 12V relays (K1, K2, K3), two 12V batteries (B1, B2), and two switches (S1, S2) to manage the power supply to the motor (M1).
In the idle state, both batteries are connected in parallel, allowing for easy recharging and ensuring that the voltage remains stable at 12V. When S1 is activated, K3 closes, providing power to the motor and initiating operation at a slow speed. For higher speeds, S2 is engaged, which activates relays K1 and K2 to reconfigure the battery connections into a series configuration. This arrangement increases the voltage supplied to the motor, thus allowing it to operate at a faster speed.
The selection of batteries (B1 and B2) is critical and should be based on the current rating of the motor (M1). Sealed lead-acid batteries are often recommended due to their availability and cost-effectiveness. The relays used in this controller are standard automotive relays rated for 30A, which are suitable for handling the motor's current requirements.
It is important to note that in series mode, only battery B2 supplies power to the relays. This design choice is made to simplify the switching mechanism, though it does lead to a slight imbalance in battery discharge rates. To mitigate potential issues from discharging one battery more than the other, it is advisable to avoid completely draining either battery, as this can lead to reduced battery lifespan.
For users seeking additional speed settings, the circuit can be modified by integrating additional components at designated points in the schematic. This includes adding another relay (K1) and switch (S1) along with a current-limiting resistor (R1), which should be selected based on the motor's specifications. The resistor should be of low resistance (under 10 Ohm) and high wattage to handle the motor's current without overheating.
Overall, this contactor controller design offers a reliable and straightforward solution for controlling motor speed in electric vehicles, with the flexibility to accommodate various battery and motor configurations.The simplest of all motor controllers (besides a straight on/off switch) is the contactor controller. I designed this contactor controller for use in my electric scooter project. It is based around three 12V relays, two 12V batteries, two switches and of course a motor. Having no silicon to "fry", it is quite reliable and robust. A contactor controller works by rearranging the two (or more) supply batteries between series and parallel.
This gives the motor a slow speed (batteries in parallel, current adds) and a fast speed (batteries in series, voltage adds). This assures that both batteries are discharged equally. When the circuit is "at rest", the batteries are connected in parallel, which allows easy recharging.
K1, K2, K3 3 12V 30A SPDT Relay (See Notes) S1, S2 2 SPST Switch or Button B1, B2 2 12V Battery (See Notes) M1 1 12V or 24V Motor (See Notes) MISC 1 Case, Wire, etc. Notes S1 closes K3 and thus causes M1 to operate. S2 activates K1 and K2, reconfiguring the batteries for series operation and thus causes M1 to operate at "fast" speed.
B1 and B2 should be chosen based on the current requirements of M1. Often, sealed lead-acid type batteries are available at local suppliers for surprisingly low prices. These batteries are ideal for things such as scooters, go-karts, etc. The relays are standard automotive type relays, available cheaply from any auto parts store. Your motor will depend on your requirements. 12V motors will normally run fine at 24V, and vice versa. You will notice that in series mode, all three relays only pull power from B2. This is because the relays have 12V coils, and it is impossible to switch the batteries from series to parallel and keep power to the coils at the same time. This does, however, mean that B2 is discharged slighty before B1. This should normally not be an issue unless the batteries are being drained completely "dead". Draining a battery dead is not good for it in any situation, and should be avoided. If you wish, you can use a small 12V battery to run the relays separately. You can add two more speeds to this controller using the schematic below. It connects at points A and B shown above on the controller schematic. K1 is simply another of the same relay as used in the controller. S1 is another switch. R1 needs to be chosen based on your motor, but it will be of low value (under 10 Ohm) and high wattage (normally at least 100W).
It must be capable of handling the full current drawn by the motor. This is not exactly an efficient way to limit current to the motor as excess current is dissipated as heat by the resistor, so it is normally only used for a "starter" speed.
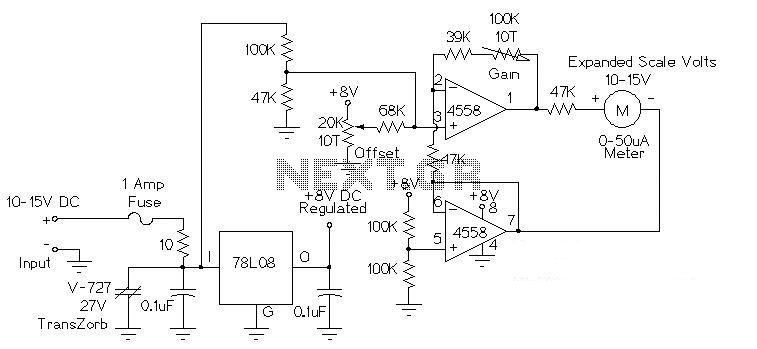
12V Analogue Battery Volt Meter
This circuit is used to measure the voltage on a 12V (nominal) lead acid rechargeable battery system. It was specifically designed for use in solar powered systems, but is general enough that it can be used for automotive or other...
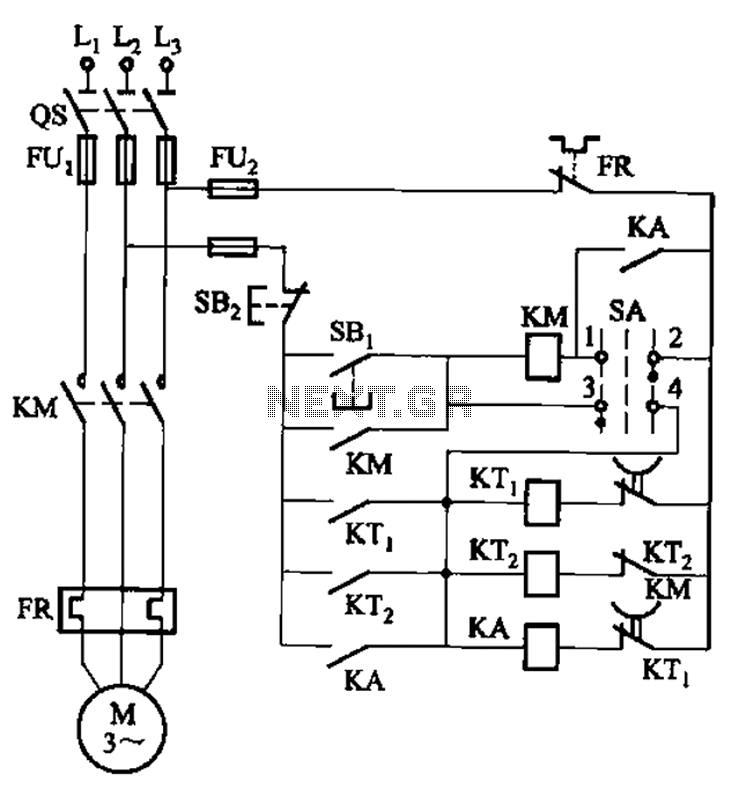
Third batch start and stop cycle control circuits
The circuit illustrated in Figure 3-78 utilizes two relays for automatic control, featuring a more complex line structure. This configuration allows for intermittent motor operation. Additionally, it can operate continuously when switch SA is positioned to the right.
The circuit employs...
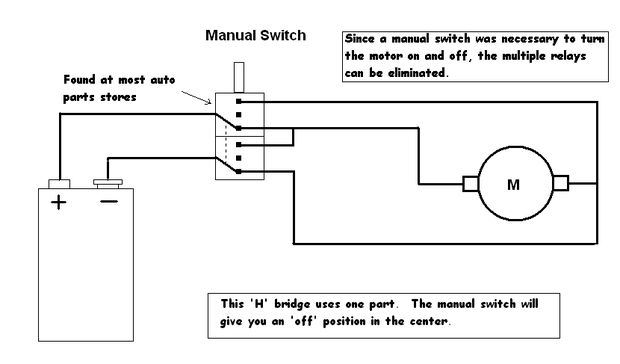
what relay should i use parallel port
Control a toy car. The toy car is operated via a wired controller, rather than being radio-controlled. The intention is to utilize relays to control the toy through a parallel port. There are various types and models of relays, and...
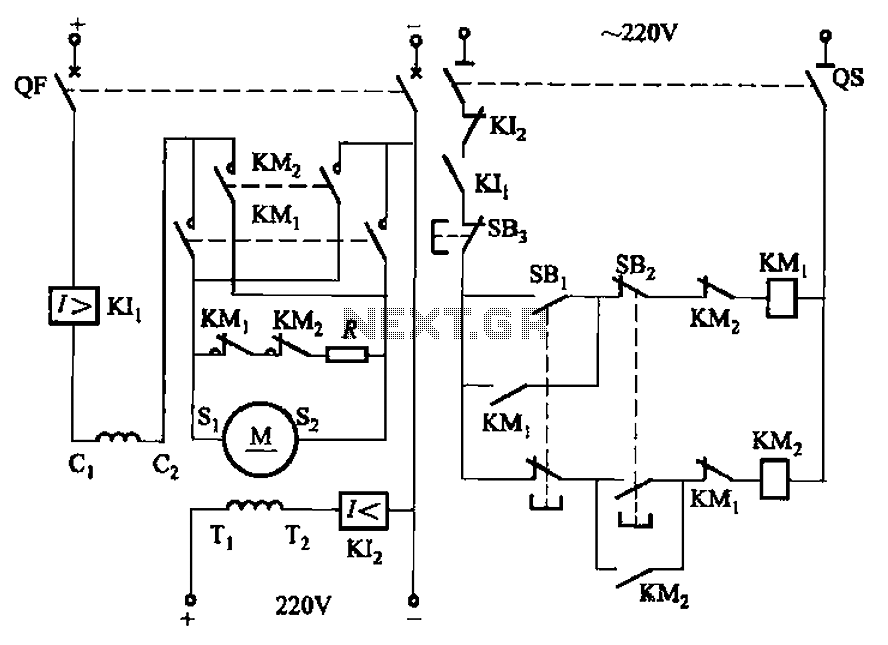
Compound excited DC motor reversing circuit
The circuit depicted in Figure 3-194 features a re-excitation type DC motor with six terminals: S1 and S2 for the armature windings; C1 and C2 for the series excitation (field) windings; and T1 and T2 for the shunt (field) winding....
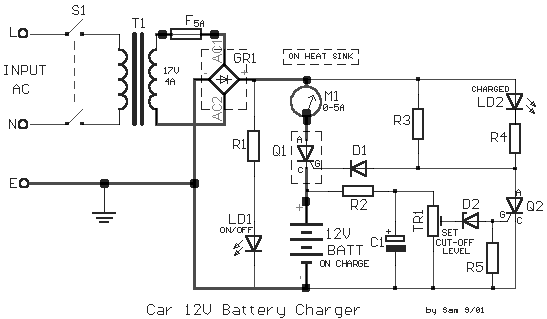
12V Car Battery Charger circuit
The following circuit diagram represents a battery charger designed for a 12V car battery. This circuit includes overcharging protection, which automatically disconnects the charging circuit. Unlike typical battery chargers that continuously supply a few amperes to the battery while powered...
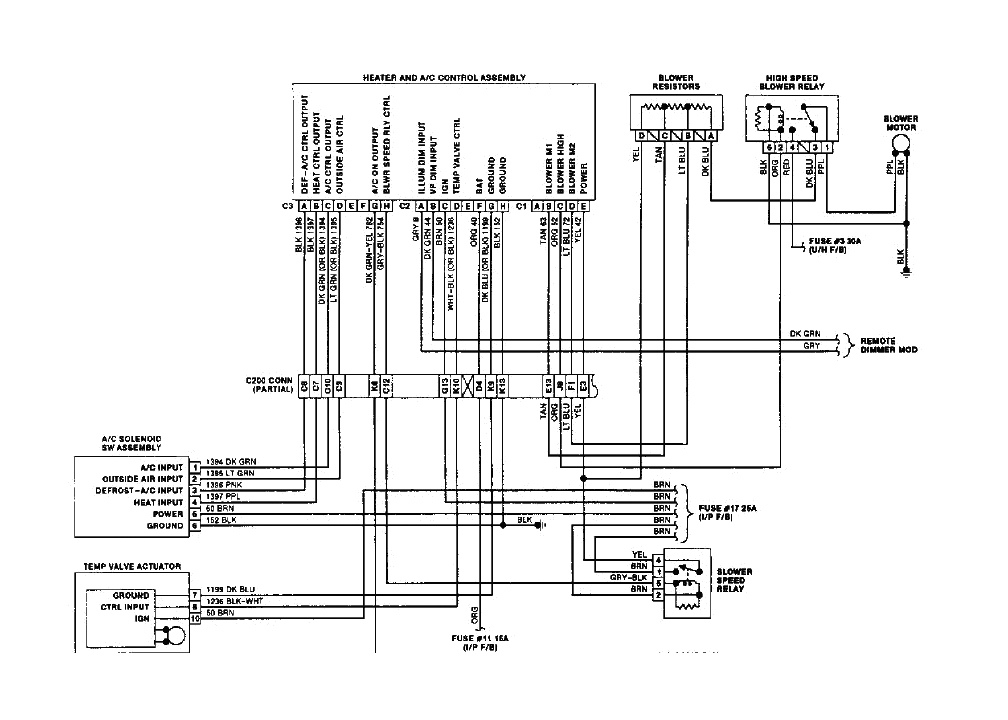
Buick LeSabre
This line provides ground to the relay and is normally open (N-O) when the control unit (CU) is OFF, and is normally closed (N-C) for all other control functions. The OFF switch on the CU is "sticky." Several questions arise:...
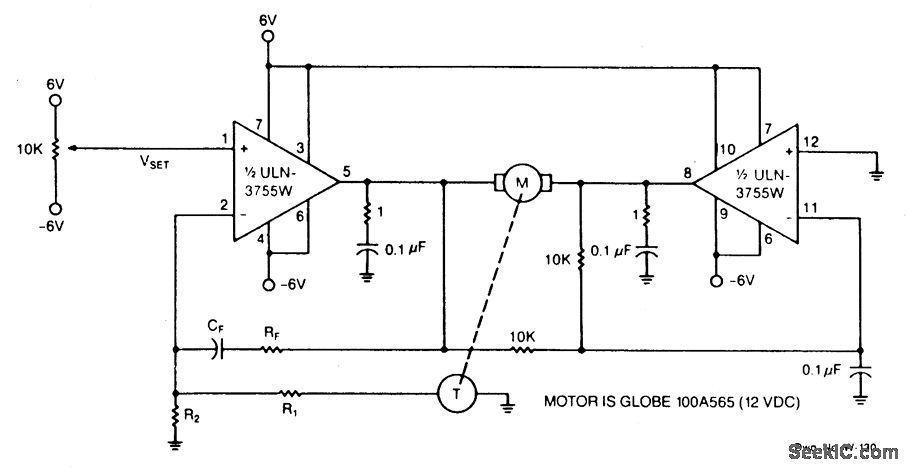
DC MOTOR SPEED CONTROL
Power operational amplifiers provide precise speed control for DC motors. The circuit enables bidirectional speed control. The amplifiers' push-pull configuration guarantees a full rail-to-rail voltage swing (excluding the saturation drops of the output stages) across the motor in both directions....
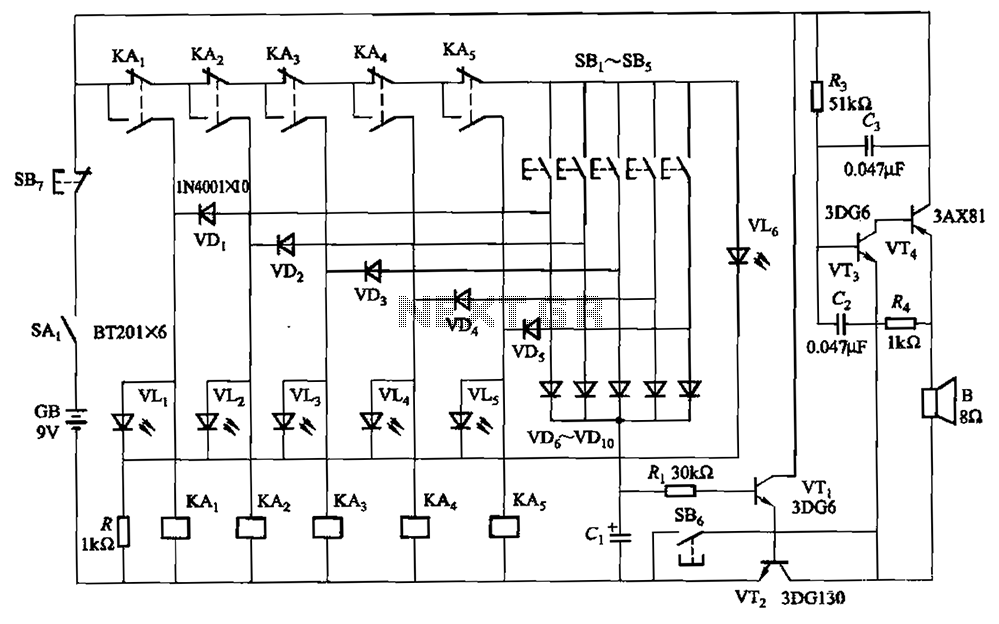
Electronics - circuit relay type answer
A relay-style circuit designed for a five electronic responder group. This circuit features self-locking capabilities, sound and light displays, time monitoring, and additional functions. The circuit includes a monitoring time button operated by the moderator. When this button is pressed,...
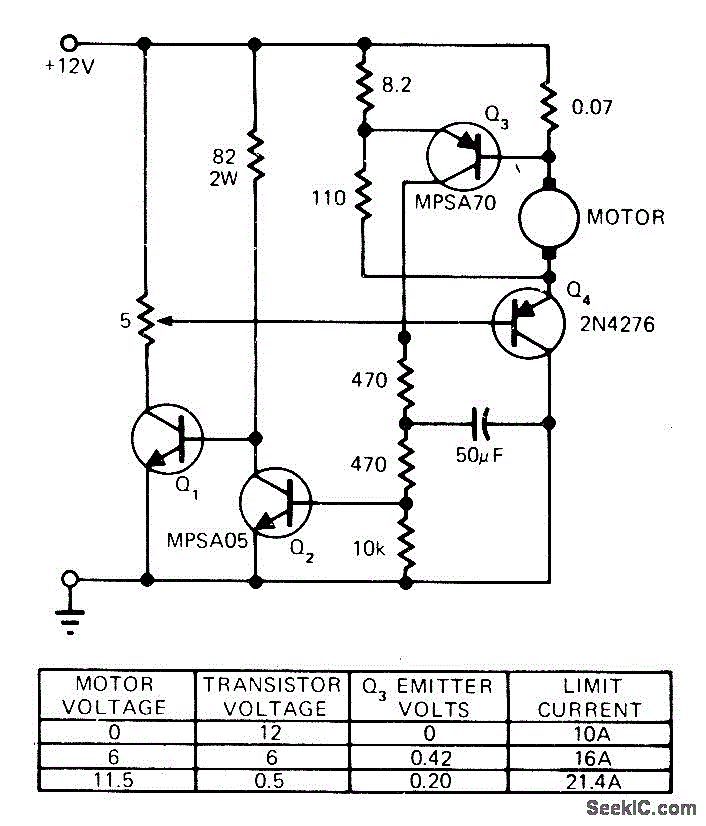
STALLED_MOTOR_PROTECTION
The modification of a basic speed control circuit for small DC permanent-magnet motors implements a maximum current limit during normal operating conditions and a reduced current limit during stall conditions. This design aims to limit the dissipation of series transistor...