


ATmega8535 Line Follower Robot circuit diagram
#ATmega8535
#line follower
#robot
#proximity sensor
#photodiode
#motor control
#sensor module
#tutorial
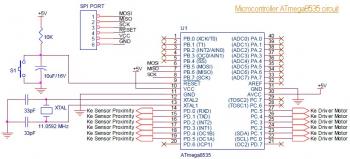
Description: This is the circuit diagram of a line follower/line tracker robot. The circuit is derived from tutorial documentation, which can be downloaded at the end of this article. The line follower robot utilizes eight proximity sensor modules. Each sensor module employs photodiodes to detect the reflection of light from the line or floor. The motor driver, L298, is capable of controlling motors with a current output of up to 2A for a single DC motor. For dual DC motors, the output is limited to 1A for each channel. This motor driver is well-suited for small and medium DC motors, making it an excellent choice for applications such as line follower robots and firefighting robots.
The line follower robot circuit is designed to autonomously navigate along a predetermined path, typically marked by a contrasting line on the ground. The core components of this circuit include eight proximity sensor modules, which are strategically positioned to detect the line's presence. Each sensor module consists of a photodiode that senses light reflection. When the robot is on the line, the sensors detect the reflected light, sending signals to the microcontroller, which processes the information to determine the robot's direction.
The L298 motor driver plays a crucial role in controlling the movement of the robot. It can drive two DC motors simultaneously, allowing for differential steering. This means that the speed and direction of each motor can be adjusted independently, enabling the robot to turn and navigate effectively. The L298 can handle a maximum output current of 2A per motor, making it suitable for small to medium-sized motors commonly used in robotic applications.
The design of the circuit also includes power management considerations, ensuring that the sensors and motors receive adequate voltage and current for optimal performance. The microcontroller, typically an Arduino or similar platform, interfaces with the sensor modules and motor driver, executing the logic required to keep the robot following the line. The overall architecture of the circuit is modular, allowing for easy modifications and upgrades as needed for advanced functionalities or improved performance.
In summary, the line follower robot circuit is a well-structured design that integrates sensor technology with motor control to achieve autonomous navigation, making it an excellent platform for educational purposes and robotics experimentation.This is the circuit diagram of Line Follower / Line Tracker robot. The circuit taken from the tutorial documentation. You may download the full tutorial at the end of this article. The line follower robot use 8 pieces of proximity sensor module. The sensor module use photodioda for detecting the reclection of light from the line/floor. The motor d river L298 able to control the motor with current output up to 2A for single DC motor. For double DC motors, there should be up to 1A for each output channel. This motor driver is very good for small and medium DC motor. L298 is great motor driver for small and medium size or robot such as line follower robot and fire fighter robot.
The line follower robot circuit is designed to autonomously navigate along a predetermined path, typically marked by a contrasting line on the ground. The core components of this circuit include eight proximity sensor modules, which are strategically positioned to detect the line's presence. Each sensor module consists of a photodiode that senses light reflection. When the robot is on the line, the sensors detect the reflected light, sending signals to the microcontroller, which processes the information to determine the robot's direction.
The L298 motor driver plays a crucial role in controlling the movement of the robot. It can drive two DC motors simultaneously, allowing for differential steering. This means that the speed and direction of each motor can be adjusted independently, enabling the robot to turn and navigate effectively. The L298 can handle a maximum output current of 2A per motor, making it suitable for small to medium-sized motors commonly used in robotic applications.
The design of the circuit also includes power management considerations, ensuring that the sensors and motors receive adequate voltage and current for optimal performance. The microcontroller, typically an Arduino or similar platform, interfaces with the sensor modules and motor driver, executing the logic required to keep the robot following the line. The overall architecture of the circuit is modular, allowing for easy modifications and upgrades as needed for advanced functionalities or improved performance.
In summary, the line follower robot circuit is a well-structured design that integrates sensor technology with motor control to achieve autonomous navigation, making it an excellent platform for educational purposes and robotics experimentation.This is the circuit diagram of Line Follower / Line Tracker robot. The circuit taken from the tutorial documentation. You may download the full tutorial at the end of this article. The line follower robot use 8 pieces of proximity sensor module. The sensor module use photodioda for detecting the reclection of light from the line/floor. The motor d river L298 able to control the motor with current output up to 2A for single DC motor. For double DC motors, there should be up to 1A for each output channel. This motor driver is very good for small and medium DC motor. L298 is great motor driver for small and medium size or robot such as line follower robot and fire fighter robot.
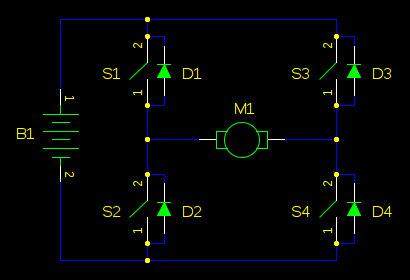
boost Why should I worry about a motor causing my supply voltage to shoot up when the back-EMF cant exceed the supply voltage
In motor control circuits, precautions must be taken to prevent the motor from feeding back into the power supply, which can cause the supply voltage to rise and potentially damage components. However, unless an external force is accelerating the motor,...
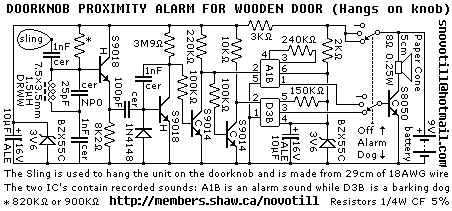
Doorknob Proximity Alarm for wooden door
Reverse engineered circuit diagram of a popular retail doorknob alarm. It contains a small transmitter and the doorknob acts as an antenna so it will not work on a metal door. When a person comes close to the doorknob this...
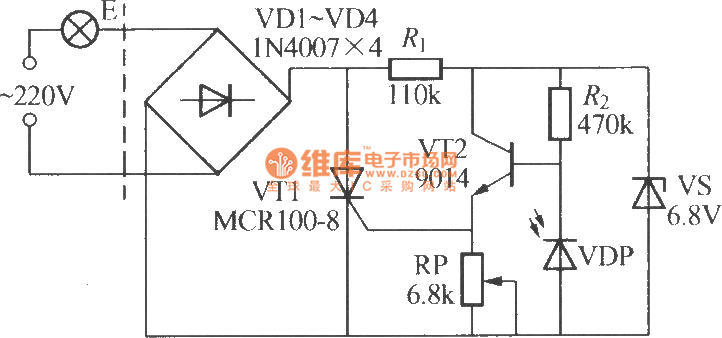
Simple light-operated street lamp circuit diagram(3)
The VDP is a photodiode that exhibits low resistance during the day, approximately 1 kΩ. As a result, transistor VT2 remains off, which keeps thyristor VT1 in the off-state due to the absence of trigger current at the gate, preventing...
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
Gray Projects
After learning to operate the device, it became evident that inertia posed a significant challenge. The constructed system is notably heavy, making it difficult to initiate motor operation at full speed. Despite having some understanding of physics, practical experience is...
Map Bot
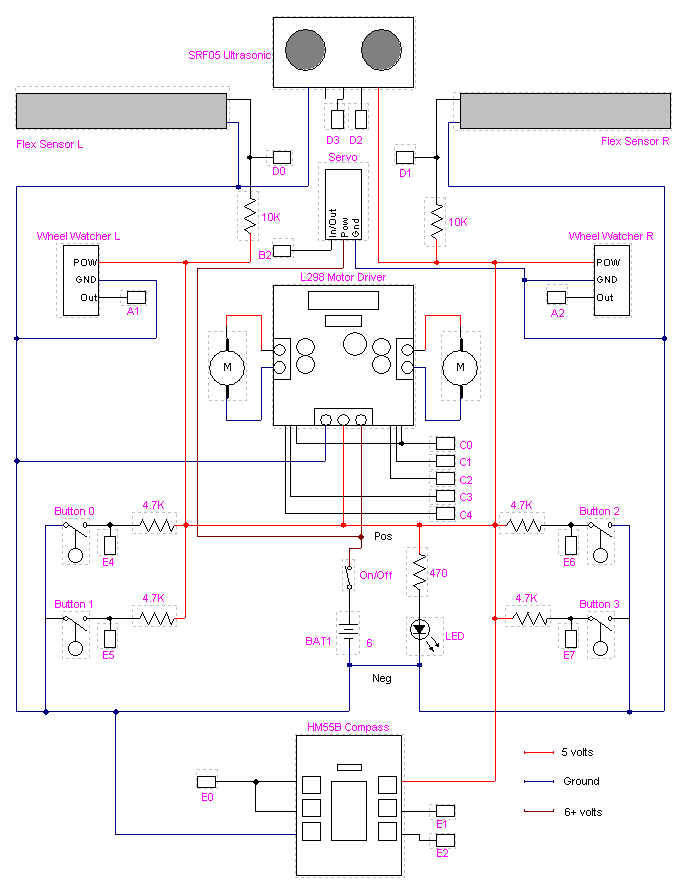
The purpose of this robot is to navigate and map a single floor of a house, using the created map to intelligently traverse the area. Diagnostic software has been developed to verify that all subsystems of the robot are functioning...
Dual-Motor SIP&PUFF Controlled Kayak System
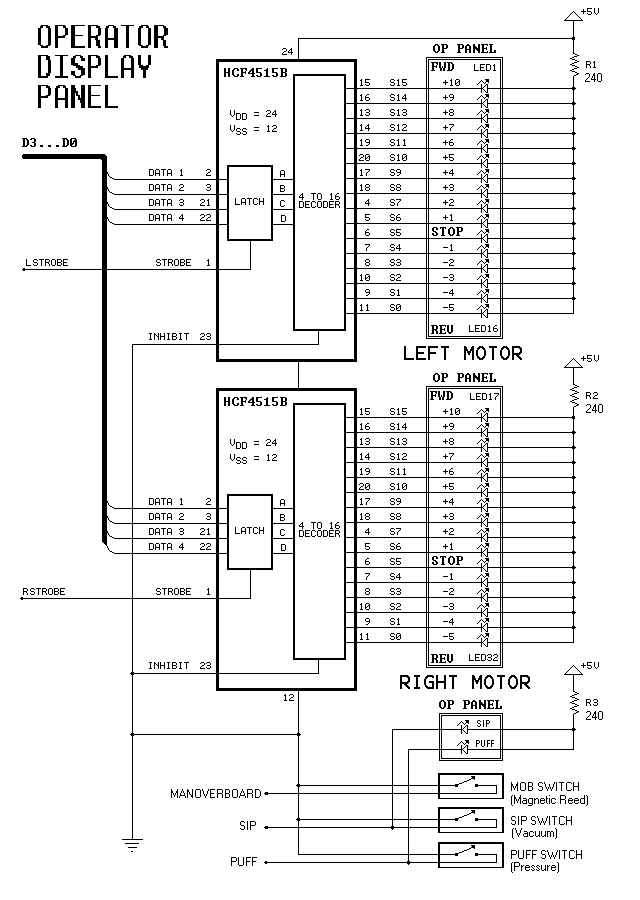
The YouTube video below demonstrates the quick and easy setup of the system at the launch site.
The provided description indicates a focus on the efficiency of system installation at a launch site, as showcased in a YouTube video. In an...
Discussing Measuring Flash Duration
A simple method can be tried that may not be as accurate as professional scientific tools but appears to be more reliable than some manufacturers' claims. A resistor should be wired in parallel with the photodiode to mitigate saturation effects....
Motor control circuit for forward and reverse phase induction
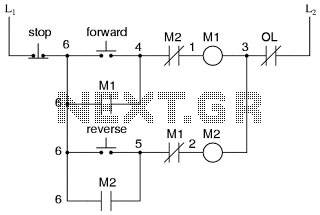
This is the power diagram for motor forward and reverse operation. To change the motor direction, one polarity must be altered, for example, changing R to S. For detailed information, please refer to the following.
The described power diagram illustrates a...