


ATmega16 Line Follower Robot circuit diagram
#ATmega16
#line follower
#sensor module
#DC motor
#microcontroller
#robot
#automation
#embedded systems
#motor control
#educational circuits
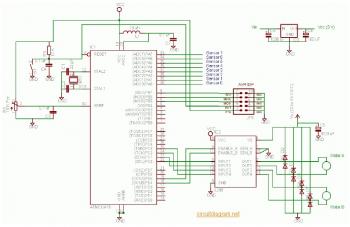
Description: The complete electrical circuit diagram of a line follower robot is based on the ATmega16 microcontroller. This robot consists of three primary modules: the sensor module, the microcontroller module, and the DC motor module. A comprehensive tutorial, including circuit operation, programming, source code, and schematic diagrams for the ATmega16 line follower robot, is available for download.
The line follower robot operates by using a series of sensors to detect the presence of a line on the ground, typically marked in a contrasting color. The sensor module is equipped with infrared (IR) sensors that can identify the line's position. When the sensors detect the line, they send signals to the microcontroller module, which processes the information and determines the appropriate actions for the motors.
The ATmega16 microcontroller serves as the brain of the robot, executing the programmed logic to control the movement of the DC motors based on the input from the sensors. The microcontroller is programmed to respond to the sensor readings by adjusting the speed and direction of the motors, enabling the robot to follow the line accurately.
The DC motor module consists of two motors that drive the wheels of the robot. The motor driver circuit, often based on an H-bridge configuration, allows for bidirectional control of the motors, enabling the robot to turn left or right as needed. The entire system is powered by a suitable battery source, ensuring that the robot can operate autonomously.
For those interested in building their own line follower robot, the tutorial provides detailed instructions on assembling the circuit, programming the microcontroller, and troubleshooting common issues. The schematic diagram included in the tutorial serves as a valuable reference for understanding the connections between the various components of the robot.Here the complete electrical circuit diagram of line follower robot which built based on ATmega16. There are three modules of line follower robot circuit that are sensor module, microcontroller module and DC motor module. Download thedocument of ATmega16 line follower robot tutorialfor complete tutorial including the working explanation of circuit
and program, source code and schematic diagram. We aim to transmit more information by carrying articles. Please send us an E-mail to wanghuali@hqew. net within 15 days if we are involved in the problems of article content, copyright or other problems. We will delete it soon.
The line follower robot operates by using a series of sensors to detect the presence of a line on the ground, typically marked in a contrasting color. The sensor module is equipped with infrared (IR) sensors that can identify the line's position. When the sensors detect the line, they send signals to the microcontroller module, which processes the information and determines the appropriate actions for the motors.
The ATmega16 microcontroller serves as the brain of the robot, executing the programmed logic to control the movement of the DC motors based on the input from the sensors. The microcontroller is programmed to respond to the sensor readings by adjusting the speed and direction of the motors, enabling the robot to follow the line accurately.
The DC motor module consists of two motors that drive the wheels of the robot. The motor driver circuit, often based on an H-bridge configuration, allows for bidirectional control of the motors, enabling the robot to turn left or right as needed. The entire system is powered by a suitable battery source, ensuring that the robot can operate autonomously.
For those interested in building their own line follower robot, the tutorial provides detailed instructions on assembling the circuit, programming the microcontroller, and troubleshooting common issues. The schematic diagram included in the tutorial serves as a valuable reference for understanding the connections between the various components of the robot.Here the complete electrical circuit diagram of line follower robot which built based on ATmega16. There are three modules of line follower robot circuit that are sensor module, microcontroller module and DC motor module. Download thedocument of ATmega16 line follower robot tutorialfor complete tutorial including the working explanation of circuit
and program, source code and schematic diagram. We aim to transmit more information by carrying articles. Please send us an E-mail to wanghuali@hqew. net within 15 days if we are involved in the problems of article content, copyright or other problems. We will delete it soon.
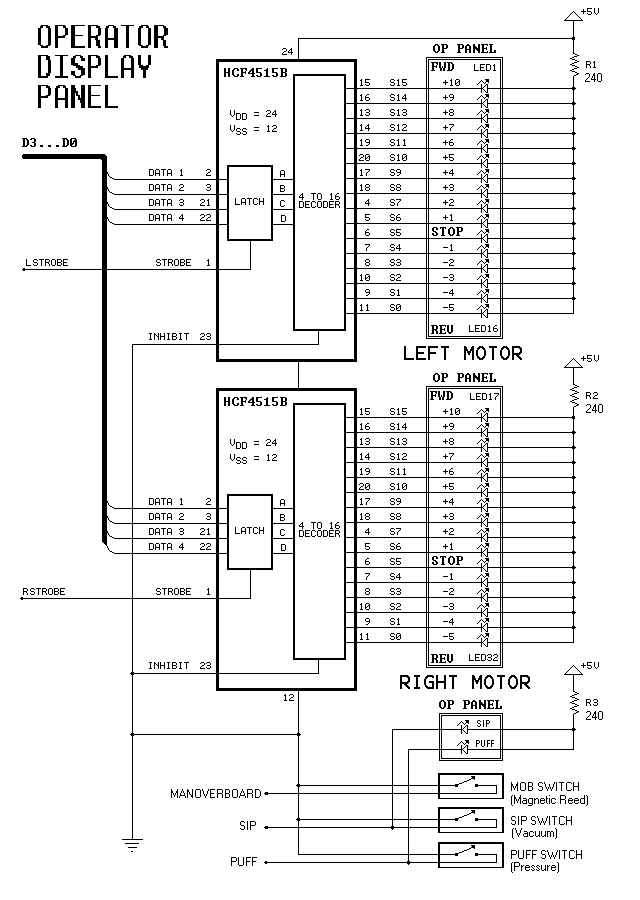
Dual-Motor SIP&PUFF Controlled Kayak System
The YouTube video below demonstrates the quick and easy setup of the system at the launch site.
The provided description indicates a focus on the efficiency of system installation at a launch site, as showcased in a YouTube video. In an...
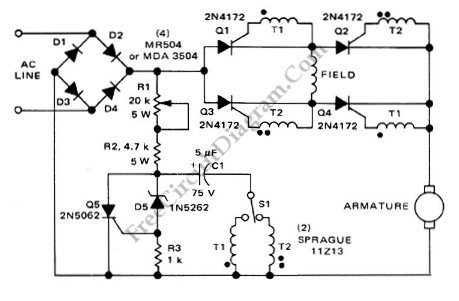
Series-Wound Direction And Speed Motor Control
This is a motor controller circuit that controls the speed and direction of series-wound motors. This circuit employs silicon controlled rectifiers (SCR).
The motor controller circuit is designed to manage both the speed and direction of series-wound motors, which are commonly...
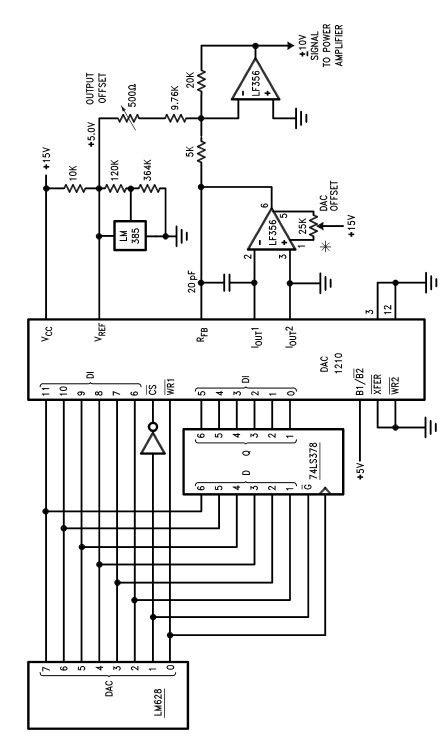
DC motor driver circuit design using LM628 LM629 dedicated motion-control processors
The LM628 and LM629 dedicated motion-control processors can be utilized to design various applications involving DC and brushless DC servo motors, as well as other servomechanisms. The power path of this electronic project, which functions as a motor driver, is...
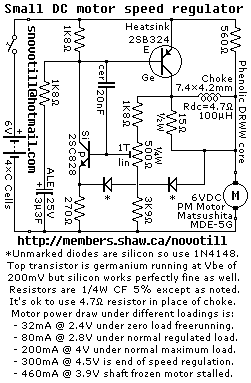
Small DC Motor Speed Regulator
Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The...

Driving circuit schematic
The driving circuit depicted in Figure 18-12 consists of a connection between the driving portion, the microcontroller, and the air conditioning operation components of the bridge. The microcontroller's digital signal levels from ports P4.0 to P4.3 (approximately 12 feet) and...
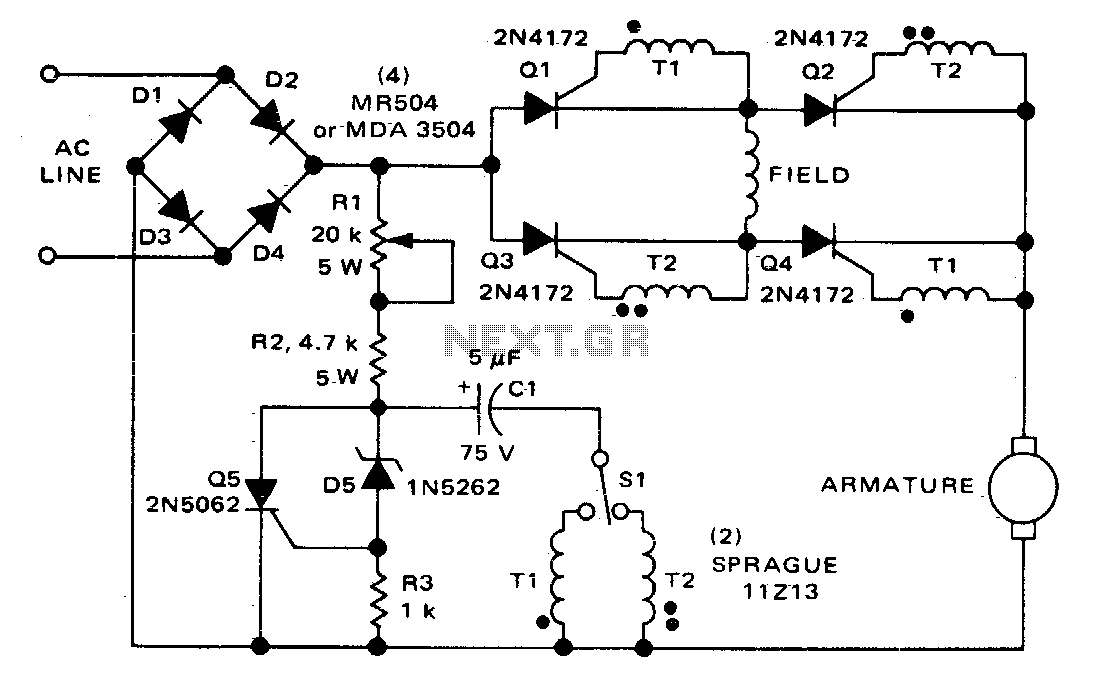
Direction and speed control for series-wound motors
The circuit can control the speed and direction of rotation of a series-wound DC motor. Silicon controlled rectifiers Q1-Q4 are arranged in a bridge configuration and are triggered in diagonal pairs. The selection of which pair to activate is managed...
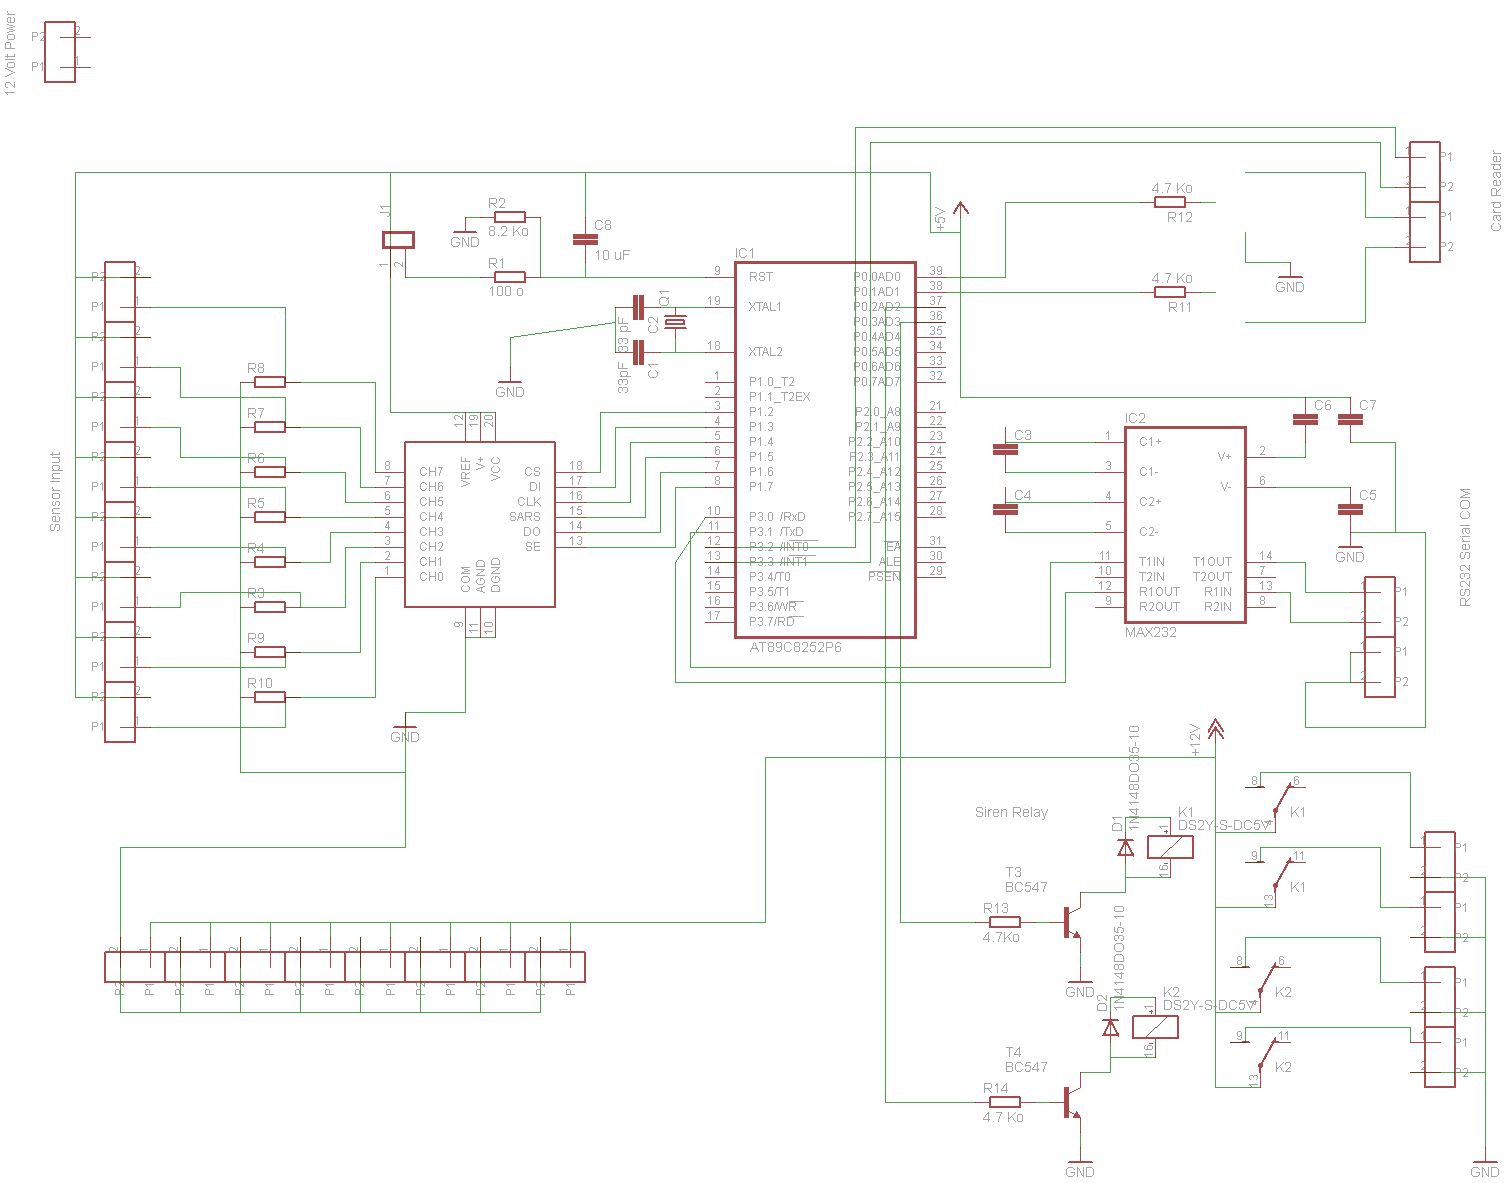
home security system
The fundamental design of this project employs an Atmel AT89S8252-24PC Microcontroller, which features 2KB of EEPROM for runtime data storage. An ADC0838CCN analog-to-digital converter will be utilized to process up to eight inputs from sensor devices, including passive infrared sensors...
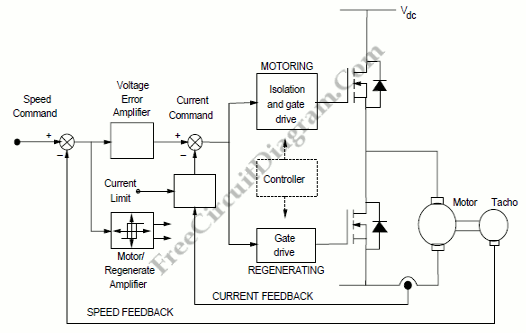
DC Motor Control System Block Diagram
A schematic arrangement for a two-quadrant controller is shown in the figure below. This figure illustrates the outer speed control loop and the inner current control loop. The tachogenerator derives the speed feedback signal; alternatively, an approximation of the motor...
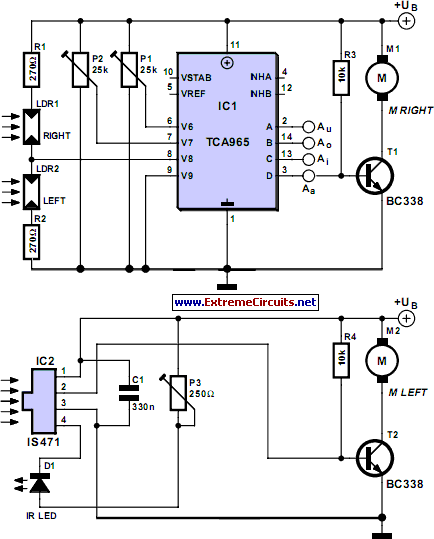
discrete robot schematics
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The primary component in the circuit is a window discriminator, which functions as an advanced window comparator. Resistors R1 and R2, in...