


Serial Servo Controller with Arduino
#arduino
#servo
#controller
#serial interface
#jitter reduction
#snapshot positions
#startup values
#motor control
#pwm
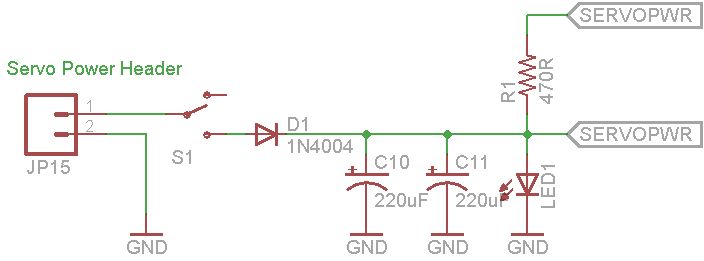
Description: This document explains how to utilize an Arduino to control up to 12 servos simultaneously with minimal jitter. A straightforward serial interface allows for the control of the position of these 12 servo channels. Additionally, it is possible to save and playback up to 10 snapshot positions at any time, along with startup values for each servo. The application consists of two main components: the firmware and hardware. This includes the Arduino and an additional board designated to supply power to the servos. It is crucial to separate the power supply for the servos from the microprocessor power to prevent potential issues, such as a brownout condition, in cases where the servos require more current than the battery can provide, particularly if all 12 servos stall simultaneously. The document also covers the necessary firmware to operate this application on the Arduino. The second part discusses simple software that enables control of the firmware via serial commands. This software offers an interface to the Arduino firmware for controlling the servos, saving startup positions, and recording a sequence of positions (or frames) for playback when desired. The software is based on .NET, so it is essential to have the latest .NET framework installed. An installer and source code will be provided.
The described application utilizes an Arduino microcontroller, which serves as the central processing unit for controlling multiple servo motors. The architecture includes a dedicated power supply board to ensure that the servos receive adequate voltage and current without affecting the Arduino's performance. This separation is critical, as servos can draw significant current, especially when starting or under load, which could lead to voltage drops affecting the Arduino.
The firmware component is programmed to handle the communication between the Arduino and the servos. It implements a serial communication protocol that allows for real-time control of servo positions, enabling users to send commands to adjust the angles of each servo. The firmware also includes functionality to store and retrieve predefined positions, allowing for complex movements and sequences to be executed with ease.
The software interface developed for this application allows users to interact with the firmware through a user-friendly graphical interface. Users can issue commands to the Arduino, set servo positions, and initiate playback of recorded sequences. The software's reliance on the .NET framework ensures compatibility with a wide range of Windows operating systems, enhancing accessibility for users.
Overall, this application provides a robust and flexible solution for controlling multiple servos, making it suitable for various robotics and automation projects. The combination of reliable hardware design, efficient firmware, and intuitive software interface facilitates comprehensive control over servo motors, paving the way for innovative applications in the field of electronics and robotics.I`m going to show you how to use your Arduino to control up to 12 servos at once with minimal jitter. Using a simple serial interface you can control the position of up to 12 servo channels. Up to 10 snapshot positions can be saved and played back at any time. Start up values for each servo can be saved as well. There are two major parts to the ap plication. The first part I will discuss is the firmware and hardware. This includes the Arduino and another board we will use to supply power to the servos. It`s important to isolate the servo power supply from the microprocessor power in case the servos need more current than the battery can supply (imagine all 12 servos stalling at once). If the power supplies are the same you could have a brownout condition on your microprocessor depending what type of power supply you are using.
I will also show you the firmware required to run this application on the Arduino. In the second part I will discuss some simple software that will allow you to control the firmware through serial commands. This software provides an interface to the Arduino firmware to control the servos, save servo start up positions, even record a series of positions, or frames, (of all channels saved at once) to playback in sequence when desired.
The software is. Net based so make sure you have the latest. Net framework installed. I will be supplying an installer and source code.
The described application utilizes an Arduino microcontroller, which serves as the central processing unit for controlling multiple servo motors. The architecture includes a dedicated power supply board to ensure that the servos receive adequate voltage and current without affecting the Arduino's performance. This separation is critical, as servos can draw significant current, especially when starting or under load, which could lead to voltage drops affecting the Arduino.
The firmware component is programmed to handle the communication between the Arduino and the servos. It implements a serial communication protocol that allows for real-time control of servo positions, enabling users to send commands to adjust the angles of each servo. The firmware also includes functionality to store and retrieve predefined positions, allowing for complex movements and sequences to be executed with ease.
The software interface developed for this application allows users to interact with the firmware through a user-friendly graphical interface. Users can issue commands to the Arduino, set servo positions, and initiate playback of recorded sequences. The software's reliance on the .NET framework ensures compatibility with a wide range of Windows operating systems, enhancing accessibility for users.
Overall, this application provides a robust and flexible solution for controlling multiple servos, making it suitable for various robotics and automation projects. The combination of reliable hardware design, efficient firmware, and intuitive software interface facilitates comprehensive control over servo motors, paving the way for innovative applications in the field of electronics and robotics.I`m going to show you how to use your Arduino to control up to 12 servos at once with minimal jitter. Using a simple serial interface you can control the position of up to 12 servo channels. Up to 10 snapshot positions can be saved and played back at any time. Start up values for each servo can be saved as well. There are two major parts to the ap plication. The first part I will discuss is the firmware and hardware. This includes the Arduino and another board we will use to supply power to the servos. It`s important to isolate the servo power supply from the microprocessor power in case the servos need more current than the battery can supply (imagine all 12 servos stalling at once). If the power supplies are the same you could have a brownout condition on your microprocessor depending what type of power supply you are using.
I will also show you the firmware required to run this application on the Arduino. In the second part I will discuss some simple software that will allow you to control the firmware through serial commands. This software provides an interface to the Arduino firmware to control the servos, save servo start up positions, even record a series of positions, or frames, (of all channels saved at once) to playback in sequence when desired.
The software is. Net based so make sure you have the latest. Net framework installed. I will be supplying an installer and source code.
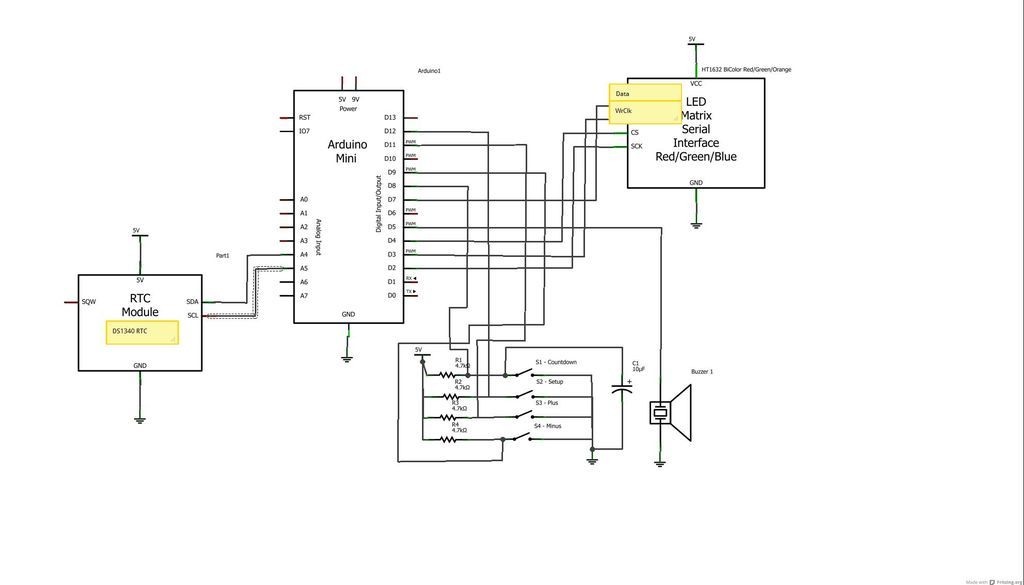
Colorful Countdown Clock for tight timeline management using Arduino
The device is designed to promote respectful time management during meetings, particularly useful in ship-room or SCRUM meetings. The following is a list of components required, including links for purchasing specific parts. It is advisable to check eBay or other...
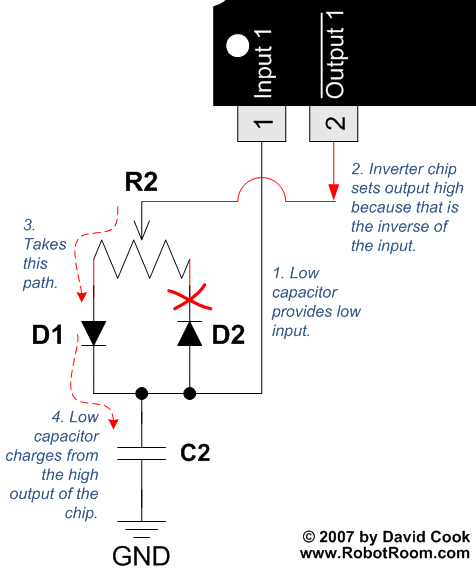
PWM - Pulse Width Modulation for DC Motor Speed and LED Brightness 2
To understand how the 74AC14 PWM circuit functions, it is essential to focus on the schematic section that includes the trimpot, diodes, capacitor, and the first inverter logic gate. Initially, when power is applied to the circuit, the capacitor is...
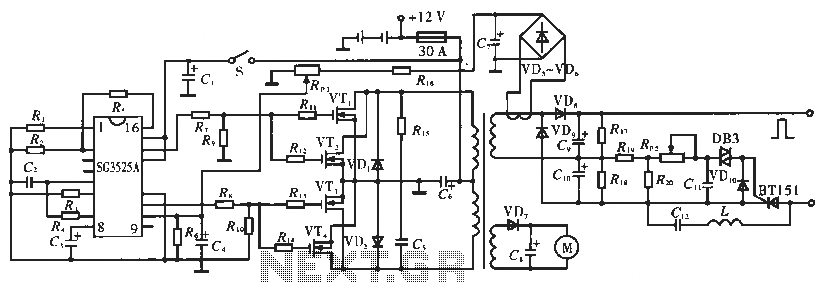
Electronic pulse circuitry fishing
The circuit utilizes the SC3525A, a PWM silicon chip from US General Semiconductor. It features an error amplifier with an inverting input at pin 1. Pin 2 serves as the non-inverting input for the error amplifier. Pins 5 and 6...
8 Channel PWM with AT90S1200
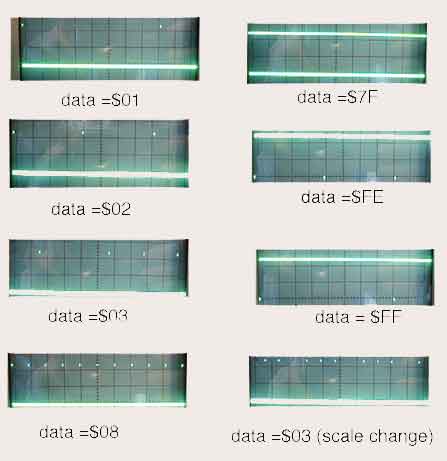
The assembly code given here was written to see what it would take to make an AT90S1200 generate 8 channels of proper PWM. In this case, by proper, I mean with the maximum high frequency content consistent with the needed...
arduino unipolar stepper
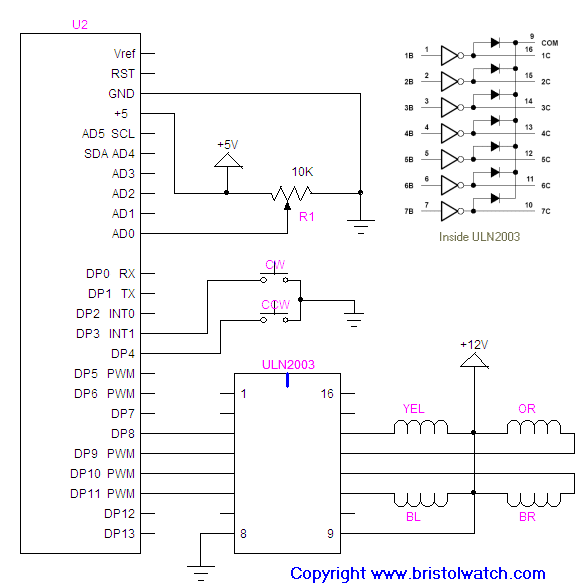
How to connect and program the Arduino/Atmega168 microcontroller to operate a unipolar stepper motor.
To connect and program the Arduino/Atmega168 microcontroller for operating a unipolar stepper motor, the following steps should be followed:
1. **Components Required**:
- Arduino or Atmega168...
Discrete PWM Generator Circuit
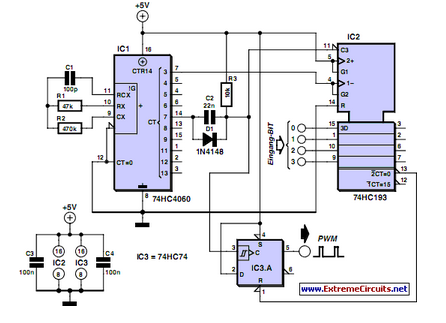
PWM waveforms are frequently utilized to regulate the speed of DC motors. The duty cycle of the digital waveform can be defined using an adjustable parameter.
PWM (Pulse Width Modulation) is a technique employed to control the power delivered to electrical...
integrated circuit How do I control a two 12VDC 10A motors using an Arduino
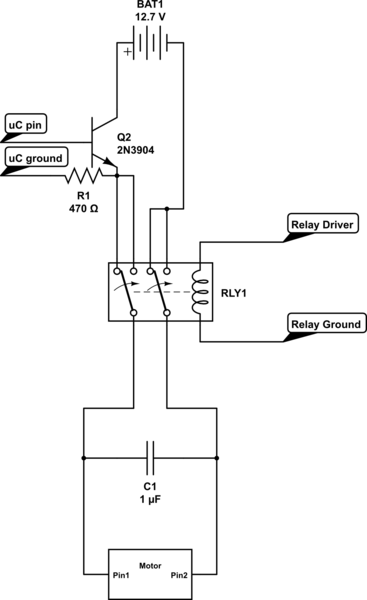
Control the state (on/off) and direction of two linear actuators that are essentially DC motors. The linear actuators operate at 12VDC and draw 10 amps of current at full load. A 25A external power supply has been purchased, as the...
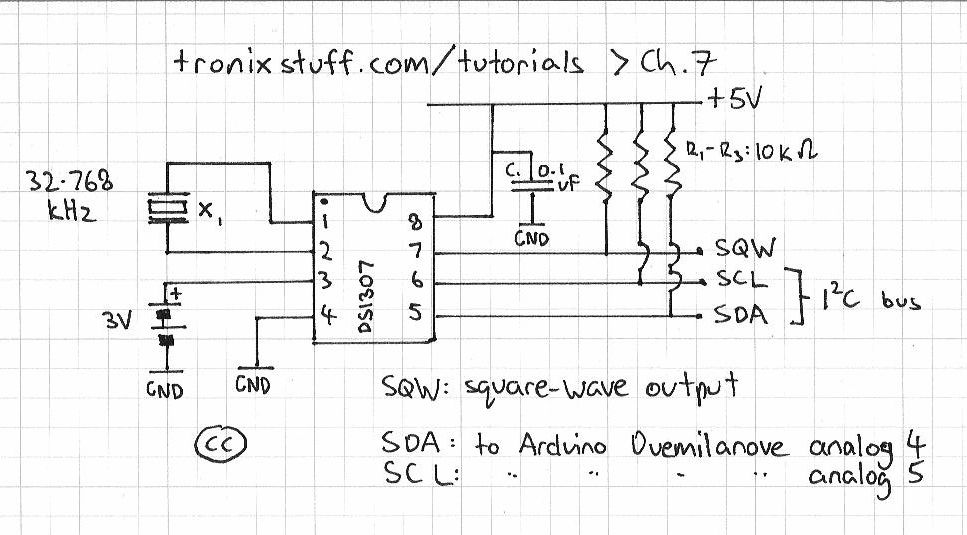
getting started with arduino chapter seven
This is part of a series titled "Getting Started with Arduino," a tutorial on Arduino microcontrollers. The first chapter is here, and the complete index is available as well. This week focuses on the concept of real-time and how time...
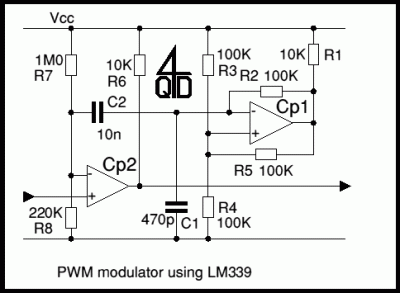
Pulse Width Modulators using LM339
The first example utilizes a standard op-amp oscillator circuit to produce a triangular waveform, which is then level-shifted and supplied to a comparator (e.g., LM339) to generate a PWM waveform. It is common for users to prefer using two comparators...