


integrated circuit How do I control a two 12VDC 10A motors using an Arduino
#arduino
#H-bridge
#DC motor
#12VDC
#high current
#linear actuator
#motor driver
#PWM control
#power supply
#direction control
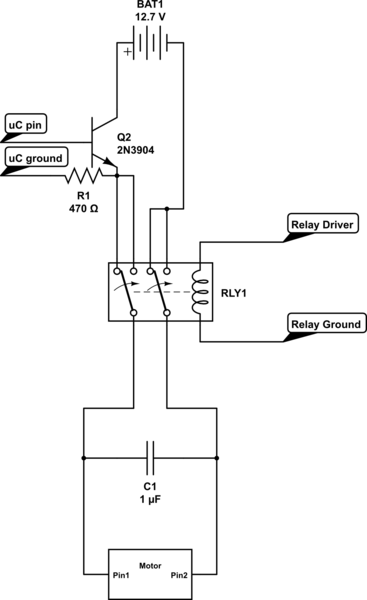
Description: Control the state (on/off) and direction of two linear actuators that are essentially DC motors. The linear actuators operate at 12VDC and draw 10 amps of current at full load. A 25A external power supply has been purchased, as the Arduino microcontroller cannot provide sufficient current. There is interest in using an H-bridge to control the direction of each motor, as well as the potential use of a relay that functions as an electromechanical switch to draw current from the power supply. Assistance is requested in creating a circuit diagram for this setup.
To control two linear actuators, which are DC motors operating at 12VDC and drawing up to 10A each, a robust circuit design is necessary to handle the current requirements and enable directional control. The proposed solution involves using an H-bridge circuit for each motor, allowing for bidirectional control, and relays to manage the power supply effectively.
An H-bridge consists of four switches (transistors or MOSFETs) arranged in a bridge configuration. When the switches are activated in pairs, current flows through the motor in one direction, while activating the opposite pair reverses the current flow, causing the motor to rotate in the opposite direction. The Arduino microcontroller will send control signals to these switches, typically using PWM (Pulse Width Modulation) to control speed as well.
In addition to the H-bridge, relays can be incorporated to handle the high current drawn by the motors. The relay acts as an electromechanical switch that can be controlled by the Arduino. When the relay is activated, it connects the power supply to the H-bridge, allowing the motors to receive the necessary current without overloading the Arduino.
The circuit can be designed as follows:
1. **Power Supply**: A 25A, 12VDC power supply is connected to the H-bridge inputs.
2. **H-Bridge Configuration**: Two H-bridge circuits are constructed, one for each motor. Each H-bridge consists of four MOSFETs (or transistors) that are controlled by the Arduino.
3. **Arduino Control**: The Arduino sends signals to the gates of the MOSFETs based on desired motor direction and speed. This can be done using digital pins for direction and PWM pins for speed control.
4. **Relay Integration**: A relay module is connected to the Arduino, which activates the relay when the motors are supposed to operate. The relay connects the power supply to the H-bridge, allowing the motors to draw the necessary current.
5. **Protection Components**: It is advisable to include flyback diodes across the motor terminals to protect the circuit from voltage spikes generated when the motors are turned off.
A schematic diagram would illustrate these components clearly, showing the connections between the Arduino, H-bridges, relays, and power supply. This setup not only provides control over the actuators but also ensures that the Arduino operates within its safe current limits while allowing for the necessary power to be delivered to the motors.Control the state (on/off) and direction of two linear actuators that are really just DC motors. It seems easy but the problem is that the linear actuators are each 12VDC and consume 10 amps of current at full load. I bought a 25A external power supply because obviously the arduino microcontroller cannot not provide that much current.
I saw something about using an H bridge to control each motor`s direction and then I read something about using a relay that acts as an electromechanical switch to draw current from the power supply. Can someone help me out or draw me a circuit diagram of what this looks like so I could be able to put it together I would love to know how all of this works and I know it is probably challenging to beging electronics with but I am willing to learn as much as I can about this stuff.
To control two linear actuators, which are DC motors operating at 12VDC and drawing up to 10A each, a robust circuit design is necessary to handle the current requirements and enable directional control. The proposed solution involves using an H-bridge circuit for each motor, allowing for bidirectional control, and relays to manage the power supply effectively.
An H-bridge consists of four switches (transistors or MOSFETs) arranged in a bridge configuration. When the switches are activated in pairs, current flows through the motor in one direction, while activating the opposite pair reverses the current flow, causing the motor to rotate in the opposite direction. The Arduino microcontroller will send control signals to these switches, typically using PWM (Pulse Width Modulation) to control speed as well.
In addition to the H-bridge, relays can be incorporated to handle the high current drawn by the motors. The relay acts as an electromechanical switch that can be controlled by the Arduino. When the relay is activated, it connects the power supply to the H-bridge, allowing the motors to receive the necessary current without overloading the Arduino.
The circuit can be designed as follows:
1. **Power Supply**: A 25A, 12VDC power supply is connected to the H-bridge inputs.
2. **H-Bridge Configuration**: Two H-bridge circuits are constructed, one for each motor. Each H-bridge consists of four MOSFETs (or transistors) that are controlled by the Arduino.
3. **Arduino Control**: The Arduino sends signals to the gates of the MOSFETs based on desired motor direction and speed. This can be done using digital pins for direction and PWM pins for speed control.
4. **Relay Integration**: A relay module is connected to the Arduino, which activates the relay when the motors are supposed to operate. The relay connects the power supply to the H-bridge, allowing the motors to draw the necessary current.
5. **Protection Components**: It is advisable to include flyback diodes across the motor terminals to protect the circuit from voltage spikes generated when the motors are turned off.
A schematic diagram would illustrate these components clearly, showing the connections between the Arduino, H-bridges, relays, and power supply. This setup not only provides control over the actuators but also ensures that the Arduino operates within its safe current limits while allowing for the necessary power to be delivered to the motors.Control the state (on/off) and direction of two linear actuators that are really just DC motors. It seems easy but the problem is that the linear actuators are each 12VDC and consume 10 amps of current at full load. I bought a 25A external power supply because obviously the arduino microcontroller cannot not provide that much current.
I saw something about using an H bridge to control each motor`s direction and then I read something about using a relay that acts as an electromechanical switch to draw current from the power supply. Can someone help me out or draw me a circuit diagram of what this looks like so I could be able to put it together I would love to know how all of this works and I know it is probably challenging to beging electronics with but I am willing to learn as much as I can about this stuff.
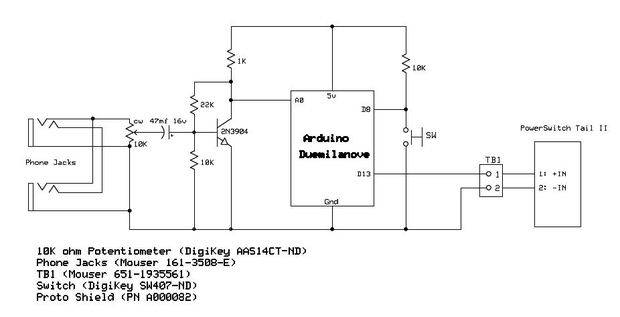
Arduino Audio Triggered Power Switch
Have you ever wanted your home entertainment or sound system to power on automatically when plugging in your iPod or another portable MP3 player?
To achieve automatic power activation of a home entertainment system when a portable device is connected,...
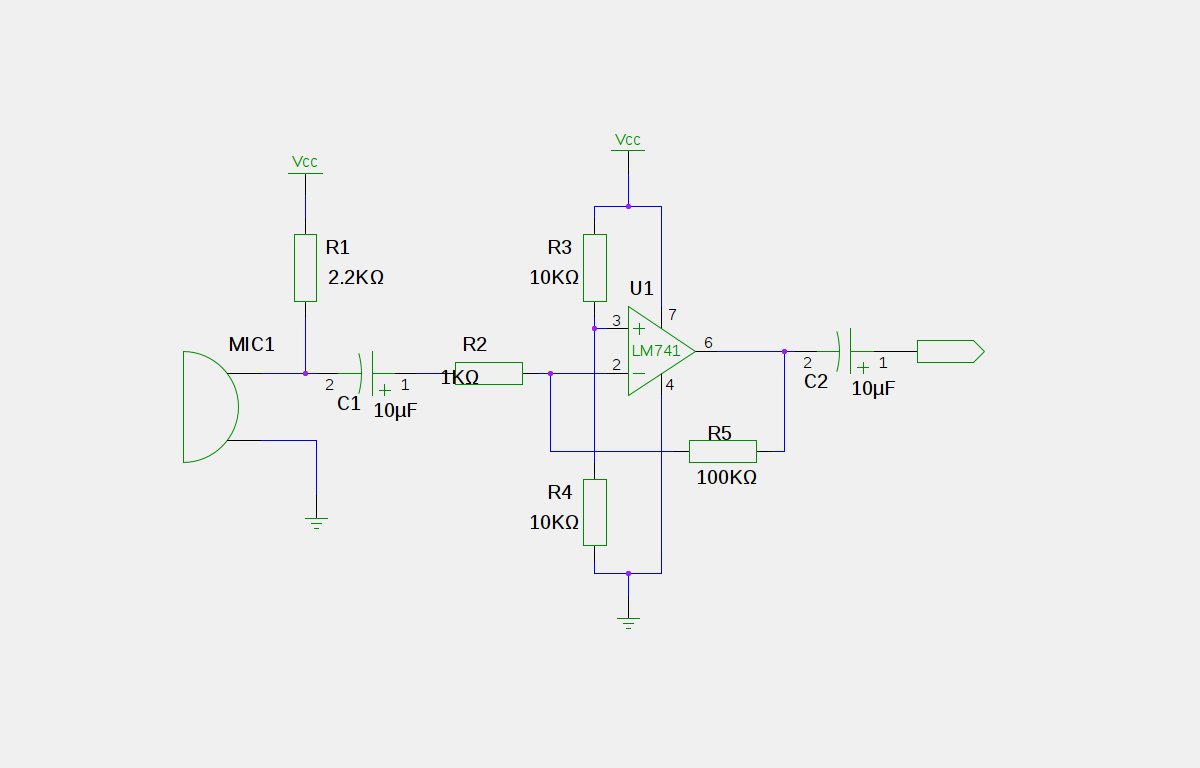
arduino How to make a clean amplified microphone analog to digital conversion
An electret microphone has been connected to an operational amplifier (op-amp), with the output directed to an Arduino microcontroller. The analog-to-digital converter (ADC) on the microcontroller converts a voltage range of 0 to 5 volts into a 10-bit number, ranging...
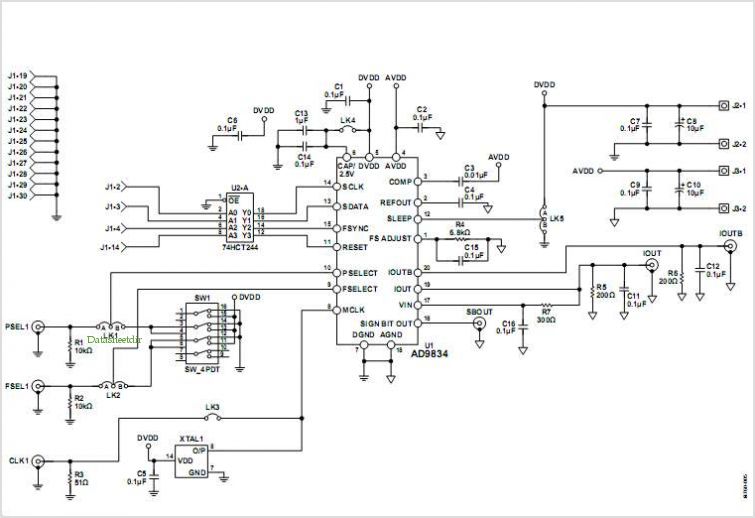
Evaluation Board For The Ad9834 Direct Digital Synthesizer
This document outlines the design of a low-cost 90 W flyback switching power supply intended for use in a multi-sync color monitor. To reduce screen interference caused by switching noise, the power supply can be automatically synchronized to the fixed...
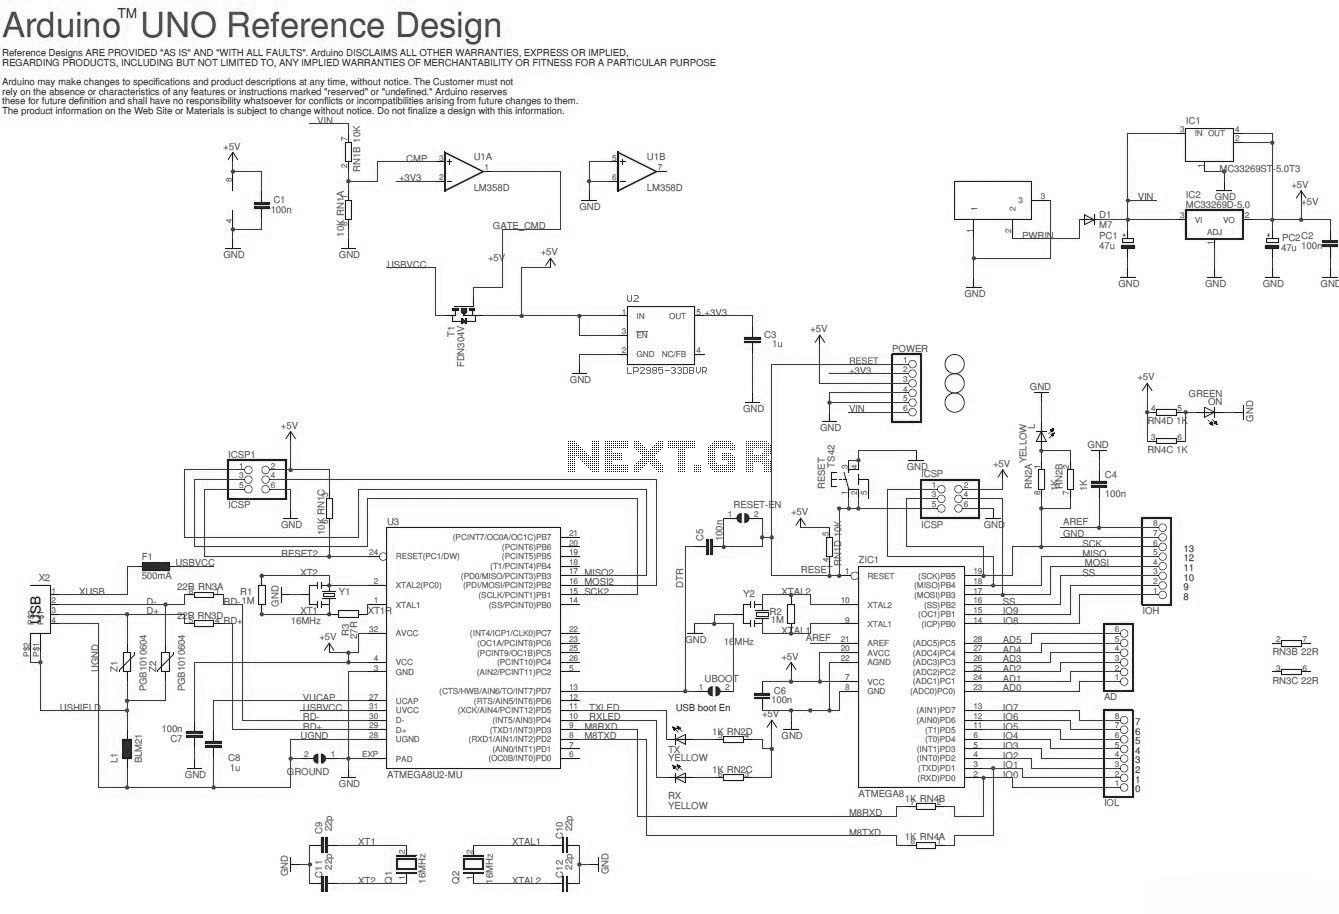
Arduino UNO
The Arduino Uno schematic diagram is available for viewing. The Arduino Uno is a microcontroller board that utilizes the ATmega328 chip. It features 14 digital input/output pins, of which 6 can be used as PWM outputs, and 6 analog input...
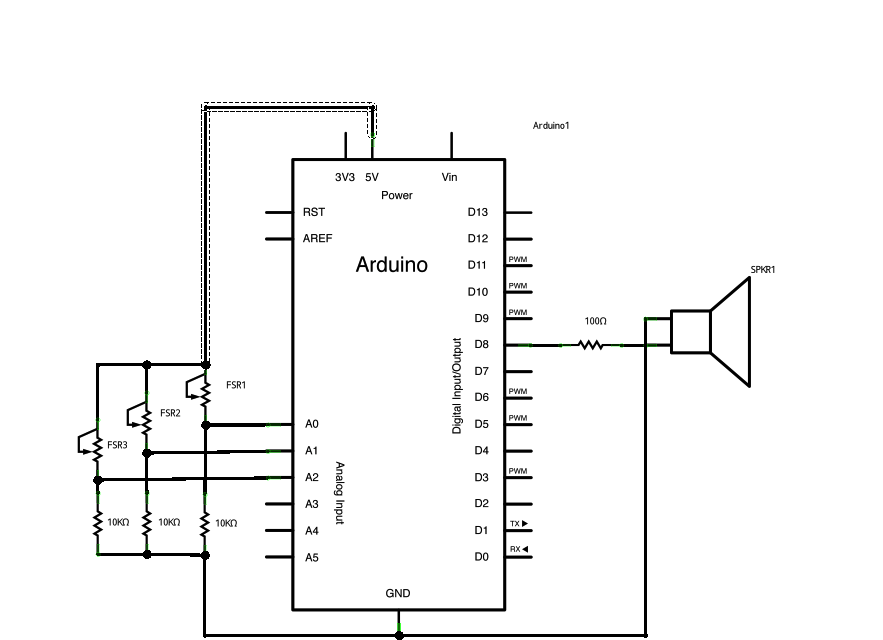
Arduino Tone 3
Power three force-sensitive resistors (FSRs) or any other analog sensor with 5V in parallel. Connect each sensor to analog pins 0-2, utilizing a 10K resistor as a reference to ground on each input line. The provided sketch reads three analog...
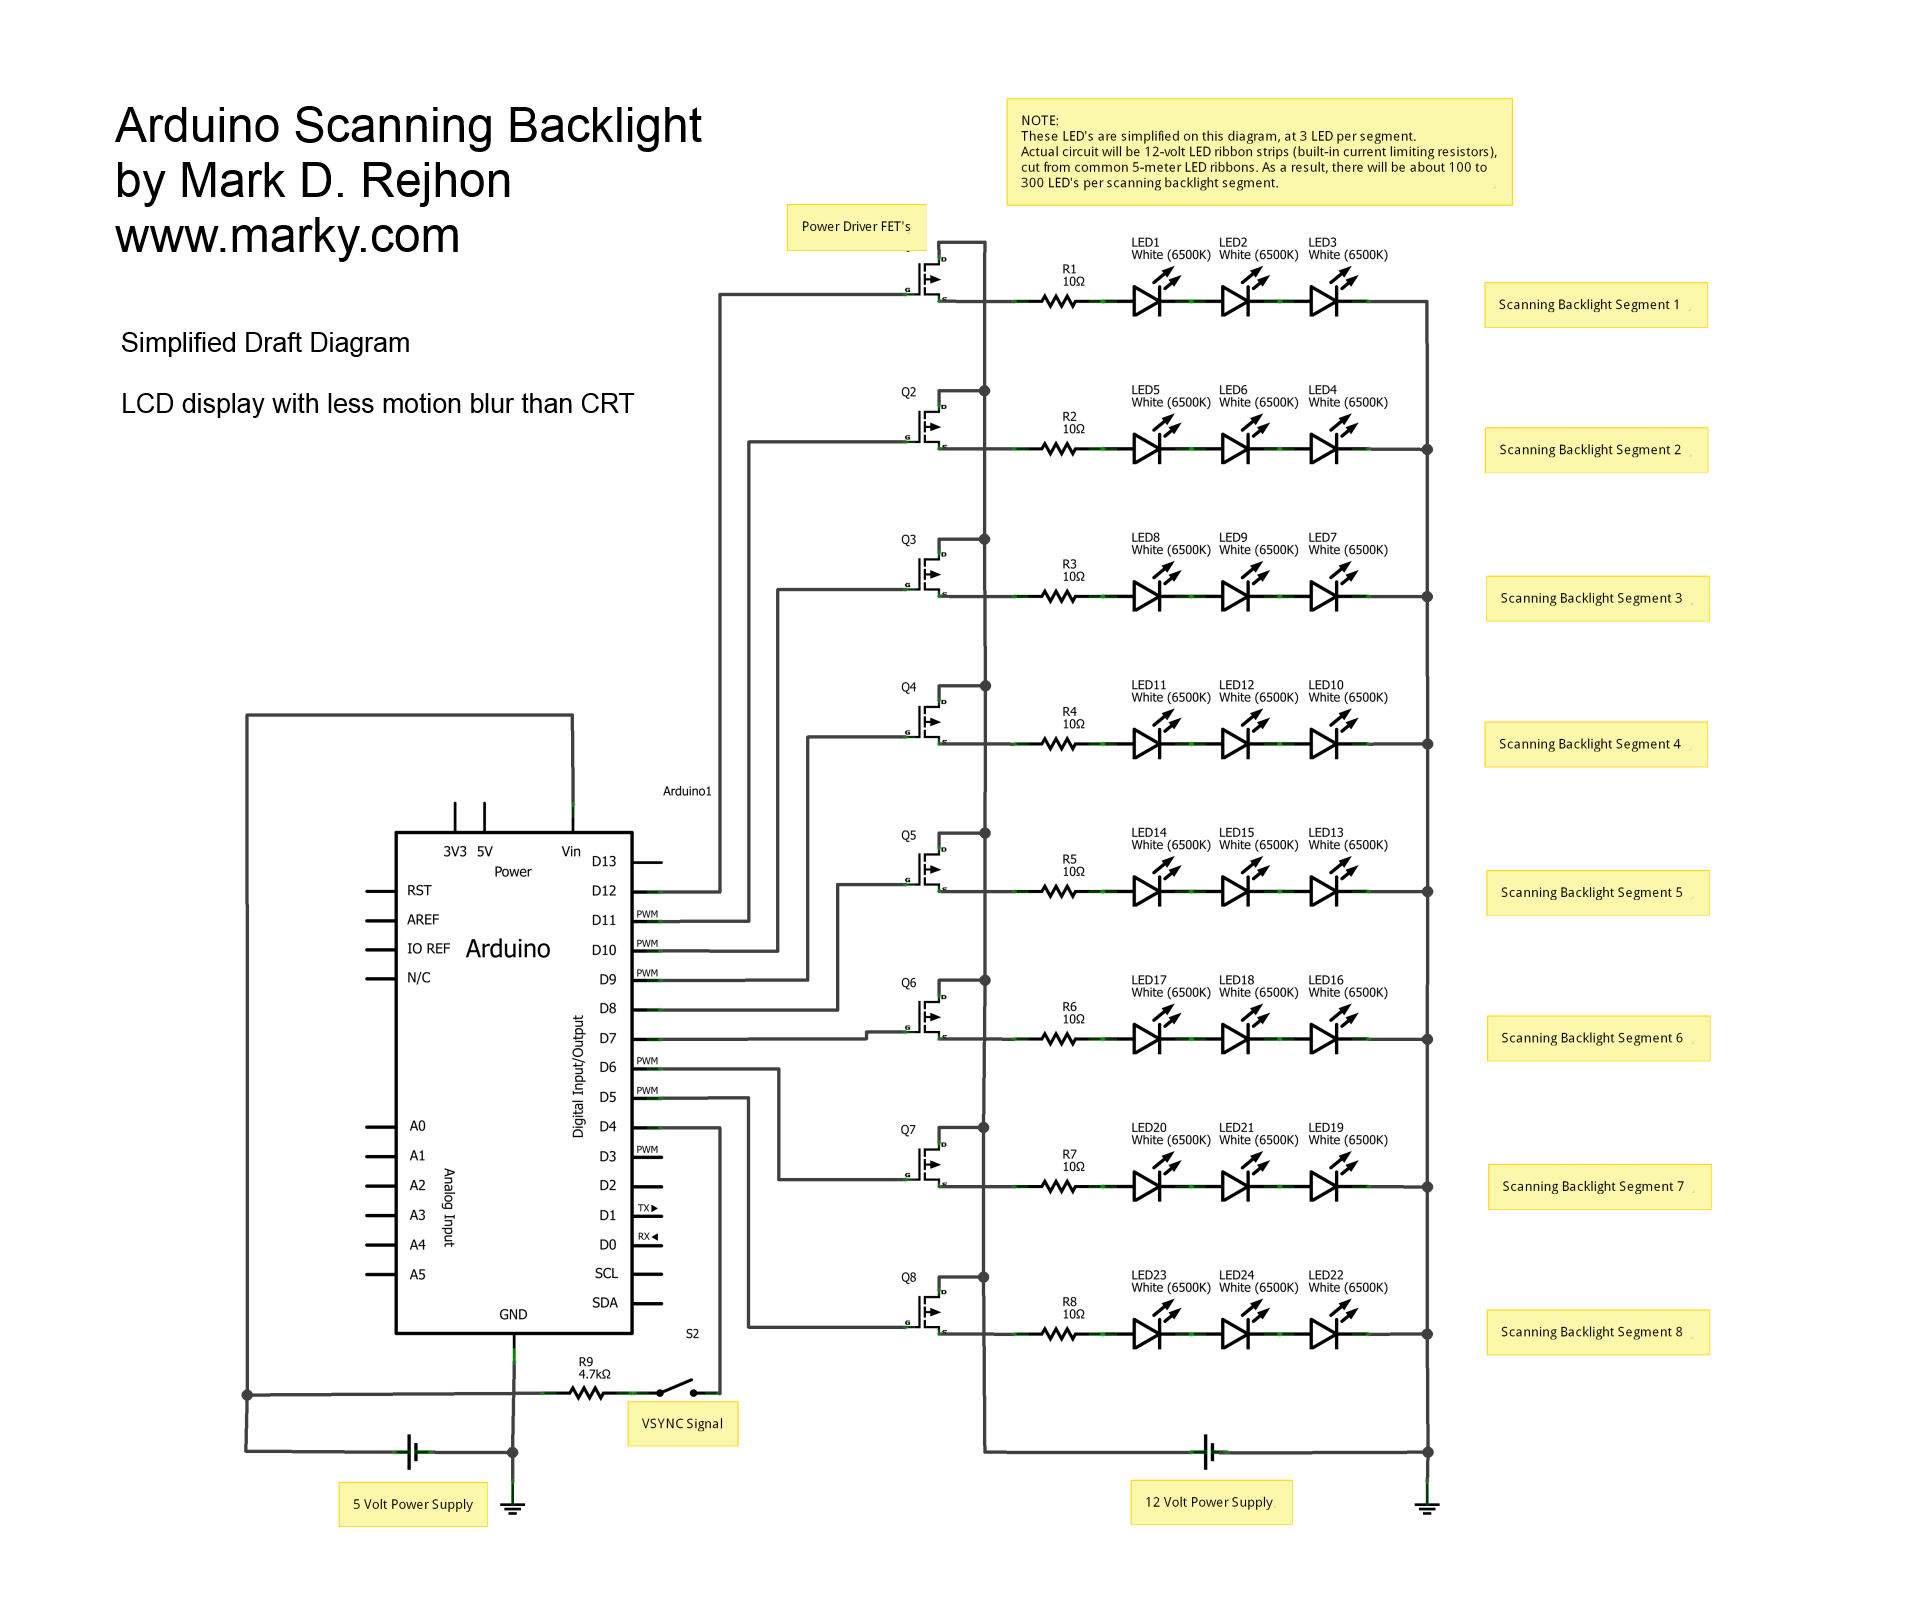
arduino scanning backlight
This is a simplified schematic diagram for a homemade scanning backlight driven by an Arduino, an open-source electronics prototyping platform. The Arduino monitors the VSYNC signal (input-lag compensated) and executes a backlight scanning sequence, using ultra-short strobes of super bright...
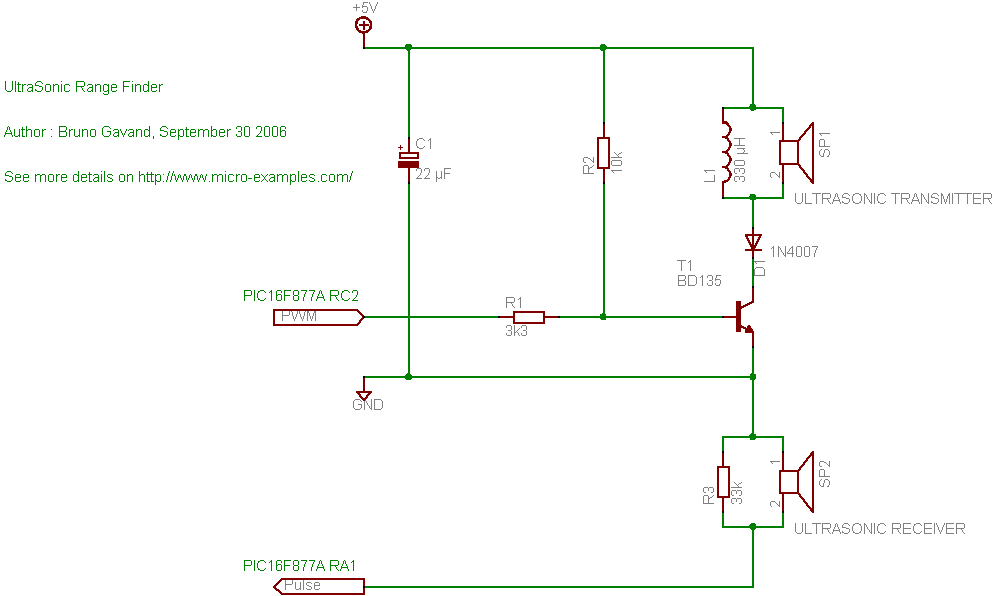
ultrasound How do I drive an ultrasonic transducer with an Arduino
A cat deterrent system utilizing an Arduino, similar to existing models. Detection has been successfully implemented, and it has been determined that an ultrasonic transducer is required to generate the necessary deterrent sound.
The proposed cat deterrent system employs an Arduino...
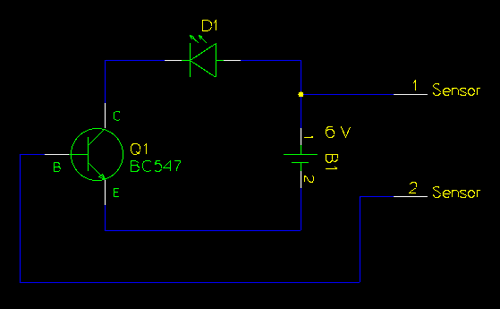
Glove circuit that lights up with a hand shake
The task involved testing the capacitive properties of food by connecting various edibles to an Arduino. This project, known as BeetBox, was developed by Scott Garner, a student at NYU-ITP, who designed an innovative musical instrument that uses beets as...
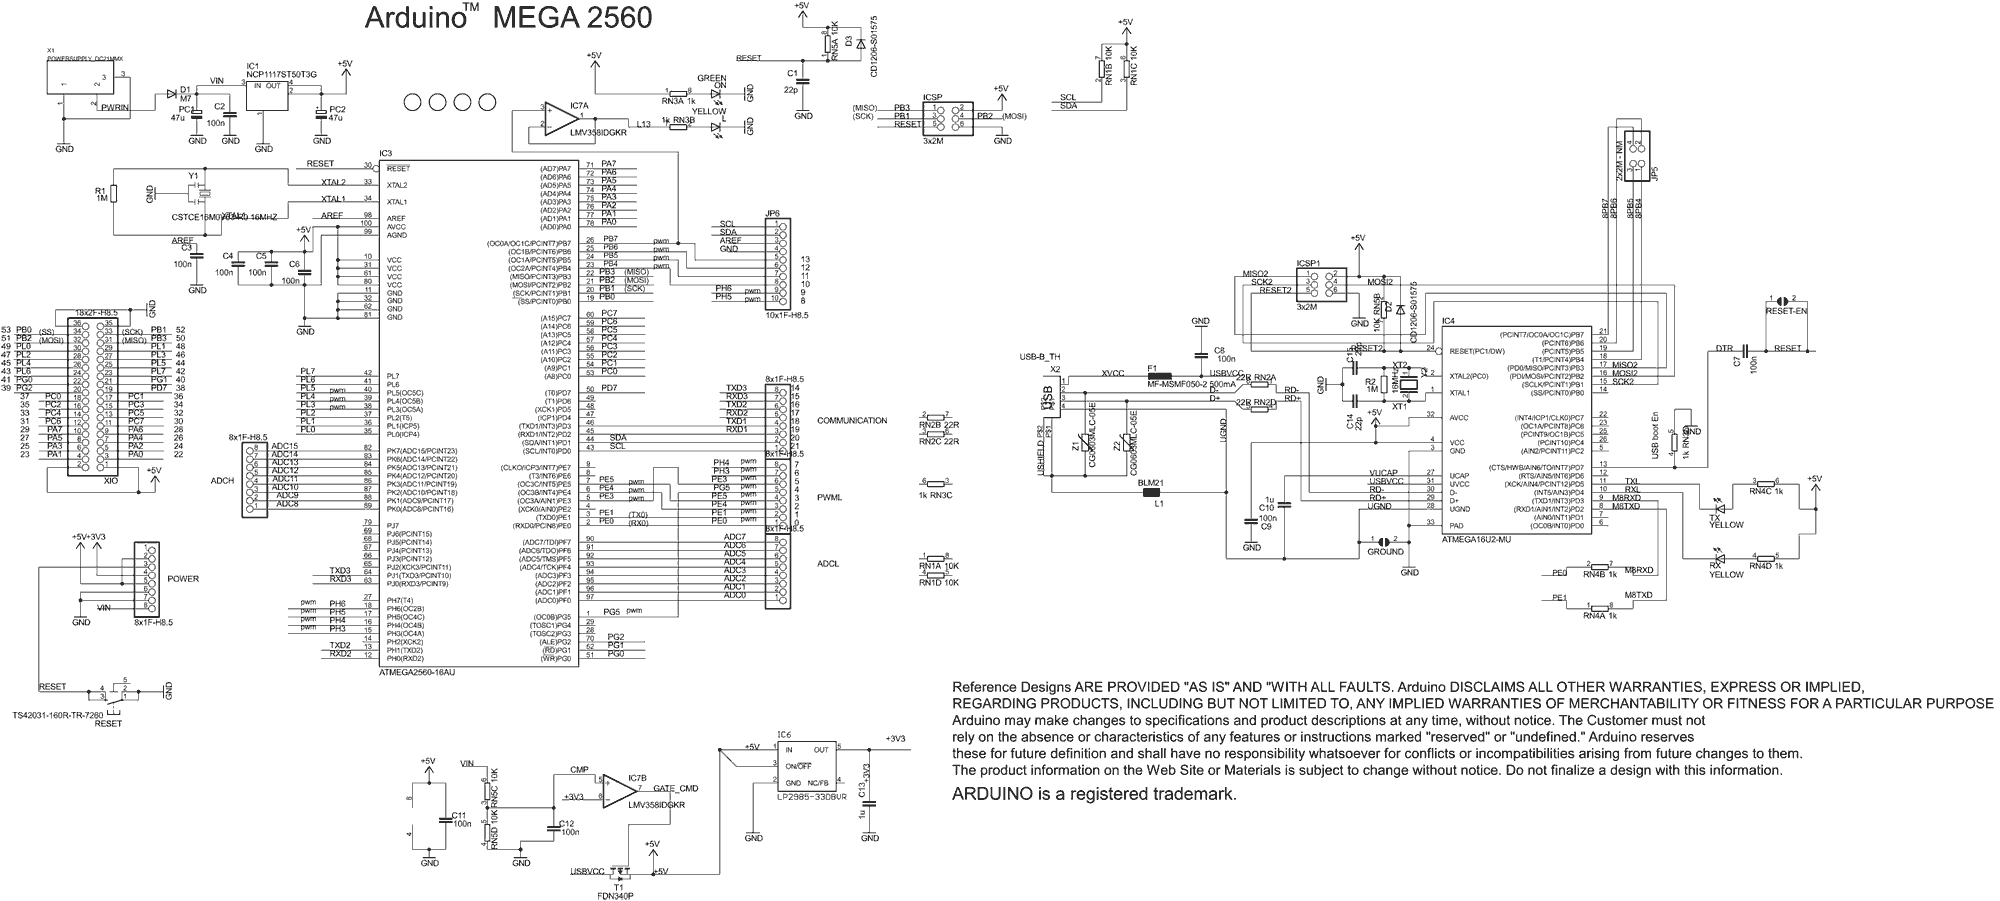
Arduino Mega 2560
Arduino Mega 2560 Board tutorials, projects, drivers, schematic, and complete information.
The Arduino Mega 2560 is a microcontroller board based on the ATmega2560. It features 54 digital input/output pins, 16 analog inputs, 4 UARTs (hardware serial ports), a 16 MHz crystal...