


mobile robot schematics
#mobile robot
#DTMF decoder
#ATMEGA16
#L293D
#DC motor
#cellphone control
#microcontroller
#motor driver
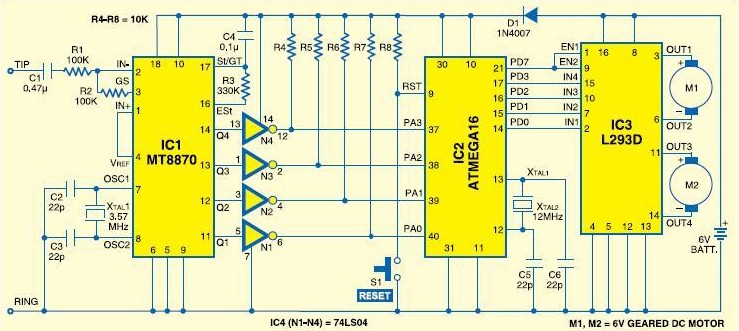
Description: Mobile robot schematic diagram for a cellphone-controlled robot. Detailed modules used for the cellphone-controlled mobile robot include: DTMF Decoder: MT8870/CM8870; Microcontroller: ATMEGA16; Motor Driver: L293D; Actuator: DC Motor 5-6V.
The mobile robot schematic diagram is designed for operation via a cellphone interface, utilizing several key components to facilitate control and movement. The DTMF (Dual-Tone Multi-Frequency) decoder, specifically the MT8870 or CM8870, serves as the primary interface for receiving commands from the cellphone. This decoder interprets the DTMF signals generated by the cellphone keypad, converting them into corresponding digital signals that can be processed by the microcontroller.
The microcontroller at the heart of this system is the ATMEGA16, which is responsible for interpreting the output from the DTMF decoder and executing the appropriate control logic. It processes the signals received and determines the actions that the robot should perform, such as moving forward, backward, or turning.
To drive the robot's movement, a motor driver, specifically the L293D, is employed. This component acts as an interface between the microcontroller and the DC motors, allowing the low-power signals from the microcontroller to control the higher-power motors effectively. The L293D can drive two DC motors simultaneously, providing the capability to control the direction and speed of the robot's movement.
The actuators used in this mobile robot are DC motors rated for 5-6V. These motors convert electrical energy into mechanical energy, enabling the robot to move. The selection of these motors is crucial as they must provide adequate torque and speed for the intended application, ensuring the robot can navigate effectively.
Overall, this schematic diagram integrates these components to create a functional mobile robot that can be controlled remotely via a cellphone, showcasing the synergy between telecommunications and robotics.Mobile robot schematic diagram for cellphone controlled robot. Detail module used for cellphone controlled mobile robot: DTMF Decoder: MT8870/CM8870 ; Microcontroller: ATMEGA16 ; Motor Driver: L293D ; Actuator: DC Motor 5-6V
The mobile robot schematic diagram is designed for operation via a cellphone interface, utilizing several key components to facilitate control and movement. The DTMF (Dual-Tone Multi-Frequency) decoder, specifically the MT8870 or CM8870, serves as the primary interface for receiving commands from the cellphone. This decoder interprets the DTMF signals generated by the cellphone keypad, converting them into corresponding digital signals that can be processed by the microcontroller.
The microcontroller at the heart of this system is the ATMEGA16, which is responsible for interpreting the output from the DTMF decoder and executing the appropriate control logic. It processes the signals received and determines the actions that the robot should perform, such as moving forward, backward, or turning.
To drive the robot's movement, a motor driver, specifically the L293D, is employed. This component acts as an interface between the microcontroller and the DC motors, allowing the low-power signals from the microcontroller to control the higher-power motors effectively. The L293D can drive two DC motors simultaneously, providing the capability to control the direction and speed of the robot's movement.
The actuators used in this mobile robot are DC motors rated for 5-6V. These motors convert electrical energy into mechanical energy, enabling the robot to move. The selection of these motors is crucial as they must provide adequate torque and speed for the intended application, ensuring the robot can navigate effectively.
Overall, this schematic diagram integrates these components to create a functional mobile robot that can be controlled remotely via a cellphone, showcasing the synergy between telecommunications and robotics.Mobile robot schematic diagram for cellphone controlled robot. Detail module used for cellphone controlled mobile robot: DTMF Decoder: MT8870/CM8870 ; Microcontroller: ATMEGA16 ; Motor Driver: L293D ; Actuator: DC Motor 5-6V
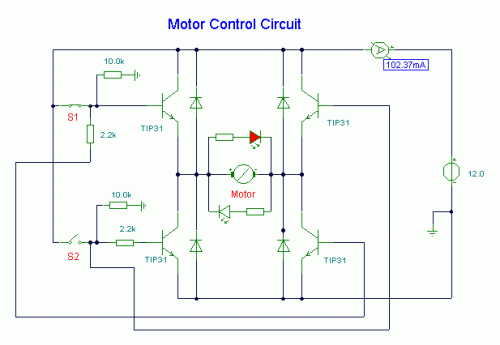
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes can be either red or green and are used solely for indicating direction. The TIP31 transistors may need to be adjusted based on the motor specifications. It is important...
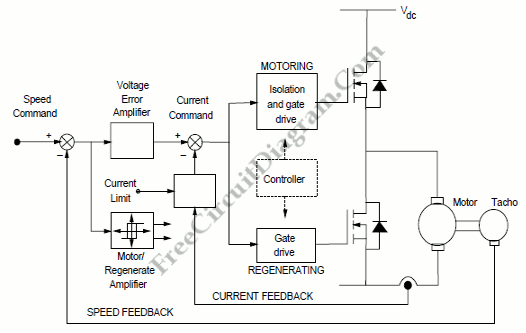
DC Motor Control System Block Diagram
A schematic arrangement for a two-quadrant controller is shown in the figure below. This figure illustrates the outer speed control loop and the inner current control loop. The tachogenerator derives the speed feedback signal; alternatively, an approximation of the motor...
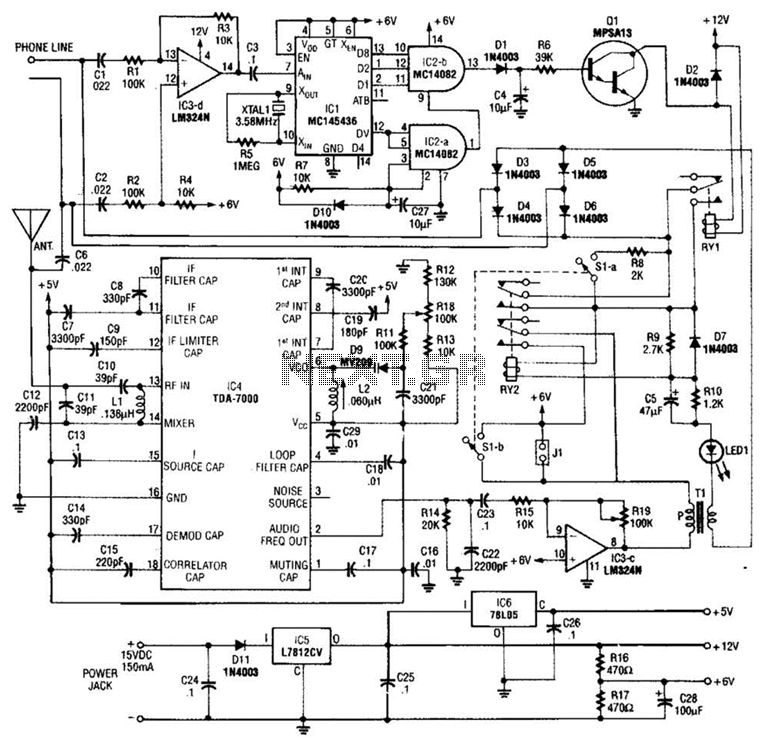
Music On Hold Circuit
When the asterisk (*) is pressed on the touch-tone phone, a DTMF decoder, referred to as TCI, manages the on-hold logic. Audio from the FM receiver IC4 is transmitted over the telephone line when a hold condition is active. RY2...
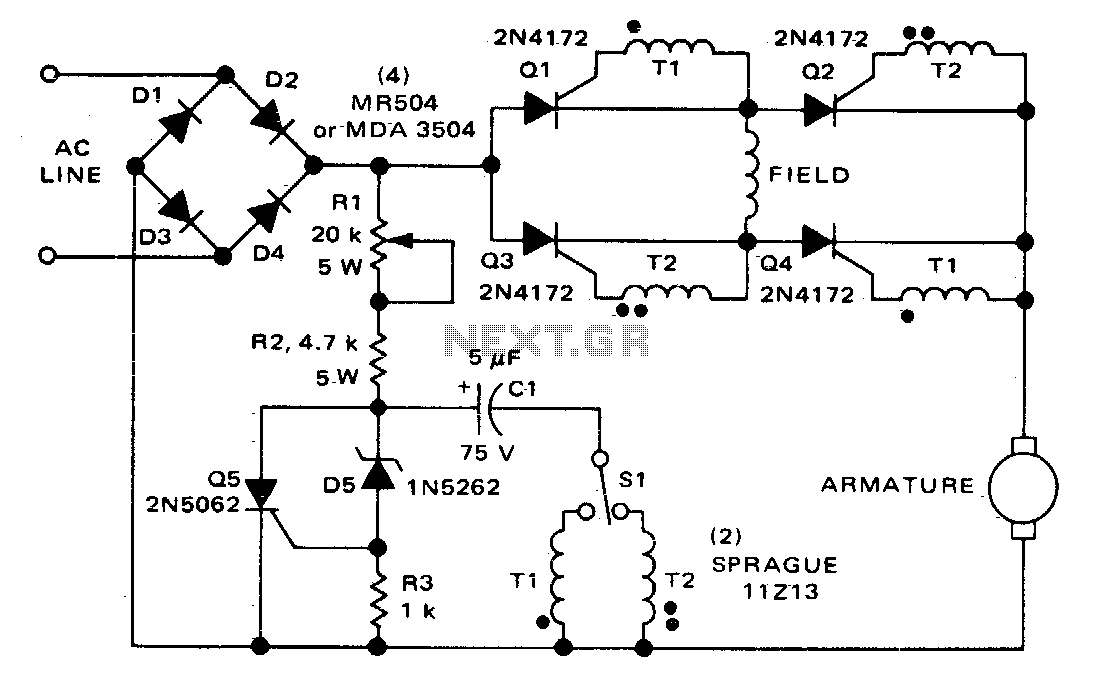
Direction and speed control for series-wound motors
The circuit can control the speed and direction of rotation of a series-wound DC motor. Silicon controlled rectifiers Q1-Q4 are arranged in a bridge configuration and are triggered in diagonal pairs. The selection of which pair to activate is managed...
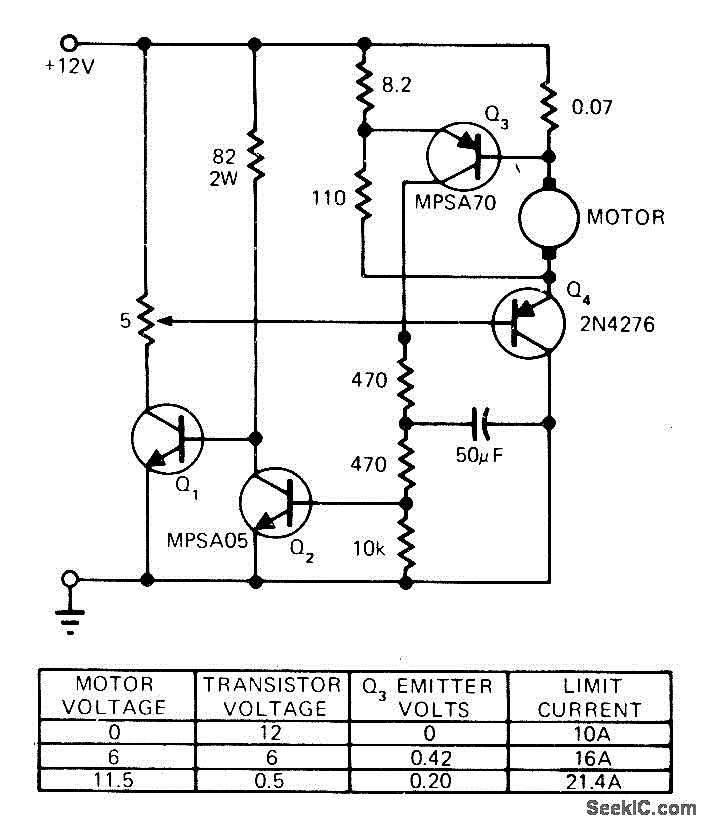
STALLED_MOTOR_PROTECTION
The modification of a basic speed control circuit for small DC permanent-magnet motors implements a maximum current limit during normal operating conditions and a reduced current limit during stall conditions. This design aims to limit the dissipation of series transistor...
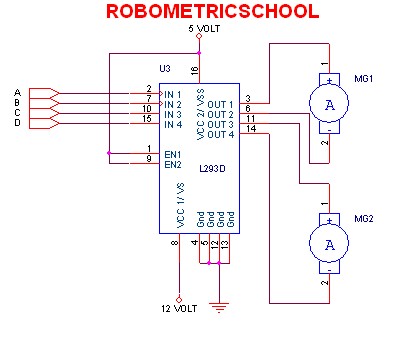
Electronic Circuit Schematic DC Motor Driver using L293D Dual H-Bridge
The electronic schematic of a DC motor driver using the L293D, as illustrated in Figure 2, enables the control of two DC motors continuously. It allows for one motor to rotate clockwise while the other rotates counterclockwise. Additionally, all motors...
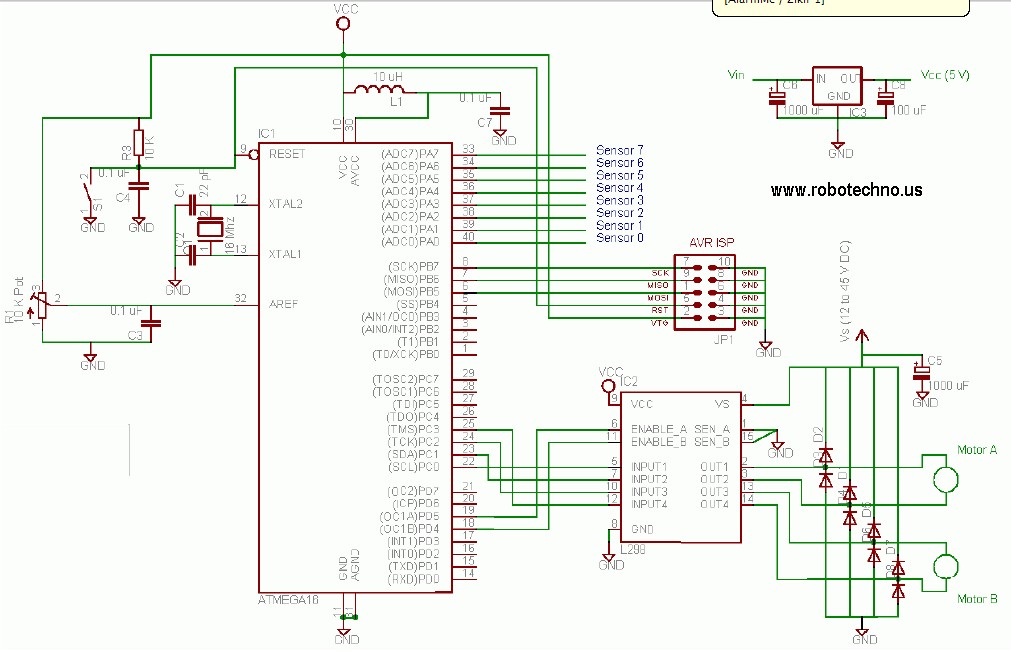
line follower tutorial based atmega16 l298 motor driver
This line follower robot utilizes the following components: eight phototransistor proximity sensors, an ATMega16 microcontroller, an L298 motor driver, and is programmed using the C programming language.
The line follower robot is designed to navigate along a designated path by detecting...
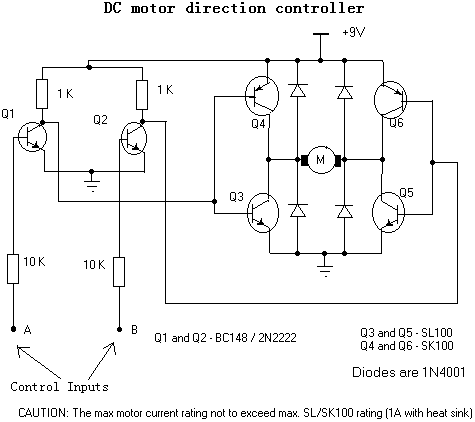
DC Motor Direction Controller
For controlling a small DC motor, such as the one found in a tape recorder, Q1 and Q2 are in saturation when both points A and B are HIGH. Component: ..
To control a small DC motor effectively, a circuit utilizing...
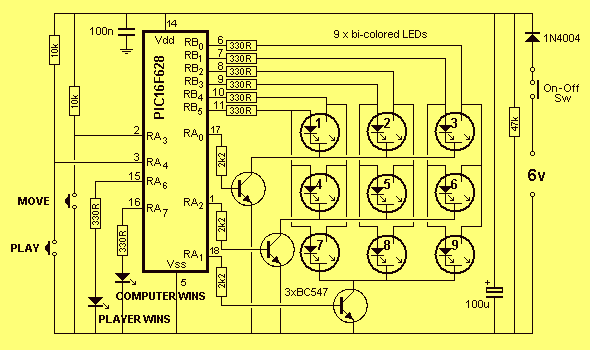
Electronic TIC TAC TOE
This project is not to introduce Tic Tac Toe. Everyone knows this game. It is to introduce two features: bi-coloured LEDs, microcontrollers, and the skill of writing an ALGORITHM. You can use the project to learn the skills of creating...