


Electronic Circuit Schematic DC Motor Driver using L293D Dual H-Bridge
#L293D
#DC motor
#H-Bridge
#motor driver
#PWM control
#bidirectional control
#Arduino
#robotics
#electronics
#DIY
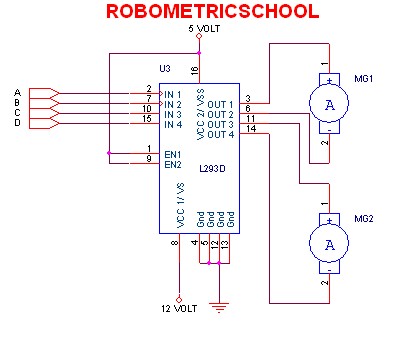
Description: The electronic schematic of a DC motor driver using the L293D, as illustrated in Figure 2, enables the control of two DC motors continuously. It allows for one motor to rotate clockwise while the other rotates counterclockwise. Additionally, all motors can be controlled to rotate either clockwise, counterclockwise, or to stop entirely. Control is achieved through input signals to the L293D.
According to the guidance provided in Figure 3, the motor will rotate clockwise when a logic high (1) is applied to input A and a logic low (0) is applied to input B. Conversely, the motor will rotate counterclockwise when input A receives a logic low (0) and input B is set to a logic high (1). To stop all motors, a logic high (1) must be applied to all input pins. It is crucial to avoid applying a logic low (0) to all inputs simultaneously, as this can lead to errors or damage to the L293D, potentially resulting in overheating or short circuits.
The L293D is a dual H-bridge motor driver capable of controlling the direction and speed of DC motors. Each H-bridge can control one motor, allowing for independent operation of two motors. The device features built-in diodes for back EMF protection, which is essential for safeguarding the circuit from voltage spikes generated by the motors during operation.
To implement the circuit, the L293D is connected to the power supply, motors, and a microcontroller or other control logic. The control signals from the microcontroller dictate the state of the inputs A and B for each motor. By using PWM (Pulse Width Modulation) on the enable pins of the L293D, speed control can also be achieved, allowing for variable motor speeds in addition to directional control.
Proper heat dissipation measures should be considered, as the L293D can generate heat during operation, especially under high load conditions. Heat sinks may be necessary to maintain optimal operating temperatures and prevent thermal shutdown. Overall, the L293D motor driver is a versatile component for robotics and automation applications, providing efficient control of DC motors in various configurations.According electronic schematic of DC driver motor using L293D in figure 2, we can use it to control two DC motor continuously. We can control DC motor one to rotate clock wise and DC motor two to rotate anti clock wise. We also can control all motor to rotate clock wise, anti click wise, or stop all. We can control it with give control in input of L293D. You can use guidance like in figure 3 bellow: From figure 3 above, we can make motor rotate clock wise when in input we give 1 logic in A and 0 logic in B. Also we can make motor rotate anti clock wise when input we give 0 logic in A and 1 logic in B. We can stop all motor with give in all input 1 logic. Attention you don`t give in all input with 0 logic, because it can make L293D error or damage like burn or shot circuit.
So careful when you set it. Thank you very much for your visiting in Robometricschool blog, We hope you will get more information about Robotic, Mechatronic, and Electronic. And don`t forget to give us your comment about this article. Let keep for building comment.
According to the guidance provided in Figure 3, the motor will rotate clockwise when a logic high (1) is applied to input A and a logic low (0) is applied to input B. Conversely, the motor will rotate counterclockwise when input A receives a logic low (0) and input B is set to a logic high (1). To stop all motors, a logic high (1) must be applied to all input pins. It is crucial to avoid applying a logic low (0) to all inputs simultaneously, as this can lead to errors or damage to the L293D, potentially resulting in overheating or short circuits.
The L293D is a dual H-bridge motor driver capable of controlling the direction and speed of DC motors. Each H-bridge can control one motor, allowing for independent operation of two motors. The device features built-in diodes for back EMF protection, which is essential for safeguarding the circuit from voltage spikes generated by the motors during operation.
To implement the circuit, the L293D is connected to the power supply, motors, and a microcontroller or other control logic. The control signals from the microcontroller dictate the state of the inputs A and B for each motor. By using PWM (Pulse Width Modulation) on the enable pins of the L293D, speed control can also be achieved, allowing for variable motor speeds in addition to directional control.
Proper heat dissipation measures should be considered, as the L293D can generate heat during operation, especially under high load conditions. Heat sinks may be necessary to maintain optimal operating temperatures and prevent thermal shutdown. Overall, the L293D motor driver is a versatile component for robotics and automation applications, providing efficient control of DC motors in various configurations.According electronic schematic of DC driver motor using L293D in figure 2, we can use it to control two DC motor continuously. We can control DC motor one to rotate clock wise and DC motor two to rotate anti clock wise. We also can control all motor to rotate clock wise, anti click wise, or stop all. We can control it with give control in input of L293D. You can use guidance like in figure 3 bellow: From figure 3 above, we can make motor rotate clock wise when in input we give 1 logic in A and 0 logic in B. Also we can make motor rotate anti clock wise when input we give 0 logic in A and 1 logic in B. We can stop all motor with give in all input 1 logic. Attention you don`t give in all input with 0 logic, because it can make L293D error or damage like burn or shot circuit.
So careful when you set it. Thank you very much for your visiting in Robometricschool blog, We hope you will get more information about Robotic, Mechatronic, and Electronic. And don`t forget to give us your comment about this article. Let keep for building comment.
arduino electronics
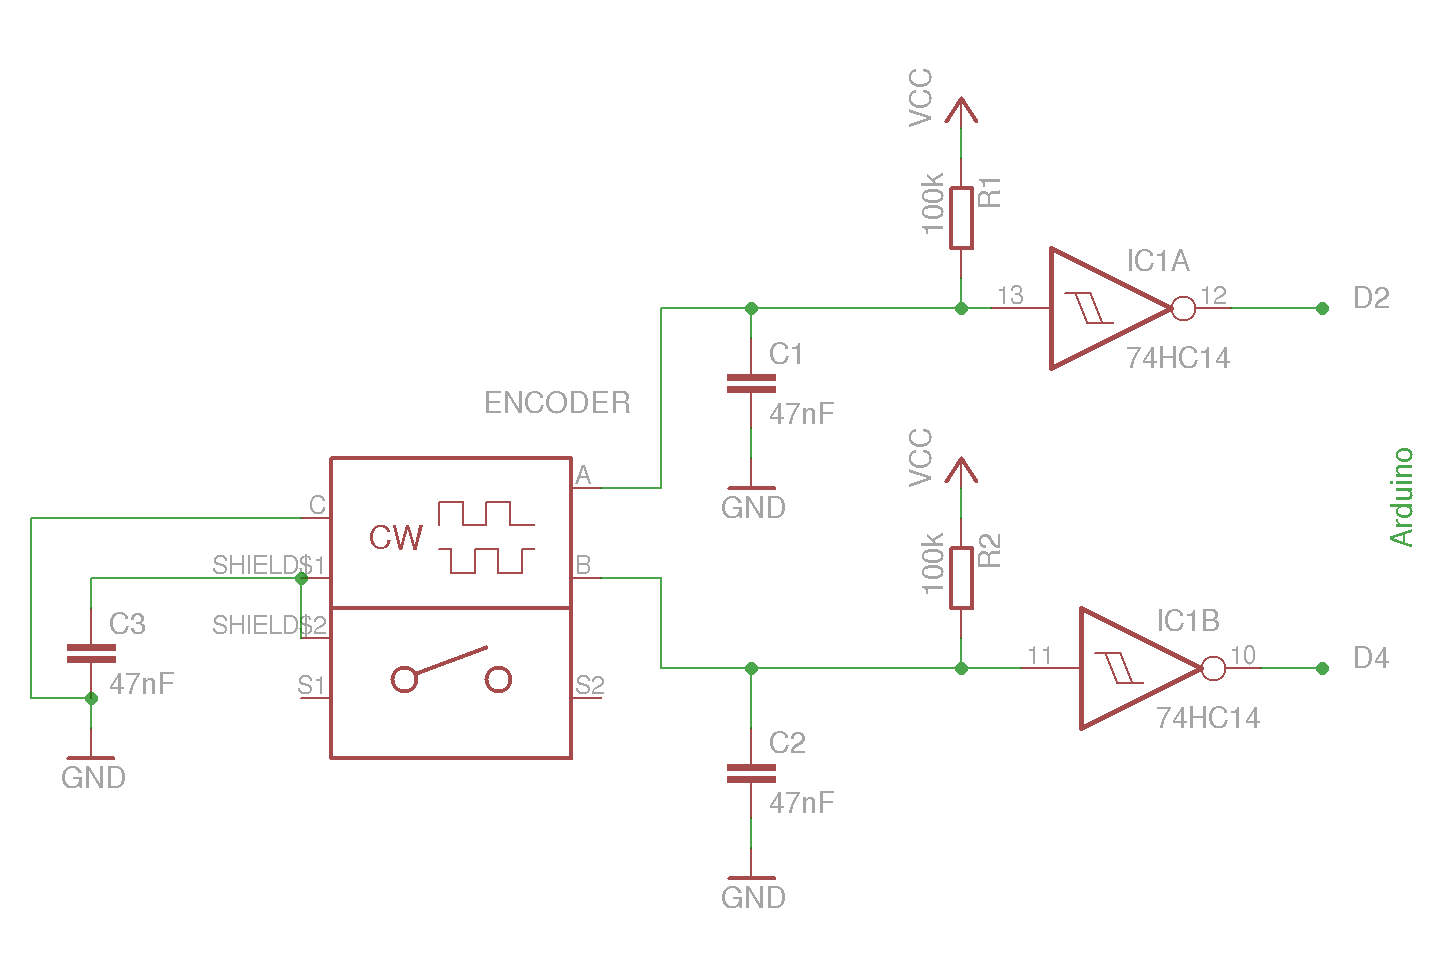
The example circuit and code should be sufficient to begin without delving into additional details. A rotary encoder is an electromechanical component with a shaft that records rotation and converts it into electrical pulses to indicate the direction of rotation....
The Cylonduino Arduino Experiement
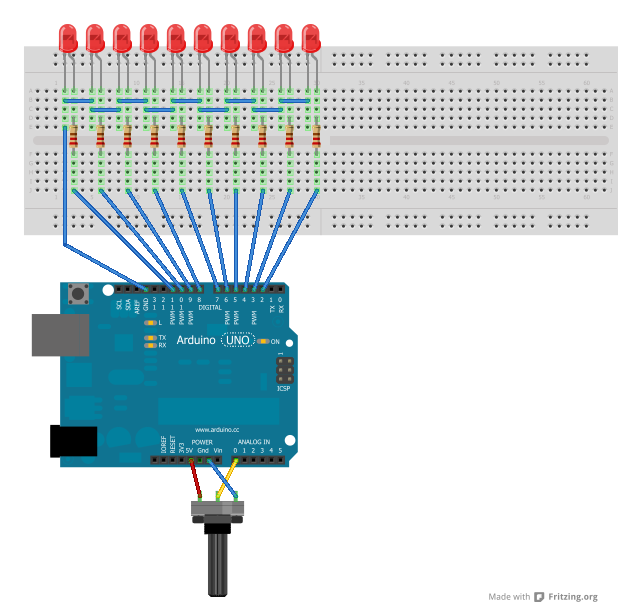
A significant amount of extra hours has been dedicated to work in anticipation of an editing deadline. Despite this, it is deemed appropriate to attempt some hardware hacking. An interest in electronics has existed since before the advent of computers,...
bidirectional dc motor driver schematic
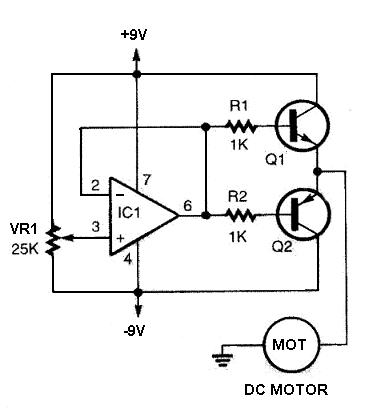
The DC motor driver circuit depicted in the images can be utilized for controlling DC motors, allowing for bidirectional rotation and adjustable speed. This straightforward circuit is constructed using a 741 operational amplifier (op-amp) as a voltage comparator, along with...
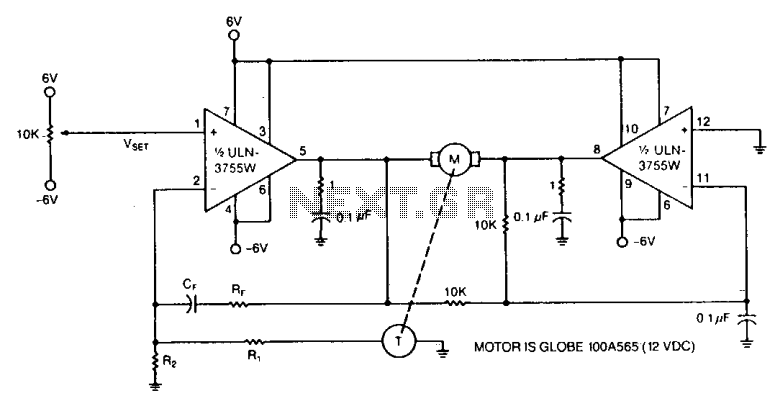
Dc motor speed control 2
Power operational amplifiers provide precise speed control for DC motors. The circuit enables bidirectional speed control. The push-pull configuration of the amplifiers ensures a full rail-to-rail voltage swing (minus the saturation drops of the output stages) across the motor in...
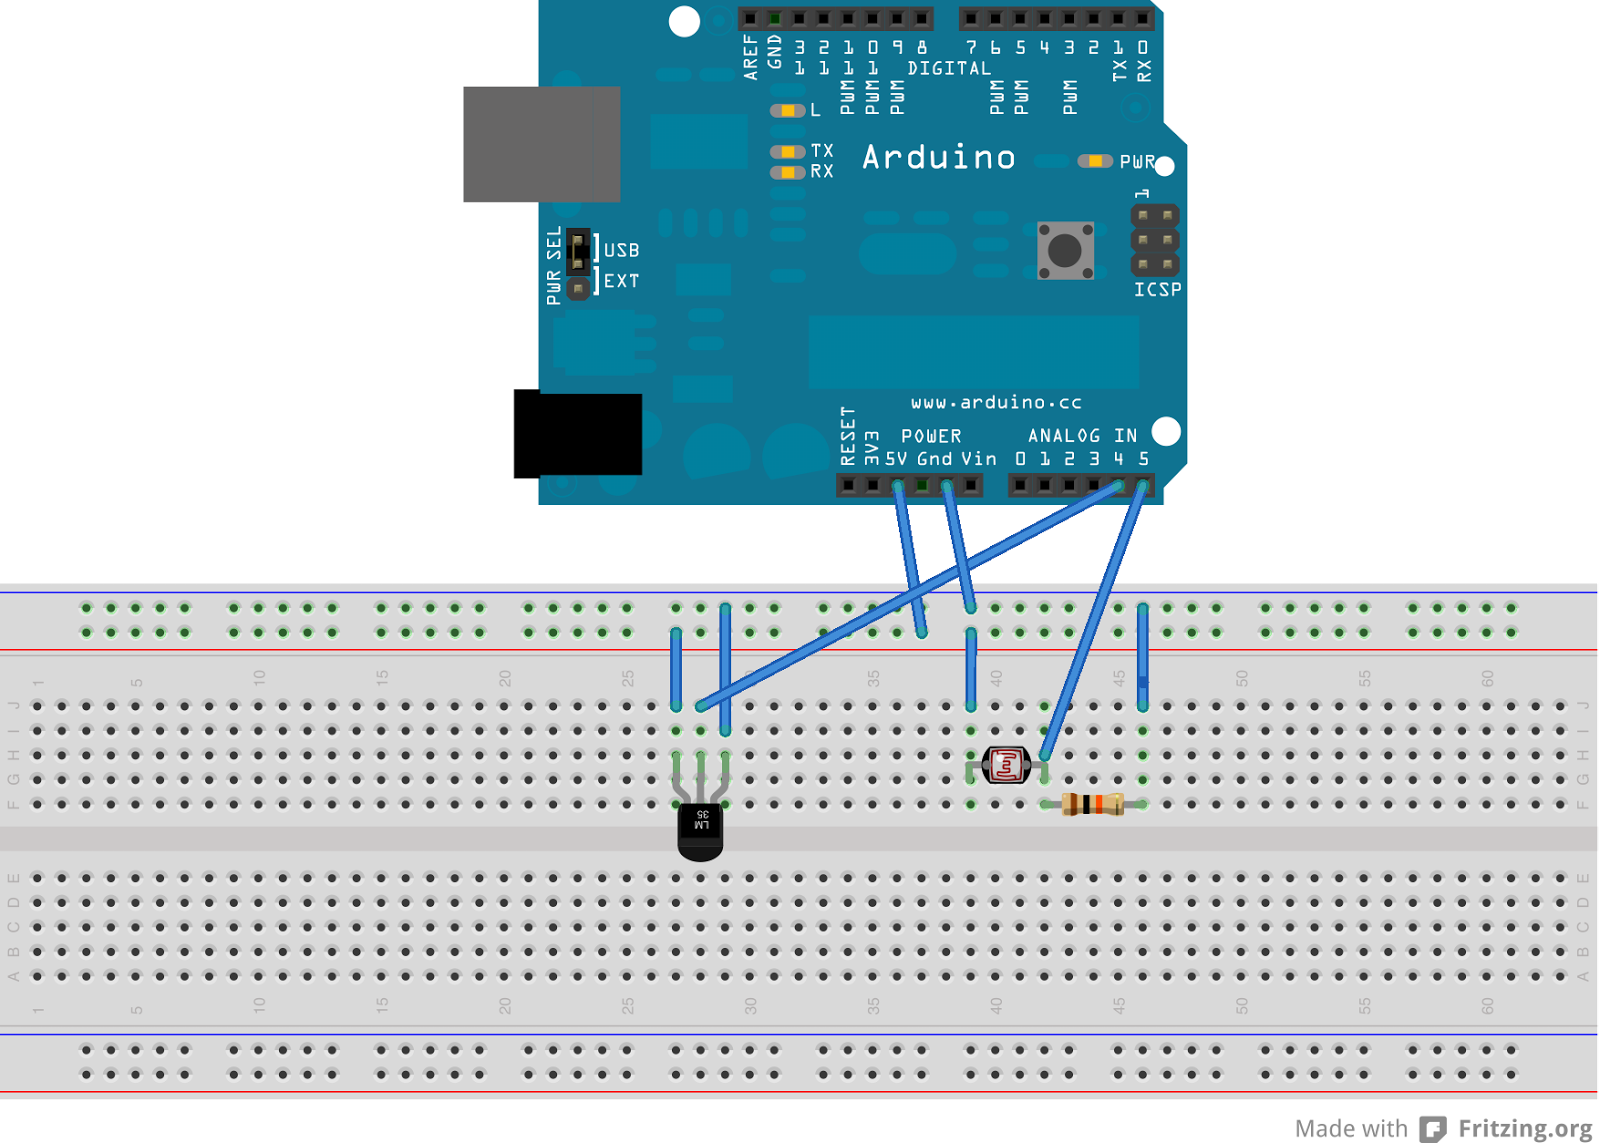
arduino temperature and light sensor
This device transmits data regarding the state of an office to Twitter, as it is deemed slightly more relevant than sharing similar information about a residence. It holds potential significance for biodiversity-related activities, especially when integrated with long-range WiFi technologies....
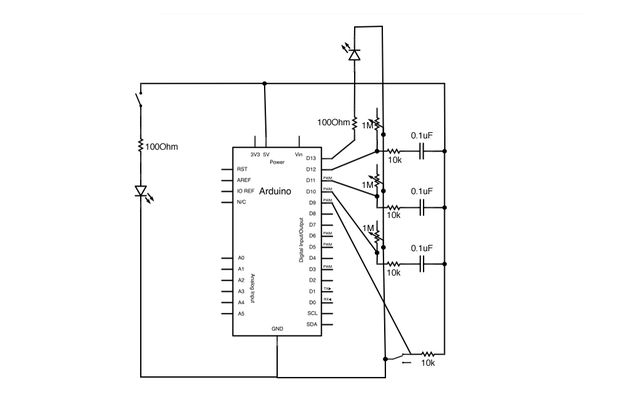
Arduino Vocal Effects Box Schematic
The schematic has been divided into three sections for improved comprehension. The first section illustrates the audio output circuit. This project is designed to output audio.
The audio output circuit typically involves several key components that work together to process and...
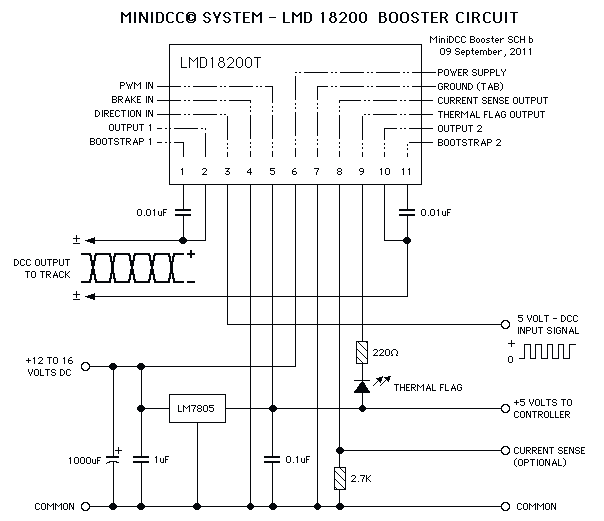
H-Bridge Motor Control Circuits
These circuits could be used as the basis for Model Railroad DCC Boosters or PWM motor controllers. The first schematic is for a basic 3 Amp - DCC Booster using the LMD 18200 CMOS, H-Bridge. Included in the design is...
Arduino Differential Controller
Faulty readings from the DS18B20 temperature sensors used in tank thermometers were likely caused by the waterproofing method involving heat shrink and silicone. This situation provided an opportunity to enhance the code for better tolerance against erroneous readings. The tank...
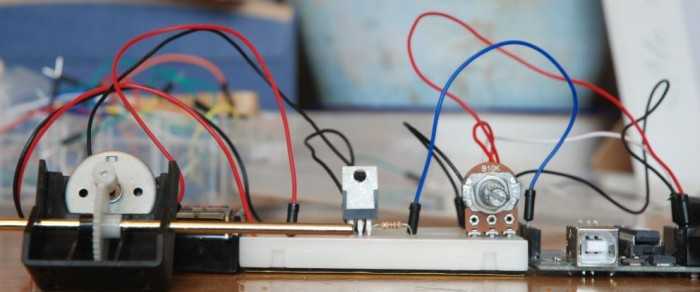
Control the speed of a DC motor with a potentiometer with an Arduino board
A quick circuit showing how to control the speed of a DC motor with a potentiometer with your Arduino board. Also shows how to use a TIP120 transistor to allow the Arduino control a larger power supply.
This circuit utilizes an...