


line follower tutorial based atmega16 l298 motor driver
#ATMega16
#L298
#motor driver
#line follower
#phototransistors
#C programming
#robotics
#sensor array
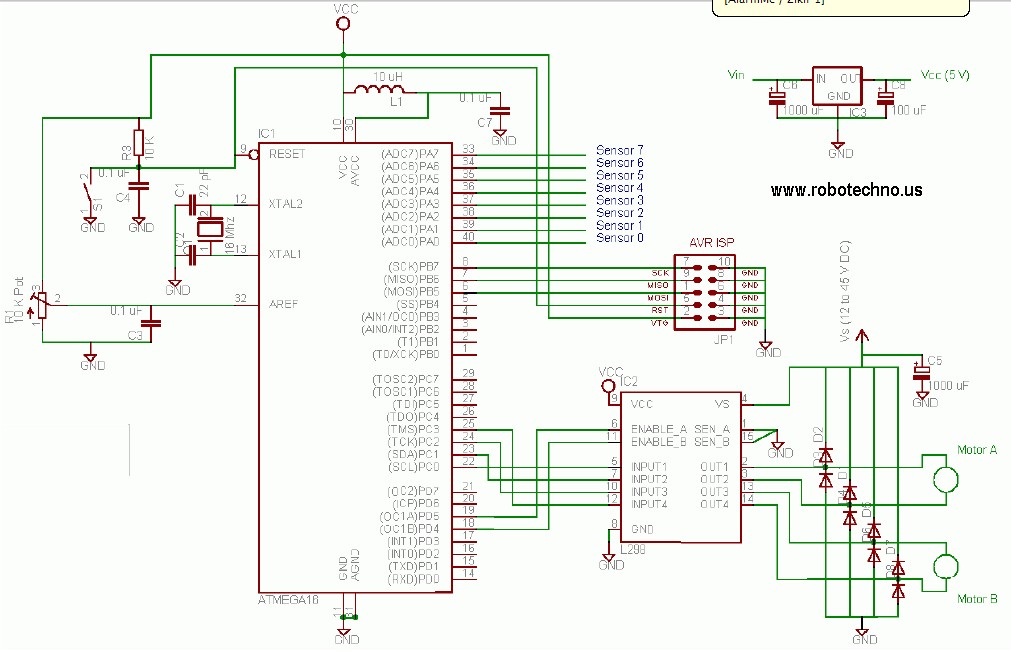
Description: This line follower robot utilizes the following components: eight phototransistor proximity sensors, an ATMega16 microcontroller, an L298 motor driver, and is programmed using the C programming language.
The line follower robot is designed to navigate along a designated path by detecting and following lines on the ground. The system employs eight phototransistor proximity sensors strategically placed to enhance detection accuracy. These sensors are capable of identifying contrasts between the line color and the surface, allowing the robot to make real-time adjustments to its movement.
The heart of the robot is the ATMega16 microcontroller, which processes the input signals from the phototransistor sensors. This microcontroller is programmed in the C programming language, enabling the implementation of algorithms that determine the robot's direction based on sensor readings. The software logic typically involves comparing the values from the sensors to decide whether the robot should move forward, turn left, or turn right.
The L298 motor driver is utilized to control the motors that drive the robot's wheels. This driver can control the speed and direction of the motors based on the signals received from the ATMega16 microcontroller. It is capable of driving two DC motors, allowing for differential steering, which is essential for maneuvering the robot along curves and corners of the line.
Overall, the combination of these components allows the line follower robot to operate efficiently and reliably, making it a practical example of robotics and automation in action. The integration of sensors, microcontroller, and motor driver, along with the programming in C, showcases the fundamental principles of electronic circuit design and embedded systems.This line follower robot use the following module: Proximity sensor: 8 pcs of phototransistors; ATMega16 Microcontroller; Motor driver L298; C Programming language
The line follower robot is designed to navigate along a designated path by detecting and following lines on the ground. The system employs eight phototransistor proximity sensors strategically placed to enhance detection accuracy. These sensors are capable of identifying contrasts between the line color and the surface, allowing the robot to make real-time adjustments to its movement.
The heart of the robot is the ATMega16 microcontroller, which processes the input signals from the phototransistor sensors. This microcontroller is programmed in the C programming language, enabling the implementation of algorithms that determine the robot's direction based on sensor readings. The software logic typically involves comparing the values from the sensors to decide whether the robot should move forward, turn left, or turn right.
The L298 motor driver is utilized to control the motors that drive the robot's wheels. This driver can control the speed and direction of the motors based on the signals received from the ATMega16 microcontroller. It is capable of driving two DC motors, allowing for differential steering, which is essential for maneuvering the robot along curves and corners of the line.
Overall, the combination of these components allows the line follower robot to operate efficiently and reliably, making it a practical example of robotics and automation in action. The integration of sensors, microcontroller, and motor driver, along with the programming in C, showcases the fundamental principles of electronic circuit design and embedded systems.This line follower robot use the following module: Proximity sensor: 8 pcs of phototransistors; ATMega16 Microcontroller; Motor driver L298; C Programming language
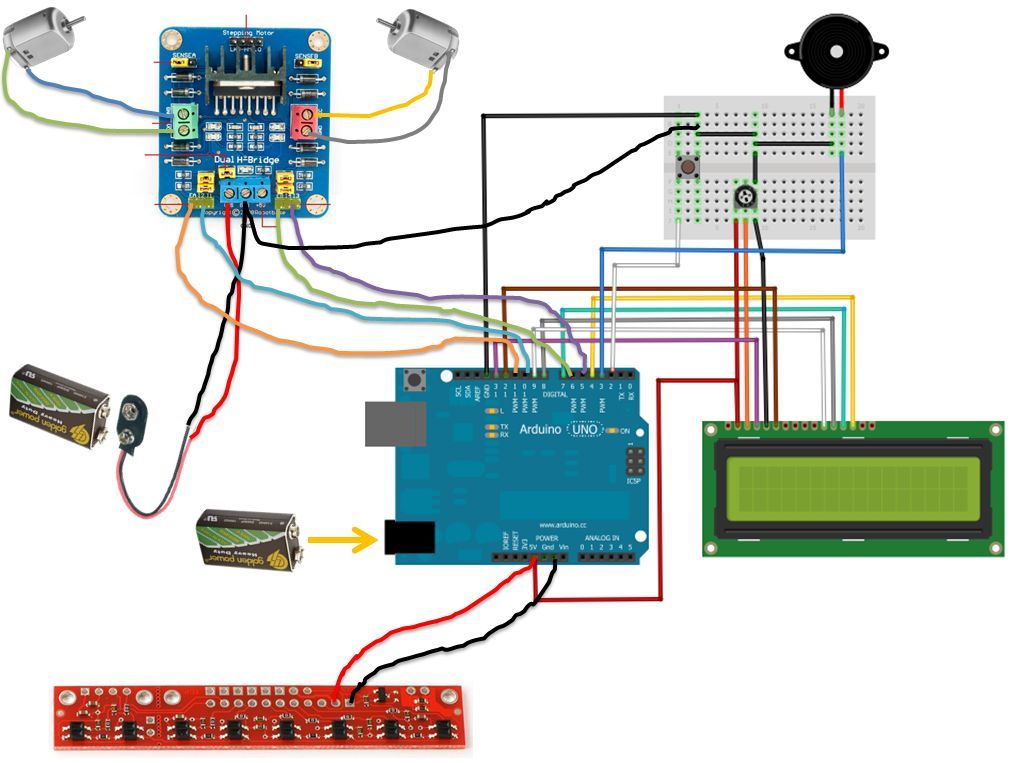
LINUSBot - Line Follower Robot using Arduino
If the robot is positioned on the black line, it will continue moving forward. However, if it veers off the line and enters a white area, it will assess whether to correct its path to the left or right, allowing...
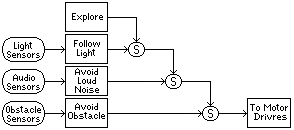
Subsumption Architecture
This term refers to a robotic control concept developed by Rodney Brooks, closely associated with behavior-based robotics, which incorporates modular behavior-based artificial intelligence. Unlike traditional artificial intelligence that relies on a centralized, top-down planning, execution, and monitoring structure, subsumption architecture...
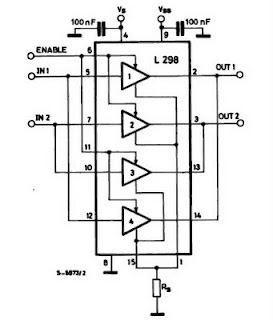
Motor driver L298 Circuit Schematic Diagram
The IC H-Bridge DC motor driver L298 contains two H-Bridge circuits, allowing it to drive two DC motors simultaneously. Each H-Bridge circuit can deliver currents up to 2A. When used in parallel, the L298 can provide a total current capacity...
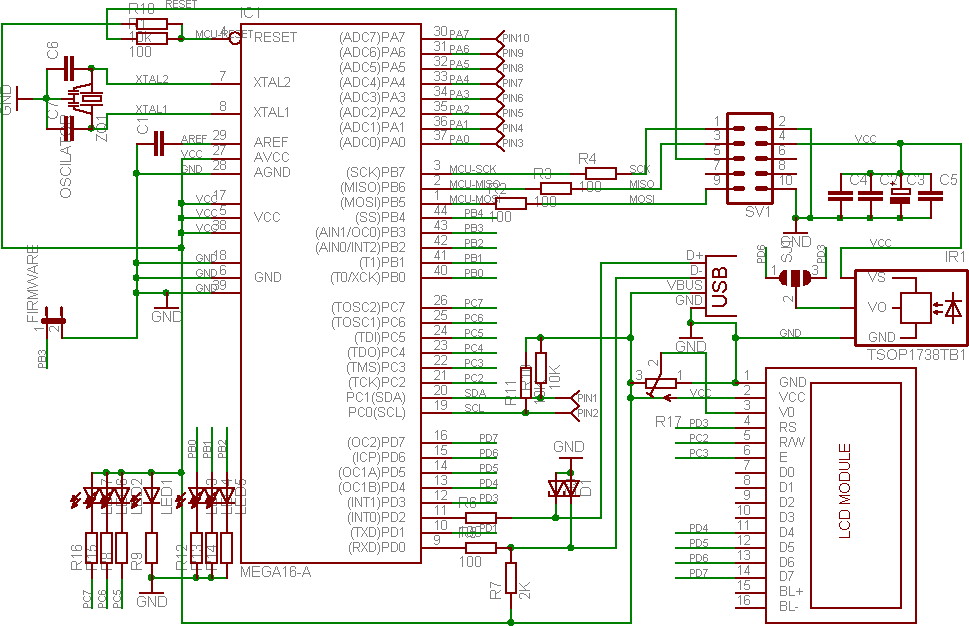
ATMEGA USB 001
In previous discussions, it was mentioned that several ATMEL ATMEGA16 processors were resoldered. A decision was made to create a useful application utilizing this microcontroller. Given that this controller offers increased ROM and RAM capacity, high-level programming in C was...
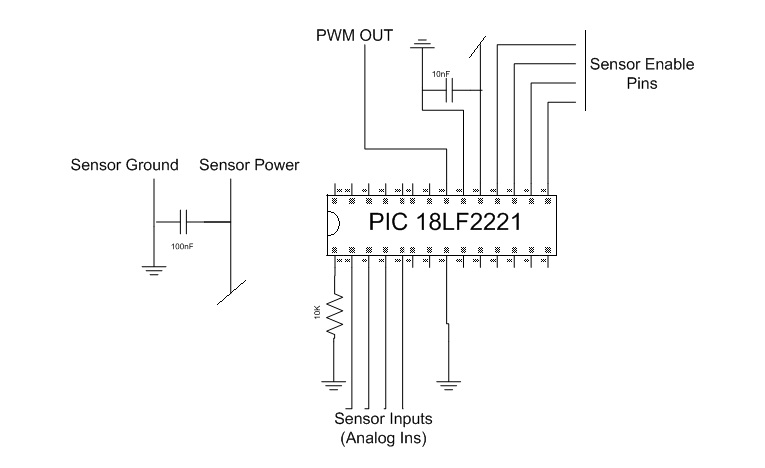
maze robot sensor integration
This project was completed during a robotics course taught by Prof. Dave Barret at Olin College. The final project aimed to navigate a maze using a Surveyor robotic platform. Additional sensors were incorporated into the robot, with a focus on...
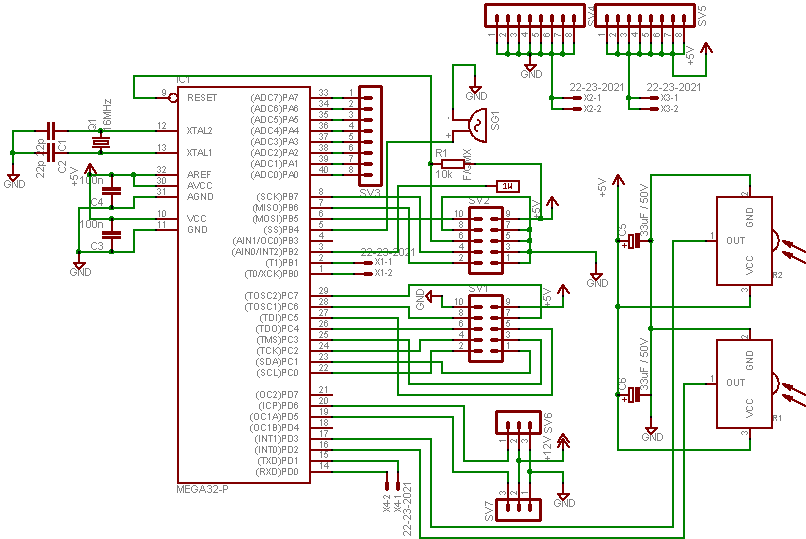
Basic tracked robot with Targeting Laser pod Tutorials
In this project, an ATMEGA16 microcontroller operating at 16MHz will be utilized. To distinguish this project from others, a unique feature has been incorporated: a battery monitoring system. Many robots operate on new or freshly recharged batteries, and if the...
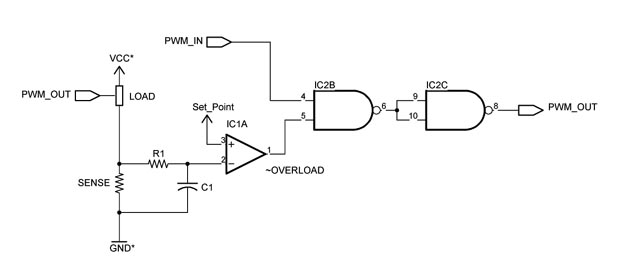
Custom Motor Driver
This chapter was removed from Applied Robotics 2 due to space constraints. It addresses general motor control issues and details the construction of a 5-amp motor driver. The principles discussed can be applied to larger motor controllers. Although commercially available...

Music Driven Motor Schematic
Music Driven Motor Schematic. The geared motor drives the stem of a dancing flower to the beat of music.
The music-driven motor schematic involves a geared motor that is activated in response to sound signals, specifically music. This design typically incorporates...
Sensor
The article "Creating a Line Follower Robot with AVR" is a continuation of a previous article on Line Follower Robots, introducing a new AVR ATMega8535 and providing a block diagram of the Line Follower Robot. The earlier article, "Creating a...