


Sequencer circuit
#4017
#sequencer
#reset circuit
#IC
#counter
#logic circuit
#CMOS
#digital counter
#pulse divider
#timing circuit
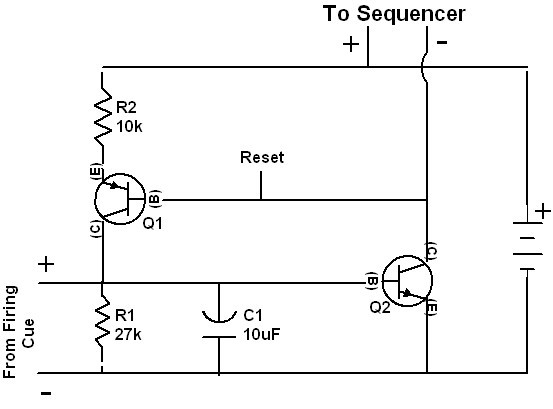
Description: The 4017 integrated circuits are not initialized to a known state because the reset pins are not briefly forced high when the circuit is powered on. While the chips might typically power up in the normal reset condition, this is not guaranteed by the IC manufacturer and is likely a minor concern. Additionally, in IC2 4017, outputs Q2 through Q9 are shorted together and connected to the reset pin, which represents a significant design flaw. This seems to be an attempt to modify the design of the lower schematic provided. In that design, only 20 outputs are used, and when IC2 toggles Q2 high, it resets IC2 back to Q0 being high. In the upper schematic, if all 10 banks of outputs on IC2 are utilized, none of the outputs should connect back to the reset pin. Moreover, only specific types of logic can tolerate outputs being shorted together, and the 4017 is not one of them. Furthermore, tying an output pin back to the asynchronous reset pin creates a race condition. The width of the reset pulse will be limited to the propagation delay from the reset pin to the output pin driving it. Although this may work, many circuit designers would avoid this approach, which is likely another minor concern. There is agreement that a 4017 cannot drive the positive side of a relay. While it may work in certain cases, as evidenced by a video, unless extremely sensitive relays are used that require minimal current to energize, this approach violates the output drive specifications of the 4017. The 555 schematic referenced is incorrect; it depicts the monostable mode, which generates one output pulse when triggered. The correct configuration is the astable or free-running oscillator, as referenced in figure 9b of the provided link. There is no single design that suits all applications. A system requiring selectable delays should consider using a microcontroller such as a PIC or AVR. These devices may require an initial learning period, but they offer significant flexibility in design without the need for hardware changes. Microcontrollers typically have inexpensive or DIY programmers and accessible software, along with valuable online forums for support. It is essential to thoroughly understand the design requirements and experiment with components before finalizing a design. Feedback on design flaws is crucial for improvement, and understanding the underlying concerns is encouraged. Adding a resistor will not resolve the issue of triggering the reset at the end of a partial sequence.
The 4017 decade counter is a versatile component commonly used in various digital circuits for counting applications. However, its proper configuration is critical for reliable operation. The initialization of the 4017 is vital; without ensuring that the reset pins are briefly forced high during power-up, the state of the outputs may become unpredictable. This lack of initialization can lead to erratic behavior in applications that depend on specific output states.
Shorting outputs Q2 through Q9 to the reset pin is a notable design flaw. In a typical application, each output should be independently controlled to ensure proper functioning. When Q2 is driven high, it inadvertently resets the counter, causing it to revert to its initial state, which can disrupt the intended counting sequence. This feedback loop can lead to unintended consequences, especially in designs requiring all outputs to function independently.
The race condition created by tying an output back to the reset pin can result in unreliable circuit operation. The timing of the reset pulse is contingent upon the propagation delay, which is typically not designed to handle such configurations. This can lead to scenarios where the reset does not occur as intended, further complicating the circuit's behavior.
The limitation of the 4017 in driving relays is another significant consideration. While it may appear to function in certain scenarios, relying on the 4017 to drive the positive side of a relay can lead to potential damage or failure of the IC. A dedicated driver circuit or a relay module with appropriate specifications should be employed to ensure reliable operation.
For applications requiring variable timing or complex logic, transitioning to microcontrollers offers a more robust solution. Microcontrollers provide the flexibility to implement various timing sequences, logic operations, and control mechanisms that can be adapted to meet specific project requirements. The availability of simple programming tools and community support makes them an attractive option for both novice and experienced designers.
Overall, careful consideration of circuit design and component selection is essential for achieving desired performance and reliability in electronic systems. Understanding the limitations and capabilities of components like the 4017, along with the advantages of microcontrollers, can significantly enhance the quality of electronic designs.First, the 4017`s aren`t initialized to a known state since the reset pins aren`t briefly forced high when the circuit powers on. The chips might usually power up in the normal reset condition, but that isn`t probably guaranteed by the IC manufacturer.
This is probably only a minor concern. Second, on the IC2 4017, outputs Q2 through Q9 are shorted together and tied to the reset pin. This is a major design flaw. This appears to be an attempt to modify the design of the lower schematic you provide. In that design, there are only 20 outputs used, and when IC2 toggles Q2 high, that high will reset IC2 back to Q0 being high. In your upper schematic, if you are really using all 10 banks of outputs on IC2, none of the outputs need to feed back to the reset pin.
Regardless, only certain types of logic can tolerate outputs being shorted together, and the 4017 isn`t one of them. Third, tying an output pin back to the asynchronous (instantaneous, not on a clock edge) reset pin creates what is called a race condition.
The width of the reset pulse will only be as long as the propogation delay from the reset pin to the output pin driving it. While this might work, there are a lot of circuit designers who wouldn`t do that. This is also probably only a minor concern. I agree with Cat that a 4017 can`t drive the positive side of a relay. Doing so might work for some reason (as the relay clicks in Janneman1`s video seems to prove), but unless you are using extremely sensitive relays that take little current to energize them, you are violating the output drive spec of the 4017.
I don`t know - maybe it works for very short relay pulses, or maybe the chip will put up with this for a while, but this is another major concern. Cat, the 555 schematic you pasted in isn`t the right one. That schematic is the monostable mode that generates one output pulse when the input is triggered. Janneman1 refers to figure 9b in the provided link, which is the correct astable or free running oscillator configuration.
Sorry I don`t have replacement schematics to offer. Cat is right - "think about how you shoot and build your system around that". There`s no one design that fits everyone. Frankly, my belief is that a system where delays and such need to be selectable are screaming for a microcontroller like a PIC or AVR. Sure, they might take some time to learn but once you have that out of the way, you`ll be amazed at how flexible your design can be without changing the hardware.
Also, programmers and software don`t have to be expensive or even purchased. Nearly all microcontrollers have simple programmers that can be built and software that can be downloaded, and all the microcontrollers I have looked at have forums like pyrouniverse that are invaluable for getting things working. Don`t just jump in and build something in a rush. Think about what you are trying to do, and spend time learning enough to understand things. Buy some parts. Play around. Figure out what works and what doesn`t. THEN start getting serious about a final design you`ll build for real. I`m sure everyone is glad you provided some feedback. I know very little about circuit design and would not have known there were problems outside the couple of thing I asked about.
Hopefully anytime anyone sees a major flaw in anyone`s design electronics or otherwise they will speak up. If you have time I would really like to understand more about this concern. Adding a resistor would not solve the problem How would one trigger the reset when they hit the end of a partial sequence and wanted to start over Cat, the 555 schematic you pasted in isn`t the right one.
That s
The 4017 decade counter is a versatile component commonly used in various digital circuits for counting applications. However, its proper configuration is critical for reliable operation. The initialization of the 4017 is vital; without ensuring that the reset pins are briefly forced high during power-up, the state of the outputs may become unpredictable. This lack of initialization can lead to erratic behavior in applications that depend on specific output states.
Shorting outputs Q2 through Q9 to the reset pin is a notable design flaw. In a typical application, each output should be independently controlled to ensure proper functioning. When Q2 is driven high, it inadvertently resets the counter, causing it to revert to its initial state, which can disrupt the intended counting sequence. This feedback loop can lead to unintended consequences, especially in designs requiring all outputs to function independently.
The race condition created by tying an output back to the reset pin can result in unreliable circuit operation. The timing of the reset pulse is contingent upon the propagation delay, which is typically not designed to handle such configurations. This can lead to scenarios where the reset does not occur as intended, further complicating the circuit's behavior.
The limitation of the 4017 in driving relays is another significant consideration. While it may appear to function in certain scenarios, relying on the 4017 to drive the positive side of a relay can lead to potential damage or failure of the IC. A dedicated driver circuit or a relay module with appropriate specifications should be employed to ensure reliable operation.
For applications requiring variable timing or complex logic, transitioning to microcontrollers offers a more robust solution. Microcontrollers provide the flexibility to implement various timing sequences, logic operations, and control mechanisms that can be adapted to meet specific project requirements. The availability of simple programming tools and community support makes them an attractive option for both novice and experienced designers.
Overall, careful consideration of circuit design and component selection is essential for achieving desired performance and reliability in electronic systems. Understanding the limitations and capabilities of components like the 4017, along with the advantages of microcontrollers, can significantly enhance the quality of electronic designs.First, the 4017`s aren`t initialized to a known state since the reset pins aren`t briefly forced high when the circuit powers on. The chips might usually power up in the normal reset condition, but that isn`t probably guaranteed by the IC manufacturer.
This is probably only a minor concern. Second, on the IC2 4017, outputs Q2 through Q9 are shorted together and tied to the reset pin. This is a major design flaw. This appears to be an attempt to modify the design of the lower schematic you provide. In that design, there are only 20 outputs used, and when IC2 toggles Q2 high, that high will reset IC2 back to Q0 being high. In your upper schematic, if you are really using all 10 banks of outputs on IC2, none of the outputs need to feed back to the reset pin.
Regardless, only certain types of logic can tolerate outputs being shorted together, and the 4017 isn`t one of them. Third, tying an output pin back to the asynchronous (instantaneous, not on a clock edge) reset pin creates what is called a race condition.
The width of the reset pulse will only be as long as the propogation delay from the reset pin to the output pin driving it. While this might work, there are a lot of circuit designers who wouldn`t do that. This is also probably only a minor concern. I agree with Cat that a 4017 can`t drive the positive side of a relay. Doing so might work for some reason (as the relay clicks in Janneman1`s video seems to prove), but unless you are using extremely sensitive relays that take little current to energize them, you are violating the output drive spec of the 4017.
I don`t know - maybe it works for very short relay pulses, or maybe the chip will put up with this for a while, but this is another major concern. Cat, the 555 schematic you pasted in isn`t the right one. That schematic is the monostable mode that generates one output pulse when the input is triggered. Janneman1 refers to figure 9b in the provided link, which is the correct astable or free running oscillator configuration.
Sorry I don`t have replacement schematics to offer. Cat is right - "think about how you shoot and build your system around that". There`s no one design that fits everyone. Frankly, my belief is that a system where delays and such need to be selectable are screaming for a microcontroller like a PIC or AVR. Sure, they might take some time to learn but once you have that out of the way, you`ll be amazed at how flexible your design can be without changing the hardware.
Also, programmers and software don`t have to be expensive or even purchased. Nearly all microcontrollers have simple programmers that can be built and software that can be downloaded, and all the microcontrollers I have looked at have forums like pyrouniverse that are invaluable for getting things working. Don`t just jump in and build something in a rush. Think about what you are trying to do, and spend time learning enough to understand things. Buy some parts. Play around. Figure out what works and what doesn`t. THEN start getting serious about a final design you`ll build for real. I`m sure everyone is glad you provided some feedback. I know very little about circuit design and would not have known there were problems outside the couple of thing I asked about.
Hopefully anytime anyone sees a major flaw in anyone`s design electronics or otherwise they will speak up. If you have time I would really like to understand more about this concern. Adding a resistor would not solve the problem How would one trigger the reset when they hit the end of a partial sequence and wanted to start over Cat, the 555 schematic you pasted in isn`t the right one.
That s
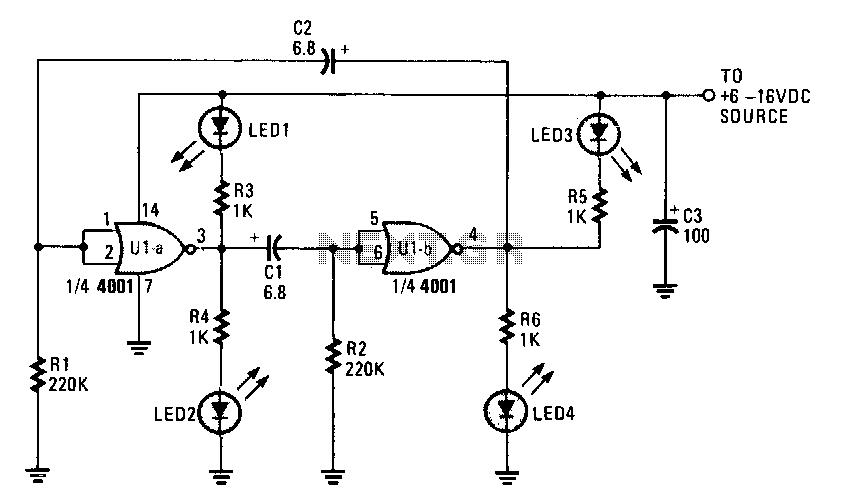
Cmos-flasher
This circuit utilizes a low-cost CMOS integrated circuit (IC) to control four light-emitting diodes (LEDs), turning them on and off at a frequency determined by the resistor values R1 and R2, as well as the capacitor values C1 and C2....
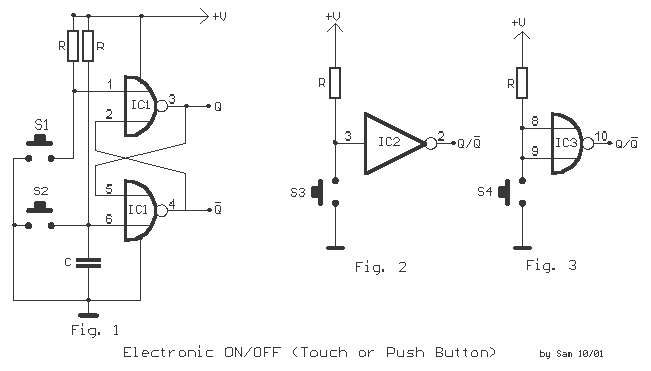
Electronic Switch ON-OFF
Here we have three choices, with which we can make electronic switches that use our touch or pressing (push button). We thus exploit the very big resistance of entry, that present the gates CMOS. In the fig.1 we have two...
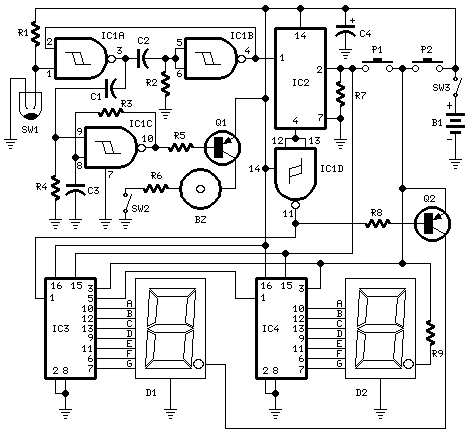
Digital Step-Km Counter
Digital step-kilometer counter with a maximum range of 9,950 meters, displayed using two digits. The device can be conveniently placed in a pants pocket for use during walking and jogging activities. Circuit components include resistors R1 and R3, each rated...
Cmos mixer
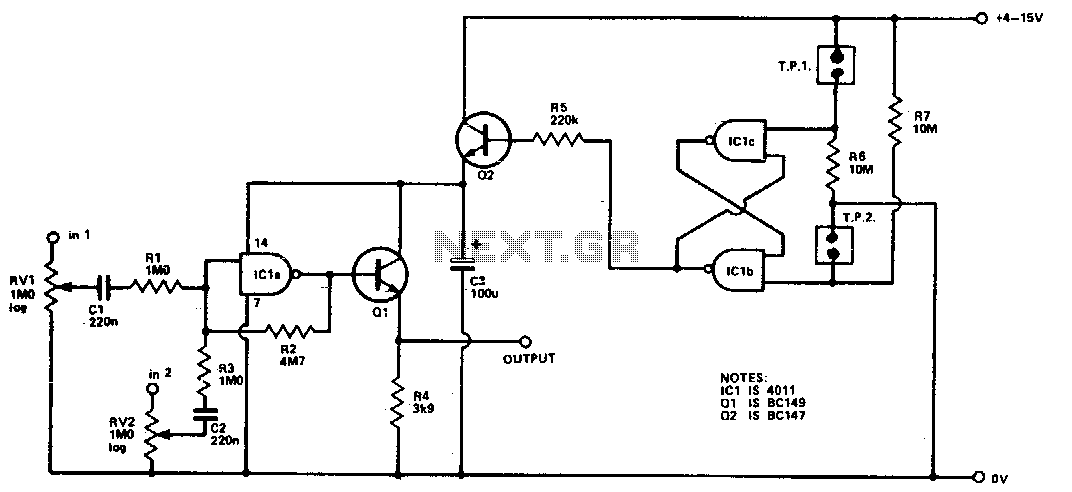
Four inputs can be mixed by duplicating the circuit to the left of C3 and using the fourth gate of ICI. Two gates are used in a touch-operated switching circuit that controls the voltage on the base of switching transistor...
Digital integrated circuits using CMOS circuit Responder
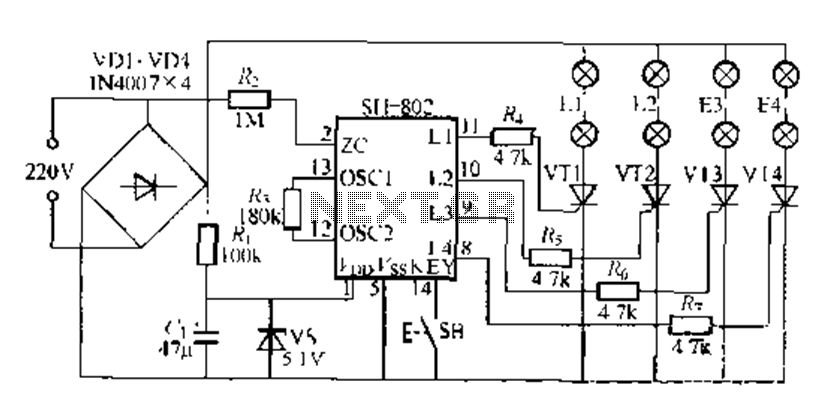
A digital integrated circuit simplifies the response process significantly. The diagram illustrates a circuit comprising four responder groups.
The digital integrated circuit described serves as a crucial component in various electronic systems, primarily focusing on enhancing response efficiency. It comprises four...
4017 based sequencer
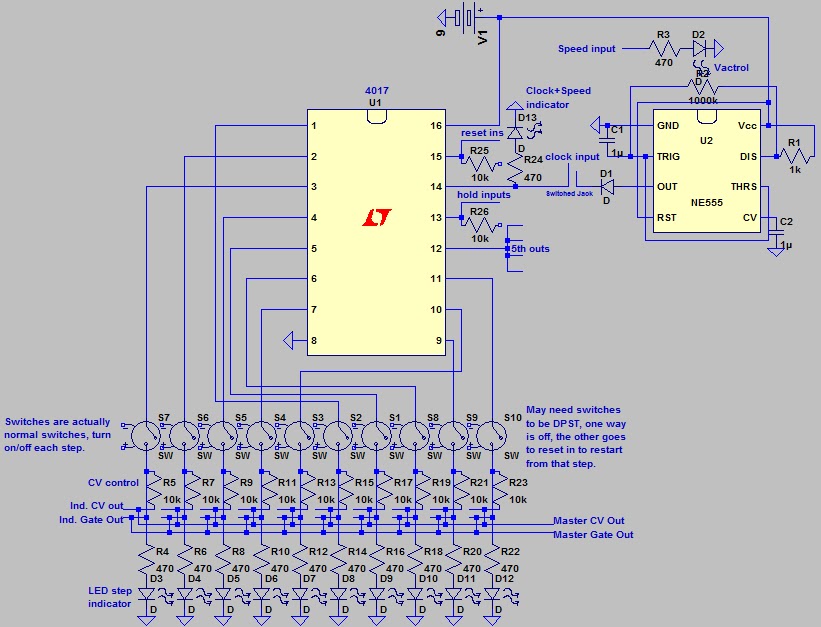
Below is the clock section. The knob controls the speed of the internal oscillator, which can be voltage-controlled via the Speed In input. Alternatively, a user-defined clock signal can be inserted via the Clock In. This feature is somewhat unconventional,...
Winding electronic counter 2
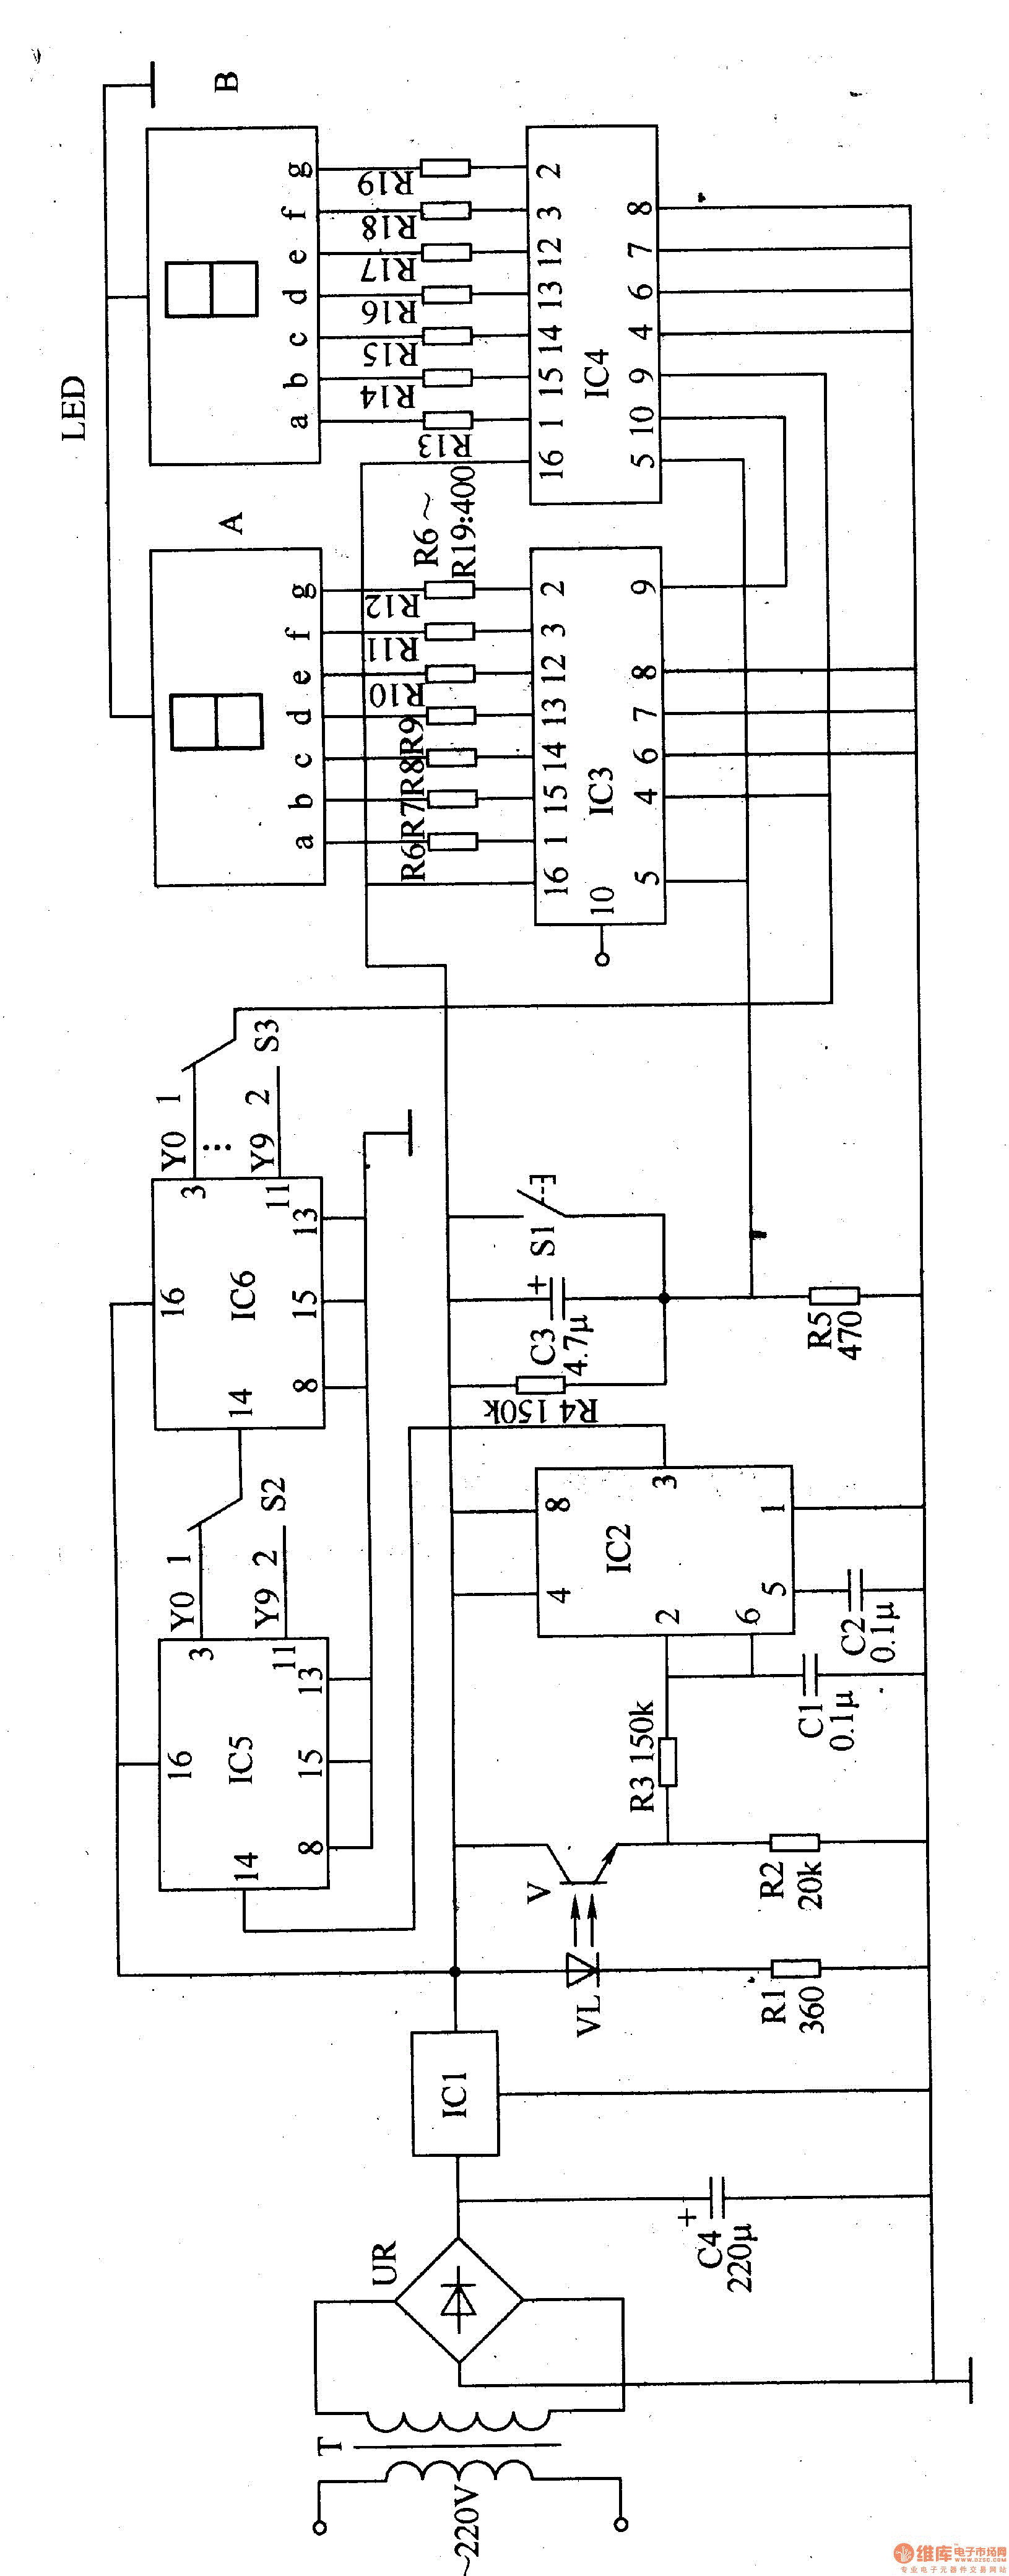
The electronic counter of the winding machine utilizes an LED digital display to indicate the number of turns of the wound coil, with a maximum counting capacity of 9900 turns. The operational principle of the winding machine circuit consists of...
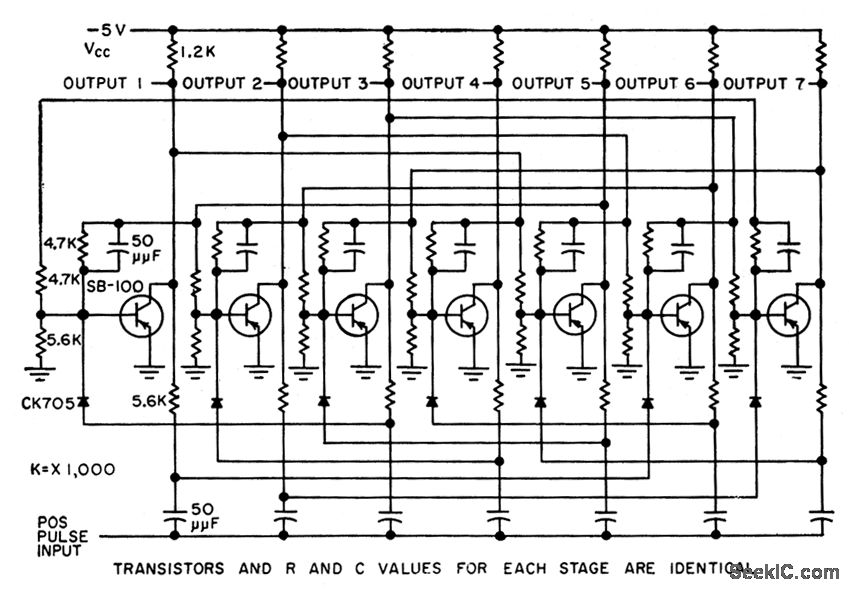
RING OF 7 COUNTER
Uses surface-barrier transistors in an arrangement where a pattern of four on stages is stepped along a ring, allowing the maximum number of stages in the ring to be significantly higher than in conventional rings. -W. Carlson, Ring Counter has...
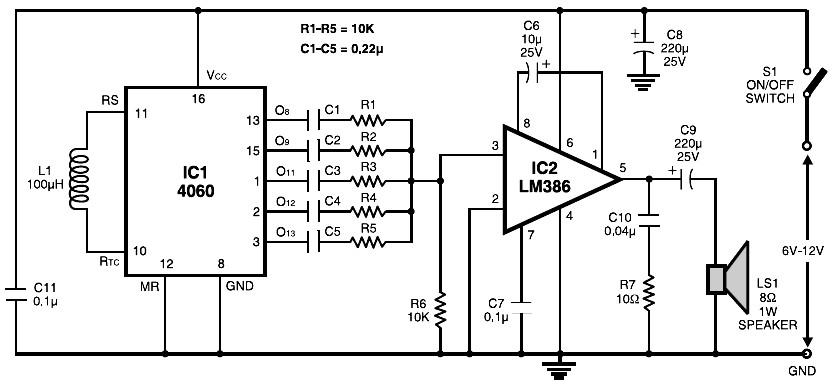
Multitone Siren Alarm circuit diagram
The circuit is built around the popular CMOS oscillator-divider IC 4060 and a small audio amplifier LM386. The IC 4060 functions as a multitone generator. A 100 H inductor is used at the input of the IC 4060, allowing it...