


Boba Fett project movement
#timer
#pulse generation
#I/O pin
#frequency division
#8-bit variable
#signal generation
#period control
#microcontroller
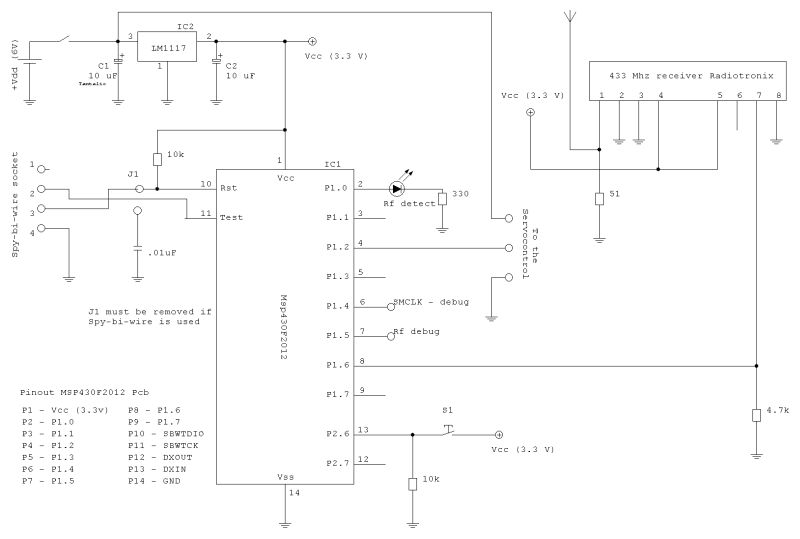
Description: The timer generates a basic period (for instance, 20 ms), and with certain associated variables, it is possible to activate an I/O pin to produce a signal. By utilizing an 8-bit variable, the generated frequency can be divided into "chunks" of 256 (since 8 bits equal 256), allowing for 256 "steps," each measuring 0.078125 ms (20 ms / 256 = 0.078125). The start and end positions are immediately loaded into the duty cycle variable, enabling the servomotor to reach these positions at full speed whenever the S2 pushbutton is pressed. The frequency of the command pulse determines how quickly the servo executes the movement and the strength to maintain its position. The default frequency used is 50 Hz, as it provides the appropriate speed and feedback. The module is designed to accept a frequency rather than a simple on/off signal, meaning a precise frequency must indicate the triggering of the arm or ON condition, while the absence of this frequency signifies the OFF condition. After detecting the wave front, each timer interrupt (illustrated by the timer wave) triggers a reading of the input line, expecting a specific number of high readings and a specific number of low readings. In the absence of signals, the receiver may still capture some noise, which can occasionally match the frequency of the valid signal but only for a short duration.
The described timer circuit is integral for controlling a servomotor's movement with precision. The timer's ability to generate a consistent 20 ms period allows for fine control over the output signal frequency, which is essential for servomotor applications. The division of this period into 256 steps through an 8-bit variable provides a high resolution for position control, enabling the servomotor to respond accurately to user inputs.
The duty cycle variable plays a crucial role in determining the servomotor's position. By preloading the start and end positions, the system can ensure that the motor reaches its target position at maximum speed, enhancing responsiveness. The S2 pushbutton serves as a trigger, initiating the movement sequence, which is critical for applications requiring immediate action.
The choice of a 50 Hz frequency is significant; it strikes a balance between speed and feedback, allowing the servomotor to execute movements smoothly while maintaining stability in its position. The system's design to interpret frequency rather than simple on/off signals adds robustness, as it can differentiate between valid commands and noise. This capability is vital in noisy environments where interference could otherwise lead to erratic behavior.
The implementation of timer interrupts to monitor the input line further enhances the reliability of the system. By expecting a defined number of high and low readings, the circuit can effectively filter out noise, ensuring that only valid signals are acted upon. This approach mitigates the risk of false triggering due to transient disturbances.
Overall, this timer-based control mechanism for servomotors exemplifies a sophisticated approach to electronic design, leveraging precise timing and signal processing to achieve reliable and responsive control in various applications.the timer will generate the basic period (for example 20ms) and with some associated variables will be possible to "fire" an I/O pin to generate the signal. For example, using a 8 bit variable, we can divide the generated frequency in "chunks" of 256 (8 bit = 256), so basically we can have 256 "steps" each one of 0.
078125 ms (20 ms / 256 = 0. 078125). The start and end positions are loaded immediately in the duty cycle variable, so the servomotor can reach the positions at full speed every time the S2 pushbutton is pressed. The frequency of the command pulse determine how fast the servo "execute" the movement and the "strenght" to retain the position.
The default frequency used is 50 Hz because has the right speed and feedback speed. The module is designed to receive a frequency, not a simple on/off signal, so we have to assume a precise frequency as indication of triggering the arm, or ON condition, and the absence of this frequency as OFF condition. After that, knowing the front of the wave was detected, every timer interrupt (the wave below represent the timer) we read the input line and we expect a determined amount of readings high and a determined amount of readings low.
In absence of signals, the receiver picks up anyway some "noise", and this noise can sometime have the same frequency of the valid signal, but for short time.
The described timer circuit is integral for controlling a servomotor's movement with precision. The timer's ability to generate a consistent 20 ms period allows for fine control over the output signal frequency, which is essential for servomotor applications. The division of this period into 256 steps through an 8-bit variable provides a high resolution for position control, enabling the servomotor to respond accurately to user inputs.
The duty cycle variable plays a crucial role in determining the servomotor's position. By preloading the start and end positions, the system can ensure that the motor reaches its target position at maximum speed, enhancing responsiveness. The S2 pushbutton serves as a trigger, initiating the movement sequence, which is critical for applications requiring immediate action.
The choice of a 50 Hz frequency is significant; it strikes a balance between speed and feedback, allowing the servomotor to execute movements smoothly while maintaining stability in its position. The system's design to interpret frequency rather than simple on/off signals adds robustness, as it can differentiate between valid commands and noise. This capability is vital in noisy environments where interference could otherwise lead to erratic behavior.
The implementation of timer interrupts to monitor the input line further enhances the reliability of the system. By expecting a defined number of high and low readings, the circuit can effectively filter out noise, ensuring that only valid signals are acted upon. This approach mitigates the risk of false triggering due to transient disturbances.
Overall, this timer-based control mechanism for servomotors exemplifies a sophisticated approach to electronic design, leveraging precise timing and signal processing to achieve reliable and responsive control in various applications.the timer will generate the basic period (for example 20ms) and with some associated variables will be possible to "fire" an I/O pin to generate the signal. For example, using a 8 bit variable, we can divide the generated frequency in "chunks" of 256 (8 bit = 256), so basically we can have 256 "steps" each one of 0.
078125 ms (20 ms / 256 = 0. 078125). The start and end positions are loaded immediately in the duty cycle variable, so the servomotor can reach the positions at full speed every time the S2 pushbutton is pressed. The frequency of the command pulse determine how fast the servo "execute" the movement and the "strenght" to retain the position.
The default frequency used is 50 Hz because has the right speed and feedback speed. The module is designed to receive a frequency, not a simple on/off signal, so we have to assume a precise frequency as indication of triggering the arm, or ON condition, and the absence of this frequency as OFF condition. After that, knowing the front of the wave was detected, every timer interrupt (the wave below represent the timer) we read the input line and we expect a determined amount of readings high and a determined amount of readings low.
In absence of signals, the receiver picks up anyway some "noise", and this noise can sometime have the same frequency of the valid signal, but for short time.
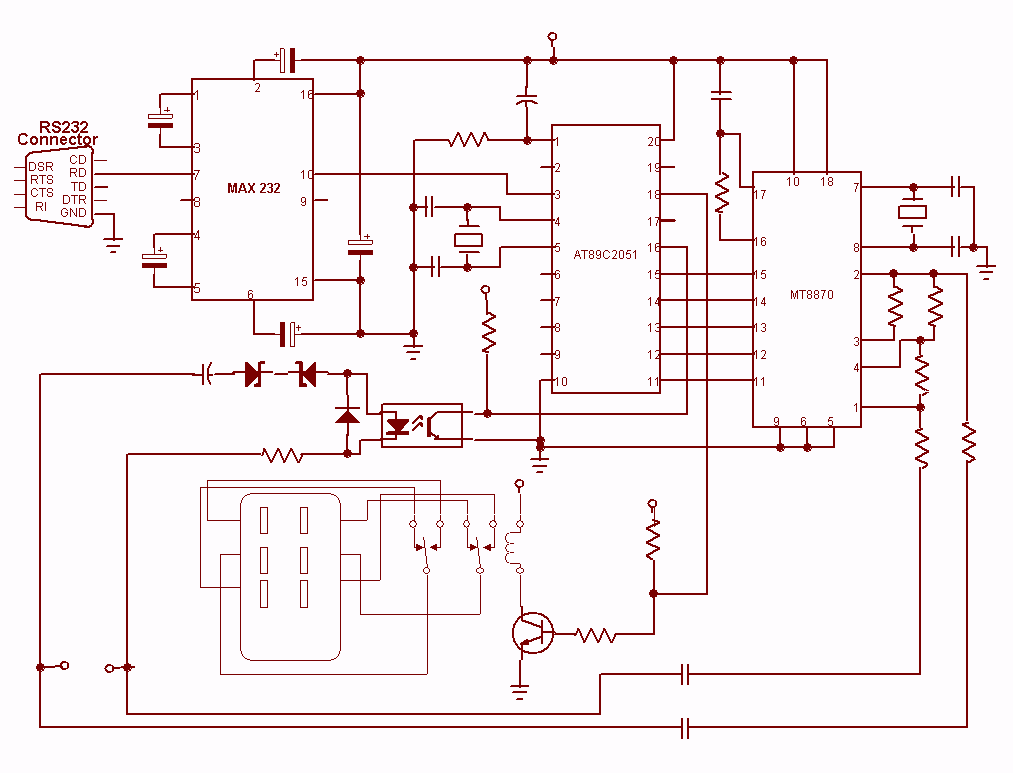
Interactive Voice Response System
Nowadays every institution needs automation. As a part of college automation, a project has been developed for a Voice Interactive System for College Automation. This project allows users to quickly access student attendance and marks through the telephone line without...
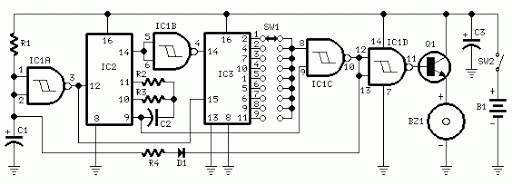
Jogging TimerCircuit
3V battery-powered circuit that emits a beep after a fixed delay of several minutes. This circuit was created in response to requests from users seeking a timer functionality.
The described circuit operates on a 3V power supply, making it suitable for...
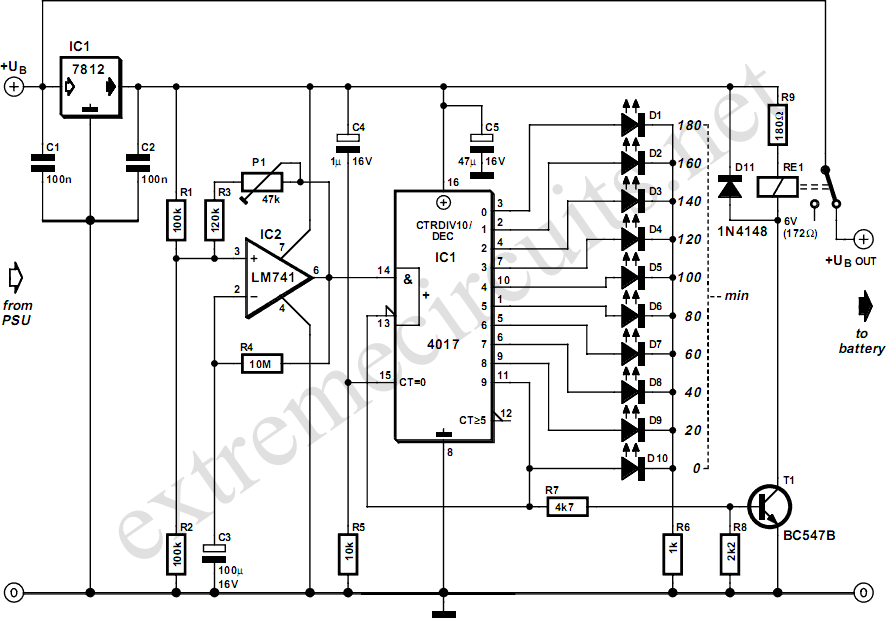
Three Hour Timer
Manufacturers of cordless drills typically recommend a battery charging time of three hours. After this time, the battery should be disconnected from the charger to prevent the risk of overcharging. The following circuit is designed to prevent this scenario by...
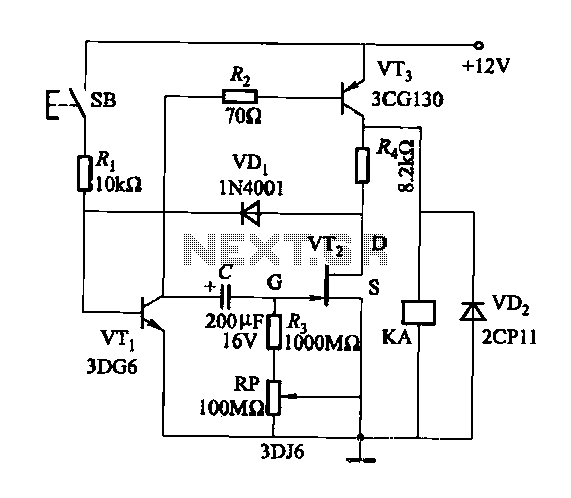
Discharge time relay circuit
Discharge time relay circuit. The timer utilizes a field effect transistor, providing high timing accuracy and extended timing capabilities. With R3 set to 1,000,000 ohms and C at 200 microfarads, a delay time of 8 hours can be achieved. When...
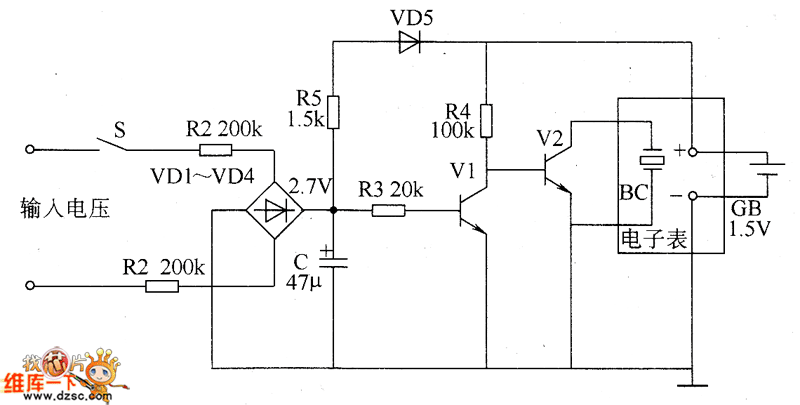
Cumulative timer circuit diagram
The cumulative timer circuit comprises resistor R1 and an internal crystal oscillator, represented in a chart. Resistors R1 and R2 are metal film types, while resistors R3 to R5 are rated at 1/8W and also of the metal film variety....
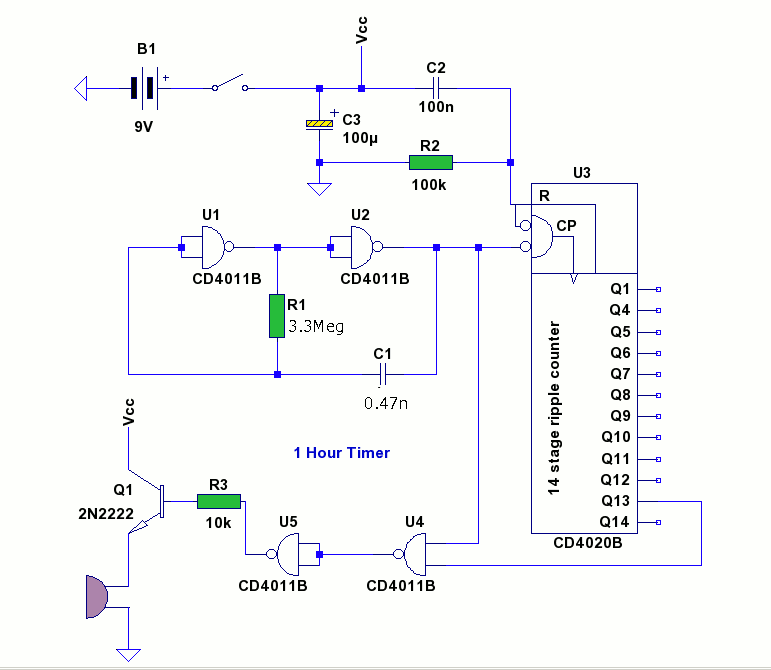
1 Hour Timer
Speaker relay delay controlling circuit for audio amplifier
The speaker relay delay control circuit is designed to protect audio amplifiers and speakers from potential damage caused by inrush current or transient signals during power-up or power-down sequences. This circuit typically employs...
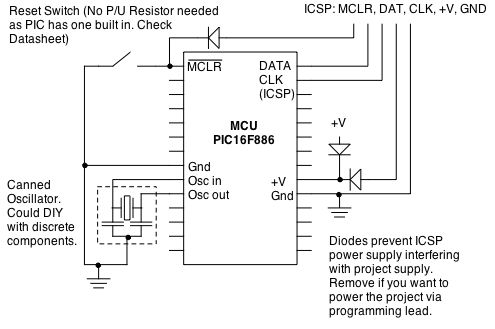
Augmenting a Microcontroller
Microcontrollers (MCUs) are versatile integrated circuits that enhance the functionality of electronics, robotics, and other projects. However, they...
Microcontrollers (MCUs) serve as the central processing unit in a variety of electronic applications, offering programmable control that allows for complex functionalities in...

Microcontroller Programming
This page is a work in progress. The board and source files will soon be available for building and programming to play custom songs. After assembling the board, communication with the programmer was verified, and both the LED and switch...
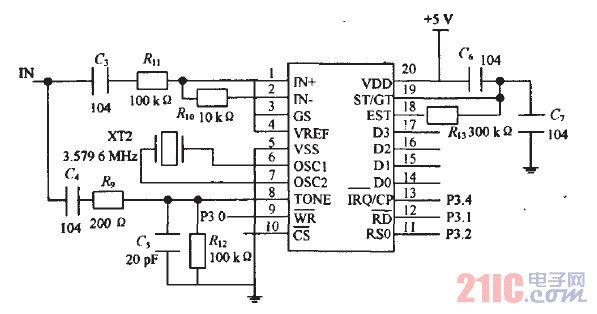
the remote intellectual pronunciation anti-theft alarm system design of the one-chip computer
Precautions must be taken against low safety coefficients, as the applicable space for security measures continues to shrink. With advancements in science and technology, innovations such as magnetic door sensors, touch-type systems, radar monitoring, and infrared detection have emerged, leading...