


servo timer
#servo motor
#timer
#parachute deployment
#water rockets
#RC servo
#delay circuit
#configurable timer
#trigger circuit
#automation
#mechanical latch

Description: The Servo Timer II was primarily designed for parachute deployment on water rockets but can be used for other applications. The timer controls a single RC servo motor that can open a latch on a parachute door. Once triggered, the timer waits a set amount of time before moving the servo motor. The timer has a number of configurable parameters along with several trigger options. It may also be used in other applications such as staging rockets, controlling camera direction, etc. A big thank you goes to PK from Whooshtronics for his great support on this project. Also, thank you to everyone who helped with ideas and suggestions on Australian Rocketry’s forum. The Servo Timer II development has been covered on these forum threads and also on the Yahoo water rocket forum. A thank you goes to the water rocket community who have supported over the years and given feedback on the previous versions of this timer. Suggestions have been incorporated into this design. Updated: 26th May 2013 - Sorry, but there are no more Servo Timer IIs left for sale, as they have all sold out. Thank you to everyone who has purchased the timer. Support will continue for the timers. If there are any questions or comments, please contact. Those interested in building their own can request the STII PCB layout (in Eagle .brd format) and HEX files for free. All SMD components can be substituted with through-hole components to facilitate building on a prototyping board. (Sorry, there is no through-hole PCB layout.) Built-in G-switch: The built-in G-switch detects a launch when the timer experiences acceleration of over 2G. Depending on the application, such as when triggering occurs at burnout or apogee, or where the board cannot be oriented vertically, the built-in G-switch trigger option can be disabled. Break wire: A pair of contacts is available on the input connector to connect a loop of wire. Depending on the configuration, either a break in the loop will trigger the timer, or connecting the loop will trigger it. This allows the timer to be triggered by simple mechanical contacts or switches whose contacts are normally open or closed. External higher acceleration G-switches can also be directly connected to this input. Pressure switches used for detecting burnout may also be connected. External 3-12V input signal: This input is routed through an opto-coupler isolating the timer from the triggering circuitry. This allows other circuits and flight computers operating on different power supplies to trigger the timer directly without additional circuitry. This input can usually be connected directly to a pyro output of a flight computer or altimeter. Launch detect: This is typically achieved using a G or acceleration switch. Triggering occurs as soon as the rocket leaves the launch pad. Another variation is a set of contacts that are closed, and an insulator is removed from between them during launch. The insulator is usually attached to the launcher. Burnout detect: This technique can use a pressure switch to detect when the pressure inside the rocket has reached atmospheric pressure or some preset value. This is useful for staging rockets. This allows the rocket to deploy the second stage at the correct time, regardless of how much pressure or water was used in the booster. Negative G detect: This technique detects when the rocket has stopped producing thrust and starts to slow down. An inverted mercury switch can be used here, where the mercury floats upwards to make contact as drag continues to slow the rocket down after burnout. Negative Gs happen shortly after burnout. In normal operation, when the timer is first turned ON, the servo motor moves to the start position. When the timer expires, the servo motor moves to the end position. Due to the large variety of RC servo motors available, the system can accommodate diverse applications.
The Servo Timer II is an innovative electronic timing solution specifically designed for applications requiring precise control of servo motors, particularly in the context of water rockets. The core functionality revolves around the timer's ability to manage the deployment of a parachute through a single RC servo motor, which releases a latch mechanism. The timer is equipped with a configurable delay feature that allows users to set a specific time interval before the servo motor is activated, ensuring that parachute deployment occurs at the optimal moment.
The system supports multiple triggering mechanisms, enhancing its versatility beyond parachute deployment. It can be employed in staging rockets, where precise timing is crucial for the successful separation of rocket stages, as well as in controlling camera angles for aerial photography. The inclusion of a built-in G-switch allows for automatic launch detection by sensing accelerative forces greater than 2G, providing a reliable method for initiating the timer as the rocket takes off.
The device features a break wire mechanism for triggering, which can be configured to respond to either the breaking of a wire loop or the closing of a circuit. This adaptability allows integration with various mechanical switches and external G-switches, extending the timer's application range. Furthermore, the system can accommodate external pressure switches to detect burnout, ensuring accurate stage separation regardless of the rocket's internal pressure conditions.
For enhanced connectivity, the Servo Timer II includes an external input signal feature, which utilizes an opto-coupler to isolate the timer from other circuits. This design element allows for seamless integration with flight computers or altimeters, enabling direct triggering from different power supplies without additional circuitry complications.
The timer's operational sequence is straightforward: upon activation, the servo motor moves to a predetermined start position. Once the timer countdown concludes, the servo transitions to the end position, executing the desired function, such as opening the parachute latch. This mechanism is designed to work with a wide variety of RC servo motors, ensuring compatibility with numerous setups and applications.
Overall, the Servo Timer II represents a significant advancement in timing technology for rocketry and related fields, combining flexibility, reliability, and ease of use in a compact design.The Servo Timer II was primarily designed for parachute deployment on water rockets, but can be used for other applications. The timer controls a single RC servo motor that can open a latch on a parachute door. Once triggered the timer waits a set amount of time before moving the servo motor. The timer has a number of configurable parameters along with several trigger options. It may also be used in other applications such as staging rockets, controlling camera direction etc. A big thank you goes to PK from Whooshtronics for his great support on this project. Also thank you to everyone who helped with ideas and suggestions on Australian Rocketry`s forum. The Servo Timer II development has been covered on these forum threads: and and also on the Yahoo water rocket forum here: Also a thank you goes to the water rocket community who have supported us over the years and given us feedback on the previous versions of this timer. We have taken your suggestions and incorporated them into this design. Updated: 26th May 2013 - Sorry but there are no more Servo Timer IIs left for sale, as they have all sold out.
Thank you to everyone who has purchased the timer. We will continue to provide support for the timers. If you have any questions or comments please contact us. If you would like to build your own, the STII PCB layout (in Eagle. brd format) and. HEX files are now available for FREE on request. All the SMD components can be substituted with through-hole components to make it easier to build on a prototyping board. (Sorry we don`t have a through-hole PCB layout) Built in G-switch: The built in G-switch will detect a launch when the timer experiences acceleration of over 2G.
Depending on the application, such as when triggering occurs at burnout or apogee, or where the board cannot be oriented vertically, the built in G-switch trigger option can be disabled. Break wire: A pair of contacts is available on the input connector to connect a loop of wire. Depending on the configuration, either a break in the loop will trigger the timer, or connecting the loop will trigger it.
This allows the timer to be triggered by simple mechanical contacts or switches whose contacts are normally open or closed. External higher acceleration G-switches can also be directly connected to this input. Pressure switches used for detecting burnout may also be connected. External 3-12V input signal: This input is routed through an opto-coupler isolating the timer from the triggering circuitry.
This allows other circuits and flight computers operating on different power supplies to trigger the timer directly without additional circuitry. This input can usually be connected directly to a pyro output of a flight computer or altimeter. Launch detect This is typically achieved using a G or acceleration switch. Triggering occurs as soon as the rocket leaves the launch pad. Another variation to this is a set of contacts that are closed and an insulator is removed from between them during launch.
The insulator is usually attached to the launcher. Burnout detect - This technique can use a pressure switch to detect when the pressure inside the rocket has reached atmospheric pressure, or some preset value. This is useful for staging rockets. This allows the rocket to deploy the second stage at the correct time regardless of how much pressure or water was used in the booster.
Negative G detect This is another technique used to detect when the rocket has stopped producing thrust and the rocket starts to slow down. An inverted mercury switch can be used here where the mercury floats upwards to make contact as drag continues to slow the rocket down after burnout.
Negative Gs happen shortly after burnout. In normal operation when the timer is first turned ON the servo motor moves to the start position. When the timer expires, the servo motor moves to the end position. Due to the large variety of RC servo motors av
The Servo Timer II is an innovative electronic timing solution specifically designed for applications requiring precise control of servo motors, particularly in the context of water rockets. The core functionality revolves around the timer's ability to manage the deployment of a parachute through a single RC servo motor, which releases a latch mechanism. The timer is equipped with a configurable delay feature that allows users to set a specific time interval before the servo motor is activated, ensuring that parachute deployment occurs at the optimal moment.
The system supports multiple triggering mechanisms, enhancing its versatility beyond parachute deployment. It can be employed in staging rockets, where precise timing is crucial for the successful separation of rocket stages, as well as in controlling camera angles for aerial photography. The inclusion of a built-in G-switch allows for automatic launch detection by sensing accelerative forces greater than 2G, providing a reliable method for initiating the timer as the rocket takes off.
The device features a break wire mechanism for triggering, which can be configured to respond to either the breaking of a wire loop or the closing of a circuit. This adaptability allows integration with various mechanical switches and external G-switches, extending the timer's application range. Furthermore, the system can accommodate external pressure switches to detect burnout, ensuring accurate stage separation regardless of the rocket's internal pressure conditions.
For enhanced connectivity, the Servo Timer II includes an external input signal feature, which utilizes an opto-coupler to isolate the timer from other circuits. This design element allows for seamless integration with flight computers or altimeters, enabling direct triggering from different power supplies without additional circuitry complications.
The timer's operational sequence is straightforward: upon activation, the servo motor moves to a predetermined start position. Once the timer countdown concludes, the servo transitions to the end position, executing the desired function, such as opening the parachute latch. This mechanism is designed to work with a wide variety of RC servo motors, ensuring compatibility with numerous setups and applications.
Overall, the Servo Timer II represents a significant advancement in timing technology for rocketry and related fields, combining flexibility, reliability, and ease of use in a compact design.The Servo Timer II was primarily designed for parachute deployment on water rockets, but can be used for other applications. The timer controls a single RC servo motor that can open a latch on a parachute door. Once triggered the timer waits a set amount of time before moving the servo motor. The timer has a number of configurable parameters along with several trigger options. It may also be used in other applications such as staging rockets, controlling camera direction etc. A big thank you goes to PK from Whooshtronics for his great support on this project. Also thank you to everyone who helped with ideas and suggestions on Australian Rocketry`s forum. The Servo Timer II development has been covered on these forum threads: and and also on the Yahoo water rocket forum here: Also a thank you goes to the water rocket community who have supported us over the years and given us feedback on the previous versions of this timer. We have taken your suggestions and incorporated them into this design. Updated: 26th May 2013 - Sorry but there are no more Servo Timer IIs left for sale, as they have all sold out.
Thank you to everyone who has purchased the timer. We will continue to provide support for the timers. If you have any questions or comments please contact us. If you would like to build your own, the STII PCB layout (in Eagle. brd format) and. HEX files are now available for FREE on request. All the SMD components can be substituted with through-hole components to make it easier to build on a prototyping board. (Sorry we don`t have a through-hole PCB layout) Built in G-switch: The built in G-switch will detect a launch when the timer experiences acceleration of over 2G.
Depending on the application, such as when triggering occurs at burnout or apogee, or where the board cannot be oriented vertically, the built in G-switch trigger option can be disabled. Break wire: A pair of contacts is available on the input connector to connect a loop of wire. Depending on the configuration, either a break in the loop will trigger the timer, or connecting the loop will trigger it.
This allows the timer to be triggered by simple mechanical contacts or switches whose contacts are normally open or closed. External higher acceleration G-switches can also be directly connected to this input. Pressure switches used for detecting burnout may also be connected. External 3-12V input signal: This input is routed through an opto-coupler isolating the timer from the triggering circuitry.
This allows other circuits and flight computers operating on different power supplies to trigger the timer directly without additional circuitry. This input can usually be connected directly to a pyro output of a flight computer or altimeter. Launch detect This is typically achieved using a G or acceleration switch. Triggering occurs as soon as the rocket leaves the launch pad. Another variation to this is a set of contacts that are closed and an insulator is removed from between them during launch.
The insulator is usually attached to the launcher. Burnout detect - This technique can use a pressure switch to detect when the pressure inside the rocket has reached atmospheric pressure, or some preset value. This is useful for staging rockets. This allows the rocket to deploy the second stage at the correct time regardless of how much pressure or water was used in the booster.
Negative G detect This is another technique used to detect when the rocket has stopped producing thrust and the rocket starts to slow down. An inverted mercury switch can be used here where the mercury floats upwards to make contact as drag continues to slow the rocket down after burnout.
Negative Gs happen shortly after burnout. In normal operation when the timer is first turned ON the servo motor moves to the start position. When the timer expires, the servo motor moves to the end position. Due to the large variety of RC servo motors av
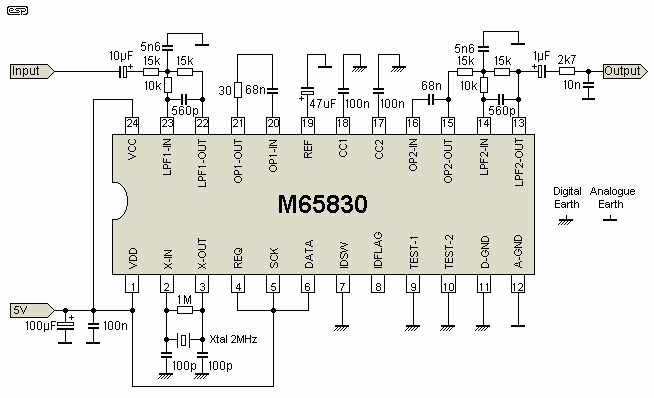
The Delay
The delay circuit utilizes the Mitsubishi M65830 Digital Delay chip, as illustrated in Figure 1. This chip has been in use for some time and is known for its simplicity and effectiveness, particularly when a fixed delay is sufficient. However,...
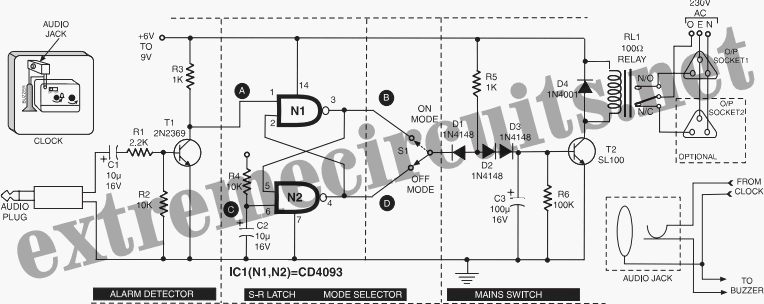
Time Switch
This circuit is specifically designed for individuals who frequently need to wake up early in the morning. Standard alarms in electronic watches are often insufficiently loud.
The circuit utilizes a high-decibel audio output mechanism to ensure that the alarm is audible...

Counters and Timer Circuits
AN79 Linear Technology AN79 modifies methods presented in AN74, allowing for the verification of 30 nanosecond amplifier settling times with 0.1% resolution. The sampling-based technique used is detailed, and results are presented. Appendices cover oscilloscope overdrive issues, the construction of...
Circuit digital Clock Timer
The following circuit illustrates a Cat and Dog Repellent Timer Circuit Diagram. Features include the capability to maintain a deep cycle battery charged by a solar panel.
The Cat and Dog Repellent Timer Circuit is designed to provide a humane method...
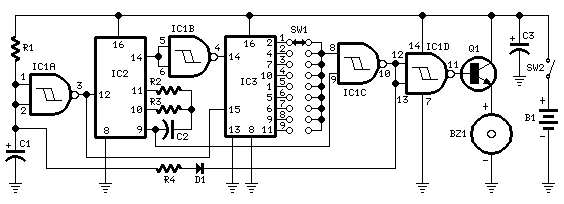
Jogging Timer
This circuit was developed in response to requests from visitors for a timer that can emit a beep after intervals of one, two, three minutes, and so forth, suitable for jogging purposes. As illustrated in the circuit diagram, SW1 is...
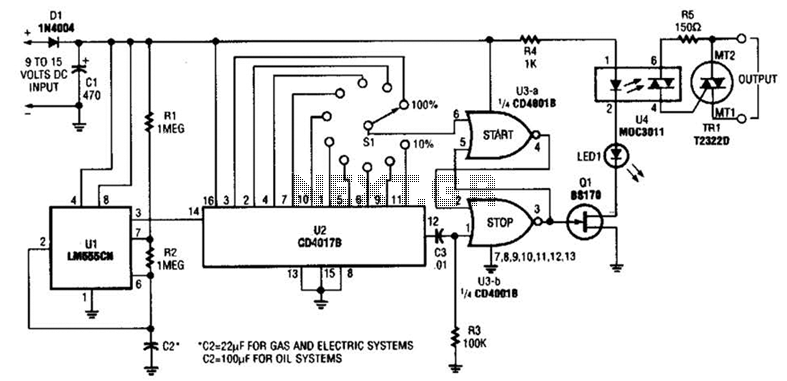
Furnace Fuel Miser Circuit
A timer (LM555CN) and decode counter are utilized to generate duty cycles ranging from 10% to 100% for controlling the operational time of a heating system. V2 operates as a decode counter that can be adjusted for duty cycles between...
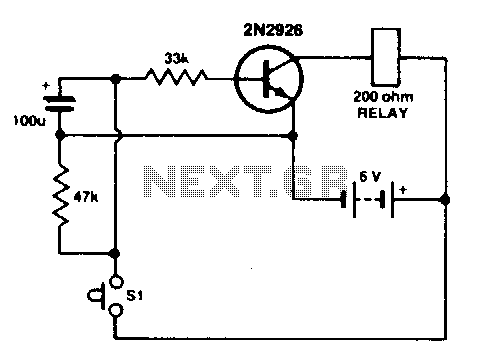
Simple timer
Press SI. The 100 µF electrolytic capacitor rapidly charges up from approximately 0 V. The transistor becomes forward biased, allowing collector current to flow and operate the relay. When SI is released, the capacitor discharges through the 33 K resistor...
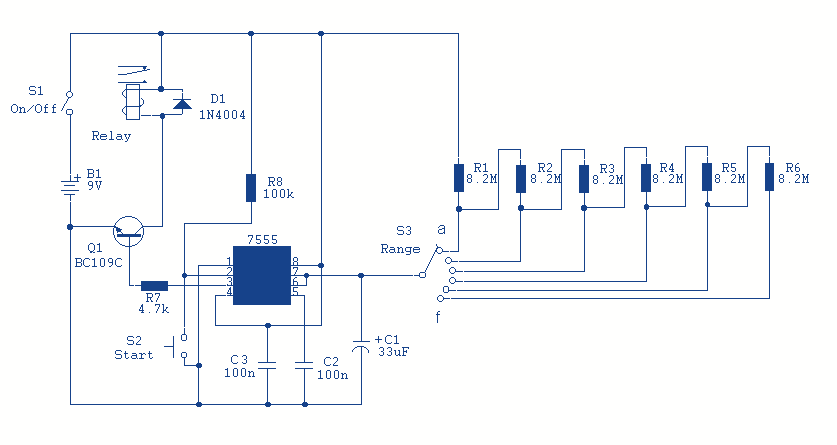
5 to 30 Minute Timer
A switched timer for intervals of 5 to 30 minutes incremented in 5 minute steps. Simple to build, simple to make, nothing too complicated here. However, you must use the CMOS type 555 timer designated the 7555; a normal 555...
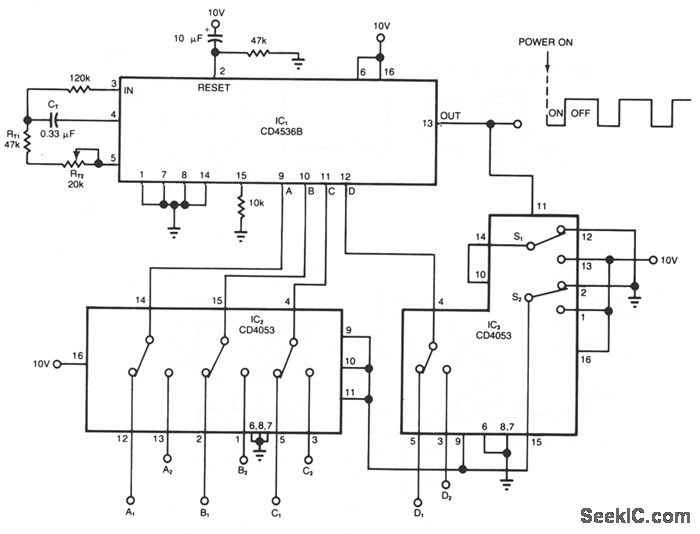
SEQUENTIAL TIMER
The timer circuit provides independent control of the output's on and off intervals, which can range from 0.055 seconds to 30 minutes, with minimal impact from power-line transients. IC1 is a CMOS programmable timer chip that features 24 ripple-binary counter...