


Cipher scheme on the basis of the ultrasonic ranger of AT89C52
#AT89C52
#ultrasonic
#range finding
#measurement
#distance sensor
#microcontroller
#industrial
#medical
#automotive
#flaw detection
Description: The technology of range finding is extensively employed in civil and industrial fields, such as measurement, medical flaw detection, and car anti-collision systems, due to the relatively lower speed of ultrasonic waves compared to the speed of light. This characteristic makes the flight time easier to measure, facilitates directional transmission, and provides good directivity. Additionally, the emission intensity can be easily controlled, and the method is free from electromagnetic interference. However, the propagation velocity of ultrasonic waves varies with ambient temperature, and neglecting this temperature effect can influence the accuracy of measurements. The ultrasonic ranger described in this text utilizes a transition time detection method and incorporates a DS18B20 temperature sensor to measure the ambient temperature on-site. This data is used to calculate and implement temperature compensation for wave speed through software, thereby reducing measurement errors. Four factors limit the maximum measurable distance of this system: ultrasonic range, reflected texture, sensitivity of the angle of incidence and reflection, and the echo microphone's capability. The echo microphone determines the minimum measurable distance based on its pulsing direct receiving capability. To enhance measurement accuracy, multiple ultrasonic transducers can be employed to transmit ultrasonic waves in separate channels. The speed of ultrasonic waves is temperature-dependent, and measuring the relationship between ultrasonic wave speed and temperature allows for more accurate distance calculations. During range finding, the speed of sound is confirmed using the ambient temperature detected by the temperature sensor. By measuring the time taken for the ultrasonic wave to travel and return, the distance can be calculated accurately. The operating principle of the ranger involves a microcontroller sending a driving signal, activating a timer, and recording the time until the first echo is received. Given the known speed of sound in air, the distance to the target can be determined using a specific formula. Additionally, multiple ultrasonic measurements can be taken in quick succession to calculate an average value. The propagation velocity of ultrasonic waves remains constant in the same medium under identical atmospheric conditions, meaning that the speed of sound does not vary with frequency within a significant range. However, higher frequencies experience greater attenuation and shorter travel distances. For practical engineering applications, the ultrasonic ranger is designed to operate at a frequency of 40 kHz, with a corresponding wavelength of 0.85 cm.
The ultrasonic range-finding system operates on the principle of measuring the time delay between the emission of an ultrasonic pulse and the reception of its echo. This time delay is directly related to the distance between the ultrasonic transducer and the target object. The system's accuracy is enhanced by implementing a temperature compensation algorithm that adjusts the calculated distance based on the ambient temperature, which affects the speed of sound in air. The DS18B20 temperature sensor is integrated into the system to provide real-time temperature readings, allowing for dynamic adjustments during operation.
In terms of hardware architecture, the system consists of a microcontroller unit (MCU), which manages the overall operation, including pulse generation, timing, and data processing. The ultrasonic transducer emits a high-frequency sound wave, which travels through the air until it encounters an object, reflecting back to the transducer. The MCU measures the time taken for the echo to return and, using the known speed of sound (adjusted for temperature), calculates the distance to the object.
The design also incorporates an echo microphone, which is sensitive to the incoming reflected waves. The configuration of the microphone and transducer must be optimized to ensure maximum sensitivity and minimal interference from ambient noise. The system can be calibrated for various reflective surfaces, ensuring reliable operation in diverse environments.
To further enhance measurement reliability, the system can employ multiple transducers arranged in an array, allowing for simultaneous measurements from different angles. This multi-channel approach can mitigate the effects of obstructions and improve the overall accuracy of the range-finding process.
In conclusion, the ultrasonic range-finding technology described is a versatile and effective method for distance measurement in various applications, leveraging temperature compensation and advanced signal processing techniques to achieve high accuracy and reliability.The technology of range finding employs extensively in civil, industrial fields such as measuring, medical flaw detection, car anticollision of position of the material, etc. , because the ultrasonic speed wants to the velocity of light it is much smaller, its flight time is easier to measure, and easy directional transmission, directivity is good,
the emission intensity is easy to control, and is free of electromagnetic disturbance, therefore utilize ultrasonic range finding to be a valid non-contact type range finding method. But the propagation velocity under different ambient temperature of supersonic wave is different, such as neglecting temperature effect, will influence final survey accuracy.
The ultrasonic ranger that this text introduces adopts the detecting method of transition time, has used DS1 8B20 temperature sensor to gauge on-the-spot temperature, and calculate and realize the temperature compensation of the wave speed through the software and dispel the impact on measuring result of the temperature, make the error in emasurement reduce. 4 factors that the measurable distance of maximum of limiting this system exists: Ultrasonic range, reflected texture, reflecting and incidenting the degree of sensitivity of included angle and echo microphone among the acoustic wave.
The echo microphone determines the minimum measurable distance about the pulsing direct receiving capability of the acoustic wave. It is metric coverage for increasing, be lasted error in emasurement, it can if you can`t adopt, launch supersonic waves multi-channel separately a plurality of ultrasonic transducer /design method that be received.
It is an acoustic wave range because of supersonic wave, its wave speed c is temperature-dependent, through measuring the relation of obtaining ultrasonic wave speed and temperature, as shown in Table 1. During range finding, can after wave speed c. wave speed confirm their, through the automatic detection ambient temperature of the temperature sensor, confirm, so long as measure time t with round supersonic wave, can try to get the distance H, can obtain this environment and make the journey that supersonic wave passes more accurately in this way, have improved the accuracy of measurements.
Use the detecting method of transition time in this cipher scheme, the operating principle of the ranger is: While the one-chip computer sends out the driving signal, turn on the time-recorder in the one-chip computer, begin to time. Visit supersonic wave of penetrating of the hair in transmission, when being stopped the idea of the time-recorder of the one-chip computer when receive the probe to receive the first back wave, because the speed of supersonic wave in the air has already known, can try to get the probe and distance to be examined between the goals according to the formula.
Moreover, can send out ultrasonic measurement many times within relatively short time and finish, calculate then reveals for mean value. Supersonic wave is in the identical spread media Atmospheric condition The propagation velocity is the same, namely the velocity of sound does not vary with frequency within the range of significant frequency, but the higher its frequency is, the more terribly decay, the shorter the travelling distance is.
Consider actual engineering survey requires, while designing the ultrasonic ranger, choose the frequency f =The supersonic wave of 40kHz, the wavelength is 0. 85cm. The technology of range finding employs extensively in civil, industrial fields such as measuring, medical flaw detection, car anticollision of position of the material, etc.
, because the ultrasonic speed wants to the velocity of light it is much smaller, its flight time is easier to measure, and easy directional transmission, directivity is good, the emission intensity is easy to control, and is free of electromagnetic disturbance, therefore utilize ultrasonic range finding t
The ultrasonic range-finding system operates on the principle of measuring the time delay between the emission of an ultrasonic pulse and the reception of its echo. This time delay is directly related to the distance between the ultrasonic transducer and the target object. The system's accuracy is enhanced by implementing a temperature compensation algorithm that adjusts the calculated distance based on the ambient temperature, which affects the speed of sound in air. The DS18B20 temperature sensor is integrated into the system to provide real-time temperature readings, allowing for dynamic adjustments during operation.
In terms of hardware architecture, the system consists of a microcontroller unit (MCU), which manages the overall operation, including pulse generation, timing, and data processing. The ultrasonic transducer emits a high-frequency sound wave, which travels through the air until it encounters an object, reflecting back to the transducer. The MCU measures the time taken for the echo to return and, using the known speed of sound (adjusted for temperature), calculates the distance to the object.
The design also incorporates an echo microphone, which is sensitive to the incoming reflected waves. The configuration of the microphone and transducer must be optimized to ensure maximum sensitivity and minimal interference from ambient noise. The system can be calibrated for various reflective surfaces, ensuring reliable operation in diverse environments.
To further enhance measurement reliability, the system can employ multiple transducers arranged in an array, allowing for simultaneous measurements from different angles. This multi-channel approach can mitigate the effects of obstructions and improve the overall accuracy of the range-finding process.
In conclusion, the ultrasonic range-finding technology described is a versatile and effective method for distance measurement in various applications, leveraging temperature compensation and advanced signal processing techniques to achieve high accuracy and reliability.The technology of range finding employs extensively in civil, industrial fields such as measuring, medical flaw detection, car anticollision of position of the material, etc. , because the ultrasonic speed wants to the velocity of light it is much smaller, its flight time is easier to measure, and easy directional transmission, directivity is good,
the emission intensity is easy to control, and is free of electromagnetic disturbance, therefore utilize ultrasonic range finding to be a valid non-contact type range finding method. But the propagation velocity under different ambient temperature of supersonic wave is different, such as neglecting temperature effect, will influence final survey accuracy.
The ultrasonic ranger that this text introduces adopts the detecting method of transition time, has used DS1 8B20 temperature sensor to gauge on-the-spot temperature, and calculate and realize the temperature compensation of the wave speed through the software and dispel the impact on measuring result of the temperature, make the error in emasurement reduce. 4 factors that the measurable distance of maximum of limiting this system exists: Ultrasonic range, reflected texture, reflecting and incidenting the degree of sensitivity of included angle and echo microphone among the acoustic wave.
The echo microphone determines the minimum measurable distance about the pulsing direct receiving capability of the acoustic wave. It is metric coverage for increasing, be lasted error in emasurement, it can if you can`t adopt, launch supersonic waves multi-channel separately a plurality of ultrasonic transducer /design method that be received.
It is an acoustic wave range because of supersonic wave, its wave speed c is temperature-dependent, through measuring the relation of obtaining ultrasonic wave speed and temperature, as shown in Table 1. During range finding, can after wave speed c. wave speed confirm their, through the automatic detection ambient temperature of the temperature sensor, confirm, so long as measure time t with round supersonic wave, can try to get the distance H, can obtain this environment and make the journey that supersonic wave passes more accurately in this way, have improved the accuracy of measurements.
Use the detecting method of transition time in this cipher scheme, the operating principle of the ranger is: While the one-chip computer sends out the driving signal, turn on the time-recorder in the one-chip computer, begin to time. Visit supersonic wave of penetrating of the hair in transmission, when being stopped the idea of the time-recorder of the one-chip computer when receive the probe to receive the first back wave, because the speed of supersonic wave in the air has already known, can try to get the probe and distance to be examined between the goals according to the formula.
Moreover, can send out ultrasonic measurement many times within relatively short time and finish, calculate then reveals for mean value. Supersonic wave is in the identical spread media Atmospheric condition The propagation velocity is the same, namely the velocity of sound does not vary with frequency within the range of significant frequency, but the higher its frequency is, the more terribly decay, the shorter the travelling distance is.
Consider actual engineering survey requires, while designing the ultrasonic ranger, choose the frequency f =The supersonic wave of 40kHz, the wavelength is 0. 85cm. The technology of range finding employs extensively in civil, industrial fields such as measuring, medical flaw detection, car anticollision of position of the material, etc.
, because the ultrasonic speed wants to the velocity of light it is much smaller, its flight time is easier to measure, and easy directional transmission, directivity is good, the emission intensity is easy to control, and is free of electromagnetic disturbance, therefore utilize ultrasonic range finding t
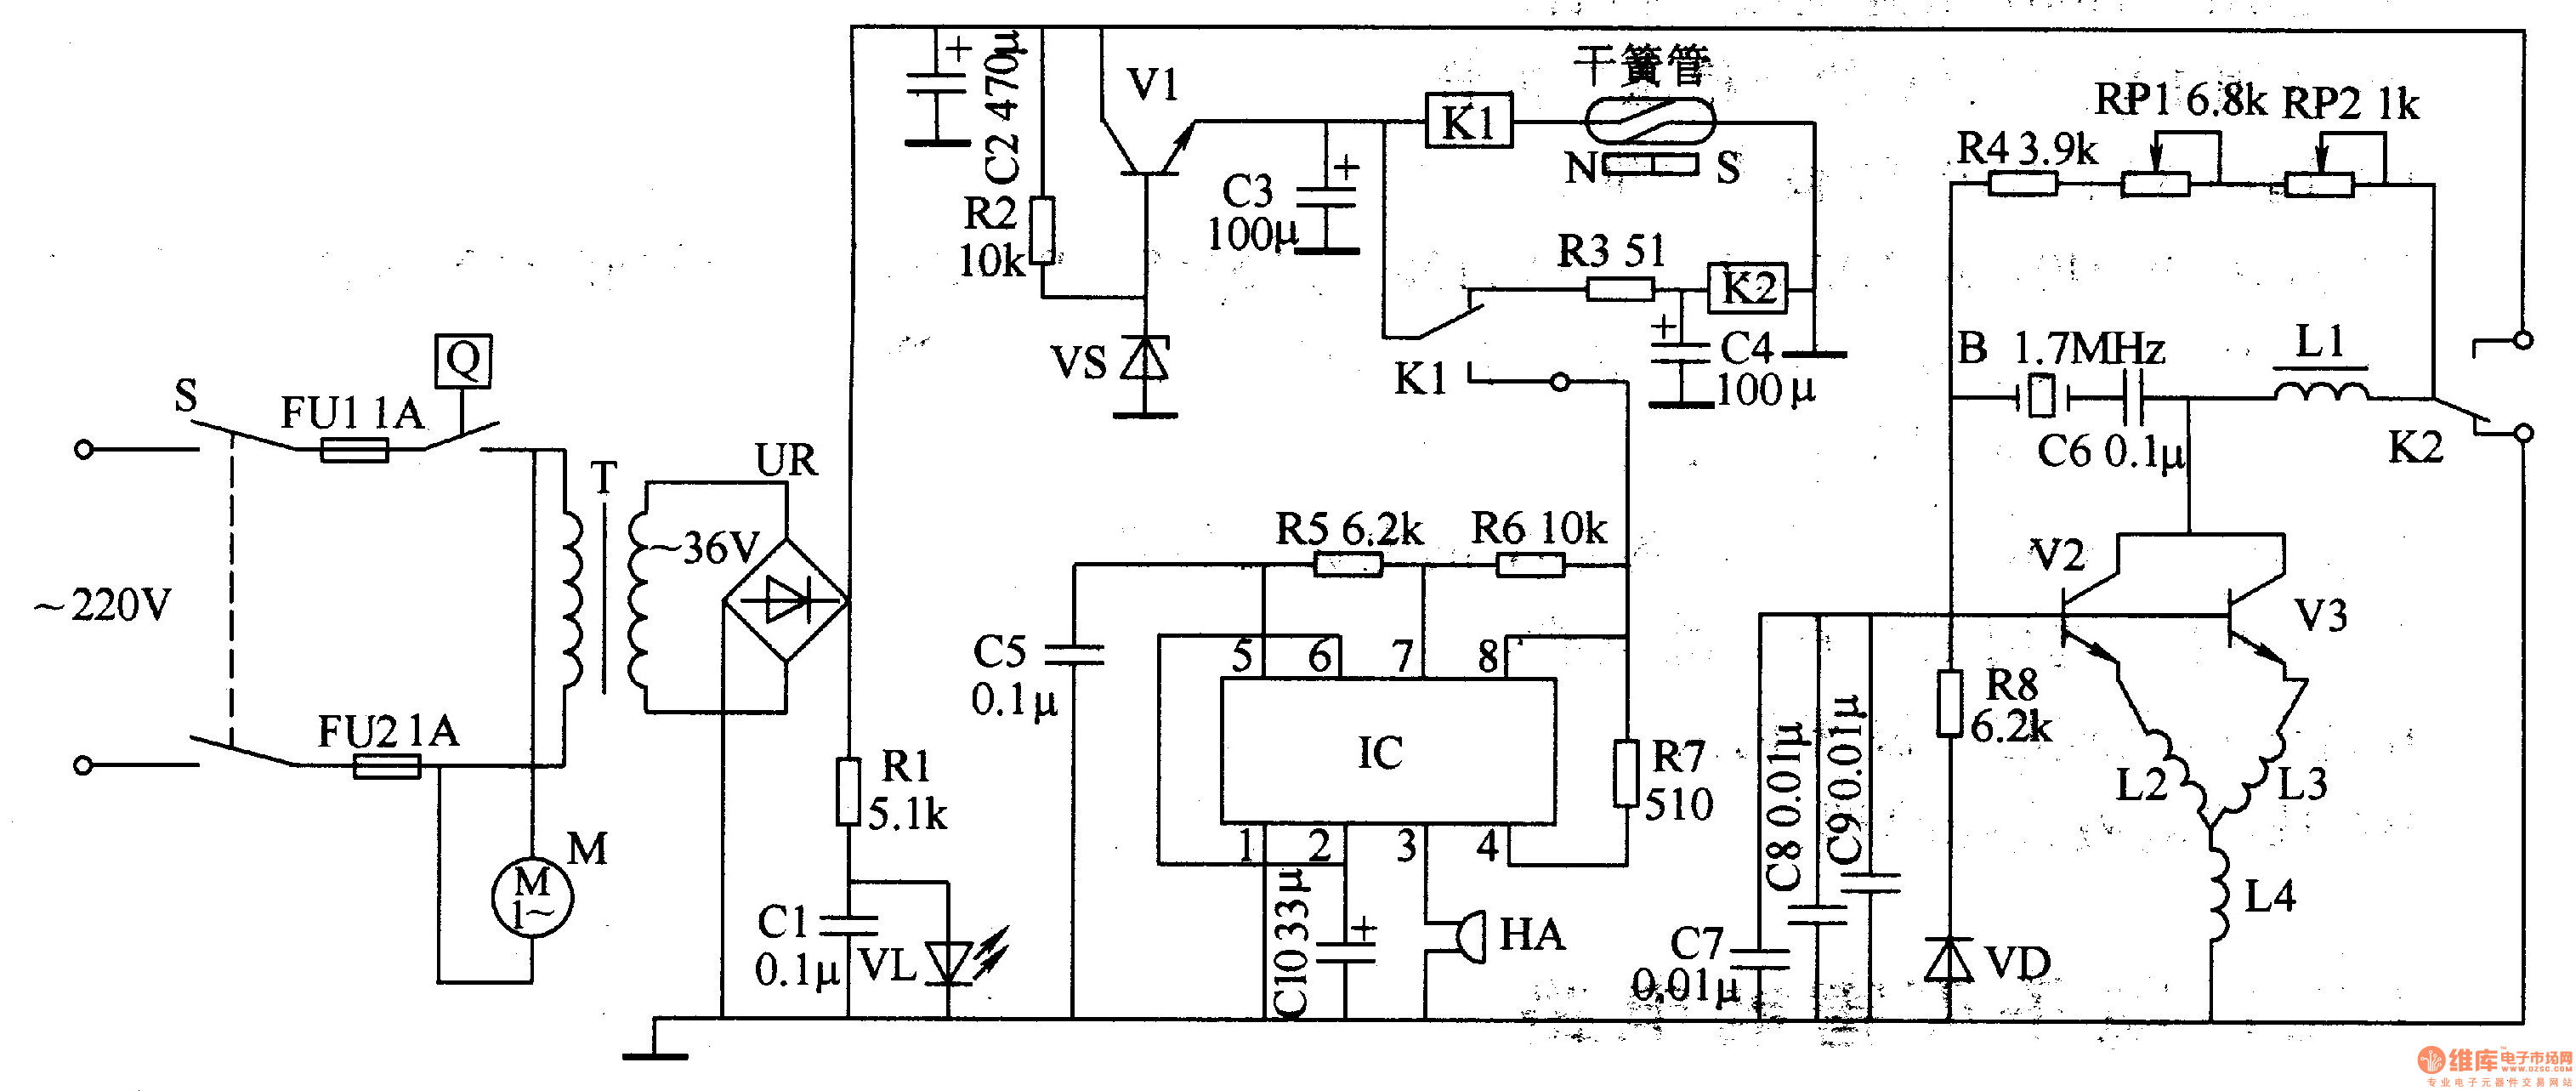
Ultrasonic atomizer 2
The ultrasonic atomizer circuit consists of a power supply circuit, control circuit, water detection alarm circuit, and an ultrasonic oscillator, as illustrated in Figure 3-190. The power supply circuit includes a power switch (S), fuses (FU1, FU2), a timer (Q),...
ultrasonic electrostatic transducer for
This is a complete design circuit for an ultrasonic transceiver utilized in various pulse/echo-ranging applications. The circuit features the LM1812, which transmits a burst of oscillations through transducer X1. Subsequently, the same transducer listens for a return echo. If an...
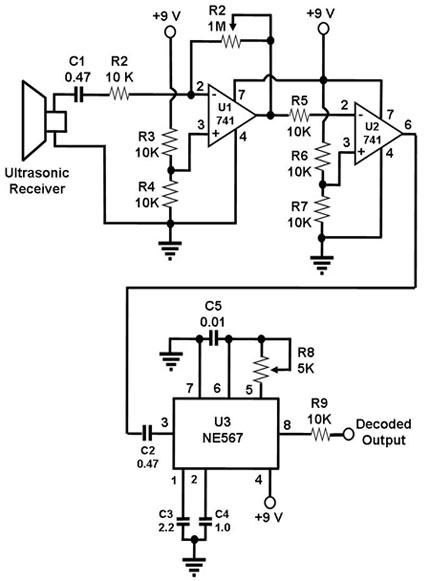
ultrasonic receiver circuit
The ultrasonic receiver utilized in this circuit is specifically designed to vibrate optimally at a frequency of approximately 40 kHz. Consequently, the transmitter associated with this receiver must also emit waves at 40 kHz. When these waves interact with the...
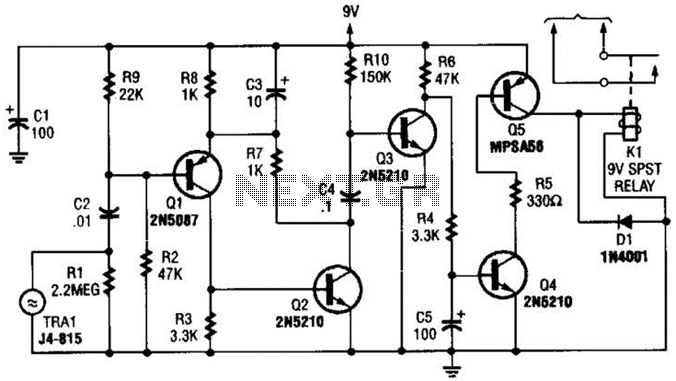
Ultrasonic Remote Control Receiver Circuit
A GC Electronics P/N J4-815 transducer is utilized to receive 40-kHz acoustic remote-control signals. The receiver activates a relay to control another circuit.
The GC Electronics P/N J4-815 transducer is designed specifically for the reception of 40-kHz acoustic signals, which are...
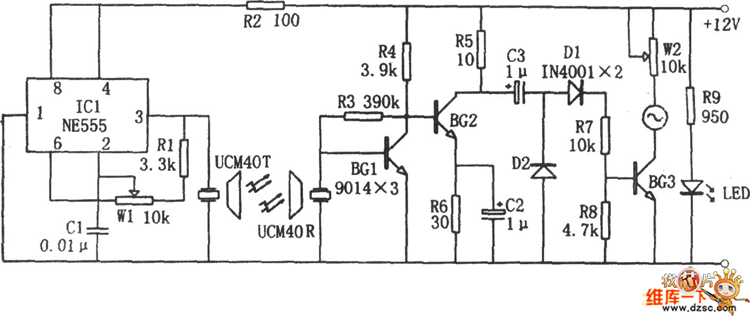
Ultrasonic Liquid Level Indicator Circuit Composed Of NE555
The image depicts an ultrasonic liquid level indicator circuit. This circuit consists of an ultrasonic transmitter circuit and a receiver circuit. The ultrasonic transmitter circuit includes a 555 timer, resistor R1, variable resistor W1, capacitor C1, and the ultrasonic transmitter...
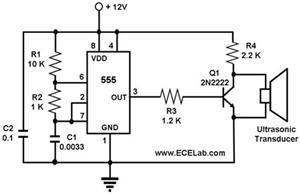
ultrasonic circuit diagram
The ultrasonic cleaning machine functions as a humidifier and operates on a simple circuit primarily consisting of an ultrasonic oscillator. It generates ultrasonic frequency signals, typically within the range of 20-40 kHz, using a transistor. These signals are transmitted to...
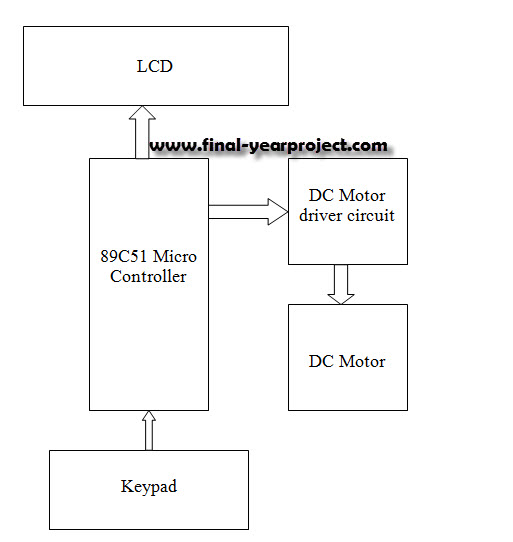
Speed Control of DC Motor using Microcontroller by using PWM ECE Project
This report details an electronic project focused on the speed control of a DC motor using a microcontroller and PWM (Pulse Width Modulation). The system integrates a microcontroller with an LCD, keypad, and a DC motor driver. The microcontroller generates...
Ultrasonic-pest-controller
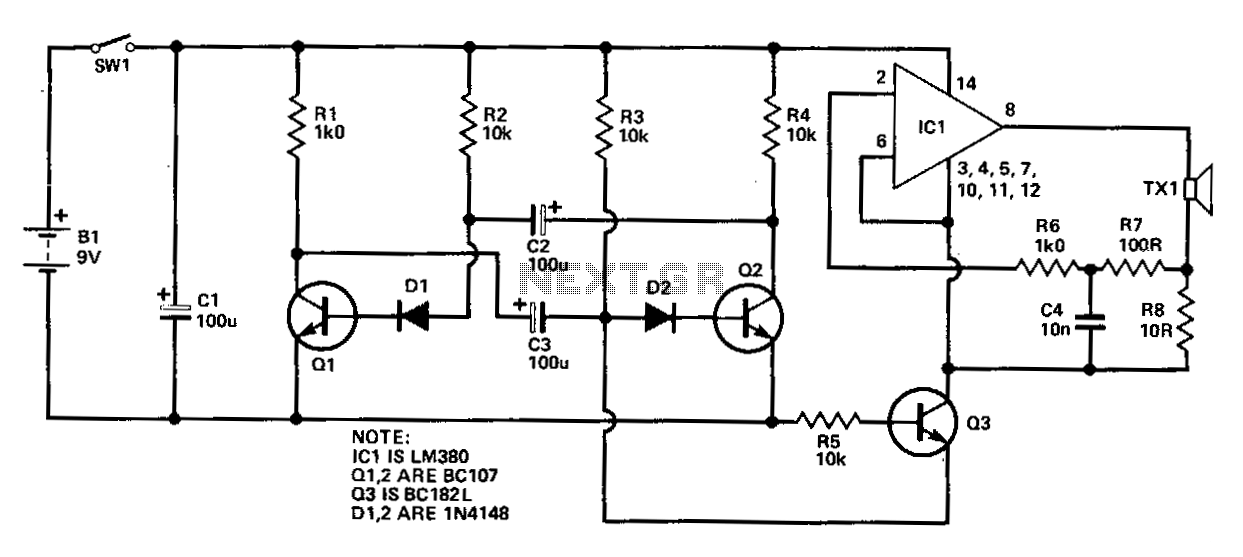
This circuit comprises two fundamental components: an oscillator tuned to 40 kHz and a voltage doubler with a pulse generator. The pulses generated are approximately 10 ms in duration and occur 2-3 times per second to minimize battery consumption while...
Medical ultrasonic atomizer 1
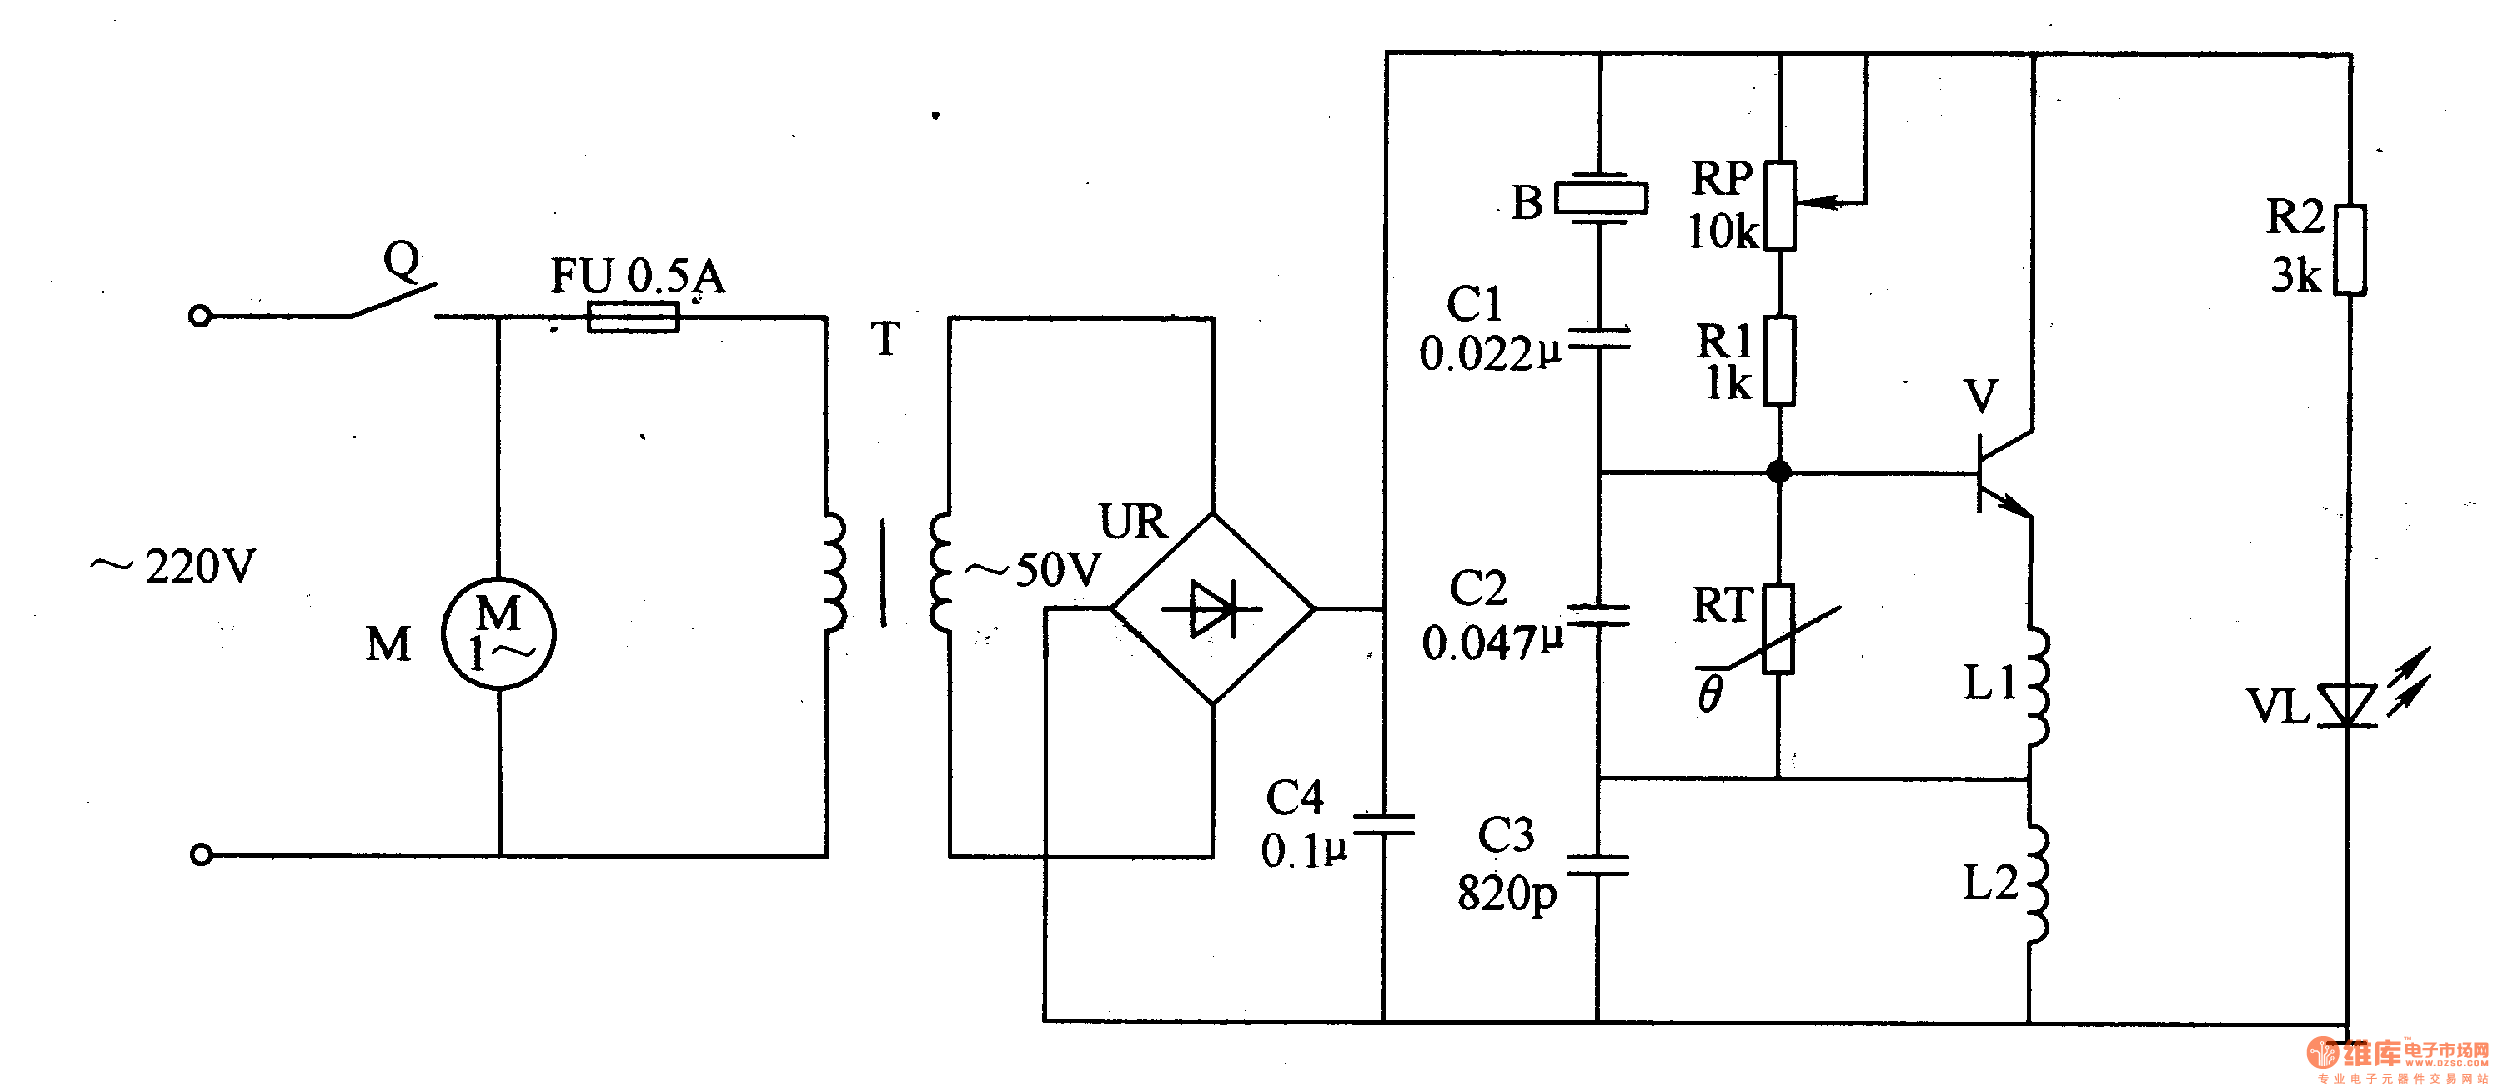
The medical ultrasonic atomizer circuit consists of a power supply circuit, an ultrasonic oscillator, and an atomizer circuit, as illustrated in figure 9-110. The power supply circuit includes a timer (Q), a fuse (FU), a current transformer (T), bridge rectifiers...