


Electronic Schematic Diagram of Light Detector Robot using Light Dependent Resistor (LDR)
#LDR
#light detector
#microcontroller
#DC motor
#sensor
#robot
#light dependent resistor
#automation
#electronic schematic
#motor control
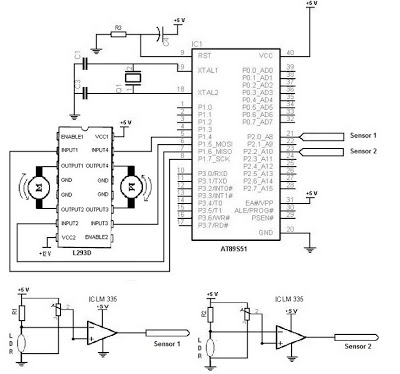
Description: The electronic schematic of the Light Detector Robot can be divided into three main components: the sensor, the microcontroller, and the DC motor driver. The light sensor utilized in this design is a Light Dependent Resistor (LDR), which alters its resistance in response to light detection. The LDR is connected to a resistor to form a voltage divider that serves as the output from the sensor. This voltage is then fed into an integrated circuit (IC) such as the LM355 or LM311, which compares it with a reference voltage. The IC converts the analog voltage from the sensor into a digital signal for the microcontroller AT89S51. The AT89S51 microcontroller processes the input data from the sensor. It can be programmed using assembly language or C programming to determine the robot's movement based on the light detected by the sensor. Programming the microcontroller requires proficiency in microcontroller programming techniques, and tools such as MIDE Programming Software and ISP Programming can be utilized for this purpose. The final component of the schematic involves the design of a DC motor driver using the L293D IC, which facilitates control over two DC motors. The input data for this IC is derived from the microcontroller, and its output is connected to the DC motors that drive the robot's wheels. The electronic schematic diagram of the Light Detector Robot, utilizing the Light Dependent Resistor (LDR), serves as a foundation for completing the project.
The Light Detector Robot operates through a well-defined interaction between its components. The LDR, as the primary sensor, responds to light intensity by changing its resistance, which in turn affects the voltage output in the voltage divider configuration. This change in voltage is crucial as it determines whether the robot will move towards or away from the light source. The LM355 or LM311 IC plays a vital role in translating this analog signal into a digital format that the microcontroller can interpret.
The AT89S51 microcontroller is central to the robot's operation, executing programmed instructions that dictate the robot's behavior based on the sensor input. The programming process involves writing algorithms that define how the robot should react to various light levels. This may include actions such as moving forward when light is detected or turning away from darkness. The choice of programming language, either assembly or C, impacts the complexity and efficiency of the control logic implemented within the microcontroller.
For the motor control aspect, the L293D IC is employed to manage the operation of two DC motors, allowing for bidirectional movement. The microcontroller sends control signals to the L293D, which in turn regulates the power supplied to the motors, facilitating precise movements of the robot. The integration of these components results in a functional Light Detector Robot capable of navigating its environment based on light detection, making it an excellent project for those interested in robotics and electronics. Proper troubleshooting and adjustments may be necessary during the development process to ensure optimal performance of the robot.To describe the performance or work of electronic schematic of Light Detector Robot as like in figure 1 above we can divide into three parts. In sensor, Microcontroller, and driver dc motor. In this part we use LDR as light detector or sensor. LDR will change the resistance when this component detect the light. With the circuit above LDR connected with the resistor to make voltage divider as output sensor. This voltage will be input in IC LM355 or LM311 that will compared with reference voltage. This IC used to make digital voltage in output from this sensor that used to as input data to microcontrolller AT89S51. Microcontroller AT89S51 can used to controlled the input data from sensor part. We can program this IC using specific program like assembly or C programming to follow the logical how this robot will move when this robot detect the light from the sensor part.
To program this IC you must have skill in microcontroller. You can use MIDE Programming Software and also ISP Programming to do it. This is the last part in this schematic. We can design dc motor driver using IC L293D to get 2 part DC motor driver. Data input this IC came from microcontroller and the output of this IC will be connected to DC motor that run the wheel of this robot. So you can try using the Electronic Schematic Diagram of Light Detector Robot using Light Dependent Resistor (LDR) to complete your project.
And if you get some error you can contact me or comment in this blog. Thank you very much for your visiting in Robometricschool blog, We hope you will get more information about Robotic, Mechatronic, and Electronic. And don`t forget to give us your comment about this article. Let keep for building comment.
The Light Detector Robot operates through a well-defined interaction between its components. The LDR, as the primary sensor, responds to light intensity by changing its resistance, which in turn affects the voltage output in the voltage divider configuration. This change in voltage is crucial as it determines whether the robot will move towards or away from the light source. The LM355 or LM311 IC plays a vital role in translating this analog signal into a digital format that the microcontroller can interpret.
The AT89S51 microcontroller is central to the robot's operation, executing programmed instructions that dictate the robot's behavior based on the sensor input. The programming process involves writing algorithms that define how the robot should react to various light levels. This may include actions such as moving forward when light is detected or turning away from darkness. The choice of programming language, either assembly or C, impacts the complexity and efficiency of the control logic implemented within the microcontroller.
For the motor control aspect, the L293D IC is employed to manage the operation of two DC motors, allowing for bidirectional movement. The microcontroller sends control signals to the L293D, which in turn regulates the power supplied to the motors, facilitating precise movements of the robot. The integration of these components results in a functional Light Detector Robot capable of navigating its environment based on light detection, making it an excellent project for those interested in robotics and electronics. Proper troubleshooting and adjustments may be necessary during the development process to ensure optimal performance of the robot.To describe the performance or work of electronic schematic of Light Detector Robot as like in figure 1 above we can divide into three parts. In sensor, Microcontroller, and driver dc motor. In this part we use LDR as light detector or sensor. LDR will change the resistance when this component detect the light. With the circuit above LDR connected with the resistor to make voltage divider as output sensor. This voltage will be input in IC LM355 or LM311 that will compared with reference voltage. This IC used to make digital voltage in output from this sensor that used to as input data to microcontrolller AT89S51. Microcontroller AT89S51 can used to controlled the input data from sensor part. We can program this IC using specific program like assembly or C programming to follow the logical how this robot will move when this robot detect the light from the sensor part.
To program this IC you must have skill in microcontroller. You can use MIDE Programming Software and also ISP Programming to do it. This is the last part in this schematic. We can design dc motor driver using IC L293D to get 2 part DC motor driver. Data input this IC came from microcontroller and the output of this IC will be connected to DC motor that run the wheel of this robot. So you can try using the Electronic Schematic Diagram of Light Detector Robot using Light Dependent Resistor (LDR) to complete your project.
And if you get some error you can contact me or comment in this blog. Thank you very much for your visiting in Robometricschool blog, We hope you will get more information about Robotic, Mechatronic, and Electronic. And don`t forget to give us your comment about this article. Let keep for building comment.
Motorized Video Camera Mount
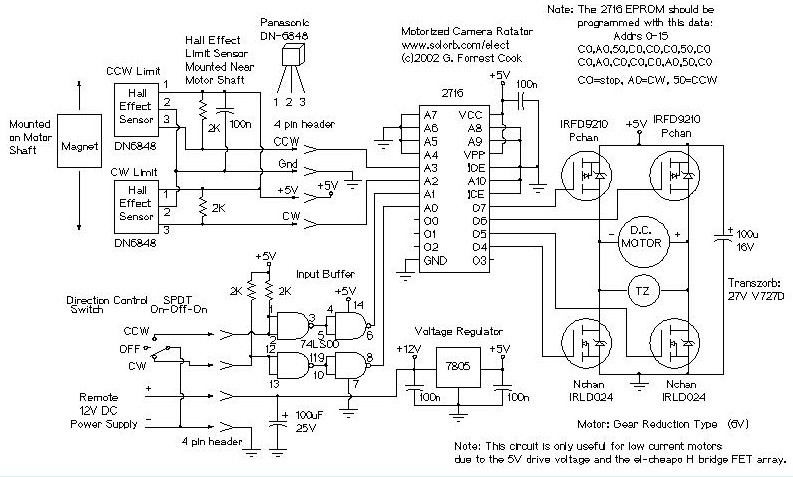
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
Automatic Room light Control With Bi Directional Visitor Counter
The objective of this project is to create a controller-based model that counts the number of individuals entering a specific room and activates the lighting accordingly. This is achieved through the use of sensors that detect the current number of...
delay circuit for photography
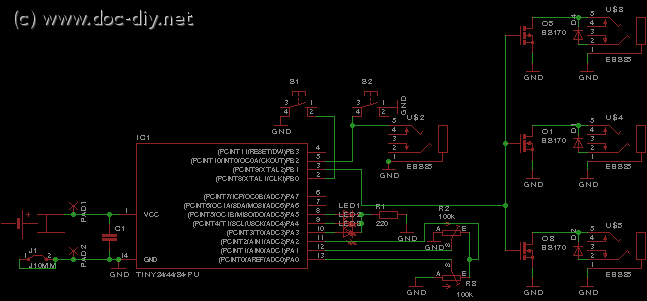
This article outlines the construction of a simple microcontroller-based delay circuit designed for photographic applications such as drop or high-speed photography. It can control the trigger lag of cameras and flash units, generate periodic trigger pulses, or manage magnetic valves....
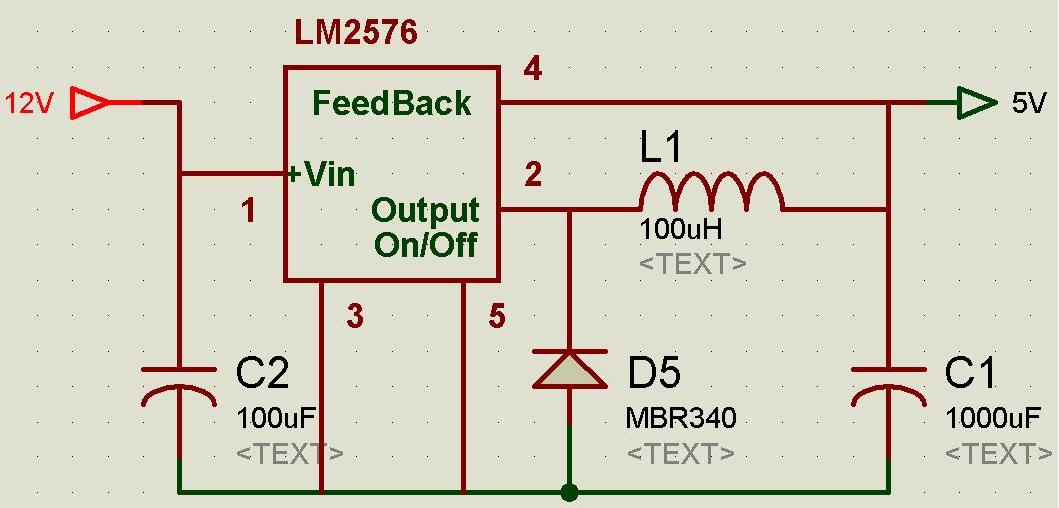
Some Voltage Regulator Ciruits for Microcontroller based Projects
A regulated and noise-free power supply voltage is essential for microcontrollers and other components such as amplifiers, filters, and GPS devices. Voltage surges in the supply voltage can permanently damage embedded systems. A voltage regulator must maintain the output voltage...
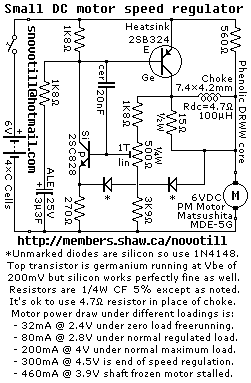
Small DC Motor Speed Regulator
Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The...
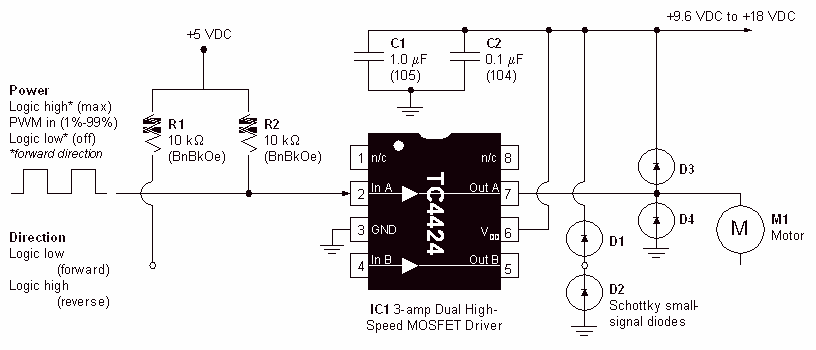
DC Motor-Driver H-Bridge Circuit
Physical motion of some form helps differentiate a robot from a computer. It would be nice if a motor could be attached directly to a chip that controlled the movement. But, most chips can't pass enough current or voltage to...
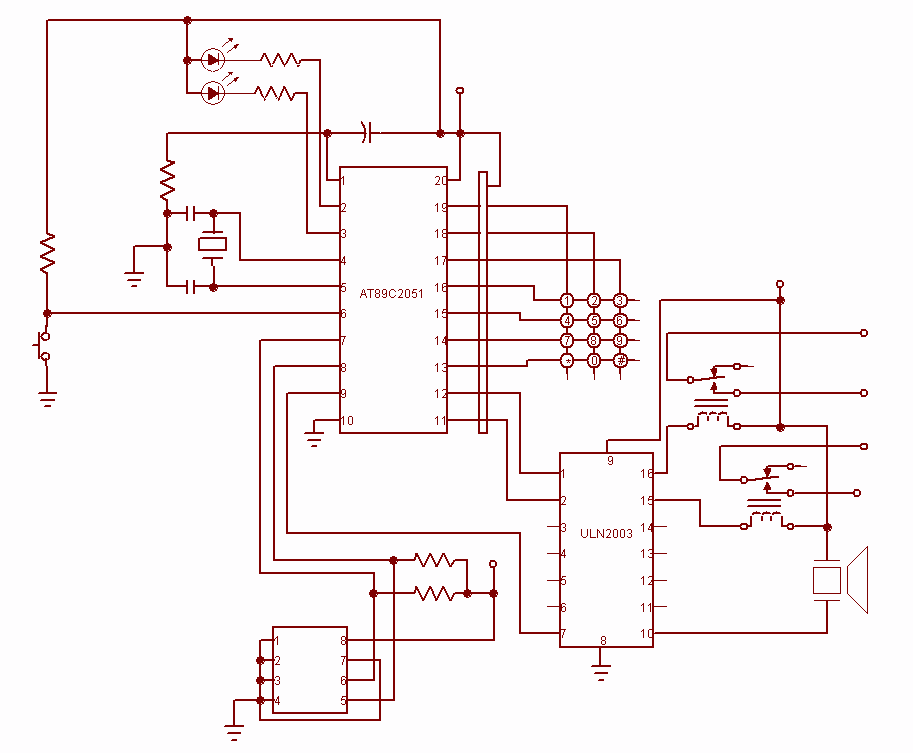
Password Based Door Locking
Security is a prime concern in our day-to-day life. Everyone wants to be as much secure as possible. An access control for doors forms a vital link in a security chain. The microcontroller based Door locker is an access control...
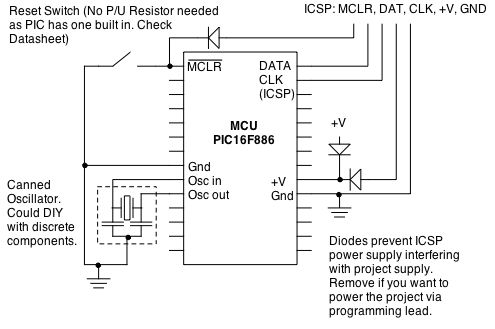
Augmenting a Microcontroller
Microcontrollers (MCUs) are versatile integrated circuits that enhance the functionality of electronics, robotics, and other projects. However, they...
Microcontrollers (MCUs) serve as the central processing unit in a variety of electronic applications, offering programmable control that allows for complex functionalities in...
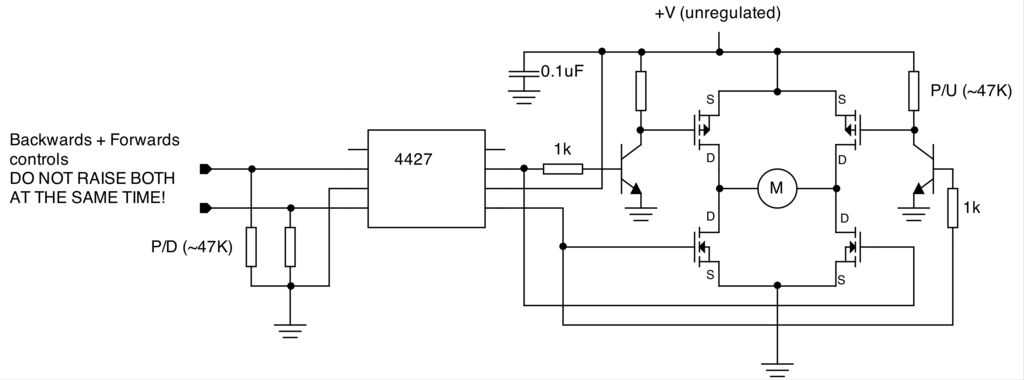
Augmenting a Microcontroller Circuit
To create a versatile and generic microcontroller board, the information provided thus far is sufficient. It covers the essential components needed to achieve this.
The design of a microcontroller board requires careful consideration of various factors to ensure versatility and functionality....