


Edge Avoider Robot without microcontroller
#edge detection
#robot
#sensor
#motor control
#obstacle avoidance
#autonomous
#mobile device
#surface detection
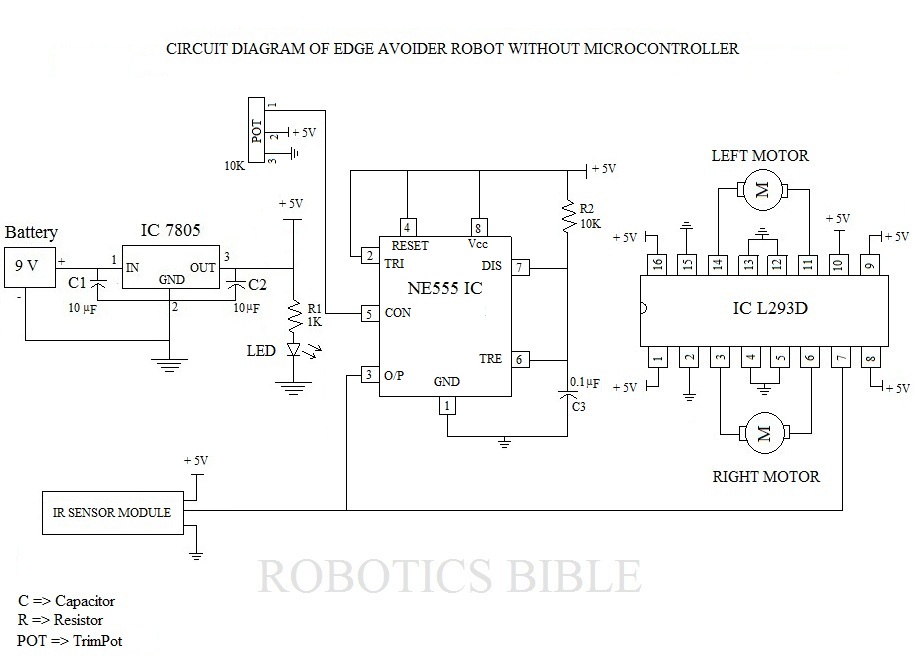
Description: The Edge Avoider Robot (EAR) is a mobile device that detects and avoids areas where there is no surface beneath it.
The Edge Avoider Robot (EAR) operates using a combination of sensors and microcontroller technology to navigate its environment effectively. The primary function of the EAR is to prevent it from falling off edges, such as tables or staircases, by utilizing proximity sensors that detect the presence of a surface. These sensors are typically mounted on the front and sides of the robot, allowing it to sense the distance to nearby edges.
In terms of circuit design, the EAR can be constructed using a microcontroller, such as an Arduino or Raspberry Pi, which processes the sensor inputs and controls the motors that drive the robot. The sensors used may include infrared (IR) or ultrasonic distance sensors, which emit signals and measure the time it takes for the signals to reflect back. This information is crucial for determining the proximity of the edge.
The power supply for the EAR can be achieved through rechargeable batteries, ensuring that the device remains mobile. The motors are usually controlled via a motor driver circuit, which can handle the current requirements of the motors while allowing the microcontroller to send control signals.
The software aspect involves programming the microcontroller to interpret sensor data and make real-time decisions on motor control. The robot can be programmed with various algorithms to enhance its edge-avoiding capabilities, such as simple reactive behaviors or more complex navigation strategies.
Overall, the Edge Avoider Robot is a practical application of basic robotics principles, integrating hardware and software to achieve a specific task of edge detection and avoidance. This project not only serves as an educational tool for understanding robotics but also demonstrates the importance of sensor integration and control systems in mobile devices.Edge Avoider Robot (EAR) is a mobile device, which senses and avoids the absence of surface below it..
The Edge Avoider Robot (EAR) operates using a combination of sensors and microcontroller technology to navigate its environment effectively. The primary function of the EAR is to prevent it from falling off edges, such as tables or staircases, by utilizing proximity sensors that detect the presence of a surface. These sensors are typically mounted on the front and sides of the robot, allowing it to sense the distance to nearby edges.
In terms of circuit design, the EAR can be constructed using a microcontroller, such as an Arduino or Raspberry Pi, which processes the sensor inputs and controls the motors that drive the robot. The sensors used may include infrared (IR) or ultrasonic distance sensors, which emit signals and measure the time it takes for the signals to reflect back. This information is crucial for determining the proximity of the edge.
The power supply for the EAR can be achieved through rechargeable batteries, ensuring that the device remains mobile. The motors are usually controlled via a motor driver circuit, which can handle the current requirements of the motors while allowing the microcontroller to send control signals.
The software aspect involves programming the microcontroller to interpret sensor data and make real-time decisions on motor control. The robot can be programmed with various algorithms to enhance its edge-avoiding capabilities, such as simple reactive behaviors or more complex navigation strategies.
Overall, the Edge Avoider Robot is a practical application of basic robotics principles, integrating hardware and software to achieve a specific task of edge detection and avoidance. This project not only serves as an educational tool for understanding robotics but also demonstrates the importance of sensor integration and control systems in mobile devices.Edge Avoider Robot (EAR) is a mobile device, which senses and avoids the absence of surface below it..
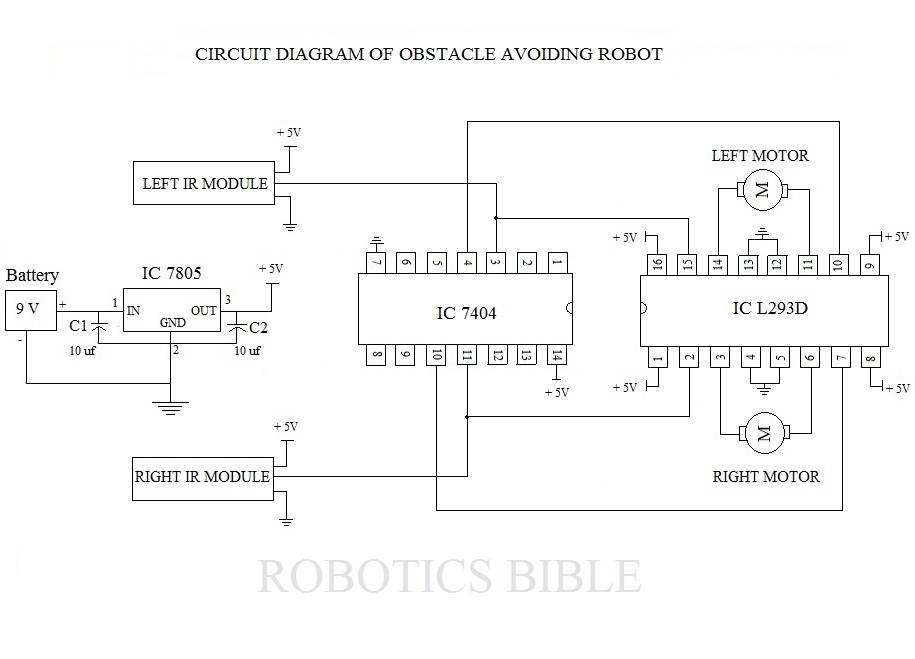
Obstacle Avoiding Robot without microcontroller
An obstacle-avoiding robot is an intelligent device that can automatically sense and navigate around obstacles in its path. It is designed without a microcontroller to simplify the circuitry and programming requirements. Understanding the circuit diagram is essential for constructing this...
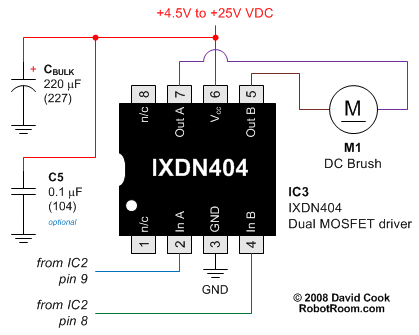
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
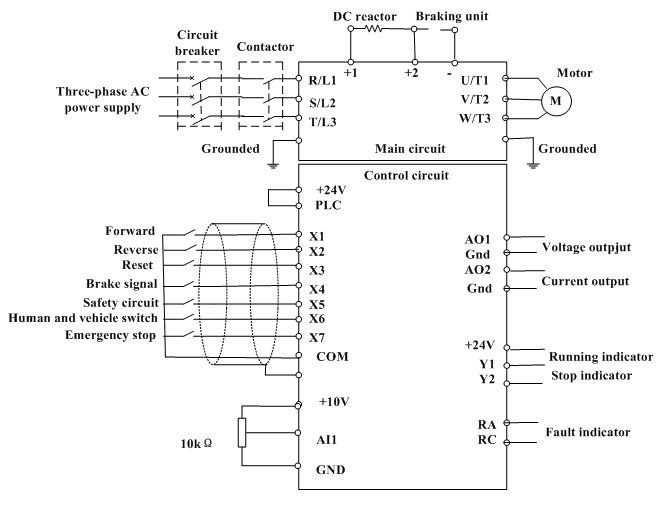
motor control inverter (AC drive) in mine industry
Motor control, energy efficiency of inverter (AC drive) selection, and parameters setting guidance in the mining industry: vector control, open loop or closed loop control, with energy braking unit or energy feedback unit.
In the context of motor control for the...
robotic vacuum cleaner
A robot has been designed and built to vacuum the floor of a room or area autonomously, requiring only the initial activation by a user. This project addresses the demand for an affordable and user-friendly product that can independently vacuum...
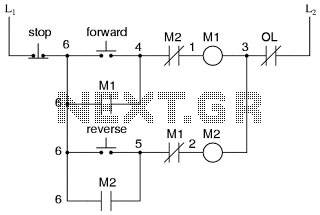
Motor control circuit for forward and reverse phase induction
This is the power diagram for motor forward and reverse operation. To change the motor direction, one polarity must be altered, for example, changing R to S. For detailed information, please refer to the following.
The described power diagram illustrates a...
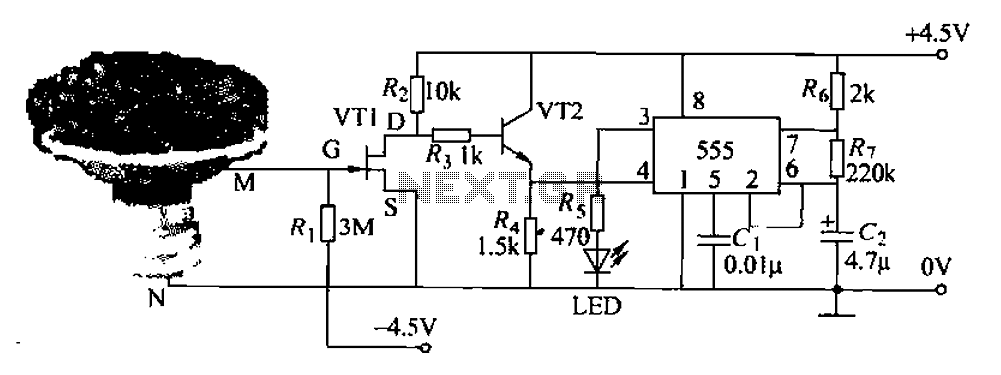
Pots water alarm circuit
The flowers in pots require watering, as relying solely on the observation of moist soil surfaces can be unreliable. To address this issue, a flower watering indicator has been developed. This circuit includes a field effect transistor (VT1), a second...
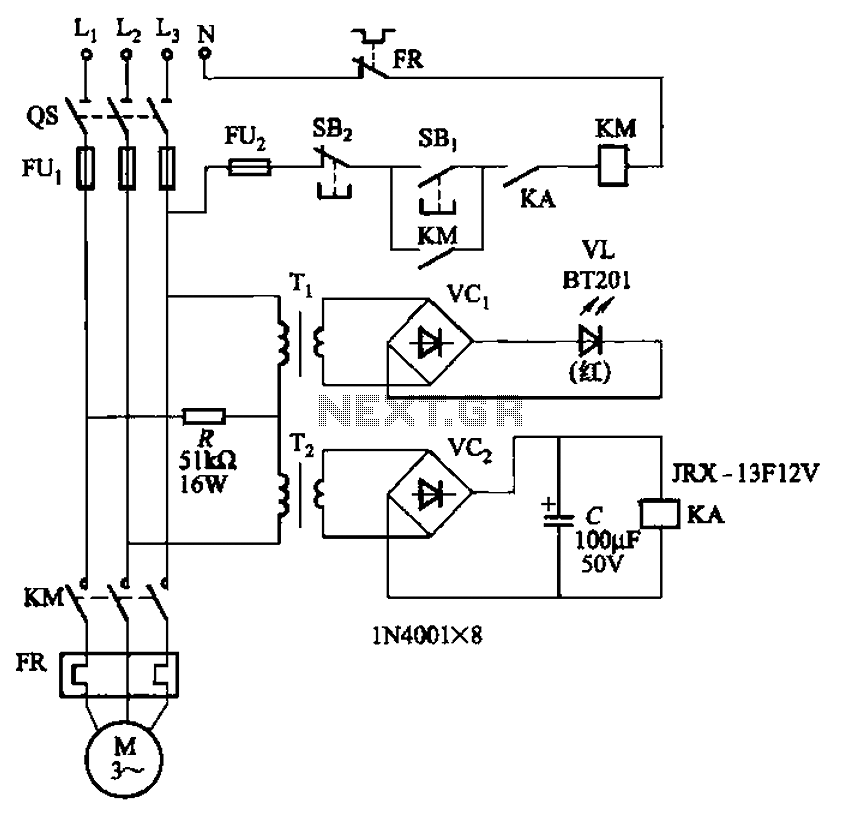
Allowing only one-way operation of the motor-controlled circuit 2
The circuit depicted in Figure 3-92 employs a dual-phase sequence protection relay for sensing. When the power supply exhibits a positive phase sequence (U, V, W), the relay KA is activated. If the power supply maintains the correct phase sequence,...
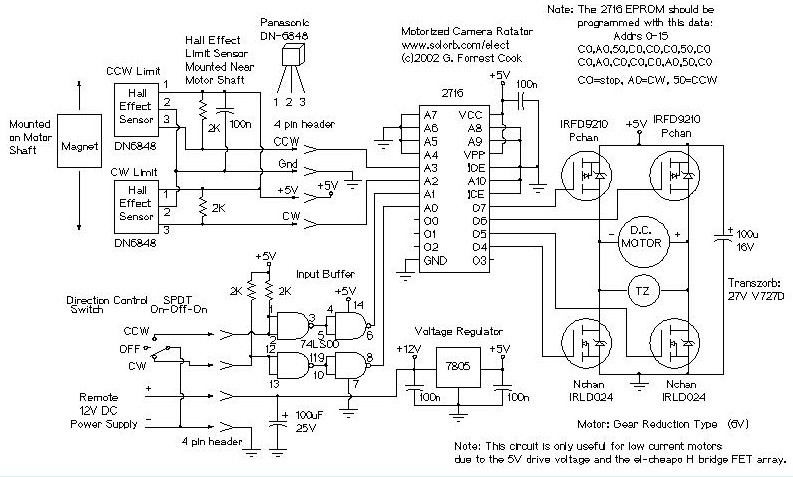
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
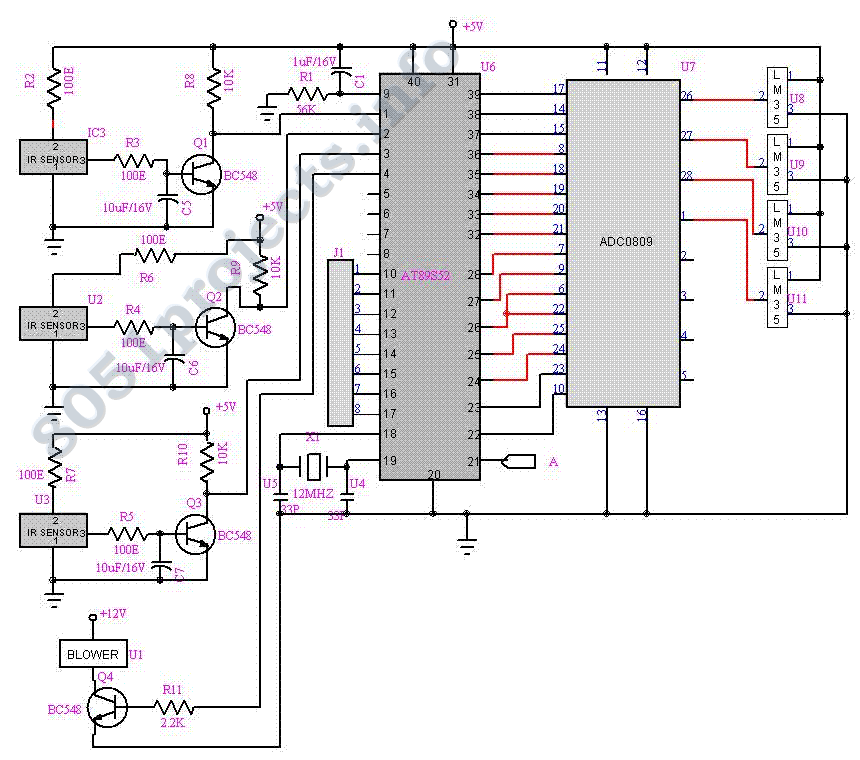
Fighting Robot circuit
The need for a device that can detect and extinguish a fire on its own is long past due. Many house fires originate when someone is either sleeping or not home. With the invention of such a device, people and...