


analog pid control using opamps
#PID control
#op-amp
#analog control
#feedback loop
#sensor input
#setpoint
#control system
#transducer
#temperature control
#pressure control
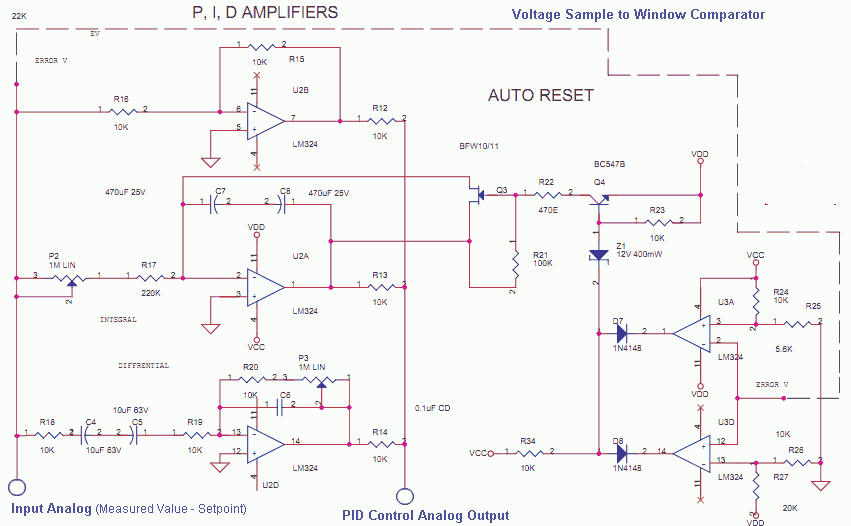
Description: The Measured Value and the Setpoint are two inputs to a control system. The Measured Value is the amplified input from a transducer or sensor for a specific parameter that requires regulation, such as pressure or temperature. The Setpoint is the user-defined input set using a potentiometer, thumbwheel, EPROM, or flash value. This value represents the target at which the parameter should be maintained. The difference between the Measured Value and the Setpoint is referred to as the Error, which serves as the input for the PID analog computation stage. Three operational amplifiers (op-amps) are configured as proportional, integrator, and differentiator amplifiers. The summation of these values results in the PID control output. In contemporary systems, this computation is often performed in firmware on microcontrollers (MCUs), digital signal processors (DSPs), or software applications in SCADA systems. The analog PID control output can be converted into a 4-20 mA control signal, representing 0-100% power to an actuator, which may include components such as heaters, pumps, fans, or motors utilizing AC/DC drives. Actuators can also include steam valves or pneumatic or hydraulic motorized solenoids. It is crucial to select the appropriate size and type of actuator for the application; for example, a small fan is inadequate for cooling a large furnace, and a small solenoid valve cannot effectively fill a large tank. Effective proportional or PID control relies on the careful selection or design of the sensor, actuator, and system environment. Auto-reset functionality is essential to prevent the integrator from excessively dampening the process, ensuring that it can respond adequately to reach the desired process value. In the proportional band, the integrator remains active. For instance, if the Setpoint is 1000 °C, the proportional band may be set at 10%. The temperature will rise undamped to 950 °C, after which the integrator is engaged through a window comparator constructed from two op-amps, which helps to mitigate overshoot, undershoot, ringing, and oscillations. Additionally, the PID control output can be configured as a time-proportional output, such as pulse-width modulation (PWM), with longer cycle times exceeding 20 seconds, for example, 2 seconds on and 18 seconds off to achieve 10% control. Shorter cycle times may be necessary for smaller systems with lower inertia.
The control system outlined operates on a feedback mechanism that continuously monitors the process variable (the Measured Value) against the desired target (the Setpoint). This feedback loop is essential for maintaining stability and accuracy in various applications. The PID controller's three components—proportional, integral, and derivative—each play a distinct role:
1. **Proportional Control**: This component produces an output that is proportional to the current error value. It provides immediate correction based on the magnitude of the error, thereby driving the system towards the Setpoint. However, solely relying on proportional control can result in a steady-state error.
2. **Integral Control**: This component accumulates the error over time, addressing any residual steady-state error that the proportional control cannot eliminate. The integrator adjusts the output based on the sum of past errors, ensuring that the process variable aligns closely with the Setpoint over time.
3. **Differential Control**: This component predicts future errors based on the rate of change of the error. By anticipating the direction and speed of the error change, the differentiator can apply corrective actions preemptively, reducing overshoot and improving system response time.
The combined output from these three components is processed to generate a control signal that effectively drives the actuator. The actuator's response must be appropriately matched to the system dynamics; thus, careful consideration is required during the design phase to ensure that the control system functions optimally under varying conditions.
In applications where rapid response is critical, such as in temperature control of fast-heating processes, the PID parameters must be tuned meticulously to achieve the desired performance without introducing instability. Tuning may involve adjusting gain settings for each PID component, and methods such as Ziegler-Nichols or software-based optimization techniques can be employed to achieve optimal results.
Overall, the described control system exemplifies the integration of analog and digital techniques to achieve precise control over physical parameters, ensuring efficiency and reliability in industrial and commercial applications.The Measured Value and The Setpoint are two inputs to a Control System. The Measured Value is the Amplified input of a Transducer or Sensor for some Parameter that needs to be controlled. It could be Pressure or Temperature. etc. The Setpoint is the User Defined Input using a Potentiometer, Thumbwheel, EPROM or Flash Value. This is the value at whi ch the process has to be maintained for that parameter. The difference of these two is the Error, this is the input for this PID Analog Computation Stage. The three Opamps are configured as Proportional, Integrator and Differentiator Amps. The Addition or Summation of these Values is the PID Control Output. (These days it is Math in the Firmware on a MCU, DSP or Software Application in SCADA) This Analog PID Control Output can now be translated to a 4-20 mA Control Signal, that means 0-100% of power to the Actuator, which could be a Heater, Pump, Fan, Motor using AC/DC Drives. It could be a Steam Valve, Pneumatic or Hydraulic Motorized/Solenoids. The Actuator Size/Array must be right for the Process, a tiny fan cannot cool a Large Furnace, a small solenoid valve cannot fill a Big Tank.
An effective Proportional or PID control depends on choosing or designing the Sensor, Actuator and System Environment prudently. The Auto Reset is needed to ensure the Integrator does not dampen the Process so much that it fails to even raise to the Process value fast enough (Diffrentiator).
So in the Proportional Band the Integrator is Active. If the Setpoint is 1000 deg C, the proportional band is 10%. The Raise of temperature till 950 deg is Undampended. After that Integrator is called in by the Window Comparator made of two opamps, the integrator prevents OverShoot, Undershoot, Ringing and Oscillations. The PID control output can also be a Time Proportional Output like PWM. With a large cycle time of 20 or More seconds. Like 2 Seconds on and 18 Seconds off for 10% Control. Fast Cycle times may be needed for small systems with less inertia.
The control system outlined operates on a feedback mechanism that continuously monitors the process variable (the Measured Value) against the desired target (the Setpoint). This feedback loop is essential for maintaining stability and accuracy in various applications. The PID controller's three components—proportional, integral, and derivative—each play a distinct role:
1. **Proportional Control**: This component produces an output that is proportional to the current error value. It provides immediate correction based on the magnitude of the error, thereby driving the system towards the Setpoint. However, solely relying on proportional control can result in a steady-state error.
2. **Integral Control**: This component accumulates the error over time, addressing any residual steady-state error that the proportional control cannot eliminate. The integrator adjusts the output based on the sum of past errors, ensuring that the process variable aligns closely with the Setpoint over time.
3. **Differential Control**: This component predicts future errors based on the rate of change of the error. By anticipating the direction and speed of the error change, the differentiator can apply corrective actions preemptively, reducing overshoot and improving system response time.
The combined output from these three components is processed to generate a control signal that effectively drives the actuator. The actuator's response must be appropriately matched to the system dynamics; thus, careful consideration is required during the design phase to ensure that the control system functions optimally under varying conditions.
In applications where rapid response is critical, such as in temperature control of fast-heating processes, the PID parameters must be tuned meticulously to achieve the desired performance without introducing instability. Tuning may involve adjusting gain settings for each PID component, and methods such as Ziegler-Nichols or software-based optimization techniques can be employed to achieve optimal results.
Overall, the described control system exemplifies the integration of analog and digital techniques to achieve precise control over physical parameters, ensuring efficiency and reliability in industrial and commercial applications.The Measured Value and The Setpoint are two inputs to a Control System. The Measured Value is the Amplified input of a Transducer or Sensor for some Parameter that needs to be controlled. It could be Pressure or Temperature. etc. The Setpoint is the User Defined Input using a Potentiometer, Thumbwheel, EPROM or Flash Value. This is the value at whi ch the process has to be maintained for that parameter. The difference of these two is the Error, this is the input for this PID Analog Computation Stage. The three Opamps are configured as Proportional, Integrator and Differentiator Amps. The Addition or Summation of these Values is the PID Control Output. (These days it is Math in the Firmware on a MCU, DSP or Software Application in SCADA) This Analog PID Control Output can now be translated to a 4-20 mA Control Signal, that means 0-100% of power to the Actuator, which could be a Heater, Pump, Fan, Motor using AC/DC Drives. It could be a Steam Valve, Pneumatic or Hydraulic Motorized/Solenoids. The Actuator Size/Array must be right for the Process, a tiny fan cannot cool a Large Furnace, a small solenoid valve cannot fill a Big Tank.
An effective Proportional or PID control depends on choosing or designing the Sensor, Actuator and System Environment prudently. The Auto Reset is needed to ensure the Integrator does not dampen the Process so much that it fails to even raise to the Process value fast enough (Diffrentiator).
So in the Proportional Band the Integrator is Active. If the Setpoint is 1000 deg C, the proportional band is 10%. The Raise of temperature till 950 deg is Undampended. After that Integrator is called in by the Window Comparator made of two opamps, the integrator prevents OverShoot, Undershoot, Ringing and Oscillations. The PID control output can also be a Time Proportional Output like PWM. With a large cycle time of 20 or More seconds. Like 2 Seconds on and 18 Seconds off for 10% Control. Fast Cycle times may be needed for small systems with less inertia.
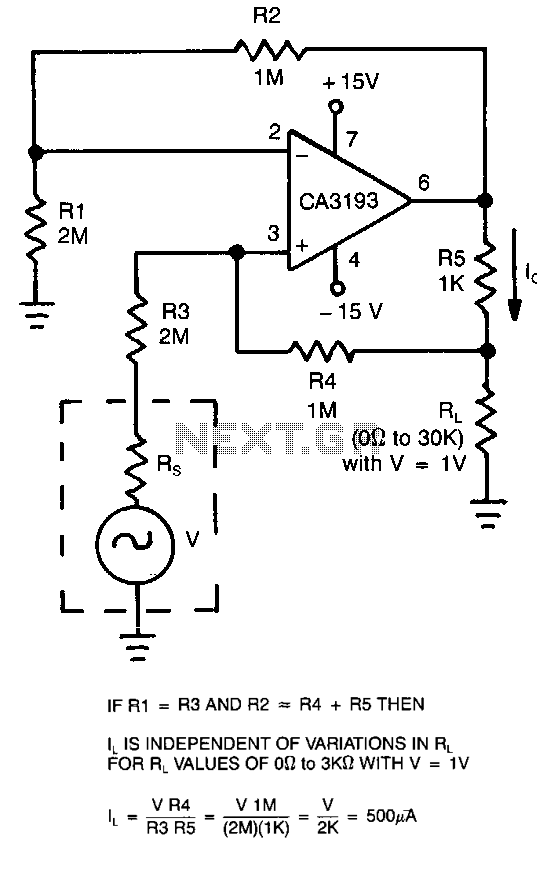
Bilateral-current-source
This circuit employs a CA3193 precision operational amplifier to provide a current that remains consistent regardless of variations in the load resistance (RL). By configuring the input resistance (RI) to be equal to resistance R3 and setting resistance R2 to...
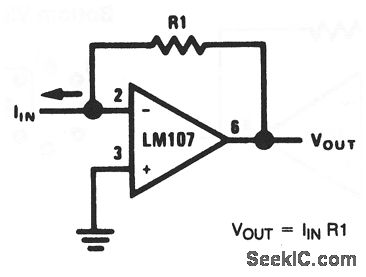
Basic current to voltage converter
This basic circuit feeds the input current directly into the summing node (pin 2), causing the op-amp output to adjust and extract the same current from the summing node through resistor R1. The scale factor of the circuit is defined...
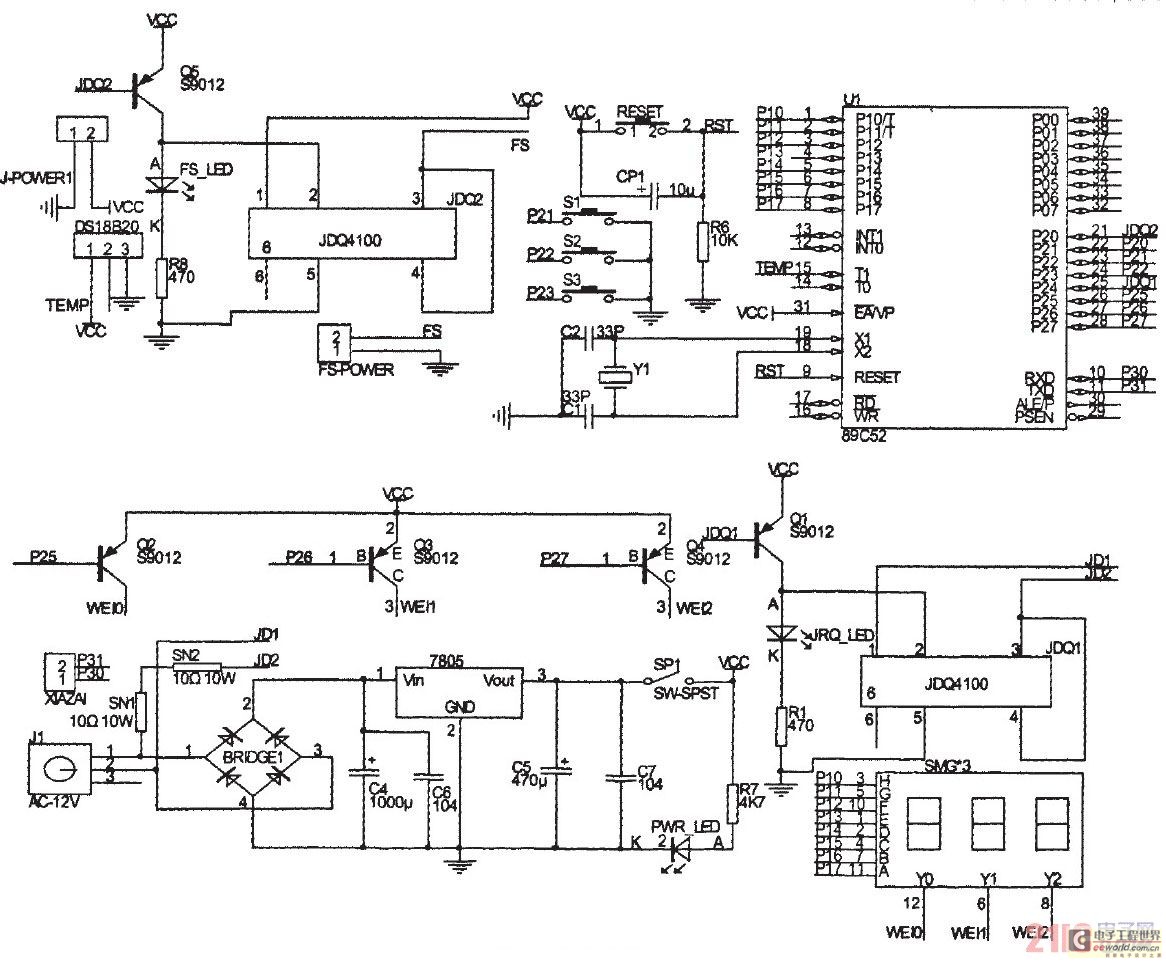
The method of temperature controlling system of producing one-chip computer calorstat is analyzed
The primary principle of the system is to gather real-time temperature data from a temperature sensor using a microcontroller, which then compares this data with pre-defined thermostat values to maintain the desired temperature within a sample container. This text covers...
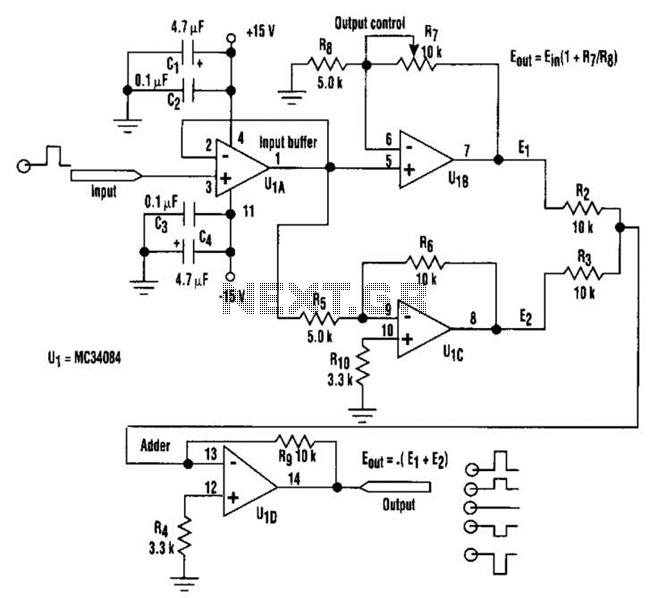
Polarity Gain Adjustment Circuit
By adjusting one potentiometer, the output of this circuit can be varied from a positive version of the input signal, smoothly transitioning through zero output, and then to a negative version of the input. For instance, if the input signal...
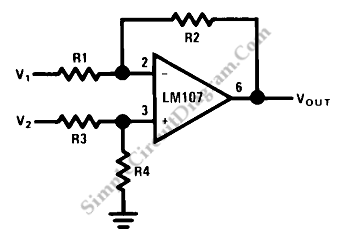
Op-Amp Circuit: Difference Amplifier
This circuit is a difference amplifier. It functions as an inverting amplifier that enables the subtraction of two voltages, effectively performing a summation.
The difference amplifier is a fundamental circuit configuration in analog electronics, primarily used for amplifying the difference between...
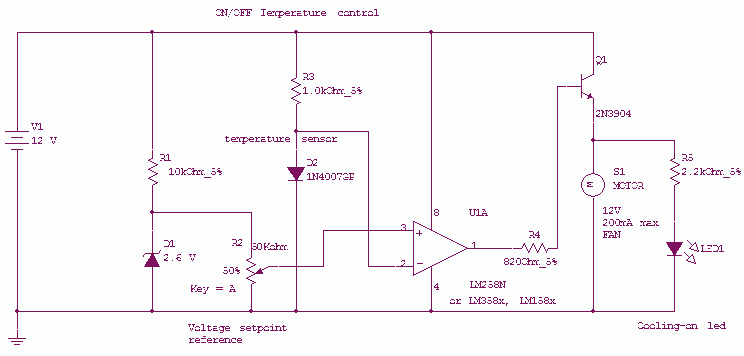
Temperature Controler switch
This circuit controls a load (in this case a DC brushless fan) based on a temperature compared with a setpoint. The transducer is a diode in the forward polarization regime. In fact, when forward biased, the forward voltage drop across...
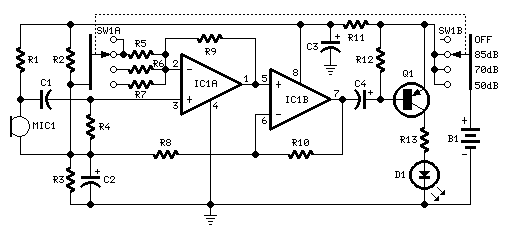
Room Noise Detector Schematic Circuit
This circuit is designed to signal the exceeding of a fixed threshold in room noise through a flashing LED. Three fixed levels are selectable: 50, 70, and 85 dB. Two operational amplifiers provide the necessary gain for sounds captured by...
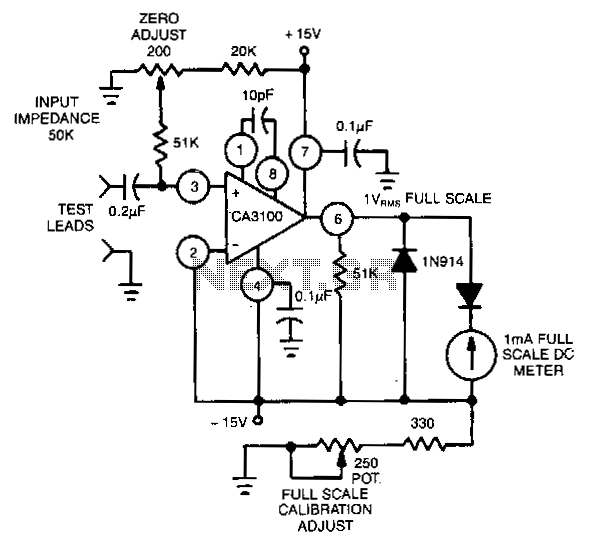
1Mhz-meter-driver-amplifier
This circuit utilizes the CA3100 BiMOS operational amplifier to drive a 1-mA meter movement to its full scale with a 1-V RMS input.
The circuit configuration incorporates the CA3100 BiMOS operational amplifier, which is known for its high input impedance and...
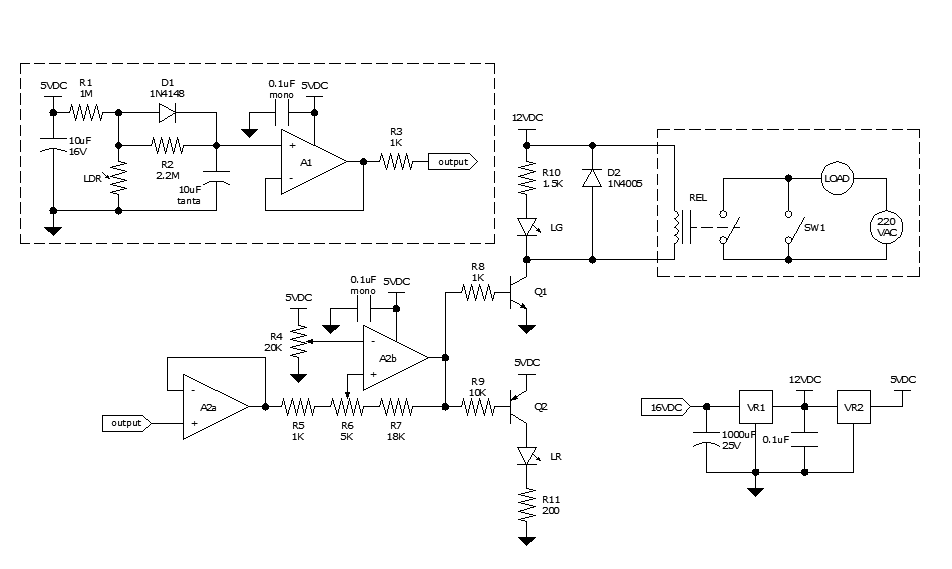
All-analog automatic night light circuit
Approximately ten days ago, an all-linear automatic night light circuit was installed to control the lights in the living room. The circuit comprises three operational amplifiers (op-amps): two configured as voltage followers and one as a comparator. As depicted in...