


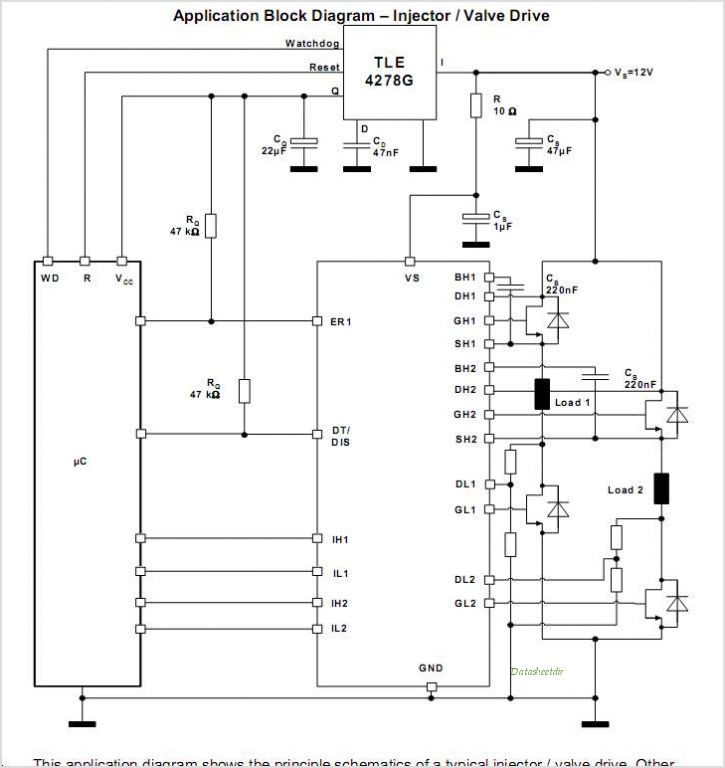
TLE6282 H-Bridge And Half Bridge Driver IC
#H-Bridge
#Half Bridge
#TLE6282
#driver IC
#motor driver
#PWM
#control circuit
#power electronics
#switching
Description: The converter utilizes a TinySwitch-III family member (U2, a TNY279PN) to deliver up to 1.8 A of load current to six high-intensity Luxeon LEDs (LXHL series). The output voltage is slightly below the forward voltage drop of the LEDs, enabling operation in constant current (CC) mode when the LEDs are connected. If the LEDs are disconnected, Zener Diode VR1 provides voltage feedback, regulating the output voltage at approximately 13.5 VDC. A 100 mΩ resistor (R11) senses the output current, and an operational amplifier (U1) drives the optocoupler (U3), which provides feedback to U2. The TinySwitch-III devices regulate operation by disabling or skipping MOSFET switching cycles. When the load current reaches the current limit threshold, U1 activates U3, causing the photo-transistor in U3 to pull current from the EN/UV pin of U2, resulting in skipped switching cycles. Once the output current falls below the threshold, U1 ceases to drive U3, allowing switching cycles to resume. The TL431 (U4) serves as a reference for U1 to compare against the voltage drop across R11. The output diode (D9) is positioned in the lower leg of the transformer (T1) secondary winding to minimize EMI noise. An RCD clamp (R16, C4, and D13) protects the drain node of the MOSFET from flyback voltage spikes. The Valley Fill circuit (D5, D6, D7, C15, C16, and R15) limits the third and fifth harmonics of the line frequency current, ensuring compliance with Total Harmonic Distortion (THD) requirements specified in IEC61000-3-2. Frequency jittering in U2, a shield winding in T1, and a Y-class capacitor (C8) across T1 reduce conducted EMI, enabling a simple pi filter (C13, L1, L2, and C14) to meet EN55022B limits.
The circuit described operates as a highly efficient LED driver, leveraging the TinySwitch-III family’s capabilities for constant current regulation. The TNY279PN specifically is designed for off-line applications, featuring integrated high-voltage MOSFETs and a control circuit that allows for compact designs. The output current regulation is achieved through the feedback mechanism involving the operational amplifier and optocoupler, ensuring stable operation even under varying load conditions.
The use of a Zener diode for voltage feedback when the load is disconnected is a critical design feature that prevents overvoltage conditions, maintaining safe operation of the circuit. The sensing resistor (R11) plays a vital role in current measurement, providing necessary data for the operational amplifier to maintain the desired output current level.
The RCD clamp circuit is essential for protecting the MOSFET from voltage spikes that occur during the turn-off phase, which can be damaging if not properly managed. The Valley Fill circuit enhances the power factor and minimizes harmonic distortion, addressing the regulatory requirements for modern electronic devices.
Additionally, the frequency jittering function and the implementation of a shielded transformer winding contribute to EMI reduction, which is increasingly important in densely packed electronic environments. The pi filter further cleanses the output, ensuring compliance with stringent electromagnetic compatibility (EMC) standards.
This design exemplifies a robust and efficient approach to driving high-intensity LEDs, suitable for applications requiring reliable and consistent lighting performance while adhering to regulatory standards for harmonic distortion and electromagnetic interference.The converter shown uses a member of the TinySwitch-III family (U2, a TNY279PN) to provide up to 1. 8 A of load current to six, high-intensity, Luxeon LEDs (the LXHL series). The output voltage is slightly below the forward voltage drop of the LEDs Therefore, when the LEDs are connected to the supply, it operates in constant c urrent (CC) mode. If the LEDs are discon- nected from the supply, Zener Diode VR1 provides voltage feedback, which regulates the output voltage at about 13. 5 VDC. A 100 m © resistor (R11) senses the output current and an Opamp (U1) drives the Optocoupler (U3), which provides feedback to U2.
The TinySwitch-III family of devices regulate by disabling or skipping MOSFET switching cycles. As the load current reaches the current limit set-point threshold, U1 drives U3 on. The photo- Transistor in U3 pulls current out of the EN/UV pin of U2, causing it to skip switching cycles. Once the output current drops below the current limit set-point threshold, U1 stops driving U3, which stops pulling current out of the EN/UV pin of U2, and switching cycles are enabled again.
The TL431 (U4) provides a reference for U1 to compare against the voltage drop across R11. The output Diode (D9) is located in the lower leg of the transformer (T1) secondary winding to reduce EMI noise generation. An RCD clamp (R16, C4 and D13) protects the drain node of the MOSFET from the‚ flyback voltage spike.
The Valley Fill circuit (D5, D6, D7, C15, C16 and R15) limits the values of the third and fth harmonics of the line frequency current, which enables this supply to meet the requirements for Total Harmonic Distortion (THD) speci ed in IEC61000-3-2. The frequency jittering function in U2, a shield winding in T1 and a Y class capacitor (C8) across T1 reduce the generation of conducted EMI so that a simple pi lter (C13, L1, L2 and C14) allows the supply to meet EN55022B limits.
The circuit described operates as a highly efficient LED driver, leveraging the TinySwitch-III family’s capabilities for constant current regulation. The TNY279PN specifically is designed for off-line applications, featuring integrated high-voltage MOSFETs and a control circuit that allows for compact designs. The output current regulation is achieved through the feedback mechanism involving the operational amplifier and optocoupler, ensuring stable operation even under varying load conditions.
The use of a Zener diode for voltage feedback when the load is disconnected is a critical design feature that prevents overvoltage conditions, maintaining safe operation of the circuit. The sensing resistor (R11) plays a vital role in current measurement, providing necessary data for the operational amplifier to maintain the desired output current level.
The RCD clamp circuit is essential for protecting the MOSFET from voltage spikes that occur during the turn-off phase, which can be damaging if not properly managed. The Valley Fill circuit enhances the power factor and minimizes harmonic distortion, addressing the regulatory requirements for modern electronic devices.
Additionally, the frequency jittering function and the implementation of a shielded transformer winding contribute to EMI reduction, which is increasingly important in densely packed electronic environments. The pi filter further cleanses the output, ensuring compliance with stringent electromagnetic compatibility (EMC) standards.
This design exemplifies a robust and efficient approach to driving high-intensity LEDs, suitable for applications requiring reliable and consistent lighting performance while adhering to regulatory standards for harmonic distortion and electromagnetic interference.The converter shown uses a member of the TinySwitch-III family (U2, a TNY279PN) to provide up to 1. 8 A of load current to six, high-intensity, Luxeon LEDs (the LXHL series). The output voltage is slightly below the forward voltage drop of the LEDs Therefore, when the LEDs are connected to the supply, it operates in constant c urrent (CC) mode. If the LEDs are discon- nected from the supply, Zener Diode VR1 provides voltage feedback, which regulates the output voltage at about 13. 5 VDC. A 100 m © resistor (R11) senses the output current and an Opamp (U1) drives the Optocoupler (U3), which provides feedback to U2.
The TinySwitch-III family of devices regulate by disabling or skipping MOSFET switching cycles. As the load current reaches the current limit set-point threshold, U1 drives U3 on. The photo- Transistor in U3 pulls current out of the EN/UV pin of U2, causing it to skip switching cycles. Once the output current drops below the current limit set-point threshold, U1 stops driving U3, which stops pulling current out of the EN/UV pin of U2, and switching cycles are enabled again.
The TL431 (U4) provides a reference for U1 to compare against the voltage drop across R11. The output Diode (D9) is located in the lower leg of the transformer (T1) secondary winding to reduce EMI noise generation. An RCD clamp (R16, C4 and D13) protects the drain node of the MOSFET from the‚ flyback voltage spike.
The Valley Fill circuit (D5, D6, D7, C15, C16 and R15) limits the values of the third and fth harmonics of the line frequency current, which enables this supply to meet the requirements for Total Harmonic Distortion (THD) speci ed in IEC61000-3-2. The frequency jittering function in U2, a shield winding in T1 and a Y class capacitor (C8) across T1 reduce the generation of conducted EMI so that a simple pi lter (C13, L1, L2 and C14) allows the supply to meet EN55022B limits.
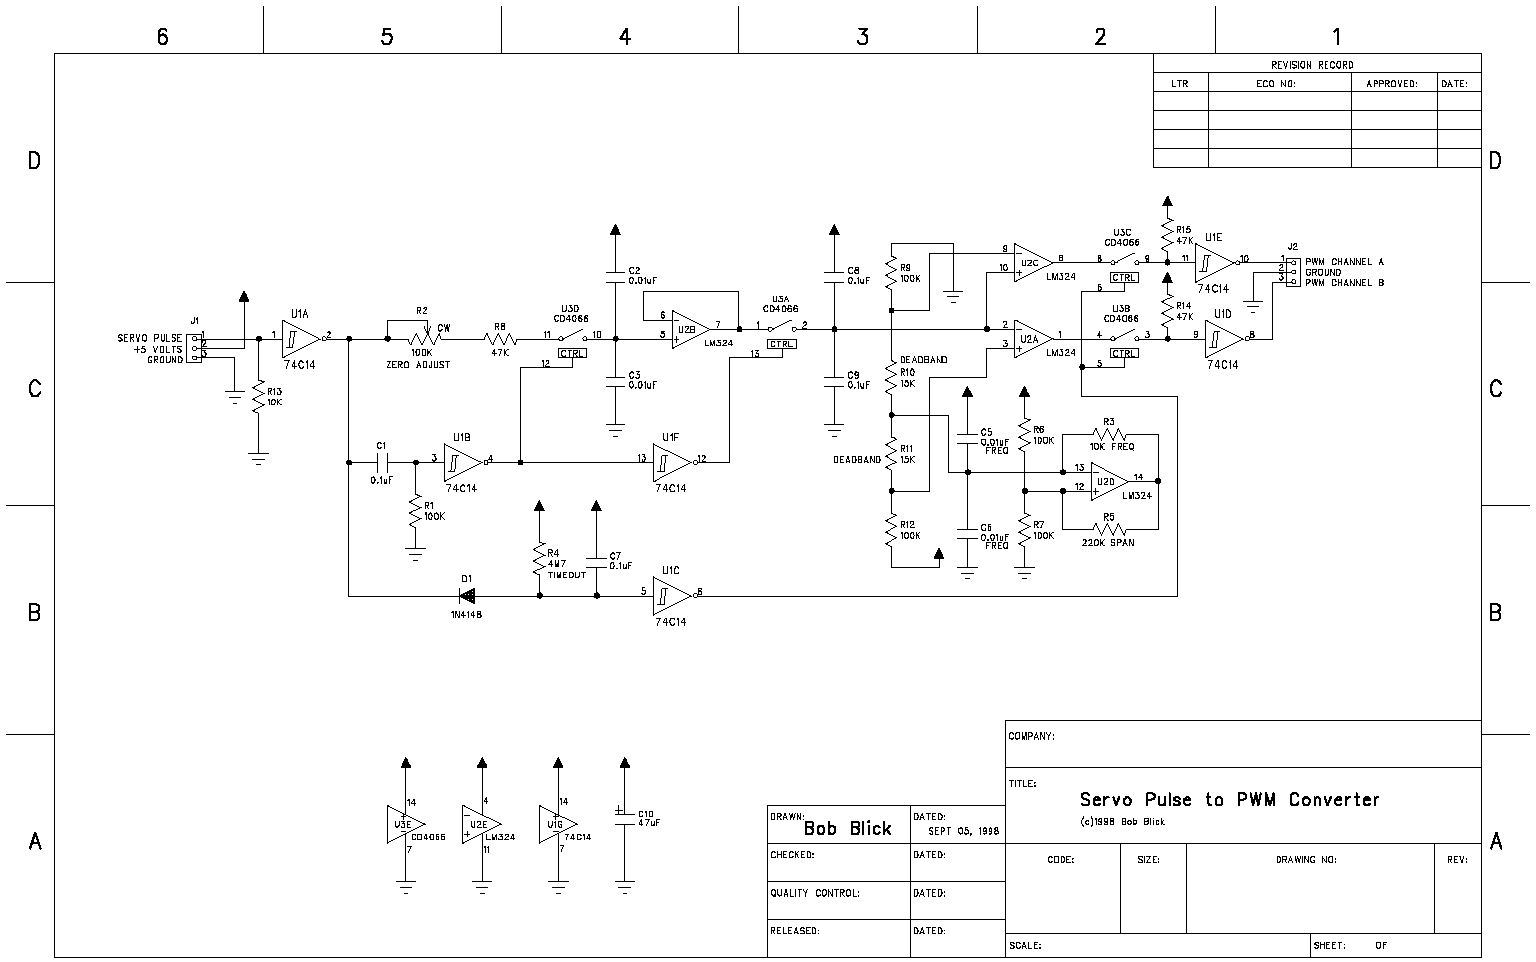
Servo pulse to PWM converter
The circuit presented on this page attempts to be an interface to convert pulses such as provided by a Basic Stamp or R/C receiver to a dual PWM (Pulse Width Modulation) signal required by an H-bridge. The simplest circuit would...
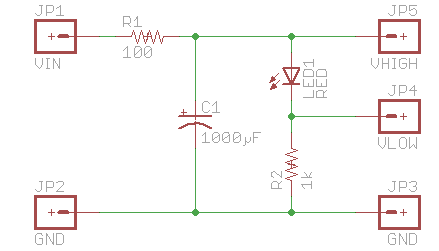
led discharge circuit
It is sufficient to explore PWM (Pulse Width Modulation) and digital-to-analog conversion, illustrating how to create a personal electronics workbench for investigating RC (Resistor-Capacitor) filters, charge and discharge curves, pulse generators, timers, and even a simple oscilloscope to understand the...
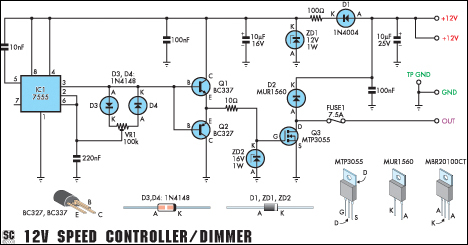
12v speed controllerdimmer
This versatile circuit functions as a speed controller for a 12V motor with a continuous rating of up to 5A or as a dimmer for a 12V halogen or standard incandescent lamp with a maximum rating of 50W. It adjusts...
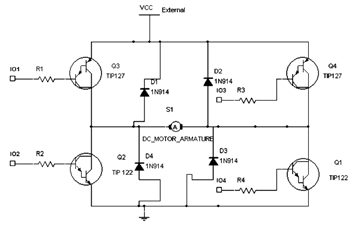
The H-Bridge Circuit Control Design in DC Motor Application
The diagram below illustrates an H-Bridge circuit featuring four inputs and an external power supply. The control application must enable the motor to operate in both forward and reverse directions.
The H-Bridge is a crucial component in motor control applications, allowing...
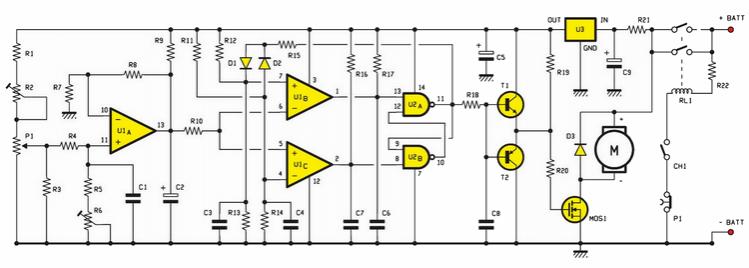
PWM circuit
An electric scooter and E-Bike PWM speed controller circuit has been constructed. However, the oscillator is not functioning as intended. The printed circuit board has been checked and is confirmed to be in good condition, including all resistors.
The electric scooter...
STHS Computer Technology
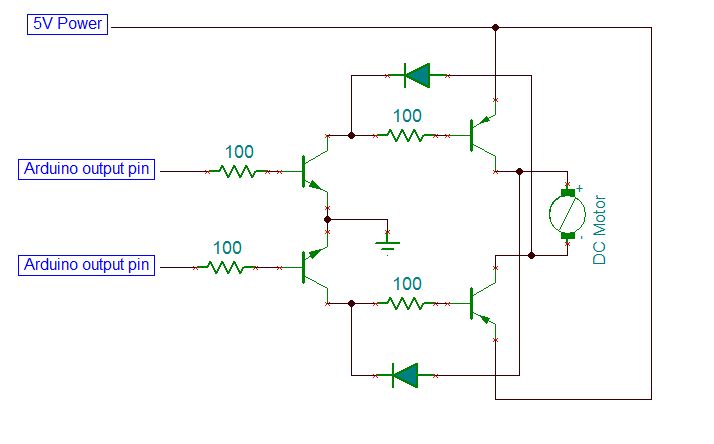
On the breadboard, construct two bi-directional motor control circuits, commonly referred to as "H-bridge" circuits. These circuits will manage the two DC motors that propel the wheels. Each circuit will have two wires connected to the Arduino (one for forward...
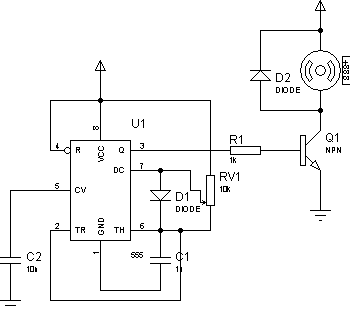
Control motor PWM schematic
There are two primary methods to control the speed of a DC motor: by varying the supply voltage and through pulse width modulation (PWM). The first method is less convenient, particularly in digital systems, as it necessitates the use of...
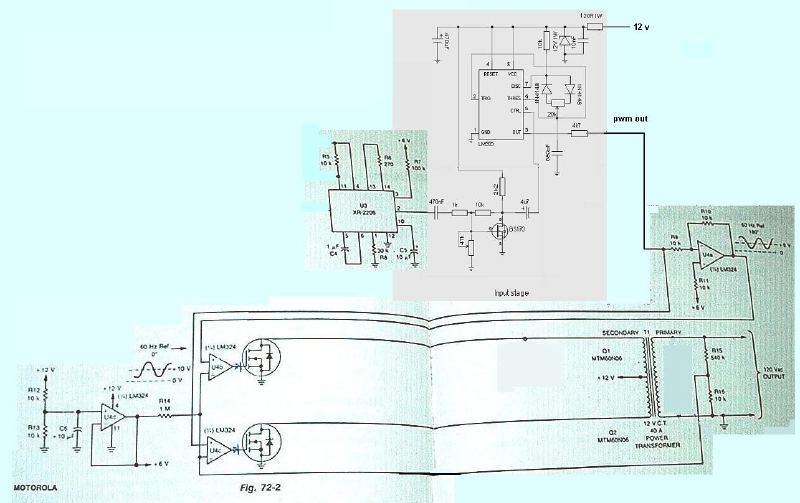
About a PWM power inverter
A few months ago, a search was conducted for an easy-to-build PWM inverter that does not require any PIC programming. The investigation led to a consideration of a 555 PWM amplifier circuit.
The 555 timer IC is widely used in various...
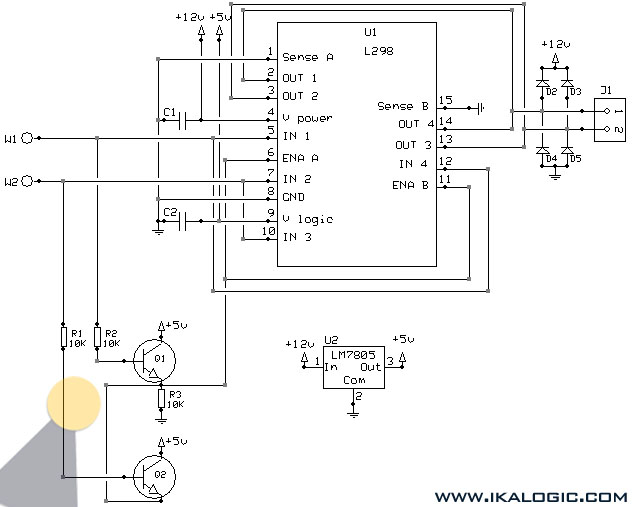
4A H-bridge motor driver using the L298 IC Schematic
This implementation utilizes the L298 integrated circuit to drive motors and inductive loads with a continuous current capacity of up to 4A. The L298 consists of two independent channels, each capable of driving loads of up to 2A. By connecting...