


STHS Computer Technology
#H-bridge
#DC motor
#Arduino
#bidirectional control
#motor driver
#breadboard
#PWM
#robotics
#wheel control
#microcontroller
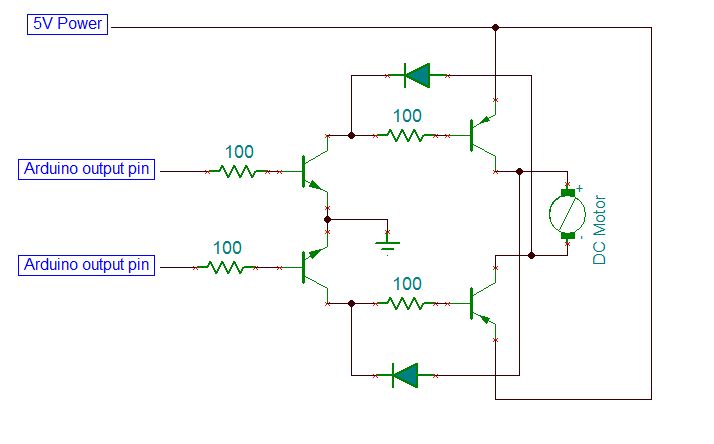
Description: On the breadboard, construct two bi-directional motor control circuits, commonly referred to as "H-bridge" circuits. These circuits will manage the two DC motors that propel the wheels. Each circuit will have two wires connected to the Arduino (one for forward movement and one for backward movement) to control the circuit, along with two wires connected to the respective DC motor being controlled. It is essential to test the circuits to confirm that both motors can be operated in both forward and reverse directions. A sample Arduino sketch is provided for testing the motors. The code should be modified to verify each motor's operation and direction, and the circuit should be inspected for any motor that does not perform as expected. Additionally, a schematic circuit diagram is available for one QRD line sensor connected to the Arduino. Since two sensors will be wired, the robot will be able to detect whether it is on the line, slightly off to the left, slightly off to the right, or completely off the line. It is important to test both QRD1114 sensors to ensure they are functioning correctly and sending accurate signals to the Arduino. A sample Arduino sketch is also provided for testing the circuits. Ensure that a good range of values is obtained from both sensors, differentiating between light and dark. Record the highest and lowest values obtained from each sensor, as the midpoint of these values will serve as the "cut off" or "threshold" value, which will be used to determine if the sensor detects the dark line.
To create an effective H-bridge circuit for controlling DC motors, it is essential to understand the basic configuration and operation of the components involved. An H-bridge consists of four switches (transistors or MOSFETs) arranged in an "H" shape, allowing current to flow in either direction through the motor, thus enabling forward and reverse rotation.
In this setup, the Arduino will control the H-bridge by sending signals to the gates of the transistors. When one pair of transistors is activated, the motor will rotate in one direction, while activating the other pair will reverse the motor's direction. The control signals can be generated using digital output pins from the Arduino, with one pin dedicated to each direction of the motor.
For the QRD line sensors, the circuit typically includes an infrared LED and a phototransistor. The LED emits infrared light, which reflects off the surface below it. The phototransistor detects the reflected light. When the sensor is over a dark line, less light is reflected, resulting in a lower signal at the phototransistor's output. Conversely, when the sensor is over a lighter surface, more light is reflected, yielding a higher output signal.
To ensure reliable operation, the Arduino must read the sensor values and establish a threshold. By determining the highest and lowest values from the sensors, the midpoint can be calculated and used as the threshold value. This threshold will allow the robot to make decisions based on the sensor readings, enabling it to follow the line accurately.
Testing of both the H-bridge circuits and the QRD line sensors is crucial. For the motors, the Arduino sketch should be modified to test each motor's functionality in both directions, ensuring proper operation. For the QRD sensors, the Arduino should continuously read values and compare them against the established threshold to maintain accurate line following behavior. Proper calibration and testing will ensure the robot performs as intended, effectively navigating its environment.On the breadboard, build two bi-directional motor control circuits (also known as "H-bridge") circuits. These circuits will control the two DC motors that drive the wheels. Each circuit will have two wires from the Arduino (one for forward, one for backward) to control the circuit, and two wires from the single DC motor that it is controlling.
You should test your circuits to ensure you can control both motors in both forward and reverse directions. Here is a sample Arduino sketch you can use to test the motors. Edit the code to check each motor and direction, and double-check the circuit for any motor that doesn`t behave as expected.
Here`s the schematic circuit diagram of one QRD line sensor connected to the Arduino. You will be wiring two of these, so your robot can tell whether it is on the line, off a little bit to the left, off a little bit to the right, or completely off the line. Now test that both QRD1114`s are operating correctly, and sending a proper signal to the Arduino. Here is a sample Arduino sketch to test the circuits. Make sure you are getting a good range of values from both sensors between light and dark. Make a not of the highest and lowest values you get from each sensor. You will use a value half way in between these for your "cut off" or "threshold" value. This is the boundary value we`ll use to decide if the sensor is seeing the dark line or not.
To create an effective H-bridge circuit for controlling DC motors, it is essential to understand the basic configuration and operation of the components involved. An H-bridge consists of four switches (transistors or MOSFETs) arranged in an "H" shape, allowing current to flow in either direction through the motor, thus enabling forward and reverse rotation.
In this setup, the Arduino will control the H-bridge by sending signals to the gates of the transistors. When one pair of transistors is activated, the motor will rotate in one direction, while activating the other pair will reverse the motor's direction. The control signals can be generated using digital output pins from the Arduino, with one pin dedicated to each direction of the motor.
For the QRD line sensors, the circuit typically includes an infrared LED and a phototransistor. The LED emits infrared light, which reflects off the surface below it. The phototransistor detects the reflected light. When the sensor is over a dark line, less light is reflected, resulting in a lower signal at the phototransistor's output. Conversely, when the sensor is over a lighter surface, more light is reflected, yielding a higher output signal.
To ensure reliable operation, the Arduino must read the sensor values and establish a threshold. By determining the highest and lowest values from the sensors, the midpoint can be calculated and used as the threshold value. This threshold will allow the robot to make decisions based on the sensor readings, enabling it to follow the line accurately.
Testing of both the H-bridge circuits and the QRD line sensors is crucial. For the motors, the Arduino sketch should be modified to test each motor's functionality in both directions, ensuring proper operation. For the QRD sensors, the Arduino should continuously read values and compare them against the established threshold to maintain accurate line following behavior. Proper calibration and testing will ensure the robot performs as intended, effectively navigating its environment.On the breadboard, build two bi-directional motor control circuits (also known as "H-bridge") circuits. These circuits will control the two DC motors that drive the wheels. Each circuit will have two wires from the Arduino (one for forward, one for backward) to control the circuit, and two wires from the single DC motor that it is controlling.
You should test your circuits to ensure you can control both motors in both forward and reverse directions. Here is a sample Arduino sketch you can use to test the motors. Edit the code to check each motor and direction, and double-check the circuit for any motor that doesn`t behave as expected.
Here`s the schematic circuit diagram of one QRD line sensor connected to the Arduino. You will be wiring two of these, so your robot can tell whether it is on the line, off a little bit to the left, off a little bit to the right, or completely off the line. Now test that both QRD1114`s are operating correctly, and sending a proper signal to the Arduino. Here is a sample Arduino sketch to test the circuits. Make sure you are getting a good range of values from both sensors between light and dark. Make a not of the highest and lowest values you get from each sensor. You will use a value half way in between these for your "cut off" or "threshold" value. This is the boundary value we`ll use to decide if the sensor is seeing the dark line or not.
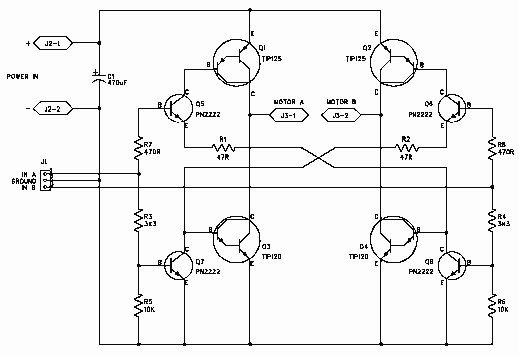
H-Bridge
H-Bridge
This circuit drives small DC motors up to about 100 watts or 5 amps or 40 volts, whichever comes first. Using bigger parts could make it more powerful. Using a real H-bridge IC makes sense for this size of motor,...
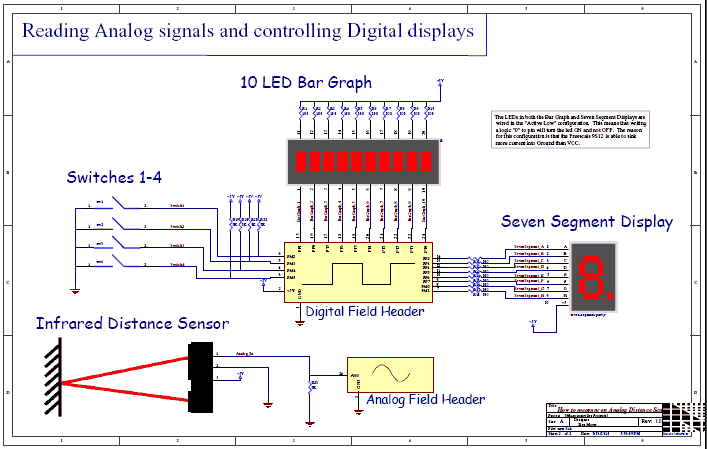
Arduino Differential Controller
Faulty readings from the DS18B20 temperature sensors used in tank thermometers were likely caused by the waterproofing method involving heat shrink and silicone. This situation provided an opportunity to enhance the code for better tolerance against erroneous readings. The tank...
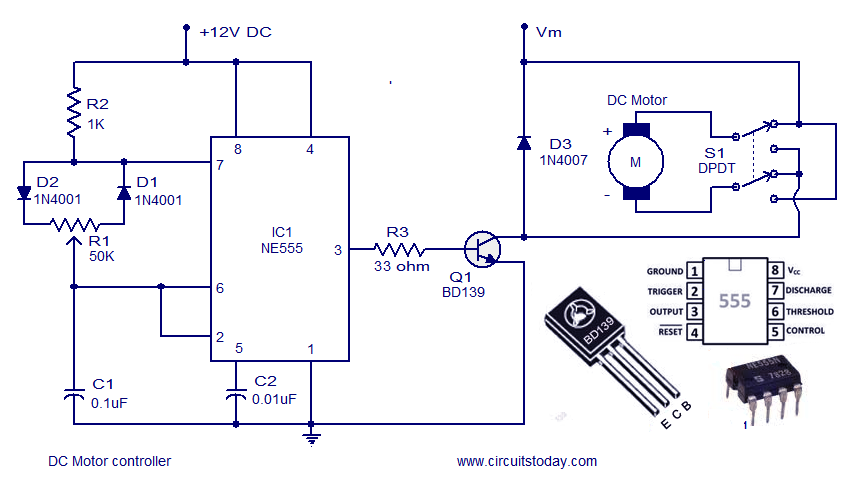
Dc motor speed controller circuit using NE555
A DC motor controller based on an NE555 timer is presented here. The direction of rotation of the DC motor can also be changed using this DC motor speed control circuit.
The described circuit utilizes the NE555 timer IC in astable...
PWM Speed Control Circuit Using Forward-Reverse and Regenerative Braking
This is a circuit design for a PWM speed control circuit for DC motor rotation. The circuit features two functions: Forward-Reverse operation and Regenerative Braking. The control is achieved using a MOSFET. The circuit allows for the control of a...
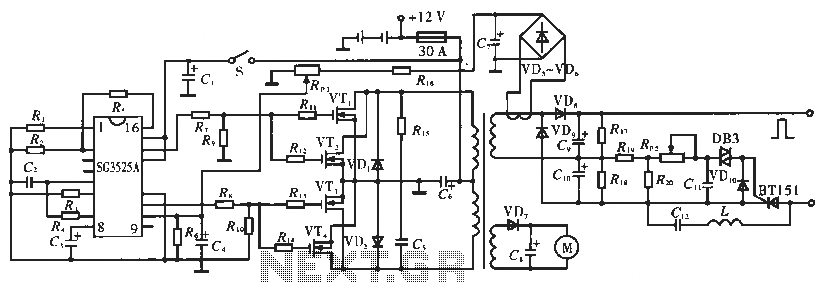
Electronic pulse circuitry fishing
The circuit utilizes the SC3525A, a PWM silicon chip from US General Semiconductor. It features an error amplifier with an inverting input at pin 1. Pin 2 serves as the non-inverting input for the error amplifier. Pins 5 and 6...
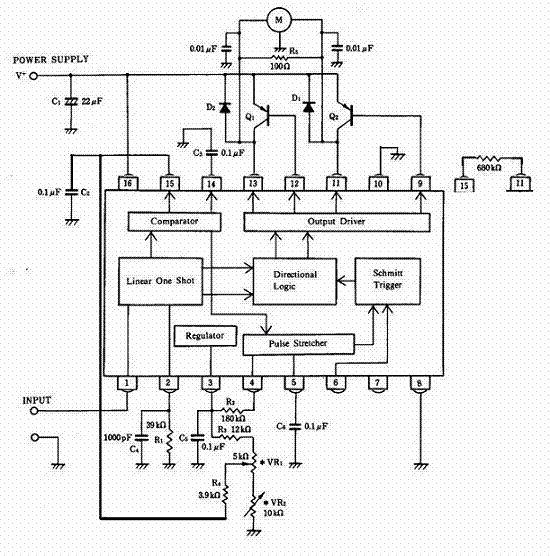
Dome Drive Schematic
A few modifications have been made to the dead band and pulse stretcher resistors, and the position feedback potentiometer has been altered to function as a "zero the speed" or "center your transmitter sticks." Additionally, a traditional PNP-NPN H-bridge has...
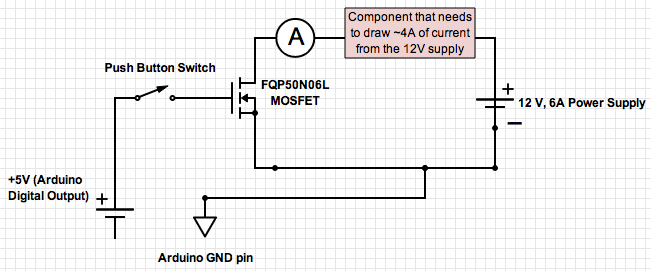
arduino Circuit with switching MOSFET not working
If the ground of the Arduino is disconnected from the negative terminal of the power supply, current flows through the MOSFET, even when the switch is not closed.
In an electronic circuit involving an Arduino and a MOSFET, maintaining a common...
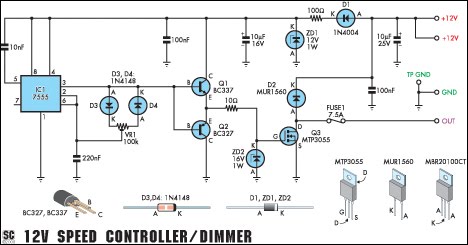
12V Speed Controller/Dimmer
This circuit serves as a speed controller for a 12V motor with a continuous rating of up to 5A or as a dimmer for a 12V halogen or standard incandescent lamp rated up to 50W. It regulates power to the...
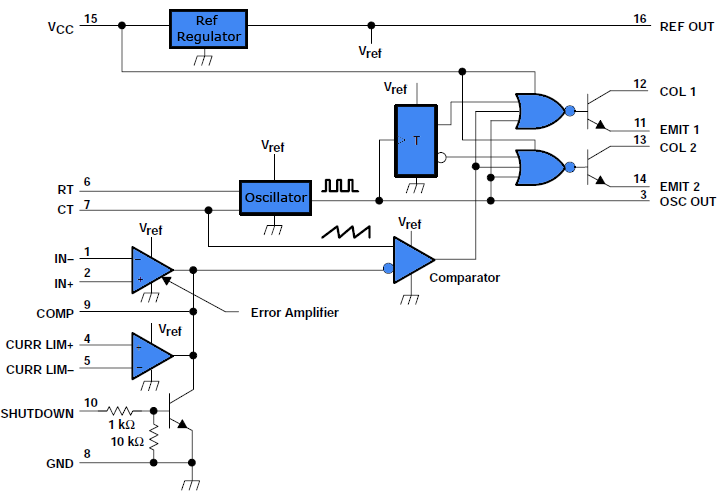
Simple PWM inverter circuit diagram using PWM chip SG3524
This document outlines a simple PWM (Pulse Width Modulation) DC to AC voltage inverter circuit based on the SG3524 integrated circuit. The SG3524 is a fixed frequency PWM voltage regulator control circuit that offers indifferent outputs suitable for both single-ended...