


The "BEAM Stepper" drive circuit
#stepper motor
#74AC240
#driver circuit
#square wave oscillator
#bipolar stepper
#buffer
#motor control
#electronics
#circuit design
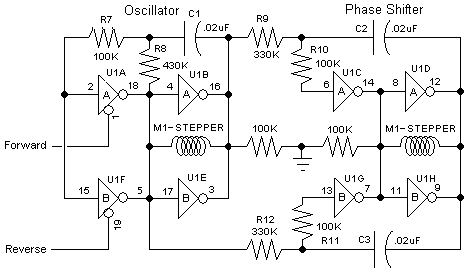
Description: The 74AC240 stepper driver works by alternately enabling each half of the buffer. Only one half can be enabled at a time.
Let’s assume that the top half of the driver is enabled. U1A & U1B along with R8, C1, and the input protection resistor R7 form a square wave oscillator. The outputs of U1A & U1B directly drive one coil of a bipolar stepper motor. More: The "BEAM Stepper" drive circuit A Duane C Johnson / Wilf Rigter joint effort Duane Johnson and Wilf Rigter came up with this interesting 74AC240-based circuit to drive small bipolar stepper motors (e.g., the ones in floppy drives): The 7
The 74AC240 is a high-speed hex buffer/driver with three-state outputs, primarily used in digital circuits for driving loads. In this specific application as a stepper motor driver, the circuit utilizes the device's capability to produce square wave signals that control the motor's coils. The configuration involves enabling either the upper or lower half of the buffer, allowing for a controlled sequence of energizing the motor coils, which is essential for stepper motor operation.
When the top half of the buffer (U1A and U1B) is activated, it generates an oscillating signal facilitated by the components R8 and C1, which form an RC timing circuit. This arrangement effectively creates a square wave oscillator that toggles at a specific frequency, determined by the values of R8 and C1. The input protection resistor R7 ensures that the inputs to the buffer are safeguarded against voltage spikes, thus enhancing the reliability of the circuit.
The outputs from U1A and U1B are connected directly to one of the coils of the bipolar stepper motor. As the square wave oscillates, it alternates the current through the motor coil, causing the motor to step in precise increments. The design is particularly effective for small bipolar stepper motors, such as those found in floppy drives, where precise control over position and speed is necessary.
The collaboration between Duane C. Johnson and Wilf Rigter has resulted in a practical and efficient circuit for controlling stepper motors using the 74AC240, demonstrating the versatility of this IC in various applications within the realm of robotics and automation. This circuit exemplifies the principles of digital electronics applied to motion control, showcasing how simple components can be combined to achieve complex tasks.The 74AC240 stepper driver works by alternately enabling each half of the buffer. Only one half can be enabled at a time. Let`s assume that the top half of the driver is enabled. U1A & U1B along with R8, C1, and the input protection resistor R7 form a square wave oscillator. The outputs of U1A & U1B directly drive one coil of a bipolar stepper motor. The "BEAM Stepper" drive circuit A Duane C Johnson / Wilf Rigter joint effort Duane Johnson and Wilf Rigter came up with this interesting 74AC240-based circuit to drive small bipolar stepper motors (e.g., the ones in floppy drives): The 7
Let’s assume that the top half of the driver is enabled. U1A & U1B along with R8, C1, and the input protection resistor R7 form a square wave oscillator. The outputs of U1A & U1B directly drive one coil of a bipolar stepper motor. More: The "BEAM Stepper" drive circuit A Duane C Johnson / Wilf Rigter joint effort Duane Johnson and Wilf Rigter came up with this interesting 74AC240-based circuit to drive small bipolar stepper motors (e.g., the ones in floppy drives): The 7
The 74AC240 is a high-speed hex buffer/driver with three-state outputs, primarily used in digital circuits for driving loads. In this specific application as a stepper motor driver, the circuit utilizes the device's capability to produce square wave signals that control the motor's coils. The configuration involves enabling either the upper or lower half of the buffer, allowing for a controlled sequence of energizing the motor coils, which is essential for stepper motor operation.
When the top half of the buffer (U1A and U1B) is activated, it generates an oscillating signal facilitated by the components R8 and C1, which form an RC timing circuit. This arrangement effectively creates a square wave oscillator that toggles at a specific frequency, determined by the values of R8 and C1. The input protection resistor R7 ensures that the inputs to the buffer are safeguarded against voltage spikes, thus enhancing the reliability of the circuit.
The outputs from U1A and U1B are connected directly to one of the coils of the bipolar stepper motor. As the square wave oscillates, it alternates the current through the motor coil, causing the motor to step in precise increments. The design is particularly effective for small bipolar stepper motors, such as those found in floppy drives, where precise control over position and speed is necessary.
The collaboration between Duane C. Johnson and Wilf Rigter has resulted in a practical and efficient circuit for controlling stepper motors using the 74AC240, demonstrating the versatility of this IC in various applications within the realm of robotics and automation. This circuit exemplifies the principles of digital electronics applied to motion control, showcasing how simple components can be combined to achieve complex tasks.The 74AC240 stepper driver works by alternately enabling each half of the buffer. Only one half can be enabled at a time. Let`s assume that the top half of the driver is enabled. U1A & U1B along with R8, C1, and the input protection resistor R7 form a square wave oscillator. The outputs of U1A & U1B directly drive one coil of a bipolar stepper motor. The "BEAM Stepper" drive circuit A Duane C Johnson / Wilf Rigter joint effort Duane Johnson and Wilf Rigter came up with this interesting 74AC240-based circuit to drive small bipolar stepper motors (e.g., the ones in floppy drives): The 7
driving stepper motor using uln2003
The simplest method to drive a stepper motor with a lower current rating is by utilizing the ULN2003. The ULN2003 consists of seven Darlington transistors and can handle up to 500mA per channel, with an internal voltage drop of approximately...
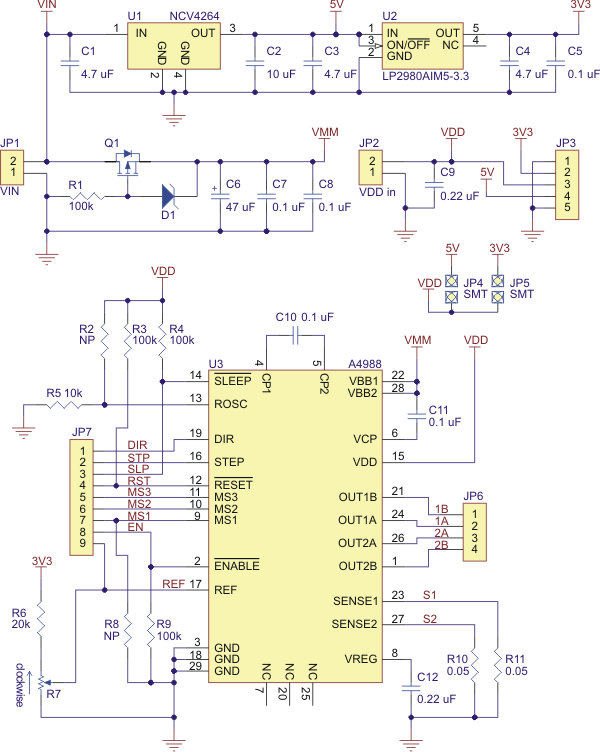
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
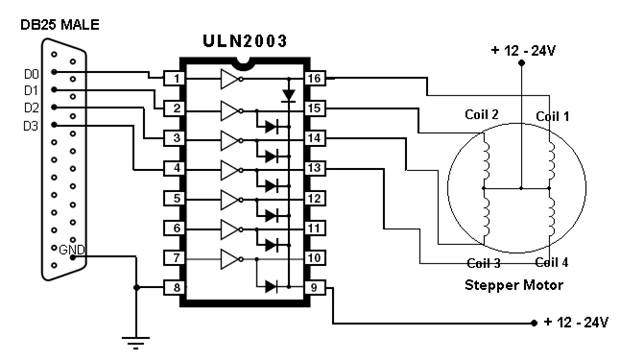
Computer Controlled Stepper Motor
This article outlines the process of connecting a stepper motor to a computer's parallel port and writing code to control it using the scroll wheel of a mouse. For those unfamiliar with stepper motors, this project offers an engaging introduction....
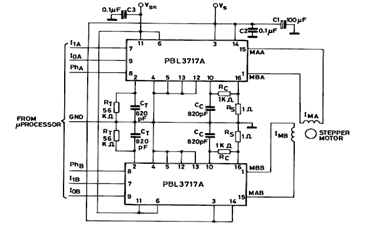
Two Phase Bipolar Stepper Motor Driver Circuit using PBL3717A
The diagram below illustrates a Two Phase Bipolar Stepper Motor Driver utilizing the PBL3717A. It depicts two PBL3717A integrated circuits (ICs) that control and drive two bipolar stepper motors.
The Two Phase Bipolar Stepper Motor Driver circuit is designed to efficiently...
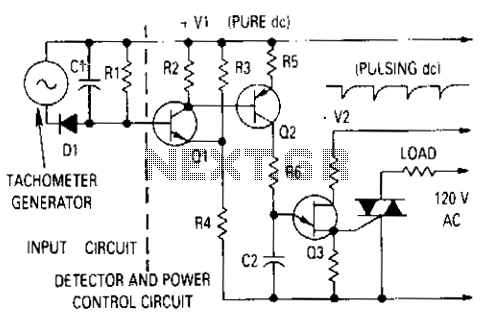
Motor control with tachometer
The generator output is rectified, filtered, and applied between the positive supply voltage and the base of the detector transistor. This configuration provides a negative voltage that reduces the base voltage as the speed increases. During normal operation, if the...
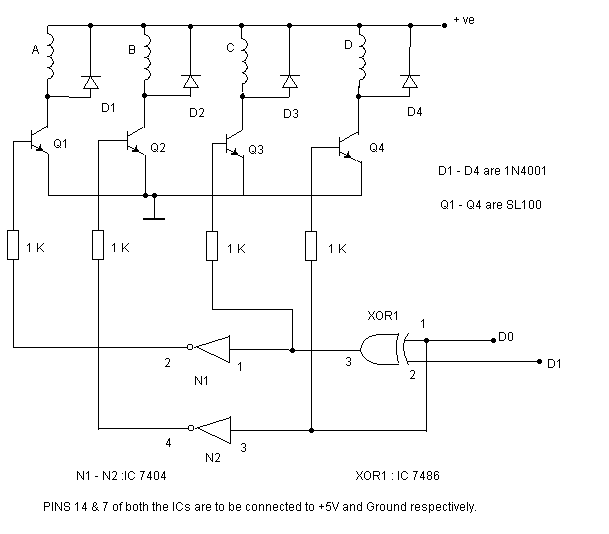
Simple stepper motor controller
The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils. The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100....
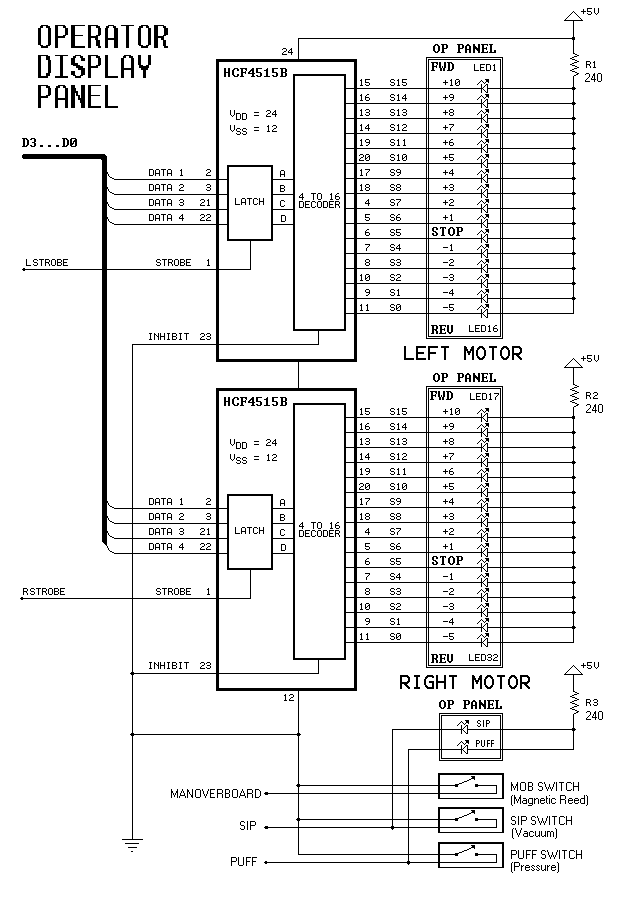
Dual-Motor SIP&PUFF Controlled Kayak System
The YouTube video below demonstrates the quick and easy setup of the system at the launch site.
The provided description indicates a focus on the efficiency of system installation at a launch site, as showcased in a YouTube video. In an...
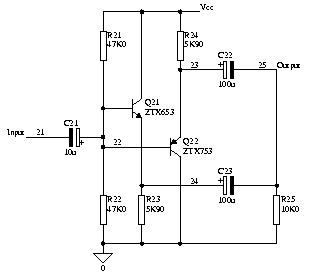
2 transistor buffer
When designed with general-purpose small-signal transistors, the bandwidth ranges from 50 MHz to 250 MHz, necessitating careful grounding and power supply decoupling. The simulation schematic illustrates a two-transistor buffer. Due to copyright issues, models from other sources are not included...
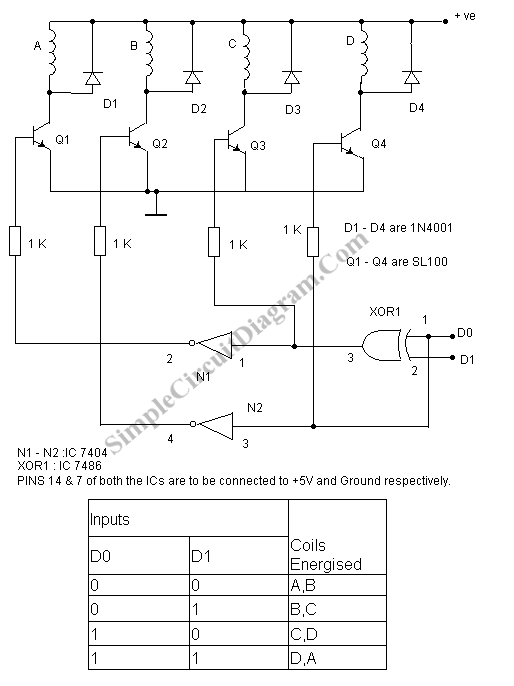
Stepper Motor Control No Microcontroller Needed
A stepper motor is an effective solution for achieving high-precision motion control. To operate a stepper motor, a corresponding control circuit is required.
A stepper motor control circuit typically consists of several key components that facilitate the precise movement of the...