


stepper motor question
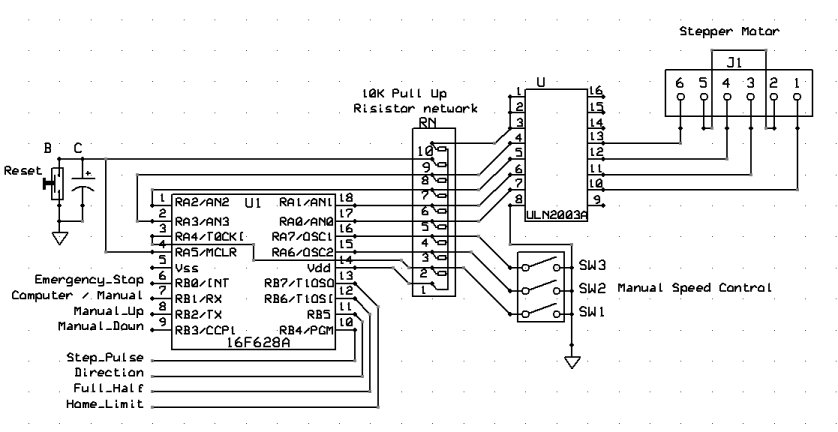
Description: The inquiry was focused not only on power consumption but also on the observation that some stepper motors have more wires than the standard four, while others are classified as bipolar.
Stepper motors are widely used in various applications due to their precision control and ability to maintain position without requiring feedback systems. The conventional four-wire stepper motors are typically unipolar, meaning they have a center tap connected to the power supply, allowing current to flow in one direction through each coil. This configuration enables simpler control circuits but limits the torque and efficiency compared to bipolar stepper motors.
Bipolar stepper motors, on the other hand, utilize two coils without a center tap. These motors require more complex control circuits, often involving an H-bridge configuration that allows current to flow in both directions through the coils. This design increases torque and efficiency, making bipolar motors suitable for applications that demand higher performance.
When examining stepper motors, the number of wires can indicate the motor type and its operational characteristics. For instance, a five-wire motor typically indicates a unipolar design with a common connection, while a six-wire motor can be either unipolar or bipolar, depending on how the coils are configured. Understanding these distinctions is crucial for selecting the appropriate motor for specific applications, as it impacts not only power consumption but also control complexity and performance.
In summary, the choice between unipolar and bipolar stepper motors is influenced by factors such as wiring configuration, power requirements, and desired performance characteristics. Proper analysis of these elements is essential for effective motor selection in electronic designs.The reason i was asking more so than just the power consumption was the fact that some stepper motors seem to have more wires than the four that i have and other stepper motors are called bipolar.
Stepper motors are widely used in various applications due to their precision control and ability to maintain position without requiring feedback systems. The conventional four-wire stepper motors are typically unipolar, meaning they have a center tap connected to the power supply, allowing current to flow in one direction through each coil. This configuration enables simpler control circuits but limits the torque and efficiency compared to bipolar stepper motors.
Bipolar stepper motors, on the other hand, utilize two coils without a center tap. These motors require more complex control circuits, often involving an H-bridge configuration that allows current to flow in both directions through the coils. This design increases torque and efficiency, making bipolar motors suitable for applications that demand higher performance.
When examining stepper motors, the number of wires can indicate the motor type and its operational characteristics. For instance, a five-wire motor typically indicates a unipolar design with a common connection, while a six-wire motor can be either unipolar or bipolar, depending on how the coils are configured. Understanding these distinctions is crucial for selecting the appropriate motor for specific applications, as it impacts not only power consumption but also control complexity and performance.
In summary, the choice between unipolar and bipolar stepper motors is influenced by factors such as wiring configuration, power requirements, and desired performance characteristics. Proper analysis of these elements is essential for effective motor selection in electronic designs.The reason i was asking more so than just the power consumption was the fact that some stepper motors seem to have more wires than the four that i have and other stepper motors are called bipolar.
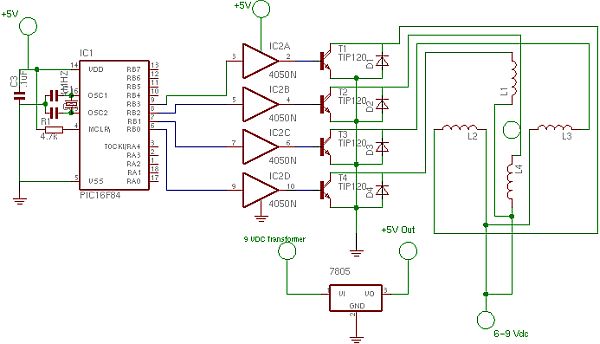
stepper motor controller using pic16f628a
Since completing the degree in April, there has been a pursuit for employment. The search has been gradual, but there is optimism for future financial success.
In the context of electronic schematics, the pursuit of employment can be likened to the...
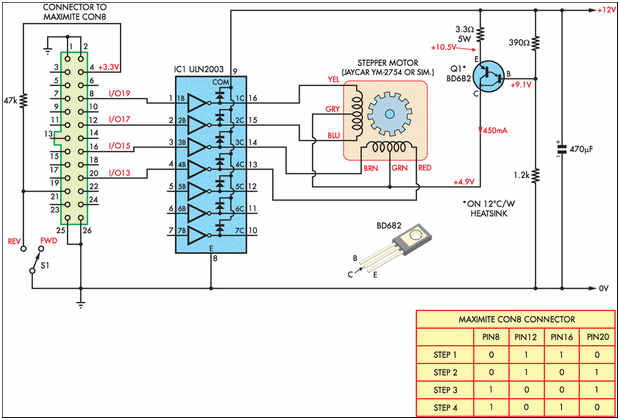
Rotate a stepper motor using a computer
Designing and implementing this circuit was an exciting endeavor. The design of the interface involved learning how to control a device from a computer. A parallel port cable was utilized for this purpose, enabling instant control of the stepper motor....
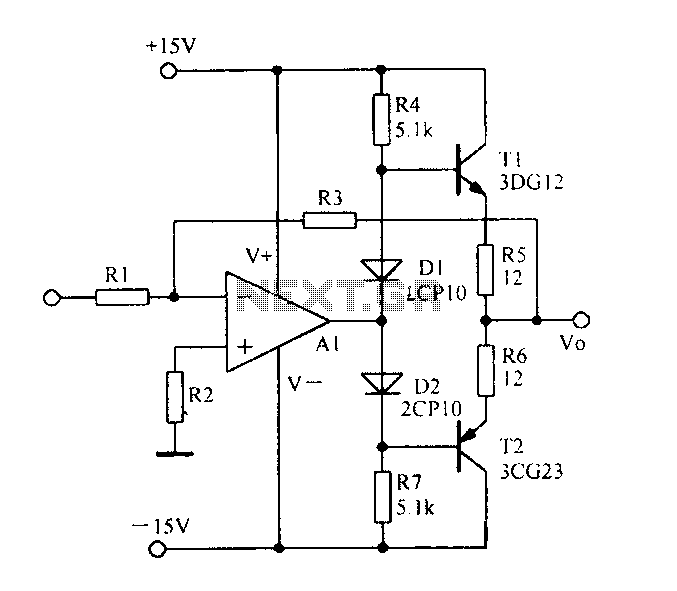
Current spreading circuit diagram of a bipolar output
Current spreading bipolar output when the circuit diagram is as follows.
The circuit described involves a current spreading bipolar output configuration. This type of circuit is typically used in applications requiring efficient current distribution across multiple output paths, often seen in...
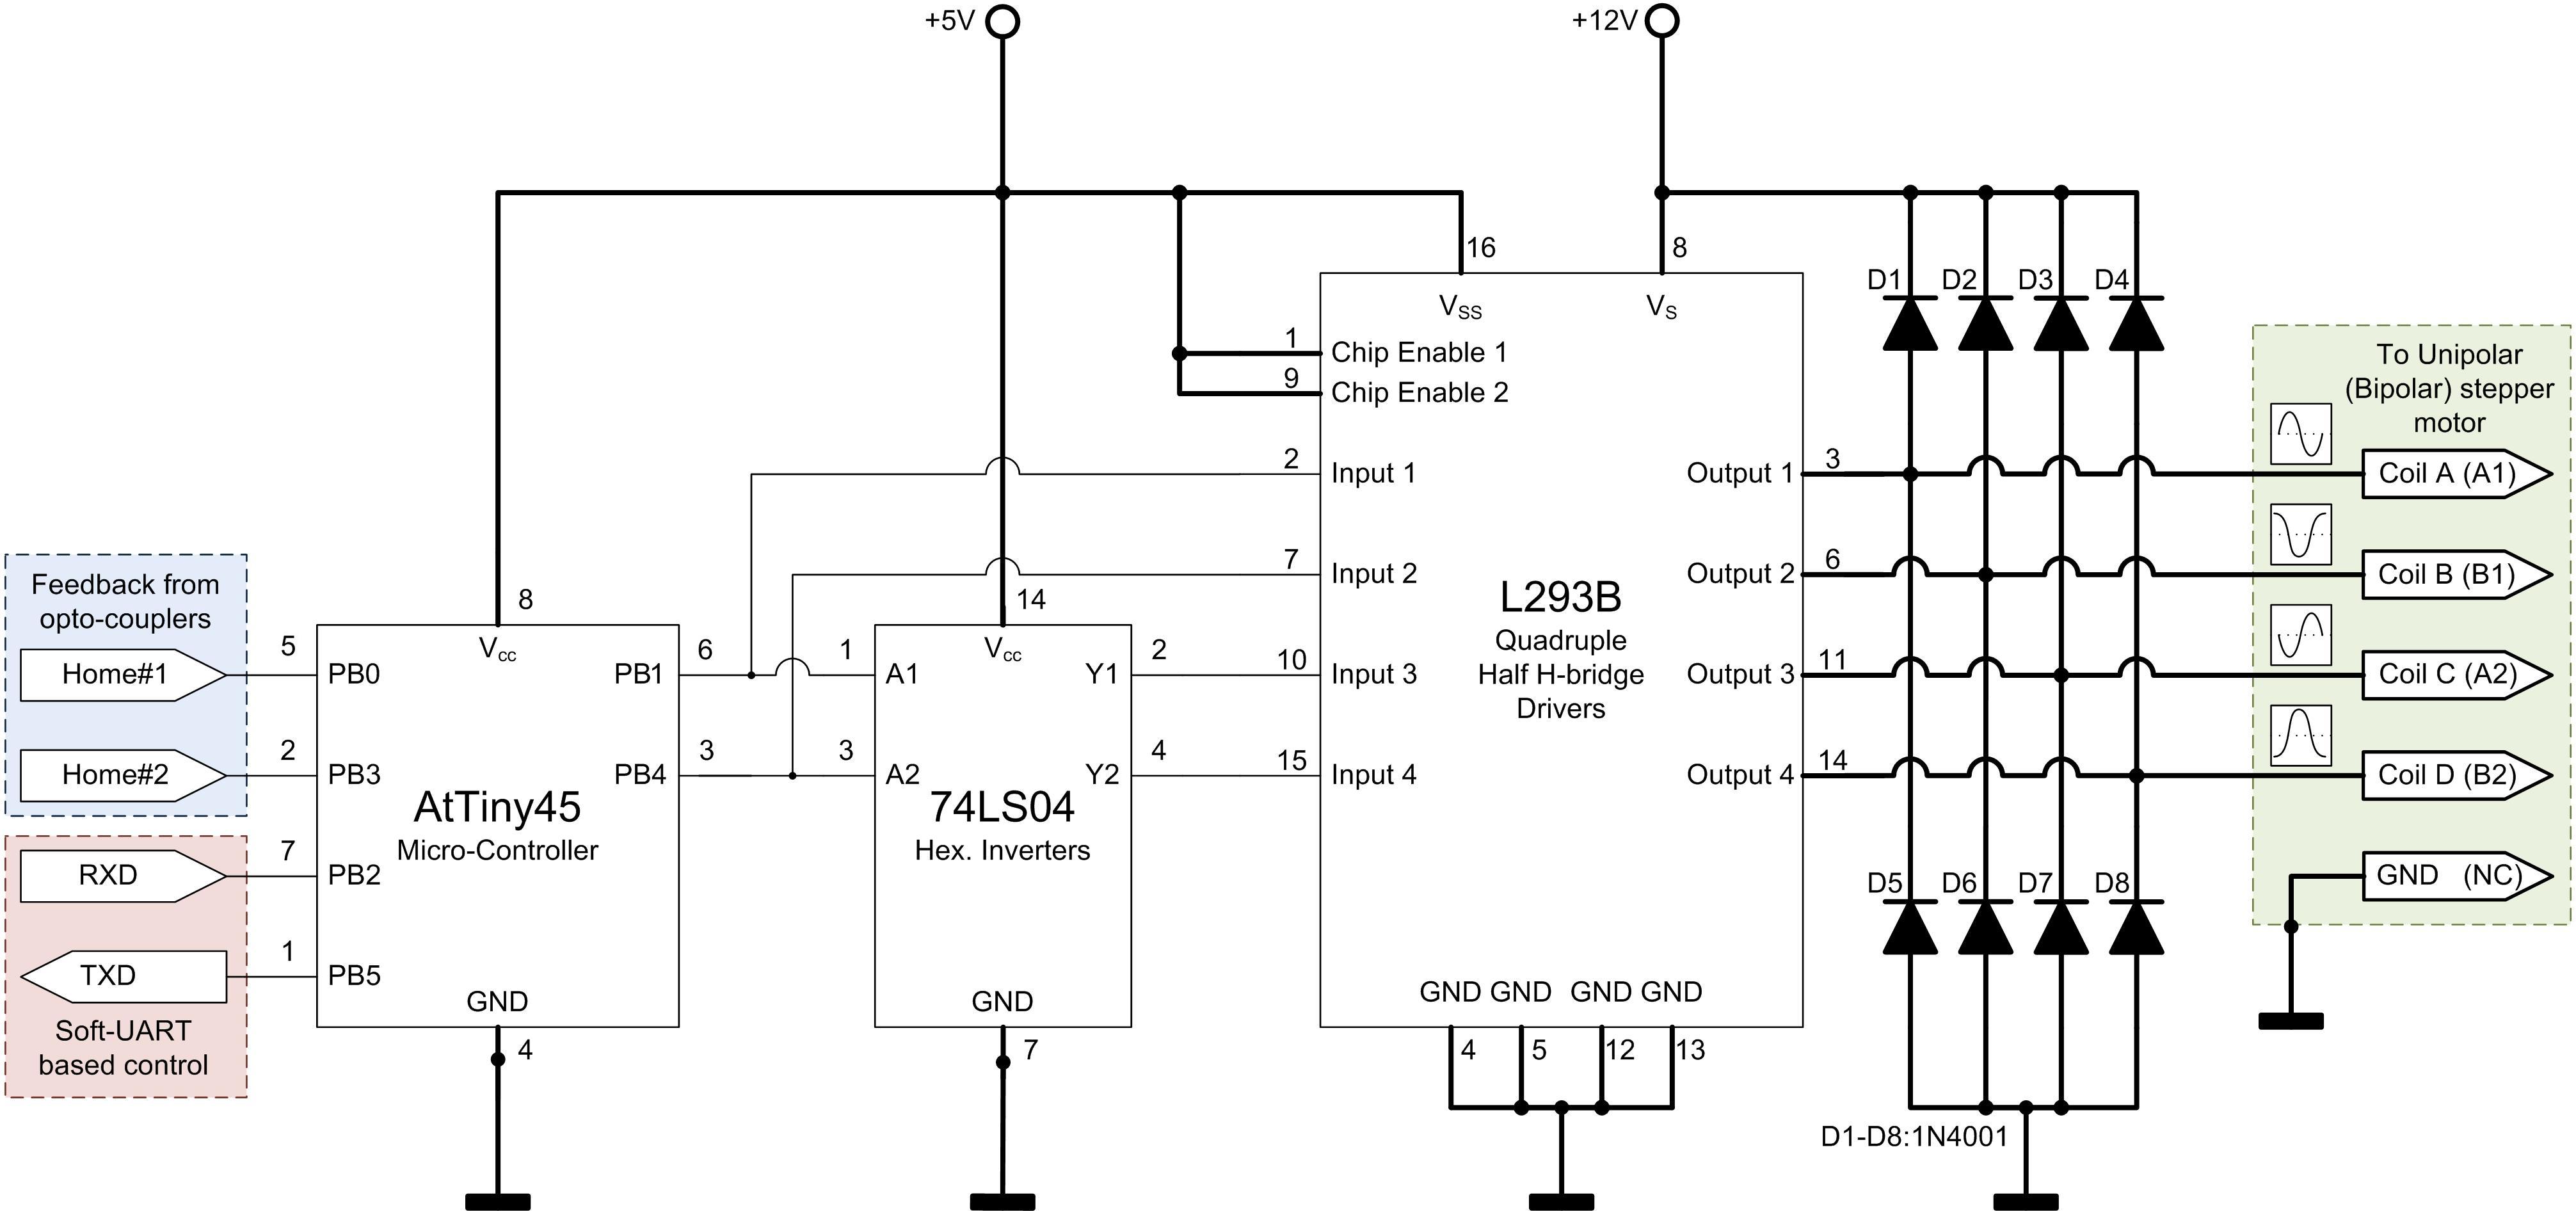
micro stepper
In a traditional microstepping motor controller, multiple parallel outputs from a microcontroller are utilized, which are then converted to analog signals using a Digital-to-Analog Converter (DAC) and sent through a power amplifier to drive the motor coils. This method is...
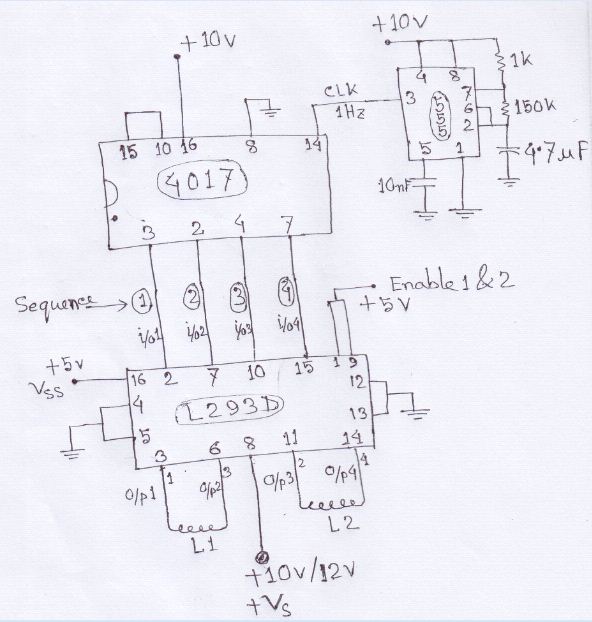
can rotate stepper motor
A stepper motor is to be rotated using a Johnson counter 4017 integrated circuit (IC). A bipolar stepper motor is utilized, with connections made from pins 3, 2, 4, and 7 of the 4017 IC following a specific sequence.
The circuit...
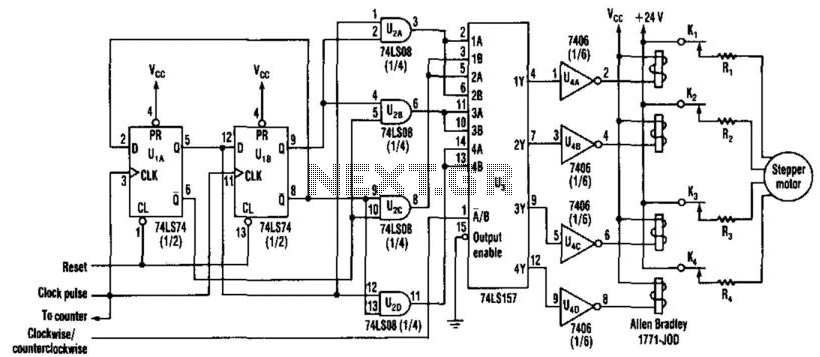
Stepper Motor Speed And Direction Controller
This new circuit utilizes four integrated circuits, with the option to operate with just three by combining the flip-flops and AND gates. The frequency of clock pulses dictates the revolutions per minute (RPM) of the motor. The circuit can enhance...
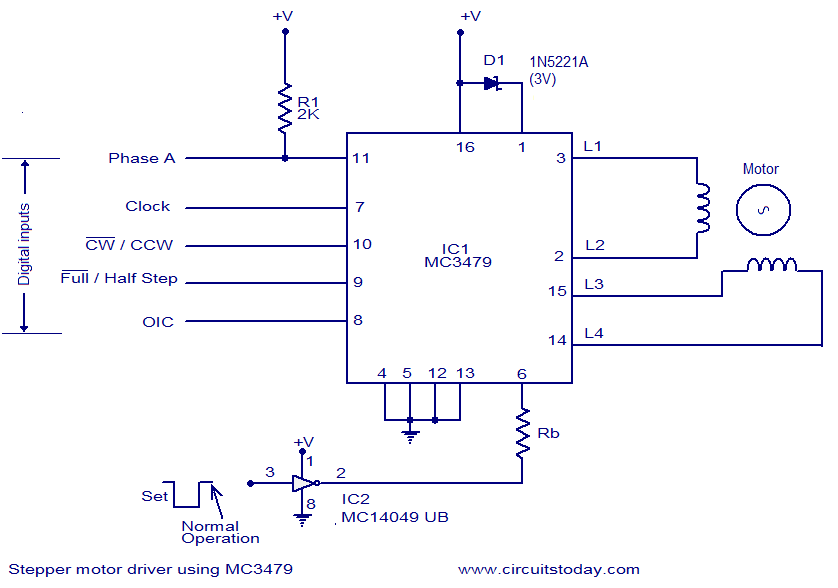
Stepper motor driver using MC3479
The circuit diagram presented is for a stepper motor driver utilizing the MC3479 integrated circuit from Motorola. The MC3479 is specifically engineered for driving a two-phase stepper motor in bipolar mode and is available in both standard DIP and surface...
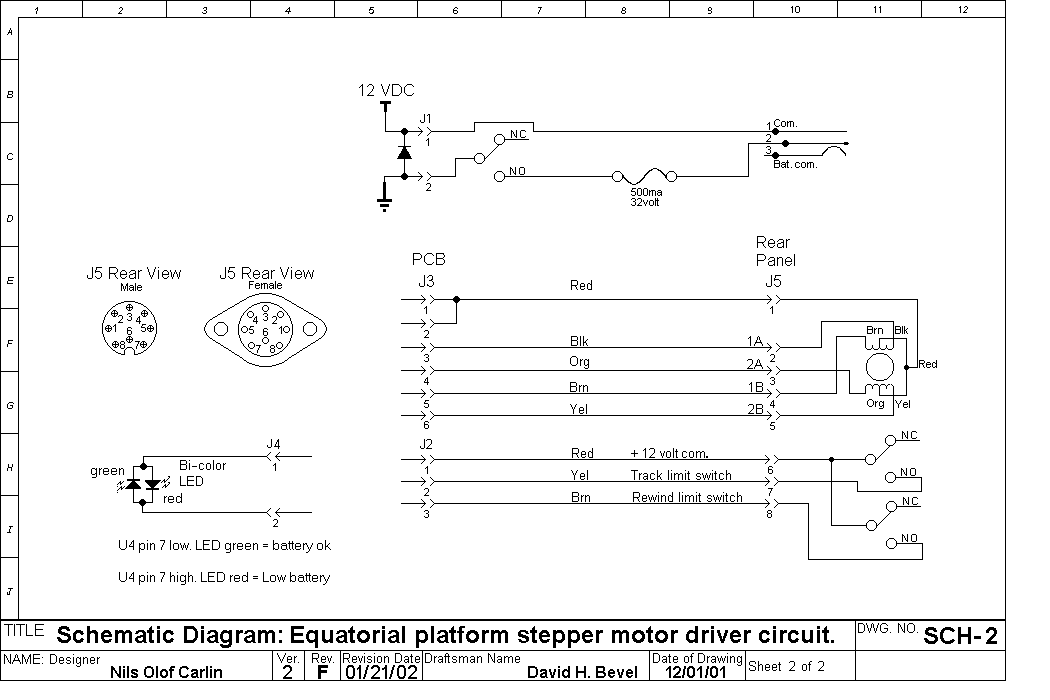
Stepper
The resistors R18 and R22, which were intended to be connected to pin 8 of U4, were incorrectly connected to pin 9. The current versions have been corrected. There is a minor error in the component layout where two versions...
STEPPER MOTOR DRIVER
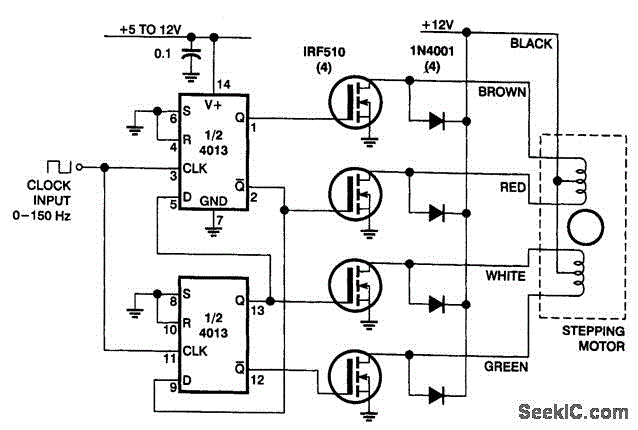
This circuit utilizes four IRF510 power FETs driven by a CMOS counter to produce the required two-phase drive quadrature. While integrated circuits (ICs) can perform this function, this method is beneficial for experimenters as it employs widely available components. The...