


can rotate stepper motor
#stepper motor
#4017 IC
#jonson counter
#bipolar stepper
#motor driver
#sequence control
#digital logic
#pulse control
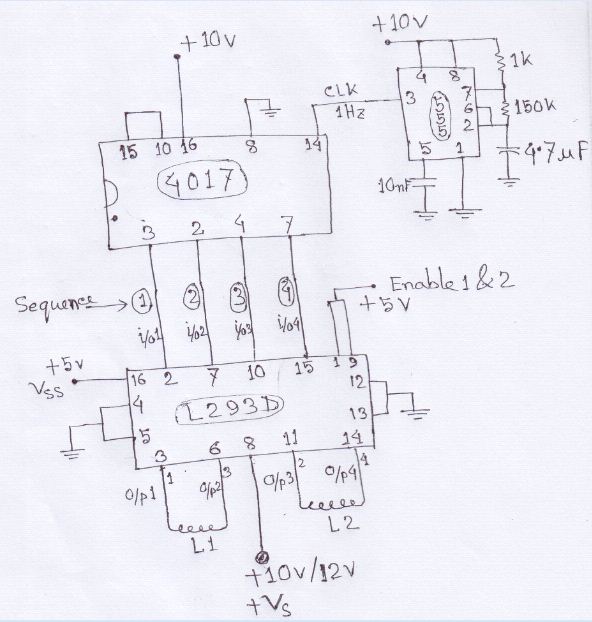
Description: A stepper motor is to be rotated using a Johnson counter 4017 integrated circuit (IC). A bipolar stepper motor is utilized, with connections made from pins 3, 2, 4, and 7 of the 4017 IC following a specific sequence.
The circuit design involves using the 4017 decade counter, which is a popular choice for controlling stepper motors due to its ability to sequentially activate outputs based on clock pulses. The Johnson counter configuration allows for efficient management of the bipolar stepper motor's phases, enabling precise control over its rotation.
In this setup, the bipolar stepper motor typically has four phases, which correspond to the four output pins being used from the 4017 IC. The motor phases are energized in a specific order to achieve smooth rotation. The output sequence from the 4017 IC can be arranged to activate pins 3, 2, 4, and 7 in a cyclic manner, effectively stepping the motor through its phases.
To implement this, a clock signal must be provided to the 4017 IC, which can be generated using a 555 timer configured in astable mode or any other suitable clock source. Each pulse from the clock will advance the counter, activating the next output pin in the sequence. This sequential activation will energize the corresponding windings of the bipolar stepper motor, causing it to rotate.
It is essential to ensure that the current ratings of the outputs from the 4017 IC are compatible with the stepper motor driver circuit, as the 4017 itself may not be able to directly drive the motor. A transistor or a dedicated stepper motor driver IC may be required to interface between the 4017 outputs and the motor windings, allowing for higher current handling and protection of the 4017 IC.
Overall, this configuration provides an effective method for controlling a bipolar stepper motor using a Johnson counter 4017 IC, allowing for precise rotational control and the ability to easily adjust the speed and direction of the motor by modifying the clock frequency or the sequence of output activation.I want to rotate stepper motor using jonson counter 4017 IC. I also using bipolar stepper motor. I connected pin 3 2 4 7 (sequence) of 4017ic with..
The circuit design involves using the 4017 decade counter, which is a popular choice for controlling stepper motors due to its ability to sequentially activate outputs based on clock pulses. The Johnson counter configuration allows for efficient management of the bipolar stepper motor's phases, enabling precise control over its rotation.
In this setup, the bipolar stepper motor typically has four phases, which correspond to the four output pins being used from the 4017 IC. The motor phases are energized in a specific order to achieve smooth rotation. The output sequence from the 4017 IC can be arranged to activate pins 3, 2, 4, and 7 in a cyclic manner, effectively stepping the motor through its phases.
To implement this, a clock signal must be provided to the 4017 IC, which can be generated using a 555 timer configured in astable mode or any other suitable clock source. Each pulse from the clock will advance the counter, activating the next output pin in the sequence. This sequential activation will energize the corresponding windings of the bipolar stepper motor, causing it to rotate.
It is essential to ensure that the current ratings of the outputs from the 4017 IC are compatible with the stepper motor driver circuit, as the 4017 itself may not be able to directly drive the motor. A transistor or a dedicated stepper motor driver IC may be required to interface between the 4017 outputs and the motor windings, allowing for higher current handling and protection of the 4017 IC.
Overall, this configuration provides an effective method for controlling a bipolar stepper motor using a Johnson counter 4017 IC, allowing for precise rotational control and the ability to easily adjust the speed and direction of the motor by modifying the clock frequency or the sequence of output activation.I want to rotate stepper motor using jonson counter 4017 IC. I also using bipolar stepper motor. I connected pin 3 2 4 7 (sequence) of 4017ic with..
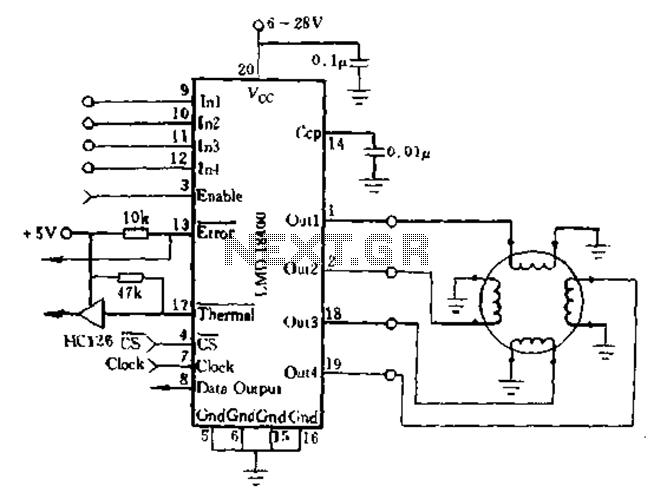
LMD18400 for four-phase stepper motor drive
The DMOS power switch exhibits an ON-state resistance with a positive temperature coefficient, allowing for the parallel connection of four switches to increase load current, resulting in a monolithic design. The LMD18400 can drive one, two, or four small DC...
Digital Electronics Education
The goal of Advanced Digital Electronics courses is to connect basic logic gates (combinational circuits) with technical subjects related to binary counter topologies (both Asynchronous and Synchronous), shift registers, memory, and Digital Signal Processors (DSP), which are categorized as sequential...
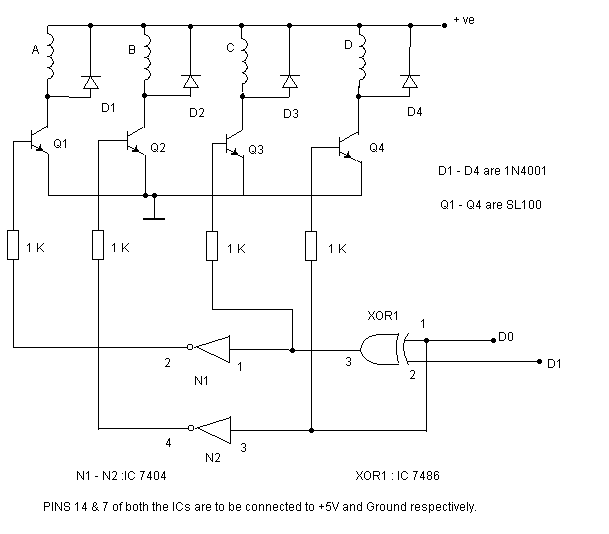
Simple stepper motor controller
The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils. The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100....
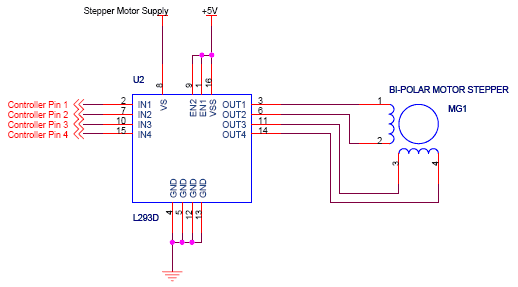
Stepper Motor Interface to Microcontroller
The circuit features four pins labeled "Controller pin 1," "Controller pin 2," "Controller pin 3," and "Controller pin 4," which are responsible for controlling the motion and direction of the stepper motor based on the step sequence programmed into the...
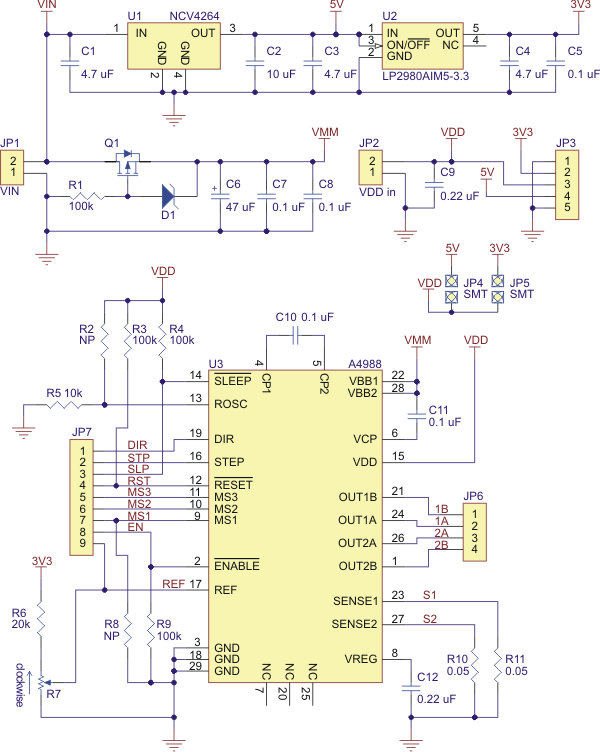
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...

Precise Camera Panning with Stepper Motors
The prototype circuit board utilized an external LCD display that received commands through an RS-232 interface. While this setup functioned adequately, programming it was cumbersome. Consequently, the circuit board was revised to support a directly attached LCD display. The image...
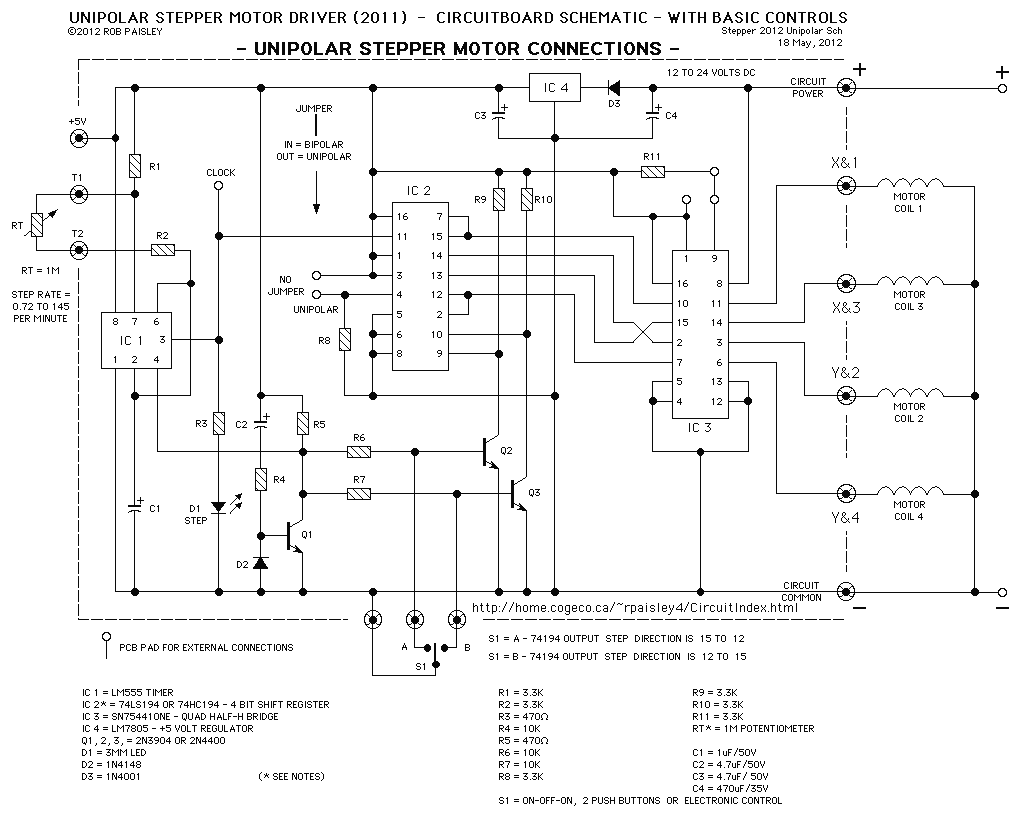
Stepper Motor Driver Circuit
The following diagram is for the main circuit of the motor driver. A testing version is shown near the end of this page. It is laid out differently and shows the SN7474 in logic block form and LEDs are used...
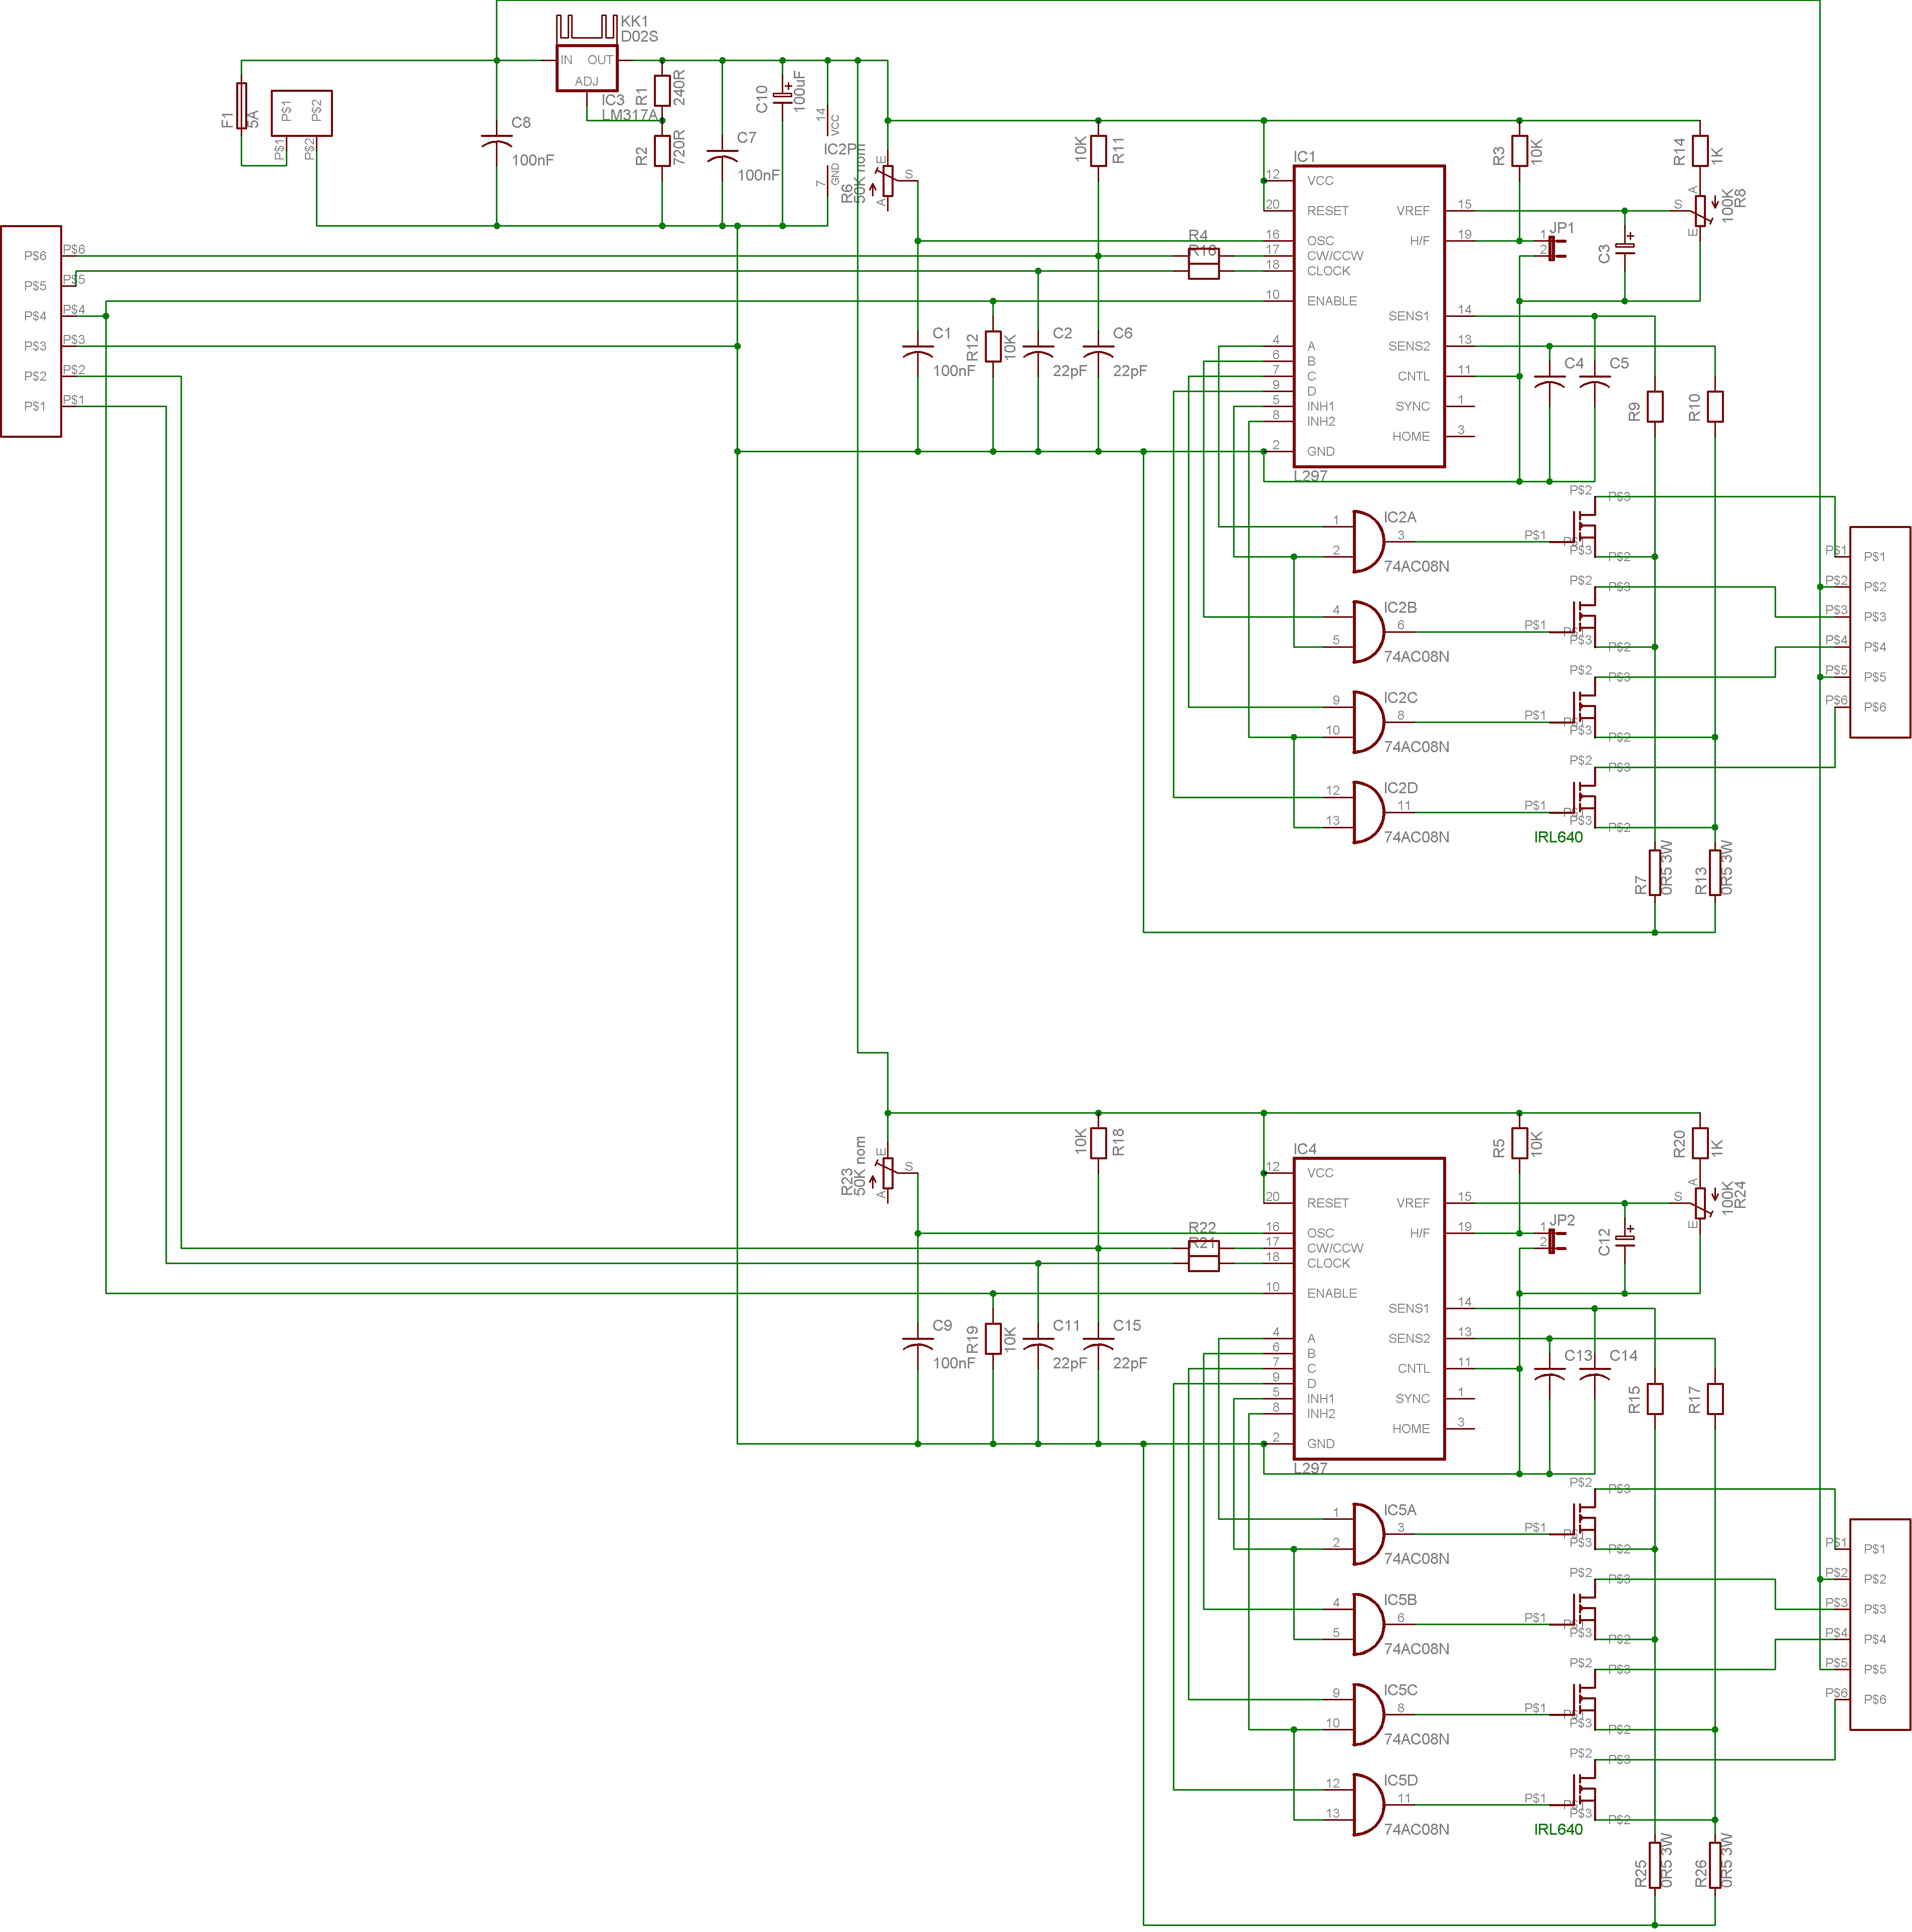
Unipolar Stepper Motor Driver
The objective of this project is to create a stepper motor driver for 2-phase unipolar stepper motors that incorporates built-in current control. This driver is intended for a CNC milling machine currently in the planning stage. Essential components must be...
Bipolar Stepper Motor Driver Circuit
The circuit operates by using a clock signal to drive four D-flip-flops in the control section, which store the on/off state of each current direction for the two stepper motor coils. The flip-flops create a finite state machine (FSM) that...