


Stepper motor getting very hot wrong driver or power supply
#stepper motor
#ULN2003A
#driver board
#power supply
#motor overheating
#Zener diode
#5-wire motor
#6-wire motor
#motor schematic
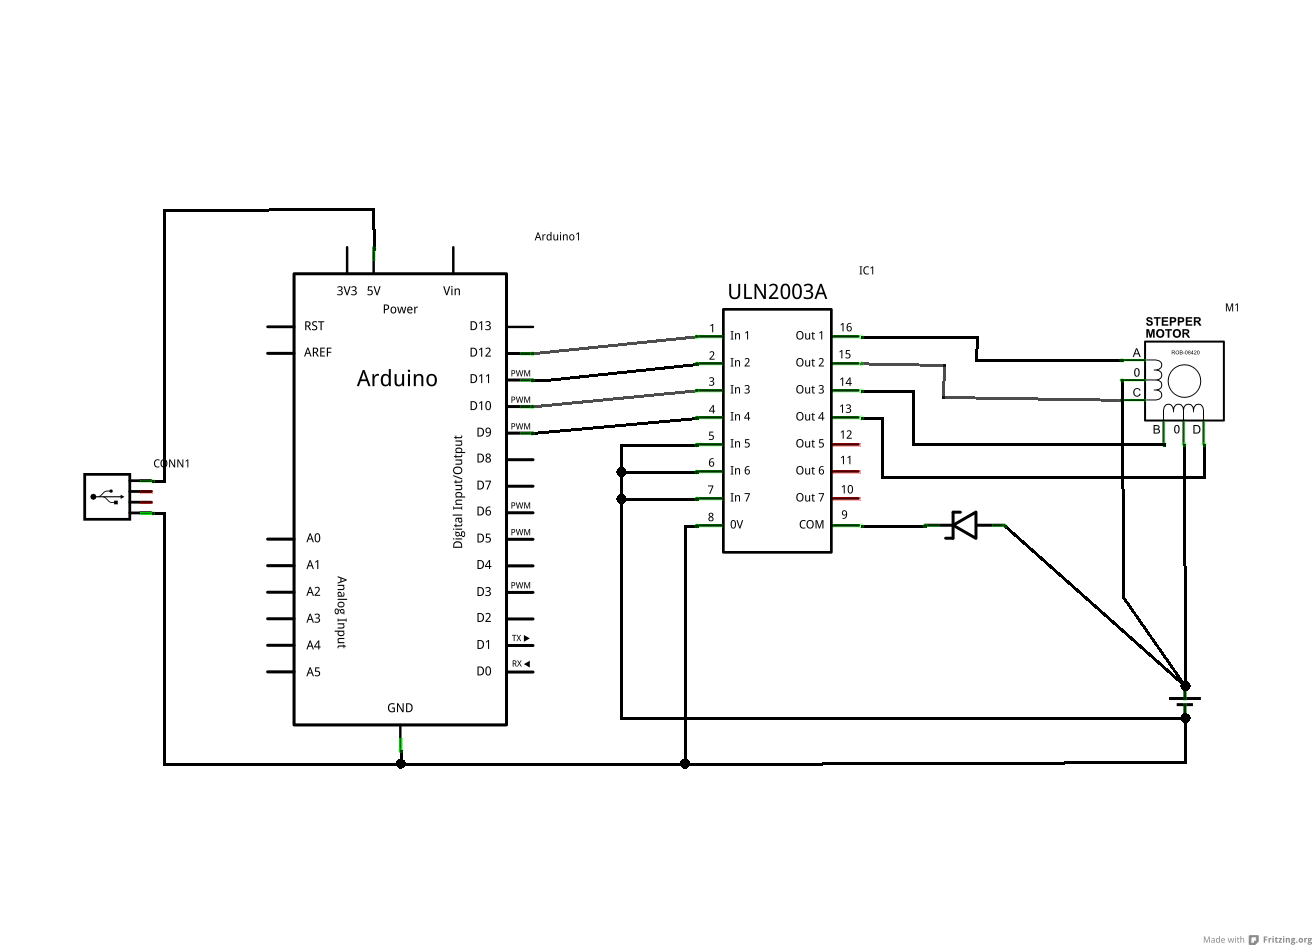
Description: The ULN2003A and Zener diode are components from the driver board within the same device. The motor in question has five wires, while the schematic depicts a six-wire motor. It is assumed that the difference lies in the fact that the two center taps of the five-wire version are connected together, which is reflected in the schematic. Although the motor operates well, it becomes excessively hot after approximately one minute of use. The temperature cannot be measured accurately, but it is painful to touch for more than half a second. To address this, the suggestion is to remove the Zener diode and replace it with a resistor and a 100µF 25V capacitor in series between COM and GND (COM -> R -> C -> GND). While the motor continues to run effectively, it still overheats. Questions arise regarding the Zener voltage, noting that the supply voltage should be lower than the Zener voltage. The resistance of the coil should be measured with an ohmmeter from the center tap to any connected phase. The supply current should also be assessed. For a 50-ohm coil, the maximum power per phase is calculated as V²/R = 144/50 = 2.9 watts. It is advised that no more than the equivalent of one phase be driven continuously. If the coil is 8 ohms, the power would be 122/8 = 18W, resulting in a current of I = V/R = 12/8 = 1.5A, which generates more heat than 3 watts. The 8-ohm version is designed for pulsed driving or with a series resistor.
The schematic indicates that each center-tapped winding behaves like two magnetically coupled inductors or two halves of a transformer winding. When the center tap is connected to V+ and one end is grounded, the other end attempts to rise to 2 x V+, minus the diode drop. Each driven output connects via a diode to COM (anode to driver, cathode to COM), which creates a scenario where driving the supply results in an attempt to achieve 2 x supply voltage. This leads to undesirable heating effects, as observed.
For optimal performance, if a 2 x V+ rail is available, connecting COM to that rail is recommended. This setup would provide a nearly ideal solution. Alternatively, connecting COM to a capacitor will yield a 2 x V+ supply. A Zener diode should be connected from COM to ground (with Vzener > 2 x Vsupply) or from COM to V+ (with Vzener > V+), ensuring that the Zener cathode is connected to COM in both cases. This arrangement allows COM to rise to 2 x V+ without the Zener conducting.
The combination of a capacitor and resistor serves to provide a load for inductive spikes and to load the transformer formed by the two halves of the winding. The resistor connected to the capacitor helps mitigate unwanted loading. A resistor to ground can drain the capacitor, and its dimensions should be adjusted as necessary.
To verify these assertions, a practical test can be conducted by either disconnecting COM (with a slight risk of damaging the ULN2003) or connecting it to V+ with the Zener as described. Monitoring COM with an oscilloscope or connecting a capacitor rated for more than 2 x V+ from COM to ground while operating the stepper motor can help measure the capacitor voltage. Voltages approaching 2 x V+ should be observable. A circuit that nearly achieves this functionality is noted, though it is important to ensure that the Zener diode polarity is correct; reversing the polarity allows the Zener to function properly, enabling COM to rise to V+ + Vzener.The ULN2003A and Zener from the driver board inside the same device. It`s a 5 wires motor, but the one in the schematic is 6 wires. I suppose the only difference is that the 5 wire version has the two center taps joined together so that`s what you see in my schematic. The motor seems to run perfectly, however after a minute or so it becomes extremely hot. I don`t have anything to measure the actual temp but it is painful to put my fingers on it for more than half a second. given the circuit above, remove the zener and put a resitor and a 100uF 25V capacitor in series between COM and GND (COM -> R -> C -> GND): the motor runs well but still overheats What is the zener voltage The supply voltage needs to be lower than the zener voltage Also, what is the zener voltage Russell McMahon Oct 8 `11 at 16:01 Hot sounds wrong. What is the coil resistane when measured with an ohm meter (multimeter) center tap to any conmnected phase What is the supply current | If you have a 50 ohm coil then the power per phase max should be V2/R = 144/50 = 2.
9 Watt. Overall yu should not have more than the equivalent of 1 phase being driven cintinually. 3 Watt sis not vast heat wise. | IF you have the 8 Ohm version. :-). | 122/8 = 18W or I = V/R = 12//8 = 1. 5A = hotter than 3 Watts. | 8 ohm version is made to be pulse driven (or with series R). Russell McMahon Oct 11 `11 at 16:24 As you can see from your drawing (even though it tends not to be intuitive at first glance) - each centre tapped winding is like two magnetically coupled inductors or two halves of a transformer winding. When you connect the centre tap to V+ and ground one end the other end rises to 2 x V+ - or tries to.
BUT each driven output is connected via a diode to com (anode to driver, cathode to com). When you ground one end of the winding and the other end is connected to V+ via a diode you are trying to drive the supply with 2 x supply (less a diode drop). Something has to give. As you have discovered. In the unlikely event that you have a 2 x V+ rail, connect com to that. That would be a near perfect solution. If you connect com to a capacitor you will get a 2 x V+ supply :-). Connect a zener from com to ground (Vzener > 2 x Vsupply) or com to V+ (Vzener > V+). Zener cathode to com in each case so com can rise to 2 x V+ without zener conducting. The above schemes with capacitor and resistor provide a load for inductive spikes. They also load the transformer formed by the two halves so the resistor to the capacitor is to reduce the unwanted loading.
The resistor to ground drains the cap. Dimension as required. The easy practical test of my assertion is to either disconnect com (slight risk of ULN2003 dying) or connect to V+ with a zener as above, the monitor com with an oscilloscope. Or connect a capacitor with voltage rating > 2 x V+ from com to ground, operate stepper and measure capacitor voltage.
Voltages of ~=2 x V+ should appear. Here is one circuit which almost gets it right - except he has the zener diode polarity reversed. As shown the zener acts like a low grade diode with the same polarity as the ULN200x internal diodes. Reverse it and it lets com rise to V+ + Vzener.
The schematic indicates that each center-tapped winding behaves like two magnetically coupled inductors or two halves of a transformer winding. When the center tap is connected to V+ and one end is grounded, the other end attempts to rise to 2 x V+, minus the diode drop. Each driven output connects via a diode to COM (anode to driver, cathode to COM), which creates a scenario where driving the supply results in an attempt to achieve 2 x supply voltage. This leads to undesirable heating effects, as observed.
For optimal performance, if a 2 x V+ rail is available, connecting COM to that rail is recommended. This setup would provide a nearly ideal solution. Alternatively, connecting COM to a capacitor will yield a 2 x V+ supply. A Zener diode should be connected from COM to ground (with Vzener > 2 x Vsupply) or from COM to V+ (with Vzener > V+), ensuring that the Zener cathode is connected to COM in both cases. This arrangement allows COM to rise to 2 x V+ without the Zener conducting.
The combination of a capacitor and resistor serves to provide a load for inductive spikes and to load the transformer formed by the two halves of the winding. The resistor connected to the capacitor helps mitigate unwanted loading. A resistor to ground can drain the capacitor, and its dimensions should be adjusted as necessary.
To verify these assertions, a practical test can be conducted by either disconnecting COM (with a slight risk of damaging the ULN2003) or connecting it to V+ with the Zener as described. Monitoring COM with an oscilloscope or connecting a capacitor rated for more than 2 x V+ from COM to ground while operating the stepper motor can help measure the capacitor voltage. Voltages approaching 2 x V+ should be observable. A circuit that nearly achieves this functionality is noted, though it is important to ensure that the Zener diode polarity is correct; reversing the polarity allows the Zener to function properly, enabling COM to rise to V+ + Vzener.The ULN2003A and Zener from the driver board inside the same device. It`s a 5 wires motor, but the one in the schematic is 6 wires. I suppose the only difference is that the 5 wire version has the two center taps joined together so that`s what you see in my schematic. The motor seems to run perfectly, however after a minute or so it becomes extremely hot. I don`t have anything to measure the actual temp but it is painful to put my fingers on it for more than half a second. given the circuit above, remove the zener and put a resitor and a 100uF 25V capacitor in series between COM and GND (COM -> R -> C -> GND): the motor runs well but still overheats What is the zener voltage The supply voltage needs to be lower than the zener voltage Also, what is the zener voltage Russell McMahon Oct 8 `11 at 16:01 Hot sounds wrong. What is the coil resistane when measured with an ohm meter (multimeter) center tap to any conmnected phase What is the supply current | If you have a 50 ohm coil then the power per phase max should be V2/R = 144/50 = 2.
9 Watt. Overall yu should not have more than the equivalent of 1 phase being driven cintinually. 3 Watt sis not vast heat wise. | IF you have the 8 Ohm version. :-). | 122/8 = 18W or I = V/R = 12//8 = 1. 5A = hotter than 3 Watts. | 8 ohm version is made to be pulse driven (or with series R). Russell McMahon Oct 11 `11 at 16:24 As you can see from your drawing (even though it tends not to be intuitive at first glance) - each centre tapped winding is like two magnetically coupled inductors or two halves of a transformer winding. When you connect the centre tap to V+ and ground one end the other end rises to 2 x V+ - or tries to.
BUT each driven output is connected via a diode to com (anode to driver, cathode to com). When you ground one end of the winding and the other end is connected to V+ via a diode you are trying to drive the supply with 2 x supply (less a diode drop). Something has to give. As you have discovered. In the unlikely event that you have a 2 x V+ rail, connect com to that. That would be a near perfect solution. If you connect com to a capacitor you will get a 2 x V+ supply :-). Connect a zener from com to ground (Vzener > 2 x Vsupply) or com to V+ (Vzener > V+). Zener cathode to com in each case so com can rise to 2 x V+ without zener conducting. The above schemes with capacitor and resistor provide a load for inductive spikes. They also load the transformer formed by the two halves so the resistor to the capacitor is to reduce the unwanted loading.
The resistor to ground drains the cap. Dimension as required. The easy practical test of my assertion is to either disconnect com (slight risk of ULN2003 dying) or connect to V+ with a zener as above, the monitor com with an oscilloscope. Or connect a capacitor with voltage rating > 2 x V+ from com to ground, operate stepper and measure capacitor voltage.
Voltages of ~=2 x V+ should appear. Here is one circuit which almost gets it right - except he has the zener diode polarity reversed. As shown the zener acts like a low grade diode with the same polarity as the ULN200x internal diodes. Reverse it and it lets com rise to V+ + Vzener.
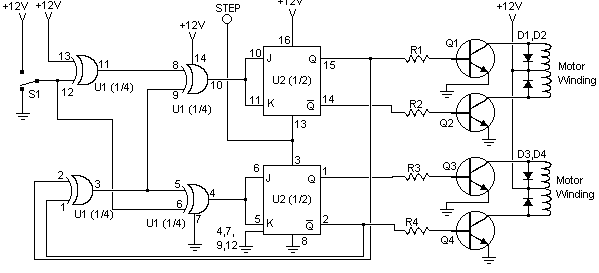
Stepper Motor Controllers
The circuit is straightforward and cost-effective. This is advantageous since most commercially available stepper motor controller ICs tend to be quite pricey. It is constructed using standard components and can be easily modified for computer control. By utilizing inexpensive surplus...
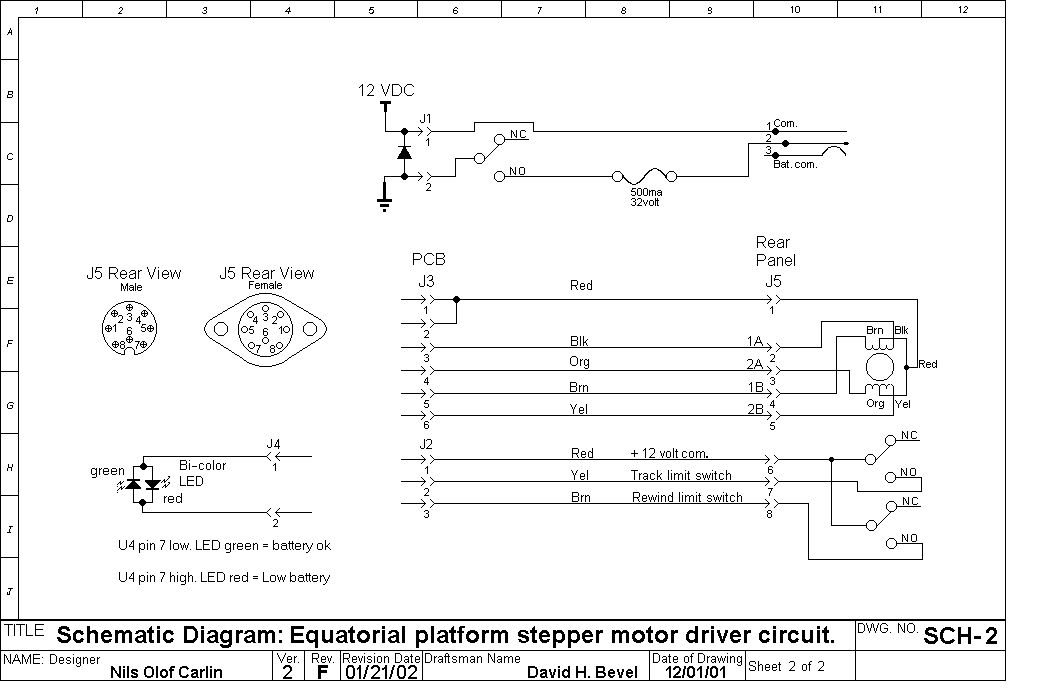
Stepper
The resistors R18 and R22, which were intended to be connected to pin 8 of U4, were incorrectly connected to pin 9. The current versions have been corrected. There is a minor error in the component layout where two versions...
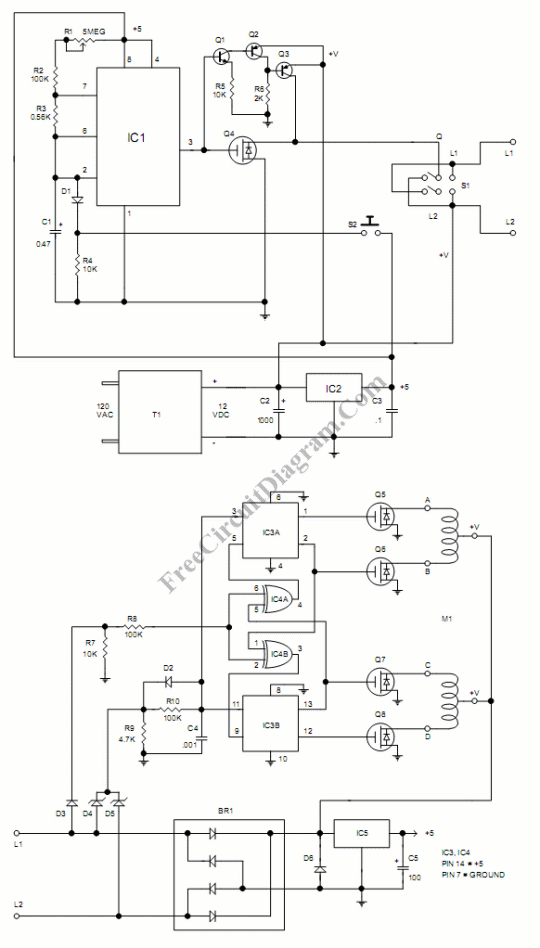
Stepper Motor Controller
A stepper motor provides a simple, low-cost, and precise method for position control. It can be driven by a circuit that is mounted near the motor and controlled by a microcontroller.
Stepper motors are widely utilized in applications requiring precise control...
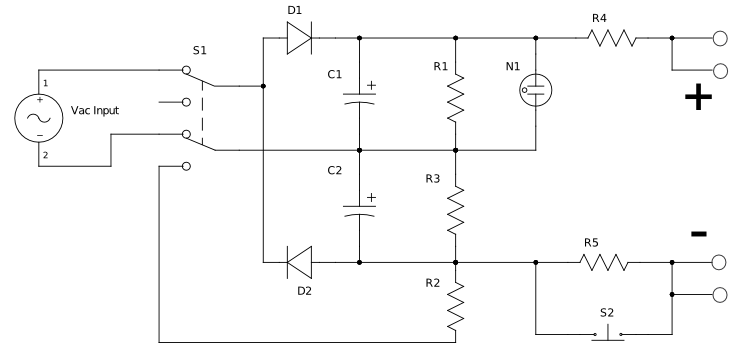
Zener diode tester
This circuit is designed for testing zener diodes. It connects to a 120V AC line and boosts the output voltage to over 300V, enabling the testing of zener diodes with various voltage ratings. The circuit features a push-button switch that...
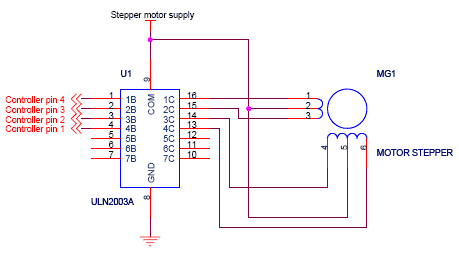
stepper motor interfacing connections
Stepper motor interfacing with a microcontroller. Full-step and half-step stepper control. Working principles and basics of stepper motors. Tutorial on 6-lead unipolar stepper motors and bipolar stepper motors.
Stepper motors are widely used in various applications requiring precise control of angular...
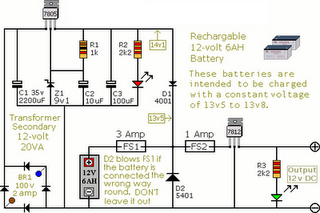
Circuit Diagram Of Alarm Power Supply
The following circuit illustrates an Alarm Power Supply Circuit Diagram. Features include a 1-amp current output, suitable for a Modular Burglar Alarm operating at 12 volts.
The Alarm Power Supply Circuit is designed to provide a stable and reliable power source...
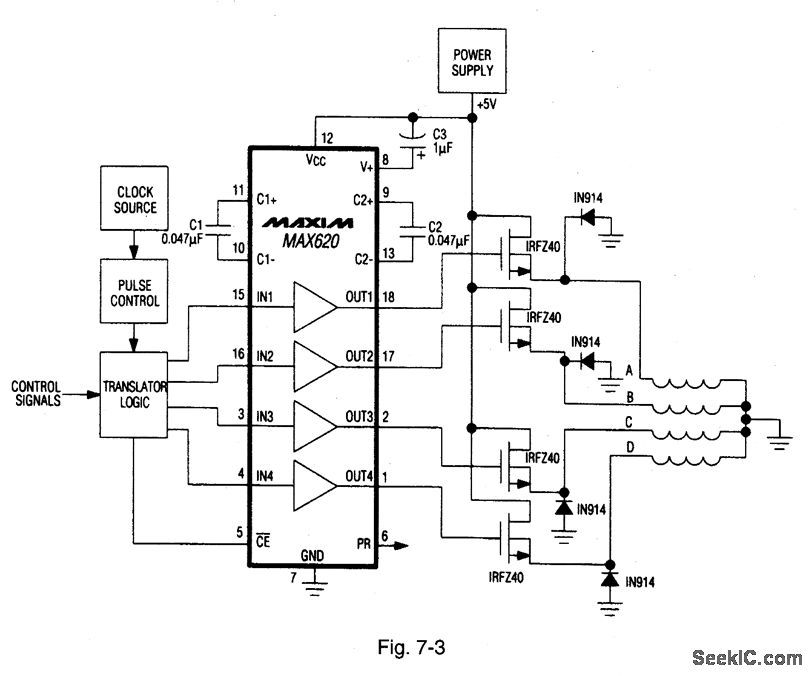
Four phase stepper motor drive system
A MAX620 is connected to create a complete stepper motor drive system. TTL/CMOS signals from the logic network are converted to high-side levels that control four N-channel power MOSFETs, which supply current to each of the four phases of the...
Stepper Motor Generator
Any stepper motor can function as a generator. Unlike other types of generators, a stepper motor generates a significant induced voltage even at low rotational speeds. The specific model used here has a DC resistance ranging from 2 ohms to...
unipolar stepper motor controller
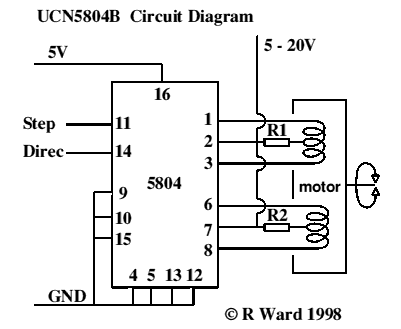
This integrated circuit is highly efficient and does not require any external glue logic for operation. It features two pins for motor control: one pin is dedicated to controlling the direction of the motor, while the other pin is used...