


Stepper Motor Controller Schematic
#stepper motor
#CD4050
#TIP122
#microcontroller
#Uni polar
#1N4007 diode
#hex buffer
#6v/2amps
#1.8degree
#motor coil
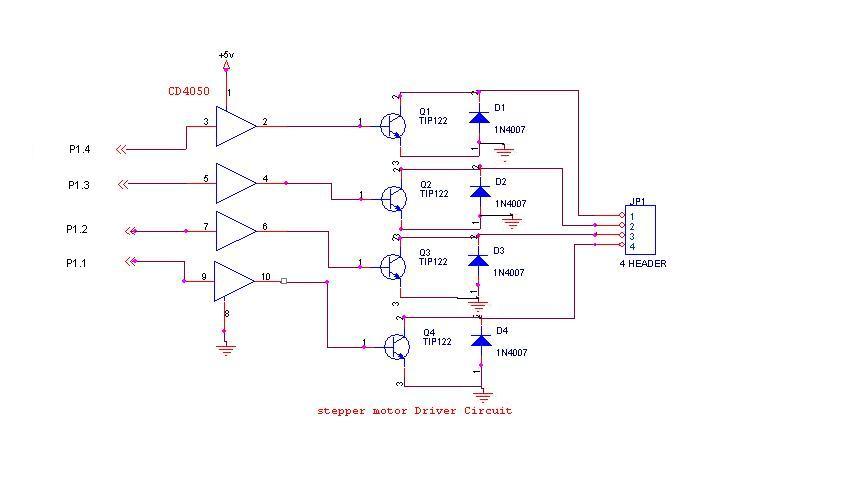
Description: A 6V, 2A stepper motor is utilized in this circuit. The CD4050 hex buffer is employed to connect to the microcontroller. The output of the CD4050 is linked to the base of a TIP122 transistor. The emitter and collector of the TIP122 are connected to a 1N4007 diode, while the collector of the TIP122 is connected to the stepper motor coil. This demonstration employs a unipolar stepper motor with six wires, color-coded as follows: Black for coil 1, Red for coil 2, Green for coil 3, Yellow for coil 4, and two white wires connected to provide a 6V input supply voltage. The code provided includes a delay function and a rotation function to control the stepper motor.
The circuit described operates a unipolar stepper motor using a 6V power supply and a microcontroller interfaced through a CD4050 hex buffer. The CD4050 serves to buffer the microcontroller's output signals, ensuring adequate drive capability for the TIP122 transistor, which functions as a switch to control the motor coils.
The TIP122, a Darlington pair transistor, is used to handle the higher current required by the stepper motor. The connection of the emitter and collector to a 1N4007 diode is crucial for flyback protection, preventing voltage spikes generated when the motor coils are de-energized from damaging the transistor or the microcontroller.
The stepper motor in use is a unipolar type, which typically has six wires: four for the coils and two for the common connection to the power supply. The color coding indicates the function of each wire, facilitating correct connections. The motor's operation is controlled through a series of signals sent from the microcontroller, which are defined in the provided code snippets.
The code includes a `rotate` function that sequentially energizes the coils of the stepper motor to achieve rotation. The `delay` function introduces a timing mechanism to control the speed of rotation. The loop in the `main` function continuously calls the `rotate` function, allowing for ongoing operation of the stepper motor.
In summary, this circuit effectively demonstrates the control of a unipolar stepper motor using a microcontroller, a hex buffer, and a transistor, showcasing fundamental principles of motor control in electronic design.We are using 6v/2amps 1. 8degree stepper motor. In this circuit CD4050 hex buffer using to connect to the microcontroller. The output of cd4050 is connected to the TIP122 of the BASE. The Emitter and collecter is conneted to 1N4007 diode the colleter of tip122 is connected to the stepper motor coil. In this demo we are using Uni polar Stepper motor using 6wires, the color coding of the stepper motors
are Black coil 1, Red coil 2, Green coil 3, Yellow coil 4 and 2 white are connected to give 6V input supply voltage. #include "reg51. h" void delay(unsigned int y); void rotate() { P1=0x09; delay(30); P1=0x05; delay(30); P1=0x06; delay(30); P1=0x0a; delay(30); } void delay(unsigned int y) { int i, j; //delay subroutine for(i=0;i<=y;i+) for(j=0;j<=498;j+); } void main() { while(1) { rotate(); } }
The circuit described operates a unipolar stepper motor using a 6V power supply and a microcontroller interfaced through a CD4050 hex buffer. The CD4050 serves to buffer the microcontroller's output signals, ensuring adequate drive capability for the TIP122 transistor, which functions as a switch to control the motor coils.
The TIP122, a Darlington pair transistor, is used to handle the higher current required by the stepper motor. The connection of the emitter and collector to a 1N4007 diode is crucial for flyback protection, preventing voltage spikes generated when the motor coils are de-energized from damaging the transistor or the microcontroller.
The stepper motor in use is a unipolar type, which typically has six wires: four for the coils and two for the common connection to the power supply. The color coding indicates the function of each wire, facilitating correct connections. The motor's operation is controlled through a series of signals sent from the microcontroller, which are defined in the provided code snippets.
The code includes a `rotate` function that sequentially energizes the coils of the stepper motor to achieve rotation. The `delay` function introduces a timing mechanism to control the speed of rotation. The loop in the `main` function continuously calls the `rotate` function, allowing for ongoing operation of the stepper motor.
In summary, this circuit effectively demonstrates the control of a unipolar stepper motor using a microcontroller, a hex buffer, and a transistor, showcasing fundamental principles of motor control in electronic design.We are using 6v/2amps 1. 8degree stepper motor. In this circuit CD4050 hex buffer using to connect to the microcontroller. The output of cd4050 is connected to the TIP122 of the BASE. The Emitter and collecter is conneted to 1N4007 diode the colleter of tip122 is connected to the stepper motor coil. In this demo we are using Uni polar Stepper motor using 6wires, the color coding of the stepper motors
are Black coil 1, Red coil 2, Green coil 3, Yellow coil 4 and 2 white are connected to give 6V input supply voltage. #include "reg51. h" void delay(unsigned int y); void rotate() { P1=0x09; delay(30); P1=0x05; delay(30); P1=0x06; delay(30); P1=0x0a; delay(30); } void delay(unsigned int y) { int i, j; //delay subroutine for(i=0;i<=y;i+) for(j=0;j<=498;j+); } void main() { while(1) { rotate(); } }
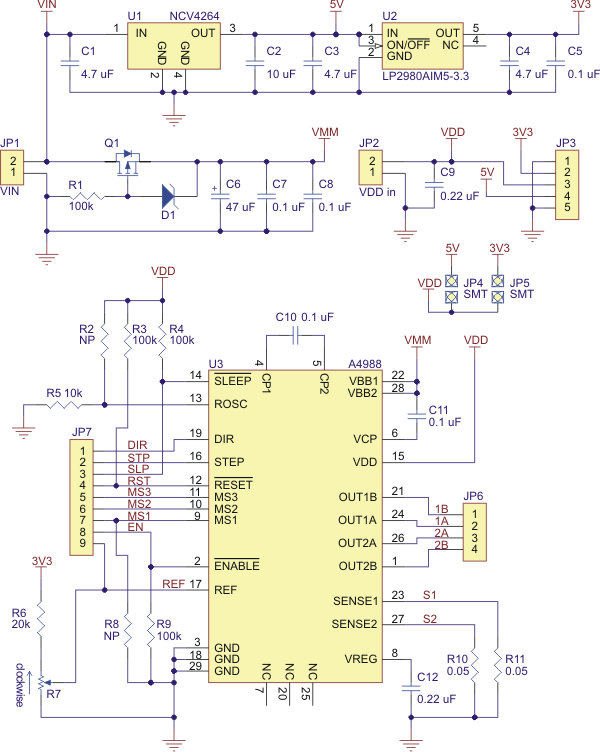
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
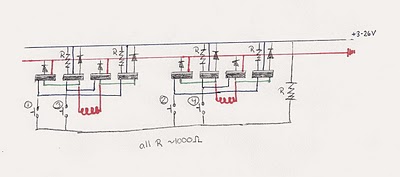
Bipolar Stepper Motor circuit
There was difficulty in understanding that the Source pin connects to low voltage (source of electrons) and the Drain pin connects to high voltage (absorbs electrons). This concept is fundamental to basic electricity, but it required some time to comprehend.
In...
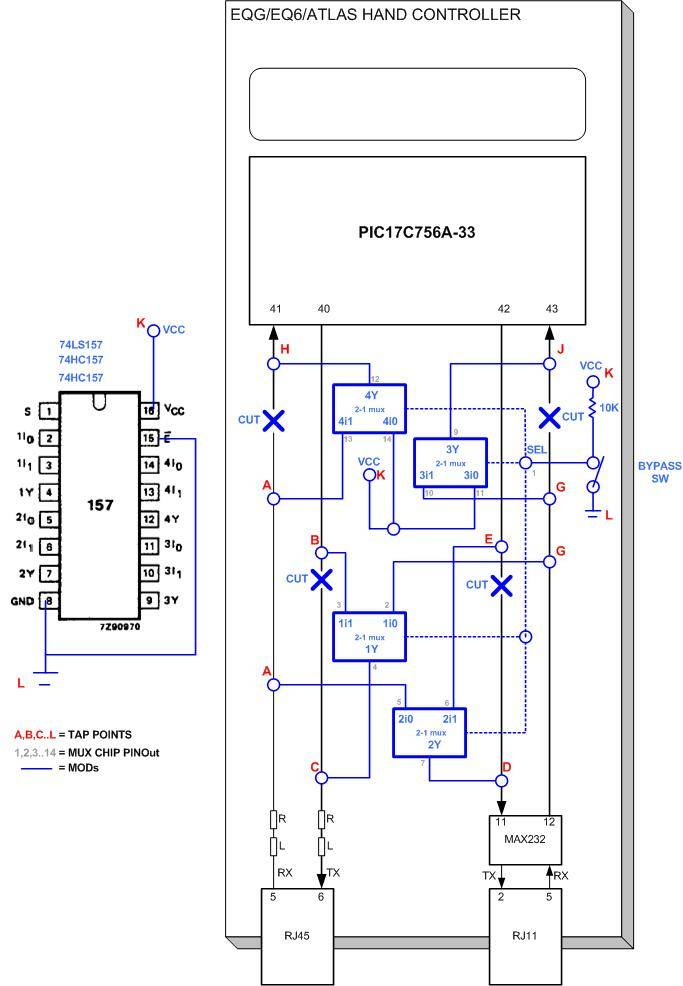
EQG MOD FOR DIRECT STEPPER MOTOR ACCESS
The modifications allow direct access to the stepper motor controls of the mount. Any erroneous commands or invalid data sent to the mount could inadvertently activate the stepper motors, leading to potential damage to connected equipment as the motors may...
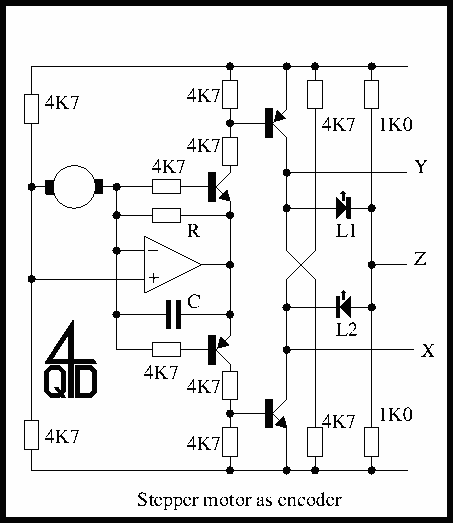
Stepper Motor Encoder Circuit
The circuit is a simple op-amp but with two diodes (the transistor b-e junctions in the feedback to split the feedback for positive and negative outputs. On positive output from the stepper coil the top transistor turns on, on negative,...
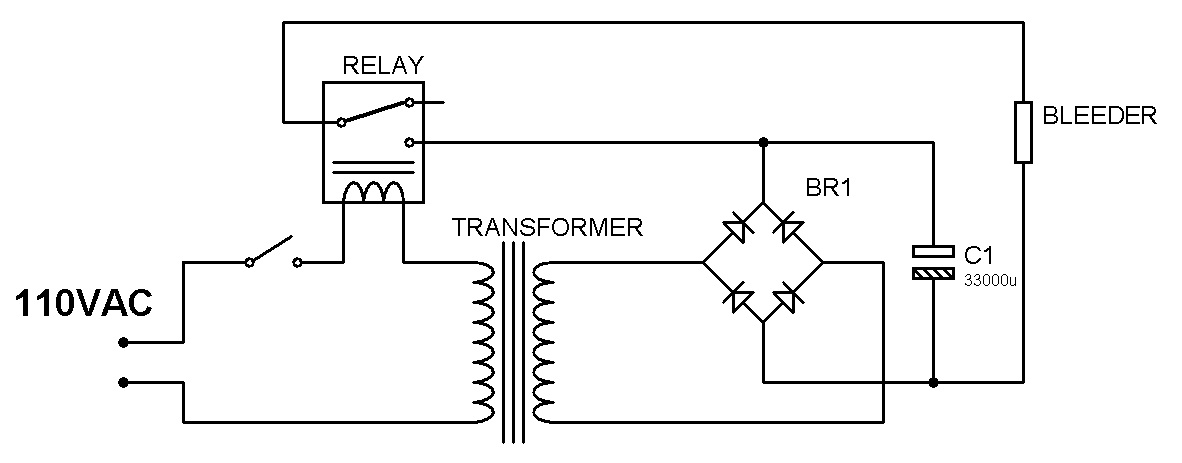
CO2 Laser
The motor controller is a custom-built unit that integrates custom printed circuit boards, the Pico Systems Universal Stepper Controller card, Gecko G320 motor drives, and an internal power supply. It also interfaces with servos requiring DC power and motor encoders,...
DC motor driver for DCMP(AVR-008)
A microcontroller is used to control various types of DC motors, including permanent magnet DC motors, DC servo motors, and stepper motors. This project utilizes the AVR-008 microcontroller from Circuits-Home, which is frequently referred to as the 3-in-1 driver motor...
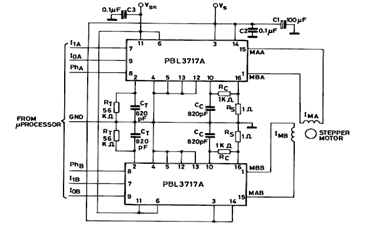
Two Phase Bipolar Stepper Motor Driver Circuit using PBL3717A
The diagram below illustrates a Two Phase Bipolar Stepper Motor Driver utilizing the PBL3717A. It depicts two PBL3717A integrated circuits (ICs) that control and drive two bipolar stepper motors.
The Two Phase Bipolar Stepper Motor Driver circuit is designed to efficiently...
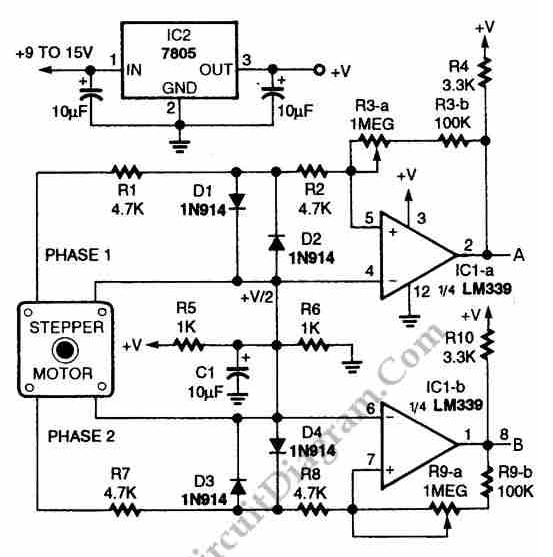
Digital Encoder Circuit diagram Using Stepper Motor
The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of utilizing a digital rotation encoder as an input, this circuit employs a...
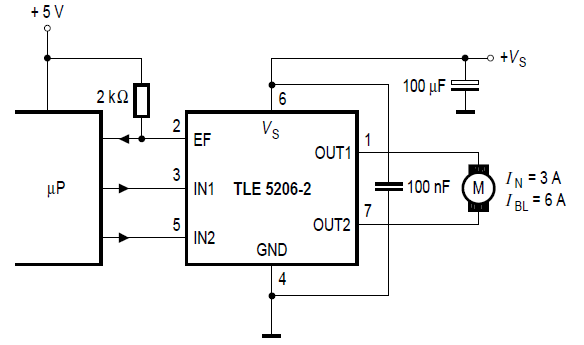
stepper remote control car
Stepper motor control circuit diagram using TLE5206 for remote control car.
The stepper motor control circuit is designed to manage the operation of a stepper motor, specifically utilizing the TLE5206 integrated circuit. This circuit is particularly suitable for applications in remote...