


stepper motor controller circuit and code
#stepper motor
#Arduino
#motor driver
#bipolar motor
#4-pin control
#library
#circuit schematics
#coil activation
#DIY electronics
#motor controller
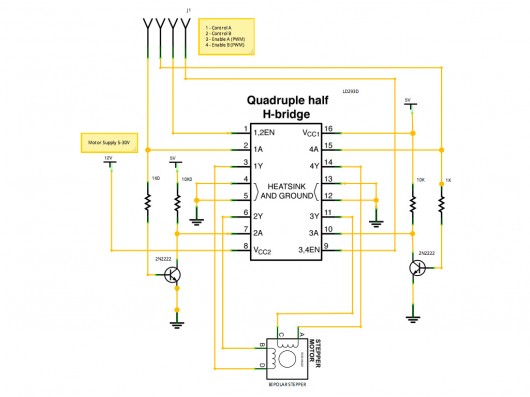
Description: A stepper motor controller based on schematics available on the Arduino website. Initially, a two-pin configuration was attempted for a bipolar stepper motor, but it did not function as expected, especially with the library provided on the site. The circuit kept both coils active simultaneously. Subsequently, a four-pin configuration was tried with the same library, but it also did not work. Afterward, a custom code was created that successfully operated the motor. It was realized that merging the two circuits could potentially lead to the creation of a PWM-enabled bipolar motor controller using the L297D. Although this idea seems unconventional, it may be feasible if the Arduino can be programmed to send four synchronized PWM signals. Further research indicated that the TI DRV8811 and Allegro A3977 chips are more suitable for microstepping. The two PNP transistors are connected similarly to the circuit proposed on the Arduino website, and the enable pins are utilized. The circuit requires four pins, and no alternative configuration was found to reduce this number. The code developed for controlling the stepper motor employs direct port commands to minimize processor time, with a dedicated function called in the main loop for each step, allowing other tasks to be performed while the motor operates. There is also a need to build a peristaltic pump, and a request for a list of all necessary parts, including resistors, was made. Additionally, inquiries were made regarding the motor power supply, specifically whether a regulated power supply or a wall-wart was used. It was noted that two wall-wart power supplies were utilized: one 9VDC regulated with a 7805 +5V voltage regulator for logic control and one unregulated 12VDC for the stepper motor. The focus is primarily on the unregulated supply for the stepper motor, with 5V drawn from the Arduino for logic. Specifications for the wall-wart supply and voltage-current requirements for the motor were requested, along with a link to the motor source. There was also a query regarding the library used, as a compilation error was encountered with the function motorReset().
The stepper motor controller circuit design utilizes an Arduino microcontroller to facilitate precise control of the stepper motor. The circuit can be implemented in two configurations: a two-pin or a four-pin setup. The two-pin configuration typically involves energizing two coils of a bipolar stepper motor, but it is crucial to ensure that only one coil is energized at a time to avoid simultaneous activation, which can lead to overheating and inefficiency. The four-pin configuration allows for more refined control, enabling the use of half-stepping or microstepping techniques, which improve the resolution and smoothness of motor movement.
For the circuit, the integration of the L297D can enhance the functionality by allowing for PWM control, which can modulate the power delivered to the motor coils, thereby providing smoother operation and improved torque control. The use of the TI DRV8811 or Allegro A3977 chips is recommended for applications requiring microstepping capabilities, as these integrated circuits are designed to handle the complexities of stepper motor control, including current regulation and fault detection.
The circuit design incorporates two PNP transistors that act as switches to control the current flow to the motor coils, driven by the output from the Arduino. The enable pins from the motor driver ICs allow for easy activation and deactivation of the motor, which can be beneficial for power management and system efficiency.
Power supply considerations are critical for the operation of the stepper motor. The choice of a 9VDC regulated power supply for the Arduino ensures stable logic levels, while the unregulated 12VDC supply provides the necessary voltage for the motor's operation. It is essential to verify that the power supply meets the voltage and current specifications required by the motor to prevent underperformance or damage.
In summary, the stepper motor controller circuit provides a robust solution for controlling stepper motors with options for both basic and advanced configurations. Proper attention to power supply specifications and circuit design will ensure reliable operation and performance.A step motor controller based on the schematics found on the Arduino Web site. First I try the 2 pins one for bipolar stepper motor. I wont be able to make it work, even less with the library available on the site. Maybe I`m dumb and I really dont understand something, but this circuit keeps both coils active at the same time. So I tried the second circuit, the 4 pins one. With the same library I wasn`t able to make it work either. So I create apieceof code of my own and I finally managed to make the motor run correctly. After that, I realize that I can merge the to circuits to possibly create a PWM abled bipolar motor controller with the L297D. A somewhat bizzare idea, but I think it`s possible if we can program the Arduino to send 4 synced PWM signals.
I`ll come back later (maybe never) with this thought. After some research I found that the TI DRV8811 and the Allegro A3977 are much more appropriate chips to do microstepping. The two PNP transistors are connected like the circuit proposed on the Arduino Web site. Plus, I use the enable pins. So my circuit needs four pins, and I don`t found a way to use less. There is my code to control the stepper motor. Like you see in my code I use direct port command to take less processor time. And I create a function called in the main loop for each steps. This way the code can do something else when the motor is running. i need to build a peristaltic pump. can i ask for the list of all the parts including the resistors & etc thanks Hi, your site is very helpful, but I need help with the motor power supply.
How exactly did you power your motor Did you have to use a regulated power supply or used a wall-wart Thanks @Phil: I used two wall-wart power supply. One 9VDC regulated with a 7805 +5V voltage regulator for the logic control and one NOT regulated 12VDC for the stepper motor.
I am more interested in the unregulated one for the stepper motor, I will draw 5v from the arduino for the logic. What are the exact specifications of your wall-wart supply, and the voltage-current requirements for the motor If you have a link for where you got the motor that would be awesome.
Thank you for the quick response! Muy interesante su trabajo. Es de agradecer. Pero, tengo una duda, cual es la librerGa que ha utilizado. Cuando compilo el programa, me da error en la funciG³n motorReset(); . Debo ser muy torpe, disculpe. Very interesting work. It is ap
The stepper motor controller circuit design utilizes an Arduino microcontroller to facilitate precise control of the stepper motor. The circuit can be implemented in two configurations: a two-pin or a four-pin setup. The two-pin configuration typically involves energizing two coils of a bipolar stepper motor, but it is crucial to ensure that only one coil is energized at a time to avoid simultaneous activation, which can lead to overheating and inefficiency. The four-pin configuration allows for more refined control, enabling the use of half-stepping or microstepping techniques, which improve the resolution and smoothness of motor movement.
For the circuit, the integration of the L297D can enhance the functionality by allowing for PWM control, which can modulate the power delivered to the motor coils, thereby providing smoother operation and improved torque control. The use of the TI DRV8811 or Allegro A3977 chips is recommended for applications requiring microstepping capabilities, as these integrated circuits are designed to handle the complexities of stepper motor control, including current regulation and fault detection.
The circuit design incorporates two PNP transistors that act as switches to control the current flow to the motor coils, driven by the output from the Arduino. The enable pins from the motor driver ICs allow for easy activation and deactivation of the motor, which can be beneficial for power management and system efficiency.
Power supply considerations are critical for the operation of the stepper motor. The choice of a 9VDC regulated power supply for the Arduino ensures stable logic levels, while the unregulated 12VDC supply provides the necessary voltage for the motor's operation. It is essential to verify that the power supply meets the voltage and current specifications required by the motor to prevent underperformance or damage.
In summary, the stepper motor controller circuit provides a robust solution for controlling stepper motors with options for both basic and advanced configurations. Proper attention to power supply specifications and circuit design will ensure reliable operation and performance.A step motor controller based on the schematics found on the Arduino Web site. First I try the 2 pins one for bipolar stepper motor. I wont be able to make it work, even less with the library available on the site. Maybe I`m dumb and I really dont understand something, but this circuit keeps both coils active at the same time. So I tried the second circuit, the 4 pins one. With the same library I wasn`t able to make it work either. So I create apieceof code of my own and I finally managed to make the motor run correctly. After that, I realize that I can merge the to circuits to possibly create a PWM abled bipolar motor controller with the L297D. A somewhat bizzare idea, but I think it`s possible if we can program the Arduino to send 4 synced PWM signals.
I`ll come back later (maybe never) with this thought. After some research I found that the TI DRV8811 and the Allegro A3977 are much more appropriate chips to do microstepping. The two PNP transistors are connected like the circuit proposed on the Arduino Web site. Plus, I use the enable pins. So my circuit needs four pins, and I don`t found a way to use less. There is my code to control the stepper motor. Like you see in my code I use direct port command to take less processor time. And I create a function called in the main loop for each steps. This way the code can do something else when the motor is running. i need to build a peristaltic pump. can i ask for the list of all the parts including the resistors & etc thanks Hi, your site is very helpful, but I need help with the motor power supply.
How exactly did you power your motor Did you have to use a regulated power supply or used a wall-wart Thanks @Phil: I used two wall-wart power supply. One 9VDC regulated with a 7805 +5V voltage regulator for the logic control and one NOT regulated 12VDC for the stepper motor.
I am more interested in the unregulated one for the stepper motor, I will draw 5v from the arduino for the logic. What are the exact specifications of your wall-wart supply, and the voltage-current requirements for the motor If you have a link for where you got the motor that would be awesome.
Thank you for the quick response! Muy interesante su trabajo. Es de agradecer. Pero, tengo una duda, cual es la librerGa que ha utilizado. Cuando compilo el programa, me da error en la funciG³n motorReset(); . Debo ser muy torpe, disculpe. Very interesting work. It is ap
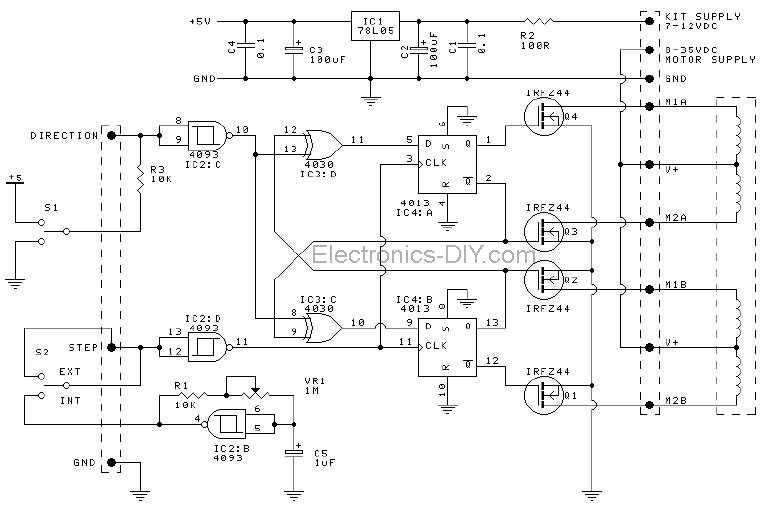
Stepper Motor Driver
These motors consist of two coils and are operated by altering the direction of current flow through the coils in a specific sequence. They feature only four wires and cannot be directly connected to this kit. Refer to Kit 1406...
Bug Eyed Eggliner
The Bug-Eyed Eggliner project involves creating a whimsical animated figure with large, illuminated, and movable eyes. The project utilizes a combination of wooden balls for the eyes, a PICAXE microcontroller for control, and a servo mechanism to achieve eye movement....
Stepper Motor Controller
The first phase of a motion-controlled photography rig has been completed, focusing on the setup of bipolar stepper motor controllers. This component is crucial for motor control, which is essential for achieving motion in the project. A list of materials...
Credit card sized ethernet arduino controller
The Arduino is a user-friendly and versatile controller platform suitable for various projects. Recently, an Ethernet shield was purchased for the Arduino to enable remote control of projects, which proved to be highly effective. This led to the idea of...
Arduino Serial Call Response
This sketch transmits an ASCII 'A' (byte value 65) upon startup and continues to do so until it receives a serial response from the computer. After receiving a response, it sends three sensor values as individual bytes and waits for...
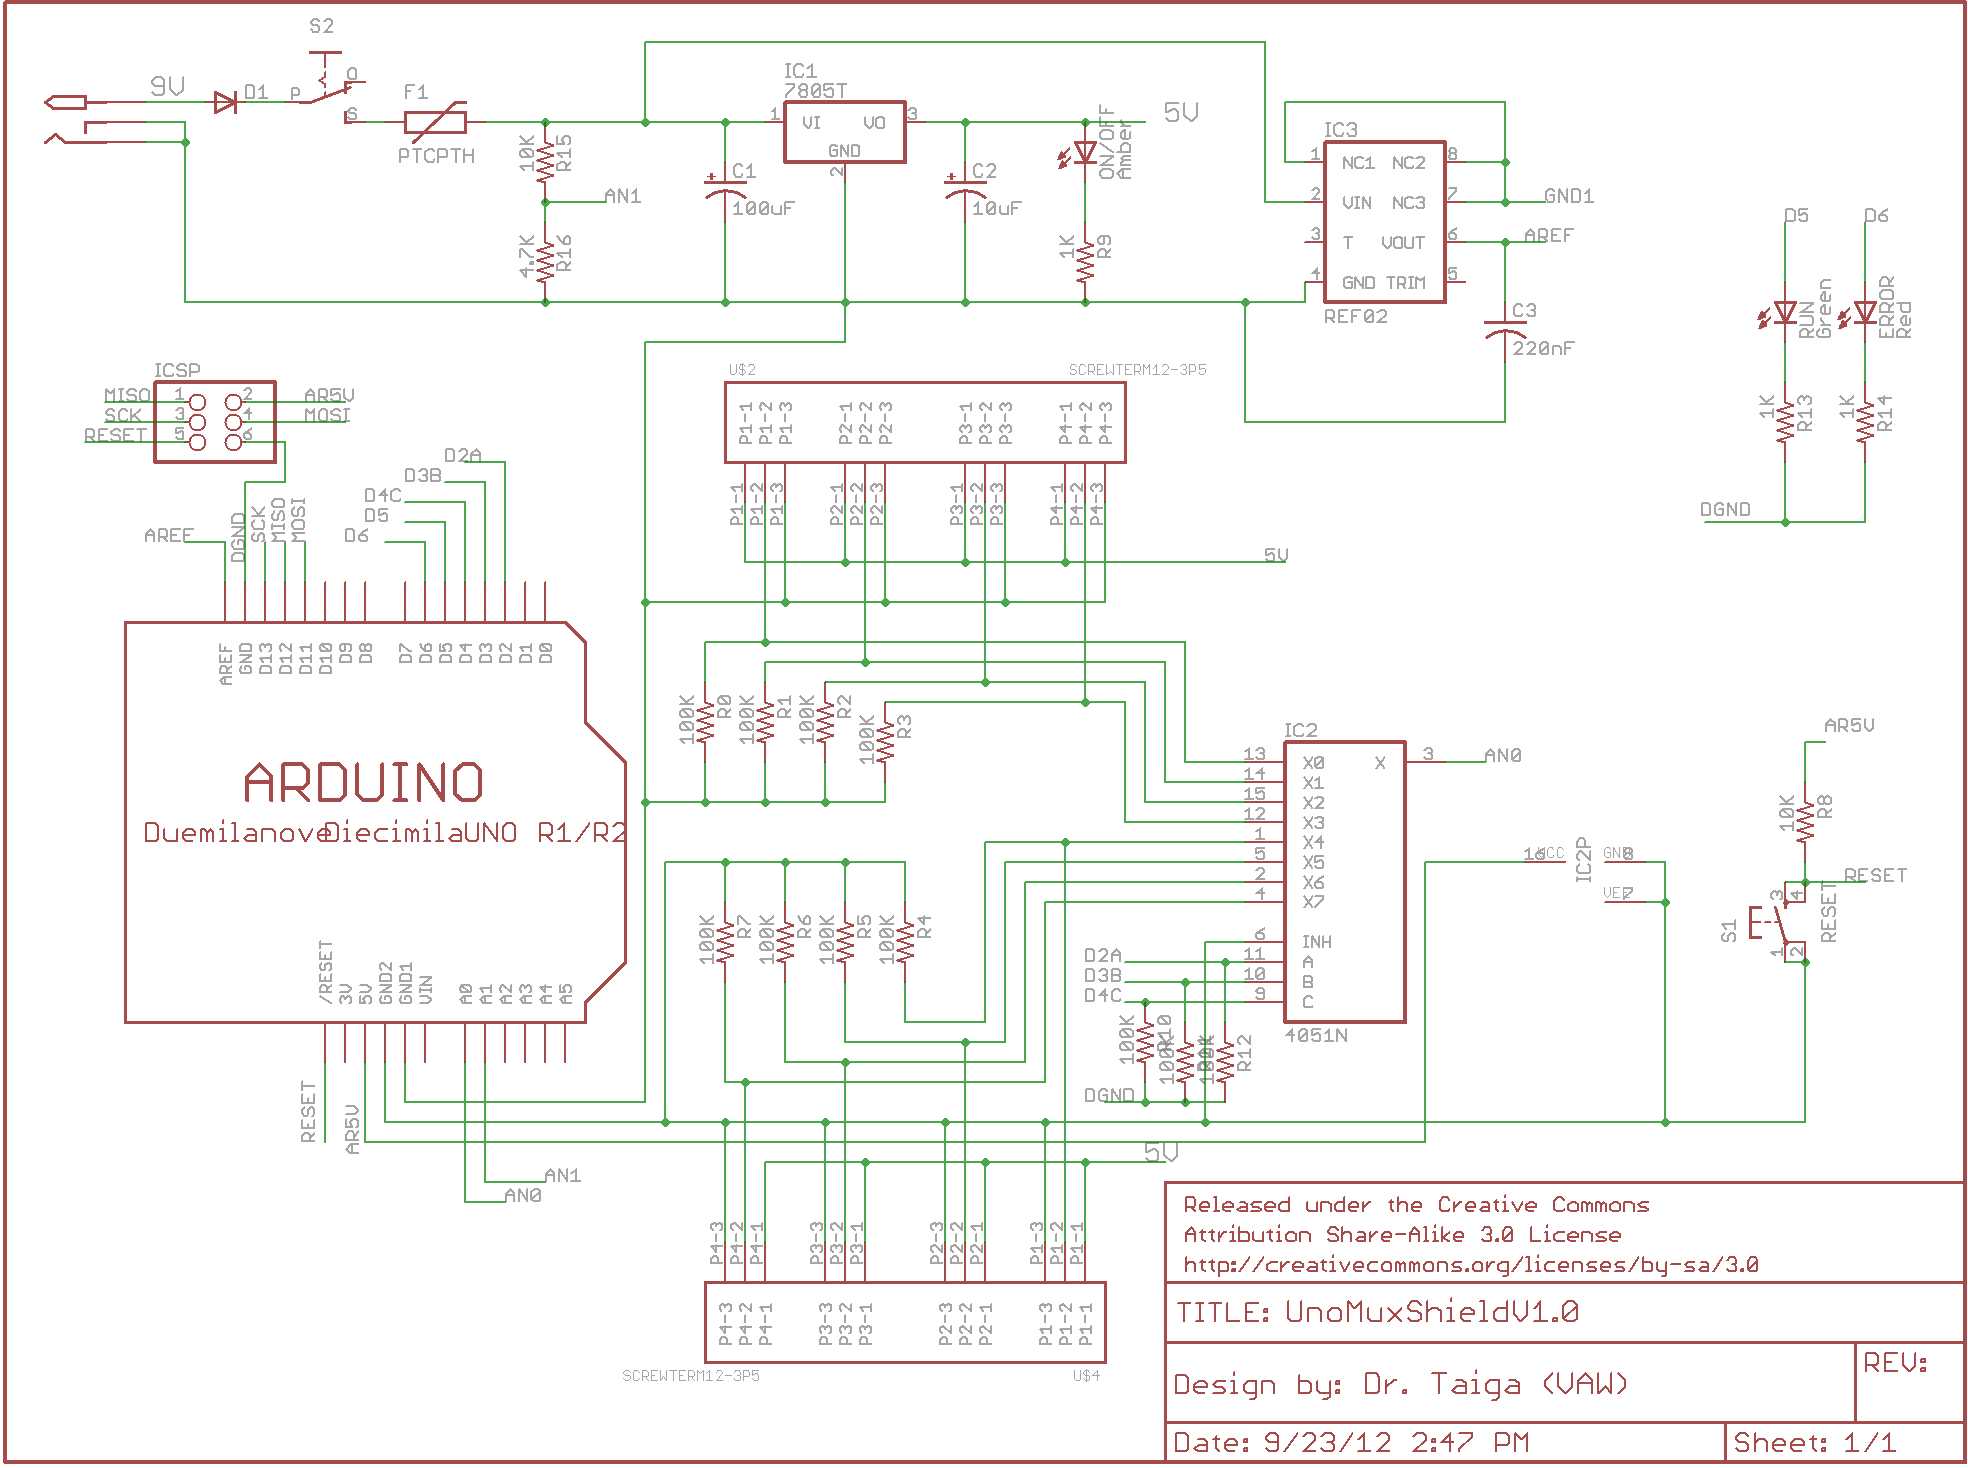
arduino multiplexer shield
There is enthusiasm for using Arduinos in science projects. However, it is important to address several shortcomings of the Arduino before it can be utilized for more serious applications. Specifically, the addition of robust screw terminals is necessary.
The Arduino platform...
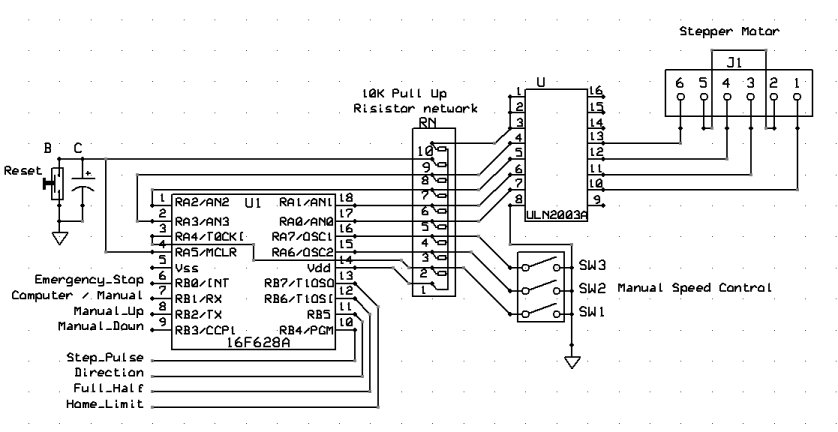
stepper motor question
The inquiry was focused not only on power consumption but also on the observation that some stepper motors have more wires than the standard four, while others are classified as bipolar.
Stepper motors are widely used in various applications due to...
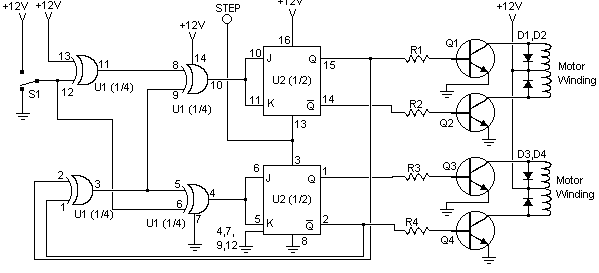
Stepper Motor Controllers
The circuit is straightforward and cost-effective. This is advantageous since most commercially available stepper motor controller ICs tend to be quite pricey. It is constructed using standard components and can be easily modified for computer control. By utilizing inexpensive surplus...
DIY Stepper Controller Circuit
The schematic for the board is illustrated below. The three primary components of the board include (1) the power input and voltage regulation, (2) the L297 input and outputs, and (3) the L298 stepper motor control circuit. The motor is...