


sn754410
#H-Bridge
#SN754410
#motor driver
#heat sink
#current draw
#aluminum can
#DIY
#robotics
#power management
#heat transfer
Description: After testing the motors, a current draw of up to 1.3 Amps was observed. Two SN754410 H-Bridges were stacked, and a heat sink was constructed from an aluminum can. This setup should handle 2 Amps or more. The heat sink consists of the aluminum can shaped into fins, with heat transfer paste and silicone glue applied at each end for stability. The diodes from the previous circuit were removed and replaced with standard resistors. A standard pull-down resistor was implemented for enabling. The robot will draw significant power to keep the Android screen on, so enabling the SN754410 will not have a considerable impact. The motor driver circuit was tested on a breadboard. Initial concerns about using diodes to pull the enable pin high were alleviated as the setup functioned as intended. Current draw will still need to be verified for both the enable pin and each motor activation. A simple test was conducted using an Android phone connected to an IOIO board, which interfaces with the SN754410 motor driver chip. The IOIO board includes a voltage regulator providing 5V and 3.3V outputs for powering the project. Five buttons were created to test each motor in both forward and reverse directions. The full source code in Basic for Android is available for review. The IOIO connection method has proven useful; in a previous Chicken Gate circuit, diodes were used to prevent back current from the motors. Further research indicates that the internal diodes in the SN754410 and L293D (interchangeable components) should suffice. While external diodes can reduce heat, the current configuration involves two 170mA stall motors on each side of the motor driver, making a simple heat sink on the motor driver chip effective and straightforward. Capacitors are still required to smooth the inductive load. A significant change being trialed involves using the IOIO pins with diodes to pull the enable pins high on the motor driver (as shown in the schematic). According to the datasheet, the high-level input voltage requirement is 2V. The 3.3V from the IOIO, minus a 0.7V drop across the diode, results in 2.6V at the enable pin. It is essential to ensure that the current draw does not exceed 20mA from the IOIO pin. The motor driver remains warm when inactive, so it is preferable for the enable to be inactive, achieving an enable switch without utilizing another IOIO pin. It is noted that diodes were removed in favor of resistors. The current circuit diagram functions, but caution is advised. The robot is designed with four motors, operating two at a time; left-side and right-side motors will be paired for coordinated movement. The 4WD robot chassis acquired from Hobby King appears to be a good value, including four gear motors and an adequate platform for the project. Space is allocated for the IOIO control board in a middle layer, with plans to build a motor driver board secured underneath the chassis. The Android phone will be positioned on top, along with some sensors. The low stall current of 170mA allows for the use of a simple motor driver like the SN754410. Testing with a digital multimeter (DMM) will be conducted. The assembly of the kit was relatively straightforward, taking approximately 20 minutes. Attention is advised to ensure that the mounts in the provided instructions are correctly pushed through; otherwise, the entire build may need to be redone.
The circuit employs the SN754410 H-Bridge motor driver, which is designed to control the direction and speed of DC motors. It features four output pins for motor control, with the ability to drive two motors simultaneously. The enable pins are crucial for powering the motors; they must be pulled high to activate the driver. The incorporation of the IOIO board facilitates microcontroller interfacing, allowing for the control of the motor driver using an Android device. The use of resistors for enabling the SN754410 simplifies the circuit, though careful consideration of current limits is necessary to avoid damaging the components.
The heat sink created from an aluminum can is an effective low-cost solution for managing thermal dissipation, particularly important given the observed current draw. The design choice to forego external diodes in favor of relying on the internal diodes of the SN754410 is practical, provided the motor stall current remains within acceptable limits. The testing setup, including the Android phone and the IOIO board, demonstrates a modern approach to robotics, integrating mobile technology with traditional motor control techniques.
In summary, the described circuit is a robust solution for controlling a four-wheel drive robot, utilizing readily available components while ensuring efficient thermal management and power distribution. The design reflects a balance between functionality and simplicity, suitable for a variety of robotic applications.After testing the motors I found current draw as high as 1. 3Amps. So I stuck 2 of the SN754410 H-Bridges on top of each other, and then built a heat sink from an aluminum can. Should be OK for 2Amps or more. The heat sink is just the aluminum can bent into fins with some heat transfer paste and a spot of silicon glue at each end to hold it on.
Dod gy but it might work. I dropped the diodes from the previous circuit, and put more standard resistors instead. Also went for the standard pull down resistor to enable. This robot is going to draw plenty of power keeping the Android screen on, so having the SN754410 enabled isn`t going to make much difference anyhow. I`ve tested the motor driver circuit shown on the previous post by plugging it into a breadboard. I wasn`t confident on using the diodes to pull the enable pin high, but it seems to have worked. I still need to check the current draw using the pin for both enable and also to activate each motor.
Show in the pictures is a simple test using an Android phone hooked up to an IOIO board which goes to the SN754410 motor driver chip. The IOIO is an amazing piece of kit that provides a voltage regulator with 5V and 3V3 outputs to power your project.
In this case I`ve created 5 buttons to test each of the motors in forward and reverse. Download the full source code in Basic for Android if you want to take a look. The IOIO connection method is particularly useful. On my Chicken Gate circuit I had diodes everywhere to stop back current from the motors. I`ve done a bit more research and I believe the internal diodes in the SN754410 and L293D (interchangeable parts) will do the job. Having external diodes will reduce the heat produced, but for my chassis I have 2 x 170mA motor stall on each side of the motor driver, so a simple heat sink on the motor driver chip should be effective and easier.
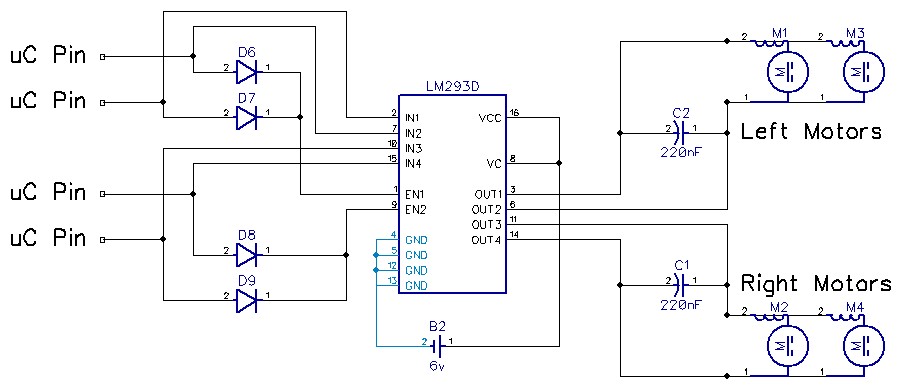
I still need the capacitors to smooth the inductive load. New circuit is at the bottom of this post. One major change I`m going to trial is to pull the enable pins on the motor driver high using the pins from the IOIO with diodes to direct the current (see schematic). According to the datasheet the high level input voltage is 2. I`m guessing this is the voltage required to activate the enable or the operating pins. So the 3V3 (that`s 3. 3V in techno speak apparently) comes from the IOIO, there`s a 0. 7V drop across the diode, leaving 2V6 at the enable pin. I`ll also have to check that the current draw isn`t over 20mA from the IOIO pin. Why Because on the chicken gate the motor driver remains warm when nothing is going on, so I don`t want the enable to be active, this achieves an enable switch without using another pin from the IOIO board.
Note that I removed the diodes (dumb idea) and used resistors instead. The circuit diagram below works, but I don`t recommend it. The robot has 4 motors, but I`m going to operate 2 at one time together the left side and right side motors will be paired. So all forward all reverse turn left with left reverse, right forward turn right with right reverse, left forward .
My 4WD Robot chassis has arrived from Hobby King. So far it seems like a great package for the price. It includes the 4 gear motors and a pretty good platform for what I`m doing. There`s space for the IOIO control board in a middle layer. I`ll build a motor driver board to glue underneath the chassis. The Android phone can sit on top and be visible along with some sensors. e thing I liked was the low stall current of 170mA which means I can get away with a simple motor driver like the SN754410. I`ll have to put the DMM onto this for testing. Building the kit was pretty easy, it took maybe 20 minutes. Don`t forget to push through the mounts in figure 1 on the instructions, otherwise you need to do the whole build again (like me!)
The circuit employs the SN754410 H-Bridge motor driver, which is designed to control the direction and speed of DC motors. It features four output pins for motor control, with the ability to drive two motors simultaneously. The enable pins are crucial for powering the motors; they must be pulled high to activate the driver. The incorporation of the IOIO board facilitates microcontroller interfacing, allowing for the control of the motor driver using an Android device. The use of resistors for enabling the SN754410 simplifies the circuit, though careful consideration of current limits is necessary to avoid damaging the components.
The heat sink created from an aluminum can is an effective low-cost solution for managing thermal dissipation, particularly important given the observed current draw. The design choice to forego external diodes in favor of relying on the internal diodes of the SN754410 is practical, provided the motor stall current remains within acceptable limits. The testing setup, including the Android phone and the IOIO board, demonstrates a modern approach to robotics, integrating mobile technology with traditional motor control techniques.
In summary, the described circuit is a robust solution for controlling a four-wheel drive robot, utilizing readily available components while ensuring efficient thermal management and power distribution. The design reflects a balance between functionality and simplicity, suitable for a variety of robotic applications.After testing the motors I found current draw as high as 1. 3Amps. So I stuck 2 of the SN754410 H-Bridges on top of each other, and then built a heat sink from an aluminum can. Should be OK for 2Amps or more. The heat sink is just the aluminum can bent into fins with some heat transfer paste and a spot of silicon glue at each end to hold it on.
Dod gy but it might work. I dropped the diodes from the previous circuit, and put more standard resistors instead. Also went for the standard pull down resistor to enable. This robot is going to draw plenty of power keeping the Android screen on, so having the SN754410 enabled isn`t going to make much difference anyhow. I`ve tested the motor driver circuit shown on the previous post by plugging it into a breadboard. I wasn`t confident on using the diodes to pull the enable pin high, but it seems to have worked. I still need to check the current draw using the pin for both enable and also to activate each motor.
Show in the pictures is a simple test using an Android phone hooked up to an IOIO board which goes to the SN754410 motor driver chip. The IOIO is an amazing piece of kit that provides a voltage regulator with 5V and 3V3 outputs to power your project.
In this case I`ve created 5 buttons to test each of the motors in forward and reverse. Download the full source code in Basic for Android if you want to take a look. The IOIO connection method is particularly useful. On my Chicken Gate circuit I had diodes everywhere to stop back current from the motors. I`ve done a bit more research and I believe the internal diodes in the SN754410 and L293D (interchangeable parts) will do the job. Having external diodes will reduce the heat produced, but for my chassis I have 2 x 170mA motor stall on each side of the motor driver, so a simple heat sink on the motor driver chip should be effective and easier.
I still need the capacitors to smooth the inductive load. New circuit is at the bottom of this post. One major change I`m going to trial is to pull the enable pins on the motor driver high using the pins from the IOIO with diodes to direct the current (see schematic). According to the datasheet the high level input voltage is 2. I`m guessing this is the voltage required to activate the enable or the operating pins. So the 3V3 (that`s 3. 3V in techno speak apparently) comes from the IOIO, there`s a 0. 7V drop across the diode, leaving 2V6 at the enable pin. I`ll also have to check that the current draw isn`t over 20mA from the IOIO pin. Why Because on the chicken gate the motor driver remains warm when nothing is going on, so I don`t want the enable to be active, this achieves an enable switch without using another pin from the IOIO board.
Note that I removed the diodes (dumb idea) and used resistors instead. The circuit diagram below works, but I don`t recommend it. The robot has 4 motors, but I`m going to operate 2 at one time together the left side and right side motors will be paired. So all forward all reverse turn left with left reverse, right forward turn right with right reverse, left forward .
My 4WD Robot chassis has arrived from Hobby King. So far it seems like a great package for the price. It includes the 4 gear motors and a pretty good platform for what I`m doing. There`s space for the IOIO control board in a middle layer. I`ll build a motor driver board to glue underneath the chassis. The Android phone can sit on top and be visible along with some sensors. e thing I liked was the low stall current of 170mA which means I can get away with a simple motor driver like the SN754410. I`ll have to put the DMM onto this for testing. Building the kit was pretty easy, it took maybe 20 minutes. Don`t forget to push through the mounts in figure 1 on the instructions, otherwise you need to do the whole build again (like me!)
H-bridge driving problemMOSFET frequently damage
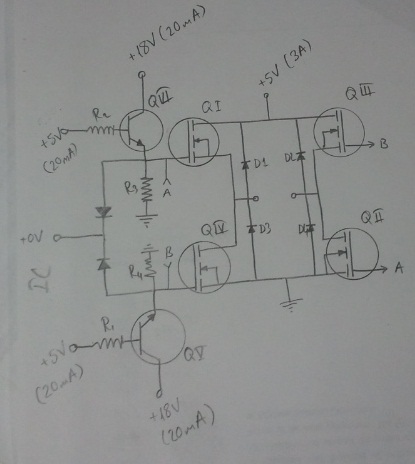
An H-bridge is being utilized with IRF740 MOSFETs to convert 315V DC to 230V AC. However, the upper MOSFETs are frequently damaged within a few seconds, and the cause of this issue has not been identified.
The described circuit employs an...
Electrical drive III
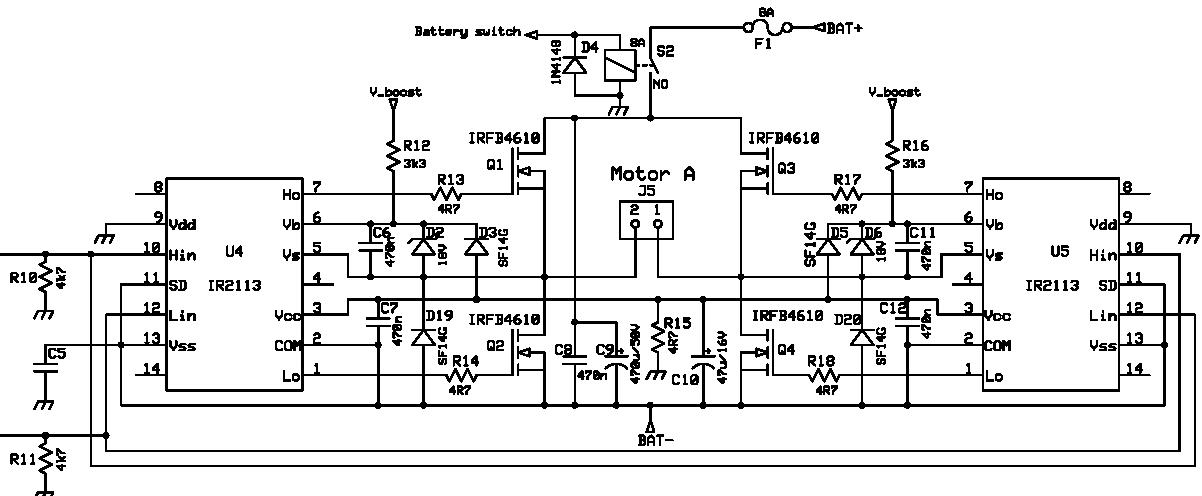
For the DIY Motion Platform III, the electrical motion drive was expanded to three channels. The small signal concept remained unchanged, but the MOSFET half-bridge was modified to a full bridge (H-bridge). The DAC converter was upgraded to a four-channel...
h bridge Where to place decoupling capacitor
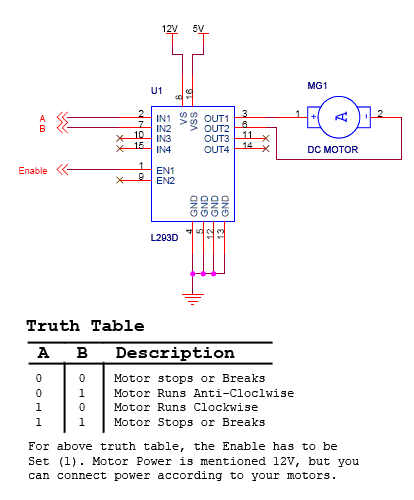
This circuit is designed to drive a motor, and it has been suggested that a decoupling capacitor should be included to mitigate voltage spikes. There are conflicting opinions on the placement of this capacitor; some advise positioning it close to...
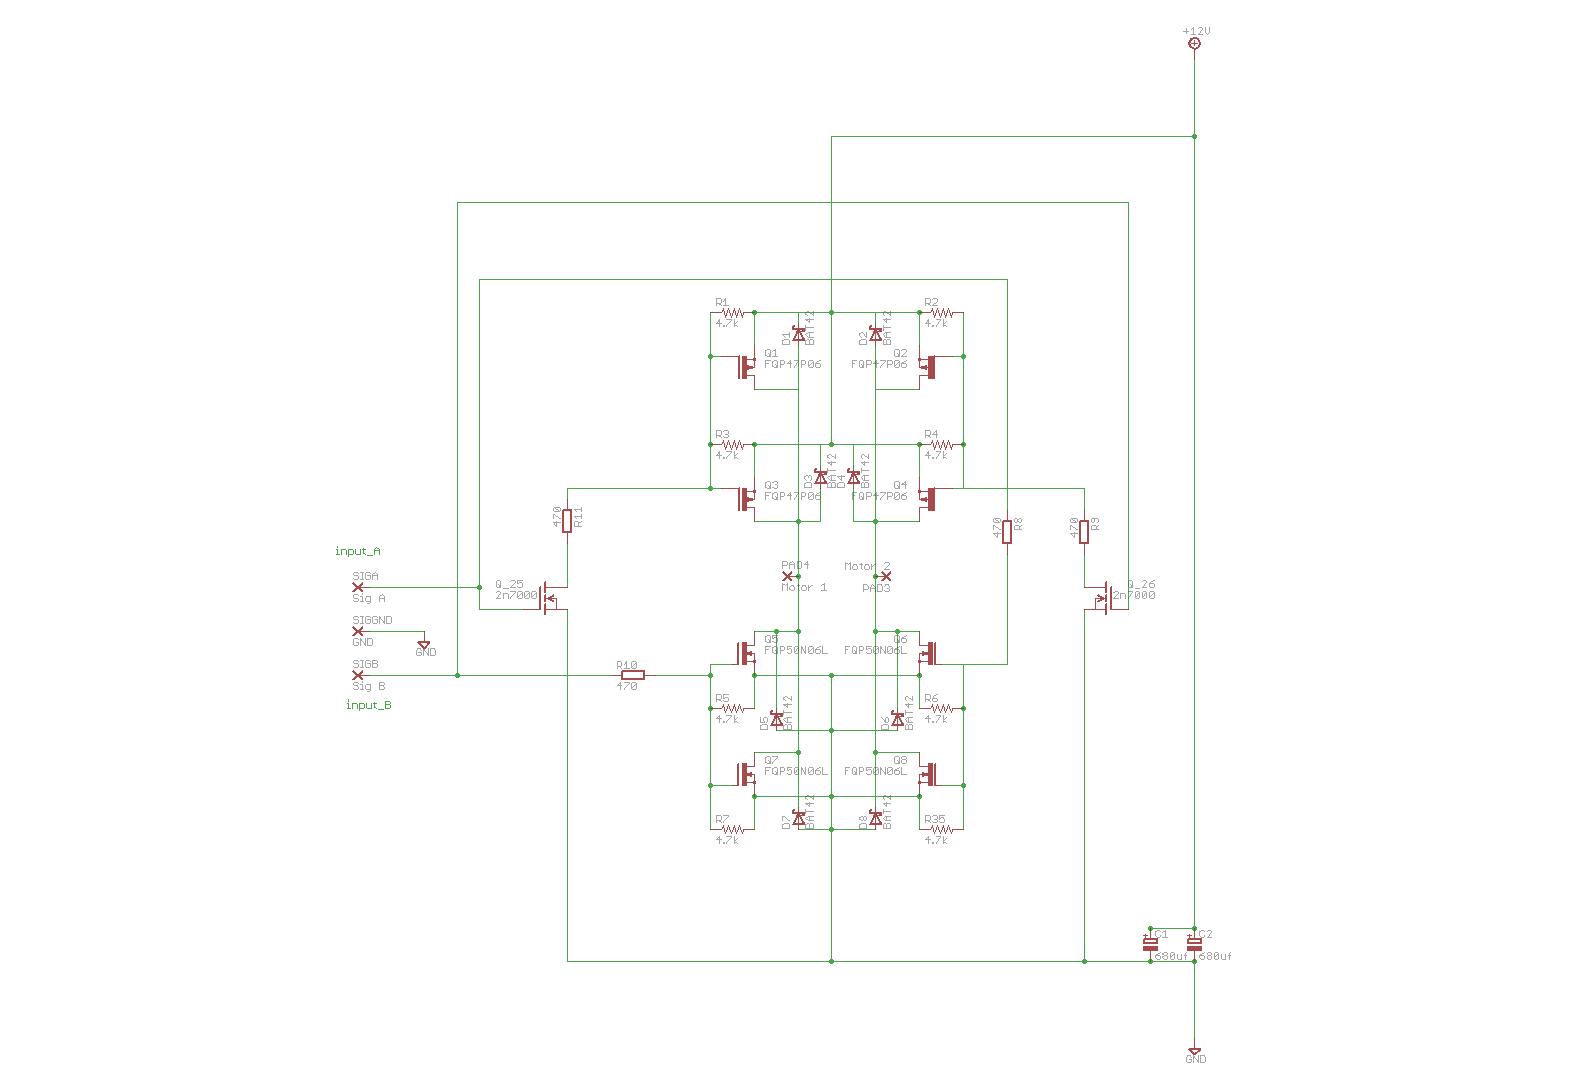
H-Bridge popping
A design for an H-Bridge has been created to control a 12VDC, 6 Amp motor. The circuit functioned effectively on a breadboard at 7.2 VDC while operating a small DC motor.
The H-Bridge circuit is a crucial component in motor control...
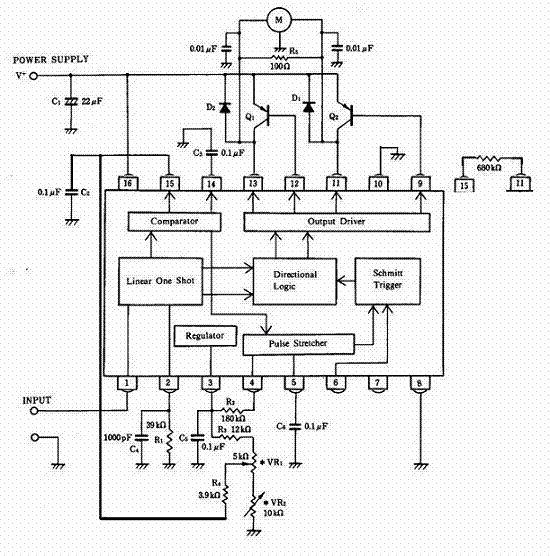
Dome Drive Schematic
A few modifications have been made to the dead band and pulse stretcher resistors, and the position feedback potentiometer has been altered to function as a "zero the speed" or "center your transmitter sticks." Additionally, a traditional PNP-NPN H-bridge has...
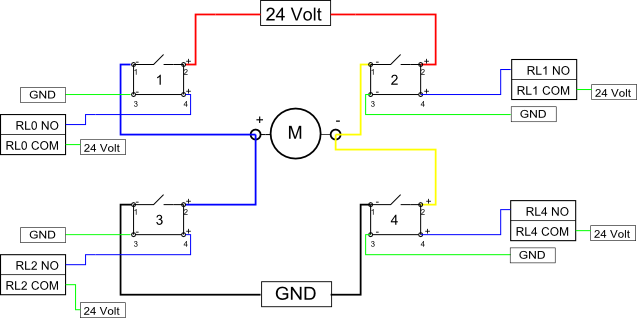
quick jobs h bridge circuit to drive
Eight solid-state relays (SSR) and an ADAM-4068 (Serial-I/O device) are utilized to wire a circuit for controlling a motor in a robotic application. The ADAM-6048 is a versatile device that facilitates control of digital inputs and outputs via RS-485 serial...
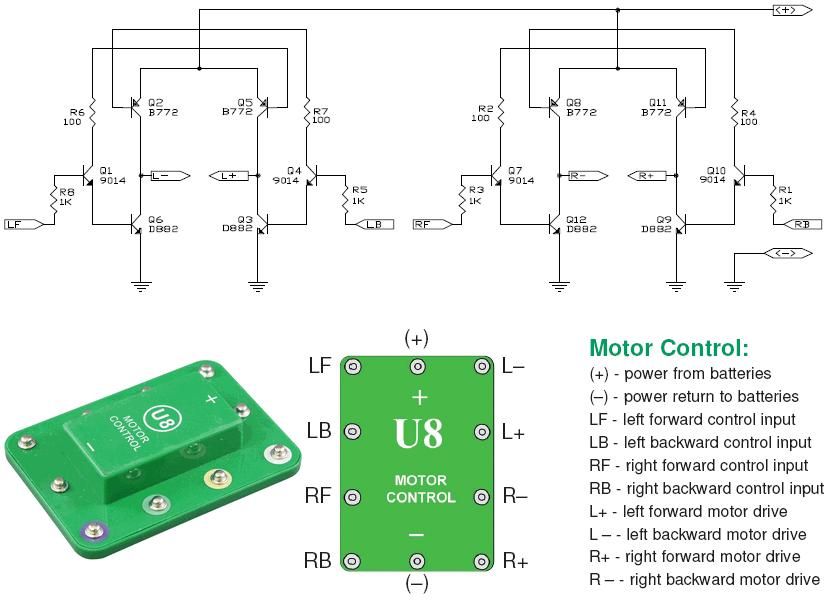
The H-Bridge
This is the Snap Circuits Motor Control IC, also known as an H-bridge. The electronic schematic of the Motor Control block is illustrated at the top of the figure.
The Snap Circuits Motor Control IC is designed to control the direction...
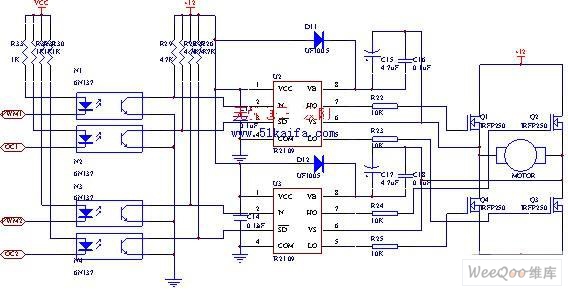
Using IRFP250 power tube H-bridge motor drive circuit
The drive circuit for the electromotor comprises a FET bridge circuit, a FET base drive circuit, a current sensor for the motor drive circuit, and a relay. The FET bridge circuit primarily consists of four high-power MOSFETs, which must possess...
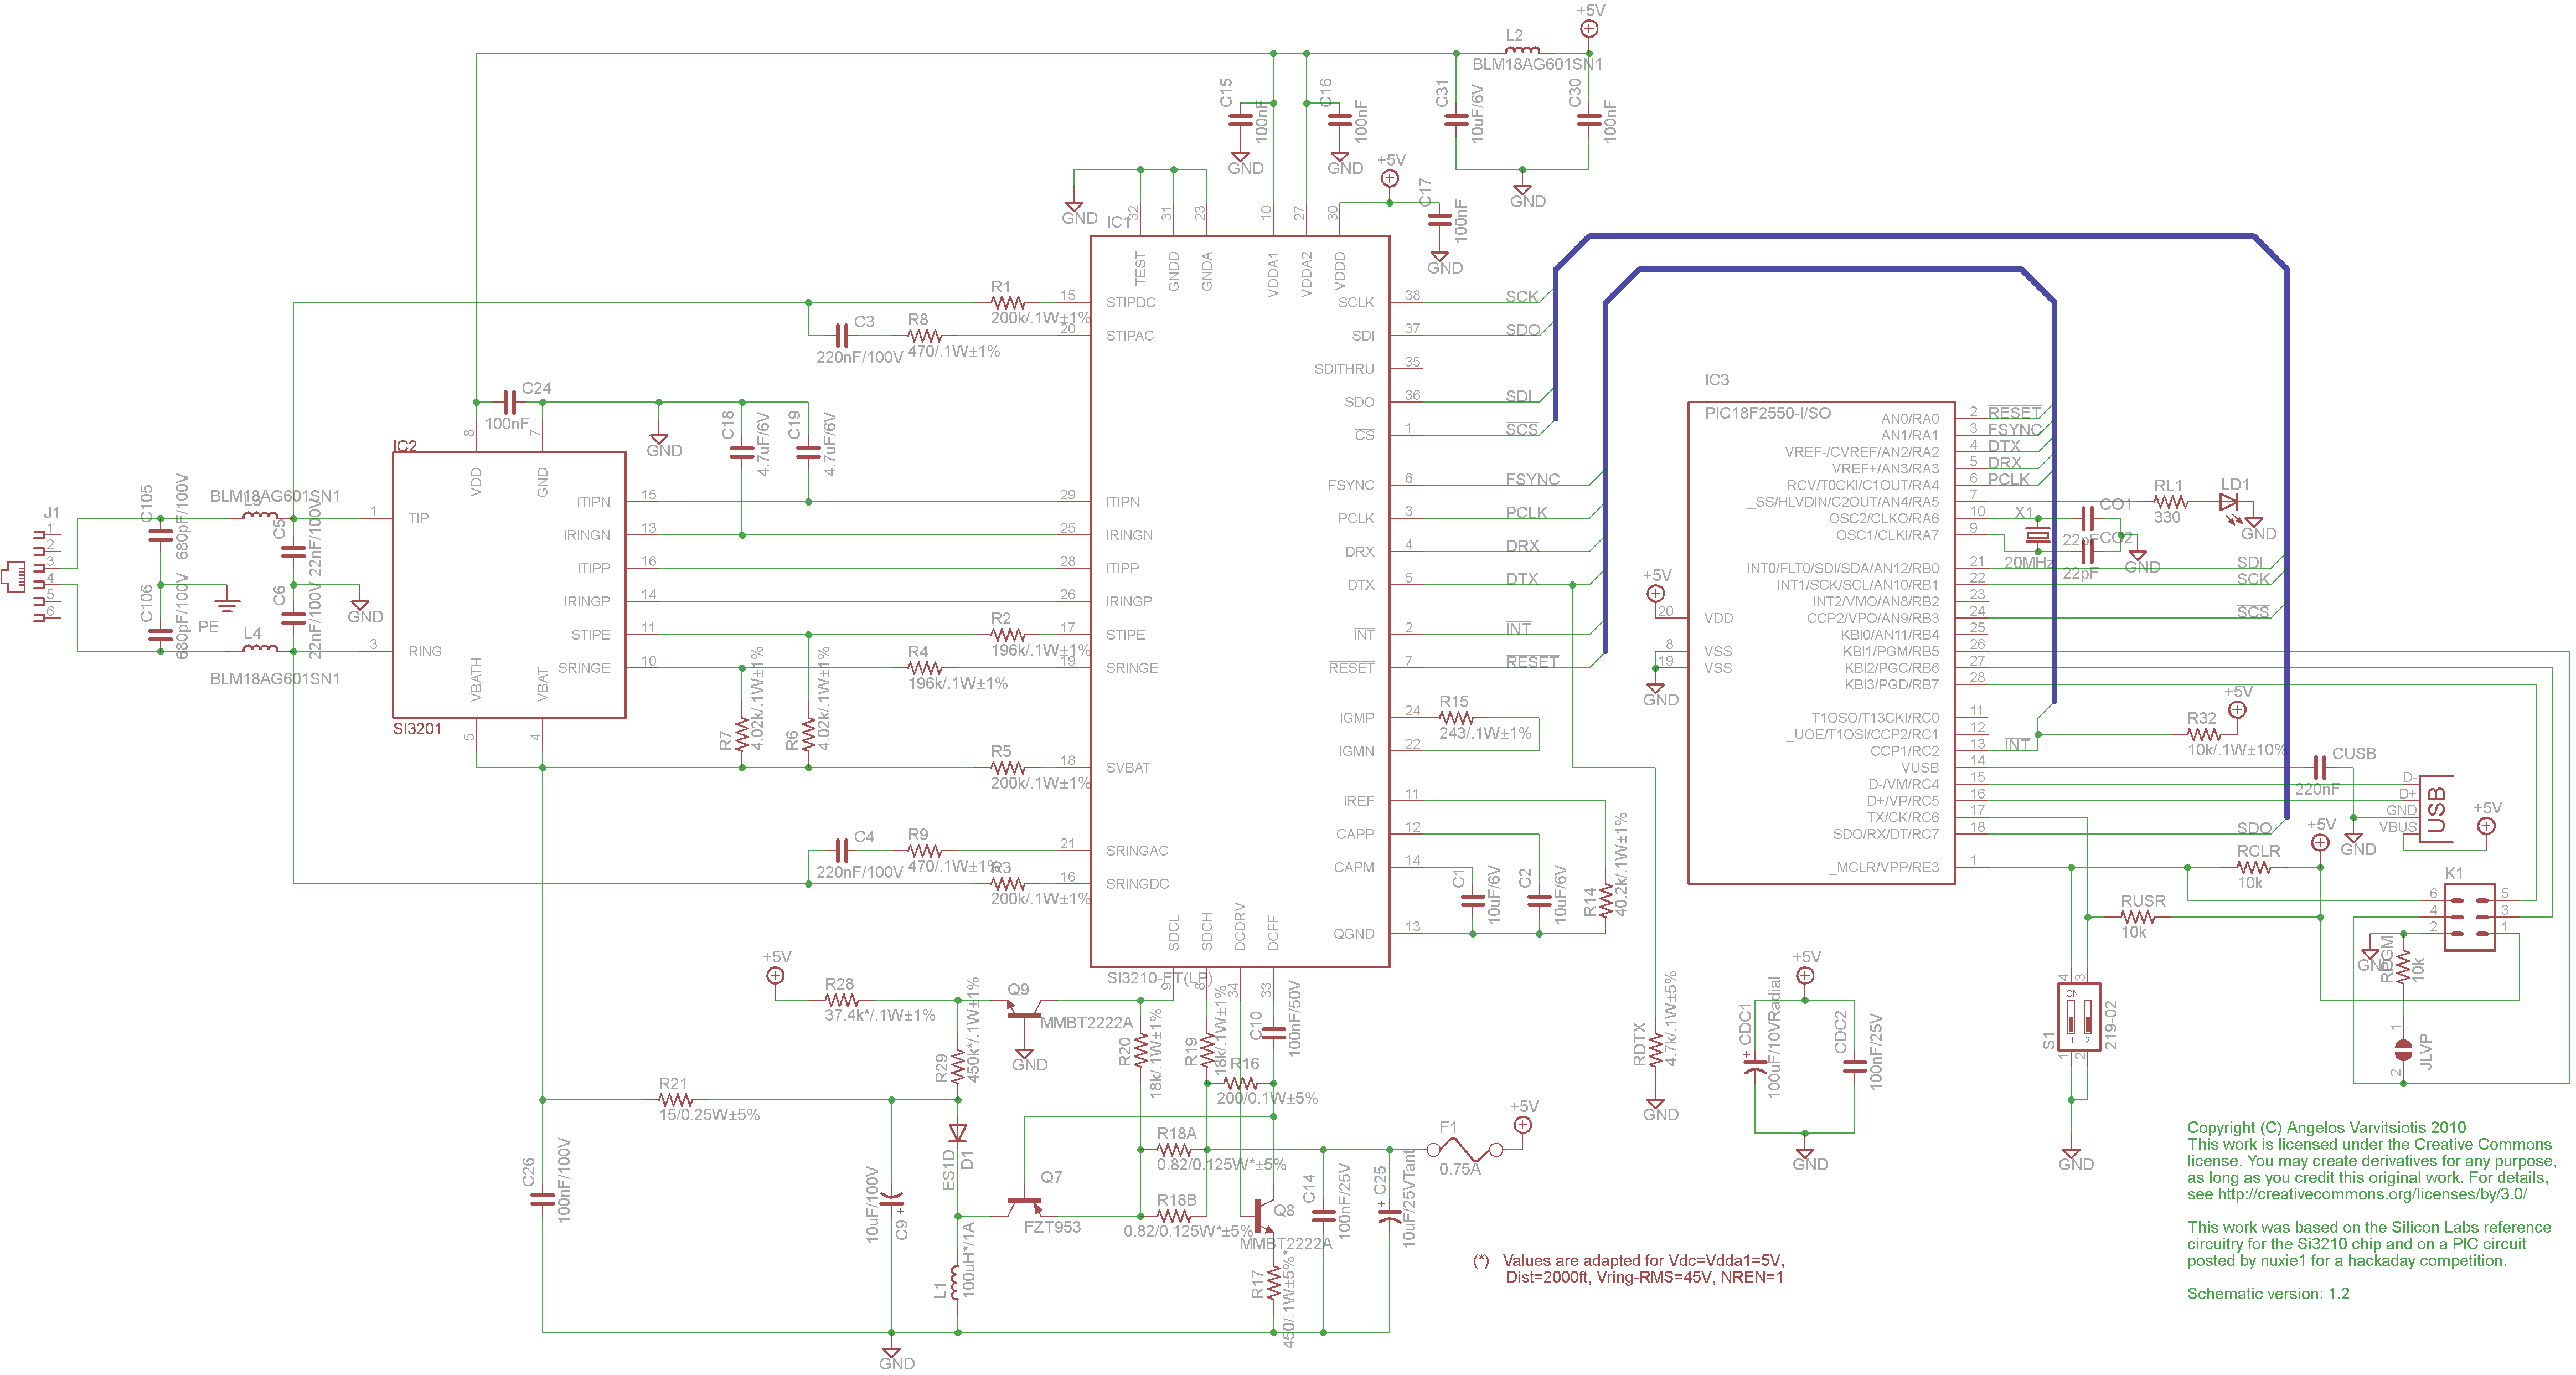
dyi setup and debugging guide
This page discusses the differences between assembled Open USB FXS dongle boards and DIY boards. While the assembled boards are fully tested and quality control approved, DIY boards may encounter various issues during assembly. Fortunately, most of these issues can...