


Simple stepper motor controller
#stepper motor
#unipolar
#controller
#transistor
#darlington pair
#SL100
#2N3055
#coils
#protection diodes
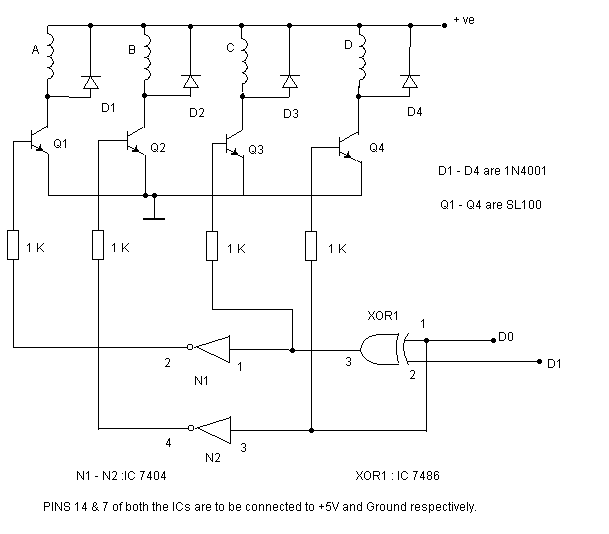
Description: The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils. The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100. For higher currents, power transistors like 2N3055 can be used as a Darlington pair along with SL100. The diodes are used to protect the transistor from transients. To reverse the motor just reverse the above sequence viz. 11,10,01,00.
Alternately, a 2-bit UP/DOWN counter can also be used to control the direction, and a 555 multivibrator can be used to control the speed.
The circuit described is designed to drive a unipolar stepper motor with four coils, commonly found in devices such as printers and scanners. The configuration allows for precise control of the motor's rotation by energizing the coils in a specific sequence. Each coil is activated in a binary sequence (11, 10, 01, 00), which translates to the motor's stepping motion.
The SL100 transistor acts as a switch to control the current flowing through each coil. It is important to use appropriate heat sinks to dissipate the heat generated during operation, especially when the motor is driven at higher currents. For applications requiring more current, the 2N3055 power transistor can be utilized in a Darlington configuration to increase the current gain, allowing for efficient control of higher power levels.
Diodes are strategically placed across the coils to protect the transistors from voltage spikes caused by the inductive loads when the coils are switched off. This protection is critical in preventing damage to the transistors and ensuring reliable operation of the circuit.
The direction of the motor can be easily reversed by altering the sequence in which the coils are energized. This can be achieved through a simple control mechanism, such as a 2-bit UP/DOWN counter, which provides a straightforward method for determining the sequence of activation. Additionally, a 555 timer configured as a multivibrator can be integrated into the circuit to regulate the speed of the motor by adjusting the timing of the coil activation sequence. This combination of components allows for versatile control of the stepper motor, making it suitable for various applications in robotics and automation. The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils (I've swiped it off an old fax machine). The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100.
For higher currents power transistors like 2N3055 can be used as darlington pair along with SL100. The diodes are used to protect the transistor from transients. To reverse the motor just reverse the above sequence viz. 11,10,01,00. Alternately a 2bit UP/DOWN counter can also be used to control the direction , and a 555 multi-vibrator can be used to control the speed.
Alternately, a 2-bit UP/DOWN counter can also be used to control the direction, and a 555 multivibrator can be used to control the speed.
The circuit described is designed to drive a unipolar stepper motor with four coils, commonly found in devices such as printers and scanners. The configuration allows for precise control of the motor's rotation by energizing the coils in a specific sequence. Each coil is activated in a binary sequence (11, 10, 01, 00), which translates to the motor's stepping motion.
The SL100 transistor acts as a switch to control the current flowing through each coil. It is important to use appropriate heat sinks to dissipate the heat generated during operation, especially when the motor is driven at higher currents. For applications requiring more current, the 2N3055 power transistor can be utilized in a Darlington configuration to increase the current gain, allowing for efficient control of higher power levels.
Diodes are strategically placed across the coils to protect the transistors from voltage spikes caused by the inductive loads when the coils are switched off. This protection is critical in preventing damage to the transistors and ensuring reliable operation of the circuit.
The direction of the motor can be easily reversed by altering the sequence in which the coils are energized. This can be achieved through a simple control mechanism, such as a 2-bit UP/DOWN counter, which provides a straightforward method for determining the sequence of activation. Additionally, a 555 timer configured as a multivibrator can be integrated into the circuit to regulate the speed of the motor by adjusting the timing of the coil activation sequence. This combination of components allows for versatile control of the stepper motor, making it suitable for various applications in robotics and automation. The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils (I've swiped it off an old fax machine). The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100.
For higher currents power transistors like 2N3055 can be used as darlington pair along with SL100. The diodes are used to protect the transistor from transients. To reverse the motor just reverse the above sequence viz. 11,10,01,00. Alternately a 2bit UP/DOWN counter can also be used to control the direction , and a 555 multi-vibrator can be used to control the speed.
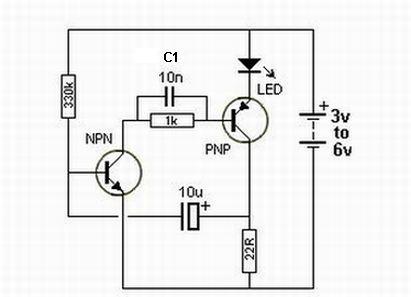
transistors Role of capacitor in this circuit
Oscillation is expected at the resonant frequency where the positive feedback is in phase with the input, specifically at 0 degrees. For oscillation to take place, the gain must be equal to or greater than 1 at that frequency. There...
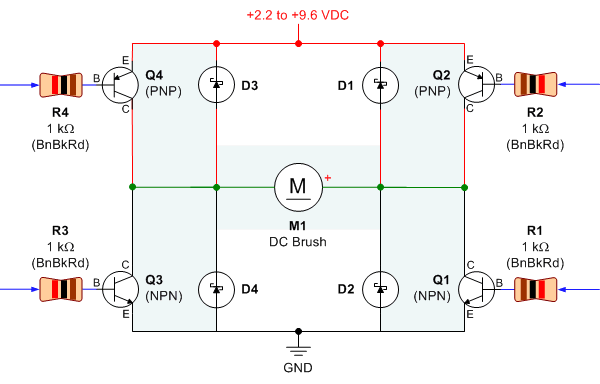
Bipolar Transistor HBridge Motor Driver
Schematic, breadboard photo, parts list, and results of several transistor variations on the classic bipolar H-bridge motor driver circuit.
The classic bipolar H-bridge motor driver circuit is a widely used configuration that allows for the control of DC motors in both...
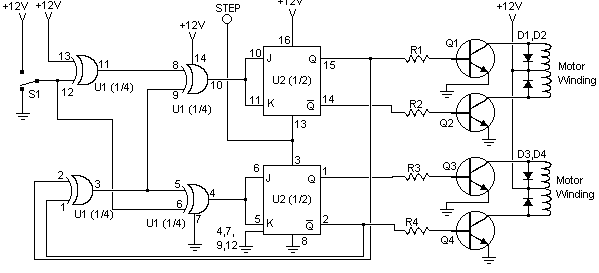
Stepper Motor Controllers
The circuit is straightforward and cost-effective. This is advantageous since most commercially available stepper motor controller ICs tend to be quite pricey. It is constructed using standard components and can be easily modified for computer control. By utilizing inexpensive surplus...
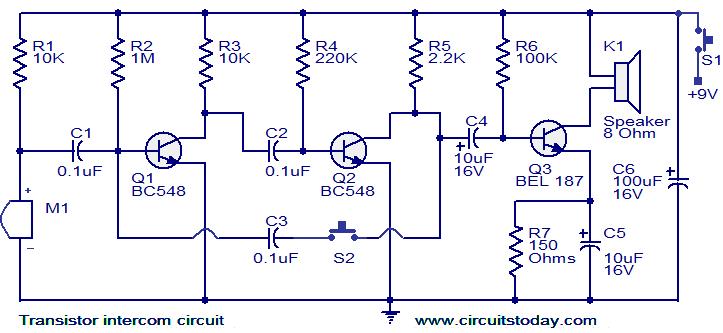
Transistor intercom circuit
This document describes a simple yet effective intercom circuit that is entirely based on transistors. The design features a three-stage RC coupled amplifier. When the pushbutton S2 is activated, the amplifier circuit, which includes transistors T1 and T2, functions as...
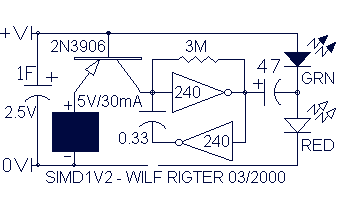
Wilf Rigter`s SIMD1 V2
In the never-ending quest for simplicity, even one extra diode is a price I loathe to pay. To avoid using extra components, it struck me that the two diodes in SIMD1 V1 were connected like the two junctions in one...
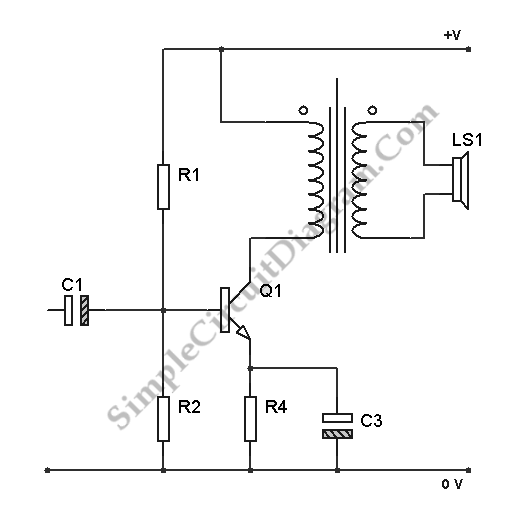
Transistor Class A Power Amplifier
The transistor is biased in Class A, meaning that the collector current flows continuously. This current can vary, increasing or decreasing in response to the input signal.
In a Class A biasing configuration, the transistor operates in the active region for...
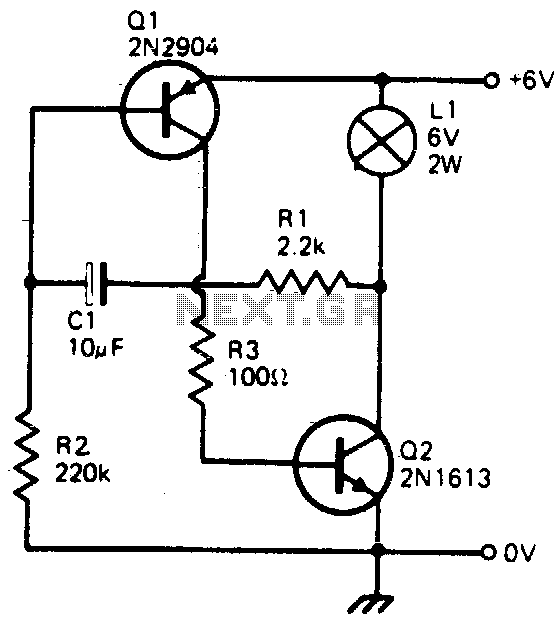
Transistorized flasher
This simple circuit will flash a 6-volt lamp at a rate determined by the size of capacitor C1. It is most economical on power as it only draws current when the lamp is on. When the lamp is off, both...
Darlington amplifier
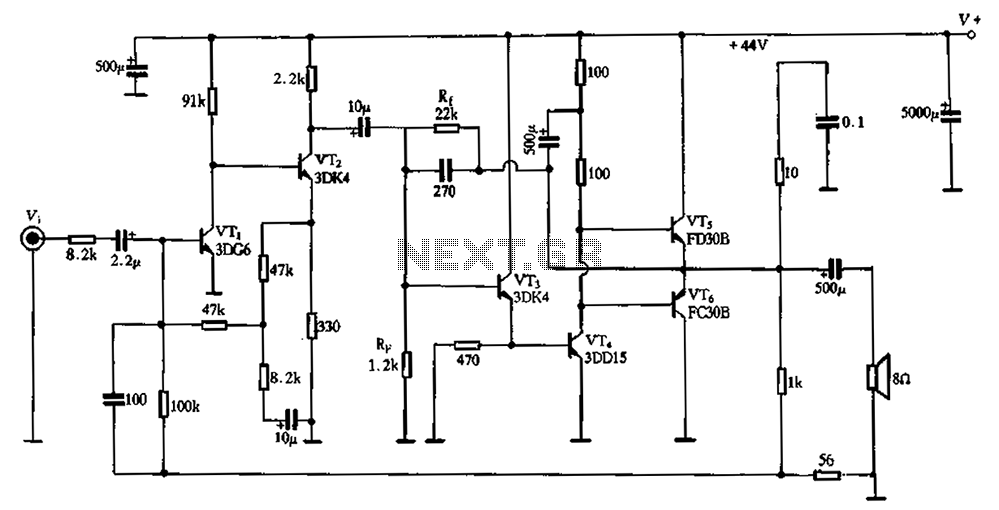
The circuit schematic depicted in Figure 2-3 illustrates a twin direct-coupled input amplifier stage composed of components OV, RLR, and VT2. The emitter of VT2 is connected to the base of VT3, utilizing local feedback to stabilize its DC operating...
Motor Generator Stepper
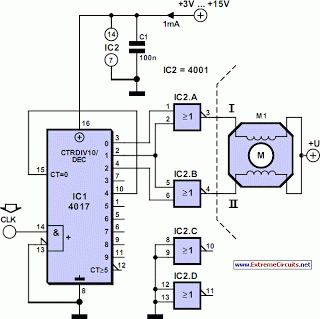
Stepper motors are a frequently discussed topic. This circuit converts a clock signal from a square wave generator into signals that have a 90-degree phase difference, which are necessary for driving the stepper motor windings. The trade-off for this simplicity...