


Servo4 Module
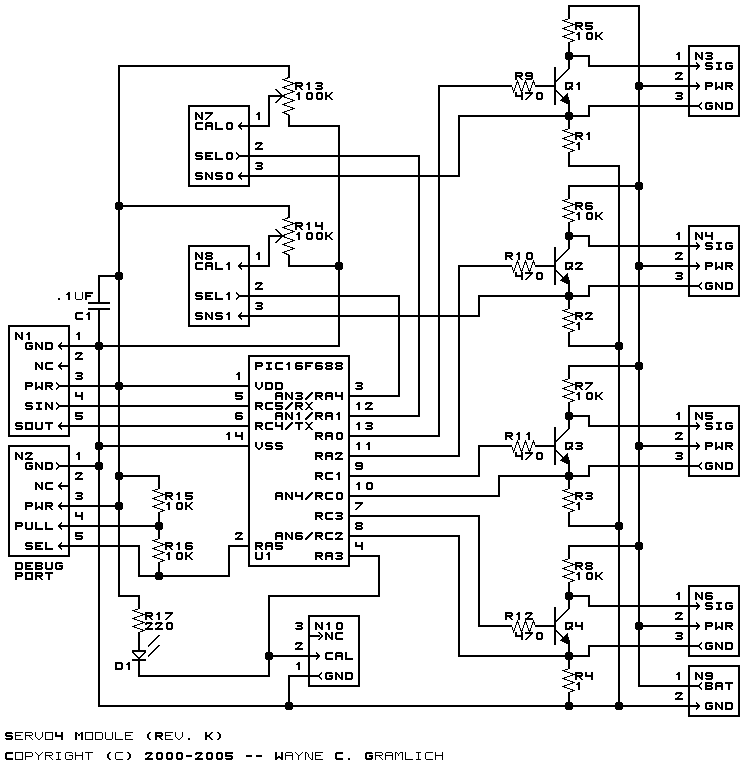
Description: In pure servo mode, it is anticipated that up to four unmodified servos are connected to the board, allowing for independent control of each. Current feedback is provided for all four servos. In differential steering mode, the module can also manage up to four servos, where the first two are expected to be modified for continuous rotation, while the latter two are standard unmodified servos. The first two servos feature current feedback, whereas the second two do not. Two trim potentiometers are utilized to establish the no rotation condition for the first two servos. During differential steering calibration mode, jumper N10 is moved upward, which activates yellow LED D1 and enables servos 0 and 1. The trim pot R5 is assigned to servo 0, while R6 is designated for servo 1. The calibration mode's objective is to facilitate adjustments to the two modified servos connected to servo 0 and servo 1 until they cease rotation. This process eliminates the need for the programmer to experiment in determining the position number for each servo that results in a stationary state. The stop value readings are obtained using the Read Current Draw command for servos 2 and 3.
The circuit design described facilitates the operation of servos in both pure and differential steering modes. In pure servo mode, the board is capable of controlling four independent unmodified servos, each equipped with current feedback to monitor performance and ensure accurate operation. This feedback is crucial for applications requiring precise positioning and responsiveness.
In differential steering mode, the configuration changes to accommodate two modified continuous rotation servos alongside two standard servos. This setup is particularly useful in robotic applications where maneuverability is essential. The inclusion of current feedback for the modified servos enables real-time adjustments, enhancing control over the movement dynamics.
The use of trim potentiometers R5 and R6 is an important feature that allows for fine-tuning of the modified servos. By establishing a no rotation condition, users can ensure that the servos operate effectively without unwanted motion. This calibration process is critical for achieving optimal performance, especially in scenarios where precise positioning is required.
The activation of jumper N10 to initiate calibration mode, indicated by the illumination of LED D1, represents a straightforward method for enabling servos 0 and 1. This visual feedback aids in the setup process, making it easier for users to confirm that the system is in the correct operational state.
The Read Current Draw command for servos 2 and 3 provides valuable data on the current consumption, which can be utilized to determine the stop values for the modified servos. This feature not only simplifies the calibration process but also enhances the overall efficiency of the system by allowing for adjustments based on real-time feedback.
In summary, this circuit design effectively supports the operation of multiple servos in various modes, with features that facilitate calibration and feedback, ensuring precise control and adaptability for a range of applications.In pure servo mode, it is expected that up to 4 unmodified servos are attached to the board. The four servos can be independently controlled. There is current feedback on all four servos. In differential steering mode, the module can control up to 4 servos. The first two servos are expected to be servos that have modified been for continuous rotat ion. The second two servos are regular unmodified servos. The first two servos have current feedback and the second two servos do not. There are two trim pots that are used to set the no rotation condition for the first two servos. In differential steering calibration mode, N10 is jumpered upward and it causes yellow LED D1 to light. It causes both servos 0 and 1 to be enabled. The value of trim pot R5 to be sent to servo 0 and trim pot R6 to be sent to servo 1. The purpose of calibration mode is to allow you to adjust the two modified servos that are connected to servo 0 and servo 1 and adjust them until they stop rotating.
This frees the programmer from having to experiment to find the `position` number for each servo that corresponds to each servo being motionless. The values of the stop value are read out using the Read Current Draw command for servo 2 and 3.
The circuit design described facilitates the operation of servos in both pure and differential steering modes. In pure servo mode, the board is capable of controlling four independent unmodified servos, each equipped with current feedback to monitor performance and ensure accurate operation. This feedback is crucial for applications requiring precise positioning and responsiveness.
In differential steering mode, the configuration changes to accommodate two modified continuous rotation servos alongside two standard servos. This setup is particularly useful in robotic applications where maneuverability is essential. The inclusion of current feedback for the modified servos enables real-time adjustments, enhancing control over the movement dynamics.
The use of trim potentiometers R5 and R6 is an important feature that allows for fine-tuning of the modified servos. By establishing a no rotation condition, users can ensure that the servos operate effectively without unwanted motion. This calibration process is critical for achieving optimal performance, especially in scenarios where precise positioning is required.
The activation of jumper N10 to initiate calibration mode, indicated by the illumination of LED D1, represents a straightforward method for enabling servos 0 and 1. This visual feedback aids in the setup process, making it easier for users to confirm that the system is in the correct operational state.
The Read Current Draw command for servos 2 and 3 provides valuable data on the current consumption, which can be utilized to determine the stop values for the modified servos. This feature not only simplifies the calibration process but also enhances the overall efficiency of the system by allowing for adjustments based on real-time feedback.
In summary, this circuit design effectively supports the operation of multiple servos in various modes, with features that facilitate calibration and feedback, ensuring precise control and adaptability for a range of applications.In pure servo mode, it is expected that up to 4 unmodified servos are attached to the board. The four servos can be independently controlled. There is current feedback on all four servos. In differential steering mode, the module can control up to 4 servos. The first two servos are expected to be servos that have modified been for continuous rotat ion. The second two servos are regular unmodified servos. The first two servos have current feedback and the second two servos do not. There are two trim pots that are used to set the no rotation condition for the first two servos. In differential steering calibration mode, N10 is jumpered upward and it causes yellow LED D1 to light. It causes both servos 0 and 1 to be enabled. The value of trim pot R5 to be sent to servo 0 and trim pot R6 to be sent to servo 1. The purpose of calibration mode is to allow you to adjust the two modified servos that are connected to servo 0 and servo 1 and adjust them until they stop rotating.
This frees the programmer from having to experiment to find the `position` number for each servo that corresponds to each servo being motionless. The values of the stop value are read out using the Read Current Draw command for servo 2 and 3.
Hobby-Servo Encoder Retrofit
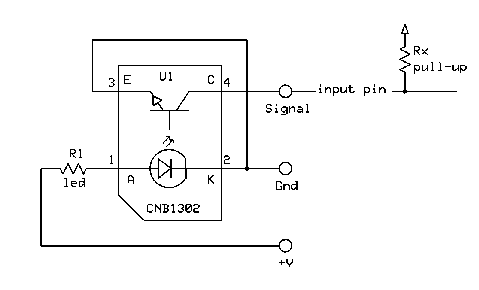
The encoder strip should be laser-printed on sticky label material. It is then cut out and wrapped around the barrel of the second drive gear. Bright white sticky address labels, such as Avery "WeatherProof White Labels" #15510, are recommended. The...
Servo Reversers
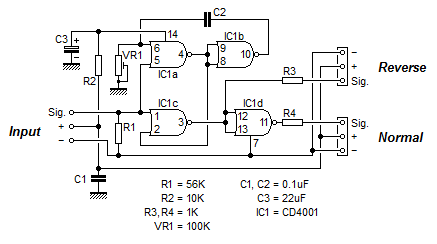
This project describes a simple servo reverser that can be inexpensively constructed using a CD4001 NOR gate, four resistors, three capacitors, and one variable potentiometer (see schematic below).
The proposed circuit utilizes the CD4001 NOR gate as the primary component for...
Having a current negative feedback speed control system
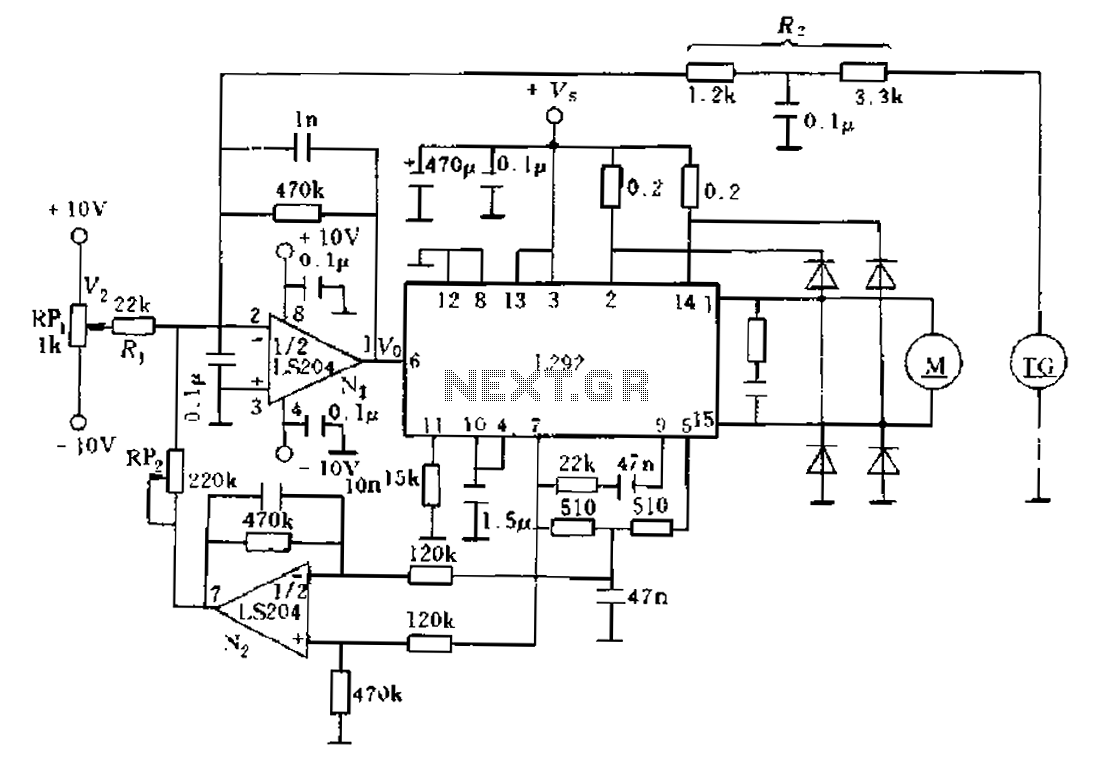
An alternative solution involves enhancing the existing feedback signal directed to an error amplifier summing junction, which is integrated into a current feedback loop for improvement. The L292 circuit demonstrates that the electrical current is proportional to the average current...
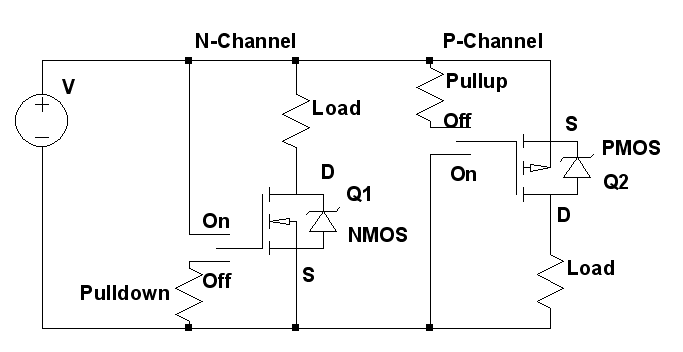
Driving a servo with MOSFET
Construct a compact battery-powered device that incorporates a servo motor. The design should include a mechanism to turn off the servo to conserve battery life. It has been noted that MOSFETs can be utilized for this purpose; however, there is...
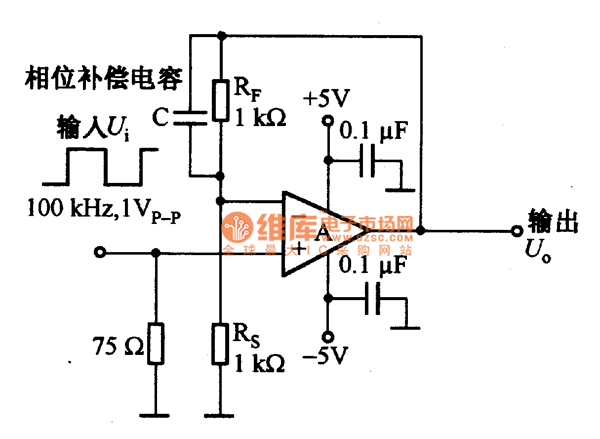
Feedback resistance circuit diagram of current feedback operational amplifier
The current feedback operational amplifier maintains a consistent bandwidth even when the open-loop gain is altered. This characteristic makes it particularly suitable for applications in video signal amplification and the driving circuits of video cables. The accompanying diagram illustrates a...
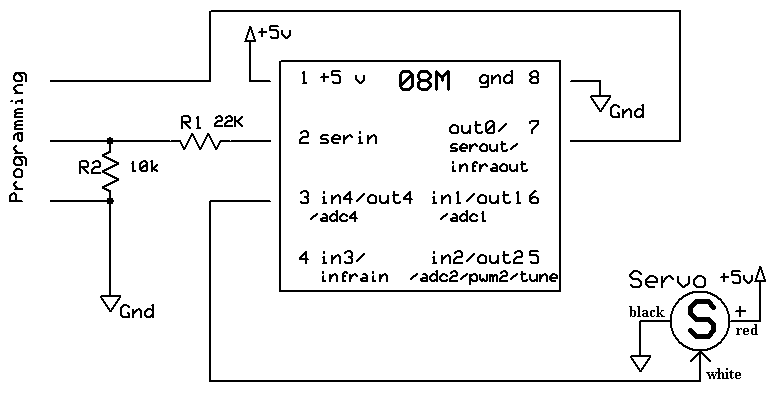
Animation with Servos
A servo consists of a small motor and gear mechanism that rotates a shaft to a precise location and maintains that position. The image displays a typical servo with its cover removed. The shaft's position is controlled by a digital...
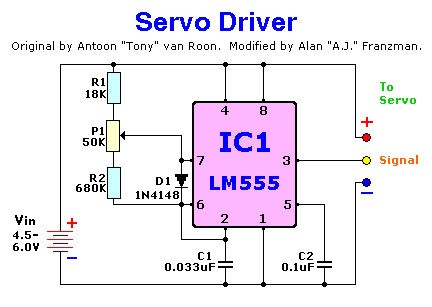
Servo Driver
This circuit can be utilized to verify the functionality of servos, assess full travel, detect binding, and identify any drag or rubbing when the servos are integrated into a model. It may also serve as a control circuit in robotics...
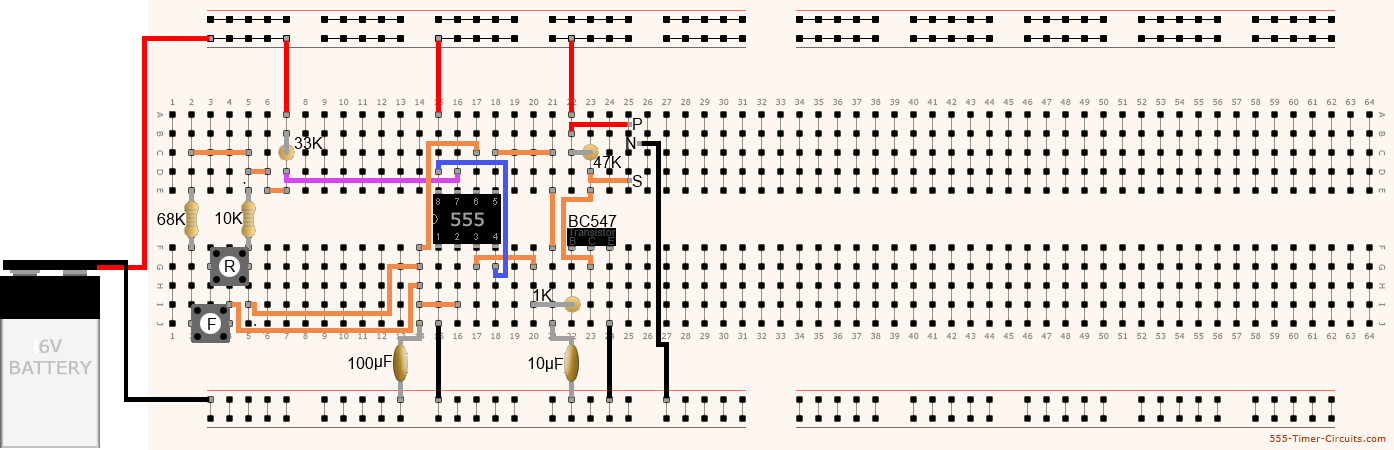
servo tester
A servo tester circuit has been built as shown. The only observable action is for the servo to twitch when the power is switched on. There is no clear reason for its failure to operate correctly. Suggestions for troubleshooting are...
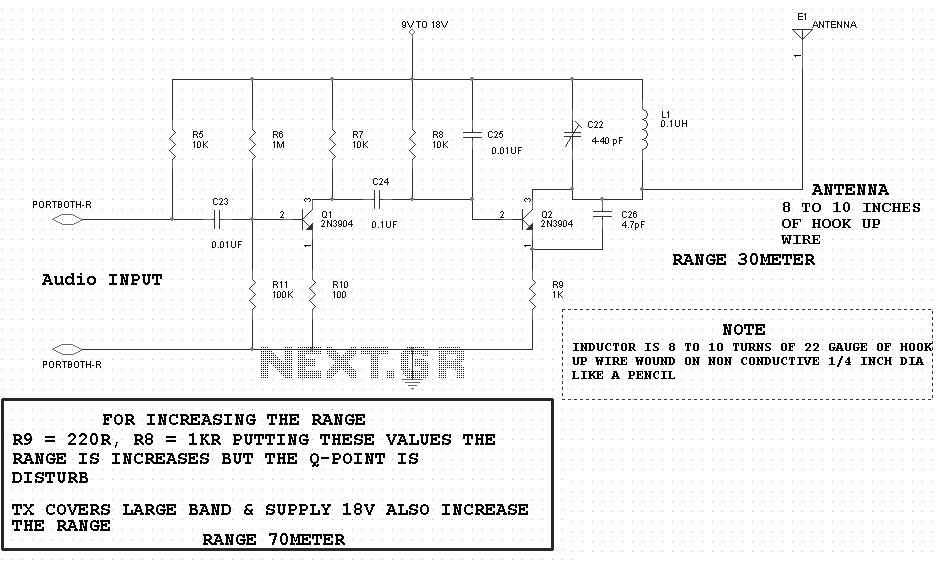
Simple Servo Testers
This is a simple servo tester designed to thoroughly evaluate the capabilities of nearly any modern servo. It features two pushbuttons, labeled CENTRE and SWEEP, along with a potentiometer that functions in the following manner:
The servo tester circuit is primarily...